Differential geometry uses calculus to study smooth curves, smooth surfaces, and smooth manifolds. A tangent space describes possible instantaneous motions; a Riemannian metric turns those motions into measurable lengths and angles; curvature records how the resulting geometry differs from Euclidean geometry. Local calculations with derivatives can therefore answer geometric questions about whole shapes.
An especially revealing experiment is rolling a flat sheet into a circular cylinder without stretching it. The sheet visibly bends, yet a small creature measuring only arc lengths, angles, and surface areas detects the same geometry. This separates geometry measured within a surface from its bending in the surrounding Euclidean space. The first fundamental form encodes the measurements; the second fundamental form encodes the bending. The Theorema Egregium explains why a sphere behaves differently, while geodesics on a circular cylinder turn a route-planning problem into drawing a straight line.
Analytic torsion is a spectral invariant constructed from regularized determinants of the Laplacians on differential forms with suitable flat coefficients. It is the analytic counterpart of combinatorial Reidemeister torsion, whose refinements include Turaev torsion; equality theorems relate the spectral and combinatorial invariants under appropriate hypotheses on the manifold and coefficients.
The differential geometry of smooth surfaces studies their induced Riemannian metrics and intrinsic or extrinsic curvature. The first fundamental form measures lengths, while the second fundamental form and shape operator describe bending in an ambient Euclidean space. A regular parametric surface must have linearly independent tangent vectors : otherwise its parameters cannot provide a manifold chart with two independent directions.
For a sphere of radius , use colatitude and longitude :Thus a change has arc length : equally spaced longitudes draw closer together toward a pole. The coordinate degeneracy at the poles belongs to this parametrization, not to the smooth surface.
Both principal curvatures of the sphere have magnitude and the same sign, giving Gaussian curvature . A plane has , and a circular cylinder also has because one principal curvature vanishes. These three familiar shapes show why visible bending alone cannot measure intrinsic Gaussian curvature.
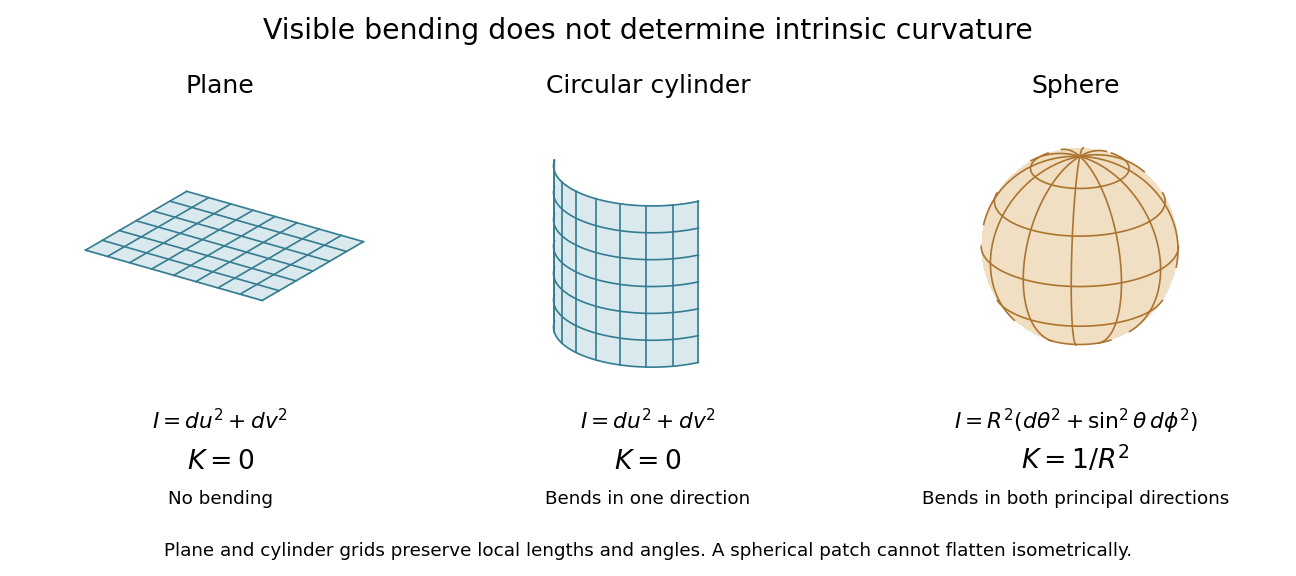
Visible bending and Gaussian curvature are different measurements
. Details. A smooth map between manifolds pulls a function back by composition and pulls a covariant tensor back by applying its differential to each vector argument. The pullback of a differential form is the alternating-tensor case and commutes with the exterior derivative.
This family includes the Laplace-Beltrami operator on functions, the Hodge Laplacian on differential forms, and the rough Laplacian associated with a connection on a vector bundle. Their domains and sign conventions must be specified when comparing them.
Imagine folding a sheet along its horizontal axis by the smooth map , . The inputs and have the same output. Along , horizontal motion still changes the output, but vertical motion produces no first-order change: . These inputs are critical points of a smooth map even though their differential is not the zero linear map. The missing direction in the target tangent space is what matters.
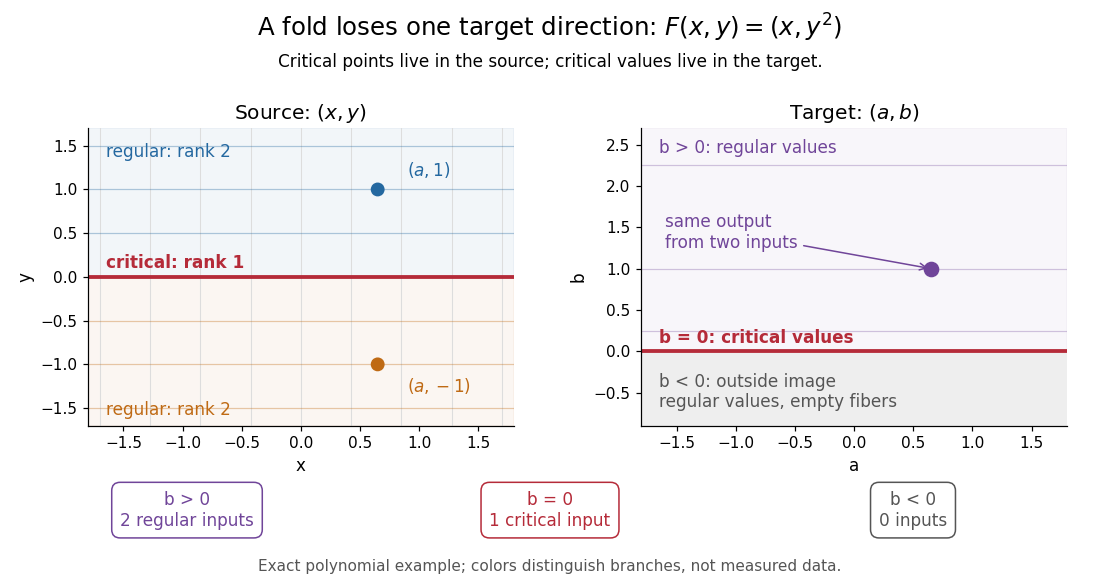
Precisely, let be a smooth map between smooth manifolds without boundary. An input is a critical point of a smooth map when its differentialis not surjective, equivalently when its rank of a linear map is less than . An input where it is surjective is a regular point; a map with no critical points of a smooth map is a submersion. The threshold is the target dimension, not . In manifold charts, compute the matrix rank of the Jacobian matrix; changes of charts preserve that matrix rank. [ref]
For the fold,Thus its set of critical points of a smooth map is the entire horizontal axis. Away from that axis, its differential can produce every infinitesimal target displacement. At the axis, it can produce only horizontal ones. This diagnoses where the two inverse branches in the picture merge.
For a scalar smooth function , the target dimension is one. A linear map to fails to be surjective exactly when it is zero, so here a critical point of a smooth map means . In Euclidean space this is precisely the familiar critical point condition : every first partial derivative vanishes. On a Riemannian manifold, it is equivalently for the chosen Riemannian metric; the Riemannian gradient depends on that metric, but whether it vanishes does not. See Loring W. Tu, An Introduction to Manifolds, Proposition 8.23 for the scalar coordinate criterion. The scalar smooth function has a critical point at zero without a local maximum or local minimum.
A source of lower dimension gives a different warning. For the smooth map , , the Jacobian matrix is the column , of matrix rank one at every input. Every input is a critical point of a smooth map, since the target dimension is two, even though this parametric curve has nonzero velocity everywhere and is an immersion. More generally, if , no differential can be surjective, so every input is critical. The terminology measures the ability to fill target directions, rather than whether the parametrized curve looks smooth.
A critical point of a smooth map is an input; a critical value is an output reached from at least one such input. For the fold , all inputs are critical points of a smooth map, and all outputs are critical values. The identical coordinate pairs live in different copies of . To classify an output , inspect its entire fiber of a function:For both inputs have matrix rank two, so the output is a regular value. For its input has matrix rank one, so the output is a critical value. For the fiber of a function is the empty set, and the output is a regular value despite being outside the image of a function.
In general, for a smooth map , write for its set of critical points of a smooth map. Its set of critical values is . Equivalently, is a critical value if some has a differential that is not surjective. A regular value requires a surjective differential at every input in that fiber of a function. The universal condition holds vacuously for an empty fiber of a function: every output outside is a regular value. These quantifiers are explicit in Loring W. Tu, An Introduction to Manifolds, Definition 8.22 and its two following remarks.
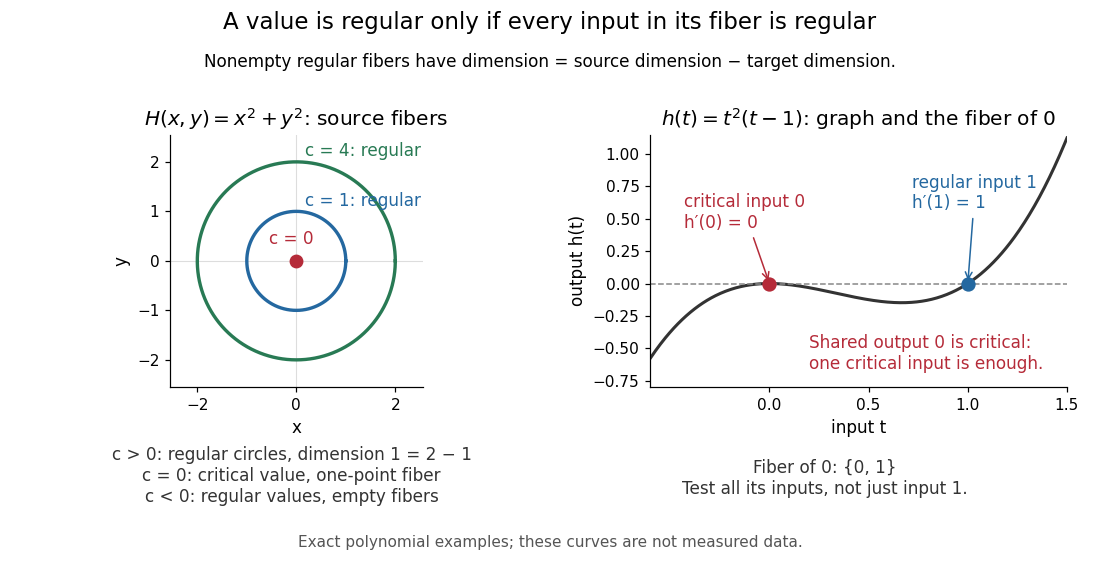
Regular circular fibers and a critical value reached from both critical and regular inputs
. Details. The distinction is useful when solving equations. For a smooth map between smooth manifolds without boundary and a regular value with nonempty fiber of a function, the regular level set theorem makes an embedded submanifold of dimension , with tangent spaceThe implicit function theorem explains the freedom count: locally, independent equations fix coordinates and leave free. The rank-nullity theorem gives the same count for the displayed kernel of a linear map. See Eckhard Meinrenken, Differentiable Manifolds, Theorems 1.11 and 1.15 for the local projection description and its consequence for level sets.
For example, , , has gradient and just one critical point, the origin, with critical value zero. For , its fiber of a function is the circle of radius , a one-dimensional embedded submanifold; negative are regular values with empty fibers. At , the fiber of a function is a single point instead of a circle. A critical value does not force its fiber of a function to be nonsmooth: that singleton is itself a zero-dimensional embedded submanifold, but the regular dimension conclusion does not apply.
Nor does a single regular input certify a regular value. The scalar smooth function has and derivative . The input zero is a critical point, while the input one is regular because . Their shared output zero is nevertheless a critical value. Conversely, different critical points of a smooth map can share one critical value: sends both critical inputs and to zero. Counting inputs and counting critical outputs are different tasks.
Finally, for , every output on the parabola is a critical value, and every output off it is a regular value with empty fiber of a function. There is no nonempty regular fiber of a function here, so the negative expression never becomes a claimed manifold dimension. Both diagrams show exact mathematical examples, not measured data.
Calibrated geometry constructs volume-minimizing submanifolds through closed differential forms with a tangent-plane bound. It gives an algebraic sufficient condition for solving the nonlinear minimal surface problem.
A generalized calibration bounds the full energy of a supersymmetric brane, including its potential or gauge couplings. For a membrane, compatible spinor bilinears obey . In a stationary gauge , Cartan's magic formula proves . The closed charge form then supplies the energy bound. This extends ordinary calibration from volume alone to charged branes, as developed in Topological charges for branes in M-theory.
An oriented submanifold is calibrated by a calibration when its tangent planes attain the comass bound at every point. Closedness then compares its volume with homologous competitors by Stokes theorem.
If is calibrated by and is homologous with the same boundary, Stokes theorem gives . The tangent-plane bound gives , while calibration gives . Thus minimizes volume in its relative homology class and is a minimal submanifold wherever smooth.
A calibration is a closed real differential form whose comass is at most one. Restricting it to any oriented unit tangent plane therefore gives at most that plane's volume. A calibrated submanifold attains equality everywhere, and calibration implies volume minimization among homologous competitors.
In a flux-free static supergravity background with a parallel unit Killing spinor, this two-form satisfies the membrane tangent-plane bound because is a Hermitian involution. Its eigenvalues are , so , with equality precisely at the kappa symmetry projector condition. Parallel transport gives and hence . This constructs an ordinary calibration; flux backgrounds instead call for a generalized calibration.
On a graded nilpotent Lie group whose first layer generates its Lie algebra, a horizontal curve obeys for a control in the first layer. The displayed infimum is over horizontal curves with prescribed endpoints. The distance is left invariant and homogeneous under the graded dilations. On a free nilpotent Lie group it measures the least Euclidean length of a path realizing a prescribed truncated path signature.
On a connected manifold, a smooth bracket-generating family of vector fields connects every pair of points by a piecewise smooth horizontal curve. For a free step-N nilpotent Lie group, this says that every group element is the path signature of a sufficiently regular path. In the planar step-two case, a closed rectangle prescribes the signed area and a following straight segment prescribes the displacement.
Hodge theory connects de Rham cohomology with harmonic differential forms through the Hodge Laplacian on a compact Riemannian manifold. The Hodge decomposition theorem supplies a unique harmonic representative of each cohomology class. On a compact Kähler manifold, the decomposition additionally respects the complex bidegrees of differential forms.
A pure integral Hodge structure is a finite-rank free abelian group with a complex decomposition satisfying and . The integer is its weight. Its equivalent Hodge filtration is .
A pure integral variation consists of a local system of free abelian groups, holomorphic filtration subbundles of its associated flat bundle, and fibrewise Hodge structures of fixed weight and Hodge numbers. Its flat connection satisfies Griffiths transversality. A polarized variation additionally has a flat integral bilinear form polarizing every fibre.
In a variation of Hodge structure, differentiation lowers the filtration index by at most one. In the relative de Rham construction, an absolute form of degree at least contributes, after extracting one base differential, a relative form of degree at least . This filtration shift proves the condition for geometric variations.
The flat connection on the complexified fibre-cohomology local system differentiates cohomology classes using topological parallel transport. For a smooth proper holomorphic family, relative de Rham cohomology identifies it with the connecting morphism obtained by retaining one base differential in the absolute de Rham complex.
A polarization is a nondegenerate integral bilinear form of symmetry , orthogonal on Hodge summands except complementary bidegrees, satisfying the displayed positivity for every nonzero . This convention takes the cup-product pairing as the primitive geometric polarization. Omitting the constant sign factor and rescaling is an equivalent convention. The full intersection pairing of a K3 surface is not itself a polarization: its real space has one positive direction as well as nineteen negative directions.
Fix a lattice, a bilinear polarization and Hodge numbers. The period domain consists of the Hodge filtrations with these dimensions satisfying orthogonality, opposition and positivity. It is an open subset of its compact dual of a period domain, described algebraically by the dimensions and orthogonality conditions alone.
On the K3 intersection lattice, this open quadric has complex dimension twenty and records the period line . Fixing a positive class of type adds and yields a nineteen-dimensional domain for primitive polarized cohomology of signature . The distinction is necessary: the unrestricted full lattice has signature and does not satisfy polarization positivity on all of .
Positive complex Lagrangian subspaces for the integral symplectic form are graphs . Isotropy is the symmetry of , and gives positivity. For in the symplectic group, the action is .
The compact dual is the complex projective flag variety imposing prescribed filtration dimensions and , but neither real opposition nor positivity. In weight one it is the complex Lagrangian Grassmannian. In polarized K3 weight two it is an isotropic-line quadric.
A decreasing filtration defines a Hodge structure when for every . The decomposition is recovered as . This filtration is the holomorphic datum that varies in a variation of Hodge structure.
The space of Taylor-equivalence classes of smooth maps , with derivatives through order agreeing at the source point. The projection has total dimension and fiber dimension . First-order fibers are canonically ; higher-order fibers have coordinate-dependent Taylor descriptions. The truncation to order is an affine bundle modeled on .
A harmonic map between Riemannian manifolds is a critical point of the Dirichlet energy . For a Euclidean domain and target unit sphere, the equation is . Stationary wave maps are exactly harmonic maps of their spatial domain.
A submanifold is a manifold sitting inside another manifold through an immersion or embedding. An embedded submanifold has the subspace topology and local coordinates in which it is a coordinate plane. Smooth transverse intersections are governed by the tangent spaces of the participating submanifolds.
Morse theory relates the critical points of a Morse function to changes in the homotopy type of its sublevel sets. Crossing a nondegenerate critical value attaches a cell or handle of dimension equal to the Morse index. The theory also applies to geodesic energy through broken-geodesic approximations.
The free chain group in degree has one oriented generator for each index- critical point. A cellular chain complex obtained from the Morse handle-attachment theorem computes the integral homology. Under the Morse-Smale gradient flow condition its differential can instead be obtained by signed counts of connecting trajectories. Over a field, if is the rank of , then . This identity implies both weak and strong Morse inequalities.
Here is the signed number of unparametrized trajectories of a Morse-Smale gradient flow from to . Compactifying one-dimensional trajectory moduli spaces gives . The generators coincide with the cells furnished by the unstable manifolds, and the trajectory count is their cellular incidence number, so the complex computes integral homology.
On the Klein bottle given by , the Morse function , , has one minimum, two saddles, and one maximum. In its descending Morse-Smale gradient flow, the two branches from either saddle to the minimum cancel. From the maximum to the fiber saddle, reflection of the fiber under the base identification reverses the transverse orientation, making the two contributions add. The contributions to the base saddle cancel. With a choice of generator orientations the displayed Morse chain complex follows. Thus integral homology is , and ; the top attaching word independently gives the coefficient two on the fiber generator.
For distinct ordered , the quotient on Real projective space has one critical point of index . Its descending flow is . The unstable cell at is . Between adjacent critical points there are two trajectories, whose relative orientation is the degree of the antipodal map on . Thus, up to generator orientation, the differential is two in even degrees and zero in odd degrees. This gives the integral cellular homology of real projective space rather than only its mod-two ranks.
For a closed manifold and a Morse function, the displayed strong inequalities hold for every , with equality at the top dimension. Indeed the Morse chain complex rank formula makes the alternating sum equal to . Adding the inequalities at and gives . The weak inequalities, even together with equality of Euler characteristics, are less restrictive: and satisfy those numerical conditions but violate the strong inequality at .
Crossing one nondegenerate critical point of Morse index in a compact sublevel interval attaches a handle . Between critical levels a suitably normalized gradient flow identifies the sublevels. The Morse lemma supplies the local quadratic model for the attachment. Retracting each handle to its core disk gives a CW complex model with one -cell per critical point. Closed manifolds have finite such decompositions; a noncompact manifold requires a proper bounded-below exhaustion for the corresponding statement.
On a complete compact Riemannian manifold, nondegenerate critical points of fixed-endpoint geodesic energy yield a CW complex model of the path space, with one cell per geodesic and dimension equal to its Morse index. Finite-dimensional broken-geodesic models prove the assertion at bounded energy, and exhaustion gives the full path space. On with distinct nonantipodal endpoints the cell dimensions are , one in each such dimension.
A Morse-Bott critical manifold is a smooth submanifold of critical points such that the kernel of the Hessian matrix at every is exactly . The Hessian is therefore nondegenerate in normal directions. Repeated based great-circle geodesics on a round sphere form such critical manifolds, parametrized by their unit initial directions.
The Morse index of a fixed-endpoint geodesic equals the number of conjugate points strictly between its endpoints, counted with multiplicity. Its nullity equals the multiplicity of the terminal conjugate point. A conjugate multiplicity is the dimension of the space of Jacobi fields vanishing at the initial point and at the point in question.
On the unit round sphere , a geodesic of speed on has normal Jacobi equation . Its conjugate parameters are , each with multiplicity . If is not an integer, its index is . For , its index is and its nullity is .
A pseudo-Riemannian manifold is a smooth manifold with a smooth metric tensor that is a nondegenerate bilinear form on each tangent space. Positivity is not required. A Riemannian manifold is the positive-definite case, while a Lorentzian manifold has exactly one temporal direction in its metric signature.
Geometric splitting theorems give hypotheses under which a manifold decomposes as a metric product. The Cheeger-Gromoll splitting theorem gives a Euclidean line factor for a complete connected Riemannian manifold with nonnegative Ricci curvature containing a globally minimizing geodesic line. Other splitting theorems use different curvature or causal hypotheses.
A pseudo-Riemannian metric is a smooth nondegenerate symmetric bilinear form on every tangent space, with locally constant signature. Its positive-definite special case is a Riemannian metric. Unlike a positive-definite metric, an indefinite metric admits nonzero null vectors. In either signature its Levi-Civita connection is uniquely determined by torsion-freeness and metric compatibility.
A Ricci-flat manifold has vanishing Ricci tensor. This is weaker than vanishing Riemann curvature tensor: the latter describes complete local flatness. A Kerr black hole supplies a Lorentzian manifold that is Ricci flat in its vacuum region but has nonzero Riemann curvature tensor.
For a twice continuously differentiable regular curve in Euclidean space, its unsigned curvature measures how quickly its unit tangent vector changes per unit arc length. WriteThe curvature iswhere the norm is the Euclidean norm. Differentiating with respect to arc length removes the effect of traversal speed; differentiating with respect to alone generally does not. See Ghomi's university lecture notes, section 1.7.
For a circle of radius , use . Then , and , giving . A straight line with has constant unit tangent vector, so .
The same circle traversed as has speed and : its curvature remains . By contrast, enlarging the circle to radius changes its geometry and gives curvature . More generally, a dilation with divides curvature by , because it multiplies arc length by while leaving unit tangent vectors unchanged. Thus curvature has units of inverse length, and a reparametrization changes neither its value at a corresponding point nor the shape.
Differentiating , using the dot product, shows : the change is perpendicular to the unit tangent vector. Wherever , the principal normal vector points toward the bend. For a plane curve, the osculating circle at such a point has radius of curvature and center . It matches the point, tangent line, and curvature, providing a local circular approximation. At there is no finite osculating circle defined by this formula. See Ghomi's university lecture notes, section 1.13.
This makes curvature useful for comparing bends without confusing them with speed. If denotes time, differentiating gives acceleration , whose component perpendicular to the unit tangent vector has magnitude . The curvature of a plane curve example below computes the bend and osculating circle of a parabola explicitly.
For smooth surfaces, bending has more than one direction. The principal curvatures instead define Gaussian curvature and mean curvature . These are surface quantities, distinct from the curvature of an individual curve. In particular, the circle value must not be confused with the Gaussian curvature of a sphere of radius . See Ritter's Oxford lecture notes, section 12.2.
Fix the standard orientation of a vector space on the plane. For an oriented regular curve in that plane, let be its unit tangent vector and let be its left unit normal, obtained by an anticlockwise rotation through . Its signed curvature , also commonly written , is defined byHere increases with the chosen traversal and is the determinant. Positive signed curvature means turning left; negative signed curvature means turning right. The left unit normal exists even when ; when it points opposite to the principal normal vector. See Ghomi's university lecture notes, section 1.10.
For an arbitrary regular parametric curve traversed with increasing , the signed curvature isFor the anticlockwise circle , the numerator is and the denominator is , so . For the clockwise traversal , the numerator is , so , while unsigned curvature is in both cases. On this circle points inward for anticlockwise traversal and outward for clockwise traversal. For any simple closed regular curve traversed anticlockwise, is the inward unit normal, but signed curvature can still be negative along nonconvex portions.
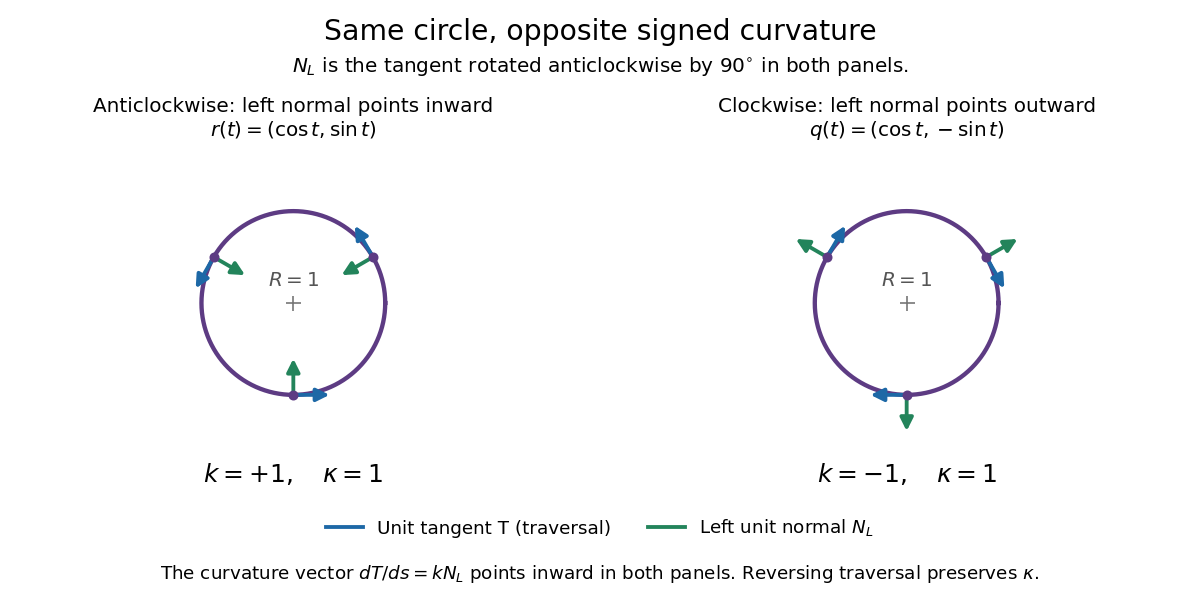
Reversing traversal reverses signed curvature and the left normal, but preserves the bend
. Details. To see why the formula uses the cube of the speed, write and . The term parallel to contributes zero to the determinant, giving . Under a reparametrization with , the numerator gains a factor and the denominator gains . Thus orientation-preserving reparametrization preserves signed curvature, while reversing traversal changes its sign at corresponding points. Unsigned curvature is preserved in either case.
Locally write the unit tangent vector as . Differentiating with respect to arc length gives : signed curvature records the direction as well as the amount of turning. Its integral therefore measures net turning, as in the turning tangent theorem; the integral of is total curvature and counts both left and right turns positively.
The unit tangent of a simple regular closed plane curve traversed anticlockwise turns once. Consequently its integrated signed curvature is ; clockwise orientation gives . Simplicity and one traversal are essential to this value.
For an oriented plane curve written locally as the graph , its signed curvature isThe equation describes straight lines, while describes consistently oriented arcs of circles of radius .
A Morse function is a smooth real-valued function whose critical points are all nondegenerate. Near a critical point of index , the Morse lemma gives coordinates in which the function is a constant minus squares plus the remaining positive squares.
A descending gradient-like field decreases away from its critical points and agrees with a negative gradient in chosen Morse lemma coordinates near those points. It transports attaching spheres and belt spheres across regular levels. Perturbations away from the critical points can arrange the transverse intersections used by the Morse-Smale complex, while preserving the prescribed local models.
The incoming and outgoing boundaries are the regular levels zero and one, and all critical points lie in the interior. Near the boundary use a collar coordinate as the function. The Morse handle-attachment theorem produces a relative chain group freely generated by the interior critical points. Thus is the alternating sum of their Morse indices, regardless of how their critical values are ordered.
If a cobordism Morse function on a trivial cobordism has exactly two critical points, its relative Morse chain complex has two generators and must be acyclic. Their indices therefore differ by one. The only differential is multiplication by the signed intersection of the lower point's belt sphere with the higher point's attaching sphere in a common regular level. A two-term complex of copies of is acyclic exactly when that integer is a unit. Algebraic intersection is therefore a necessary condition; it is not by itself a geometric handle-cancellation statement.
The critical points of are exactly pairs of critical points of its factors. Its Hessian matrix is their block direct sum, so their Morse indices add and nondegeneracy is preserved. The critical-count polynomial is the product of those of the factors. This construction also gives products of arbitrary smooth functions, with the critical-point count still multiplying even when some Hessians are degenerate.
For a closed connected orientable surface of genus , the Künneth theorem gives the Betti numbers of as . The weak Morse inequalities give the displayed lower bound. A surface Morse function with one minimum, saddles and one maximum exists from its standard handle decomposition. Adding a positive multiple of the cosine Morse function on the circle makes a product of Morse functions, whose critical counts are precisely these four Betti numbers. The lower bound is attained.
A Morse function is perfect over a specified field when its numbers of critical points equal the Betti numbers over that field. Over the rationals this forces every integer matrix in its Morse chain complex to have rank zero, hence to vanish. Consequently its integral homology is free of rank in every degree; a manifold with integral homology torsion cannot admit such an integral-critical-count perfect function.
The Morse lemma gives coordinates . Choose a Riemannian metric Euclidean in these coordinates. A downward gradient flow converging to has eventually, while . Thus its Riemannian distance from decays exponentially. A partition of unity makes this a global metric choice; changing the metric may change the trajectories.
The Morse index of a nondegenerate critical point is the number of negative directions of its Hessian matrix, counted with multiplicity. Equivalently, it is the maximal dimension of a subspace on which the second variation is negative definite. The same definition applies to a finite-index critical point of an infinite-dimensional energy.
The Morse lemma puts a smooth function near a nondegenerate critical point into a quadratic normal form.
At a nondegenerate critical point placed at the origin, integral Taylor theorem gives , where is a smooth symmetric matrix and . A constant linear change makes diagonal with entries . Successive completion of squares, with the Schur complement at each step, produces a smooth invertible triangular matrix such that . The pivots keep their nonzero signs near zero. The map has invertible derivative at zero, so the inverse function theorem makes it a coordinate system. The signs are the Hessian matrix signature by Sylvester's law of inertia.
A rank- distribution on a smooth manifold is a rank- vector subbundle of its tangent bundle. It is involutive when the Lie bracket of vector fields of any two local sections is again a section.
For a codimension-one tangent distribution, a coorientation is an orientation of its normal quotient line bundle. An oriented real line bundle is trivial: local positive sections can be combined with a partition of unity without cancellation. Hence a cooriented distribution is the kernel of a global nowhere-vanishing one-form. This choice is independent of the orientation of the ambient manifold, and reversing it does not change the Godbillon-Vey invariant.
A smooth distribution is involutive if its local smooth sections are closed under the Lie bracket of vector fields. The Frobenius theorem identifies this algebraic condition with being an integrable distribution.
A distribution is integrable when every point lies on an immersed submanifold whose tangent spaces equal the distribution. Such submanifolds are its integral manifolds.
An integral manifold of a rank- smooth distribution is an immersed -dimensional submanifold with at every point. For an integrable distribution, maximal connected integral manifolds form its leaves.
The map descends to an injective immersion from into the three-dimensional torus. Injectivity follows because an integer difference in with an integer difference in must be zero. Its image is dense by an irrational rotation of the circle, and is tangent to the commuting independent fields and . It is a leaf of a regular foliation, but cannot be an embedded submanifold: in an embedding chart the coordinate plane would be locally closed yet contain a dense ambient subset.
A smooth curve tangent to a regular integrable distribution lies in one maximal leaf of a regular foliation. In a Frobenius theorem chart its transverse coordinates have zero derivative, so each short segment lies in one plaque. A finite chain of such segments covers any compact parameter interval and joins plaques in the same leaf. A single embedded local plaque only gives confinement while the curve remains in its chart. A dense immersed cylinder in a three-dimensional torus shows why global embedded confinement cannot generally replace the immersed statement.
If has constant rank, the Frobenius theorem says that is integrable exactly when its annihilator is closed under the exterior derivative: equivalently,This is also equivalent to involutivity of .
For a nowhere-zero 1-form , the hyperplane distribution is tangent to hypersurfaces exactly when . In general relativity this characterizes hypersurface-orthogonal vector fields and implies vanishing twist.
A nowhere-zero differential one-form is hypersurface orthogonal if locally with . Its kernel consists of tangent vectors to the level hypersurfaces of . Frobenius theorem makes this equivalent to , where is the exterior derivative. With a torsion-free Levi-Civita connection, this is . For a timelike unit normal, projecting the derivative on both indices gives zero antisymmetric part, which explains why hypersurface orthogonality implies symmetric extrinsic curvature.
For a non-null Killing vector field of a Levi-Civita connection, hypersurface orthogonality implies that , with , is a closed differential form. The Killing equation and give , whence . The Poincaré lemma gives locally. For a timelike , supplies local static time coordinates. This does not assert global exactness.
For an involutive distribution of constant rank , induct on . Straighten a nonzero section by the flow-box theorem, and choose a frame with no component in the remaining fields. Involutivity implies for their column . The invertible solution of , initialized by on , makes independent of . Its restriction to the transverse slice is involutive of rank , so induction provides coordinates spanning it. Extending these coordinates independently of gives . Conversely, fields tangent to an integral manifold have tangent brackets because they preserve the ideal of smooth functions vanishing on it.
A plane distribution on a three-manifold is a rank-two distribution. Locally it is the kernel of a nowhere-zero differential 1-form .
The Frobenius theorem gives the local criterion
A contact structure on a three-manifold is a plane distribution locally of the form with nowhere zero. It is maximally nonintegrable; the standard example on is .
A smooth interval family of contact forms on a compact manifold without boundary is carried back to its initial contact distribution by a smooth isotopy. The pullback of each form is a positive smooth multiple of the initial form. Solve for the horizontal generator of contact stability and integrate the resulting scalar equation for the contact conformal factor along an isotopy.
If a time-dependent vector field satisfies , its flow maps satisfy , where . Thus the conformal factor is smooth and positive even when changes sign.
For a family of contact forms, require and solve . The contact distribution symplectic form gives a unique smooth solution. Then , with and the Reeb vector field.
A contact form defines the hyperplane distribution . Multiplying by a nowhere-zero function leaves this distribution unchanged. The contact distribution symplectic form distinguishes it from an integrable hyperplane distribution.
For a contact form on a -manifold, is nondegenerate: the contact condition says its top exterior power is nowhere zero on the hyperplanes. This fiberwise symplectic form identifies contact-plane vectors with covectors on that plane and determines the horizontal generator of contact stability.
For on , the Reeb field is . If is irrational, its only closed orbits are the two coordinate circles.
A surjective submersion between Riemannian manifolds is Riemannian when its derivative is a linear isometry from the orthogonal complement of its kernel onto the target tangent space. Its vertical space is the kernel and its horizontal space is the orthogonal complement.
For a surjective Riemannian submersion , let be the unnormalised mean curvature vector of its fibres, using an orthonormal vertical frame. With the positive Laplace-Beltrami operator, tracing the Riemannian Hessian in horizontal and vertical directions gives . Horizontal traces agree with those on the base; a vertical Hessian term is . Thus minimal fibres, in particular totally geodesic submanifolds as fibres, make pullback an injection from each base eigenspace into the corresponding total-space eigenspace. Its image is exactly the eigenfunctions constant on each whole fibre.
For a Riemannian submersion with totally geodesic submanifolds as fibers, the positive Laplace-Beltrami operator commutes with pullback of functions. Horizontal terms in the Riemannian Hessian are pulled back from the base, and vertical terms vanish. Minimal fibers suffice because only the trace of the vertical second fundamental form enters.
A basic function for a Riemannian submersion is a function pulled back from the base. It is constant along each fiber. Its Riemannian gradient is the horizontal lift of a vector field through a submersion of the base gradient. Constancy on connected fiber components alone need not imply global descent when fibers are disconnected.
If is a submersion at , there are local coordinates in whichEvery fiber of a submersion is consequently an embedded submanifold of codimension .
After choosing a Riemannian metric on the source of a submersion , the orthogonal complements map isomorphically to . Therefore every vector field on has the smooth lift
The fibers of a proper submersion over a connected base are mutually diffeomorphic. Lift a compactly supported vector field moving one nearby base point to another; properness makes the lifted field compactly supported, and its time-one flow identifies the fibers.
An immersion is a smooth map whose differential is injective at every point. A parametrized surface in is immersed when its two coordinate tangent vectors are linearly independent.
An isometric immersion is an immersion between Riemannian manifolds whose derivative preserves the inner products of tangent vectors; equivalently, . Its derivative is injective and the target may have larger dimension. A local isometry additionally requires a local diffeomorphism, so its tangent maps are linear isomorphisms. For example, a sphere with its induced Riemannian metric is isometrically immersed in Euclidean space, although its positive intrinsic sectional curvature differs from that of the ambient space.
A smooth embedding is an injective immersion that is a homeomorphism onto its image with the subspace topology.
This is the differentiable specialization of an embedding, with an injective differential in addition to its topological embedding property.
Choose finitely many coordinate charts on a compact manifold and smooth functions supported in them, positive on a cover. Extend the displayed chart products by zero. A positive first coordinate and its matching chart coordinates separate points, while their derivatives detect every nonzero tangent vector. Thus the map is an injective immersion; compactness makes it a smooth embedding. Extra zero coordinates make its codimension positive if required.
A smooth embedding of a compact manifold remains an embedding under sufficiently small C1 metric on a smooth mapping space perturbations. A positive uniform lower bound on its differential preserves immersion. Finite coordinate neighborhoods give uniform local injectivity for nearby maps, and compactness separates the remaining pairs of points. A uniform second-derivative bound gives an explicit local Taylor estimate, although it is not necessary for the C1 openness statement.
For smooth maps from a compact manifold with a fixed Riemannian metric to Euclidean space, the displayed metric measures uniform convergence of maps and their first derivatives. For a manifold embedded in Euclidean space use its induced metric. Different fixed metrics give equivalent topologies on a compact domain.
A tubular neighborhood of a smooth embedded submanifold is a neighborhood identified with a neighborhood of the zero section in its normal bundle. Radial deformation of punctured fibers gives the sphere bundle, and excision identifies the associated pair with a normal disk-bundle pair.
A smooth embedded submanifold has a neighborhood diffeomorphic to a neighborhood of the zero section of its normal bundle, with the zero section identified with the submanifold. One may prescribe the normal-bundle splitting of the derivative along that section. Choose a Riemannian metric making the splitting orthogonal and use its normal exponential map: its derivative there is the required isomorphism, so the inverse function theorem supplies local diffeomorphisms. A sufficiently small, possibly varying, fibre radius makes these fit into a tubular neighborhood.
A compact smooth embedding has a tubular neighborhood identified with its normal bundle. Collapse the complement of its open disk neighborhood to the basepoint and identify the remaining quotient with the Thom space of that normal bundle. Pulling back its Thom class constructs a Gysin class. For a graph embedding into a product with Euclidean space, desuspending the auxiliary coordinates gives the corresponding wrong-way map.
An immersed submanifold of is a manifold with an injective immersion ; when is treated as a subset, its manifold topology can be finer than its subspace topology.
For irrational , the mapis an injective immersion with dense image. It is not a smooth embedding, since points with arbitrarily large parameter return arbitrarily close to its initial point in the subspace topology.
An injective immersion from a compact smooth manifold into a Hausdorff smooth manifold is a smooth embedding. Indeed, it is a continuous bijection onto its image, and compactness makes its inverse continuous.
Articles were limited to the first 100 out of 973 total.
Articles by others on the same topic

Differential geometry is a branch of mathematics that uses the techniques of calculus and linear algebra to study the properties of geometric objects, particularly those that are curved, such as surfaces and manifolds. It combines concepts from both differential calculus, which deals with the notion of smoothness and rates of change, and geometry, concerning the properties and relations of points, lines, surfaces, and solids.



Bibliography:
- maths-people.anu.edu.au/~andrews/DG/ Lectures on Differential Geometry by Ben Andrews