Topology studies topological spaces through open sets and continuous maps. Its central equivalence is a homeomorphism: a bijection that preserves continuity in both directions. This lets us distinguish spaces by connectedness or compactness even when numerical metric values are irrelevant. The open interval and the real line have the same topology in this sense, although only the former is a bounded set with its usual metric.
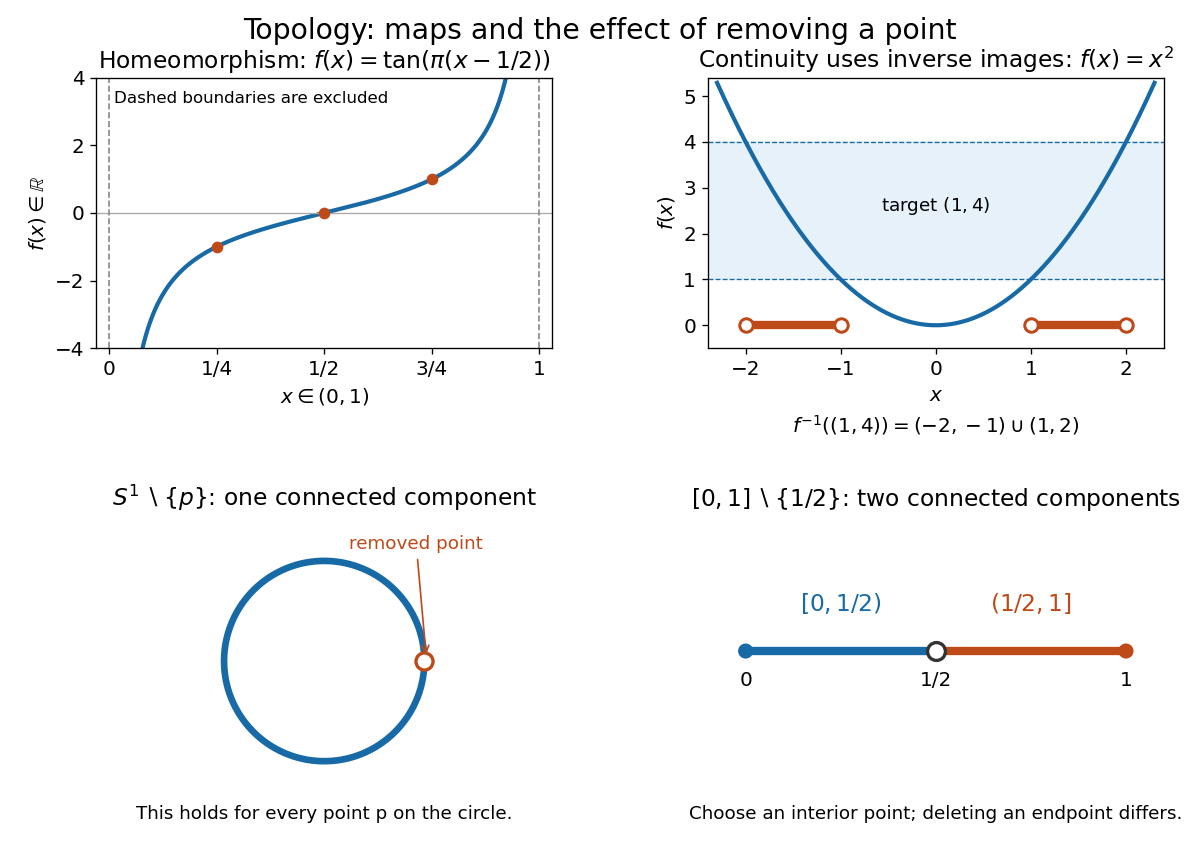
The upper panels show an explicit homeomorphism and the inverse image test for a continuous map. The lower panels exhibit an obstruction to a homeomorphism: removing any point from a circle leaves a connected space, whereas removing an interior point from a closed interval gives two connected components.
Homotopy is a different notion: it varies a continuous map continuously with a parameter and may collapse points. For example, contracts to zero. Thus this closed interval and a singleton have the same homotopy type, but there is no homeomorphism between them because there is no bijection. Homotopy equivalence need not preserve compactness. [ref]
The abstract viewpoint already appears explicitly in Tietze's 1923 paper: he describes topology as the study of properties invariant under invertible continuous maps with continuous inverses, and discusses axioms for neighbourhoods, citing Hausdorff's 1914 book, page 213. [ref]
https://gdz.sub.uni-goettingen.de/fulltext/PPN235181684_0088/00000294?_format=xml. Tietze, Beiträge zur allgemeinen Topologie I, page 290
For a family of functions into topological spaces, the initial topology on is the coarsest topology making them all continuous. Its subbasis consists of for open subsets . A map into is continuous exactly when all its composites with the are continuous.
On the real plane, take the initial topology of all separately continuous real-valued functions. Its coordinate lines have their usual induced topology, and the nonzero rational grid is dense, but its diagonal is uncountable and discrete. Thus the space is separable and nonmetrizable. Rectangular bump functions show that no sequence from the nonzero rational grid converges to the origin, so the space is not first countable either.
Fix a point of an uncountable set and declare closed when or is countable. Finite unions and arbitrary intersections satisfy the closed-set axioms. Every convergent sequence is eventually constant: the countable set of its values different from the limit is closed, so its complement is a neighborhood of the limit. A real-valued map constant at outside a countable set is continuous, because each closed inverse image either contains or lies in that countable exceptional set.
A space is zero-dimensional when its topology has a base of clopen sets. In the Hausdorff setting these sets separate distinct points, so the space is totally disconnected. Conversely a compact Hausdorff totally disconnected space has a clopen base, by the Šura-Bura component lemma and finite subcovers of the complement of a neighborhood.
The characteristic functions of a clopen topological basis give a topological embedding of a zero-dimensional topological space into a product of discrete two-point topological spaces. The separation axiom makes those functions distinguish points, and their coordinate preimages recover the original topological basis.
In a normal Hausdorff space, strong zero-dimensionality means that any disjoint closed sets can be separated by a clopen set, equivalently by disjoint clopen neighborhoods. For general Tychonoff spaces, the usual definition asks this for completely separated sets. In the normal setting Urysohn's lemma makes the formulations agree. The condition is equivalent to zero-dimensionality of the Stone-Čech compactification.
For normal Hausdorff , if has a clopen base, extend a Urysohn's lemma separator of two closed subsets of . Their closures in are separated; compactness gives a clopen separator, whose trace works in . Conversely separate the traces of the low and high level sets of a continuous by clopen . The characteristic function of extends into on . Density ensures its one level contains the zero level of and misses the one level. Applying this with separating a point from a closed set gives a clopen base for .
A Hausdorff compactification is a compact Hausdorff space with a topological embedding whose image is dense. It retains the original topology on while adjoining boundary points. For a locally compact noncompact Hausdorff space, its one-point compactification is an example. For every Tychonoff space, the Stone-Čech compactification extends all continuous maps into compact Hausdorff targets.
If a locally compact Hausdorff space is densely embedded in a Hausdorff space, its image is open. Around a point choose an ambient open set whose trace lies in a compact neighborhood . Density puts that ambient open set inside the ambient closure of its trace, which lies in because compact subsets of a Hausdorff space are closed. Thus the ambient open set lies in the image.
For a Hausdorff compactification , let be the intersections of the closures of the positive and negative tails, respectively. Each is nonempty and connected by the closed-filter-base theorem. Their union equals the remainder: an image point has a bounded-interval neighbourhood excluding sufficiently long tails, whereas every neighbourhood of a remainder point meets tails by density and compactness of bounded intervals. If the remainder is finite, each must be a singleton, so there can be only one or two remainder points. In particular there is no three-point compactification of the real line.
A Tychonoff space is Čech-complete if it is a G-delta set in a Hausdorff compactification. The G-delta compactification invariance makes this independent of the chosen compactification, and equivalent to being a G-delta set in its Stone-Čech compactification.
Write the dense space as in compact Hausdorff . Every is dense and open. A dense open subset of has the form with dense and open in . The compact Baire category theorem makes dense in , hence in . Therefore every Čech-complete space is a Baire space. The rationals are not a Baire space, as deleting their points one at a time gives dense open sets with empty intersection.
For the comparison map , the fibers of compactification comparison maps identity pulls a G-delta set presentation of back from . Conversely if with closed compact, then . Each image is closed and misses . Thus is a G-delta set in one Hausdorff compactification exactly when it is in every one.
If is the canonical map from the Stone-Čech compactification onto a Hausdorff compactification, its fibers over the original points are singletons. If and , choose an open neighborhood of in whose closure excludes . Choose open with and . The open neighborhood of has dense trace , placing in , a contradiction. This controls when images of closed remainder sets stay in the remainder.
For two topologies on the same set , is finer than when every -open set is -open. Equivalently, the identity function is continuous, by the definition using preimages of open sets. The inclusion may be an equality; strictly finer means proper inclusion.
The topological disjoint union of topological spaces has the labelled disjoint union as its underlying set. A subset is open exactly when its intersection with each labelled copy is open in that copy. Each copy is a clopen set, and a function from the topological disjoint union is continuous exactly when its restriction to every copy is continuous. This follows immediately by testing preimages of open sets on each copy. A topological space is homeomorphic to the topological disjoint union of its connected components exactly when all those connected components are open.
A topological invariant is a property or mathematical object preserved by homeomorphisms of topological spaces. Connectedness and compactness are examples. The fundamental group is an invariant up to group isomorphism; it is also preserved up to isomorphism by homotopy equivalence, a stronger invariance property which does not hold for every topological invariant.
An end of a noncompact topological space describes a coherent way to escape every compact subset. For a cofinal compact exhaustion, when one exists, , it is represented by nested connected components of the complements. A connected noncompact manifold is disconnected at infinity when it has more than one end.
Orientability asks whether local choices of handedness can agree everywhere on a manifold. On a smooth manifold, an orientation of a smooth manifold chooses an orientation of a vector space for each tangent space, continuously with position. An ordered basis describes the same handedness as another one when the change-of-basis determinant is positive. An oriented atlas implements this condition through positive Jacobian determinants of the smooth transition maps.
A paper strip makes the obstruction visible. Join its short ends without twisting: the resulting untwisted band admits a consistent choice of unit normal. Add a half-turn before joining: on the Möbius band, following the core circle of a Möbius band reverses that choice when you first return to the same point. A local decision about handedness has encountered a global contradiction. The normal reversal around the Möbius core makes this precise for an explicit model.
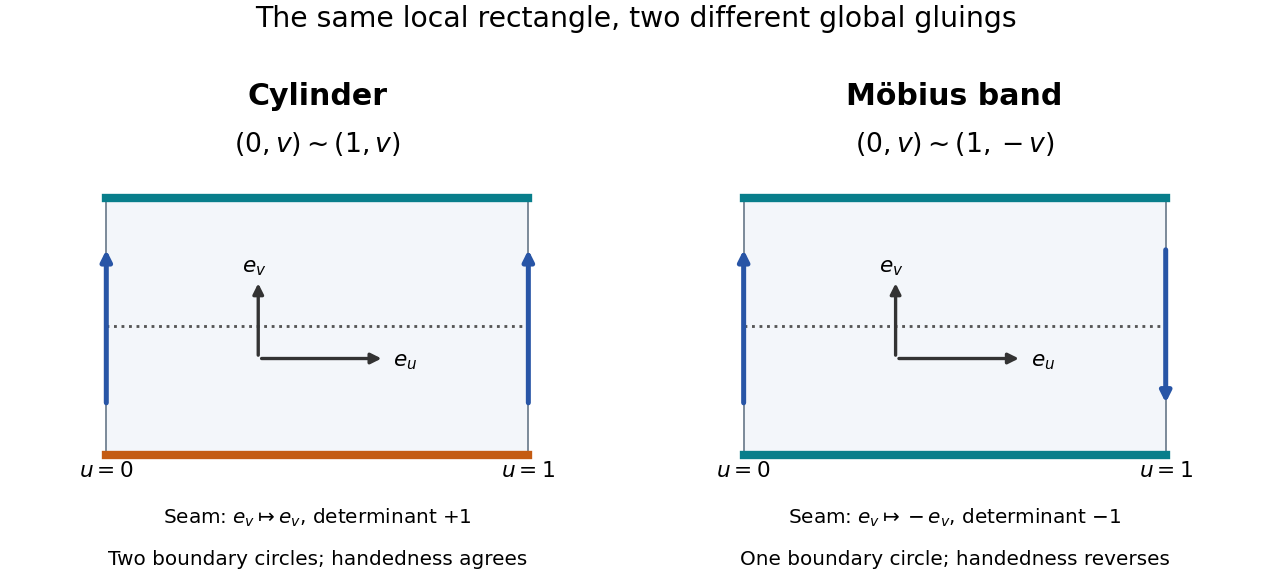
Both rectangles have coordinates . The untwisted band identifies with ; the Möbius band identifies with . Across a seam the corresponding local coordinate changes preserve or reverse , giving determinants and . This sign explains the handedness change; the drawing also tracks the two boundary circles of the untwisted band and the single boundary circle of the Möbius band.
For a smooth topological surface embedded in , choosing an orientation of a surface is equivalent to choosing a continuous unit normal. This picture is specific to surfaces in three-dimensional space: the general definition uses compatible local orientations, without requiring an embedding. Orientability is a topological invariant, so a homeomorphism cannot turn a Möbius band into a untwisted band. The sphere and torus are orientable surfaces; the Klein bottle is not. [ref]
The distinction matters when a sign has geometric meaning. A signed flux surface integral needs an orientation of a surface, and Stokes theorem relates that choice to the outward-normal-first boundary orientation. Ordinary unsigned surface area does not require orientability. Thus a Möbius band still has a perfectly meaningful area even though it has no continuous global unit normal.
A connected orientable manifold of positive dimension has two possible orientations: reversing every local choice gives the other one. If a manifold has several connected components, each component can be oriented independently when it is orientable. For topological surfaces, a useful obstruction criterion is the presence of a Möbius band: a surface is nonorientable exactly when it contains such a band. [ref]
https://pi.math.cornell.edu/~mec/Winter2009/Victor/part3.htm. Cornell Mathematical Explorers' Club, Orientable and Nonorientable Surfaces
A non-Hausdorff manifold is a locally Euclidean topological space for which distinct points need not have disjoint neighborhoods. The real line with two origins is a basic example. Nonseparated algebraic schemes exhibit analogous gluing phenomena, but are not generally topological manifolds.
Take with its Euclidean topology and identify with for every , retaining two distinct origins. This quotient space is locally homeomorphic to the real line but is not Hausdorff. Any open neighbourhoods of its origins have preimages containing and , so a nonzero gives a shared image point. All equivalence classes in the original metric space are finite and closed. This shows that closed equivalence classes do not suffice for a Hausdorff quotient space.
A Stone space is a compact Hausdorff space that is totally disconnected, equivalently a compact Hausdorff space with a basis of clopen sets. The topology on a type space gives an important example.
The nonempty open sets are the upper tails of the natural numbers. Arbitrary nonempty unions select the smallest starting index, and finite intersections select the largest, so these sets form a topology. A map into this space is continuous exactly when the inverse image of every upper tail is open.
For a map from the cofinite topology to the tail topology on the natural numbers, continuity is equivalent to every set being empty or cofinite. If the image is unbounded, every such set is nonempty and cofinite, so . If it is bounded, its maximum exists, and the inverse image of the tail at forces eventually, with always. Conversely either condition makes every tail preimage empty or cofinite.
The Fell topology on the closed subsets of a locally compact space has subbasic open sets requiring intersection with an open set or avoidance of a compact set. On a locally compact separable metric space, its sequential convergence says that every convergent subsequence of points from the varying sets has its limit in the limiting set, and every point of the limiting set is approximated by points from the varying sets.
These sets form a topology: a nonempty union of upper rays is another upper ray, or all of when their endpoints have no lower bound; a finite intersection of rays has endpoint the maximum of their endpoints. The whole line must be included. The continuous map from with the cofinite topology to this space is nonconstant, because each upper ray has cofinite inverse image.
For the topology consisting of the empty set, the whole real line, and upper open rays, a nonempty subset is compact exactly when it has a smallest element. An open set containing the smallest element contains the entire subset. Conversely, if there is no smallest element, the rays indexed by points of the subset cover it, but any finite selection misses its smallest chosen endpoint.
A topological space is hyperconnected if any two nonempty open sets intersect. Every continuous map from a nonempty hyperconnected space to a Hausdorff space is constant: two distinct image points would have disjoint open neighbourhoods whose nonempty inverse images contradict hyperconnectedness. Every infinite set with the cofinite topology is hyperconnected.
A closed cover of a topological space is a family of closed sets whose union is the whole space. A finite closed cover can be used in separation and antipodal arguments: in a metric space, vanishing distance to a closed member means actual membership. Unlike an open cover, a closed cover does not automatically have a partition of unity subordinate to its members.
Given a partition of a set, declare a subset open precisely when it is a union of partition blocks. Arbitrary unions and finite intersections of such unions are again unions of blocks, giving a topology. The quotient map to the block set with its discrete topology pulls that topology back to the original set. For the partition of into its two parity classes, the only open sets are the empty set, those two classes, and all of .
On an infinite set, the family consisting of all finite subsets and the whole set need not be closed under arbitrary unions. On , the union of the singleton subsets of is infinite and proper, so this family is not a topology. It must not be confused with the cofinite topology, whose proper open sets have finite complements.
The lower limit topology on has basis of a topology . Every such nonempty interval contains a rational, so this topological space is separable. Its topology is finer than the usual Euclidean topology; the one-sided basic neighbourhoods allow its square to have an uncountable discrete antidiagonal.
The Sorgenfrey plane is the product topology on two copies of the Sorgenfrey line. It is separable because meets every nonempty basic rectangle . Its antidiagonal is an uncountable discrete subspace: meets it only at . In a discrete space every dense subset is the whole space, so this subspace is not separable. Thus separability need not pass to subspaces of nonmetrizable spaces.
// Target: analysis.bigb
The th symmetric product of a space is , where the symmetric group permutes the factors. Its points are unordered -tuples, with repetitions allowed. If is a Riemann surface, elementary symmetric functions in local complex coordinates make its symmetric product a smooth complex manifold, including along the locus of repeated points. A collection of disjoint circles in gives a product torus in this symmetric product.
A topological space is extremally disconnected when the closure of every open set is open. This concerns open sets, not arbitrary subsets. In particular, a nonisolated singleton in a Hausdorff space is closed but not open, so its closure gives a counterexample to that stronger condition.
The open sets are the empty set and subsets whose complement is countable. On an uncountable set, any two nonempty open sets intersect, so the space is not Hausdorff. On a countable underlying set this topology is discrete. The compact subsets of a cocountable space are finite, regardless of the cardinality of the underlying set.
Only finite subsets are compact in the cocountable topology. An infinite subset contains distinct . The open sets obtained by removing the tails form an increasing open cover, but every finite selection misses a tail point. Finite sets are compact in every topology.
A family of subsets of a topological space is locally finite if every point has a neighbourhood meeting only finitely many of its members. On a compact space such a family has only finitely many nonempty members. For singleton subsets of a Riemann surface, this is the condition permitting prescribed poles of a meromorphic function without accumulation inside the surface.
The indiscrete topology on a set has only the empty set and the whole set as open sets. When has more than one point it is not a Hausdorff space. For example the quotient topology on is indiscrete: a nonempty open saturated subset contains an interval and all its rational translates, which cover .
A triangulation of a surface decomposes it into triangles meeting along full edges or vertices. On a closed surface, each edge is incident with two triangle faces, so . Euler characteristic connects this local counting relation with the surface's topology.
If a topological space is the union of finitely many closed subspaces and continuous maps on those subspaces agree on every overlap, they combine into a continuous map on the whole space. For a closed set in the target, its preimage is a finite union of closed sets, proving continuity.
The cofinite topology on a set declares the empty set and all cofinite subsets to be open sets: a nonempty open set may exclude only a finite set of points. There is no assumed metric. On an infinite set, this gives a particularly small collection of open sets while still making every singleton a closed set. On a finite set, every subset has finite complement, so the cofinite topology is the discrete topology.[ref]
For an original example, use and chooseBoth are open sets, and their intersection is . Thus are in both. Their finite exclusions cannot separate the infinite remainder. The finite intersection of any finite collection of nonempty open sets is again a nonempty open set, since its complement is a finite union of finite sets. An arbitrary nonempty union is open because its complement is contained in the finite complement of any one nonempty member.
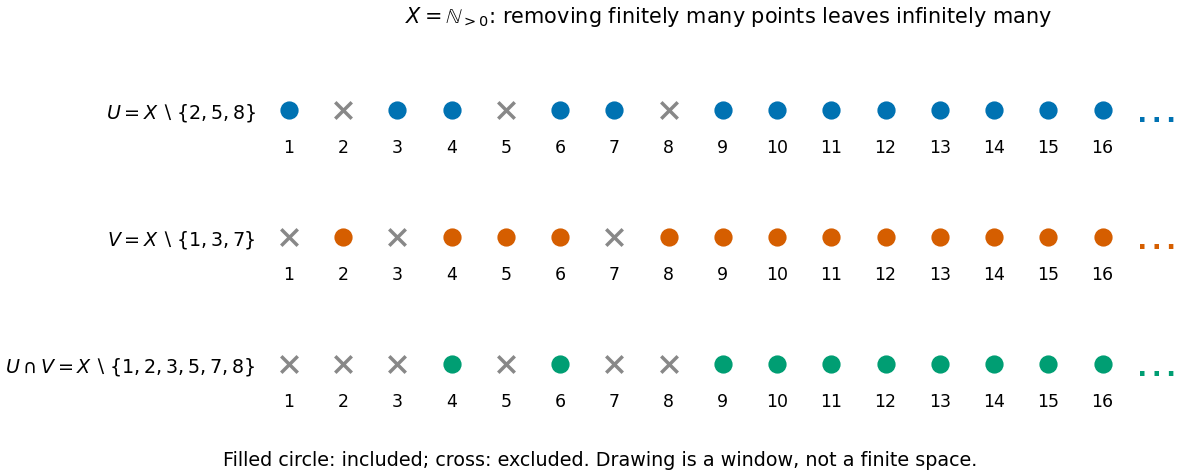
Two open sets with finite exclusions still overlap in an infinite cofinite topology
. Original sets on . Only the first sixteen labels are drawn; the dots continue indefinitely and are all included after the last excluded label. Spacing is for readability and defines no metric. Filled circles belong to the displayed set; crosses are excluded. Details.The cofinite topology is useful for separating hypotheses that familiar metric spaces package together. An infinite cofinite topological space is a T1 space, because its singletons are closed, but is not a Hausdorff space, because two nonempty open sets cannot be disjoint sets. It is a hyperconnected space and hence a connected space. Moreover, every subset of a cofinite space is compact, and sequence convergence in the cofinite topology can have many limits. These are compatible properties, rather than contradictions: the usual uniqueness and closedness results use the Hausdorff space hypothesis.[ref]
Chapter 1: Topological spaces. Example 1.5.10 and Proposition 1.5.11: closed points, overlapping neighbourhoods, non-repeating sequences and uniqueness in Hausdorff spaces
Let be the underlying set of real numbers with the cofinite topology. The diagonal in with its subspace topology is homeomorphic to the usual real line. Indeed, is a continuous bijection: its first coordinate is continuous because usual finite sets are closed, and its second coordinate is the identity. The inverse is the second coordinate projection restricted to . Consequently is not compact, whereas is compact by the fact that every subset of a cofinite space is compact. Thus is not homeomorphic to .
For a set with its cofinite topology, a subset is a connected subset exactly when is empty, a singleton, or infinite. Indeed, its subspace topology is the cofinite topology on : the traces of open sets are precisely for finite , together with the empty set. For infinite , two nonempty open sets intersect, because their complements have finite union. Hence is a hyperconnected space and therefore a connected space. A finite has the discrete topology, which admits a separation of a topological space as soon as has at least two points.
For an infinite set with its cofinite topology, every infinite subset is connected, but has an infinite disconnected topological subspace. Choose and use . The open sets and have disjoint nonempty traces and on , covering it. Thus is a product of a discrete two-point subspace with an infinite cofinite factor. The ambient open rectangles may intersect; only their traces must be disjoint for a separation of .
By convergence of a sequence in a topological space, means that every open neighbourhood of contains all sufficiently late terms. In the cofinite topology, this is equivalent to the condition that, for every , the value occurs only finitely often. Necessity uses the open neighbourhood ; sufficiency chooses an index beyond every last occurrence of the finitely many points excluded by a given open neighbourhood.
Consequently a sequence with distinct terms converges to every point of . For the original choice on , take the two open neighbourhoodsAll terms with lie in and all terms with lie in . More generally, each finite excluded set has a last visit, so and , and in fact for every . No numerical distance is tending to zero here; the open sets specify the meaning of convergence.
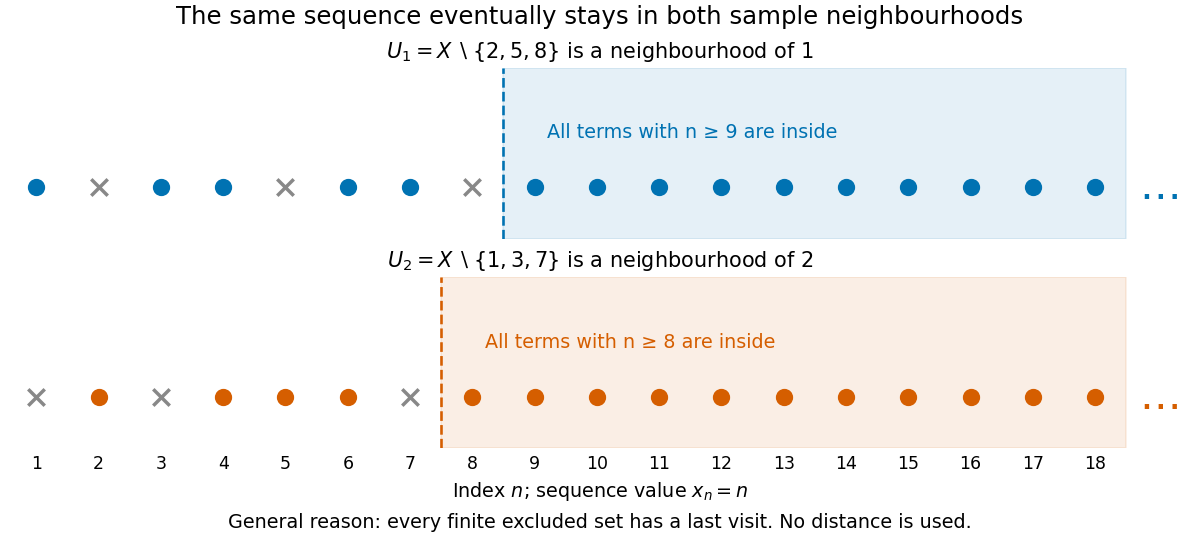
The same sequence eventually stays in neighbourhoods of two different limits
. Original sequence in the cofinite topology. Two sample neighbourhoods have different finite exclusions and different last-visit indices. Their memberships illustrate the general finite-exclusion argument; testing just these two neighbourhoods would not by itself prove convergence. Details.Distinct terms are sufficient, not necessary. The sequence also converges to every point, since each value occurs only twice. By contrast, the constant sequence converges only to : an open neighbourhood of any can exclude . The alternating sequence converges to no point, since some value different from any proposed limit occurs infinitely often.
Every subset of a cofinite topological space is a compact subset. To see the finite reduction directly, take an open cover of a nonempty by open sets of and choose one member containing a point of . Since has finite complement, the set is finite. Choose a covering member for each of those remaining points. Those members together with are a finite subcover. The empty set is already compact.
Equivalently, the subspace topology on is itself cofinite: for finite , the trace of is . The argument applies again inside . A concrete open cover of needs only the two members and when these labels are distinct: each fills the other's single gap.
On , the subset of even integers is compact but not closed, because it is infinite and proper. A compact subset of a Hausdorff space is guaranteed to be closed, whereas compactness without the Hausdorff space assumption does not suffice. Changing the topology changes compactness: the same infinite set with its discrete topology has the singleton open cover, which has no finite subcover. The finite-exception argument is special to finite complements; in the cocountable topology, compact subsets of a cocountable space must instead be finite.
If is an infinite set with its cofinite topology and is a Hausdorff space, every continuous map is a constant function. Otherwise two distinct image points would have disjoint open neighbourhoods. Their inverse images would be nonempty disjoint open sets of , contradicting its hyperconnected space property.
For example, from with its cofinite topology into the real line with its usual Euclidean metric is not continuous: the inverse image of the open interval is , which is not open in the infinite domain. A continuous real-valued readout on that domain can only report one value. Finite cofinite domains are different: their discrete topology allows arbitrary functions into any topological space.
Let be a nonempty infinite set with the cofinite topology, let be any topological space, and let be Hausdorff. For a continuous map , every slice is constant. Thus , where for any fixed . The map is continuous, since is continuous into the product topology. It is unique because the coordinate projection is a surjection. If is a surjection, so is .
For and homeomorphic to the circle, a surjective cannot be injective: otherwise the compact-to-Hausdorff continuous bijection theorem would contradict the fact that the circle and interval are not homeomorphic. Hence distinct satisfy simultaneously for all .
A continuous map from a nonempty finite product space of infinite sets with their cofinite topologies to a Hausdorff space is a constant function. Fixing all but one coordinate gives a continuous map from an infinite cofinite topology, so changing that coordinate does not change the value. Any two points in a finite Cartesian product can be joined by finitely many one-coordinate changes. This proves the assertion. In particular every real-valued continuous function on is constant when is the real line equipped with the cofinite topology.
A nonempty Hausdorff space is the continuous image of exactly when it is compact, connected, locally connected, and second-countable.
A Peano continuum is a compact, connected, locally connected metric space. By the Hahn-Mazurkiewicz theorem, every Peano continuum is the image of a continuous surjection from .
A topological -manifold without boundary is a topological space satisfying three conditions: it is Hausdorff, it is second countable, and every point lies in an open set with a homeomorphism onto an open set . Here is a fixed dimension of a manifold, and has the usual topology of Euclidean space. The pair is a coordinate chart. Unless explicitly qualified, “topological manifold” here means without boundary.[ref]
The Hausdorff condition requires disjoint open neighbourhoods for distinct points. Second countability requires a countable basis of a topology. Neither follows merely from the local homeomorphisms: non-Hausdorff manifolds fail the first condition, while an uncountable disjoint union of copies of the real line fails the second. Indeed, a basis of a topology must supply a different nonempty member inside each copy, so it cannot be countable.
The circle and the real line are both one-dimensional topological manifolds, with the same local model. Their global topologies differ: the circle is compact, while the real line is not. By contrast, the junction of a topological tripod already fails the local test. Thus local coordinate charts specify what kind of small pieces are allowed; global topological invariants distinguish how those pieces fit together.[ref]
Introduction. Introduction to Topological Manifolds by John M. Lee, second edition, Chapter 1, pages 1–3 on local models and pages 5–6 on topological invariants
The usefulness of a topological manifold is that local questions about continuity can be transported into Euclidean space, while compactness, connectedness, and the fundamental group still record global information. For calculus, further structure is needed: a smooth atlas requires smooth transition maps, letting the chain rule reconcile derivatives computed in different coordinate charts. A topological atlas by itself only guarantees homeomorphisms between coordinates.[ref]
Week 2 course notes. Topology I: smooth manifolds, Week 2, Section 1.2, equation (11) and Definitions 1.15–1.16, pages 5–6
An orientation of a topological manifold chooses a generator of every local homology group , compatibly on coordinate neighbourhoods. Each choice is a local orientation of a manifold. Compatibility means the generators are locally restrictions of the same relative orientation class. It can be checked by choosing oriented coordinate balls and requiring agreement wherever their local classes overlap.
For a connected closed manifold, an orientation gives a unique fundamental class in whose restriction at each point is the chosen local generator. In an oriented triangulation this class is the sum of compatibly signed top simplices: interior faces cancel in opposite pairs, while the local coefficient in every top simplex is one. Reversing every local generator negates the fundamental class.
A topological atlas is a family of coordinate charts whose domains form an open cover of a topological manifold. Each point must belong to at least one chart domain; no individual domain needs to cover the entire topological manifold. On overlaps, topological transition maps describe the same points in two coordinate systems.
For two coordinate charts in a topological atlas, the topological transition map is the homeomorphismBoth domains are open sets in Euclidean space. Function composition gives and wherever all three coordinate charts overlap. These identities express consistency of the coordinate descriptions; imposing smooth functions as the coordinate changes gives a smooth atlas.
Take the circle with its subspace topology. Write for its west point and for its east point. Two coordinate charts obtained by stereographic projection areBoth take values in the entire real line. Geometrically, join to and intersect the resulting line with : the height is . Projecting from instead gives height . Each projection omits its own starting point, but the other coordinate chart includes that point. Hence .[ref]
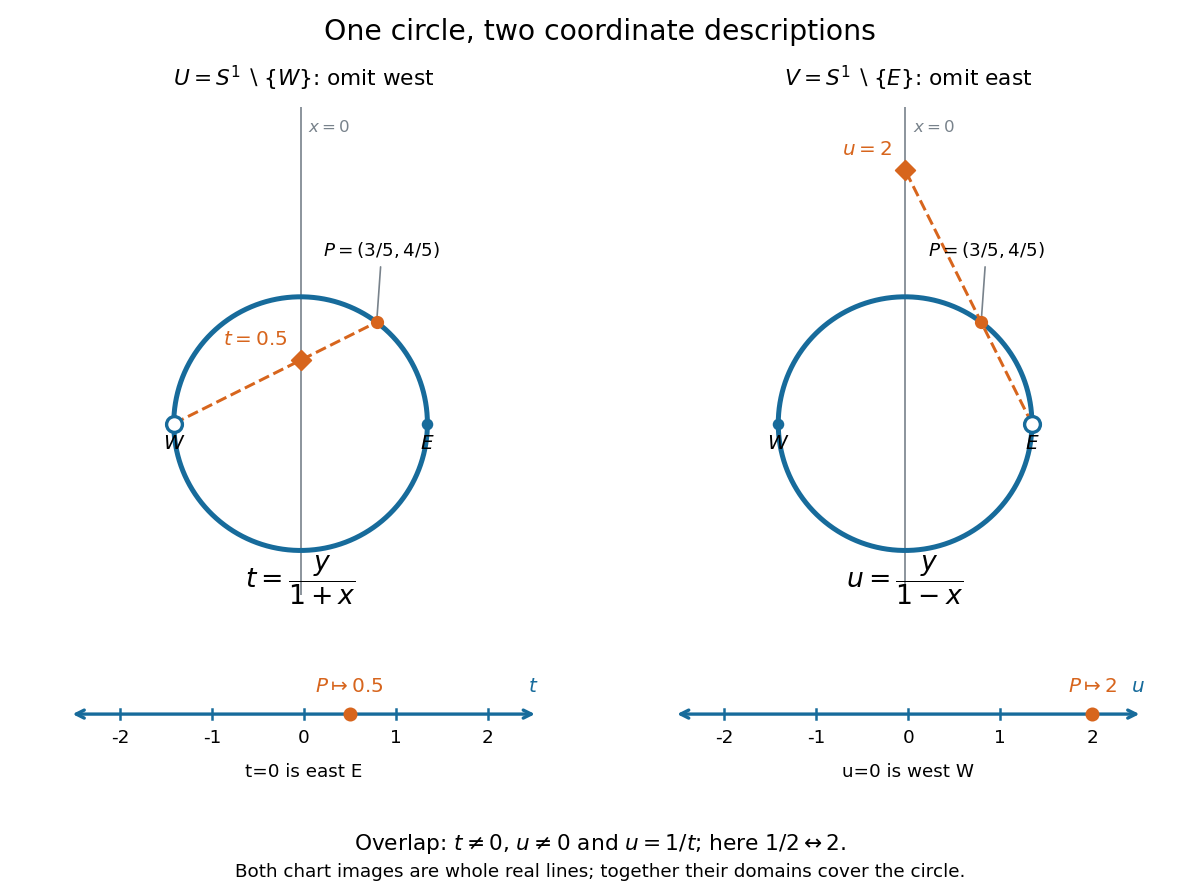
To verify the homeomorphisms, solve the displayed equations for . The inverse functions areEach formula lies on the circle, avoids its excluded point, and is continuous for every real argument. Substitution into the projection formulas returns or ; substitution in the other direction returns . Thus these are continuous bijections with continuous inverse functions, as required for coordinate charts. Since the Euclidean plane is Hausdorff and second countable, the subset with its subspace topology is too. This checks all three conditions for a topological manifold, rather than just drawing a smooth-looking curve.
On the overlap , both are excluded, so . Using , the topological transition map isFor example, has and . The two connected components of the overlap, the upper and lower arcs, correspond to the positive and negative parts of the punctured real line. The values and represent and , respectively, and belong to only one chart each. The reciprocal coordinate change and its inverse function are smooth functions away from zero, so this topological atlas also supplies a smooth atlas.
Why can neither chart be enlarged to a single coordinate chart on the whole circle? The circle is a closed set and a bounded set in the Euclidean plane, hence compact by the Heine-Borel theorem. A global coordinate chart would give a homeomorphism to a nonempty open set . Its image would be compact and therefore closed in the real line. By connectedness of the real line, this forces , which is not compact. This is the one-dimensional instance of no compact manifold has a single Euclidean chart. Locally the circle is indistinguishable from the real line; globally compactness obstructs a single chart.
For , a topological -manifold with boundary is a Hausdorff second-countable space locally homeomorphic to relatively open sets in the half-space . The openness here is in the subspace topology of , not necessarily in . Its intrinsic boundary consists of points sent to ; the remaining points have ordinary coordinate charts with images open in Euclidean space. The intrinsic boundary is independent of the chosen chart.[ref]
Week 2 course notes. Topology I: smooth manifolds, Week 2, Section 1.3, equation (21), Definition 1.21 and Remark 1.24, page 7
The closed interval illustrates the distinction: its interior points have open interval charts, while and have charts modeled on , using and . Its intrinsic boundary is . The circle has empty intrinsic boundary even though its boundary of a set as a subset of the Euclidean plane is the whole circle. A topological manifold without boundary is therefore a special case with , and a smooth atlas on the half-space charts gives a manifold with boundary in the smooth sense.
The manifold boundary of a topological manifold with boundary consists of the points which, in a half-space coordinate chart, have last coordinate zero. These are precisely the points without a neighbourhood homeomorphic to an open set in the full Euclidean space of the same dimension. It is an intrinsic property, independent of the coordinate chart. It differs from the boundary of a set in an ambient topological space: a circle has empty manifold boundary, but its boundary of a set in the Euclidean plane is the entire circle.
The category of topological manifolds has topological manifolds without boundary as its objects of a category and all continuous maps between them as its categorical morphisms. Allowing every dimension of a manifold lets maps connect spaces of different dimensions. Identity functions are continuous, and function composition preserves continuity, so the category laws are inherited from functions. Its isomorphisms are exactly homeomorphisms.
In coordinate charts on and on , a continuous map is represented locally by on . Changing coordinate charts changes this expression through topological transition maps, while itself stays fixed. This viewpoint separates the underlying continuous map from the coordinates used to describe it; restricting to smooth manifolds and smooth maps gives the corresponding smooth category.
A piecewise linear ball is a simplicial complex admitting a homeomorphism to an -simplex that is linear on the simplexes of suitable finite simplicial subdivisions. Its boundary is a piecewise linear sphere.
Two piecewise linear balls of dimension three glued along a common boundary disk form another piecewise linear ball. The Schoenflies theorem identifies each boundary pair with a sphere and a hemisphere. Coning the resulting boundary homeomorphisms extends them over the balls, which then become the two halves of a standard ball. The same argument shows that removing a ball attached along one boundary disk leaves a ball.
A smooth four-manifold is a four-dimensional smooth manifold. Its intersection form and gauge-theoretic invariants impose strong constraints on its possible smooth and symplectic structures.
Remove tubular neighborhoods of diffeomorphic embedded oriented surfaces with opposite normal Euler numbers, and glue their boundary circle bundles by a fiber-reversing identification. The resulting smooth manifold is a fiber sum. The square-zero case uses trivial normal bundles. Additional symplectic hypotheses give a symplectic fiber sum along a square-zero surface.
For standard unknotted spheres contained in four-balls in and , the standard fiber-reversing gluing gives the displayed connected sum. The complement of an unknotted in is , and its double is . The portions of and outside the four-balls remain as connected summands. Taking both ambient manifolds to be the Complex projective plane gives a smooth fiber sum with no symplectic form, by the symplectic connected-sum obstruction.
If a closed oriented smooth four-manifold splits as a connected sum with both , its ordinary Seiberg–Witten invariants of a four-manifold vanish. Combined with Taubes nonvanishing theorem, this obstructs a symplectic structure in that orientation.
A closed symplectic manifold of real dimension four with has a nonzero Seiberg–Witten invariant of a four-manifold in its canonical structure, with value . The positive index of the intersection form hypothesis avoids chamber dependence. This provides the symplectic connected-sum obstruction.
A closed symplectic manifold of real dimension four cannot be a connected sum of two oriented smooth four-manifolds each with positive positive index of the intersection form. The total exceeds one; Taubes nonvanishing theorem and connected-sum vanishing of the Seiberg–Witten invariant would force the same invariant to be both nonzero and zero.
Glue two copies of a compact manifold along their boundaries to form its double. A collar gives the double a smooth structure when is smooth. Folding the copies onto gives a retraction; in particular, inclusion of either copy is injective on homology. For an oriented manifold, use the opposite orientation on the second copy.
A topological tripod is three copies of the closed interval with their zero endpoints identified to a single junction . Equivalently, embed three line segments with distinct directions in the Euclidean plane and use the subspace topology. It is a compact, connected metric space, and is Hausdorff, second countable, and paracompact. Every interior arm point has a coordinate chart to an open interval, and each outer endpoint has a half-interval chart as in a topological manifold with boundary. The junction has neither kind of chart.
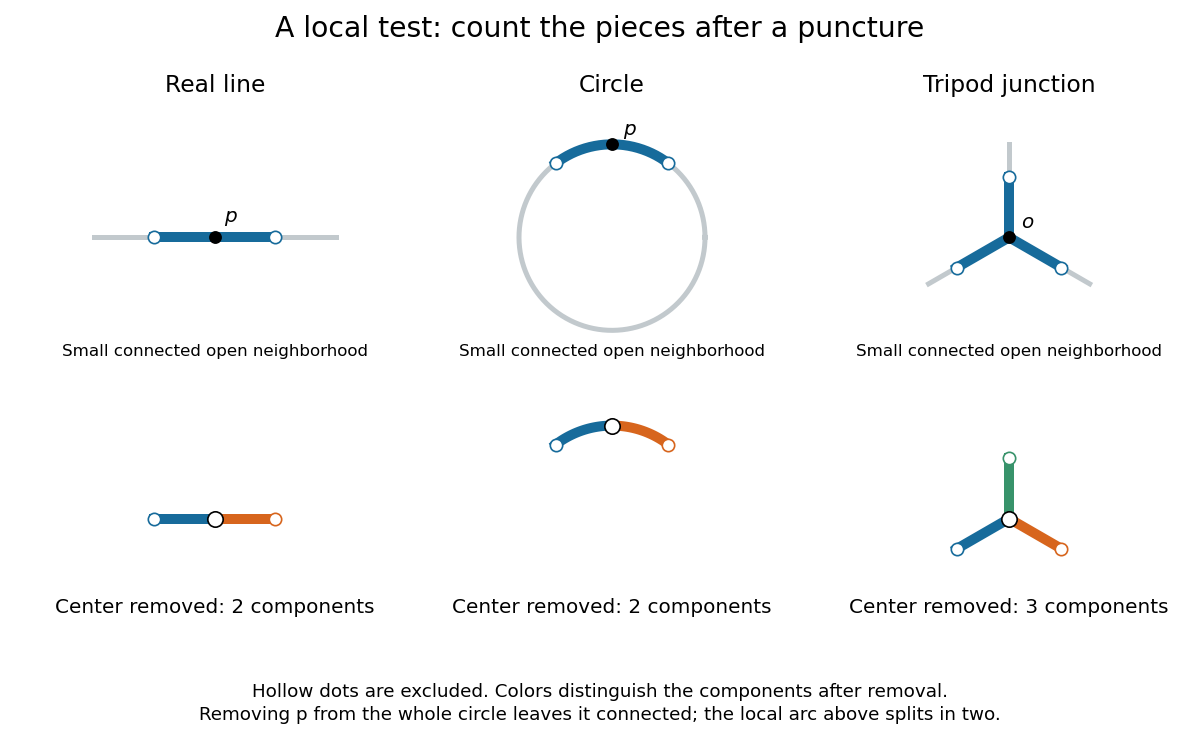
Removing the center of a small neighborhood leaves two pieces on a line or circle, but three at a tripod junction
. Details. Here is a precise local obstruction. Let be a small open neighbourhood of consisting of initial segments of the three arms, excluding their outer endpoints. Every connected open neighbourhood of contained in contains an initial segment on every arm, because is open at . Its intersection with each arm has no gaps: if a point between and a point of were missing, cutting there would separate the part beyond it from the rest of , contradicting connectedness. Thus has exactly three connected components, one interval per arm.
Suppose a coordinate chart to the real line existed at . Choose a small open interval about lying inside , and restrict the chart to . This is a connected open neighbourhood of contained in . Removing leaves three connected components in , while removing leaves two in . A homeomorphism preserves connected components, so this is impossible. This restriction step is essential: the count is proved for any sufficiently small connected chart neighborhood, not merely one chosen drawing.
A higher dimension of a manifold cannot repair the junction. For , repeat the argument with an open ball about : a punctured open ball in is path-connected, whereas still has three connected components. A zero-dimensional chart would make an isolated point, which it is not. A chart at a boundary point of a topological manifold with boundary similarly gives a punctured relative half-ball: one connected component when , and a path-connected space when . Consequently the topological tripod fails the local definition even when intrinsic boundary is allowed.
The circle provides a useful warning about scale: deleting a point from the whole circle leaves a connected space, but deleting it from a sufficiently small connected arc leaves two connected components. Local chart tests use the latter. The circle and interval are not homeomorphic article uses deletion from the whole spaces for a different, global obstruction.
Invariance of domain says that a continuous map that is an injective function between topological manifolds without boundary of the same dimension is an open map. It is useful in the Penrose singularity theorem: projecting a compact achronal boundary along timelike curves onto a Cauchy hypersurface gives a nonempty subset that is both open and closed, forcing that connected Cauchy hypersurface to be compact.
A smooth manifold carrying a nondegenerate bilinear form on each tangent space, with one negative and all remaining positive eigenvalues, or the overall reversed-sign convention. Its nonzero null vectors have vanishing metric quadratic form.
The metric signature records the signs of the diagonalized nondegenerate metric tensor, equivalently its numbers of negative and positive directions. For a four-dimensional Lorentzian manifold, both and its overall negative convention are common. The numerical signs of contractions and component Hodge star operator identities must be consistent with that choice and the orientation.
In metric signature , a spacelike submanifold of a Lorentzian manifold has an induced metric tensor defining a positive-definite quadratic form. With the overall reversed metric signature, its induced metric tensor instead has only negative eigenvalues. The definition applies to any dimension: enclosing charge-integration surfaces in four dimensions are two-dimensional examples, whereas a spacelike Cauchy hypersurface in four dimensions is three-dimensional.
A topological manifold has dimension when its manifold charts have coordinate domains open in . For a smooth manifold, each tangent space has dimension , and a tangent bundle has vector bundle rank .
The codimension is the difference between the dimension of a manifold and that of its submanifold. For complex submanifolds, complex codimension one means real codimension two.
Attaching an index- handle to an -dimensional manifold with boundary glues along . The complementary replaces the attaching region in the boundary.
A four-handle is an index-four handle. In a four-dimensional handle decomposition it is a four-ball attached along its whole boundary, a three-sphere. It caps a spherical boundary component left by earlier handle attachments.
An index- handle in dimension is this product of disks, attached along . Its core disk is , and its belt sphere is . The complementary boundary piece is . Crossing a critical point in the Morse handle-attachment theorem produces precisely this local change.
A framed embedding of the left-hand region in an -dimensional manifold specifies an index- surgery. Remove its interior and glue the right-hand region along their common boundary . The cobordism realizing this change attaches an index- handle of dimension . On an oriented surface, index-two surgery cuts out an annular neighbourhood of a simple closed curve and caps its two boundary circles.
A zero-handle in an -dimensional handle decomposition is . Its attaching region is empty, so it starts a connected component of the manifold. In dimension four it is a four-ball; adding one-handles and two-handles gives a four-dimensional handlebody with a two-dimensional CW spine.
The core disk of a -handle attachment is . Together with its cap in the preceding stage, it often represents a homology class; for a surgery trace, capped two-handle cores give the basis of its surgery linking matrix.
A handle decomposition builds an -dimensional manifold by successively adjoining along . The attaching data comprise an attaching sphere and its framing of an embedded sphere. Reading a decomposition backwards replaces index by index and interchanges its attaching spheres and belt spheres.
In a critical level handle embedding, the handles occur at distinct heights in an ambient product with the real line. Between consecutive heights, the boundary of the already attached handles travels through a product collar neighbourhood. At a handle height the horizontal slice contains the handle, attached to the incoming boundary along its attaching region. This separates the local topology changes from the intervening product regions.
Write each sphere as two disks, . In their product, is a zero-handle; and are two-handles. Their attaching circles are the core circles of the complementary solid tori in , hence a Hopf link. Constant normal directions from the disk factors give both components the zero Seifert framing. The remaining is a four-handle. This product construction establishes the actual diffeomorphism type, rather than relying on its intersection form alone. The resulting intersection matrix is .
Attach two one-handles to a four-dimensional zero-handle, then a two-handle along the commutator of their generators with the product zero framing. The result is . Its spine is the usual cell structure of the torus: one vertex, two one-cells, and a two-cell attached by . An embedded representative of its generator is obtained by taking a once-punctured torus carried by the two one-handles and capping its boundary by the core disk of the two-handle. It meets the relative co-core once and has self-intersection zero. The boundary is , whose integral homology has ranks .
A handle slide replaces the framed attaching sphere of one handle by a band sum with a parallel copy of another handle of the same index. It changes the attaching data while preserving the diffeomorphism type of the resulting manifold. On the handle incidence matrix it performs an elementary row operation, or a column operation when applied to the dual decomposition.
In the intermediate-index range, if an attaching sphere meets a belt sphere at exactly one transverse point, handle slides can remove the intersections of every other attaching sphere with . The dual slides then remove the intersections of with the other belt spheres. Each move uses a band to the unique pivot sheet and a local isotopy removing the old and new intersections. If and , the remaining incidence block is , the Schur complement of the pivot. Extreme-index cases need separate hypotheses.
The belt sphere of an index- handle is in the boundary after attachment. It is the attaching sphere of the dual index- handle. Its intersections with the attaching spheres of later handles detect passages through this handle.
The attaching sphere of an index- handle is in the previous boundary. Its framing of an embedded sphere identifies a neighbourhood with and specifies the handle attachment.
Relative to a triangulation, a normal surface meets every tetrahedron in disjoint normal disks: four types of triangles cutting off vertices and three types of quadrilaterals separating opposite pairs of edges. A normal disk meets any edge at most once; its face arcs join distinct edges. Two different quadrilateral types cannot coexist in a tetrahedron.
For tetrahedra, count the seven disk types in each tetrahedron. Across each glued face the counts of each of its three normal arc types must agree. These are homogeneous linear equations with integer coefficients. An admissible solution also has at most one nonzero quadrilateral type in each tetrahedron. Matching the arcs in their boundary order reconstructs the normal surface up to an isotopy preserving the tetrahedra.
The weight of a normal surface counts its intersections with the edges of the triangulation. It is a positive linear function of its coordinates: each corner of a normal disk contributes the reciprocal of the number of tetrahedral sectors around its edge. Thus a nontrivial decomposition into compatible coordinate vectors gives both summands strictly smaller weight.
The Haken sum of compatible normal surfaces is obtained by resolving their intersection curves in the way that preserves the normal disk types. It adds normal surface coordinates, Euler characteristic and mod-two homology classes. The alternative local resolution can create returning face arcs and need not be normal.
Articles were limited to the first 100 out of 538 total.
Articles by others on the same topic

Topology is a branch of mathematics that deals with the properties of space that are preserved under continuous transformations, such as stretching, twisting, crumpling, and bending, but not tearing or gluing. It focuses on the concepts of structure, continuity, and convergence, and is often described as "rubber-sheet geometry" because of its emphasis on the flexible and qualitative aspects of geometric forms.



Just by havin the notion of neighbourhood, concepts such as limit and continuity can be defined without the need to specify a precise numerical value to the distance between two points with a metric.
As an example. consider the orthogonal group, which is also naturally a topological space. That group does not usually have a notion of distance defined for it by default. However, we can still talk about certain properties of it, e.g. that the orthogonal group is compact, and that the orthogonal group has two connected components.