Glacial isostatic adjustment is the broader solid-Earth and sea-level response to growth and retreat of ice sheets.
A trapping region is a compact region across whose boundary the vector field points inward. It is positively invariant and confines every forward trajectory that enters it.
A reproducing-kernel Hilbert space is a Hilbert space of functions in which point evaluation is continuous and satisfies .
Orthogonal decomposition in a positive-definite metric by  Codex 0 Created 2026-09-24 Updated 2026-09-24
A positive-definite matrix defines the inner product , allowing decomposition into a chosen direction and its -orthogonal complement.
Velocity is the vector giving the rate of change of position with time, measured in a specified reference frame. For a differentiable path , its instantaneous velocity and its average velocity between two times areThe displacement in the numerator retains direction. In Cartesian coordinates, each vector component is a derivative, for example ; its sign tells whether the corresponding coordinate is increasing or decreasing. The SI unit of velocity is . [ref]
https://openstax.org/books/university-physics-volume-1/pages/3-2-instantaneous-velocity-and-speed. Ling, Sanny and Moebs, University Physics Volume 1, section 3.2: instantaneous velocity and speed
For a concrete reversal, let for . Its signed velocity is : at it is , at it is zero, and at it is . The opposite endpoint velocities describe opposite directions, although the endpoint speeds agree. The position moves from to and back to .
Recovering displacement from a measured velocity is an integration problem: , with the integral taken component by component. In the reversal example, : the negative and positive contributions cancel. This distinction is useful in navigation, where the final position depends on direction as well as speed.
These are the planar polar coordinates; the general coordinate-system definition and transformations belong to that canonical concept.
Let have degree at most , and let each contain distinct elements. The Alon-Tarsi coefficient formula isIt follows by applying Lagrange interpolation successively in each variable.
Hermite interpolation prescribes values and finitely many derivatives of a polynomial at distinct points.
The degree of a nonzero polynomial is the largest exponent of a monomial with a nonzero coefficient. Thus has degree three, while any nonzero constant polynomial has degree zero. The zero polynomial is treated separately in degree statements.
Over an integral domain, polynomial degrees add under multiplication: for nonzero factors, because the product of their leading coefficients cannot vanish. Under addition, cancellation may lower the degree: . This explains why degree is reliable for counting factors and bounding polynomial roots, but cannot always be inferred from the degrees of summands alone.
Polynomial division separates a polynomial into a multiple of a chosen divisor and a smaller polynomial remainder. Given over a field , with , there are unique polynomials satisfyingHere is the polynomial quotient. The bound concerns polynomial degree, rather than the sizes of the coefficients.[ref]
Fields and Galois Theory by James S. Milne. Fields and Galois Theory, version 5.10, Chapter 1, p. 10, §1.6: division algorithm, zero remainder alternative and uniqueness
For an original example over the rational numbers, takePolynomial long division first cancels by subtracting :Subtracting one more copy of cancels :ThusThe final polynomial remainder has polynomial degree one, below the divisor's polynomial degree two. Multiplying out the last identity checks every coefficient, including the constant term .
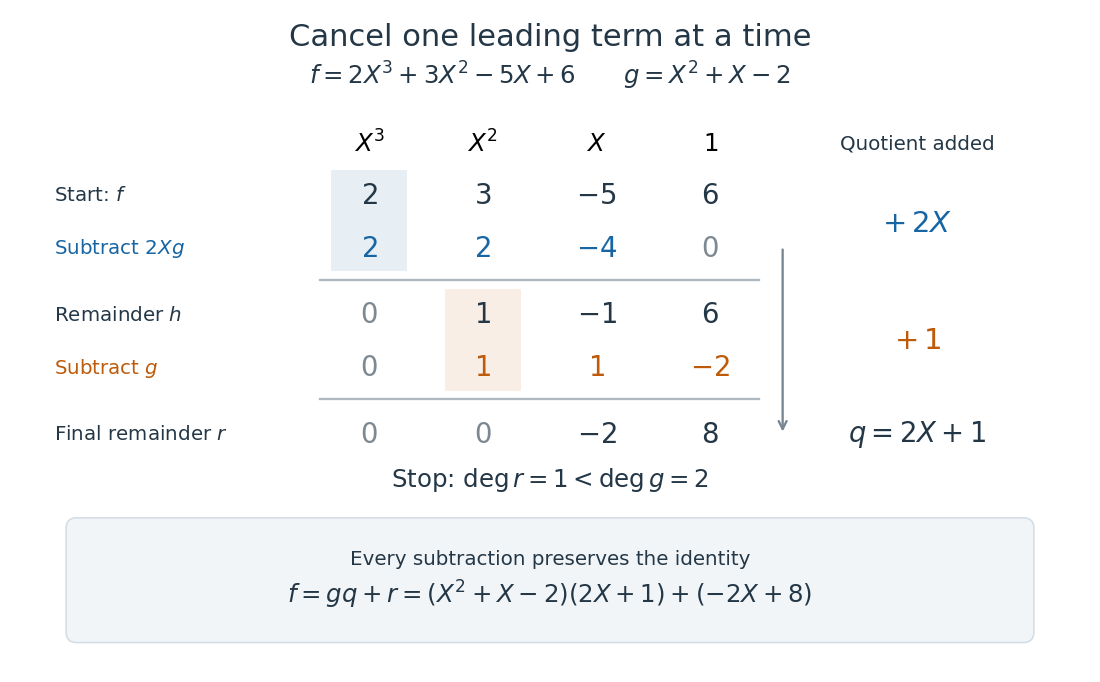

The polynomial degree bound makes this decomposition useful: it replaces a potentially long polynomial with a short polynomial remainder whenever multiples of can be discarded. At any root of a polynomial of , those multiples vanish under polynomial evaluation. Repeated polynomial division also drives the Euclidean algorithm for finding a greatest common divisor of polynomials.
The coefficient setting matters. Over a commutative ring, the same existence and uniqueness hold when the divisor's leading coefficient is a unit in a ring. A monic polynomial therefore works over the integers, even though they do not form a field; monic polynomial division over a ring explains why zero divisors cause no difficulty in that case.[ref]
Chapter 3 Ring theory. Abstract Algebra, Chapter 3 Ring theory, §3.9, Theorem 3.9.1: division with a unit leading coefficient
A nonzero divisor alone is insufficient over the integers. Dividing by with an integer polynomial quotient and a constant polynomial remainder would require for an integer , which is impossible. Over the rational numbers the division instead givesThe obstruction is the nonunit leading coefficient . This example separates existence from uniqueness: over an integral domain, the polynomial degree argument still makes any admissible pair unique, if it exists.
An irreducible polynomial is a nonconstant polynomial that cannot be written as a product of two nonconstant polynomials over its coefficient field. Over a general integral domain, neither factor may be a unit.
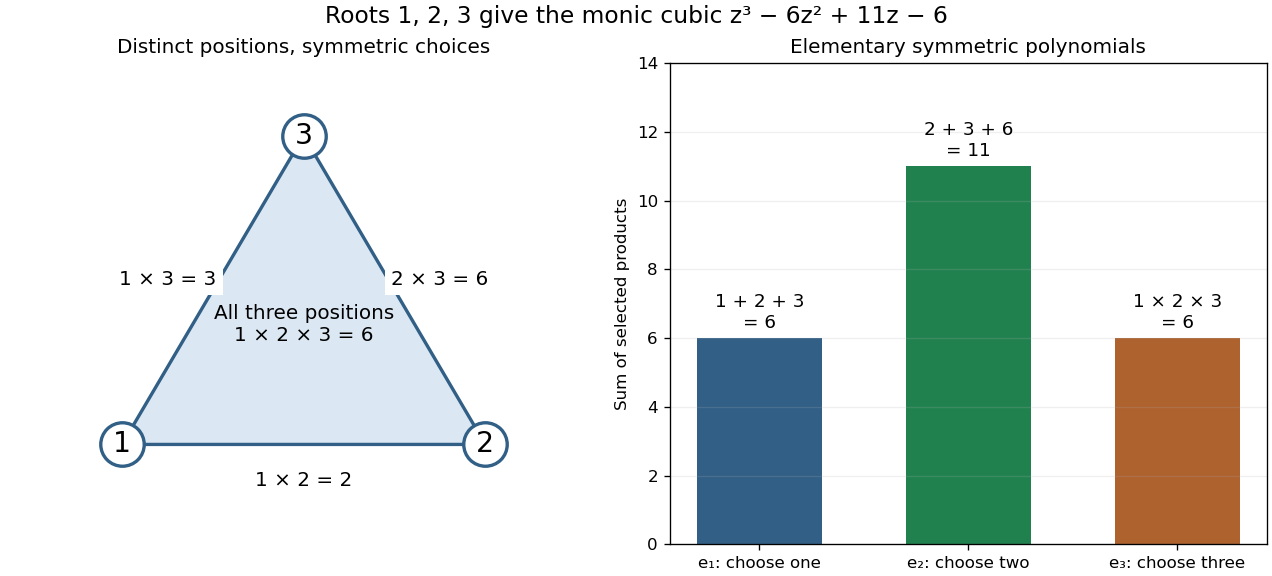
The th elementary symmetric polynomial adds every product obtained by choosing distinct positions from :The conventions are and for . The positions must be distinct, but their values may coincide. Each permutation of the variables merely rearranges the summands, so this is a symmetric polynomial.
For , , , we obtain , , and . Expanding the product givesIn general, . Thus the coefficients of a monic polynomial collect elementary symmetric polynomials of its roots of a polynomial, with alternating signs. These are the Vieta formulas.[ref]

The resultant turns a shared-root of a polynomial question into a calculation using only coefficients. For nonconstant univariate polynomials over a field , with their actual polynomial degrees , definewhere is the Sylvester matrix. ThenHere is an algebraic closure. The common root need not lie in : two real polynomials may share a nonreal complex root. The subscript identifies which variable is eliminated.[ref]
Lecture 6: Resultants and Discriminants. Algebraic Techniques and Semidefinite Optimization, MIT 6.972, Spring 2006; MIT 6.972, Lecture 6, 28 February 2006, pp. 6-1–6-2, Resultants: Sylvester matrix, root product and common-root criterion
The useful surprise is that a determinant detects a shared root of a polynomial without first finding either list of roots of a polynomial. If the coefficients depend on a parameter, the resultant itself is a polynomial in that parameter. Its zeros pick out possible exceptional parameter values. Elimination theory uses this to reduce a pair of polynomial equations in two variables to a single necessary equation in one variable; eliminating a variable with a resultant gives an exact example below.
A nonzero resultant also supplies a certificate that and are coprime polynomials. The Sylvester matrix then solves for polynomials satisfying , a Bézout's identity for polynomials. Evaluating such an identity at a hypothetical common root would give .
A root of a polynomial is a scalar satisfying in the chosen field or ring. For over the real numbers, the distinct roots of a polynomial are and . The second has multiplicity of a root two, so there are three roots when counted with multiplicity.
The domain matters. has no real polynomial root, but has the two complex number roots . The fundamental theorem of algebra guarantees a polynomial root in the complex numbers for every nonconstant complex polynomial, and complete factorization counts its degree of a polynomial many roots with multiplicity of a root. It does not promise that those roots are real or that they have a simple expression.
There are unlisted articles, also show them or only show them.