Represent a time-harmonic wave by , with . The angular frequency is the rate at which the wave phase changes at a fixed position, measured in radians per unit time. The wavenumber is its spatial rate of change, measured in radians per unit length. One full spatial cycle defines the wavelength , and one temporal cycle defines the wave period , soThe ordinary frequency is ; the paper's symbol denotes angular frequency.
A fixed wave phase satisfies a constant. Differentiating gives the phase velocity, called the wave speed here:It is the speed of an individual crest or other fixed-phase point. The group velocity isevaluated on the relevant dispersion relation. To see its meaning, superpose two equal-amplitude waves with nearby :The slowly varying wave envelope moves with speed , tending to as the two components approach one another. Thus group velocity describes a narrow wave packet and, for conservative linear surface gravity waves in still water, their energy transport. A single time-harmonic wave has no distinguished packet envelope. When , the equivalent relation is .
Treat the free surface as the material level set . The kinematic boundary condition , with , givesThis says that fluid initially on the free surface remains on it.
For constant mass density , the Euler momentum equation under gravity is . Since the flow is irrotational, . Integration in space therefore gives the Unsteady Bernoulli equationAt the free surface, and . Adding a function to the velocity potential leaves the velocity field unchanged; choose . With this choice the surface dynamic boundary condition for an inviscid interface becomesThe constant atmospheric pressure has been absorbed into this choice of potential.
Linearize about fluid at rest, with mean free surface and mean bottom . Regard , and the perturbation velocity potential as first-order quantities. A Taylor expansion from to produces products of first-order quantities, as do and . Discarding these second-order terms gives the linearized free-surface boundary conditionsEquivalently, differentiate the second condition in time and substitute the first to obtain at .
The bottom is also impermeable and moving. Its exact kinematic boundary condition follows from :Here , while and the change from evaluating at to evaluating it at are second order. HenceThe interior Laplace equation remains on . This linearization requires small slopes and small resulting excursions as well as ; close to resonance a small prescribed bottom displacement can produce a response too large for it.
Seek the periodic response of a surface gravity wave forced by a traveling bottom, with the same wavenumber and angular frequency as the bottom. The linear equations have constant coefficients in , so they preserve each such harmonic. There is no dissipative phase lag in this model; away from resonance, the surface response is in phase or in opposition with the bottom. Thus write , , with a signed coefficient . Its physical amplitude is . Arbitrary additional free surface gravity waves depend on initial data; the paper's expression selects the forced traveling component.
For , , use . The Laplace equation gives . At , the two linearized free-surface boundary conditions implyThese determine both constants in the vertical solution:Its vertical derivative at the bottom isMatching it to and multiplying by givesand thereforeAn equivalent expression for the velocity potential, which makes the bottom condition immediate, isLet be the forcing angular frequency, and let be the natural dispersion relation from Airy wave theory. ThenThe denominator vanishes at , when the forcing travels at the free-wave phase velocity. For nonzero forcing there is no bounded periodic forced solution at resonance; the undamped linear response develops secular growth. Below that speed , giving a phase reversal, while above it . At the bottom is stationary: the rest solution has and , consistent with the zero limit of , though the formula containing must be interpreted through that limit.
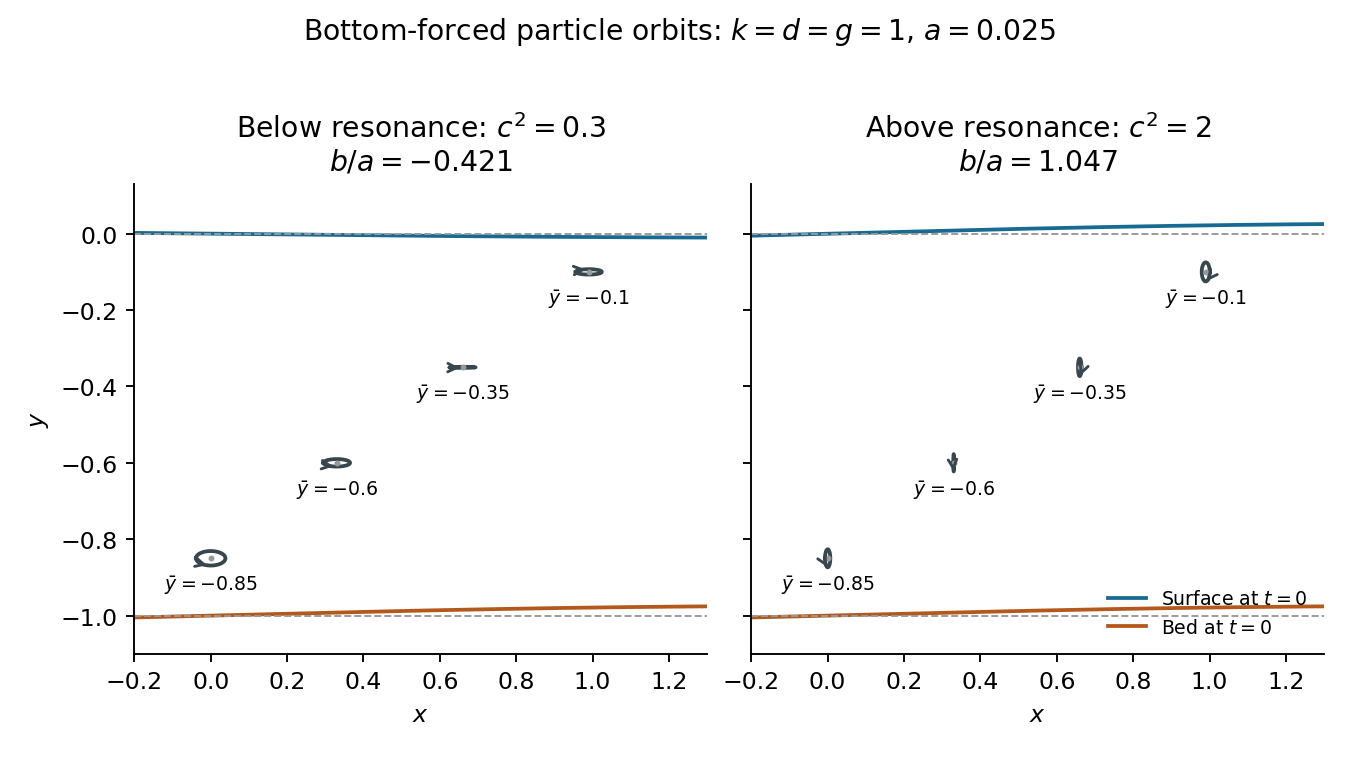
Consider the nonresonant traveling forced solution, with and . Put , , where is the mean position of a fluid element. At linear order, evaluate the velocity field at this mean position: substituting into its spatial arguments would change the already first-order velocity only at second order. With , differentiation of the velocity potential givesSince , integration, with zero mean displacements, yieldsIf both coefficients are nonzero, eliminating the wave phase proves that the pathline is an ellipse:Its principal axes of an ellipse are horizontal and vertical, with respective semi-axesThus the full axis lengths are and . The signed coefficients also determine the direction of traversal. The useful checks and reproduce the vertical displacements of the free surface and bottom.
To identify the major axis without comparing the two expressions separately, use :Consequently the major axis is horizontal if and vertical if ; equality gives circles. If or vanishes at a particular depth, the first-order orbit degenerates to a line segment. These are linearized particle orbits of a bottom-forced gravity wave, not exact closed trajectories at all orders: a higher-order calculation may introduce a mean drift.

Articles by others on the same topic
There are currently no matching articles.