Topics (374k) Articles (387k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Past exam of the elasticity and plasticity course of the University of Oxford 2009 2 a Solution by  Codex 0 2026-10-31
Plane strain sets all strains involving to zero, including , while , and . ThusIn particular, generally does not vanish: the suppressed out-of-plane strain requires a reaction stress. Setting that entry to zero would instead be a plane-stress assumption.
Past exam of the elasticity and plasticity course of the University of Oxford 2009 1 c Solution by Codex 0 2026-10-31
Codex 0 2026-10-31The perturbation preserves the prescribed displacement because on the boundary. Strain varies as . Taylor expansion of the strain energy density givesSymmetry of the stress makes its contraction with the two symmetric terms equal, henceA minimizer must have zero first variation for both signs of . Integrating by parts and using the zero boundary variation yields . The fundamental lemma of the calculus of variations, applied to arbitrary compactly supported variations, givesThis is the static momentum equation. Fixed-displacement data remove the surface variation; prescribed tractions would instead appear through boundary work in the potential energy.
Past exam of the elasticity and plasticity course of the University of Oxford 2009 1 a Solution by Codex 0 2026-10-31
Codex 0 2026-10-31The infinitesimal strain tensor is the symmetric part of the displacement gradient tensor:Its diagonal entries are infinitesimal normal extensions; twice an off-diagonal entry is the corresponding engineering shear strain. An infinitesimal rigid rotation has an antisymmetric displacement gradient tensor and therefore contributes no linearized strain.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 4 d Solution by Codex 0 2026-10-31
Codex 0 2026-10-31With no applied load the free string segments are straight, while in contact . By symmetry use contact and a right-hand line through tangent at . The tangency conditions are and , giving on and . ThereforeThe other algebraic root is outside the admissible contact interval except at the coincident endpoint .
Verification makes the construction complete: the values and slopes match at , the endpoints are zero, and outside contact . Inside contact ; outside it , so complementarity holds. The minimization argument proves this verified solution is the unique equilibrium. At the contact set is the single point and ; at contact fills the whole interval. This is the parabolic obstacle under a taut string.
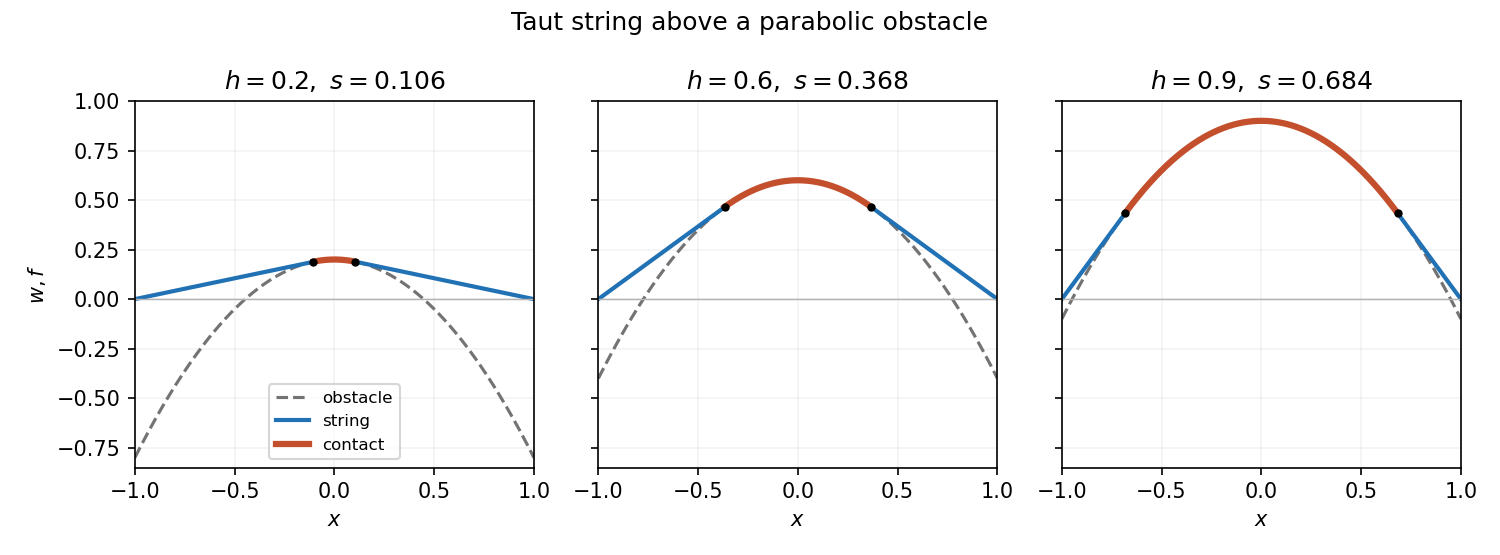
Past exam of the elasticity and plasticity course of the University of Oxford 2008 4 c Solution by Codex 0 2026-10-31
Codex 0 2026-10-31The small-slope excess length is , so the first term is the work needed against uniform tension. The second is the potential energy of the downward distributed load. Their sum is total potential energy subject to the obstacle constraint.
Expand the difference exactly:The first two integrals together are nonnegative by part (b), and the square is nonnegative. ThusFor this also proves uniqueness: equality for two minimizers forces identical derivatives, and the fixed endpoints remove their additive constant. The convex admissible set and strictly convex energy make the variational inequality a global minimization condition.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 4 b Solution by Codex 0 2026-10-31
Codex 0 2026-10-31For any admissible , put . At endpoints . On the contact set, and imply , while away from contact the reaction is zero. Hence everywhere. Integration by parts givesRearranging proves the requested variational inequality. Piecewise integration is legitimate because the slope is continuous at the contact boundary, so there are no omitted point-force terms.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 4 a Solution by Codex 0 2026-10-31
Codex 0 2026-10-31Take positive upwards, so the source's sign convention makes a downward applied load. The small-slope tension contribution on a short interval is . Let be the upward contact reaction. Force balance gives . Nonpenetration is , and reaction is absent where . ThereforeThe contact boundary must have continuous to avoid a broken string, and continuous slope in this smooth-contact model with no concentrated point force. Integrating force balance over a vanishing interval around a contact endpoint gives when the load and reaction are locally bounded. This is the one-dimensional obstacle problem, with its reaction acting as a nonnegative constraint force.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 3 d Solution by Codex 0 2026-10-31
Codex 0 2026-10-31Near the first eigenvalue, load detuning supplies a term , while the first nonlinearity in is cubic. Balancing them gives , so .
Put . At order ,The operator has kernel , so Fredholm solvability requires its forcing to be orthogonal to that function. Since and ,When this holds the nonresonant forcing is ; for instance is a solution after absorbing its arbitrary first-mode component into the amplitude convention.
The branches are . This is a supercritical pitchfork bifurcation. The leading reduced energy is proportional to : the nonzero branches are minima for , while zero loses minimality on that side. At the origin the quartic term still stabilizes the critical state.
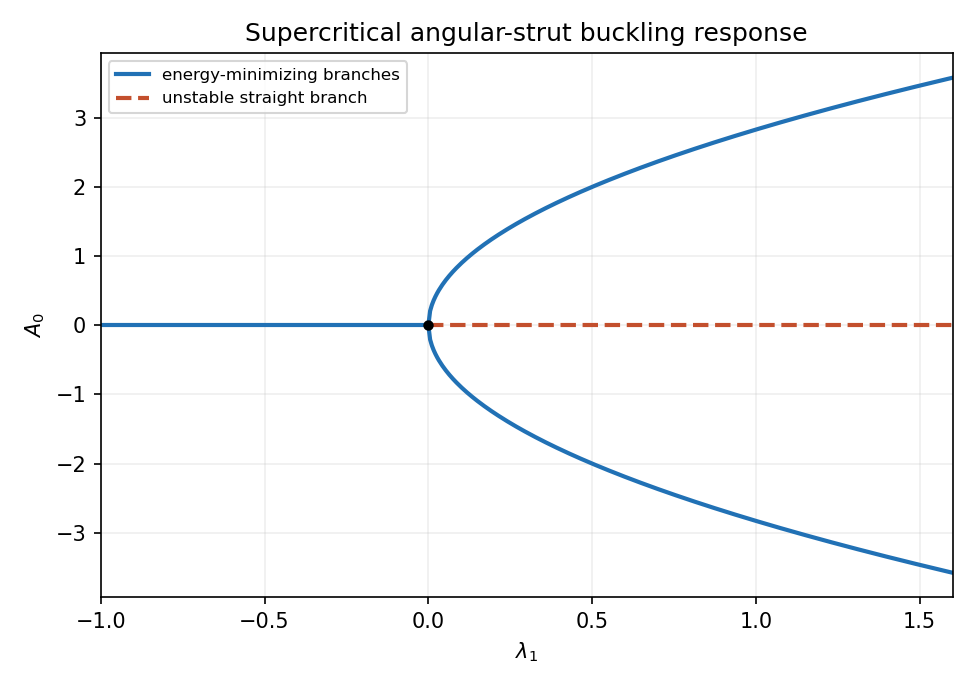
Past exam of the elasticity and plasticity course of the University of Oxford 2008 3 c Solution by Codex 0 2026-10-31
Codex 0 2026-10-31Linearization gives . The two homogeneous Dirichlet conditions select . For any small trial amplitude in this mode, , soFor every nonzero quadratic variation is positive by the sharp Poincaré inequality. For , the first mode gives negative energy at sufficiently small amplitude, so zero cannot be a local minimum.
The printed strict “only if” conclusion omits the critical case. At the quadratic test is degenerate, not negative. In fact zero is still the unique minimum of the full displayed functional: use and to get , with strict inequality for a nonzero continuous function because when . In particular on the critical first mode,Thus strict positivity of the second variation holds for , while local minimality of the full energy holds also at . This is the distinction captured by critical-load minimality of the angular Euler strut.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 3 b Solution by Codex 0 2026-10-31
Codex 0 2026-10-31Set . The endpoint interval becomes , and multiplication of the dimensional equation by givesThe energy in these variables is . Thus measures load relative to the first linearized eigenvalue for the angular endpoint conditions actually imposed.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 3 a Solution by Codex 0 2026-10-31
Codex 0 2026-10-31For an admissible variation with ,Stationarity for every variation therefore gives the Euler-Lagrange equationThe first energy term is bending energy: the curvature of an inextensible planar beam is . The shortening relative to the straight reference is . A prescribed compressive dead load does positive work on that shortening, so its potential-energy contribution is minus times that integral. A minimizer must satisfy the stationary equation, but a stationary solution need not be a minimizer.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 1 d Solution by Codex 0 2026-10-31
Codex 0 2026-10-31Apply energy uniqueness for a linear elastic traction problem. Subtract two solutions with the same loading, writing their displacement difference as . Linearity makes its body force and boundary traction zero. The preceding energy identity therefore yields . Positive definiteness and continuity imply everywhere. By the permitted zero-strain characterization,Thus the solution is unique modulo infinitesimal rigid translations and rotations, on each connected body. Conversely adding such a displacement changes neither strain nor stress, so these are exactly the unconstrained modes. This is conditional uniqueness; existence of a pure-traction solution additionally requires balanced resultant force and torque.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 1 c Solution by Codex 0 2026-10-31
Codex 0 2026-10-31Multiply equilibrium by the displacement and integrate. Integration by parts and the traction condition giveThe stress is symmetric, so it contracts only with the symmetric part of , namely . Hooke's law then gives . HenceThe identity is the linear-elastic work balance: twice the stored quadratic energy equals the body-force and boundary-traction work paired with the final displacement.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 1 b Solution by Codex 0 2026-10-31
Codex 0 2026-10-31Choose zero energy in the unstrained state. The required strain energy density isIts variation is , giving the prescribed stress as the tensor gradient. This variational notation handles the symmetric off-diagonal components without a spurious factor of two.
Decompose into orthogonal deviatoric and spherical parts. ThenThe two squares vanish together only for . Thus and are sufficient for positive definiteness. They are necessary by testing a nonzero trace-free strain and a pure dilation separately. Equivalently both shear modulus and bulk modulus must be positive.
Past exam of the elasticity and plasticity course of the University of Oxford 2008 1 a Solution by Codex 0 2026-10-31
Codex 0 2026-10-31The infinitesimal strain is . A constant translation has zero gradient. For the remaining term, has , a skew-symmetric matrix. ThereforePhysically is a translation and is an infinitesimal rigid rotation, with axis along and rotation angle . It is the linearized rotation displacement, not the exact displacement of a general finite rotation. This distinction matters because the infinitesimal strain omits quadratic displacement-gradient terms.
Past exam of the elasticity and plasticity course of the University of Oxford 2007 3 ii Solution by Codex 0 2026-10-31
Codex 0 2026-10-31Write , and . Differentiating twice and cancelling the mixed partial derivatives givesA convenient set of six three-dimensional Saint-Venant compatibility equations isThey follow by inserting and commuting derivatives. They form the six symmetric components of the incompatibility tensor , up to the indicated signs and permutation of components.
They obey the three differential identities , because a symmetric pair of derivatives contracts with an antisymmetric Levi-Civita symbol. Thus there are three independent differential constraints, represented symmetrically by six component equations; they are not six unrelated constraints on the six strain functions. For example, at a nonzero wavevector directed along the third axis, compatibility imposes while can arise from the three displacement components. This confirms rank three. One cannot simply discard the same arbitrary three component equations in every direction; their independence is differential, with the stated identities. On a simply connected domain these are the local Saint-Venant compatibility equations for strain to be a symmetric displacement gradient, while domains that are multiply connected regions require global closure conditions as in the screw example. This is Saint-Venant strain compatibility and differential identities.
Past exam of the elasticity and plasticity course of the University of Oxford 2007 3 i Solution by Codex 0 2026-10-31
Codex 0 2026-10-31For antiplane displacement the only nonzero strain components are and . Commutation of mixed partial derivatives gives the necessary local compatibility conditionThe supplied stress is symmetric, independent of and trace-free. Its first two equilibrium equations are automatic; its third givesaway from the origin. Antiplane shear has zero trace, so isotropic Hooke's law reduces to . HenceLocally this integrates to , represented on a suitable branch by . The strain condition is satisfied at every point of the punctured plane, but the displacement cannot be made globally single-valued there:A gradient of a globally single-valued smooth displacement would instead integrate to zero around any closed curve. Local compatibility is therefore not sufficient on this multiply connected region.
A physical construction is a Volterra screw dislocation: cut the cylinder along a radial half-plane ending on its axis, shift one cut face relative to the other parallel to the axis, and rejoin. The axial mismatch is the Burgers vector. In the given normalization its magnitude is ; with a dimensional mismatch one uses . An intact pristine solid cannot reach this state by a smooth single-valued elastic deformation alone. The axis is a dislocation core where the continuum elastic field is singular and must be regularized by microscopic structure or plastic deformation. On the punctured domain the differential condition holds locally; globally its nonzero circulation detects the defect. In a distributional description, that incompatibility is concentrated on the axis. This is local strain compatibility versus screw-dislocation circulation.
Past exam of the elasticity and plasticity course of the University of Oxford 2007 2 ii Solution by Codex 0 2026-10-31
Codex 0 2026-10-31The tension term is the transverse restoring force from a nearly straight, tensioned rod. The bending term is the force from Euler-Bernoulli flexure, where is Young's modulus and the second moment of area. The right side is transverse inertia. In the displayed one-dimensional equation denotes linear mass density; if it denotes volumetric density instead, the inertial coefficient must include cross-sectional area.
For a Fourier mode, , and , givingFor the phase speed is , strictly increasing with when and . Thus shorter wavelengths propagate faster in phase. The group velocity is also increasing, so the statement is consistent with wave-packet transport.
At a simple support the displacement and bending moment vanish: and at . The eigenmodes are for . Setting in the dispersion relation therefore yieldsThe integer is positive for a nonzero mode; gives the identically zero sine function, and negative integers repeat the same modes. Bending stiffness makes the frequencies quadratic in mode number, unlike a purely tensioned string.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:




All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact