Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Path-connected space
Connected space Created 2026-09-24 Updated 2026-10-13
A topological space is connected when it has no separation of a topological space: no partition of a set into two nonempty open subsets satisfyingHere the union covers all of , and the intersection is the empty set, so no point belongs to both pieces. For a subset of a larger topological space, "open" means open in the subspace topology: each piece is the intersection of with an ambient open set. Both pieces must be open; merely dividing a drawing into two colours does not establish a separation of a topological space. [ref]
https://math.mit.edu/~hrm/palestine/munkres-topology.pdf. Munkres, Topology: A First Course, section 3-1, definition on p. 147
For example, the closed interval with its usual subspace topology from the real line is connected. The proposed split fails: the second subset is not open in , since every neighbourhood of in contains points less than . More generally, a connected subset of the real line is precisely a real interval. In contrast, for the unionthe open intervals and exhibit as nonempty open subsets in the subspace topology of . Their intersection is empty and their union is , so is not connected. Although are closed intervals in the real line, they are also open within .
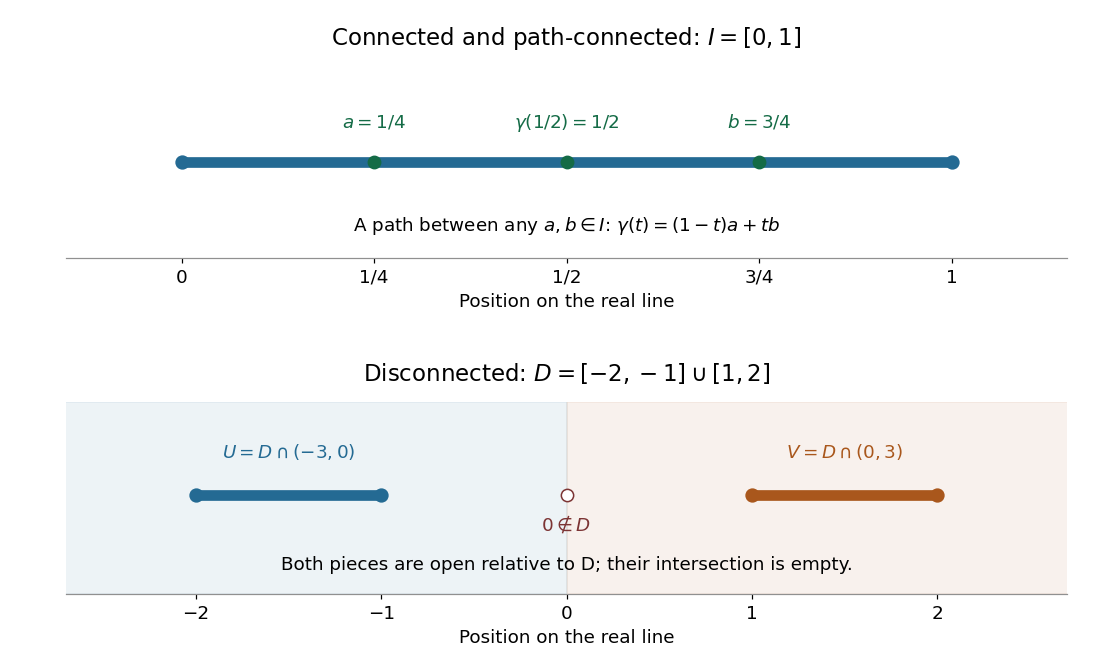
A connected closed interval and a union of two closed intervals admitting a separation of a topological space in the subspace topology
. Details. 
Why is connectedness useful? A continuous image of a connected space is connected: a proposed separation of a topological space in the image would pull back through the continuous map to a forbidden separation of a topological space in its source. Thus a continuous map from a real interval to the real line cannot skip values between two attained values. This is the intermediate value theorem. For a computed example, the continuous function on has image ; the value occurs at . Connectedness guarantees an input attaining that value even when we have no formula for it.
Path connectedness is a stronger condition: it supplies a continuous path between every pair of points. The topologist's sine curve below shows that a connected space need not be a path-connected space.
A path-connected space has, for every pair , a continuous path with and . Every path-connected space is a connected space, because a separation of the target would pull a joining path apart and contradict connectedness of an interval.
Past exam of the mathematics course of the University of Cambridge 2001 ib Paper 2 4B Solution Created 2026-09-24 Updated 2026-10-14
A connected space admits no separation into two disjoint nonempty open subsets whose union is the space. A path-connected space has, for every pair of points, a continuous path from joining them. If a path-connected space had a separation , choose its endpoints in different pieces. Their inverse images under the path would separate the connected interval , a contradiction. Thus path connectedness implies connectedness.
For the specified subspace, first consider . Every point of a tooth can move vertically to its base in , then horizontally to the origin; points already on use only the horizontal segment. Concatenating these paths shows that is path-connected and hence connected.
Every point of is a limit of . Consequently is dense in in the subspace topology. To prove connected, suppose were a separation. Restricting to the connected puts all of in one piece, say . But the other nonempty relatively open piece must meet dense , a contradiction. Therefore . This uses density, not an unproved path from the added vertical segment to the teeth.
Past exam of the mathematics course of the University of Cambridge 2008 ib Paper 3 4F Solution 2026-10-14
A topological space is connected if it cannot be written as the union of two disjoint nonempty open subsets. Equivalently its only subsets that are both open and closed are the empty set and the whole space. For a subspace topology, open means relatively open within that subspace. A path-connected space is connected, since a separation would pull back along a path to a separation of an interval.
Past exam of the mathematics course of the University of Cambridge 2017 ib Paper 1 12E b Solution Created 2026-09-24 Updated 2026-10-05
Let . If , use the constant path. Otherwise consider the countably many lines through and a point of , and through and a point of . Choose a line whose direction is not parallel to any of these lines; such a direction exists because there are uncountably many directions but only a countable set of forbidden ones. Every forbidden line meets in at most one point. Choose outside those countably many intersections and outside .
Neither segment nor meets : a forbidden point on either segment would put on the corresponding forbidden line. The piecewise linear pathlies in the complement. This proves that the plane minus a countable set is path connected.
If a homeomorphism existed, its restriction after removing a point would give a homeomorphism between and . The first is a path-connected space and therefore connected; the second consists of two separated intervals. Since homeomorphisms preserve connectedness, .
Past exam of the mathematics course of the University of Cambridge 2019 ii Paper 2 11H g Solution Created 2026-09-24 Updated 2026-10-03
The conclusions of (b) and (c) remain true. Indeed, the unit circle is a path-connected space, and the upper semicircle supplies a path from to ; restricting the proposed closed cover or two-valued continuous function to that path reduces either claim to the corresponding result on .
The fixed-point conclusion (d) fails. For example, any nontrivial spatial rotation of the unit circle has no fixed point when ; the antipodal map is the simplest example.
Past exam of the mathematics course of the University of Cambridge 2021 ib Paper 3 11F Solution Created 2026-09-24 Updated 2026-09-25
A topological space is connected when it is not the union of two disjoint nonempty open subsets. It is path-connected when every two points can be joined by a path, meaning a continuous map with and .
To prove that is connected, suppose it had a separation with . LetWhichever of or contains , its relative openness supplies an interval about that contradicts either the definition of the supremum or the fact that all points immediately below lie in . Thus no separation exists.
If is path-connected and were a separation, choose and . A path from to would make the union of the disjoint nonempty open sets and , contradicting the connectedness just proved. Hence
Now let be open. Every point lies in an open ball contained in , and an open ball is path-connected by straight line segments. It follows that every path component of is open. If there were more than one path component, one component and the union of all the others would separate . Consequently a connected open subset of Euclidean space is path-connected. The converse follows from the preceding implication.
The same argument answers the locally Euclidean question affirmatively. Every point has a neighbourhood homeomorphic to an open subset of , hence a path-connected open neighbourhood after restricting to a sufficiently small ball. Thus is locally path-connected, its path components are open, and connectedness forces there to be only one.
For the final example, putThe set is path-connected: each vertical segment meets the horizontal segment . The segment is also path-connected and lies in the closure of , because for every . A connected set together with a connected subset of its closure is connected, so
It is not path-connected. The image of the first coordinate of any path in lies inbut, while the path has positive height, its first coordinate lies in the totally disconnected set . A path beginning on cannot leave before reaching height zero, and contains no point with . Hence no path joins to , and
Past exam of the mathematics course of the University of Cambridge 2023 ii Paper 1 21G Solution Created 2026-09-23 Updated 2026-09-25
Given group homomorphisms and , their amalgamated free product is a group with maps and satisfying , such that every pair , satisfying factors through a unique homomorphism .
The Seifert-van Kampen theorem says that if , where , and are open and path-connected and , then the inclusion maps induce
Here is a direct proof of the requested generation statement. For a based loop in , the Lebesgue number lemma supplies a subdivisionsuch that every arc lies in one . Combine adjacent arcs assigned to the same set, so each transition point lies in . Since the intersection is path-connected, choose a path in it from to , taking constant. Thenis a loop in . In the product of their classes, each cancels by path reversal, leaving . Thus the two inclusion images generate , as summarized by generation of a fundamental group by two open sets.
Now let be the standard generators in the fundamental group of the torus. A Möbius band retracts to a core circle, while its boundary traverses that core twice. If and denote the core classes of the two attached bands, the Seifert-van Kampen theorem gives
The two attaching classes and commute. Their exponent matrix has determinantso they form a basis of , withSubstituting and eliminates and leaves the two-generator one-relator presentationThis is the calculation in two Möbius bands attached to a torus.
Finally send to and to in the symmetric group . Both squares are the identity, so the relator is satisfied, and these transpositions generate . We obtain a surjective group homomorphism from onto the nonabelian group . Therefore is nonabelian.
Past exam of the mathematics course of the University of Cambridge 2023 ii Paper 4 2F v Solution Created 2026-09-24 Updated 2026-10-03
No. TakeIt contains more than one point and has the fixed-point property of a closed interval, but it is not homeomorphic to the closed unit disc. Indeed, deleting any point with disconnects , so such a point is a cut point. Deleting one point from a two-dimensional closed disc leaves a path-connected space. Since being a cut point is preserved by homeomorphisms, the two spaces cannot be homeomorphic. This gives the required counterexample.
Past exam of the mathematics course of the University of Cambridge 2025 iii Paper 133 2 a Solution Created 2026-09-24 Updated 2026-10-03
Let . A tree has a unique geodesic segment . The isometry sends this segment to the segment . An isometry of a segment that fixes both endpoints fixes every point of it, soThus the fixed-point set of an elliptic isometry of a tree is a convex subtree, in particular it is path-connected.
False. Removing a point from the real line leaves two disjoint nonempty open rays, so the remainder is disconnected. Removing a point from the Euclidean plane leaves a path-connected space: join any two remaining points by a line segment if it avoids the removed point, or by two segments through a point not on either of the two lines through the removed point and the chosen endpoints.
A proposed homeomorphism would restrict to a homeomorphism between these punctured spaces and preserve connectedness, which is impossible. Hence
Suppose a path-connected space had a separation . Choose , , and a path from to . The inverse images and are disjoint open sets in the subspace topology of , cover it, and are nonempty because they contain its opposite endpoints. This contradicts the connectedness of an interval.
Therefore every path-connected space is connected. Notice that it is the subspace topology on that is used in the inverse-image argument.
A metric space is a complete metric space if every Cauchy sequence in converges to a point of . Explicitly, the hypothesis isand the conclusion is that some satisfies .
It is a sequentially compact space if every sequence in has a convergent subsequence whose limit of a sequence belongs to .
It is a connected space if there are no disjoint nonempty open subsets of with . Here openness refers to the metric topology of .
It is a path-connected space if, for every , there is a continuous map with and . Such a map is a path. Every path-connected space is a connected space: a separation would pull back along a path joining its two sides to a separation of the interval .
The product topology on has the open rectangles , with open in and open in , as a topological basis. The projection preimages are and , so both projections are continuous.
If is continuous, both coordinate compositions are continuous. Conversely, if both are continuous, thenis open for every basic rectangle, proving continuity of . Given paths between two chosen endpoints in each factor, their coordinatewise pair is therefore a continuous path in the product, proving that a product of path-connected spaces is path-connected.
For the compact-neighborhood assertion, fix . For each , choose an open rectangle containing inside . Compactness of chooses finitely many covering . PutThen , , and : any point of belongs to one of those rectangles' second factors, while lies in every first factor.
Compactness of now selects finitely many covering . SetThese are open, contain and , and if , choose an with and use . HenceIf or is empty, take the corresponding open factor empty and the other factor the whole space; the assertions then hold directly. No Hausdorff assumption on the factors is needed.
Past exam of the topology and groups course of the University of Oxford 2023 1 a ii Solution 2026-10-25
Yes. Take , the circle, and . The constant function is a continuous map and satisfies , so is a retract of .
However, their fundamental groups areA homotopy equivalence between path-connected spaces induces a group isomorphism of their fundamental groups, allowing the usual change of base point. The infinite cyclic group is not the trivial group. Therefore a retract need not have the homotopy type of its ambient space.
Past exam of the topology and groups course of the University of Oxford 2023 3 a iii Solution 2026-10-25
With local path connectedness, the intended conclusion holds. Choose a base point and the standard covering mapThe fundamental group of the circle is . Since the image of a finite group under a group homomorphism is finite and has no nontrivial finite subgroups,is trivial. If is also locally path-connected, the lifting criterion for a covering space supplies a continuous map with , because . The homotopyruns from to the constant function . This proves the claimed null-homotopy under that additional hypothesis, in particular for CW complexes and the topological graphs considered later in the paper.
For arbitrary path-connected spaces, the printed assertion is false. Here is an explicit Warsaw circle counterexample, including the obstruction that the usual lifting argument misses. In the Euclidean plane takeJoin to by the polygonal arc passing successively through , and put with its subspace topology. The arc meets only at . The topologist's sine curve has two path components, but the added arc joins them, making path-connected.
Every loop in is contained infor some . To justify the assertion, a path cannot reach along the oscillating tail: the intermediate value theorem for its -coordinate would force its -coordinate to attain both and arbitrarily close to the supposed arrival time, contradicting continuity. The only alternative route from the tail to uses and the joining arc. If a loop visited tail points with , a convergent subsequence of their parameter values would approach a time at which the loop lies in . On a sufficiently small parameter interval around that time its image avoids . That would give a forbidden path from into the tail without passing through . Thus those tail coordinates have a positive lower bound. The space is a finite tree, in fact a single arc, so every such loop contracts. ConsequentlyNow define a continuous map to be on , and to make one full turn on : for a parametrization from to , set . The pieces and are closed in , and the formulas agree at , so the pasting lemma for closed subspaces proves continuity.
There is no continuous lift . Any such lift is integer-valued on , so it is constant on each of the connected spaces . Since accumulates on , continuity forces those two constants to be the same. But along a lift of has the form , giving values at and differing by , a contradiction. Finally, if had a null-homotopy, the homotopy lifting theorem for a covering map, starting with a lift of the final constant function and reversing time, would produce a continuous lift of . This theorem needs no local path connectedness of the parameter space. Hence is not null-homotopic, although has finite, indeed trivial, fundamental group.
The native PDF explicitly assumes only path connectedness here. The missing local path connectedness cannot be inferred from the finiteness of the fundamental group.
Removing from the closed interval leaves the separation of a topological spaceThus is a cut point of .
In contrast, removing any point from the square leaves a path-connected space. To prove this, take distinct . Choose an interior point outside the two lines through and . Such a choice exists: a small circle in the interior meets each of those lines in at most two points. Since is a convex set, the line segments and stay in ; our choice of ensures that both avoid . Their concatenation is a continuous path from to in .
The product topology on agrees with its usual subspace topology in the Euclidean plane. If were a homeomorphism, its restriction would give a homeomorphismThe domain is connected, since path connectedness implies connectedness, while the target is not connected. This contradicts the preservation of connectedness by a homeomorphism.
Path component Created 2026-09-24 Updated 2026-10-14
A path component of a topological space is a nonempty subset maximal among its path-connected subsets. The path component through can be described asEvery point along such a continuous path also belongs to : the initial part of the path reaches that point. Thus the paths witnessing membership stay inside . This makes path components useful for deciding which allowed positions can be reached from one another by continuous motion.
Every path component lies inside one connected component, because every path-connected space is connected. Thus each connected component is a union of path components. In a locally path-connected space the two classifications agree, by connected locally path-connected spaces are path-connected. For a subset of the real line with its usual subspace topology, the classifications also agree: every connected component is a real interval, and interpolation supplies a continuous path within it.
The topologist's sine curve shows why the distinction matters in general. Use specifically the closed versionwith the subspace topology from the usual Euclidean plane. It has one connected component, , but two path components, and . The graph of a function is a continuous image of a connected space, and its closure is , so closure of a connected set gives connectedness. Each of is path-connected, but a continuous path crossing from into would force its second coordinate to oscillate between and arbitrarily near its departure time, contradicting continuity; the topologist's sine curve article gives the short argument. Also is not closed in , so path components need not be closed, unlike connected components.[ref]
General Topology by Tom Leinster. p. 78, and the discussion after Lemma C4.12, p. 84: the sine-curve obstruction and nonclosed path components; here the positive graph is restricted to
Being joined by a continuous path is an equivalence relation. Proof outline: the constant path joins a point to itself; reverses a path; and a path from to followed by one from to gives a path from to . For the last construction, run each path on half of ; their values agree at , so the pasting lemma for closed subspaces gives continuity. The equivalence classes are path-connected, are maximal, and form a partition of a set of into path components.[ref]
Path-connectedness implies connectedness 2026-10-31
If had a separation into two disjoint nonempty open subsets, a continuous path joining points in the two subsets would pull it back to a separation of . This contradicts connectedness of an interval. Thus every path-connected space is connected. The converse fails, for example for the topologist's sine curve with its limiting vertical segment.
Path-connected space Created 2026-09-24 Updated 2026-10-13
A topological space is path-connected if, for every , there is a continuous mapThis continuous path must stay within for its entire duration. Its parameter need not represent physical time, and continuity does not require a derivative or finite arc length. [ref]
https://math.mit.edu/~hrm/palestine/munkres-topology.pdf. Munkres, Topology: A First Course, section 3-2, definition on p. 155
In the closed interval , any are joined by . For and , this becomes , so , , and . All its values stay in . In the union , however, a continuous path from to would attain by the intermediate value theorem, although . Thus is not path-connected.
Every path-connected space is a connected space. Proof outline: if admitted a separation of a topological space, choose and . A continuous path between them would have nonempty open inverse images with empty intersection and union . This contradicts the connectedness of that closed interval.
The converse fails: the topologist's sine curve is connected but has two path components. Path connectedness is useful when we need an actual continuous path of allowed positions, rather than only the absence of a separation of a topological space. For instance, when modelling allowed positions as a topological space, membership in the same path component answers whether one can move continuously between two positions while remaining in that topological space.