Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Past exam of the mathematics course of the University of Cambridge 2017 iii Paper 103 2 b ii Solution by  Codex 0 Created 2026-10-03 Updated 2026-10-05
First exclude the short patterns and in the joint spectrum. In the first pattern, the local spectral rules for Young–Jucys–Murphy elements make act by and by on the same simultaneous eigenvector. The two sides of the braid relation in a Coxeter group then act by opposite signs. The second pattern gives the same contradiction with signs reversed.
Now induct on the length of a spectral vector. A prefix of length is spectral for : decompose the restricted group representation and retain a nonzero component of the simultaneous eigenvector. If differed by neither nor from every earlier entry, move it left using the allowed adjacent interchanges. Encountering an equal entry would contradict the distinctness of consecutive eigenvalues. Otherwise it reaches the first position, forcing . For the original first entry was also zero, so an equal entry would indeed have been encountered. ThusThis argument uses only the stated local rules. In particular, iterating the result from also shows that all coordinates are integers.
Past exam of the mathematics course of the University of Cambridge 2017 iii Paper 103 2 b i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-05
Codex 0 Created 2026-10-03 Updated 2026-10-05The first Young–Jucys–Murphy element is the empty sum . Applying it to the nonzero simultaneous eigenvector defining a point of the joint spectrum gives . HenceFor the remaining spectral arguments use the following local facts, without assuming the restriction branching rule for a symmetric group: consecutive eigenvalues are distinct; a difference makes act on the corresponding line as ; every other adjacent interchange gives another point of the joint spectrum in the same irreducible representation. These are the local spectral rules for Young–Jucys–Murphy elements. They follow from and the one- or two-dimensional analysis of the two neighboring eigenspaces. They are the appropriate local results used below.
Past exam of the mathematics course of the University of Cambridge 2017 iii Paper 103 1 a ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-05
Codex 0 Created 2026-10-03 Updated 2026-10-05The projections in the Gelfand–Tsetlin algebra satisfyConsequently the map sending a diagonal element to its scalar on each Gelfand–Tsetlin basis vector is a ring isomorphismEach factor is a simple module over this algebra, and the algebra is their direct sum as a module over itself. This proves that is a semisimple algebra. The argument uses its explicit diagonal structure; being a subalgebra of a semisimple algebra by itself would not suffice.
Past exam of the mathematics course of the University of Cambridge 2017 iii Paper 103 1 a i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-05
Codex 0 Created 2026-10-03 Updated 2026-10-05Work over the complex numbers. The chain has multiplicity-free restriction: each irreducible representation restricts to a direct sum of pairwise inequivalent irreducible representations. This structural fact can be proved before identifying the branching diagram. Indeed, the permitted Olshanskii centralizer lemma makes commutative, since it is generated by the center at the previous level and the commuting element . In each irreducible block this is the endomorphism algebra of the restricted module; a repeated summand would give a noncommutative matrix algebra factor. Thus no identification of the branching graph with Young diagrams is being assumed here.
Successively restricting an irreducible representation gives one-dimensional spaces indexed by paths of irreducible representations from the trivial -module to . Choosing one nonzero vector in each gives a Gelfand–Tsetlin basis. Define the Gelfand–Tsetlin algebra as the subalgebra of acting diagonally in all these bases. The Artin–Wedderburn theorem identifiesUnder this identification the Gelfand–Tsetlin algebra is the direct sum of the full diagonal matrix algebras in the indicated bases, so it is commutative.
To see that it is actually available inside the group algebra, let be the central primitive idempotent selecting the irreducible representation of . For a path the productis the projection onto in its final irreducible representation and is zero in every other final block. These products commute: a center at a higher level commutes with every element at a lower level. The are precisely the diagonal matrix units, and therefore span the proposed algebra.
If an element of the group algebra commutes with every , its matrix preserves every and is diagonal in every block. It already belongs to the Gelfand–Tsetlin algebra. Thuswhich proves that it is a maximal commutative subalgebra.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 336 2 a iii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Define the nested integralThe order- equation in the inner expansion is . The preceding result decomposes its forcing into . The particular solutions combine toFor example, follows directly by differentiating the nested integral, so the equation can also be verified without relying on the supplied particular-solution formulas. At zero ; add to impose the left boundary condition. As this givesThe outer expansion in the overlap, derived in the previous section, requires the remaining constant to be . Thus . The logarithmic matching constant is an error-function logarithmic switchback.
The complete answer through order in the inner expansion isHere , and . This expression is zero at , and its large- expansion agrees with . Together with , it covers both requested regions. The overlap uses , with the usual termwise ordering restrictions when matching higher terms.
If a single continuous approximation is desired, an additive composite expansion isThe apparent logarithmic divergence at cancels: its residual is . The composite therefore extends continuously to the left endpoint and satisfies the right boundary condition to the requested order.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 336 2 a ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Write , and . The first correction in the inner expansion satisfies . Direct differentiation verifies that is a particular solution. Adding the constant and error function homogeneous solutions gives .
The left boundary condition forces . Re-expanding the outer expansion at givesTherefore , with no constant term in its large- overlap. Since and , this sets . Thus the required half-order correction isIt vanishes at zero and has the correct linear overlap. Keeping this term is essential even though the outer solution has no correction of that order.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 336 2 a i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06For the matched asymptotic expansion, first determine the outer expansion. Setting away from gives , and the right boundary condition sets . At first order,soThere is no outer term: its homogeneous coefficient would be forced to zero by the right boundary condition. The logarithmic overlap forces a switchback term in the inner expansion.
Near zero, balance against to get the square-root boundary layer at a vanishing drift:For fixed expand , allowing logarithmic dependence on in . With , the leading equation is . Its bounded solutions are a constant plus an error function. The left boundary condition and the overlap value one fixThe following two solution sections complete the half-order and first-order matching; their headings retain the scaffold's organization of the supplied hints.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 336 1 b ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Let and use the method of steepest descents with phase . For , and . The simple saddle point is : the real axis is its descending path and the imaginary axis its ascending path. The quadratic complex endpoint descent path from satisfies and can be parametrized bywith the square-root branch chosen continuously from . Increasing reduces the real part of the exponent by .
For , that endpoint path goes to positive real infinity. Deform the original contour into the real path from through the saddle point towards , followed backwards along the endpoint descent path to . The integrand is an entire function, so finite contour deformations are legitimate; connecting arcs in the far decaying sector vanish. If denotes the oriented integral from to that infinity, this givesThe last expression follows by setting : , so the endpoint integral is . This derives its phase and orientation directly.
For , the descent path from goes to negative real infinity. Deform from towards that infinity and then backwards along this endpoint path to . There is no saddle point segment, anduses the same formula with the negative square-root branch. At the contour can run from to zero and then up the imaginary axis. It gives a half-Gaussian contribution and the dominant imaginary endpoint term . The change in the subdominant saddle point contribution is a Stokes phenomenon; it does not change the leading endpoint term on either side of that angle.
The Gaussian saddle and endpoint dominance by angle follows by comparing exponential sizes and gives all fixed-angle leading behaviours:At , the endpoint term has magnitude , so the saddle point term of order still dominates. In the middle interval the endpoint term grows exponentially for , is oscillatory of order at , and decays exponentially for . On the latter interval it nevertheless decays more slowly than the fixed-endpoint term. Equality of their exponential rates means on the left half-plane, hence . At that angle both terms are required; their coefficient magnitudes are unequal, so their sum has no complete destructive cancellation.
These fixed-angle asymptotic expansions are not uniform if is allowed to vary with near a dominance transition. The endpoint/saddle balance near involves ; the two-endpoint competition near has an angular scale .
The following sketches show the contour orientations, the saddle point and both endpoints. The hyperbolic endpoint paths are followed backwards when returning from infinity to ; the dotted far-end connectors indicate the vanishing connecting arc.
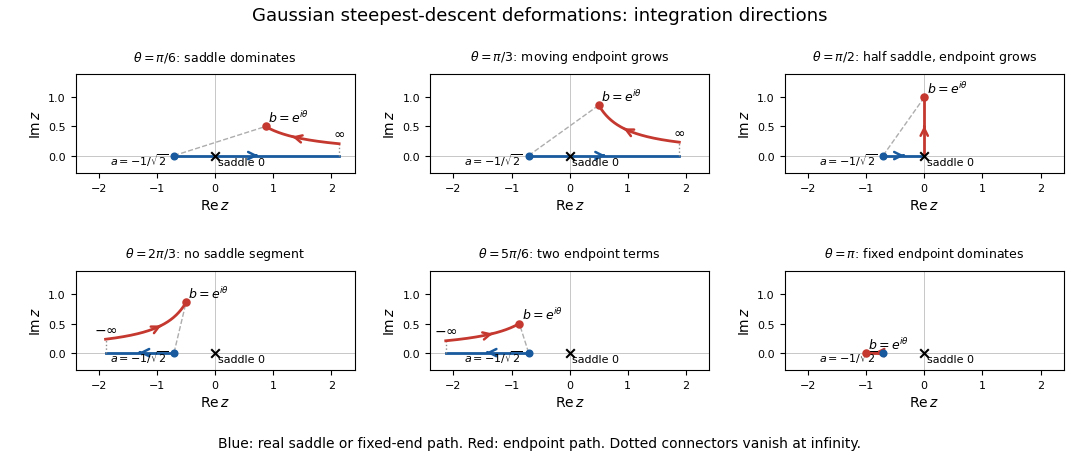
Steepest-descent contour deformations for the Gaussian integral at six endpoint angles, with saddle and endpoint paths and integration directions
. Details. Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 336 1 b i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Set . At the positive real endpoint the contour is real and crosses the saddle point at zero. The Gaussian integral givesBoth omitted tails are exponentially small. At the negative real endpoint the contour is oriented leftward and does not cross the saddle point:The endpoint contribution in steepest descent, or one integration by parts, gives . The upper-end correction is and is much smaller. ThereforeThe sign comes from contour orientation, not from a different Gaussian convention.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 333 3 i b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Conservation of shallow-water potential vorticity with fixed relative vorticity givesFor ordinary planetary-vorticity-dominated columns, moving towards the equator decreases the magnitude of absolute vorticity, so the column must become shallower and spread horizontally. This is the compression counterpart of vortex stretching. For , the depth ratio is , in either hemisphere before reaching the equator. The displayed general formula is essential if the fixed relative vorticity is large: the sign of the depth change then depends on the original absolute vorticity, and conservation cannot continue through zero absolute vorticity with positive finite depth and nonzero conserved potential vorticity.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 333 3 i a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Assume inviscid, unforced evolution, so shallow-water potential vorticity is conserved. If a column has initial depth and relative vorticity , moving to at fixed Coriolis parameter givesIts absolute vorticity is amplified by vortex stretching. A column initially without relative vorticity develops cyclonic spin: positive in the Northern Hemisphere and negative in the Southern Hemisphere. More generally the increase is in the direction of its original absolute vorticity, not necessarily the direction of if the initial spin is unusually strong.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 4 b vi Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Both eigenvalues of the linear generator, and , are negative. Nevertheless the non-normal matrix transfers the slowly decaying second component into the first before viscous decay wins. Modal decay coexists with energy amplification of order over a time of order .
This illustrates transient growth from non-normal modes: large Reynolds number permits much greater disturbance amplification even though the linear stability analysis finds no unstable eigenvalue. The energy-neutral rotational nonlinearity can redirect the amplified state and affect its subsequent evolution. The linear gain alone establishes neither sustained nonlinear instability nor a nonlinear transition threshold.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 4 b v Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14At the optimum, and the initial direction is . Since the final direction has ratio ,Using , , and simplifies this to the exact maximum gain:As , , so and . Consequently the requested large-Reynolds-number transient growth scaling isThese are the optimal time and gain of a Reynolds-scaled triangular model. The leading gain can also be read from the off-diagonal matrix exponential entry: with , is maximized at and has leading maximum .
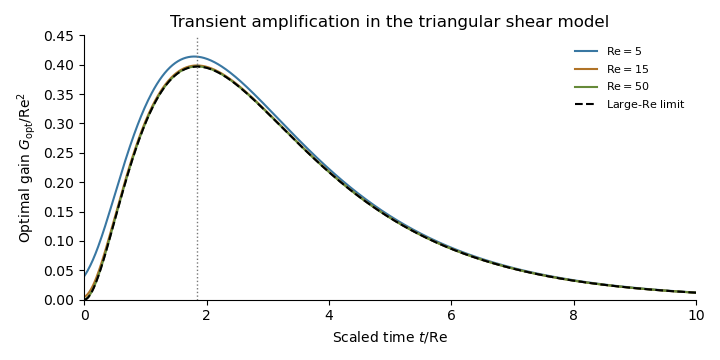
Optimal transient energy gain scaled by Reynolds number squared, approaching its large-Reynolds-number limit
. Details. Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 4 b iv Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06For the linear evolution from part (iii), maximize the energy ratio at each time. The optimal energy amplification of a linear system isThus the optimizing initial state is a right singular vector, not generally an eigenvector of .
There is a convenient exact way to find the maximizing time. Let be a unit optimizing initial vector and . The singular value decomposition gives . For , the top singular value is simple. At an interior time maximum,Since , this also equals . Thus both initial and final orientations are neutral energy-growth directions. The positive entries of let the top right singular vector be chosen with positive components. Its orientation decreases through the growth sector, so it must start at and end at .
Put and . The solution givesSetting this equal to yieldsTherefore the exact optimal time for isHere and below is the natural logarithm. This is the unique positive stationary time: decreases monotonically from one to zero, and the neutral-direction condition determines one . Also , , and admits initial energy growth, so this stationary point is the global maximum. For , the instantaneous energy-growth criterion for a linear system gives no amplification, and the maximum is one at time zero.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 4 b iii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06In the linear problem, , so . Solve with an integrating factor to obtain the complete solution:Equivalently the matrix exponential isBoth eigenvalues of are negative, so each solution eventually decays, despite the possible transient growth generated by .
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 4 b ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06For , the energy balance isThe concave quadratic changes sign at the roots of . For , the neutral orientations and the growth interval areOutside this orientation interval for transient energy growth, the energy decays; at either endpoint it is instantaneously stationary. The direction also has .
In the linear problem, the orientation evolves according to . Since both , a trajectory traversing the positive growth sector has decreasing orientation: growth begins at and ends at , as in the question.
For the full nonlinear model, however,The added rotation can reverse the direction of crossing. Thus the two roots always delimit energy growth, but the printed “begins” and “ends” labels are conditional on a decreasing-orientation passage, and are not universal for arbitrary nonlinear initial conditions.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 4 b i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06The matrix is a skew-symmetric matrix, so for real . Therefore the energy-neutral rotational nonlinearity contributes nothing directly to the energy balance:The nonlinear term rotates the state without changing its Euclidean norm. It can still change the orientation, and thereby affect later energy growth through the linear term. Thus energy cancellation does not mean the nonlinear and linear trajectories have identical energy histories.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 3 c ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Every generalized frequency in the inviscid Couette continuous spectrum is real: for real . Thus every time factor has unit modulus and there is no exponentially growing normal mode:The vorticity equation also gives , preserving its norm. For fixed nonzero , the bounded Dirichlet Green function inversion therefore gives a uniform bound on the reconstructed velocity in terms of the initial vorticity norm. Superpositions can still rearrange their velocity energy and display transient growth from non-normal modes; neutral hydrodynamic stability does not require every velocity component to decrease monotonically. Treating only smooth discrete modes would miss this continuous neutral family.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 3 c i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Impermeability requires . Let with real , and set . If is nonreal, or real outside the channel, the Rayleigh equation for inviscid shear flow gives everywhere. The two wall conditions then force . In fact there is no nonzero globally smooth eigenfunction for any : the complete family is the inviscid Couette continuous spectrum.
For each , permit a localized vorticity sheet. Let be the Dirichlet Green function satisfying . An explicit generalized eigenfunction iswhere and . It vanishes at both walls, is continuous at , and has derivative jump . Consequentlyusing the Dirac delta multiplication identity. These are vorticity-sheet eigenfunctions of inviscid Couette flow, understood as generalized eigenfunctions, not as a discrete smooth Sturm-Liouville eigenfunction expansion.
To see completeness, define the vorticity variable . Its evolution is , so for any admissible initial vorticity ,The homogeneous Dirichlet problem for has only the zero solution, so this inversion reconstructs every initial vertical-velocity field in its usual function space. The generalized frequencies fill the interval with endpoints ; the endpoint values are understood as the closure of the continuous spectrum.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 331 3 b iii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
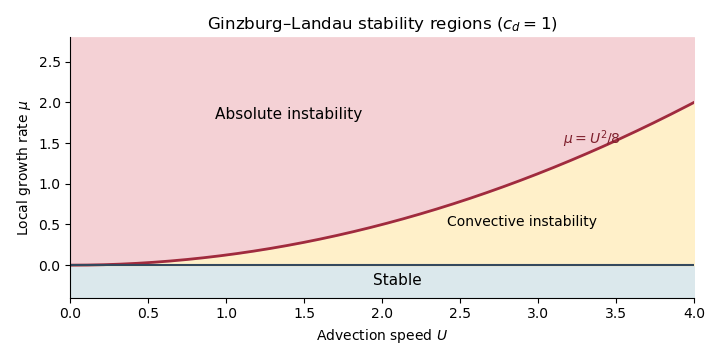
Codex 0 Created 2026-10-03 Updated 2026-10-14The dispersion relation gives the zero-group velocity saddleThus the absolute growth rate is . More generally the saddle growth rate along a ray isso a frame travelling at sees the maximal rate .
For , the three open regions areThe line is the temporal marginal boundary; the parabola is the convective-to-absolute boundary. The Green function of the linear complex Ginzburg-Landau equation has the prefactor , so zero exponential rate on the latter boundary still allows algebraic decay of the impulse response. This is the stability diagram of the linear complex Ginzburg-Landau equation.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:




All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact