Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 51 1 b Solution by  Codex 0 Created 2026-10-03 Updated 2026-10-14
Label an orthonormal basis of the -dimensional Hilbert space by , with indices modulo . LetThese are the shift and phase Heisenberg-Weyl operators. Alice holds the input and one half of the shared maximally entangled stateShe measures in the generalized Bell basisIts inner products areThere are orthonormal vectors in an -dimensional space, so this is a complete projective measurement.
For an unknown normalized state , its contraction with measurement outcome gives Bob's unnormalized stateEach outcome has probability , independently of the input. Alice communicates the two -valued labels, and Bob applies the ordered inverseThe order matters because shift and phase operators do not generally commute. Normalizing the branch recovers the unknown state exactly, and all outcomes are corrected, so success is deterministic. The quantum resource is one maximally entangled pair of local dimension . The classical resource is an -valued message, with information content bits; ordinary bits suffice in fixed-length binary encoding.
This is faithful qudit teleportation even for an input entangled with a reference . Expand a joint pure state as , without requiring the reference vectors to be orthogonal. The same contraction and correction act on each system basis vector, producing . Thus the whole joint state, not just a reduced state, is preserved. Linearity extends the conclusion to mixed inputs. This is teleportation as an identity channel on a reference.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 51 1 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Quantum teleportation transfers an arbitrary unknown qubit state to a separated receiver while using local operations and classical communication, rather than sending that input qubit. Alice and Bob first share one maximally entangled state of two qubits, such as a Bell pair; a shared spin singlet state is equivalent after a known local unitary operation.
Alice performs a joint Bell-basis measurement on the input qubit and her half of the pair. There are four possible outcomes. Bob's conditional qubit is the input state transformed by a known Pauli operator determined by that outcome. Alice sends the outcome as two classical bits, and Bob applies the inverse Pauli operator. Thus one shared Bell pair and two classical bits, together with local measurement and correction, transmit one unknown qubit exactly. The entangled resource is consumed.
The procedure does not produce a classical description of the unknown amplitudes and does not leave a second copy at Alice, so it respects the no-cloning theorem. Before receiving the classical outcome, Bob's reduced density matrix is , independent of the input; this respects the no-communication theorem. The next part proves the full identity-channel action, including inputs entangled with another system.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 3 g Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Both and are real symmetric and couple only neighboring sites whose diagonal entries in have opposite signs. For an entry of or , symmetry gives . Every nonzero entry joins signs and , while the diagonal entries vanish. Hence .
The condition is preserved by real linear combinations and commutators, so the entire Dynamical Lie algebra satisfies it. For the physical generator , differentiation gives , and therefore . This is an orthogonal dynamical symmetry in quantum control: a preserved symmetric bilinear form. It need not give eigenspaces of a commuting operator; indeed does not commute with or .
Set . Then , so the transformed generators satisfy as well as . They are consequently real antisymmetric, lying in . The original generators already supply the independent directions and , and their commutator is . These three independent directions exhaust the three-dimensional algebra. ThusHere denotes a matrix unit. The reachable connected group is a unitary conjugate of , a proper subgroup of , so there is no unitary operator controllability.
Pure-state control also fails. For every reachable state , the quantity is invariant, and its absolute value is unchanged even by an overall state phase. The normalized states and have respectively and , so no allowed control connects their rays. Therefore for this reduced three-level system, despite the absence of a simple excitation-sector obstruction within the sector.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 3 f Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Assume , as required for a connected chain and the supplied divisions. The single-excitation subspace has dimension three, so its Dynamical Lie algebra is contained in . The intended conclusion from nine independent skew-Hermitian directions is , giving unitary operator controllability, density operator controllability and pure-state controllability on this sector. Here is a direct generation argument that does not assume an independent identity control or rely on the normalization of the printed intermediate matrices.
Here denotes the hopping entry of the supplied reduced . With the stated Pauli matrices, restricting instead gives hopping ; absorbing that common factor into the reduced coupling does not change the Dynamical Lie algebra.
Write and using matrix units. The physical generators giveNext isolate the second transition and generate its other direction:Finally and . The three , three and two diagonal differences are eight independent traceless skew-Hermitian matrices, hence span . Because , subtracting the traceless part of also supplies , completing . This is the trace-direction step in identity augmentation in quantum controllability and the three-site instance of Endpoint control of an XX spin chain. If a coupling vanishes, the chain disconnects and the full-sector conclusion fails.
There is a redundant direction in the printed final pair of commutators: with the printed intermediate definitions, both are proportional to . Thus that pair cannot itself establish the stated independence. The mixed commutator above provides the missing direction and establishes the required conclusion independently.
Let be the algebra on the full eight-dimensional space. Restriction to the invariant single-excitation sector is a surjective Lie algebra homomorphism . If , the rank-nullity theorem gives , soThis is an abstract algebra isomorphism; on the full Hilbert space it is a reducible eight-dimensional representation preserving sectors of dimensions . The sector actions are linked by the same nine generators, rather than independently controllable blocks. In particular, this is not or , so it does not imply full-system controllability. The full spin Hamiltonians are traceless, so their algebra is embedded in even though its abstract type is ; its central direction is not an unrestricted overall phase on the full space.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 3 e Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Use the computational basis ordered as . Since and ,For arbitrary , a computational basis vector with ones has contributions and contributions , giving eigenvalue . All occur, soThe binomial coefficient counts which sites are excited. Thus there are exactly distinct magnetization sectors of a spin chain, and their dimensions sum to , the full Hilbert-space dimension.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 3 d Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Both the drift and local control commute with , so at every time. The propagator consequently obeys , as follows by differentiating this expression. Thus every reachable unitary operator preserves the magnetization sectors of a spin chain. If is a spectral projector of , then commutes with and .
The eigenspaces are nontrivial proper subspaces: has eigenvalue , while has eigenvalue . One cannot transfer the first pure state to the second, although their density operators have the same spectrum. Nor can one implement a unitary that mixes these two sectors. Hence . Its Dynamical Lie algebra lies in the block-diagonal commutant of . Controllability within a fixed sector, such as the single-excitation subspace, is still possible and must be tested separately.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 3 c Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14The Pauli matrices obey and , and operators on different tensor factors commute. HenceAdding gives . Each commutes separately with both and , so . Every interaction on sites also commutes with all for . Therefore equal and coefficients make their contributions cancel pair by pair, and . This is Excitation-number conservation in XXZ spin chains: is the total spin magnetization in Pauli normalization.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 3 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Assume the usual real Hamiltonian controls with freely chosen finite duration, rather than a fixed-time or amplitude-restricted task. Define the Dynamical Lie algebrathe real linear span closed under all nested commutators. Replacing each generator by gives the same algebra. The associated connected reachable group acts on propagators, on each unitary orbit of a density operator, and on pure states. For , the necessary and sufficient conditions are as follows.
For exact unitary operator controllability, . For operator control up to global phase, the possibilities are or . If every Hamiltonian is traceless, , so the central phase direction is absent and exact access is to . The full special unitary Lie algebra has dimension and the Lie algebra of the unitary group has dimension .
For density operator controllability on every spectral orbit,Scalar phases do not affect conjugation. If only a particular density spectrum is being considered, a smaller group can suffice: for distinct eigenvalue multiplicities and centralizer , the orbit criterion is . A maximally mixed state has a one-point orbit and needs no controls. This restricted-orbit condition is weaker than controllability for every density spectrum.
For pure-state controllability, up to a fixed unitary change of basis,where the last two alternatives occur only for even . Here is the standard compact symplectic Lie algebra acting on , not the real noncompact symplectic algebra. These are precisely the unitary matrix algebras whose connected groups act transitively on normalized complex vectors, and also give the ray version of controllability. For , . For even , the symplectic cases show why pure-state control can be weaker than density control: is smaller than the nondegenerate density-orbit dimension , and its scalar center acts trivially on that orbit. For , the physical density and pure-state spaces are single points, while exact operator controllability still requires the phase algebra .
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 3 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14For reachability in control theory, a state is reachable from if an admissible input and a permitted duration drive the dynamical system from to . Controllability requires this for every initial-target pair in the specified state space. Restrictions on duration or field amplitudes change the reachable set, so the admissible controls are part of the definition.
For a closed quantum system, , , and states evolve as or . This gives three notions of quantum controllability. Unitary operator controllability requires every desired to be reachable from the identity; when a global phase is immaterial, one instead asks for every special unitary operation. Density operator controllability requires every pair of density operators with the same spectrum to be connected. The spectral qualification is necessary because unitary time evolution cannot change eigenvalues; the natural state space is a unitary orbit of a density operator. Pure-state controllability requires any normalized initial state to be transferred to any target ray, .
Thus , with the operator implication also valid if global phase is discarded. The converse implications need not hold. A pure-state task concerns one vector, whereas an operator task must act correctly on every input vector at once.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 2 e Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14For real , the equilibrium equations are , and . The determinant of the coefficient matrix is , where whenever . Solving the two-by-two system, including cases with one parameter zero, givesSubstitution verifies the first equation by cancellation of and , and the third because . The nonzero determinant proves uniqueness. Its squared length is , andThus , which is inside the qubit physical Bloch vector body; in the Hilbert-Schmidt normalization of part (b), that body has radius .
The mode has eigenvalue . The block has characteristic polynomial , so the other eigenvalues areIf , they have real part . If , the square root is at most , with equality only when ; the larger eigenvalue is still negative unless . At an eventual Jordan factor does not change decay because its eigenvalue is negative. Therefore for every allowed parameter pair all eigenvalues have negative real part, and .
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 2 d Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14A steady state is attractive here if every physical initial density operator approaches it. Subtracting its Affine Bloch equation from the trajectory equation gives , so . The necessary and sufficient condition isSuch an is a Hurwitz stable matrix. To prove sufficiency without assuming diagonalizability, put it in Jordan normal form. Each Jordan block contributes , and the negative real part makes the exponential dominate all polynomial factors. For necessity, an eigenmode with positive real part grows; an eigenmode with zero real part remains constant or oscillates, so it does not tend to zero. A nontrivial Jordan block on the imaginary axis also prevents decay.
The physical Bloch vector body has nonempty interior, so differences of physical initial vectors from span the full real coordinate space. Thus convergence for every physical initial state also forces on that space. This rules out hiding a nondecaying eigenmode outside the physical set. The strict spectral condition entails uniqueness and global asymptotic stability of the steady state.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 2 c Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14A steady state is a time-independent density operator satisfying , equivalently a constant physical Bloch vector satisfying . Let . By the rank criterion for a linear system, this equation has a solution exactly whenWhen it is consistent, every algebraic solution has the form with , so the solution affine space has dimension by the rank-nullity theorem. Physical steady states are its intersection with the positive density operator body. The algebraic equilibrium is unique exactly when , in which case .
An arbitrary affine differential equation need not have an equilibrium: , is inconsistent. For the finite-dimensional, time-independent Lindblad equation under discussion, however, a physical steady state always exists. Indeed, the averages remain positive with trace one. Compactness supplies a convergent subsequence as , andThe limit is a physical steady state, proving that Finite-dimensional Lindbladians have stationary states and that the rank consistency condition is automatically satisfied for this physical generator.
In this setting, full rank also characterizes uniqueness among physical steady states. To justify the converse when is singular, a nonzero gives a fixed traceless Hermitian operator . Write its positive-negative decomposition . Time-average the evolutions of the two positive operators along a common convergent subsequence; the limits are positive stationary operators and satisfy . Their traces are equal because . If there were only one stationary density operator, both would be this matrix times the same trace, forcing , a contradiction. Hence .
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 2 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Write in the Generalized Bloch representation. Linearity of the Lindbladian gives . For the Hamiltonian term, cyclicity yieldsFor one Lindblad operator , the jump term becomes , and the two remaining terms giveThusEvery coefficient is real because is Hermitian. In addition, , although a dissipative need not be symmetric.
The Hamiltonian commutator has zero trace, and each dissipator obeys , so . Consequently for normalized density operators. Orthogonality to makes every other traceless. Define . With , trace preservation gives the block formHere the indices of range from to . Since , the offset can also be written . This is the Affine Bloch equation; its offset is zero for unital dynamics, which preserve the identity.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 2 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14The Hermitian operators form a real vector space of dimension . To see that the same basis spans all complex operators, decompose an arbitrary as , where and are Hermitian. Expand in the real orthonormal basis and combine their coefficients. The resulting complex expansion is unique because . Taking the Hilbert-Schmidt inner product with givesIf is Hermitian, then by cyclicity. Hence . The basis is a real basis of Hermitian operators and its complexification is a complex basis of all operators.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 1 e Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Spectral pulse shaping implements a calculated optical control by modifying its complex frequency spectrum. If the available input pulse has spectrum , program a calibrated mask so thatThe temporal waveform follows from Fourier inversion. For a real applied field, its spectrum has conjugate symmetry, so the mask must satisfy . Spectral phase controls interference between frequencies and hence their arrival times, chirp and temporal subpulses; spectral attenuation changes their weights. The optimized field envelope is translated into this complex mask, with compensation for known phase shifts and losses in the optical system.
A typical 4f pulse shaper contains a first diffraction grating, a focusing lens, a mask or spatial light modulator in the common focal plane, a second lens and a second grating. The first grating separates the frequencies by angle. The first lens converts those angles into different transverse positions at the spectral Fourier plane. The pixels of the spatial light modulator modify the amplitude and phase of the corresponding frequency bins. The second lens and grating reverse this spatial dispersion and recombine the components into one shaped output beam. In the ideal symmetric layout the four consecutive propagation distances are , giving the name .
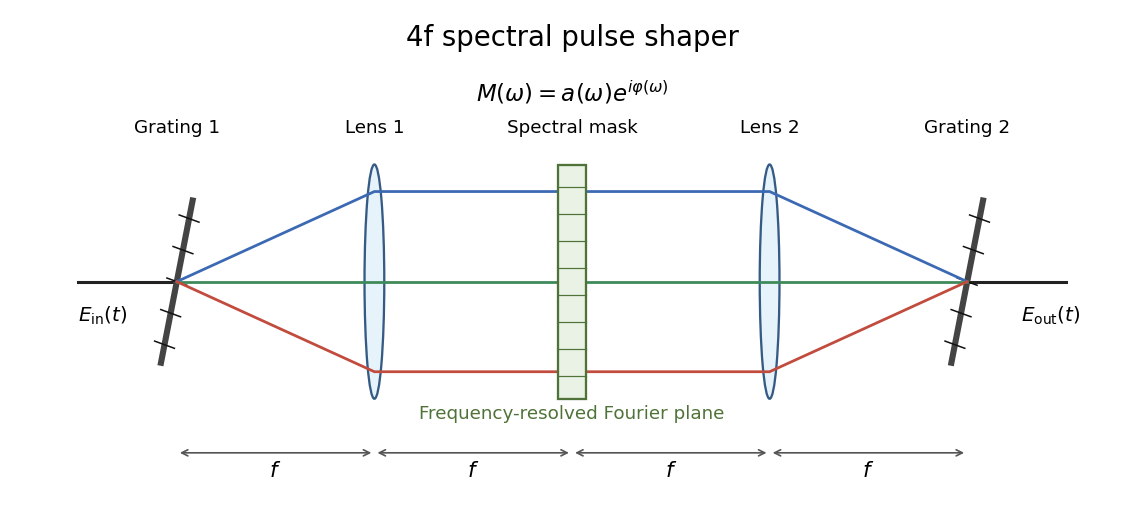
A phase-only spatial light modulator needs suitable polarization optics or another modulation stage for independent amplitude shaping. A passive mask has and cannot create frequencies absent from the input; finite bandwidth and finite pixel resolution limit temporal features and the useful shaping window. These constraints must be included when converting a mathematical optimum into a laboratory pulse. The programmed mask is an open-loop control, although repeated measurements of the output pulse or system performance can be used to calibrate or optimize it experimentally.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 1 d Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14A quantum optimal control problem specifies a terminal task, admissible fields and resource costs. Pure-state transfer can minimize ; mixed-state transfer on an accessible spectral orbit can minimize ; preparing an observable value can minimize . A gate task can minimize for an -dimensional Hilbert space, which is insensitive to an overall phase. These different terminal functions encode different tasks even when the dynamics are the same. Fluence penalties, amplitude bounds, bandwidth limits, or the total duration can be added to express experimental requirements.
For example, minimizesubject to and a specified . For a closed system, ; for an open system add the known Lindblad equation dissipator. Introducing a Hermitian costate and taking the Hilbert-Schmidt inner product gives the forward and backward equations and functional gradientFor Hamiltonian controls the second term is . The adjoint is defined by the Hilbert-Schmidt inner product; in particular, the closed-system costate equation is , integrated backward from its terminal condition. An unconstrained interior optimum has zero gradient; amplitude constraints replace this by the corresponding constrained first-order conditions.
Numerically, represent the fields by piecewise constant amplitudes on slices, or by a finite basis such as splines or Fourier modes. For piecewise constant closed-system dynamics, and . Forward products and backward costates provide all slice derivatives in one pair of propagations. In gradient ascent pulse engineering, update these amplitudes to improve the chosen objective, with projection onto amplitude bounds if needed. The exact slice derivative is the derivative of the matrix exponentialReplacing it by is only a short-slice approximation when and do not commute. Other gradient descent or nonlinear optimization methods can optimize the same finite parameter set; direct-adjoint looping avoids a separate dynamical simulation for each control coefficient.
A pulse is accepted after propagation with the actual constrained waveform confirms its terminal error and resource use. Sampling model uncertainties in the objective can favor robust pulses. Nonconvexity means a numerical stationary point need not be a global optimum, so initial guesses, convergence tolerances and a sufficiently resolved time grid matter.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 1 c Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14The Lyapunov quantum control law requires an exact instantaneous expectation value. Cyclicity writes it aswhere is a known Hermitian observable. A measurement on one system produces a random outcome, not its exact ensemble expectation, and changes the system state. Repeated measurements for state estimation or continuous weak measurements introduce noise and backaction absent from the assumed closed-system equation. Thus the law cannot be implemented unchanged as exact measurement-based quantum feedback while retaining the dynamics and guarantee in part (a). A conditional-state feedback scheme must include the measurement evolution and rederive its stability properties.
If the initial density operator and Hamiltonian model are known, we can instead solve the deterministic equations in a computer, calculate along the simulated trajectory, and apply that precomputed waveform in the laboratory as open-loop control. Ensemble measurements can help calibrate such a waveform, but they do not supply nondisturbing instantaneous feedback from an individual evolving system.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 1 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Neither monotonic decrease alone nor equality of the initial spectra guarantees convergence. A nonnegative Lyapunov function can approach a positive limiting value, and the set where can contain trajectories other than the target. Different initial spectra already obstruct exact tracking: unitary time evolution preserves the eigenvalues of each density operator, while two matrices approaching one another in norm must have the same limiting eigenvalues.
Even the spectral obstruction can be absent while the Lyapunov quantum control stalls. Take a qubit with , , and . Both density operators commute with , and the commutator of with has zero diagonal, so . Both states remain constant. They have the identical spectrum , but . Moreover generate the full special unitary Lie algebra , so the failure here is a limitation of this particular feedback law, not a lack of available state-transfer controls.
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 50 1 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14The density operators are Hermitian, so their squared Hilbert-Schmidt distance is . Both purity of a density operator values are constant under their respective unitary time evolution: cyclicity gives for every Hermitian . ConsequentlyThe terms containing cancel because . The quantity is real: is Hermitian, and the trace of the product of two Hermitian matrices equals its conjugate. The Lyapunov quantum control choice therefore gives . For , integration yields . Since the distance is , it is monotonically nonincreasing. The decrease need not be strict when .
Past exam of the mathematics course of the University of Cambridge 2010 iii Paper 5 5 d Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Fix a compact and choose such that a closed -neighbourhood of is compactly contained in . The hypothesis gives a common bound on that neighbourhood. Choose a smooth radial mollifier supported in with integral one. The mean value property for harmonic functions, integrated against its radial weights, givesin a neighbourhood of . Differentiating this fixed-radius convolution gives the uniform interior estimateThus the sequence is equicontinuous there; taking its pointwise limit gives the same local modulus of continuity for . A finite small-ball cover of now proves uniform convergence directly: choose the cover so both and vary by less than inside each ball, then use convergence at its finitely many centres to make there. The triangle inequality gives for large .
Finally, pass to the limit in the reproducing convolution identity on smaller compact sets. It yields , so is smooth locally. Also, for each compactly supported smooth test function , uniform convergence on its support givesHence its smooth Laplacian is zero. We have proved uniformly on every compact subset and is harmonic. Using the continuous representatives in the pointwise hypothesis makes this conclusion pointwise, rather than only almost everywhere. This is compact convergence of locally bounded harmonic functions.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:



All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact