
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 3A a Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 2B b Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 2B a Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 1A Solution Created 2026-09-24 Updated 2026-10-14
Since , the image of a linear map represented by lies in the kernel of . The matrix is nonzero, so this image of a linear map contains a nonzero vector; consequently . On the other hand, gives . The rank-nullity theorem in dimension two therefore givesThus the image of is a line through the origin, and maps onto that line.
Reversing the order of the matrix multiplication need not give zero. For example,gives but . This also shows why information about one composition of linear maps does not establish the corresponding property of the reversed composition.
Write . Its rank is one, so its determinant is zero. Choose its adjugate matrix:Direct matrix multiplication gives . Since the entries of are the entries of the nonzero matrix , rearranged with possible sign changes, . This establishes both required annihilation properties.
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 12A c Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 12A b Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 12A a Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 11A Solution Created 2026-09-24 Updated 2026-10-14
In Einstein summation convention, the curl of a cross product has componentsThe second line uses the contraction of two Levi-Civita symbols; the last uses the product rule. These components prove the curl of a cross product identity, including both divergence and directional-derivative terms.
Now apply that identity to . On the orientable surface, , , and . Differentiating gives . Taking a dot product with in the curl of a cross product formula therefore gives, on ,Only tangency on the surface is needed; no claim is made that the extension is tangent away from it. The right side is the surface divergence of the tangent vector field.
With the boundary oriented according to Stokes theorem, cyclic invariance of the scalar triple product giveswhere is the outward conormal of a surface boundary. Thus Stokes theorem provesThis is the surface divergence theorem for a tangent field.
For the disc in the plane, take and . The field is tangent on the disc, and . The contraction is , so the surface integral is . On the positively oriented circular boundary, and , so the boundary flux is . Both sides agree.
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 3 10A Solution Created 2026-09-24 Updated 2026-10-14
Choose coordinates that measure the curved boundary and the slope of a ray:On the positive interior, the inverse change of variables isThe two rays become and , while the curve becomes . The interior of therefore maps to the rectangle , . For , the lower edge describes a limiting boundary, since the original region is unbounded; the origin also has no uniquely defined ratio . For the region has zero area. These endpoint cases do not invalidate the change of variables on the positive interior.
For the three-dimensional integral, retain as the third coordinate. The transformed region isThe planar Jacobian determinant isThe integrand cancels this Jacobian determinant especially simply:HenceOne can first use the change of variables formula with and then pass to the limit. The nonnegative integrand allows this by the monotone convergence theorem, so the unbounded limiting slice at causes no omitted contribution.
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 9F d Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 9F c Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 9F b Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 9F a Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 8D Solution Created 2026-09-24 Updated 2026-10-14
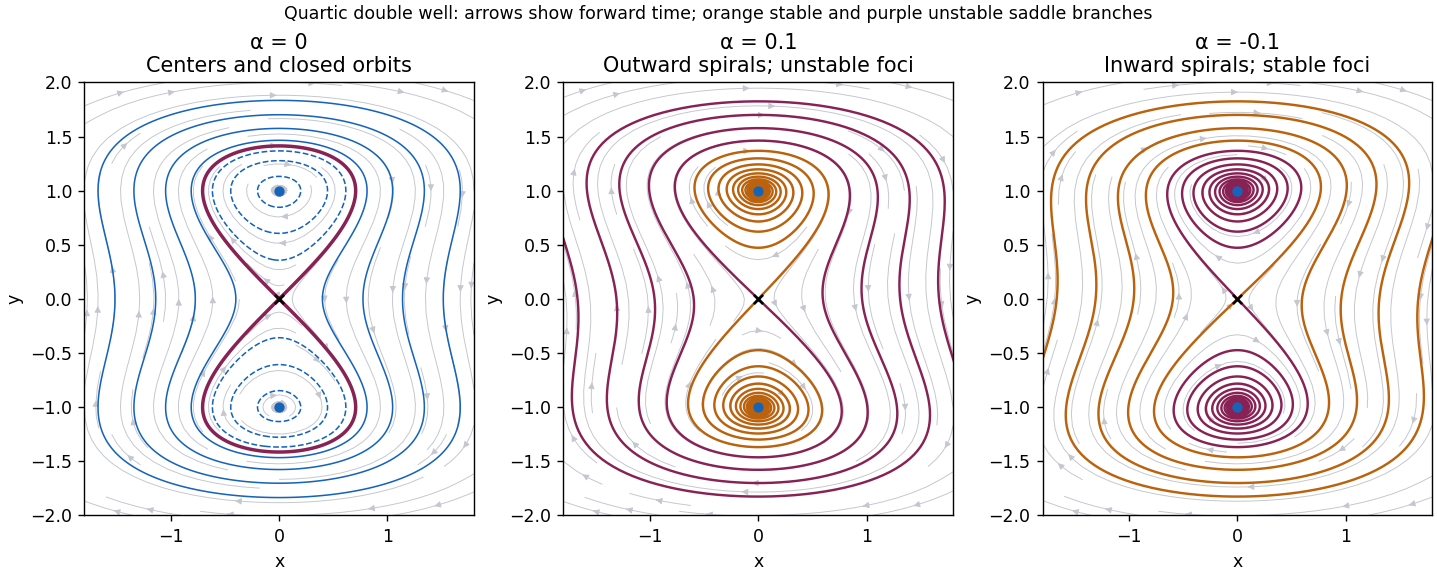
Introduce . Along a solution,At , is a first integral. The identity shows its level sets are bounded: neither nor can escape to infinity on a fixed level. Consequently trajectories remain bounded as , including those starting far from the origin. This bound also prevents finite-time escape; no explicit solution is needed.
The equilibrium points are and . The Jacobian matrix at isAt the origin its eigenvalues are , with opposite signs, so the origin is a saddle point in all three cases. An eigenvector for lies on ; the stable direction has positive slope and the unstable direction negative slope. At the eigenvalues are .
When , these latter eigenvalues are . The nonlinear classification follows from the strict minima of at the two points: nearby level sets are closed curves without other equilibria, and the nonvanishing vector field makes them periodic orbits. Thus the two points are center equilibria. For , there are two separate closed ovals, one around each center equilibrium. The level consists of the saddle point and two homoclinic orbits forming a figure eight, explicitlyFor , a single outer closed orbit encloses all three equilibrium points. Motion is clockwise, as the vector points downwards wherever . The upper homoclinic orbit leaves the origin into and returns through ; the lower one has the reflected orientation.
When , the two nonzero equilibrium points have eigenvalues and are unstable foci. Nearby paths spiral outward clockwise. The first integral becomes a strictly increasing energy along every nonconstant trajectory: although can momentarily vanish when , it cannot vanish on an interval unless the solution is an equilibrium. Thus there are no periodic orbits or homoclinic orbits. The two stable separatrices of the saddle point, traced backwards, spiral towards the corresponding unstable foci. Its unstable separatrices move onto positive energy and escape outwards. All other nonequilibrium trajectories outside the stable manifold are unbounded forwards: a bounded forward limit set would have to lie in , whose only invariant points are the three equilibria; the two unstable foci cannot attract a nonconstant trajectory, and convergence to the saddle occurs only on its stable manifold. Escape is not finite-time blow-up, since bounds the energy on every finite interval.
When , the eigenvalues at the nonzero points are , so they are stable foci. The energy decreases, keeping all forward trajectories in compact sublevel sets. A bounded limit set must lie in the invariant part of , so trajectories converge to equilibria: generically to one of the two stable foci, exceptionally to the saddle along its stable manifold. The saddle's unstable separatrices spiral into the two stable foci; its stable manifold separates their attraction basins. Again, energy monotonicity excludes periodic orbits and homoclinic orbits. These three cases give the quartic double-well phase portrait with linear damping below.
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 7D Solution Created 2026-09-24 Updated 2026-10-14
Two functions are linearly dependent if constants , not both zero, satisfy identically. Differentiating also gives . Since the determinant of these two equations is the nonzero Wronskian , both constants must vanish. Hence the two solutions are linearly independent.
Differentiating the Wronskian and substituting the homogeneous linear differential equation givesIntegrating proves Abel's identity:For variation of parameters, impose on the proposed particular solution. Then , and substitution into the inhomogeneous differential equation leaves . Solving this two-by-two linear system givesArbitrary constants of integration merely add a homogeneous solution.
For the constant positive coefficient , take . Direct differentiation verifies that and solve the homogeneous linear differential equation; their Wronskian is . The requested integrands areTaking yieldsThus grows with power one, whereas is bounded. Their combination simplifies to ; the final sine term is itself a homogeneous solution. The secular term is the response to resonance in a differential equation.
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 6D Solution Created 2026-09-24 Updated 2026-10-14
For the logistic differential equation, separate variables to obtain away from the constant solutions. Applying the positive initial condition givesThe formula also includes the constant solution . Below positive solutions increase; above they decrease. They approach as . Equivalently, linearizing gives and . Thus zero is unstable and is asymptotically stable.
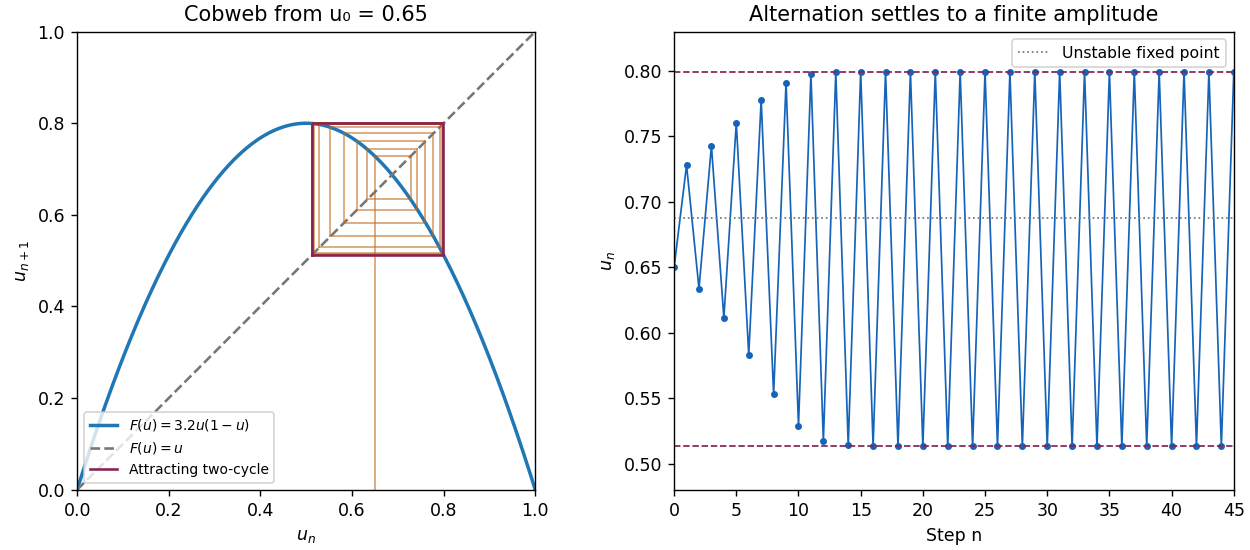
The Forward Euler method gives . Set and ; multiplying the recurrence by this scaling factor gives the logistic mapIts fixed points are and . The fixed-point multipliers are and . Since , zero is always unstable. The positive fixed point is stable for and unstable for . For , a small displacement obeys : its sign alternates and its amplitude grows, giving an oscillatory instability whose period is .
This is an artifact of Euler discretization of logistic growth. Exact small perturbations decay by the positive factor per time step; a one-dimensional autonomous differential equation cannot have a nonconstant periodic orbit, since its solutions move monotonically between equilibrium points. The artificial instability occurs when , beyond the stable step range of this discretization.
For , remove the fixed point factors from to obtain . The resulting logistic map two-cycle isThese points map to each other. Their periodic-orbit multiplier is , so the two-cycle attracts nearby iterates. The cobweb shows a small initial departure from growing with alternating sign and then settling into the finite rectangle between and . The time trace shows the corresponding finite-amplitude oscillation.
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 5D Solution Created 2026-09-24 Updated 2026-10-14
An integrating factor for a differential one-form is a nonzero function for which is an exact differential, say . Then solutions lie on level sets . Locally, the compatibility condition is .
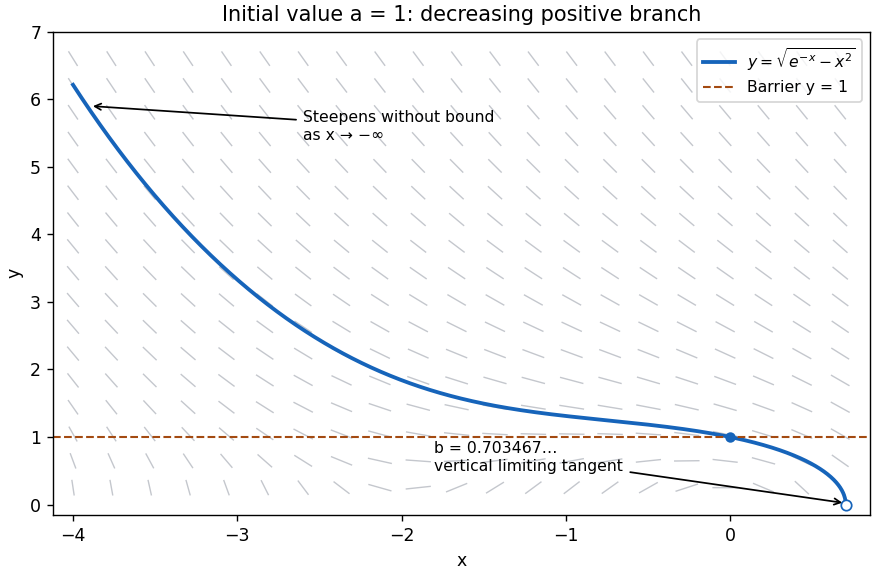
Here multiplication by , which is nonzero for , producesThe initial condition makes this first integral equal to . Taking the positive branch yields the solutionon the connected interval containing zero where the radicand is positive. This domain restriction matters because the original differential equation is singular at .
Completing the square gives . As , the differential equation consequently impliesAt , . Thus, moving a little to the left from , the curve rises above . Throughout every segment of the direction field points downwards as increases, by the inequality above. Tracing backwards therefore makes rise further, so it cannot return to . This graphical barrier argument proves and for every on the solution. The explicit first integral also shows this branch extends throughout : writing , the minimum of is , so for . Including the initial point, for all .
For the curve is on , where the strictly increasing function has the unique positive root at . The curve decreases through with slope and reaches only as a limiting endpoint. Its derivative isAs , and . As , the numerator tends to and the denominator to zero from above, so again . More precisely, at the endpoint. Both ends have the requested unbounded negative slope.


Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 4F Solution Created 2026-09-24 Updated 2026-10-14
After independent tosses, an even count arises in exactly two disjoint ways: an even count after tosses followed by a tail, or an odd count followed by a head. Independence of the last toss from the preceding ones therefore givesSubtracting the fixed point turns this into the linear recurrenceAs zero is even, , so the probability isFor this is for every ; for it is always one; for it alternates between one and zero according to the parity of .
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 3F Solution Created 2026-09-24 Updated 2026-10-14
The indicator function equals one when the event occurs and zero otherwise. Its expected value is . By linearity of expectation, no independence assumption is needed to obtainSince , including , the variance isIn particular, correlations between the events cannot simply be discarded.
Write . If , then implies . Applying Chebyshev's inequality therefore givesEquivalently, the contribution of to is . A positive mean is necessary for the displayed ratio to be defined. If , nonnegativity instead gives almost surely, and the printed ratio would be .
Past exam of the mathematics course of the University of Cambridge 2002 ia Paper 2 2D Solution Created 2026-09-24 Updated 2026-10-14
This is a separable differential equation. On the solution with , integration from the initial condition givesThe right side lies in , so taking its sine stays on the required branch. The solution isNear the origin, , so and the tangent line is horizontal. At the other end, , whileThus the curve has a vertical limiting tangent line as , even though is excluded from the domain.
For the direction field, the slope is nonnegative everywhere in the square. The segments are horizontal on and on , become steeper as increases at fixed , and become flatter as increases at fixed . Near they are almost vertical unless is correspondingly close to one. The excluded corner has no single limiting slope: the ratio depends on the path of approach.
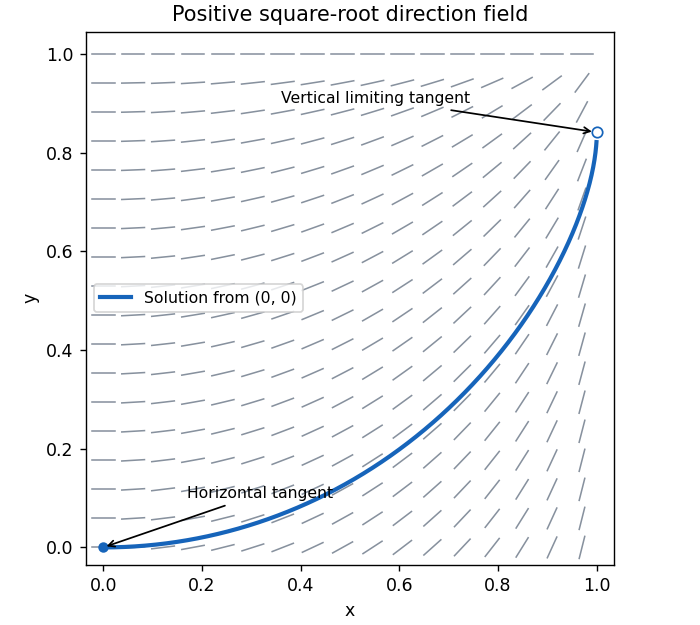
Positive slope field and the solution from the origin, with its horizontal and vertical limiting tangents
. Details. 
There are unlisted articles, also show them or only show them.