Named after Charles Hermite.
A monic orthogonal polynomial has leading coefficient one. For a fixed positive weight, there is a unique monic orthogonal polynomial of each degree.
The special orthogonal group isEvery element of is a rotation in the plane. Every element of fixes an axis and restricts to a planar rotation on its perpendicular plane.
An orientation of a surface induces the boundary direction used in Stokes theorem. Walking in the positive boundary direction keeps an upward-oriented surface on the left.
A first integral is a function of time, state, and derivatives that remains constant along every solution.
A Bernoulli differential equation is a first-order ordinary differential equation of the displayed form, with and continuous functions on an interval and a fixed real exponent . A nonlinear power can hide a first-order linear differential equation: on a suitable branch, the Bernoulli power substitution removes it exactly. The transformed solution of a differential equation can be completely regular even when recovering produces finite-time blowup.
For example, the reciprocal Bernoulli equation with finite-time blowup becomes under . The initial conditions and select a positive trajectory blowing up at and a negative trajectory tending to zero as , respectively. The integrating factor exposes both behaviors with the same short calculation.
The cases and are already first-order linear differential equations: respectively , with the zeroth-power term interpreted as the constant , and . There is no need for a nonlinear change of variable; for , would discard the unknown entirely. For other exponents, the substitution must respect the domain of exponentiation and may lose the zero solution of a differential equation.[ref]
1.5 Substitution. Notes on Diffy Qs, §1.5.2 Bernoulli equations: substitution v equals y to the power 1 minus n; n equals 0 or 1 is already linear; Example 1.5.1 selects the positive root using its initial condition
A differential inequality bounds derivatives rather than specifying them exactly; comparison and integration turn it into bounds on the function.
For , the initial-value problemhas the continuous piecewise differentiable solutionThe vector field is not Lipschitz at zero, but the direction on each side prevents any solution from leaving zero, so this solution is unique in the piecewise differentiable class.
A boundary condition prescribes values of an unknown function or its derivatives at the boundary of the domain of a differential equation.
A boundary value problem asks for a differential-equation solution satisfying conditions at more than one point or boundary component.
Lie point symmetry of an ordinary differential equation by  Codex 0 Created 2026-09-24 Updated 2026-10-03
A Lie point symmetry is a local one-parameter transformation of the independent and dependent variables that maps solution graphs of a differential equation to solution graphs.
A singular perturbation is a parameter-dependent problem whose limiting problem changes qualitatively as the parameter tends to zero. In an ordinary differential equation, a small coefficient of the highest derivative can reduce the order of the limiting differential equation, preventing it from satisfying all the original boundary conditions. Different length or time scales often require different asymptotic expansions.[ref]
Asymptotic Analysis and Singular Perturbation Theory by John K. Hunter. §1.1.2, p. 2: regular and singular perturbations
Consider the boundary value problemThis second-order differential equation is exactly solvable. Setting gives the first-order linear differential equation , so . One integration and the two boundary conditions giveBoth boundary conditions hold for every positive . For numerical evaluation, write the same ratio as , where evaluates the exponential function minus one without catastrophic cancellation near . Keep the denominator for finite : at it is approximately , rather than exactly one.
Setting gives . The outer solution selected by the right boundary condition is therefore , which fails the left boundary condition. The exact exponential function shows how that mismatch is repaired: the solution rises from zero to almost one within a boundary layer of width , using Big O notation. For each fixed , , while always. This pointwise convergence fails to be uniform convergence to the outer solution on , since for every .
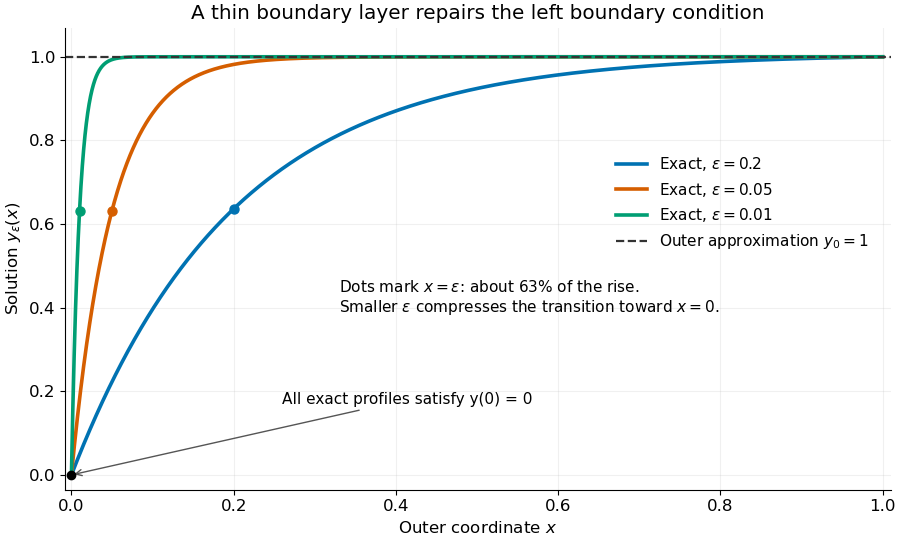
Exact solutions with a shrinking left boundary layer
. The exact normalized profiles at , , and satisfy both boundary conditions. The dashed outer solution misses the left boundary condition. Colored dots mark , where most of the initial rise has already occurred. Details.
The coefficient is small, but its product with the second derivative need not be small. Direct differentiation givesAt with fixed , these derivatives grow as and respectively as . Consequently and have exactly equal magnitudes and opposite signs. Even away from the boundary layer, their magnitudes remain equal in this example; both become exponentially small at each fixed positive . The outer expansion neglects an exponentially small transient there, rather than establishing that one derivative term is smaller than the other everywhere.
To predict the width without knowing the exact solution, suppose an order-one change occurs over distance . The derivative scales are and . The dominant balance gives . The resulting inner variable makes the boundary layer visible at a fixed scale. This is the useful feature of singular perturbation: an apparently disappearing term identifies the missing structure when one measures its derivatives on the appropriate scale.
Local existence for a scalar autonomous ordinary differential equation with continuous vector field by Codex 0 Created 2026-09-24 Updated 2026-09-24
Codex 0 Created 2026-09-24 Updated 2026-09-24 There are unlisted articles, also show them or only show them.