Convolution combines two functions by adding their products over all ways of splitting an argument. For Lebesgue integrable functions on the real line, their convolution isThe arguments and always add to . For in the L1 space, the integral exists almost everywhere and defines another element of the L1 space, with by Young's convolution inequality. Particular examples below have a value at every .
To see what the integral counts, take the indicator function . The product equals one exactly when belongs to both intervals and . Its integral is their overlap length, soAt , the overlap is and the output is ; at , the two intervals coincide and the output is one. The result is the shifted triangular function . As changes, is a reflected and translated copy of : the moving overlap makes the entire graph visible without a difficult integration.
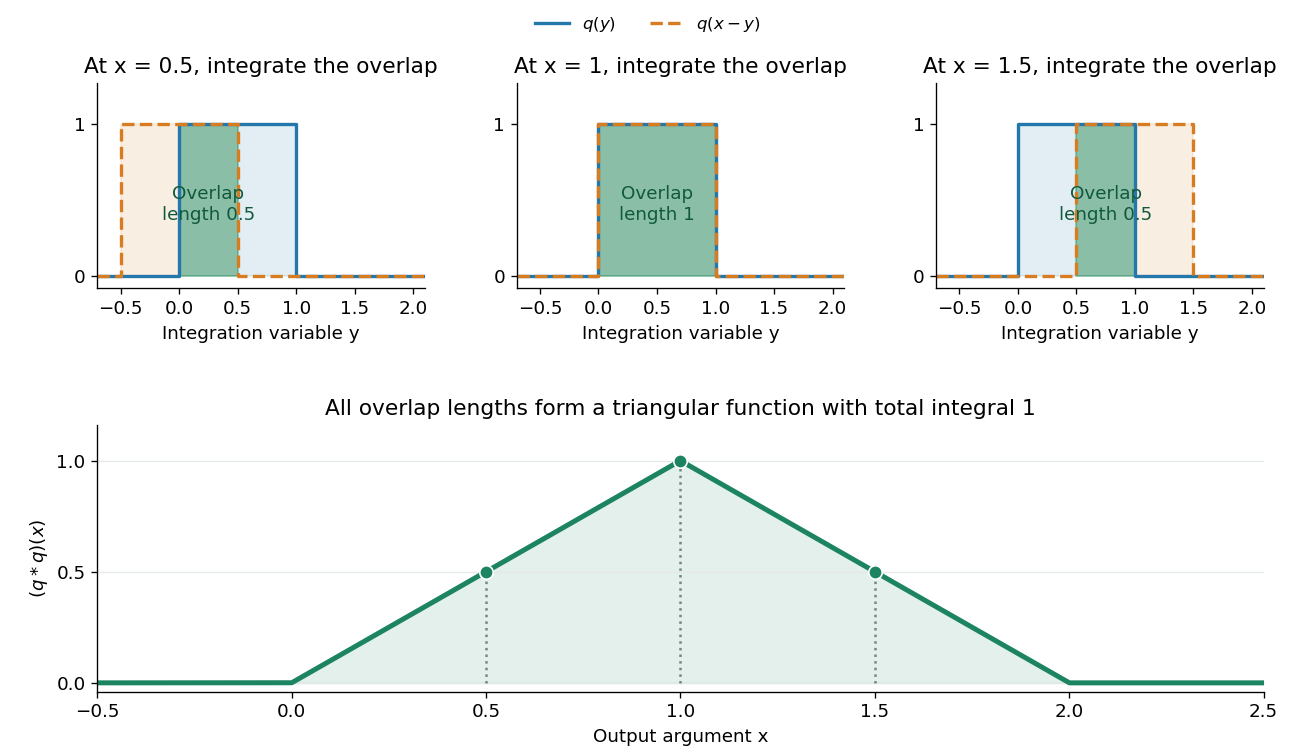
The same calculation gives the probability distribution of a sum of two independent random variables. If are independent random variables with the continuous uniform distribution on , each has probability density function . Their sum has probability density function by convolution of probability densities. The probability density function at one is larger than near zero or two because there are more combinations of the two inputs giving that sum. Its total integral is one; its expected value is one and its variance is . These follow equally from integrating the triangular function or from linearity of expectation and variance additivity for independent random variables.
Convolution also gives a useful averaging operation. For , let . Thenthe mean of in a neighborhood of . A smaller examines a smaller neighborhood. For a continuous function , this mean tends to as , an example of an approximate identity. Integrating a sharp input against a distributed convolution kernel can produce a smoother output; the triangular example turns two discontinuous inputs into a continuous output.
In signal processing, a linear time-invariant system combines shifted copies of its impulse response by the same rule. In discrete time, an input value at index contributes a scaled response at index , and discrete convolution sums these contributions. This is the superposition interpretation developed in Oppenheim, MIT Signals and Systems, Lecture 4, convolution sums and integrals. The convolution theorem then gives another description: transform both inputs with a Fourier transform and multiply their transforms. Combining shifts, combining independent quantities and multiplying frequency descriptions are three faces of the same operation.
Tonelli's theorem gives the product integral of as . Fubini's theorem then defines the convolution almost everywhere and gives an integrable result with norm at most that product. Multiplication by a complex exponential of modulus one preserves absolute integrability and permits the usual Fourier transform convolution identity.
For finite complex measures on the additive circle group, convolution is the pushforward measure of their product under addition modulo . EquivalentlyBounded tests are integrable against the product variation measure, so Fubini's theorem applies. Testing the factorization proves the displayed Fourier coefficient of a measure on the circle identity. The convolution of two probability measures is again a probability measure. On these measures convolution preserves simultaneous convergence in the weak-star topology: multiply the converging coefficients and use their common unit variation bound and dense trigonometric tests.
An integrable kernel is uniquely determined by its convolution operator on . Convolve it with a smooth compactly supported approximate identity , whose members also lie in . A zero operator makes , while translation continuity in Lp gives in , proving the assertion. Since the adjoint operator of convolution by is convolution by , this also proves the exact self-adjointness criterion almost everywhere, including necessity at the level of kernels.
Deconvolution is the inverse problem of recovering an input from a known response kernel and measured output . The convolution theorem turns it into , but division by a small amplifies noise and a zero of loses information in the corresponding mode. A unique stable inverse requires assumptions on the operator and admissible inputs; a formal Fourier transform quotient alone does not establish either property.
Tikhonov regularization of deconvolution can minimize separately at each frequency. Completing the square gives for . The regularization parameter trades reduced noise amplification against bias: the reconstruction multiplies the true noiseless component by and the noise by .
For , the convolution of the normalized interval indicator with the two-sided exponential isSplit the defining integral at in the interior case; outside the interval the absolute value has a fixed sign. These elementary integrals prove the formula and its continuity at the joining points. With Fourier transform convention , the convolution theorem gives , using its continuous value at . Parseval's identity can therefore turn the squared integral of this rational-trigonometric transform into a piecewise elementary real-space integral.
A convolution kernel is the fixed function in an operator . It specifies how shifted input values are weighted. The averaging kernel above has nonnegative values and integral one; arbitrary convolution kernels need not have either property. A linear time-invariant system uses its impulse response as a kernel when its output admits this representation.
Let be a Borel measurable function in L1 space on , and let be Lebesgue integrable. The function is measurable. Tonelli's theorem for and translation invariance of Lebesgue measure giveFiniteness justifies Fubini's theorem for the signed product, yielding . In particular an integrable odd function makes this signed total zero while the joint L1 norm can remain positive. The triangle inequality for an integral also gives the usual convolution estimate .
This integral smoothness condition on a convolution kernel controls how translations change the kernel away from the translation scale. It need not imply differentiability. Coupled with an operator bound, it yields a weak type (1,1) bound through the Calderón–Zygmund decomposition. It is distinct from the bracket-generating condition for differential operators also named after Hörmander.
A measurable convolution kernel satisfying the displayed size and cancellation properties together with the Hörmander integral kernel condition defines uniformly bounded Fourier multipliers after deletion of a ball at the origin. The deleted-ball kernels belong to , although they need not belong to at infinity. Cancellation controls low-frequency integration near the deleted ball; translation by half an oscillation controls the far tail through the oscillatory tail estimate for a singular kernel.
For set , and take . Translation by reverses the oscillatory exponential's sign. Comparing the original annulus with its translate gives twice the integral as an integrable kernel difference plus boundary-shell errors. The shell errors are bounded by . The displayed estimate follows by enlarging the constant. Its right-hand side tends to zero as , proving convergence of the Fourier integral's improper far tail without absolute integrability of itself.
Suppose a convolution operator has operator norm at most , and its kernel satisfies the Hörmander integral kernel condition with constant . Under hypotheses making its integrals well-defined, the Calderón–Zygmund decomposition gives weak type (1,1). Indeed, the bounded part has squared norm at most . The bad cubes occupy at most , while outside their dilations the cancellation estimate outside a dilated cube bounds the bad image in . Applying distributional estimates to these three regions gives .
If obeys the Hörmander integral kernel condition with constant , and an integrable is supported in a cube with , then for . Here is the concentric cube with multiplied side length. Subtract the kernel value at the cube center inside the convolution; outside , every source displacement is smaller than half the observation displacement. Tonelli theorem and the integral kernel condition give the bound.
For the Fourier transform convention , integration gives , with value one at zero. The convolution theorem makes the transform of the -fold convolution its th power. This is a simple way to construct compactly supported functions with prescribed polynomial Fourier decay.
A periodic convolution operator with continuous periodic kernel is compact on , since its kernel is square integrable. In the normalized Fourier series basis it is diagonal, with multipliers . These multipliers include the full integral rather than its normalized Fourier coefficient.
With , periodic functions have the displayed convolution identity for every real . Apply the polarized Parseval identity to and ; a change of variable gives the latter function's pairing with . The Cauchy-Schwarz inequality bounds the sum of absolute coefficient products by , so the resulting series converges absolutely and uniformly. This proves continuity of the convolution even though neither original Fourier series need converge pointwise.
When all multipliers are nonzero, the Moore–Penrose inverse of an operator acts by dividing each Fourier coefficient by . Its data domain is precisely the square-summability condition displayed. The dense range need not be closed, and writing the formal inverse series does not establish the Picard criterion.
For a continuously differentiable periodic kernel, integration by parts and the Riemann-Lebesgue lemma give . Nonperiodic data with have Fourier coefficients asymptotic to a nonzero multiple of . Their inverse coefficients therefore fail square summability, and there is no Hilbert-space inverse or least-squares minimizer. Periodic exponential data instead give the single-mode solution .
If is a compactly supported distribution and is any distribution, define . The inner function is smooth and supported in , hence is a test function for . Finite-order estimates prove continuity, while the tensor product of distributions proves commutativity after inserting compact cutoffs. For every test function , ; evaluating at zero against reflected test functions proves uniqueness. If both distributions have compact support, and the convolution theorem gives . Without a compact factor or another support/growth condition, arbitrary distributional convolution is not generally defined.
If at least one of is a compactly supported distribution, thenThe sums are Minkowski sums. The first rule follows from the pairing : a test function away from the support sum gives zero. For the second rule, localize the output to a small compact set avoiding the sum of the singular supports. The relevant pairs of input points form a compact set because one input support is compact. Cover it by finitely many product neighborhoods on each of which at least one input distribution is smooth; otherwise the output would meet the sum of the singular supports. Smooth cutoffs in these neighborhoods decompose the localized pairing into finitely many convolutions with a smooth compactly supported factor. Each is smooth by smoothing convolution with a test function. This proves the second rule locally.
The same argument works when addition is a proper map on the product of the two supports. Some condition defining the convolution is necessary; arbitrary pairs of distributions cannot always be convolved.
Target: Cauchy kernel fundamental solution. Parent: Fundamental solution of a linear differential operator. Intended file: distribution-theory.bigb.For a distribution and a compactly supported smooth kernel, differentiation with constant coefficients commutes with convolution wherever the kernel support stays inside the domain. The identity follows by testing against the translated kernel and tracking the sign of its derivative. A variable coefficient must remain inside the product before convolution; in general .
For any distribution and any test function , the convolution is a smooth function. On a compact set of values, the translated test functions and all their derivatives have supports in one fixed compact set, so distributional continuity permits every derivative:For constant-coefficient operators, . Hence a fundamental solution of a linear differential operator supplies a smooth particular solution for every compactly supported smooth datum. No temperedness of is needed.
If a Lebesgue-measurable set has positive measure, then its difference set contains an open neighbourhood of zero. For finite measure, the convolution is continuous and positive at zero; the general case follows by taking a finite positive-measure subset.
If a measurable set has measure , then for the sets and lie in an interval of length , soThus . This quantitative overlap argument is a bounded form of the Steinhaus theorem.
An approximate identity is a family of integrable kernels whose total mass is one and whose mass concentrates near zero as . Under standard hypotheses, converges to in norm and at almost every Lebesgue point.
A sequence of continuous periodic functions satisfying the displayed conditions, with normalized Haar measure and every , is a summability kernel. For in a homogeneous Banach space on the circle, subtract from its convolution with . Translation continuity controls the resulting integral near zero, while boundedness by and the vanishing tails control its complement. Thus . The nonnegative Fejér kernel is an example with norm one.
Let nonnegative integrable functions on satisfy and for every . If is a bounded function and continuous at zero, and the products are integrable, then . To prove this, subtract and split the difference integral at . The first piece is bounded by ; the second by . First use continuity to choose , then pass to the limit in . The normalization term also vanishes.
For , the Gaussian integral shows that has these properties. The factor two compensates for retaining only the nonnegative half of the full normalized Gaussian profile. Replacing it by would instead give limiting mass .
For , an integer , and a normalized nonnegative mollifier , put . If , its mollification is smooth and converges to in the Sobolev norm. The definition of a weak derivative and Fubini's theorem give for every multi-index with . The approximate identity theorem in the Lp space applied to these finitely many weak derivatives proves the claim. On a domain with boundary this direct convolution argument applies only away from the boundary unless an extension is first supplied.
For a bounded Fourier multiplier operator on and a bump function , the displayed convolution identity follows by multiplying Fourier transforms. The convergence holds in and almost everywhere by the approximate identity theorem, after accounting for the integral of the kernel. The limit is when . Smoothness and compact support alone do not imply this normalization.
If and is bounded and continuous at zero, the positive kernel has mass on , tending to one, and mass at most outside . Split the integral of at : continuity makes the near part arbitrarily small, and boundedness times the exponentially small tail controls the far part. This proves the displayed endpoint approximate identity. A shrinking cutoff still captures mass and therefore gives the same limit.
On the torus with normalized Haar measure, choose so that . The kernel is a nonnegative trigonometric polynomial. Its base has unique maximum four at the origin. Outside any fixed neighborhood its maximum is , while in a smaller neighborhood of positive measure it is at least some . Normalization consequently bounds the exterior kernel by , which tends to zero. Convolution with these kernels gives uniform trigonometric polynomial approximation to every continuous function on the torus.
In the distributional sense,This kernel is not positive, but testing it against a smooth compactly supported function and using the Dirichlet integral proves convergence.
If , then for nonzero the weighted series is absolutely convergent and its tail after is bounded by . This follows from and the reciprocal-square tail bound. For , the prefix multiplied by tends to zero by splitting at a fixed index where becomes small. The multiplied tail is bounded by , which tends to zero. Thus the whole multiplied series tends to zero as . Omitting from the unmultiplied tail bound is invalid.
The Cauchy approximate identity isIt is a probability density of total mass one, and its mass outside every fixed neighbourhood of zero tends to zero as . It therefore converges to the Dirac delta function as a distribution.
For sequences indexed by the integers, discrete convolution adds products whose indices sum to the output index:For finite sequences, treat every unspecified entry as zero; the sum then has finitely many nonzero terms. For infinite sequences, a convergence hypothesis is needed, for example absolute summability of both sequences.
Take at indices and at indices . Their convolution is at indices :Equivalently, : add an unshifted and a one-step shifted copy of . This explains the output by superposition, with every index included.
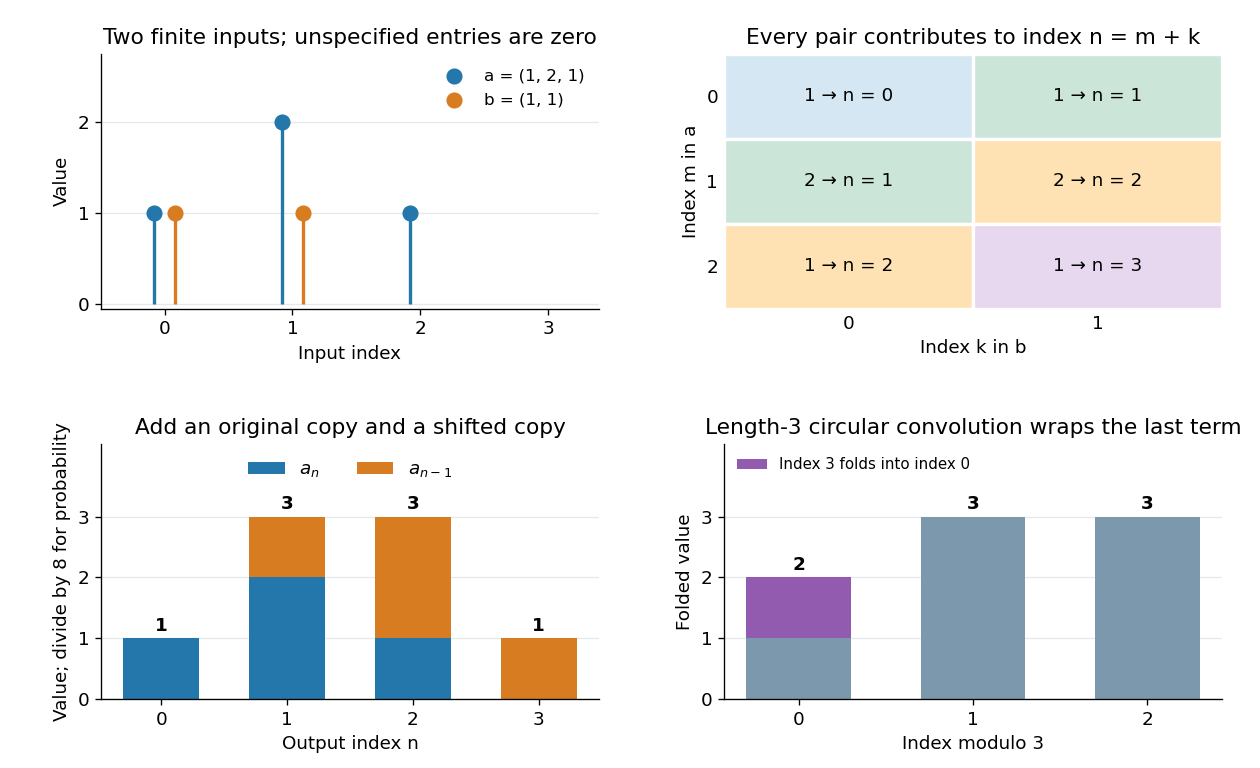
Discrete convolution combines index pairs, shifted copies, polynomial coefficients and outcome counts
. Details. The same products appear in polynomial multiplication and generating functions:A term times contributes to coefficient , precisely the index condition in discrete convolution. In probability, counts the outcomes of two independent fair coin tosses by their number of heads, while counts the outcomes of one more toss. Dividing the output by eight gives the probability mass function of the binomial distribution with and . No new arithmetic is needed to pass from coefficient multiplication to counting independent sums.
The full finite convolution is different from circular convolution, where indices wrap modulo a chosen length. Wrapping this four-term output to length three adds its last entry to its first and gives . When using a discrete Fourier transform to compute the full convolution, zero padding to length at least the sum of the input lengths minus one prevents this wraparound. [ref]
https://ocw.mit.edu/courses/res-6-008-digital-signal-processing-spring-2011/610905d8154ec2bfc090cf78022249a5_MITRES_6_008S11_lec10.pdf. Oppenheim, MIT Digital Signal Processing, Lecture 10, circular convolution and zero padding
For arrays indexed by -bit nonnegative integers, their XOR convolution is , where is bitwise exclusive or. If entries count choices of Grundy numbers, its repeated application counts sums of impartial games with a specified combined Grundy number. The Hadamard transform turns this operation into pointwise multiplication.
For arrays indexed by integers modulo , their cyclic convolution isWhen and count choices with respective residue classes and , the cyclic convolution counts pairs whose sum has residue class . Repeated cyclic convolution therefore counts sums of longer sequences. The discrete Fourier transform converts cyclic convolution into pointwise multiplication.
Circular convolution of two length- sequences uses modular arithmetic for their indices. Extending both inputs periodically gives the displayed formula. Equivalently, fold a finite discrete convolution into residue classes modulo by adding entries whose indices are congruent. The discrete Fourier transform of the circular convolution is the product of the two discrete Fourier transforms, with the usual unnormalized forward transform and inverse convention.
Zero padding extends a finite sequence by zero entries to a specified length. For input lengths , their full discrete convolution has length at most . Padding both inputs to allows circular convolution to represent this full result without folded entries.
For Lebesgue integrable functions on , use the Fourier transform convention . ThenThus the integral combining all translated products becomes an ordinary multiplication at each frequency. Different Fourier transform normalizations can place a constant in this identity; fixing the convention prevents that ambiguity. Its use in filtering is illustrated by [ref]
https://see.stanford.edu/materials/lsoftaee261/transcripts/TheFourierTransformAndItsApplications-Lecture09.pdf. Brad Osgood, Stanford EE261, Lecture 9, convolution and Fourier-domain filtering
.For the indicator function ,with . Therefore the triangular function has Fourier transform . The extra factor of the sinc function improves the large-frequency bound from a constant times to one times , matching the smoother output in the overlap picture. Fourier decay of repeated interval convolutions extends this calculation to further repetitions.
For a proof outline, Fubini's theorem permits exchanging the two integrals because the integral of over is . Set in the inner integral:The factorization of the complex exponential is the mechanism behind the simplification. The discrete convolution version similarly turns coefficient sums into products of generating functions.
For Schwartz functions and the Fourier transform convention , the displayed formula exchanges a pointwise product for a convolution. Substitute Fourier inversion for into the Fourier transform of . Fubini's theorem, justified by , givesUnlike the convolution theorem , this version cannot be asserted for arbitrary pairs in without additional hypotheses, since their pointwise product need not be an integrable function.
For and , split the convolution integral at and . The three contributions are , and . Evenness gives the displayed answer for all real .
With Fourier transform convention , one has . The convolution theorem and Fourier inversion theorem therefore yieldThe value at is . Multiplying by instead gives a normalized Laplace distribution; its self-convolution is the density .
For , the convolution of with the indicator of is outside the interval and inside it. With Fourier convention , their transforms are and . Fourier inversion therefore evaluates as .
For , induction in the convolution integral givesIts Fourier transform in the angular-frequency convention is .
Articles by others on the same topic

Convolution is a mathematical operation that combines two functions to produce a third function, representing the way in which the shape of one function is modified by the other. It is widely used in various fields, including signal processing, image processing, and machine learning.


