A finite optical record can bound later radiant energy if an independently justified exponential decay envelope applies at every later time. Let the recorded window end at , and suppose the true nonnegative radiant power satisfiesIntegration gives the exponential-envelope tail-energy boundEquality holds when the entire tail follows the envelope. This is a bound on an unobserved contribution, not automatically a standard uncertainty or a probabilistic interval.
For an original numerical example, suppose the energy inside the recorded window is known to lie in , while a justified envelope has and . The missing contribution is at most , so the total laser pulse energy lies in . The optical energy outside a time gate fraction, considering only this late contribution, is at most . Any unobserved early energy requires its own bound.
One way to justify the envelope mathematically is a differential inequality for an exponential tail envelope. Suppose is absolutely continuous on each finite interval after , , and almost everywhere. Multiplying by the integrating factor givesso . The decay law must apply throughout the unobserved region; it is a physical assumption to validate, rather than a consequence of fitting the last few samples.
The distinction is testable by a counterexample. Append a later nonnegative pulse whose support lies entirely beyond the recorded interval. Its energy can be arbitrarily large while every recorded sample is unchanged. Such a pulse violates the global envelope but cannot be excluded by a good local exponential fit alone. Similarly, an envelope with a positive constant background has an infinite integral over an infinite time interval. A finite observation horizon or an adequately defined and validated background subtraction is then essential.
Uncertain envelope parameters require a bound valid for their allowed combinations. If the allowed set is the rectangle and , then . For and , this is and the preceding total interval becomes . More restrictive joint parameter constraints can tighten this result; inserting separate best-fit values does not establish a guaranteed bound.
Finally, an electrical tail need not be an optical tail. In an original idealized linear time-invariant system, let a photodetector have unit-area impulse response for , and zero otherwise. An impulsive optical input , with the Dirac delta function, gives the calibrated output by convolution. Its electrical tail after has area even though all incident optical energy arrived at time zero. This optical tail and detector-response ambiguity requires a separate response measurement. NIST's historical procedure characterized the photodetector, cable and oscilloscope together before convolving measured responses with trial waveforms. Appendix C describes typical optical excitation of about , a photodetector rise time near , and a oscilloscope with rise time. The optical excitation was much shorter than the detector response, while the oscilloscope was fast enough that the detector dominated the measured waveform. Response data were collected at each gain setting and several signal levels.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
Optical tail and detector-response ambiguity arises because a measured temporal trace combines the optical waveform with the receiver's dynamics. In a calibrated linear time-invariant system,where is incident radiant power and the unit-area detector impulse response. One trace does not generally identify both unknown functions. The parent bounding unobserved optical energy with an exponential tail model gives an impulsive-input example; two finite-width profiles provide another exact ambiguity.
Define for , and zero otherwise. Consider model A with optical power and detector response , and model B with these two time constants exchanged. By commutativity of convolution, both give exactlyTheir optical energies after are nevertheless and . For original chosen , those are about and . Identical recorded tails therefore coexist with very different true late optical energy.
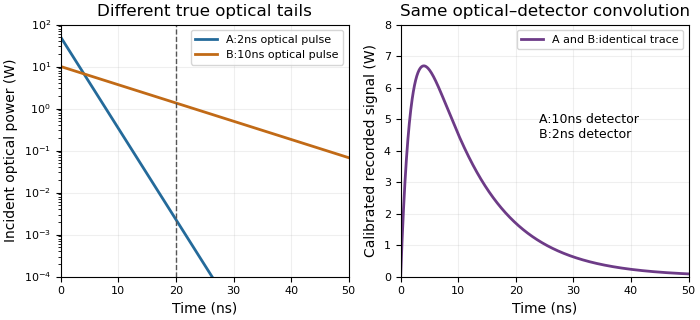
Different optical tails and detector responses can produce the same measured pulse
. Original unit-area exponential response models. Model A has a2ns optical time constant and10ns detector time constant; model B exchanges them. Both incident pulses have100nJ total energy. The measured convolution is identical despite different optical energy after20ns. Source. Details.
Known-input calibration of a pulse detector supplies information missing from this inverse problem. NIST measured the detector/cable/oscilloscope response with optical excitation much shorter than the response before calculating waveform distortions.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1 and bandwidth-correction procedure
The example above is an independent mathematical construction. A fitted electrical decay constant alone cannot establish a global optical-tail envelope.Known-input calibration of a pulse detector uses a characterized optical waveform to separate the incident signal from the receiver response. In a linear, baseline-corrected model,where is known input power, a normalized impulse response and the overall responsivity. Recording the complete response givesThus a known reference energy calibrates the area gain without requiring the input to be an ideal impulse. Shape calibration additionally uses the reference waveform.
For nonnegative normalized profiles with finite second moments, define and . Since , their temporal variances satisfy . In an original chosen example, an input standard deviation and recorded deviation imply . Treating that finite input as a delta impulse would incorrectly assign the full to the detector. This finite-input correction in pulse-detector calibration concerns standard deviations; a universal subtraction rule for arbitrary FWHM values does not follow. Negative ringing also invalidates the nonnegative-profile interpretation used for the variance identity.
NIST's primary procedure illuminated the detector with a pulse much shorter than the detector response and characterized detector, cable and oscilloscope together at the relevant gain and signal levels.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. §§6.1–6.2; Appendix C.1–C.2, printed pp. 36–37, Figure C1 and measurement procedure
Such a known input breaks the optical tail and detector-response ambiguity described by the parent article.In the frequency domain, the same model is . Division can estimate where the input spectrum is known and sufficiently nonzero; small input components amplify measurement noise. A short reference pulse is useful because it excites a broad frequency range, but detector linearity, baseline, area coverage and reference uncertainty still need checking.
Finite-input correction in pulse-detector calibration removes the known input duration from an inferred receiver width, while propagating uncertainty in both widths. Under the nonnegative, normalized, finite-variance convolution model of known-input calibration of a pulse detector,where is the known input profile, the measured output and the receiver's impulse response. The subtraction concerns temporal variances, not arbitrary reported full widths.
Differentiating on the positive-width branch givesFirst-order propagation of standard uncertainty therefore yieldsThe covariance matters when both widths use the same timebase or fitted reference.[ref]
An original near-resolution example has and , each with independent standard uncertainty . The corrected receiver width is and its propagated standard uncertainty is about , or . Width measurements individually precise to about one percent can thus give a much less precise difference-derived width.
NIST's primary bandwidth-correction procedure used roughly 120 ps optical inputs and recorded the detector, cable and oscilloscope as one response chain at different gains and signal levels.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1 and steps 1–7
A sufficiently short characterized input reduces this resolution-limit conditioning in finite-input detector calibration. Near a zero variance difference, linear uncertainty propagation may fail; a nonpositive measured difference does not represent a negative physical detector width. Report an interval or limit under the stated model rather than silently replacing the difference by zero. Negative ringing also violates the nonnegative-profile assumption behind the variance subtraction.Resolution-limit conditioning in finite-input detector calibration is the sensitivity of a small inferred detector width to uncertainty in two nearly equal measured widths. In finite-input correction in pulse-detector calibration, the nonnegative normalized convolution model givesThe signed relative sensitivities areThey diverge as the measured output width approaches the known input width . Subtracting two well-measured squared widths can therefore be a poorly conditioned inference.
For an original example, and give and . The two relative sensitivity coefficients are about and . A small independent fractional width error can produce a much larger fractional response-width error; a common multiplicative timebase error instead partly cancels because the coefficients sum to one. Correlations must therefore be retained.[ref]
Near the boundary, report uncertainty in the variance difference before transforming it. For a chosen interval , imposing the physical constraint gives a detector-width interval , approximately . A coverage-preserving detector-width bound from a variance interval uses this monotone square-root transformation on the physical intersection. It need not resemble a symmetric error bar around a point estimate. An interval wholly below zero contains no admissible width under this model; replacing it silently with a zero-width result hides the inconsistency.
NIST characterized its detector/cable/oscilloscope chain with an optical pulse much shorter than the receiver response.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37; approximately 120 ps optical input and Figure C1
That design avoids subtracting two nearly equal broad widths. The variance identity still requires nonnegative profiles and finite second moments; arbitrary full widths at half maximum and responses with negative ringing need a different model.A coverage-preserving detector-width bound from a variance interval transforms uncertainty in a nonnegative response variance without imposing a symmetric width error bar. Let and let a random interval have stated frequentist coverage for . Define the width confidence set byFor the true width ,The events are identical, so their coverage probabilities are identical. The transformation does not create coverage that the original interval lacked. Resolution-limit conditioning in finite-input detector calibration explains why working with the variance difference first is useful near a barely resolved detector response.
For an original explicit measurement model, suppose has a normal distribution with mean and known standard deviation . A reading gives an approximately 95 percent interval . Intersecting with the physical range and taking square roots gives . This is an assumed normal model for measuring , not a claim that any difference of fitted squared widths is automatically normal.
If the entire variance interval is negative, the result is an empty physical confidence set for a detector variance difference. Do not replace its negative upper endpoint by zero and report an apparently exact zero width: that changes the confidence-set construction. An empty realization signals disagreement between that interval and the physical parameter range; it can occur even in a valid procedure on an occasional sample that misses the true value.
NIST distinguishes a standard uncertainty from an interval with a justified confidence level and explains the distributional assumptions behind a coverage factor near two.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. §§6.2–6.3, Expanded Uncertainty
The normal interval above needs its stated model; the monotone transformation proof itself does not. Application to a detector additionally requires the nonnegative-profile convolution assumptions of finite-input correction in pulse-detector calibration; a correct statistical transformation cannot repair an invalid physical variance identity.An empty physical confidence set for a detector variance difference occurs when the entire reported interval for the inferred response variance lies below its admissible range. In the nonnegative-profile detector model, . An interval gives a physical width setIt is empty exactly when . The coverage-preserving detector-width bound from a variance interval proves why this intersection and transformation retain the original coverage event.
For an original reading, suppose an explicitly normal measurement model for gives with known standard deviation . The approximately 95 percent interval contains no nonnegative variance. This is disagreement between that interval and the physical model, not a negative physical detector width or an exact measurement of zero width.
Empty sets can occur occasionally even when the model is correct. If and , thenwhere is the standard normal cumulative distribution function. At the physical boundary and , the probability is about ; at it is about . The boundary probability of an empty detector-width confidence set explains why one empty realization is not a logical disproof of the detector model.
Replacing an empty set by the point zero changes the procedure. It must not be presented as though the original interval precisely determined that point. NIST likewise distinguishes an uncertainty interval from an automatically justified confidence level, emphasizing the distributional assumptions behind coverage factors.[ref]
In practice, examine the width estimates, their correlations and the physical convolution assumptions, while retaining the actual negative interval in the measurement record. NIST's short-input receiver-response measurement illustrates how an independently characterized input helps resolve detector broadening.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1
Neither clipping the estimate nor declaring the response model false follows solely from the sign of one noisy variance difference.The boundary probability of an empty detector-width confidence set is the chance that a valid uncertainty procedure yields no admissible nonnegative response width when the true variance difference is at its boundary. Under the explicit model , , take the central interval . The empty physical confidence set for a detector variance difference occurs when its upper endpoint is negative:This probability decreases with , so the largest value over the physical parameter range occurs at . If is the usual two-sided normal critical value, the boundary probability is .
At that boundary the other way to miss zero is a strictly positive lower endpoint. The two tail events are disjoint and each has probability ; the remaining probability produces a confidence set containing zero. The joint probability of empty and strictly positive detector-width intervals therefore accounts for the full two-sided noncoverage, not just the empty cases.
For an original repeated-measurement calculation, use and 400 independent measurements of a stipulated zero response-variance difference. The expected number of empty physical sets is approximately ten, with standard deviation , where . The count follows a binomial distribution only under the stated independent, common-probability model. Roughly ten additional intervals are expected to lie wholly above zero. Their existence is compatible with approximately 95 percent coverage at the boundary.
For an interior example , the empty-set probability falls to . Empty results are thus most common near the resolution boundary, where subtracting similar measured variances is already delicate.
NIST explains that interpreting expanded uncertainty as a confidence interval requires distributional assumptions.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. §§6.2–6.3, Expanded Uncertainty
These probabilities assume an actual normal model with known ; they are not inferred merely from an error bar labelled standard uncertainty. Correlation, systematic offsets or a misspecified detector response can change the repeated-measurement behavior. Retaining empty results in the record allows that behavior to be assessed rather than hiding it by replacing them with zero-width estimates.The joint probability of empty and strictly positive detector-width intervals must distinguish outcomes of one measurement from counts across repeated measurements. For one normal variance-difference estimate , let . An empty physical width set requires ; a strictly positive interval requires . Those events are disjoint for that same interval, so their intersection has probability zero.
Writing and for the standard normal cumulative distribution function, the three category probabilities areThe last category is an interval containing zero. At and a central interval, these become , as in boundary probability of an empty detector-width confidence set. For interior , the categories describe the relation to zero; they are not themselves the coverage categories for the true positive value.
For independent repetitions with the same probabilities, the counts have a multinomial distribution. For nonnegative integers summing to ,Although the measurement repetitions are independent, their category counts are not. An empty and a positive indicator cannot both equal one in the same repetition, givingThis negative covariance of empty and positive detector-interval counts follows from the fixed total count.
For an original example, take 20 independent boundary measurements with exact central 95 percent normal intervals. Then . Each count has mean , and their covariance is . The probability of exactly one empty and one strictly positive interval is , about . It is not zero, unlike the intersection of those two outcomes for a single interval.
NIST's uncertainty guidance emphasizes the assumptions needed to assign confidence levels.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. §§6.2–6.3, Expanded Uncertainty
The joint-count calculation above additionally assumes independent repetitions with a common normal model; shared calibration errors can invalidate that independence even when each marginal interval is computed in the same way.The negative covariance of empty and positive detector-interval counts arises because a fixed number of measurement intervals is divided into mutually exclusive categories. Let indicate that interval is respectively physically empty or strictly positive. The same interval cannot satisfy both, so andFor independent repetitions with common probabilities, the counts and therefore haveThe joint probability of empty and strictly positive detector-width intervals gives the underlying multinomial model. The sign describes category-count dependence, not physical antagonism between two detectors.
For an original boundary example, take and . Each count has variance , while their covariance is . The total tail-category count has variance . Treating the two counts as independent would give instead. The covariance is needed even though the individual measurement repetitions are independent.
Conditioning on the total is important. If the number of repetitions is random and independent of the category assignments, the law of total covariance givesAn independent total with a Poisson distribution has equal mean and variance, making this covariance zero; a more variable total can make it positive. This is a different sampling protocol, not a contradiction of the fixed-total formula.
Shared calibration drift is another change of model. Repetitions may then have dependent category indicators, and cross-repetition covariance terms must be added. Overdispersion of detector-interval counts under shared drift can make a simple multinomial analysis inadequate.
NIST's measurement guidance retains common influences in uncertainty propagation and requires assumptions for confidence-level interpretation.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. Appendix A, equation A-3; §§6.2–6.3, Expanded Uncertainty
State whether the repetition total is fixed, how the categories are defined and which calibration influences are shared before interpreting their empirical count covariance.Effective repetition count across independent calibration blocks accounts for dependence confined to each acquisition block rather than shared by every stored trace. Suppose block contains empty-interval indicator random variables, all with common probability and within-block correlation coefficient . Assume different blocks are independent. With , summing within-block covariances givesMatching this to the variance of an average of independent indicators yieldsFor equal blocks of size , this reduces to . The denominator involves the block size, not the total ; the single-block expression in effective repetition count for detector intervals with shared drift must not be applied as though the same drift state affected every block.
For an original comparison, fix and . One block gives . Six independent blocks of twenty give . Six very uneven blocks of sizes instead giveAll three designs store the same number of traces. The difference comes from how often the same fluctuating condition is reused. For fixed , , and positive , minimizing favors balanced blocks; this motivates optimal allocation of detector repetitions across calibration blocks when block-preparation costs also matter.
Independence must come from the physical acquisition model. Starting another file does not erase a shared clock, reference calibration, or slowly varying environmental influence. NIST's uncertainty law retains shared-input covariance explicitly.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. Appendix A, equation A-3
If drift persists between nominal blocks, those cross-block terms must be added and the displayed formula changes. A cluster bootstrap likewise requires blocks that are suitable independent resampling units.Optimal allocation of detector repetitions across calibration blocks chooses block sizes using the dependence and acquisition-cost model, not just the desired number of stored traces. For fixed total , number of independent blocks , common success probability, and positive within-block correlation , effective repetition count across independent calibration blocks givesMaximizing it is equivalent to minimizing . If two integer block sizes differ by at least two, transferring one repetition from the larger to the smaller decreases that sum by . Therefore the optimal integer sizes differ by at most one.
For an original fixed-count example, and give balanced sizes . At , their effective count is . Sizes give only under the same assumptions.
More independent blocks can help, but preparing one may consume time. In a continuous planning model let each block cost setup time , each repetition cost , and each block contain repetitions. With total time , the effective count becomesFor , differentiation gives the interior choice . Integer block counts, minimum sizes, and hardware restrictions must subsequently be imposed.
For chosen , , and , the continuous optimum is feasible with ten blocks and gives . Single-repetition blocks give 18, while two blocks of 81 repetitions also give 18. These are model-based comparisons, not measured apparatus timings.
Unequal block noise or different drift correlations require unequal-noise allocation across calibration blocks. Independence between prepared blocks must also be justified by the reference and environmental model; NIST explicitly retains shared-input covariance.[ref]
Unequal-noise allocation across calibration blocks distributes repetitions using block-specific variability while keeping the intended estimator fixed. Suppose independent blocks supply means and the target estimate is with specified weights . Let one observation in block have variance and equicorrelation within that block. ThenThe first sum is a block-specific floor; only the second decreases with repetition count. Changing the estimator weights merely to improve this calculation could change the estimand, so they remain fixed here.
For continuous positive allocations with positive costs , budget and , a Lagrange-multiplier calculation givesFor equal observation costs, repetitions are proportional to , not to the variance itself. Minimum counts and integer rounding must subsequently respect the actual acquisition constraints.
For an original two-block example, take , equal costs, , independent readings within each block, and standard deviations and in the output unit. The optimal counts are and , giving variance instead of from fifty each. If both within-block correlations are instead , the same proportions give variance , while equal counts give . The common-error floor now dominates and cannot be eliminated by taking more observations inside those same blocks.
This extends optimal allocation of detector repetitions across calibration blocks, whose balanced solution used homogeneous noise. For binary detector indicators, the per-reading variance is ; differing probabilities require a clearly specified weighted target. The planning variances and correlations must come from an appropriate measurement calibration model, not merely from counting files as independent blocks. NIST's uncertainty propagation retains shared-input covariance for exactly this reason.[ref]
An exponential-envelope tail-energy bound limits unobserved energy by integrating a justified pointwise envelope on the true optical power. If for every , with and , then . The parent bounding unobserved optical energy with an exponential tail model derives this result and distinguishes it from a statistical uncertainty.
At a later acquisition endpoint , the remaining allowance isFor an original envelope with and , the initial allowance is . Reducing the allowed missing energy to requires . This acquisition duration from an exponential tail-energy tolerance reduces the bound by a factor100. It does not prove that99% of an arbitrary underlying pulse has been captured: the actual power may lie strictly below the envelope at early times.
Joint parameter constraints also matter. An original allowed set uses dimensionless and with , and . Since , every allowed envelope satisfiesattained at . Taking separate maxima and would instead give the looser bound; those two maxima cannot occur together in the stated joint set.
The guarantee concerns optical power, not an uncorrected detector tail. Optical tail and detector-response ambiguity explains that distinction, while NIST's primary response-calibration procedure characterizes the electrical measurement chain separately.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
A delayed extra pulse or an unbounded constant background requires its own model; neither is excluded by a local exponential fit.An acquisition duration from an exponential tail-energy tolerance chooses how long to continue recording when a validated optical-power envelope bounds the remaining energy. Suppose after time the true power satisfies , with and . The exponential-envelope tail-energy bound gives a remaining allowance after extension . For tolerance ,This is a conditional upper-bound calculation, not an inference from the last sample merely falling below a detector threshold.
An original uncertainty example has guaranteed parameter limits and . The remaining allowance increases with either parameter, so a tolerance requires . Using only best-fit values and would give about , which does not guarantee the same tolerance over the allowed set. Joint parameter constraints can tighten a bound, but their coverage must be justified.
In the positive-duration branch, the local sensitivities areThis acquisition-time sensitivity to tail-model parameters explains why an uncertain slow decay can matter more than a small amplitude correction. The derivatives change interpretation at the zero-duration boundary.
The envelope must apply to optical power throughout the unrecorded region. A later pulse or an unremoved persistent background can invalidate it. NIST's separate measurement of detector response illustrates why an electrical waveform's decay alone is insufficient.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
State the chosen time origin, tolerance units, valid envelope parameters and any other excluded intervals when reporting the acquisition requirement.Acquisition-time sensitivity to tail-model parameters measures how an inferred recording extension changes when the assumed optical tail changes. In the positive-duration branch of acquisition duration from an exponential tail-energy tolerance, writeHere bounds the initial tail power, is its decay time and the tolerated missed energy. Their first-order relative effects areThese logarithmic condition numbers of a tail-acquisition requirement distinguish a fractional amplitude error from a fractional decay-time error. For a stringent tolerance with large , decay-time sensitivity stays near unity while amplitude sensitivity decreases.
For an original example, take , and . Then and . Let the independent standard uncertainties of and be and , with the tolerance fixed. The amplitude contribution to is ; the decay-time contribution is . Adding their variances gives , about .
Correlated fitted parameters require covariance terms in this propagation.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. Appendix A, equation A-3
A standard uncertainty is not a guaranteed recording margin: a worst-case requirement needs a justified allowed parameter set, as in the parent article. The zero-duration boundary is also outside this smooth positive-branch calculation.Physically, these parameters must describe the unrecorded optical power, not merely an electrical detector tail. NIST separately measured the detector/cable/oscilloscope response before correcting pulse measurements.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
A precise fit to the wrong response component does not justify the optical envelope or its acquisition-time bound.Logarithmic condition numbers of a tail-acquisition requirement quantify the fractional response of a positive recording extension to fractional parameter changes. For with , define the signed sensitivity . ThenTheir absolute values are componentwise relative condition numbers. Acquisition-time sensitivity to tail-model parameters gives the corresponding dimensional derivatives and uncertainty propagation.
These numbers depend on which coordinates are held fixed. If denotes the initial tail-energy allowance, then . In coordinates , the decay-time sensitivity at fixed is exactly one, rather than . This is the same physical formula: holding fixed while changing also changes . Transforming the parameter covariance consistently leaves the propagated output uncertainty unchanged.[ref]
An original boundary example takes and . The required extension is only , but . Increasing by multiplies the ratio by , giving and doubling the required extension exactly. Its relative change is large because the original extension was very small.
This does not mean the absolute requirement is singular there. In the active branch remains finite. At and below the threshold, the physical extension is zero, so is undefined. A logarithmic tail-duration change at the zero-extension boundary must instead use the piecewise requirement or absolute changes. Large relative conditioning alone is not evidence of a large absolute recording-time risk.
Finally, conditioning describes the stated envelope model, not its experimental validity. The optical power tail must be distinguished from detector response, which NIST measured independently in its pulse calibration procedure.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
A well-conditioned calculation based on an invalid optical envelope still gives an unjustified acquisition guarantee.Logarithmic tail-duration change at the zero-extension boundary describes a recording requirement whose input ratio crosses the point where no further acquisition is needed. For fixed decay time , put and . The physical extension isHere the logarithm applies to the input ratio, not to a zero output duration. Logarithmic condition numbers of a tail-acquisition requirement applies only where .
At , the left derivative is zero and the right derivative is . The directional derivative of a clipped logarithmic acquisition time along a signed input change isThus no single ordinary derivative describes threshold-crossing perturbations. Nevertheless, the duration is stable in absolute units:This follows because the positive-part map has Lipschitz continuity with constant one.
For an original interval example, take and a justified input-ratio range . The corresponding duration range is . Its lower part is clipped at zero. Linearizing only on the zero-duration side would incorrectly predict no possible extension even though the allowed set crosses the threshold. A relative error divided by a nominal is undefined, while this absolute bound remains meaningful.
If is uncertain too, optimize the full expression over the justified joint parameter set rather than treating this fixed- inequality as a complete uncertainty analysis. The tail model must bound optical power throughout the missed interval. NIST's calibration apparatus measured detector/cable/oscilloscope response separately, illustrating why a recorded electrical decay cannot automatically certify such an optical envelope.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
The clipping analysis is an original property of the stated conditional acquisition model.The directional derivative of a clipped logarithmic acquisition time describes the first-order recording extension when several envelope parameters change together at the acquisition threshold. For positive , writeThe logarithmic tail-duration change at the zero-extension boundary article treats a fixed decay time and logarithmic input coordinate. Here consider a boundary point and an additive parameter direction .
The one-sided directional derivative uses positive step sizes:The logarithmic chain rule gives the expression inside the maximum. Differentiating the prefactor contributes zero at the boundary because the clipped logarithm there is zero.
For an original example, let , and . Increase amplitude in direction while decreasing decay time in direction , with . The net fractional direction is , so per unit step. Reversing the direction gives derivative zero, not .
The derivative is positively homogeneous in the direction but is not linear, so no single gradient represents all threshold-crossing perturbations. Above threshold the usual smooth derivative applies; strictly below threshold all sufficiently small changes leave the extension zero. Gaussian input uncertainty at a clipped acquisition-time threshold can consequently produce a mass of outcomes exactly at zero rather than a symmetric distribution around a nominal duration. The directional calculation alone does not assign a confidence level.
This is a conditional optical-envelope calculation. Separating optical power from the receiver's electrical response remains necessary before its parameters describe missed light. NIST independently characterized the detector/cable/oscilloscope response in its pulse calibration procedure.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
A derivative can describe parameter sensitivity accurately while the envelope itself still needs experimental justification.Gaussian input uncertainty at a clipped acquisition-time threshold produces a mixed output distribution rather than an ordinary Gaussian error bar. Hold the decay time fixed and assume the logarithmic input ratio has distribution , with . The required extension isThe directional derivative of a clipped logarithmic acquisition time explains the kink; here the full input distribution is propagated through it.
Writing and for the standard normal cumulative distribution function and density, respectively,For the continuous part has density . It integrates to less than one because the remaining probability is an atom at zero. Treating this density alone as the entire distribution loses that atom.
At the nominal threshold , half the outcomes are zero and the conditional positive part has a half-normal distribution. Direct integration of the normal density givesFor an original example, and logarithmic standard deviation give mean extension about and standard deviation , although inserting the nominal input into the clipped formula gives zero. The probability of an extension above is .
The quantiles of a clipped Gaussian acquisition duration must likewise include the zero atom. A symmetric interval around the nominal zero duration cannot represent these probabilities. NIST's uncertainty discussion stresses the need to know and combine input distributions when assigning an interval probability.[ref]
This is a stated uncertainty model for a conditional recording requirement, not a worst-case optical-energy guarantee. Uncertain decay time, correlation among the original envelope parameters or a non-Gaussian logarithmic ratio requires the corresponding joint propagation instead. Establishing the optical envelope remains a separate experimental task.
Quantiles of a clipped Gaussian acquisition duration assign probability levels to a recording extension whose distribution has a point mass at zero. Under the model of Gaussian input uncertainty at a clipped acquisition-time threshold, let , , and for fixed . Its zero mass is .
Using the lower generalized quantile for givesEquivalently, . The constant branch is essential: directly using a negative untruncated normal quantile would assign an impossible negative duration. SciPy's normal-distribution documentation identifies
ppf as the inverse cumulative distribution function used for the Gaussian part of this calculation.[ref]For an original threshold example, take , and . Half the probability is at zero, so the median is zero. The 90th and 95th percentiles are approximately and . The one-sided interval has probability under this stated model.
A nominal equal-tail 95 percent construction behaves differently: actually contains probability . Its lower endpoint includes the entire zero atom instead of excluding a 2.5 percent lower tail. This coverage excess from central quantiles at a zero-duration atom is a property of the mixed distribution, not a rounding error.
Quantiles describe uncertainty in the conditional acquisition requirement. They are not automatically a frequentist confidence set for an unknown fixed physical duration, nor a worst-case guarantee on unrecorded optical energy. NIST explains why an interval's probability interpretation requires the underlying distributions and assumptions.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. §6.3, Expanded Uncertainty
Propagate any uncertainty in decay time or other envelope parameters jointly before applying this fixed- formula.Coverage excess from central quantiles at a zero-duration atom is the additional distributional probability included when a closed quantile interval captures an entire point mass at zero. Here coverage means probability under the stated duration model. For with , the zero mass is and the positive part is continuous. Let , , and use the lower quantiles from quantiles of a clipped Gaussian acquisition duration.
For the closed central interval , its probability isTo verify this, write the probability as . When both endpoints are positive, the lower left limit is and the upper value is . Once the lower endpoint is zero, its left limit is zero; if the upper endpoint is zero too, the interval contains exactly the zero atom. Endpoint inclusion is therefore part of the probability calculation.
For a nominal 95 percent central construction, zero masses , and give actual probabilities , and respectively. In the middle case, the excess is , not the whole atom: the interval already includes the probability between zero and the upper quantile.
As an original dimensional example, set , and , giving . The nominal central 95 percent interval is approximately and contains probability . SciPy documents the normal cdf and inverse-cdf ppf used to evaluate these Gaussian-component values.[ref]
SciPy 1.16.2 documentation. scipy.stats.norm, Methods: cdf and ppf
A one-sided upper interval or a separately specified probability construction can target a different included probability. Randomized endpoint inclusion at a zero-duration atom would require an explicit randomization rule, not a change made silently after seeing an endpoint equal zero. NIST explains why interval interpretation requires the input distributions and the chosen construction.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. §6.3, Expanded Uncertainty
Distributional probability for this conditional acquisition model is separate from a worst-case optical-energy guarantee or a confidence procedure for an unknown fixed parameter.Randomized endpoint inclusion at a zero-duration atom adds an independent random decision about whether an interval contains the atom, allowing an exact included probability under a specified distribution. Let the duration have zero mass and a continuous positive part. For a nominal central level , put , and assume . Choose upper endpoint with .
The coverage excess from central quantiles at a zero-duration atom shows that the closed set has probability , while has probability . Draw an independent and reportThen the joint probability over both and the auxiliary random draw isThe independence assumption is essential to the multiplication .
For an original example, let and . The endpoint is included with probability . The positive part contributes probability and randomized zero inclusion contributes , totaling . An individual reported set is still either closed, with duration-model probability , or open at zero, with probability . Exact applies to the randomized procedure jointly, not conditionally to each realized set.
The distribution sensitivity of randomized zero-endpoint probabilities matters if or the upper endpoint is estimated inaccurately. Plugging a guessed atom probability into does not establish the same equality for the true distribution. The pinned numerical reference documents a standard uniform distribution and its random-variates method, while its normal cdf/ppf methods evaluate the Gaussian component when the duration comes from a clipped normal input.[ref]
This is a mathematical probability construction. It does not remove the atom physically, improve measurement precision, or create a worst-case guarantee on missed optical energy. Its randomization rule and probability interpretation must be specified as part of the procedure.
Distribution sensitivity of randomized zero-endpoint probabilities quantifies how the probability equality in randomized endpoint inclusion at a zero-duration atom changes when its assumed duration law is wrong. Let the nominal law have zero-atom probability , choose a positive upper endpoint with nominal cumulative distribution function , and put , with . Use the parent's independently randomized decision to include zero.
If the actual zero probability is and the actual cumulative distribution function is , the included probability isSubtracting the target separates the two model errors:The first term is upper-endpoint probability error; the second is atom-probability error in a randomized endpoint rule. This identity is an algebraic consequence of independence of the auxiliary random draw, not a normal-approximation result. The documented uniform distribution random-variates construction supplies that auxiliary draw; normal cdf/ppf routines can evaluate a specified clipped-normal duration model.[ref]
For an original misspecification example, choose , , and , so . Suppose instead and . Thenwhich is below : comes from the upper endpoint and from the atom. These are stipulated distributions, not measured failure rates.
More generally, bounds and imply . This propagates validated model-error bounds only. Estimating the nominal law from the same observation used for the interval can add dependence; the unconditional fixed-rule identity then requires an appropriate joint or conditional argument.
Atom-probability error in a randomized endpoint rule is the change in included duration-model probability caused by using an inaccurate zero-atom probability in the randomization. Let , and hold the positive upper endpoint fixed at an actual cumulative distribution function value . If the true zero probability is but the rule uses a positive , its independent endpoint-inclusion probability is . Conditional on that chosen value,This is the atom term isolated in distribution sensitivity of randomized zero-endpoint probabilities, with upper-endpoint error deliberately removed. Underestimating reduces inclusion; overestimating it increases inclusion. The independent auxiliary draw can be generated from a uniform distribution.[ref]
SciPy 1.16.2 documentation. scipy.stats.uniform, support and rvs
If comes from an independent calibration, conditional probabilities must also be averaged over that calibration. For an original example, take , , and . Suppose the calibration returns or with equal probability. Its estimate is unbiased, yet the resulting included probabilities are and , averaging about rather than .
More generally, for an unbiased positive estimate in the valid rule range, Jensen's inequality givesThis reciprocal-estimation bias in randomized atom inclusion comes from a nonlinear plug-in rule, even with independent calibration. It does not identify the size of the error without a calibration model. Values below , including zero, require an explicitly defined clipped or guarded rule; the displayed inverse formula cannot simply be used there.
If a validated upper bound is available and , choosing instead guarantees under the fixed-upper-endpoint and independence assumptions. It may be conservative rather than exact. Uncertainty in remains a separate error term, and these are probabilities for a duration distribution, not a removal of the physical zero-duration atom.
Reciprocal-estimation bias in randomized atom inclusion quantifies the nonlinear plug-in loss beyond the sign supplied by Jensen's inequality. Keep the independent-calibration model of atom-probability error in a randomized endpoint rule: true atom probability , unbiased estimate , and included probability , with the upper endpoint calibrated to actual probability . Assume , , and .
The exact algebraic identitygivesThus the loss depends on squared errors weighted by the reciprocal estimated probability. The second-order delta method approximation is , but the exact remainder shows why small estimated probabilities deserve particular attention.
If almost surely for , a nonasymptotic bound isFor an original small-error example, let , let measurement calibration return or equally often, and take , . Here and the variance is . The exact included probability is about ; the second-order approximation is , while the bounded-error calculation puts the coverage loss between about and .
The bounded-relative-error assumption can fail for a finite binomial measurement calibration: an empirical atom fraction can be zero with positive probability. Such near-zero probability estimates in reciprocal plug-in rules require an explicitly defined guard or different measurement calibration model, not division by zero. The auxiliary endpoint decision must remain independent of the future duration and measurement calibration as stipulated. The documented uniform random-variates construction supplies that auxiliary randomness; it does not validate the atom estimate.[ref]
SciPy 1.16.2 documentation. scipy.stats.uniform, support and rvs
Near-zero probability estimates in reciprocal plug-in rules can make a nominal randomization undefined even when the underlying probability estimate is unbiased. For an independent measurement calibration count , the empirical atom fraction has , butThus its reciprocal is not a finite statistic on every measurement calibration outcome. The binomial probability mass function supplies this zero-count probability directly.[ref]
SciPy 1.16.2 documentation. scipy.stats.binom, Notes: pmf; Methods: pmf
In reciprocal-estimation bias in randomized atom inclusion, a fixed upper endpoint contributes actual probability and the auxiliary rule uses . Valid probabilities require a separate rule when , including zero. One possible numerical guard is with . It makes defined and between zero and one. It does not preserve the unbiasedness or the coverage properties of the unguarded formula.
For an original finite measurement calibration example, take , , , , and . A zero count occurs with probability about . On that outcome the guarded rule includes zero with probability , and its included duration-model probability is , below the nominal . Averaging over every measurement calibration outcome givesThe calculation assumes the future duration, measurement calibration sample, and auxiliary random draw have the stipulated independence, and the upper-endpoint probability is exactly .
Such finite-calibration guards for reciprocal endpoint randomization solve a domain problem, not a coverage proof. A validated upper probability bound can provide a different conservative construction under the parent's assumptions, but an arbitrary floor is not automatically such a bound. Calibration size, lower-tail events and the actual guarded rule must all enter the final joint-probability calculation.
Finite-calibration guards for reciprocal endpoint randomization must specify both a valid endpoint decision and how calibration uncertainty enters its probability guarantee. An arbitrary positive floor avoids division by zero but does not establish nominal inclusion, as the example in near-zero probability estimates in reciprocal plug-in rules demonstrates.
One finite-sample construction uses an upper confidence bound for the atom probability , based on independent calibration count . Supposewhere is a calibration failure budget. An exact one-sided binomial bound can be obtained by inversion: for , choose satisfying , and put . This is a confidence statement over calibration samples, not a posterior probability for a fixed after observing one count. The pinned reference documents the exact binomial proportion-interval method.[ref]
SciPy 1.16.2 documentation. BinomTestResult.proportion_ci, confidence_level, exact method and returned bounds
For a fixed upper duration endpoint with actual cumulative probability , setThe rule is defined and . On the event , its conditional included probability is . This calculation also requires independence of the calibration, future duration and auxiliary endpoint draw as stipulated by the parent model.
For an original zero-count example, take and . Since , inversion gives . With , , and stipulated true , the zero-count conditional included probability is approximately . The bound is much larger than the raw estimate zero, reflecting the uncertainty of a small calibration sample rather than inventing a measured atom fraction.
The calibration confidence level is not free. Since included probabilities are nonnegative even on the failure event, a general joint guarantee from this argument is onlyAt conditional target and calibration confidence , this lower guarantee is , not . To certify an unconditional target using this argument, the conditional target must be at least , provided it can fit below , or the failure budget must be reduced. Any upper-endpoint model error also needs separate accounting.
A differential inequality for an exponential tail envelope supplies a sufficient decay condition for a global power bound. Let nonnegative be absolutely continuous on every finite interval after , with andalmost everywhere, for constant . The integrating factor argument in bounding unobserved optical energy with an exponential tail model gives . Corners in the waveform are allowed under absolute continuity; an unmodeled upward jump is not.
The inequality is stronger than merely fitting a decay constant at a few sampled times. For example, obeys it and carries only after . The exponential-envelope tail-energy bound remains valid but need not be tight. Conversely, a later pulse can violate the differential condition while leaving all earlier samples unchanged.
A useful extension is a time-dependent decay-rate envelope. For locally integrable , the condition givesThis follows from the same integrating factor and is a scalar comparison bound. If throughout the tail, its integrated energy is at most .
For an original piecewise rate, choose , for the first and thereafter. Integrating the resulting continuous envelope yieldsUsing only the minimum rate would give . Faster guaranteed late decay tightens the result.
This is a conditional mathematical proof. A measured electrical waveform obeying a similar slope rule does not establish the optical condition without accounting for the detector impulse response. The primary NIST measurement procedure supplies an example of characterizing that response independently.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
A time-dependent decay-rate envelope bounds a nonnegative signal using a lower bound on its instantaneous decay rate. If is absolutely continuous on finite intervals, and almost everywhere for locally integrable , thenThe differential inequality for an exponential tail envelope article proves this comparison using an integrating factor and gives a piecewise-constant example. A strictly positive constant lower bound on gives exponential decay, but a positive rate at every instant need not supply such a lower bound.
An original example takes with and . Its integrated rate is logarithmic, soThis power-law tail from a decaying rate envelope tends to zero for every positive . Its envelope energy is nevertheless finite only when , in which caseFor original chosen , and , the allowance is . After a further it is at most . The remaining energy decreases algebraically rather than exponentially.
At the integrated envelope diverges logarithmically despite its power tending to zero. This does not prove that every signal below it has infinite energy; it means these assumptions alone supply no finite all-time energy bound. Taking the envelope itself gives a mathematical counterexample to the claim that pointwise decay implies integrable energy.
An experimental rate law therefore needs both temporal validity and an integrability check before it bounds missed optical energy. A measured detector tail is not automatically the true power profile; NIST's primary calibration procedure measures the receiver response separately.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
The power-law example is an independent comparison model, not a reported tail law of that apparatus.A power-law tail from a decaying rate envelope arises when a positive instantaneous decay rate weakens with time. The time-dependent decay-rate envelope with givesfor , and . The parent article obtains this envelope by integrating the rate. Its use for recording design additionally requires integrating over the entire unrecorded tail.
For , integration after an extension givesHence the acquisition duration from a power-law tail-energy tolerance is zero when ; otherwise it is sufficient to choose
In an original example, , and give an initial energy allowance . Reducing the remaining allowance to requires . An exponential envelope with the same initial allowance and a decay time would require only . Equal initial tail-energy allowances therefore do not imply equal acquisition durations.
For , the envelope tends to zero but its integral after every finite extension diverges. These assumptions then supply no finite missed-energy guarantee. They do not imply that every signal lying below the envelope has infinite energy.
This is an original comparison model, not a measured decay law attributed to a particular detector. In optical pulse metrology, NIST's response measurement separates receiver dynamics from the incident pulse before applying bandwidth corrections.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
The same physical distinction is necessary before interpreting any measured slow tail as a global bound on optical power.An acquisition duration from a power-law tail-energy tolerance extends a measurement until the validated envelope's unrecorded energy is below a chosen tolerance. For the model in power-law tail from a decaying rate envelope, with ,The parent article integrates this envelope and inverts the tolerance. Writing , its positive-duration requirement is when ; otherwise no additional duration is required.
In applying the rule, uncertainty in the exponent can dominate the result. With fixed and , differentiating the active branch givesThe required duration decreases with a larger exponent. For a guaranteed parameter range, a validated lower bound on a power-law tail exponent is therefore more useful than its best-fit value alone. Since decreases with for every , using the smallest allowed exponent bounds the entire tail, not just one selected sample.
For an original design example, let , and . A nominal exponent gives initial allowance , and . If the validated exponent range is instead , its slowest permitted tail has initial allowance and requires . The nominal duration does not guarantee the tolerance over that range. Upper bounds on and can likewise be used conservatively because increasing either raises the envelope pointwise.
If the allowed exponents reach one or below, these envelope assumptions alone no longer supply a finite all-time energy guarantee. This is a limitation of the bound, not proof that the actual pulse has infinite energy. The model must also hold throughout the unobserved interval: later pulses, persistent backgrounds or an electrical detector tail misidentified as optical power can invalidate it. NIST's independent receiver-response measurement illustrates this last experimental distinction.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37
The power-law examples are original conditional models, not observed decay laws attributed to that apparatus.A validated lower bound on a power-law tail exponent is an exponent constraint that is justified over the future interval where it is used to bound unrecorded energy. A fitted slope over a finite observation window is not by itself such a guarantee. Acquisition duration from a power-law tail-energy tolerance needs a global optical-power envelope, including a lower exponent limit above one for its finite-energy guarantee.
One sufficient condition, for positive absolutely continuous power, isIntegrating the logarithmic derivative gives . The time-dependent decay-rate envelope provides the equivalent integrating-factor argument when zeros of the power need handling. This is a sufficient condition, not a necessary characterization of every bounded tail.
For an original conditional estimation example, assume an exact power-law family with known and initial power . At , a measured ratio range yieldsapproximately . Within that assumed family, the lower endpoint gives a conservative extension about for a remaining-energy tolerance. A nominal exponent two would instead require .
The ratio interval constrains the exponent only conditional on the exact family, known time scale and suitable measurement uncertainty. It cannot exclude a later secondary pulse or a transition to a slower law after the observed window. Future-domain validity of a fitted power-law optical envelope therefore requires independent physical justification or explicitly limited claims. If the justified exponent set reaches one, this envelope alone supplies no finite all-time energy guarantee.
Finally, the measured trace must represent optical power rather than an uncorrected receiver tail. NIST measured the detector, cable and oscilloscope together using a short characterized optical input before correcting pulse measurements.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1 and response-measurement procedure
The exponent example is an original model calculation, not an observed law attributed to that apparatus.Future-domain validity of a fitted power-law optical envelope means that the bound applies throughout the unobserved future interval where its integral is used, rather than merely matching a recorded waveform. The validated lower bound on a power-law tail exponent supplies a sufficient differential condition for such a bound. Agreement on a finite observation window alone does not establish it.
A concrete counterexample uses a fitted profile observed only for . Choose a later time and define an additional pulseBoth and are nonnegative and continuously differentiable, and they agree exactly on the recorded interval. Yet the unobserved extra energy isThus nonnegativity, this degree of smoothness and even a perfect finite-window fit cannot exclude an arbitrarily large later contribution.
For an original example, take , and . The fitted profile predicts remaining energy , below a tolerance. Put the later pulse at with width and peak . It adds , although all recorded data are unchanged. This unobserved delayed-pulse counterexample to a fitted tail bound violates the claimed missed-energy tolerance without altering the fit quality.
To use the envelope as a guarantee, state the physical assumptions that exclude such later input, justify the rate bound over the required future interval, or limit the claim to the interval actually validated. Recording a longer finite window improves evidence but does not alone supply an all-future theorem under only the assumptions used in this counterexample.
The waveform must also represent optical power rather than detector response. NIST's primary pulse calibration separately characterized the detector/cable/oscilloscope chain with a short optical input.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1 and response-measurement procedure
Correcting the receiver is necessary for interpreting the trace, but it does not rule out the additional source pulse constructed here. The example is a mathematical comparison, not a reported failure of that apparatus.An unobserved delayed-pulse counterexample to a fitted tail bound constructs two admissible optical inputs giving the same finite measurement record but different missed energies. The future-domain validity of a fitted power-law optical envelope article gives a nonnegative, continuously differentiable delayed pulse with adjustable energy. The counterexample persists through a calibrated causal detector, not just an ideal instantaneous power readout.
Let , where the additional pulse has support after the record ends at . A linear receiver with impulse response and responsivity measures . Causality means for . Therefore, for every recorded time ,since every argument is negative. This causal indistinguishability of delayed optical inputs on a finite record holds even when the impulse response is known exactly and the recorded data are noiseless.
For an original example, record through and place the smooth sine-squared pulse of the parent article at , with width and peak . Its extra optical energy is . A chosen causal exponential receiver with decay time produces no difference in the initial record, although it will respond when the later pulse arrives. If its impulse response has unit area, the complete later output-area difference is in the receiver's output-area units.
Any rule using only the common initial record must return the same proposed bound for both inputs. Without a justified restriction on later illumination, the delayed pulse energy can be chosen larger than any proposed finite guarantee. More accurate calibration of that same initial record cannot resolve this information gap.
NIST characterized its detector, cable and oscilloscope together with a short known optical input before correcting pulse measurements.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1 and response-measurement procedure
Such response calibration addresses receiver distortion. Source shutoff, exclusion of later pulses or a future-valid rate envelope supplies the additional physical information needed for a missed-energy guarantee. The delayed pulse here is a mathematical construction, not a reported defect of that apparatus.Causal indistinguishability of delayed optical inputs on a finite record means that an observation ending at a fixed time cannot discriminate inputs whose differences have not yet reached its receivers. The unobserved delayed-pulse counterexample to a fitted tail bound proves this for one calibrated convolution channel. The same information limit holds for any finite set of causal linear channels.
Let channel have response with for , and record only for . Every perturbation supported strictly after satisfiesfor every channel. Thus the finite-record observation operator has a whole family of invisible input directions. This is compatible with nonnegative optical power: choose any nonnegative delayed pulse and compare with . No cancellation between unphysical negative powers is required.
Known propagation or detector latency can hide part of the input even before the record ends. If for , an input starting at produces no response before . The input-time horizon of a delayed optical receiver record therefore depends on the channel's time reference, not just the last stored sample time.
For an original example, suppose two ideal delay channels measure and , both recorded through . A pulse starting at input time first appears at output times and . Both stored records are unchanged by that pulse, even though it began before the nominal record endpoint. Additional causal channels with smaller delays can extend the input horizon; none can observe an input that begins after their recording ends.
Offline processing of identical stored records still gives identical results, even if the processing filter itself uses samples on both sides of each stored time. To distinguish the inputs, obtain additional observations or supply independently justified restrictions on later illumination. Exact knowledge of the receiver response alone supplies neither.
NIST's pulse calibration characterized the detector, cable and oscilloscope as a combined response chain using a short optical input.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1 and measurement procedure
Such characterization is important for aligning the physical input and recorded output times. The two pure delays above are chosen models, not measured delays of that apparatus. A future-valid optical envelope or documented source cutoff remains additional information needed for an all-future missed-energy bound.The input-time horizon of a delayed optical receiver record is the latest physical input time that could influence the recorded output, given the receiver's causal onset delay. If for and the last output time is , convolution depends only on input timesThus is a necessary timing limit on information in that record. Recoverability within the limit additionally depends on bandwidth, noise, sampling and the response's invertibility. Causal indistinguishability of delayed optical inputs on a finite record shows why later input changes cannot be inferred from the existing output samples.
For several channels with last recorded times and known onset delays , the latest possible input horizon isAny input perturbation starting strictly after is invisible in every stored channel. A channel's latest output timestamp alone is insufficient to compare its input horizon with another channel's.
For an original example, channel 1 records through with delay , while channel 2 records through with delay . Their input limits are and ; the combined limit is . Knowing both response functions exactly still supplies no observation of an input pulse beginning later than that limit.
A receiver-latency uncertainty in the inferred input-time horizon also changes the timing claim. If channel 1's delay is known only to lie between and , its possible horizon ranges from to . An input beginning at could affect the record for one allowed delay but arrive too late for another. Using the conservative endpoint avoids claiming timing access that depends on an unresolved latency. It still does not guarantee successful reconstruction of every earlier input.
NIST characterized detector, cable and oscilloscope as a combined response chain using a short known optical pulse.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1 and response-measurement procedure
Such a calibration must relate output timing to the physical input time origin. The delays above are illustrative, not quoted apparatus values. De-embedding known latency aligns the record's time reference; it cannot extend observations into an unrecorded future interval.Receiver-latency uncertainty in the inferred input-time horizon propagates uncertainty in timing calibration into the latest input time that could have influenced a stored output record. For one channel, the horizon in input-time horizon of a delayed optical receiver record is , with last output time and effective input-to-output timing offset . HenceThis linear variance identity retains shared timing influences.[ref]
A common calibration offset can cancel when it enters both quantities. In an original model, let errors be and , with independent components of standard deviations , and . Then and . Discarding their common-offset covariance would instead give .
The shared component must come from the actual calibration model. Here is the effective timing offset relating the input and output coordinates, so an output-clock alignment error can enter both and . A physical transport-delay error is not automatically correlated with the last-sample timestamp.
For hard timing limits, propagate validated bounds rather than reinterpret standard uncertainty as a guarantee. If is known and , then . Claiming the optimistic endpoint as though it held for every allowed delay would overstate the input-time reach.
With several channels, . Channel switching under uncertainty in a combined receiver horizon makes this a nonsmooth function when the maximizing channel is uncertain. Propagate the justified joint timing set or distribution; a derivative of only one nominally best channel can miss such switching.
NIST's primary pulse calibration measured the detector, cable and oscilloscope together using a short known optical input.[ref]
Calibration Service for Low-level Pulsed-Laser Radiometers at 1.06 µm: Pulse Energy and Peak Power by Rodney W. Leonhardt. Appendix C.1–C.2, printed pp. 36–37, Figure C1
The numerical timing errors above are chosen examples, not values from that apparatus. A timing horizon remains a necessary information limit; it does not guarantee invertibility of the receiver or bound future optical illumination.Channel switching under uncertainty in a combined receiver horizon occurs when uncertainty changes which receiver has the latest accessible input time. For channel , let be its last output time minus its effective input-to-output offset. The combined horizon is , as in receiver-latency uncertainty in the inferred input-time horizon. Away from ties a small perturbation may preserve the maximizing channel; near a tie it need not. Propagating only that channel's variance omits the switching operation.
An original two-channel model makes the effect exact. Suppose and are independent normal random variables with common mean and standard deviation . Independence giveswhere is the standard normal distribution cumulative distribution function. This square is already enough to show that is not normal: .
To calculate the resulting bias relative to the common nominal horizon, write . The difference has normal distribution with variance , hence . The sum and difference are independent in this model, givingFor and , the combined mean is about and its standard deviation is about . The formulas concern the uncertainty distribution of the horizon, not a promise of extra observable future illumination. The normal cdf/ppf routines provide direct evaluation of the probabilities.[ref]
SciPy 1.16.2 documentation. scipy.stats.norm, loc, scale, cdf and ppf
Shared clock or calibration errors invalidate the independence product. The distribution of the maximum of correlated receiver horizons must retain the joint timing model; NIST's general uncertainty guidance retains input covariance and requires distributional justification for coverage.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. Appendix A, equation A-3; §§6.2–6.3
For hard bounds instead, and imply without selecting a fixed winning channel. Neither calculation establishes invertibility of the physical receiver.A common-clock contribution to a maximum receiver horizon is a residual timing error that survives in every channel's inferred input-time horizon. Write , with common error independent of the remaining channel errors. Then the identityshows that selecting the latest channel does not average away the common term. With finite variances,Here means a component remaining after each channel's subtraction . A clock contribution that already cancels inside that subtraction must not be added again; see receiver-latency uncertainty in the inferred input-time horizon.
For two equal nominal horizons , take independent channel errors and . The independent maximum moments derived in channel switching under uncertainty in a combined receiver horizon giveIf the common error is also normal, each channel has variance and their correlation is , recovering the equal-channel model in distribution of the maximum of correlated receiver horizons.
For an original example, choose and . The combined mean is about above , and its standard deviation is about . Yet the difference between channel horizons has standard deviation only , because cancels there. Good agreement between channels therefore need not establish a precise absolute horizon.
A timing experiment needs an independently justified reference for the common component, in addition to channel-to-channel alignment observations. Shared-input covariance is explicitly retained in NIST's uncertainty law.[ref]
Guidelines for Evaluating and Expressing the Uncertainty of NIST Measurement Results by Barry N. Taylor and Chris E. Kuyatt. Appendix A, equation A-3
Repeated reads sharing the same clock realization cannot estimate away its absolute displacement simply by choosing the largest result. Articles by others on the same topic
There are currently no matching articles.