Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Coefficient of kinetic friction
Coefficient of kinetic friction Created 2026-10-14 Updated 2026-10-20
The coefficient of kinetic friction is the dimensionless quantity for sliding contact with positive normal force in the ideal kinetic friction model. It characterizes the pair of contacting surfaces and their condition. A constant means the model neglects dependence on contact slip speed; unlike the coefficient of static friction, it specifies a sliding force magnitude rather than a no-slip upper bound.
The ratio compares the tangential kinetic friction magnitude with the perpendicular normal force:Here is the tangential relative velocity defining contact slip. Both numerator and denominator have the same physical dimension, so the coefficient of kinetic friction has no units. It belongs to a contact pair under specified conditions, rather than to one material alone. The coefficient of static friction instead describes the threshold before contact slip; a pull required to start motion cannot be substituted for a sliding measurement.[ref]
University Physics Volume 1 by William Moebs and others. §6.2, “Magnitude of Static Friction” and “Magnitude of Kinetic Friction”, equations 6.1–6.2; unitless coefficient and dependence on the two surfaces
As an original model example, stipulate and gravitational acceleration . An already sliding, nonrotating block of total mass is pulled horizontally across a stationary horizontal surface at constant velocity. With no other vertical force, Newton's second law gives . Zero horizontal acceleration then requires a pulling force . Doubling the total mass to gives and . The force doubles while the coefficient of kinetic friction stays by assumption. These numbers are model predictions, not observations or a calibration for a particular material pair.
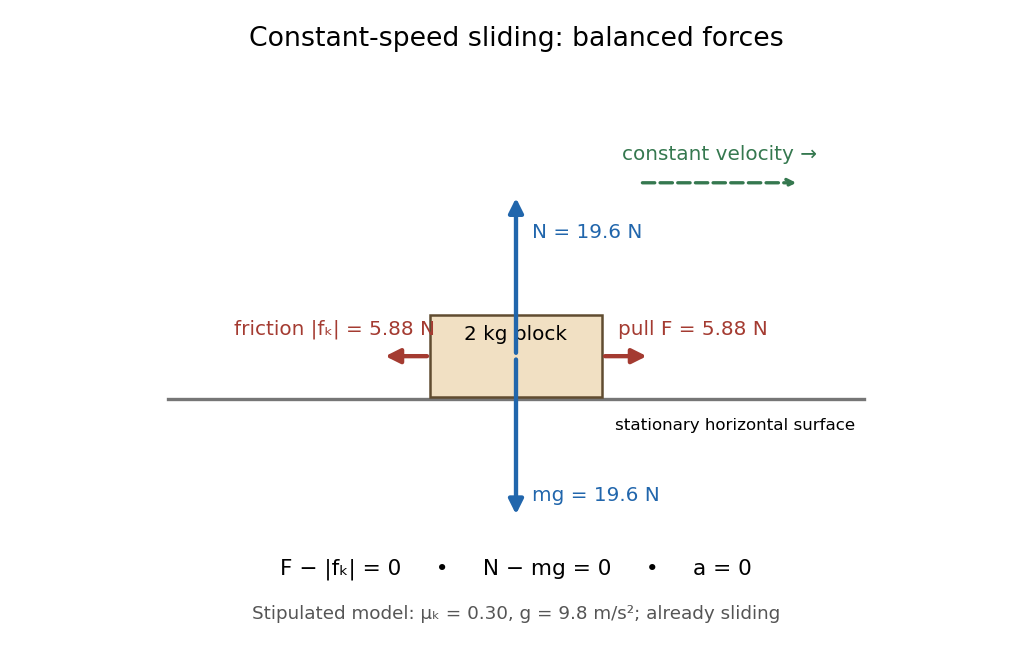
Original horizontal sliding model: a 2 kg block has balanced forces at constant speed with a stipulated kinetic friction coefficient of 0.30
. Details. 
A constant coefficient of kinetic friction is useful because one ratio can summarize many loads, as tested by load dependence of kinetic friction. It is an empirical approximation over a stated range of normal forces, speeds and surface conditions. It implies no universal independence from speed or apparent contact area: a change of face or sliding regime can change the result. Temperature, wear and lubrication are further conditions to report. Newton's second law still applies when the constant-coefficient approximation fails.[ref]
University Physics Volume 1 by William Moebs and others. §6.2, approximate empirical model; small nonzero speeds; exceptions for lubricated surfaces and high speeds; “Atomic-Scale Explanations of Friction”, apparent versus actual contact area
Coefficient of static friction Created 2026-10-05 Updated 2026-10-20
The coefficient of static friction is the nonnegative dimensionless quantity , with , in the ideal dry-contact model. It characterizes the pair of surfaces under specified conditions. It describes the largest supported tangential force, whereas the coefficient of kinetic friction describes sliding. It is an empirical approximation, not a universal material constant.[ref]
In the horizontal example, an observed state balancing a pull would only establish under the model assumptions. It would not establish : the actual static friction is below its limit. Identifying the coefficient needs an onset measurement, such as inclined-plane measurement of static friction, or the starting peak in a suitably controlled horizontal pull. The sustained sliding part of constant-speed measurement of kinetic friction measures a different coefficient.
In a simple grain model, the existing name granular friction coefficient represents resistance to downstream motion. That model excludes lift and detailed contact torques. Its coefficient should not automatically be identified with a bulk pile's angle of repose: individual contact geometry and collective rearrangement can matter.
A force gauge reads the pulling force. For horizontal straight-line sliding at constant velocity, its reading equals the opposing kinetic friction magnitude, provided these are the only horizontal forces. For total supported mass , including added loads, , so a mean sliding reading gives . The important readout is the sustained sliding force after the starting peak; the peak belongs to the static friction threshold.
The University of Mississippi's Experiment 6 uses a wooden block on a wooden plane, a triple-beam balance, added masses, and a dual-range 50 N force probe connected through LabPro to Logger Pro. Its procedure calibrates the probe with a load on a hanger, entering the corresponding force in newtons, and measures the block's mass separately. With the plane horizontal, it starts with on the block and pulls horizontally at constant speed. The recorded force trace has a starting peak; the procedure selects the subsequent constant-force interval and takes its mean. It repeats with increments up to added, then plots sliding force against normal force to estimate the coefficient of kinetic friction from the slope.[ref]
Experiment 6: The Coefficient of Friction (University of Mississippi teaching laboratory). Experiment 6, The Coefficient of Friction, PDF pp. 1–2: Equipment, Objectives, Procedure steps 1–7
For a replication, check the gauge's zero with the string slack and its response to known gravitational weights; zeroing alone does not check its scale. Keep the plane level, the pull parallel to it, and the block face and track region consistent. Specify the contacting materials and whether the surfaces are dry, cleaned or lubricated; repeat runs to see whether debris or wear changes the sliding force. Verify constant velocity independently from position versus time, rather than assuming that a flat force trace proves zero acceleration. These are proposed measurement controls, not additional observations from the laboratory writeup. Record the selected interval, variation between runs and gauge resolution as sources of measurement error.
For a block sliding right on a stationary horizontal plane, take rightward acceleration as positive. A gauge reading for a pull at angle above horizontal has horizontal component and upward component . With no vertical acceleration or other forces, Newton's second law givesand thereforeThis inference requires continued contact with and rightward contact slip, so its numerator must be nonnegative. An upward pull reduces normal force; a downward pull, represented by , increases it. The horizontal constant-velocity formula is the special case , .
For the original , model, an upward pull at maintaining constant velocity needsDividing this gauge reading by would give about , rather than : the gauge reads the full inclined force, and the pull has changed the normal force.
Even with a horizontal pull, an accelerating measurement needs the correction: . In the same model, a horizontal pull produces while the block slides right; subtracting recovers the kinetic friction. Dividing the uncorrected reading by instead gives about . Measure acceleration in an inertial frame, along the sliding direction, over the same interval as the gauge reading. These corrections follow from the force balance, independently of whether the resulting coefficient of kinetic friction is constant across runs.
// Target: classical-mechanics.bigb
Friction 2026-10-14
Friction is a contact force tangent to the surfaces. Kinetic friction opposes contact slip; static friction maintains contact without contact slip, including rolling without slipping. The perpendicular contact component is the normal force. These two components answer different questions: how strongly the surfaces press together, and how strongly they resist sliding past one another.
The ideal Coulomb dry-contact model combines a bound on static friction with a sliding law for kinetic friction. Its parameters are the coefficient of static friction and the coefficient of kinetic friction; constant coefficients are an empirical approximation, rather than a consequence of Newton's laws of motion. Surface condition matters, and the static coefficient need not universally exceed the kinetic coefficient. [ref]
The model's historical setting was practical machinery: Coulomb's Théorie des machines simples investigated friction and the stiffness of ropes. The Académie's bibliography records its 1781 prize and its appearance in volume 10, pages 161–332, of the Recueil des savants étrangers. [ref]
https://www.academie-sciences.fr/pdf/dossiers/Coulomb/Coulomb_pubd1.htm. Académie des sciences: Coulomb's published works
Kinetic friction Created 2026-10-14 Updated 2026-10-20
Kinetic friction is friction during nonzero contact slip. For one-dimensional motion along a surface, choose right as positive and write for the body's contact-point velocity and for the surface's contact-point velocity, both measured in the same inertial frame. The signed relative velocity is . The ideal Coulomb law for the tangential force on the body isHere is the magnitude of the normal force, is the coefficient of kinetic friction, and is the sign function. Thus kinetic friction opposes contact slip, which can differ from the body's direction of motion. In several tangential directions the same law reads for a nonzero tangential relative velocity . The magnitude law is documented in Ling, Sanny and Moebs, OpenStax University Physics 1, §6.2: static and kinetic friction.
For a stipulated toy model, take a nonrotating box with mass , normal force , coefficient of static friction , and coefficient of kinetic friction . These are assumed model parameters, rather than measured properties of any particular pair of materials; the prescribed normal force is consistent with horizontal support under and no other vertical forces. On stationary ground, a box already sliding right has . With an applied horizontal force to the right, Newton's second law gives , for as long as rightward contact slip persists.
Direction is clearer by comparing two instantaneous states of this same model. If the box has on stationary ground, and , so kinetic friction acts left with magnitude . If the box still has but a belt beneath it has , then : kinetic friction acts right with magnitude , even while the box moves right.
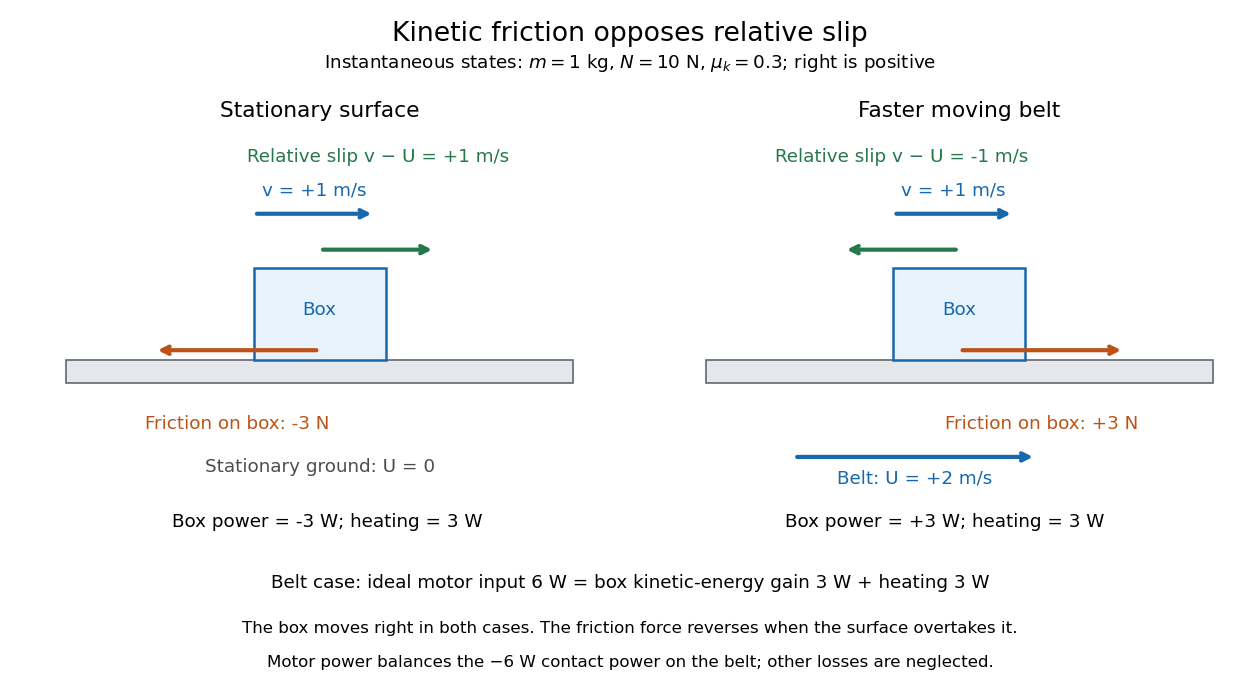
The same rightward box velocity gives opposite friction directions on stationary ground and a faster moving belt
. Details. 
In the belt case, the power delivered to the box is . With no other horizontal force, its kinetic energy therefore increases by the work-energy theorem. By Newton's third law, the box exerts on the belt, so the contact power delivered to the belt is . Their sum is : frictional heating produces thermal internal energy at . An ideal motor maintaining the prescribed belt velocity supplies against this contact load, neglecting other losses, so its input divides into of box kinetic energy and of frictional heating. These are instantaneous rates, since the box's velocity subsequently changes. This balance follows directly from power as force times velocity and conservation of energy; the power law is given in Ling, Sanny and Moebs, OpenStax University Physics 1, §7.4: power.
When contact slip vanishes, including a transition to rolling without slipping, the nonzero-slip law no longer applies. Determine the required static friction from the no-slip condition and the equations of motion, then test its bound. Substituting into the sliding law would incorrectly exclude a nonzero static friction.
Load dependence of kinetic friction 2026-10-14
Changing the added mass while retaining the same contact pair and sliding speed tests whether a constant coefficient of kinetic friction is a useful model. Compute for each level horizontal run, and plot the mean sliding force vertically against normal force horizontally. The constant-coefficient prediction is a straight line through the origin; its slope is . This extracts a ratio from several loads rather than relying on one reading.
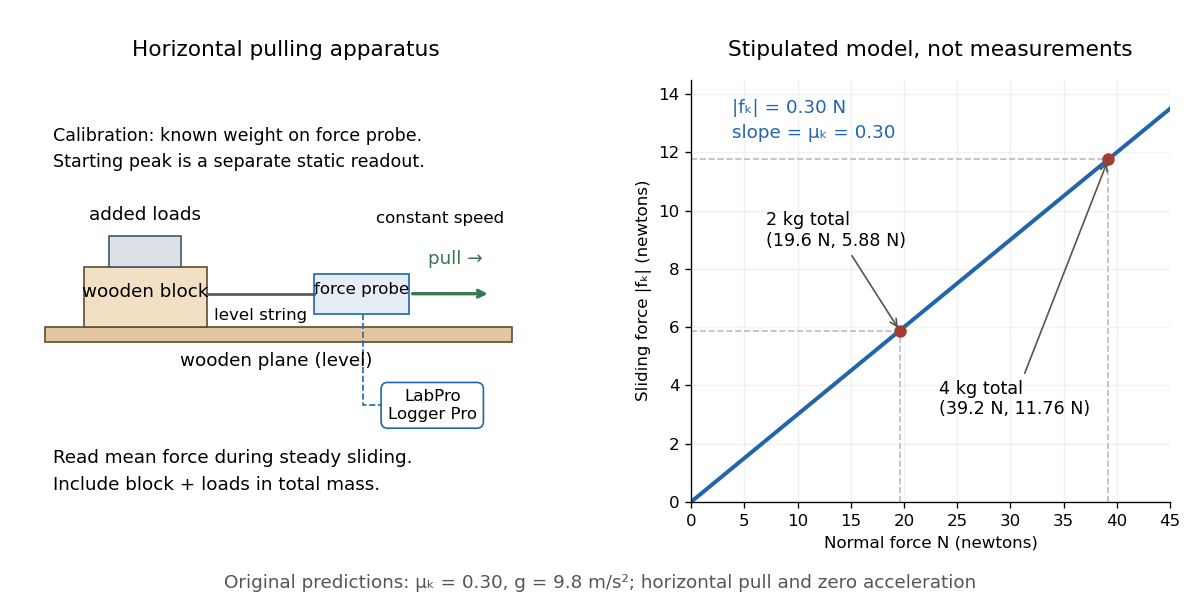
Horizontal wooden-block force-probe apparatus and original load model: 19.6 N and 39.2 N normal loads predict 5.88 N and 11.76 N sliding forces
. Details. 
The apparatus sketch identifies the contact pair and horizontal pull used by the cited laboratory procedure. The plotted line and points are the original stipulated model from coefficient of kinetic friction, not laboratory data. The two model points giveIn actual measurements, a linear regression can expose an unexplained intercept . A nonzero intercept calls for checking the gauge zero, other resisting forces and the contact model; forcing the line through zero can hide those problems. Conversely, constant ratios within measurement error support the approximation only over the loads, speeds and surface conditions tested. A load sweep alone cannot establish independence from contact area or sliding speed; those require separate controlled variations.
friction force microscopy records cantilever torsion caused by lateral tip–sample force. Choose the detector sign so that friction on a flat region contributes positively during a left-to-right trace. On a common laboratory-position axis, write the two signals schematically asHere is an offset and represents a slope-related lateral-force or detector cross-talk contribution. A reversed electronic convention reverses all plotted signs without changing the physical conclusions.
At the same controlled normal contact force , the flat-region contribution is approximately . The lower perovskite structure plateaux give a larger trace–retrace separation than the upper inorganic surface, because their coefficient of kinetic friction is larger. Genuine friction reverses sign with scan direction, so a larger friction magnitude means a higher positive trace and a more negative retrace in this convention.
Sloped edges produce additional peaks or shoulders. The normal reaction to a slope has a lateral component, and the finite tip flank can contact the rim, so edge contrast is not a direct map of the local friction coefficient. With the two scans registered and load control maintained,The half-difference therefore emphasizes friction while the half-sum diagnoses common geometrical contributions. Real contact mechanics and imperfect registration can prevent exact cancellation. The bottom panel of the figure shows these two kinds of contrast separately.
A modern teaching experiment slows gravity-driven motion enough to resolve it with a photogate. PASCO scientific's Inclined Plane Dynamics Set, ME-6966, Instruction Manual 012-10874A describes “Acceleration Down an Incline” on printed pages 15–16. Its apparatus is a GOcar on a PAStrack with an adjustable incline support, a bracket-mounted photogate, a cart-mounted picket fence, and an interface with recording software. For the interface method, the fence's pattern is aligned to interrupt the beam. Recording starts before release from rest; the cart is caught at the bottom bumper. The procedure specifies three runs per angle, starting at and reducing by , with the release position fixed. The readout is velocity against time; its slope estimates acceleration. Mean accelerations are plotted against , testing the ideal slope . An added-mass comparison is also requested. These are protocol settings, not observed results.[ref]
The cart undergoes rolling without slipping at its wheels, whereas the worked block undergoes contact slip. Even ideal wheel moment of inertia changes the cart prediction. For total cart mass , wheel radii and axial moments of inertia , rigid wheels with fixed axles and no losses giveTo derive it, combine translational kinetic energy with wheel rotational kinetic energy , then equate their rate of change to the release of gravitational potential energy . This is the multiwheel counterpart of rolling acceleration with rotational inertia. Neglecting wheel moment of inertia yields ; treating a cart as a solid rolling cylinder would give a different correction.
Useful additional controls are repeated releases without a push, checking the fence alignment and spacing, and checking that the recorded velocity trace is straight over the fitted interval. A gently moving cart on a level track can expose losses or unintended tilt. These checks help distinguish an angle or timing error from neglected wheel moment of inertia, bearing friction, or drag force. The three-run spread measures repeatability but cannot by itself reveal a shared calibration error. The inspected protocol makes the gravity component measurable; it does not measure the sliding block's coefficient of kinetic friction.
Sliding acceleration on an inclined plane 2026-10-18
First test rest. With no other tangential forces, the required uphill static friction is . Its maximum is , where is the coefficient of static friction. ThusThe tangent function is increasing on this angle range, and its inverse tangent determines the last permitted resting angle . At equality, the ideal model still permits limiting rest; a larger angle excludes it. Below the threshold, setting would incorrectly impose the maximum static friction even when less is required. Static friction on an inclined plane and inclined-plane measurement of static friction develop this onset criterion further.
For a block already sliding downhill, uphill kinetic friction has magnitude , where is the coefficient of kinetic friction. Taking downhill as positive, Newton's second law becomesEvery term in the force balance scales with mass; division by removes it. Doubling mass doubles both gravitational weight and the contact forces, while leaving this acceleration unchanged if the coefficients remain unchanged. A mass-independent result is a prediction of these assumptions, rather than a universal property of every ramp.
For an original numerical model, stipulate , , and . The critical angle is . At , the normal force is ; rest requires of uphill static friction, below its bound. A resting block can stay there. If it is already sliding downhill, however, the kinetic friction is only , giving downhill acceleration . Specifying the initial state matters.
At , the downhill component of gravitational weight is , while and the static friction bound is only . Rest is impossible. During downhill sliding,Released from rest on a sufficiently long ramp, this ideal block covers its first in , reaching speed . As an independent energy calculation, the lost gravitational potential energy is and kinetic friction removes of mechanical energy. The remaining equals by the work-energy theorem.
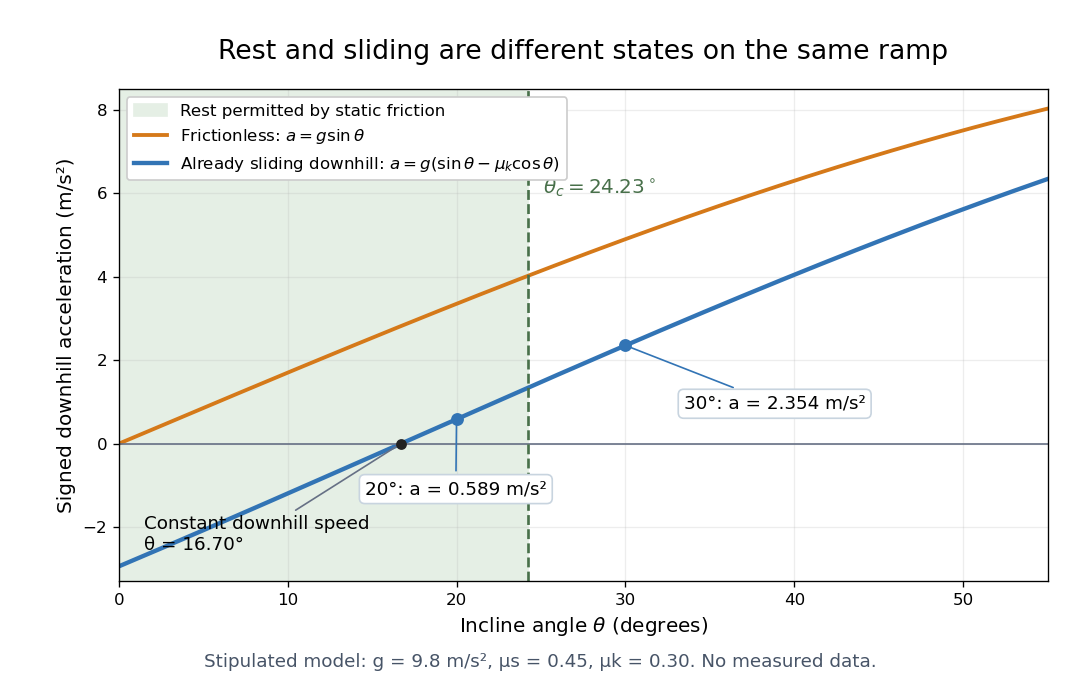

At , downhill sliding has zero acceleration and therefore constant velocity. Below that angle, a downhill-moving block slows; when it stops, test the static friction bound again. For uphill sliding, kinetic friction points downhill, so the signed downhill acceleration instead is . The sign follows contact slip, and the downhill formula cannot be used unchanged after a reversal.
Static friction Created 2026-10-05 Updated 2026-10-14
Static friction is the tangential contact force that maintains zero contact slip. “Static” describes the contact state: both surfaces can move together in the chosen inertial frame. In the ideal dry-contact model, the actual static friction adjusts to the equations of motion, subject to a bound, rather than always taking its maximum value.[ref]
6.2 Friction. Static and Kinetic Friction; Magnitude of Static Friction, equation 6.1 and responsive-force paragraph
Here is the magnitude of the normal force and the coefficient of static friction. Equality means limiting static friction; it is a threshold, not an instruction to replace every unknown contact force by .For a stipulated example, place a nonrotating block initially at rest on a stationary horizontal surface. Take gravitational acceleration and coefficient of static friction , with no other vertical force. The vertical force balance gives , so the largest allowed static friction magnitude is . Choose right as positive and apply a horizontal force . Remaining at rest requires Newton's second law to giveAt , the static friction is ; at , it is . Both states have zero acceleration. At , balancing would require , outside the bound, so this initially resting block cannot remain at rest. Its subsequent acceleration requires a kinetic friction law; setting after contact slip begins would still use the wrong contact state. At exactly , the ideal inequality still permits rest at the threshold. These are model calculations, not measured material properties.
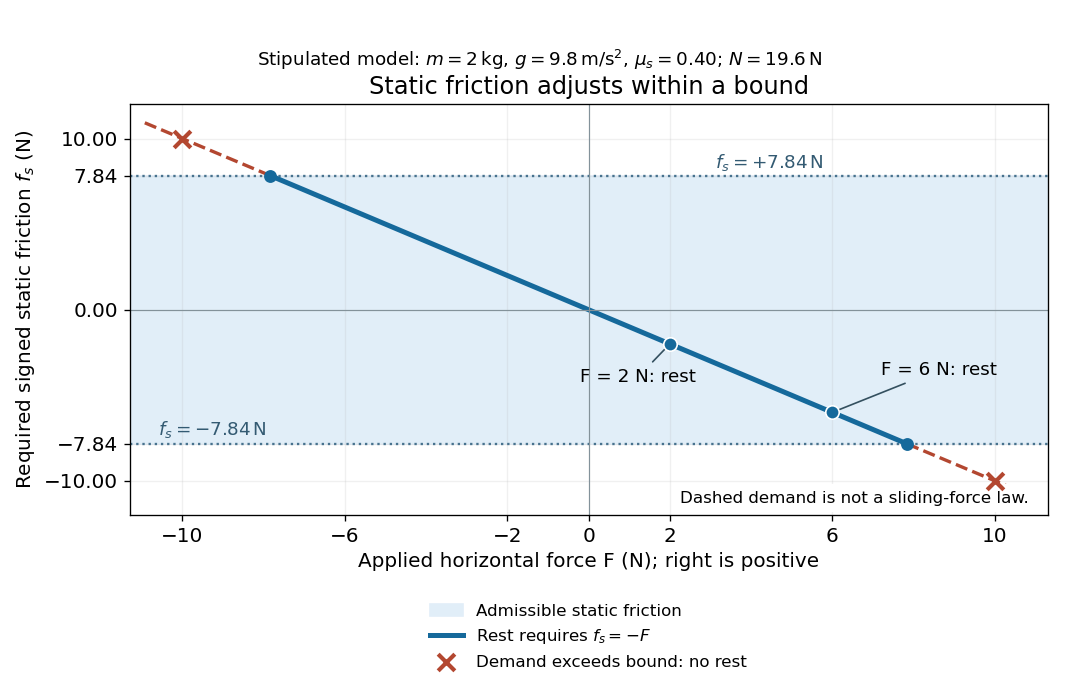
Static friction adjusts to the applied force within its admissible bound
. Original signed horizontal model for the stipulated block: the shaded band is the allowed static friction, the solid line satisfies force balance, and the dashed line shows the demand outside that band. The crossed points at are impossible static demands, not sliding forces. Details.
The toy model used in kinetic friction makes the contact-state distinction explicit: , , and coefficient of kinetic friction . On stationary ground, an initially resting box pushed right with has . At it cannot remain at rest; once it slides right, and . At , rest is allowed with , whereas an already right-sliding box has and . The applied force alone does not specify the friction branch: contact slip and motion history matter.
For a flat contact with two tangential directions, the bound applies to a vector norm, not separately to each component:For the stipulated bound, balancing horizontal components and requires a force magnitude , which is allowed. Components and require , which is forbidden even though each component separately is below . This circular bound assumes the same coefficient of static friction in every tangential direction. Near impending contact slip, the limiting static friction opposes the relative contact motion that would otherwise begin. Once actual contact slip exists, kinetic friction instead opposes its tangential relative velocity, which need not have the direction of the body's center of mass motion.
The normal force must also come from the equations of motion. On horizontal ground, an upward pull of magnitude at angle above horizontal gives, for a block remaining at rest with no other forces,The sine component unloads the contact and the cosine component demands tangential support. These equations require ; if the supporting contact opens, this dry-contact model cannot supply a negative normal force. For the stipulated block and , the positive threshold is , with and . A downward pull increases instead. An inclined plane gives another reason why is not always .
To solve a new problem, impose zero contact slip, find the required static friction and normal force from the equations of motion, then check the bound. A demand inside it permits that contact state; a demand outside it rules the state out. For an ideal driven tire undergoing rolling without slipping on stationary ground, a forward static friction can accelerate the vehicle. Its role is to prevent contact slip, rather than to oppose all motion of the whole body.
Nor does the word “static” by itself make friction do zero work. The contact power delivered to a body is , a dot product with its material contact-point velocity in the chosen inertial frame. At an ideal contact undergoing rolling without slipping on stationary ground, , so this power is zero. For a rigid body, adding the translational and rotational contributions gives , where is the contact torque about the center of mass and its angular velocity. Counting only the first term omits the rotational contribution.
At a moving contact with zero contact slip, the two material contact points share a velocity that can be nonzero. For instance, a nonrotating block moving with an accelerating belt receives positive contact power when the belt's rightward velocity and rightward static friction are positive. The belt receives by Newton's third law. These contact contributions sum to zero in the ideal no-slip model, while the block's kinetic energy can increase. Zero contact slip and zero work on each body are different conditions.