Static friction is the tangential contact force that maintains zero contact slip. “Static” describes the contact state: both surfaces can move together in the chosen inertial frame. In the ideal dry-contact model, the actual static friction adjusts to the equations of motion, subject to a bound, rather than always taking its maximum value.[ref]
6.2 Friction. Static and Kinetic Friction; Magnitude of Static Friction, equation 6.1 and responsive-force paragraph
Here is the magnitude of the normal force and the coefficient of static friction. Equality means limiting static friction; it is a threshold, not an instruction to replace every unknown contact force by .For a stipulated example, place a nonrotating block initially at rest on a stationary horizontal surface. Take gravitational acceleration and coefficient of static friction , with no other vertical force. The vertical force balance gives , so the largest allowed static friction magnitude is . Choose right as positive and apply a horizontal force . Remaining at rest requires Newton's second law to giveAt , the static friction is ; at , it is . Both states have zero acceleration. At , balancing would require , outside the bound, so this initially resting block cannot remain at rest. Its subsequent acceleration requires a kinetic friction law; setting after contact slip begins would still use the wrong contact state. At exactly , the ideal inequality still permits rest at the threshold. These are model calculations, not measured material properties.
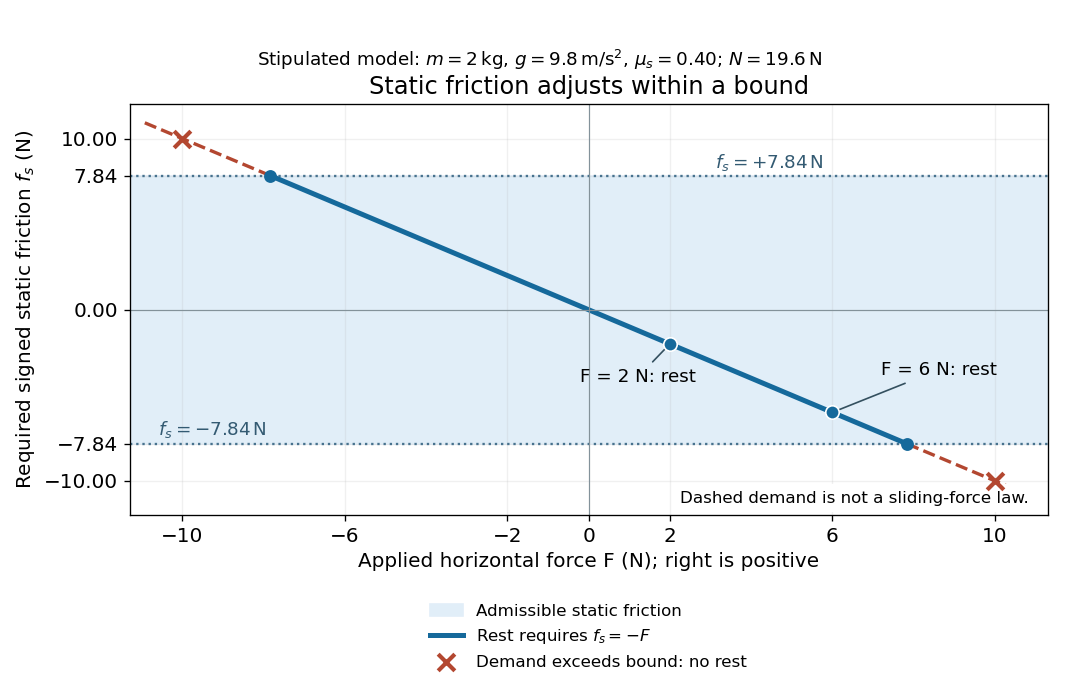
Static friction adjusts to the applied force within its admissible bound
. Original signed horizontal model for the stipulated block: the shaded band is the allowed static friction, the solid line satisfies force balance, and the dashed line shows the demand outside that band. The crossed points at are impossible static demands, not sliding forces. Details.
The toy model used in kinetic friction makes the contact-state distinction explicit: , , and coefficient of kinetic friction . On stationary ground, an initially resting box pushed right with has . At it cannot remain at rest; once it slides right, and . At , rest is allowed with , whereas an already right-sliding box has and . The applied force alone does not specify the friction branch: contact slip and motion history matter.
For a flat contact with two tangential directions, the bound applies to a vector norm, not separately to each component:For the stipulated bound, balancing horizontal components and requires a force magnitude , which is allowed. Components and require , which is forbidden even though each component separately is below . This circular bound assumes the same coefficient of static friction in every tangential direction. Near impending contact slip, the limiting static friction opposes the relative contact motion that would otherwise begin. Once actual contact slip exists, kinetic friction instead opposes its tangential relative velocity, which need not have the direction of the body's center of mass motion.
The normal force must also come from the equations of motion. On horizontal ground, an upward pull of magnitude at angle above horizontal gives, for a block remaining at rest with no other forces,The sine component unloads the contact and the cosine component demands tangential support. These equations require ; if the supporting contact opens, this dry-contact model cannot supply a negative normal force. For the stipulated block and , the positive threshold is , with and . A downward pull increases instead. An inclined plane gives another reason why is not always .
To solve a new problem, impose zero contact slip, find the required static friction and normal force from the equations of motion, then check the bound. A demand inside it permits that contact state; a demand outside it rules the state out. For an ideal driven tire undergoing rolling without slipping on stationary ground, a forward static friction can accelerate the vehicle. Its role is to prevent contact slip, rather than to oppose all motion of the whole body.
Nor does the word “static” by itself make friction do zero work. The contact power delivered to a body is , a dot product with its material contact-point velocity in the chosen inertial frame. At an ideal contact undergoing rolling without slipping on stationary ground, , so this power is zero. For a rigid body, adding the translational and rotational contributions gives , where is the contact torque about the center of mass and its angular velocity. Counting only the first term omits the rotational contribution.
At a moving contact with zero contact slip, the two material contact points share a velocity that can be nonzero. For instance, a nonrotating block moving with an accelerating belt receives positive contact power when the belt's rightward velocity and rightward static friction are positive. The belt receives by Newton's third law. These contact contributions sum to zero in the ideal no-slip model, while the block's kinetic energy can increase. Zero contact slip and zero work on each body are different conditions.
The limiting angle between a contact resultant and the compressive normal force when static friction obeys . Resolving the resultant gives , so admissible contact forces lie within a cone of half-angle about the inward normal. A contact-force magnitude is generally , distinct from N.
For symmetric upper faces inclined by alpha from the vertical, inward normals push partly downward. Limiting upward friction gives vertical support . Balancing weight yields the displayed minimum normal grip. The corresponding minimum total contact magnitude per face is . It is achieved at the limiting friction angle. The formula assumes symmetric contacts with cancelling horizontal force and torque and positive denominator.
The coefficient of static friction is the nonnegative dimensionless quantity , with , in the ideal dry-contact model. It characterizes the pair of surfaces under specified conditions. It describes the largest supported tangential force, whereas the coefficient of kinetic friction describes sliding. It is an empirical approximation, not a universal material constant.[ref]
In the horizontal example, an observed state balancing a pull would only establish under the model assumptions. It would not establish : the actual static friction is below its limit. Identifying the coefficient needs an onset measurement, such as inclined-plane measurement of static friction, or the starting peak in a suitably controlled horizontal pull. The sustained sliding part of constant-speed measurement of kinetic friction measures a different coefficient.
In a simple grain model, the existing name granular friction coefficient represents resistance to downstream motion. That model excludes lift and detailed contact torques. Its coefficient should not automatically be identified with a bulk pile's angle of repose: individual contact geometry and collective rearrangement can matter.
An inclined plane tilted slowly from horizontal turns a coefficient of static friction into a critical angle. Assume a nonrotating block on a stationary, rigid, dry surface, with gravitational weight and the contact forces as its only forces. Take to be the angle between the uphill surface direction and horizontal. Let be a unit vector pointing uphill and a perpendicular unit vector pointing outward from the surface. Resolving the gravitational weight givesThe angle between the downward vertical and the inward normal is also . Thus the inward component uses cosine and the downhill component uses sine. These are components of one force, not two additional forces.
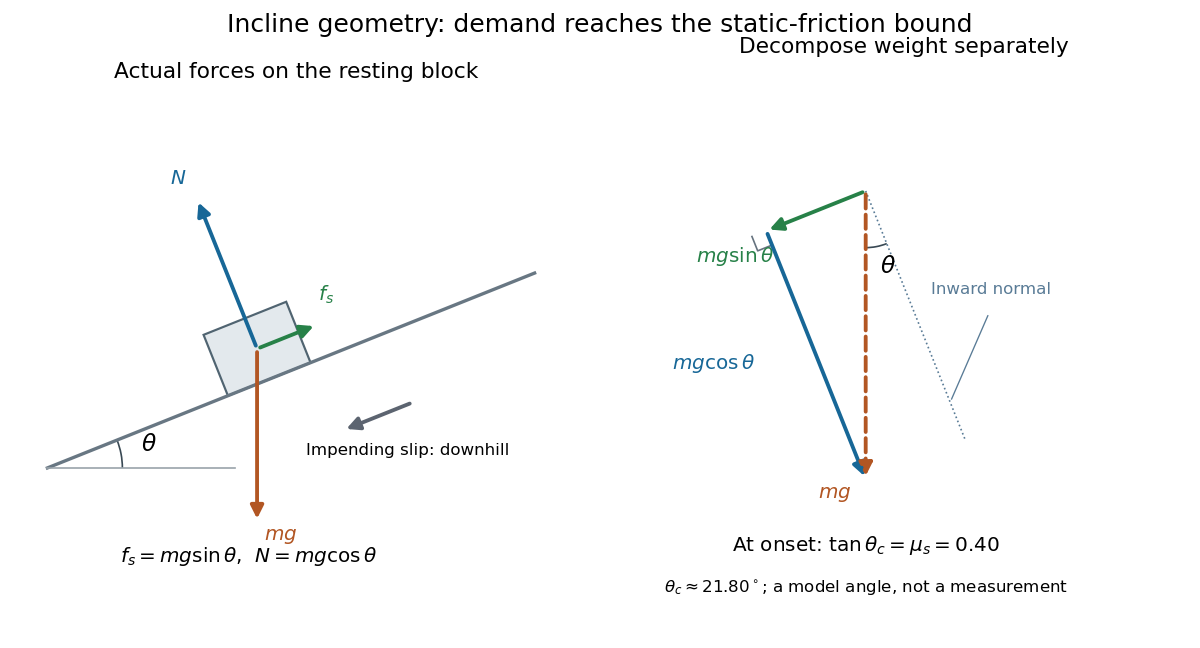

Before downhill contact slip, zero acceleration and Newton's second law requireThe required static friction points uphill. Substituting into the bound and dividing by the positive givesThe tangent function increases on this range of angles, so the last admissible resting angle isThe inverse tangent takes a dimensionless quantity to an angle. At equality the ideal model still permits a limiting resting state; increasing further excludes it. At a smaller angle, is the demand ratio, not the coefficient of static friction.[ref]
For the stipulated , and , the critical angle is approximately . At , and , comfortably below the bound . At , maintaining rest would require , but the bound is only : rest is impossible. At , and . Notice that the limiting tangential force here is smaller than the horizontal limit because tilting reduces the normal force.
Cancellation of mass makes this relation useful: the ideal critical angle tests a contact coefficient without needing a calibrated force gauge. Doubling the block's mass doubles both demanded static friction and its bound, leaving unchanged if is unchanged. This is a testable model prediction. It need not survive a change in surface condition, a direction-dependent coefficient, appreciable deformation, or vibration.
The derivation also assumes continued contact and that sliding occurs before tipping or rolling without slipping. The resultant contact force must act within the supporting footprint so that the block can satisfy torque balance; a tall block may tip first. No extra tension, imposed tangential pull, or lift is included. In a slowly raised apparatus, quasistatic process means that motion of the board contributes negligible inertial forces while locating the threshold. Once downhill contact slip begins, a constant-velocity sliding angle would concern kinetic friction, not the onset of static friction.
A university laboratory places an aluminium block on a Teflon-lined wooden board. For its inclined plane stage, the pulley and block string are removed; a rope and hook connect the board to a crank. The block is placed gently near the sheet's middle without prior sliding. Smooth cranking raises the board; a – protractor reads the smallest angle at which sliding begins. Four readings are taken without added load, then four each with , , and added symmetrically at two screws. Removing the string isolates gravity-driven onset; gentle placement and smooth raising avoid premature disturbance.[ref]
Infer under the assumptions of static friction on an inclined plane. Repetition tests onset scatter; added loads test coefficient constancy. No measured onset values are supplied here.
For a replication, additionally check the protractor zero with a level board, retain the same contact face and surface region, and observe whether tipping or rolling precedes sliding. These are proposed additional controls. A finite angle resolution and the disturbance needed to detect first motion limit the estimate; a slow ramp does not by itself establish perfectly rigid, dry, or direction-independent contact. At the model's threshold, differentiating the tangent function gives , with in radians. A hypothetical measurement error would therefore correspond to approximately in the inferred coefficient at first order. This sensitivity calculation is not an uncertainty reported by the laboratory.
Articles by others on the same topic
There are currently no matching articles.