For a smooth function on an open set , a critical point is an input where the gradient vanishes: . Equivalently, every first partial derivative is zero. Such a critical point is a stationary point; in one variable the condition is .
There is a broader convention in elementary one-variable calculus: a "critical number" is an interior input where the derivative is zero or does not exist, provided the function itself is defined there. Thus a corner can be a critical number without being a stationary point. Here the smooth meaning of critical point is used unless the broader convention is explicitly stated. [ref]
https://openstax.org/books/calculus-volume-1/pages/4-3-maxima-and-minima. Gilbert Strang and Edwin Herman, OpenStax Calculus Volume 1, §4.3: critical numbers
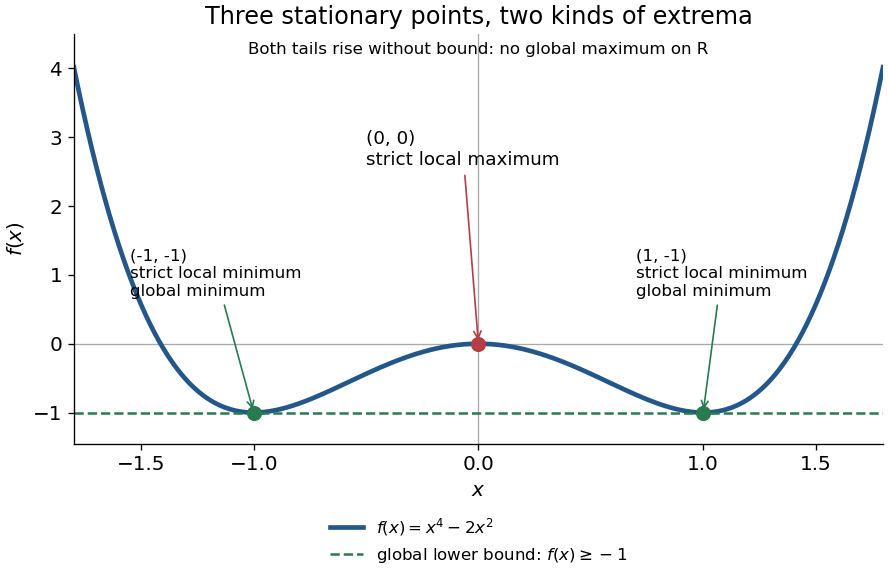
For the polynomial on the real line,The stationary points at are strict local minima and attain the global minimum; the stationary point at is a strict local maximum. One can check the local classifications from , which is positive at and negative at zero. The identity proves the global minimum directly. Since as , there is no global maximum on .
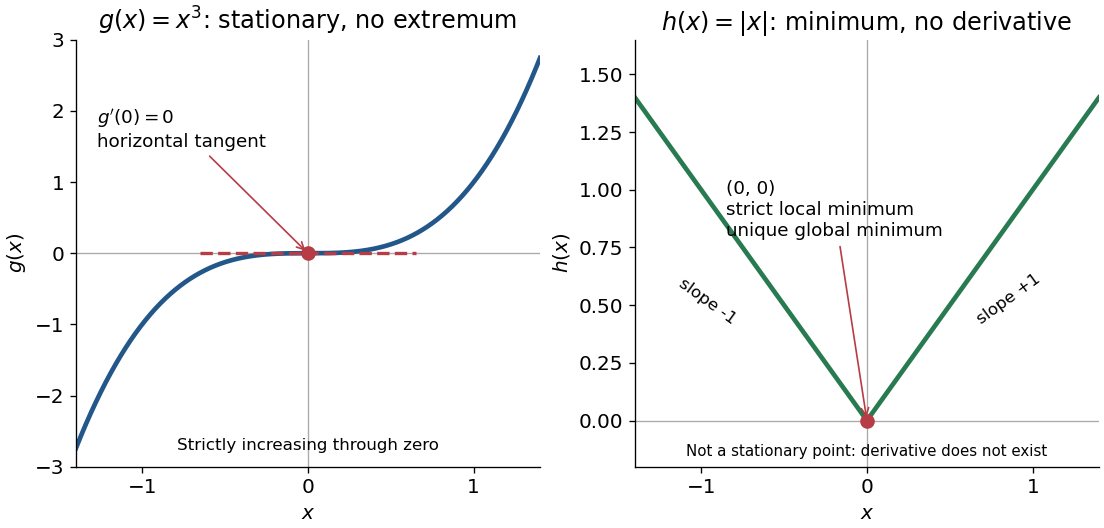
A zero derivative alone does not guarantee an extremum. The polynomial has but is strictly increasing through zero: every neighbourhood of zero contains both positive and negative values, so zero is neither a local minimum nor a local maximum. Conversely, the absolute value function has a strict local minimum and a unique global minimum at zero, but its left and right derivatives are and . It is not differentiable there, so zero is a critical number under the broader convention and is not a stationary point.


The usefulness of critical points is that they reduce the search for smooth interior extrema to equations. Every local minimum or local maximum of a differentiable function at an interior point has zero gradient; this condition is necessary, and shows that it is not sufficient. The striking feature is that all the first directional derivatives must vanish together, even though the surrounding values can form a valley, a peak, or a saddle point of a scalar function. [ref]
https://www.ocw.mit.edu/ans7870/18/18.013a/textbook/HTML/chapter14/section01.html. Daniel Kleitman, MIT Calculus with Applications, §14.1: necessary conditions for an interior extremum
Proof outline: at an interior local minimum in one variable, the difference quotient is nonnegative for small and nonpositive for small . If the derivative exists, the two sides have the same limit, forcing . Reverse the inequalities for a local maximum. In several variables, apply this argument along each coordinate line to obtain zero partial derivatives and hence zero gradient. At a domain boundary, both directions may not be available: on attains its global minimum at zero although for its smooth extension.
A critical point whose Hessian matrix is a singular matrix. The second-derivative test does not completely classify such a point. Higher-order terms can produce a local minimum, a local maximum, or a saddle point of a scalar function.
At the origin the gradient vanishes and the Hessian matrix is , which is positive semidefinite. Nevertheless, takes both signs arbitrarily close to the origin. Thus the origin is a saddle point of a scalar function. This example shows why a zero eigenvalue prevents the ordinary second-derivative test from establishing a local minimum.
The gradient of this polynomial vanishes exactly when and , giving nine stationary points. Its diagonal Hessian matrix has entries and . The second-derivative test therefore gives two strict local maxima at , with value , and two strict local minima at , with value . The origin and the four points are saddle points of a scalar function, with values zero and , respectively. Every stationary point is nondegenerate.
Completing the squares organizes the contour plot:The level set through the four outer saddle points of a scalar function factors asIt is a circle together with a hyperbola when ; for , the latter factor's complementary zero set is the pair of lines . Neither the local maxima nor the local minima are global, since the restrictions to the two coordinate axes are unbounded in opposite directions. The case , gives four outer saddle values and an exact circle-hyperbola contour crossing at all four outer saddle points of a scalar function.
The stationary points of this polynomial are the origin and , . Its Hessian matrix at the origin has eigenvalues , so the origin is a saddle point. At each of the other points the eigenvalues are and , giving strict local minima. The identityshows that they are also the only global minima, with value .
For , the level set has two closed components, one surrounding each minimum. The zero level set has two lobes meeting at the origin with the coordinate axes as tangent directions. For , there is one closed outer component. These statements also follow in polar coordinates from the quadratic equation in , together with the absence of other stationary points.
The zero level set of is the union of the coordinate axes and the circle of radius . The gradient isIts nine stationary points are the origin, the four axis points at distance , and the four points with . The factored gradient proves completeness: a zero coordinate gives the five axis cases; two nonzero coordinates give a linear system in .
The Hessian matrix has diagonal entries and off-diagonal entries . At the origin its eigenvalues are ; at the four unit-direction axis points they are . These are saddle points of a scalar function. At the two interior points with equal coordinate signs, the eigenvalues are , giving strict local minima of value . Opposite coordinate signs give the negative eigenvalues and strict local maxima of value .
On the zero circle, . Hence its direction is radial outward for , inward for , and zero at the four axis crossings. This simple geometric sign rule links the zero level set to the gradient sketch without requiring numerical differentiation.
Let be nonzero real constants with . The real function displayed in the title has exactly one stationary point:Indeed the partial derivatives are , each of which has precisely one zero. The Hessian matrix at that point is .
If every , each summand is a strictly convex function tending to as its argument tends to either infinity. Consequently has a unique global minimum. If every , negating gives the preceding case, proving a unique global maximum. If both signs occur, restricting to two coordinate directions of opposite signs gives a saddle point of a scalar function. No degenerate Hessian matrix is possible under the nonzero assumptions.
For with , its stationary points are the origin and, when , , . The origin is a strict local minimum for and a saddle point of a scalar function for . At its Hessian matrix is singular, but the vertical line gives positive values and the parabola negative values, so it remains a degenerate saddle. The other stationary points have Hessian determinant and are saddles.
For , the origin is a strict local minimum. The four axis points at distance one have Hessian eigenvalues and . The four diagonal points with have Hessian eigenvalues and . Thus for the diagonal points are the global maxima and the axis points are saddle points of a scalar function; for these roles reverse. In polar coordinates, , where . Maximizing over gives and proves the global statements. At , , so the entire unit circle is the maximum set.
A saddle point of a scalar function is a stationary point with nearby values both greater and less than its value. An indefinite Hessian matrix proves this by choosing directions with opposite signs of the quadratic term. A degenerate Hessian matrix may require higher-order terms: has a saddle point of a scalar function at the origin despite a zero quadratic coefficient in the direction. This is distinct from a saddle equilibrium of a dynamical system.
For every , the polynomial has exactly five stationary points: the origin and the four points with . Its gradient factors asIf a coordinate vanishes at a stationary point, both do. Otherwise put , to obtain and . Dividing gives and then .
At the origin, the Hessian matrix vanishes. Axis restrictions give , while diagonal restrictions give for small nonzero . Thus the origin is a degenerate saddle point of a scalar function. Its leading quartic term is nonpositive, showing why the sign of the first nonzero homogeneous term alone need not settle the problem when that term vanishes along some directions.
At each nonzero stationary point, the Hessian matrix has diagonal entries and off-diagonal entries . Its positive eigenvalues and prove strict local minima. They are also global minima of value : the arithmetic-geometric mean inequality gives , and the minimum of for is at . Equality requires .
Suppose a function near a critical point has Taylor expansion , where is its first nonzero homogeneous polynomial term. If takes both positive and negative values on directions, then is a saddle point of a scalar function. Indeed, on rays the leading term is ; for each chosen direction its sign dominates the remainder for small positive . This works even when the Hessian matrix is zero. For example, is negative on and positive on , hence detects a saddle despite having degree four.
A real-valued function , with , has a local maximum at if some satisfiesOnly a neighbourhood within the domain of a function is compared. Equality is allowed; a strict local maximum requires for every other point in that neighbourhood. A constant function therefore has a local maximum and a local minimum at every input, with neither strict. This is a local form of an extremum of a real-valued function.
For , zero is a strict local maximum because when . It is not a global maximum: values far away grow without bound. This distinction makes a local maximum useful for describing a nearby peak without claiming that it is the highest value anywhere.
Negating the function exchanges local maxima and local minima, including their strict versions. At a smooth interior local maximum, the critical point argument forces zero gradient; for a function twice continuously differentiable nearby, its Hessian matrix is negative semidefinite. These necessary conditions alone do not establish a local maximum.
A function has a strict local maximum at if some neighbourhood contains no other point with . Unlike a non-strict local maximum, equality at another sufficiently nearby point is excluded. Use neighbourhoods relative to the domain, including when is an endpoint.
A stationary point is nonisolated if every neighbourhood contains other stationary points. For a twice differentiable function, a regular smooth curve of stationary points through a point forces its Hessian matrix to annihilate the curve's nonzero tangent: differentiate the vanishing gradient along the curve. Thus the Hessian matrix has a zero eigenvalue there, but that alone need not determine whether the point is a local minimum or local maximum.
The critical set of a differentiable map consists of the points where its derivative fails to have full rank.
A real-valued function , with , has a local minimum at if some satisfiesEquality is allowed; a strict local minimum excludes equality at every other sufficiently nearby point. The comparison uses a neighbourhood relative to the domain of a function. On an open set, this is an ordinary small ball around . At an endpoint, only points belonging to the domain of a function are tested. Some elementary texts reserve "local" for interior points; here endpoints are allowed under the relative convention, but the zero-gradient condition still requires an interior point.
For , each of and is a strict local minimum, although both attain the same global minimum. For , zero is a strict local minimum despite the missing derivative. Thus the definition compares values and does not require differentiability.
A local minimum describes a valley that cannot be improved by a sufficiently small move; mathematical optimization also asks whether a better value lies farther away. At a smooth interior local minimum, the gradient is zero. If the function is twice continuously differentiable nearby, its Hessian matrix is positive semidefinite: restrict to a line through the point and its second derivative is nonnegative. The converse fails for a degenerate Hessian matrix, as at zero shows.
A local minimizer is a point of the domain of a function at which that function attains a local minimum: some neighbourhood of satisfies for all . The point and the attained value are different objects. Every global minimizer is a local minimizer, but the converse need not hold.
A local minimum is strict when every other point of the domain of a function in some neighbourhood has a larger value. Strictness is local: two separated strict local minima can have the same value, as at demonstrates. Negating the function gives a strict local maximum.
A real-valued function attains a global minimum at whenThe point is a global minimizer; is the minimum value. A global maximum reverses the inequality throughout the same domain of a function. Unlike a local minimum or local maximum, a global minimum or global maximum compares every permitted input, however distant. The domain of a function is part of the claim.
For on , completing the square giveswith equality exactly at . This proves that is the global minimum and that the two global minimizers are and . Neither is a strict global minimizer, because the other attains the same value; both are strict local minima. There is no global maximum on , whereas on the global maximum is , attained at zero.
Finding critical points supplies candidates rather than a global certificate. The squared expression above is beautiful because one inequality compares infinitely many inputs at once. A global minimum is always a local minimum under the relative-neighbourhood convention; the converse fails. For example, has a strict local minimum at , but as , so it has no global minimum on the real line.
Existence also matters: on has infimum zero and supremum one but attains neither a global minimum nor a global maximum. By the extreme value theorem, a continuous function on a nonempty closed interval attains both. To find those values, compare all interior critical numbers, including points where the derivative does not exist, and both endpoints. Checking only stationary points can miss a corner or an endpoint. [ref]
https://openstax.org/books/calculus-volume-1/pages/4-3-maxima-and-minima. Gilbert Strang and Edwin Herman, OpenStax Calculus Volume 1, §4.3: locating absolute extrema
A global minimizer is a point attaining the infimum of an objective. For an extended-real functional, it is usual to require a finite objective value; this excludes points outside its effective domain. A convention allowing as the attained value gives every point as a formal minimizer of the identically infinite function.
Articles by others on the same topic
There are currently no matching articles.