
The noncontact set is open. For , the positive gap above the obstacle has a positive minimum on the support of . Thus both and are admissible for sufficiently small . Applying the variational inequality to both signs yieldsHence the Euler-Lagrange equation on the noncontact set isIt holds classically under the assumed smoothness. On the contact set the obstacle prevents the negative variations used to obtain this equality, so a variational inequality remains the appropriate global description.
For any , the segment stays in for . Since is a minimizer, the right derivative of its energy at is nonnegative. The first variation therefore gives the variational inequalityThe factor two comes from the quadratic gradient term. Only a one-sided inequality follows because a variation pointing below the obstacle need not be admissible.
One-dimensional Sobolev embedding gives a continuous representative for each , with zero endpoint values, so the pointwise obstacle condition is meaningful. The positive part is Lipschitz and vanishes near both endpoints because . It therefore belongs to and satisfies , proving that is nonempty.
If and , then , so is a convex set. If in , the estimate gives uniform convergence. Passing to the limit in shows . Thus the admissible set is nonempty, closed and convex.
Take the zero-boundary Sobolev space with norm . The Poincaré inequality makes this equivalent to the usual Sobolev norm. DefineThe weak formulation is and for every .
In dimension three the Sobolev embedding theorem gives , so . The Cauchy-Schwarz inequality and Poincaré inequality yieldThus for every , and . Finallysince . Hence is strongly monotone with constant one in the chosen norm.
Using the dual pairing, a monotone operator satisfies for all . It is a strongly monotone operator if some givesA nonlinear coercive operator with respect to satisfies as in .
Strong monotonicity, with , givesAfter division, the lower bound is , proving coercivity. Reflexivity and separability are not needed for this particular estimate.
Work in the Banach space with its supremum norm, and take the nonempty closed bounded convex set . DefineFor the absolute value is unnecessary, and . Thus . Also, for ,so and in particular is continuous.
The image is uniformly bounded, and , so it is equicontinuous. The Arzelà-Ascoli theorem says that a uniformly bounded equicontinuous family in has relatively compact closure in the uniform norm. Hence is compact, and the Schauder fixed-point theorem supplies , the required solution. In fact the displayed contraction estimate also lets the contraction mapping theorem give uniqueness within and convergence of the corresponding Picard iteration. The initial constant here is the printed integer .
The Schauder fixed-point theorem states that a continuous compact self-map of a nonempty closed bounded convex set in a Banach space has a fixed point. Equivalently in this bounded-domain version, it suffices for the image of the map to be relatively compact. The theorem guarantees existence, without requiring a contraction estimate or promising uniqueness.
A nonlinear compact operator is a continuous map that sends bounded sets of its domain to relatively compact subsets of the target space; linearity is not part of this general definition.
For the specified diagonal operator on sequence space on l2 sequence space,so it is well-defined, linear and bounded. Let retain only its first output coordinates. This is a finite-rank operator, andThe upper bound follows by estimating each tail multiplier by ; equality follows on the unit coordinate vector . Finite-rank operators between Banach spaces are compact, and a limit of compact linear operators in operator norm is compact, the norm-closedness of compact operators. Therefore .
The Brouwer fixed-point theorem says that every continuous map has a fixed point. To use the supplied outward vector field zero theorem, first extend the construction to all of . LetThe radial retraction onto a closed ball is continuous, so is a continuous vector field on the required whole space. On , the Cauchy-Schwarz inequality givesThe supplied theorem gives with . There , hence . This explicit extension avoids presuming that the original map was defined outside the ball.
The contraction mapping theorem states that a self-map of a nonempty complete metric space with a uniform contraction constant has a unique fixed point . For every starting point, the iteration converges to , with .
For the cosine fixed-point iteration, any real gives . This closed interval is complete, and cosine maps it into . The mean value theorem giveswith . Apply the contraction mapping theorem to the tail starting at . Therefore for every real initial value. Numerically . The global real-line derivative bound is only one; entering the invariant interval supplies the strict uniform bound needed by the theorem.
Here “contractive” means strictly distance-decreasing: . “Strongly contractive” means a contraction mapping with one uniform constant satisfying .
If distinct were both fixed points, strict decrease would give , a contradiction. Thus there is at most one fixed point. This proves uniqueness if a fixed point exists; the pointwise strict inequality alone does not assert existence.
Past exam of the elasticity and plasticity course of the University of Oxford 2011 3 d Solution 2026-10-31
Take the clamp at with . An end force without an applied end moment gives the free-end condition . With , the Euler elastica equation is . For , is small, so the leading equation isIntegrating with the two boundary conditions givesTo first order, and . HenceEquivalently at leading order, the familiar cantilever response. Because , the deflection is downward. The free-end displacement field and slope are and . The remainder notation holds with fixed positive and nondimensional unit rod length.
Past exam of the elasticity and plasticity course of the University of Oxford 2011 3 c Solution 2026-10-31
Set . The Euler elastica equation becomes . Multiplying by gives the first integralStraight asymptotic ends require and a horizontal tangent, so . This is the separatrix of a simple pendulum with its angle shifted by . A nonconstant solution moves from to , with the same physical tangent at both ends, taking infinite arc length to approach either limit. One explicit representative isUsing and and integrating gives the tensile elastica loopThis solution is nontrivial, tends to horizontal straight tails, and has finite excess bending energy. It is also necessarily self-intersecting. Indeed is even and is odd. For , let . Near zero , while , so there is a root . At the two distinct parameters , both points have and the same . Numerically .
Any nonconstant smooth solution with the same straight asymptotic conditions has this first integral. Between consecutive horizontal orientations, separating variables gives the displayed solution up to translation, reflection, and reversal. It cannot pass through a straight equilibrium at a finite parameter, by uniqueness of the ordinary differential equation. Thus all such nontrivial branches have the same loop crossing. This is an ideal zero-thickness rod solution; a physical rod with self-contact excluded cannot realize the crossing without adding contact forces.
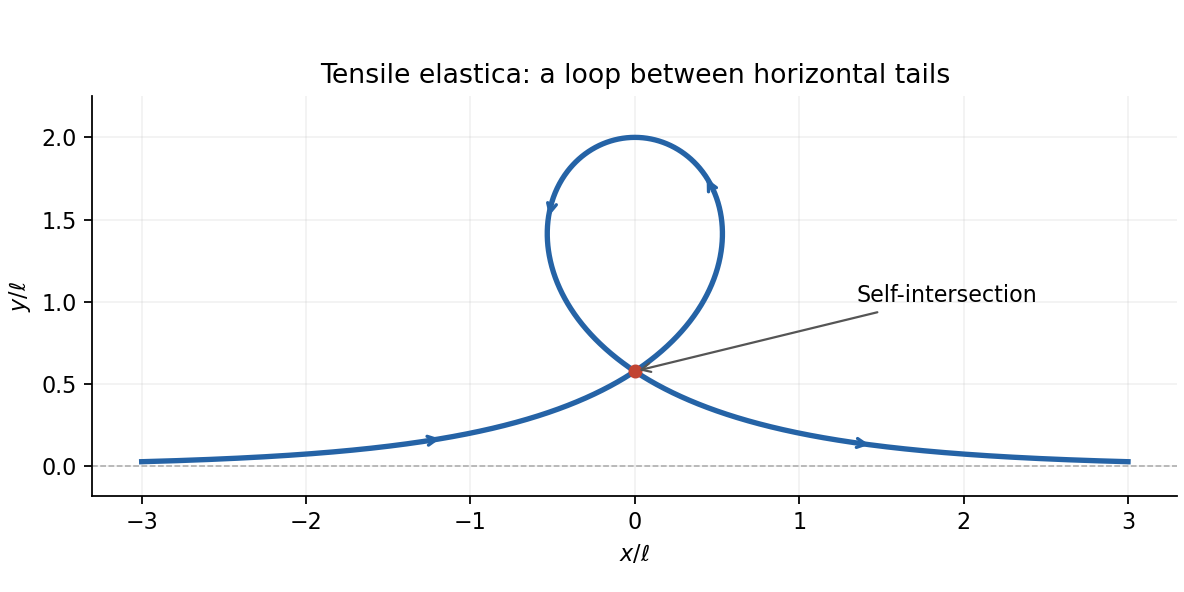
The tensile elastica loop and its self-intersection
. Details. 
Past exam of the elasticity and plasticity course of the University of Oxford 2011 3 b Solution 2026-10-31
Put . With , the Euler elastica equation is . Linearization about the straight configuration gives . Under the boundary conditions explicitly stated, , a nonzero solution requiresThus with only the stated boundary conditions, the first critical compressive force is . The corresponding linear transverse displacement field, with , isand to first order. These are the successive small-amplitude buckling modes. The nonlinear branches retain the simple pendulum equation; if the angular amplitude is and , fitting half-periods into the rod gives , which tends to as . Here is the complete elliptic integral of the first kind, with its modulus, not its squared parameter.
Endpoint position compatibility for the Euler elastica adds a condition when fully fixed clamps have equal transverse height. If the word “clamped” also imposes , then . With , this retains only even , yieldingThe same exclusion is exact on the nonlinear branches: integrating the elastica equation gives , and an odd number of half-periods reverses the nonzero endpoint slope. Hence odd changes the endpoint height. The conventional fixed-clamp first Euler buckling load is the second boxed value, whereas the source's explicitly listed boundary conditions alone give the first. Additional clamped modes with a nonzero transverse reaction require releasing the imposed . Load-controlled buckling also permits axial shortening; an exactly inextensible rod whose endpoint separation is fixed equal to its full length has no room to buckle.
Past exam of the elasticity and plasticity course of the University of Oxford 2011 3 a Solution 2026-10-31
Let be arc length, so inextensibility makes a unit tangent vector. The curvature is , hence for uniform bending stiffness. Balance of linear momentum in static equilibrium gives a constant resultant .
Taking the cross product directly,The scalar component of conservation of angular momentum therefore becomesTogether with and , this Euler elastica equation determines the centerline once the appropriate boundary conditions are supplied.
Past exam of the elasticity and plasticity course of the University of Oxford 2011 2 h Solution 2026-10-31
Substituting both profiles into the shear traction condition givesFor the normal traction, use and . Removing the common nonzero factors yields the second equation. ThusA nonzero displacement field requires the determinant to vanish:Let and . Cancelling gives the Rayleigh secular equationSquaring and excluding the zero root gives ; any candidate must still satisfy the unsquared equation and the decay inequalities. For stable isotropic elasticity , this cubic has one root in : its values at zero and one have opposite signs, and its strictly negative second derivative on this interval prevents a second crossing back to a positive final value. Both sides of the unsquared equation are positive there, so this root is valid.
The root of the squared equation is not a propagating surface wave: at , the two roots coincide, and the null combination in this representation produces zero displacement field. As a numerical example, gives and . The surface-wave speed is independent of in this homogeneous half-space model.
Past exam of the elasticity and plasticity course of the University of Oxford 2011 2 g Solution 2026-10-31
Write the in-plane displacement field as . The infinitesimal strain tensor gives , , and . The two nontrivial zero-traction conditions becomeEquivalently for the complex amplitudes they are and . Because the constitutive equation is real and linear, vanishing of these complex amplitudes enforces the conditions at every position and time.
Past exam of the elasticity and plasticity course of the University of Oxford 2011 2 f Solution 2026-10-31
The material occupies , so its outward unit normal at the surface is . A free surface has zero traction, . ThereforeThe third condition is automatic for the two-dimensional displacement field with zero third component and no dependence on the third coordinate. The first two impose zero shear and normal stress at the free surface.
Past exam of the elasticity and plasticity course of the University of Oxford 2011 2 e Solution 2026-10-31
For the root the elastic wave polarization is parallel to the complex derivative vector , givingFor the root the field has zero divergence, , givingThese relations also follow by inserting each decay root into either row of the matrix. The complete decaying displacement field has complex componentsmultiplied by , followed by the real part. The first constituent is irrotational and the second is divergence-free; both are needed to cancel the two surface tractions.
Past exam of the elasticity and plasticity course of the University of Oxford 2011 2 d Solution 2026-10-31
Use the complex amplitude and take its real part at the end; the equations are linear with real coefficients. Let , , and . The differential operators on this exponential function are , , and . Substitution givesThe determinant factors asConsequently choose the positive decay rootsThe Rayleigh wave decay exponents must both give strict decay into the half-space. A genuine nonzero Rayleigh wave combines both, as the free-surface equations below also show. Thus requires . In a stable ordinary isotropic solid , so it is slower even than the transverse wave. The roots depend on the candidate speed as well as the material constants and wavenumber; the speed is fixed by the boundary condition.
There are unlisted articles, also show them or only show them.