The focusing cubic nonlinear Schrödinger equation has the normalizationthe positive cubic term focuses the field and permits bright solitons on zero background.
In light-cone coordinates, the sine-Gordon equation can be written . Its inverse scattering transform, solitons, breathers, and scaling symmetries make it an integrable system.
The sinh-Gordon equation is an integrable nonlinear wave equation. Under the one-dimensional reduction with , it becomesWriting gives and the first integral
Radial normalization of the hydrogen ground state by  Codex 0 Created 2026-09-24 Updated 2026-09-24
With normalized , the radial ground state hasIf the angular factor is absorbed into the spherically symmetric wavefunction, its normalization constant is instead .
Radial Schrodinger equation for the hydrogen atom by Codex 0 Created 2026-09-24 Updated 2026-10-03
Codex 0 Created 2026-09-24 Updated 2026-10-03Neglecting spin, bound hydrogen eigenstates are labelled , where and . Their unperturbed energy depends only on .
Postglacial rebound is uplift following removal of an ice load. It reflects viscous flow in the mantle and elastic or viscoelastic deformation of the lithosphere.
Glaciology studies glaciers, ice sheets, snow, and their interaction with climate, oceans, and the solid Earth.
A planetary ice shell is a solid water-rich layer overlying an ocean or deeper planetary interior. Its thickness can be controlled by thermal conduction, basal heat flux, surface radiation, and solid-state mantle convection.
The Solid Earth comprises a planet's solid inner core, liquid outer core, viscously deforming mantle, and mechanically stronger crust and lithosphere.
Geometric group theory studies finitely generated groups through their actions on metric spaces and through the large-scale geometry of spaces such as their Cayley graphs.
Knot theory studies closed curves in three-dimensional Euclidean space that cannot intersect themselves, and asks which can be deformed into one another without cutting or passing one strand through another. Its basic object is a knot: a smooth embedding of a circle, considered up to ambient isotopy. Several disjoint knots form a link. More generally, knot theory studies such embeddings in other manifolds and in higher dimensions.
The central surprise is that a flexible circle can carry permanent information about how it sits in space. A trefoil knot and an unknot each consist of just one circle, but no ambient isotopy turns one into the other. A knot diagram translates this spatial question into a finite drawing; Reidemeister moves describe the changes of drawing that preserve the knot. Knot invariants translate it into computations: unequal Alexander polynomials of a knot, Jones polynomials, or knot groups certify different knots. Equal values of a particular knot invariant generally leave the question open; even an isomorphism of knot groups alone is not a complete classification.
An early foundation for working with knot diagrams is Kurt Reidemeister's 1927 paper Elementare Begründung der Knotentheorie, published in volume 5 of Abhandlungen aus dem Mathematischen Seminar der Universität Hamburg, pages 24–32.[ref] Marc Lackenby's authored notes Elementary knot theory, Section 2.4, explain the Reidemeister move theorem and its role in searching for a certificate that two knot diagrams represent the same knot.[ref]
Topology studies topological spaces through open sets and continuous maps. Its central equivalence is a homeomorphism: a bijection that preserves continuity in both directions. This lets us distinguish spaces by connectedness or compactness even when numerical metric values are irrelevant. The open interval and the real line have the same topology in this sense, although only the former is a bounded set with its usual metric.
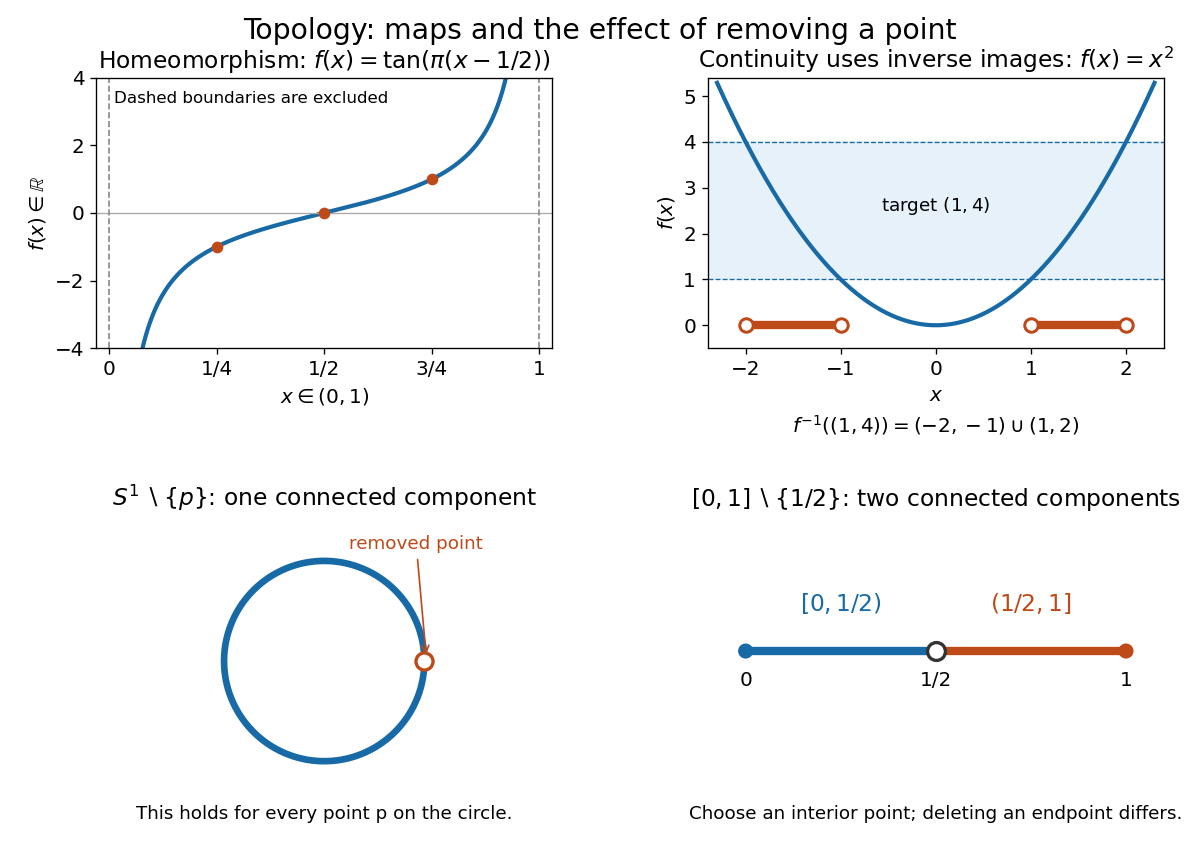

The upper panels show an explicit homeomorphism and the inverse image test for a continuous map. The lower panels exhibit an obstruction to a homeomorphism: removing any point from a circle leaves a connected space, whereas removing an interior point from a closed interval gives two connected components.
Homotopy is a different notion: it varies a continuous map continuously with a parameter and may collapse points. For example, contracts to zero. Thus this closed interval and a singleton have the same homotopy type, but there is no homeomorphism between them because there is no bijection. Homotopy equivalence need not preserve compactness. [ref]
The abstract viewpoint already appears explicitly in Tietze's 1923 paper: he describes topology as the study of properties invariant under invertible continuous maps with continuous inverses, and discusses axioms for neighbourhoods, citing Hausdorff's 1914 book, page 213. [ref]
https://gdz.sub.uni-goettingen.de/fulltext/PPN235181684_0088/00000294?_format=xml. Tietze, Beiträge zur allgemeinen Topologie I, page 290
A differential form is a smooth field of alternating multilinear maps that can be integrated over an appropriately oriented manifold of matching dimension. A one-form measures a directed displacement; a two-form measures an oriented area element. The point is to express what is being accumulated along a curve or over a surface without tying the answer to one set of coordinates. This makes line integrals, surface integrals, and the integral theorems of vector calculus parts of one construction.
For a concrete one-form, take in the plane. Travel from to along the bottom and then the right edge of the unit square. The horizontal leg contributes zero because ; the vertical leg has and contributes . Taking the left and then the top edge instead gives zero: the vertical leg has , and the horizontal leg again has . The two paths have the same endpoints but different integrals.
Now replace with the exact differential . Both paths give , because integrating an exact differential along a curve gives the endpoint difference of its potential. Here that difference is . This is the fundamental theorem of calculus applied to a function along a parametric curve, and is the basic reason conservative vector fields have path-independent work.
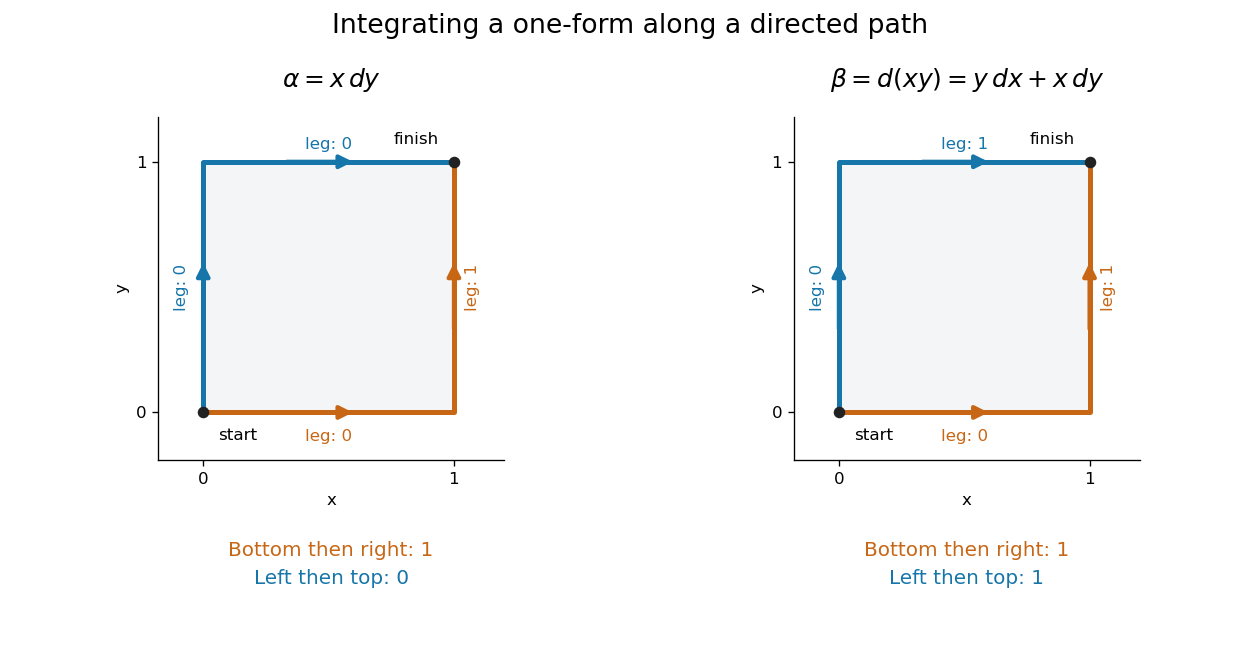
Two routes between the same endpoints distinguish a path-dependent one-form from an exact differential
. Details. 
The exterior derivative records the local obstruction in the first example: . The Generalized Stokes theorem turns the difference between the two path integrals into the integral of this two-form over the square, whose oriented area is . Interior edges cancel when adjoining pieces are added; only the outer boundary survives. That cancellation connects a local calculation with a global measurement.
More precisely, a degree- differential form assigns to each point a multilinear scalar-valued function of tangent vectors at . Interchanging two arguments changes its sign. A one-form is therefore a covector field, while a two-form vanishes on a pair of parallel vectors. Degree zero simply means a smooth function. The space is a vector space; the wedge product of differential forms combines degrees, and the exterior derivative raises degree by one.
The usefulness goes beyond bookkeeping. Pullbacks of a differential form supply the right transformation law automatically under a coordinate change. The Generalized Stokes theorem unifies the fundamental theorem of calculus, Green theorem, Stokes theorem, and divergence theorem. Meanwhile, the distinction between closed differential forms and exact differential forms detects holes through de Rham cohomology. Reyer Sjamaar develops these connections in sections 5.4 and 9.3 of his university notes. [ref].
There are unlisted articles, also show them or only show them.