A topological -manifold without boundary is a topological space satisfying three conditions: it is Hausdorff, it is second countable, and every point lies in an open set with a homeomorphism onto an open set . Here is a fixed dimension of a manifold, and has the usual topology of Euclidean space. The pair is a coordinate chart. Unless explicitly qualified, “topological manifold” here means without boundary.[ref]
The Hausdorff condition requires disjoint open neighbourhoods for distinct points. Second countability requires a countable basis of a topology. Neither follows merely from the local homeomorphisms: non-Hausdorff manifolds fail the first condition, while an uncountable disjoint union of copies of the real line fails the second. Indeed, a basis of a topology must supply a different nonempty member inside each copy, so it cannot be countable.
The circle and the real line are both one-dimensional topological manifolds, with the same local model. Their global topologies differ: the circle is compact, while the real line is not. By contrast, the junction of a topological tripod already fails the local test. Thus local coordinate charts specify what kind of small pieces are allowed; global topological invariants distinguish how those pieces fit together.[ref]
Introduction. Introduction to Topological Manifolds by John M. Lee, second edition, Chapter 1, pages 1–3 on local models and pages 5–6 on topological invariants
The usefulness of a topological manifold is that local questions about continuity can be transported into Euclidean space, while compactness, connectedness, and the fundamental group still record global information. For calculus, further structure is needed: a smooth atlas requires smooth transition maps, letting the chain rule reconcile derivatives computed in different coordinate charts. A topological atlas by itself only guarantees homeomorphisms between coordinates.[ref]
Week 2 course notes. Topology I: smooth manifolds, Week 2, Section 1.2, equation (11) and Definitions 1.15–1.16, pages 5–6
A topological atlas is a family of coordinate charts whose domains form an open cover of a topological manifold. Each point must belong to at least one chart domain; no individual domain needs to cover the entire topological manifold. On overlaps, topological transition maps describe the same points in two coordinate systems.
For two coordinate charts in a topological atlas, the topological transition map is the homeomorphismBoth domains are open sets in Euclidean space. Function composition gives and wherever all three coordinate charts overlap. These identities express consistency of the coordinate descriptions; imposing smooth functions as the coordinate changes gives a smooth atlas.
Take the circle with its subspace topology. Write for its west point and for its east point. Two coordinate charts obtained by stereographic projection areBoth take values in the entire real line. Geometrically, join to and intersect the resulting line with : the height is . Projecting from instead gives height . Each projection omits its own starting point, but the other coordinate chart includes that point. Hence .[ref]
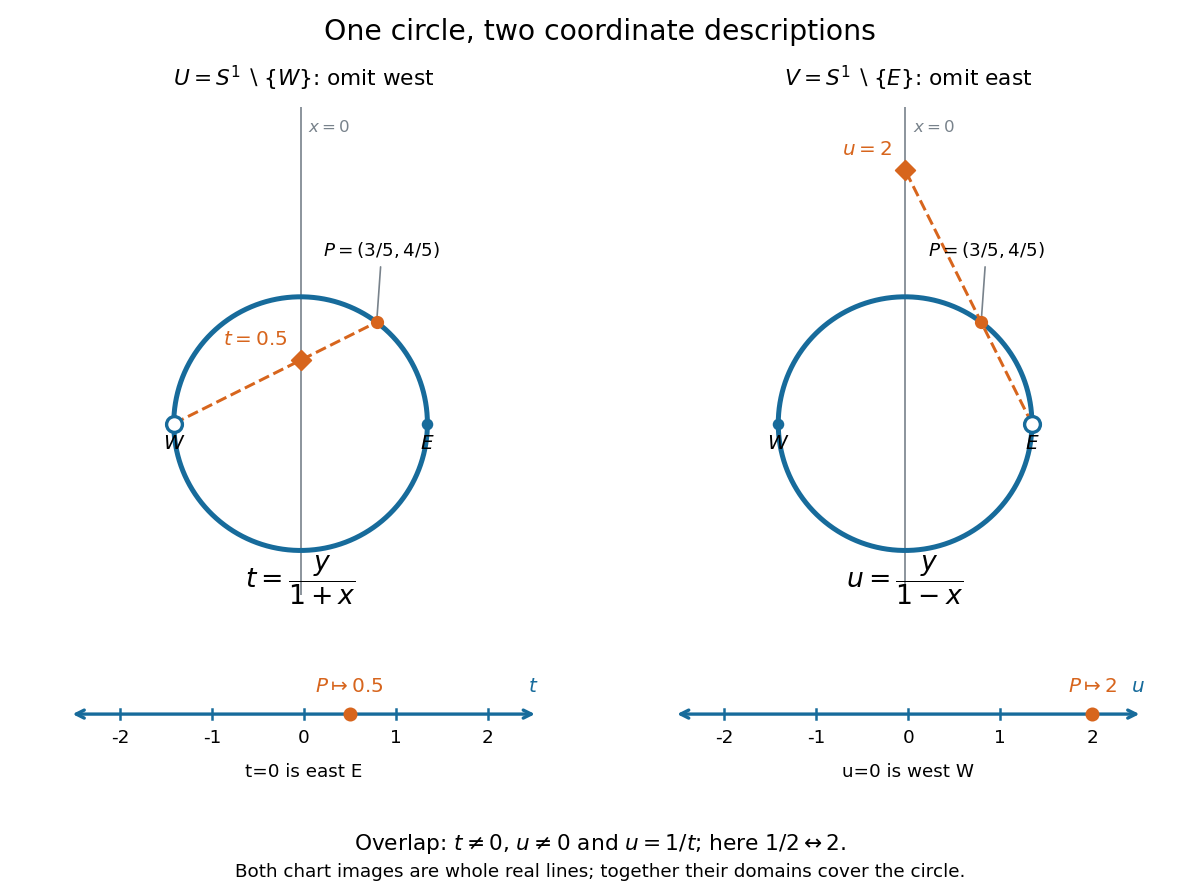
To verify the homeomorphisms, solve the displayed equations for . The inverse functions areEach formula lies on the circle, avoids its excluded point, and is continuous for every real argument. Substitution into the projection formulas returns or ; substitution in the other direction returns . Thus these are continuous bijections with continuous inverse functions, as required for coordinate charts. Since the Euclidean plane is Hausdorff and second countable, the subset with its subspace topology is too. This checks all three conditions for a topological manifold, rather than just drawing a smooth-looking curve.
On the overlap , both are excluded, so . Using , the topological transition map isFor example, has and . The two connected components of the overlap, the upper and lower arcs, correspond to the positive and negative parts of the punctured real line. The values and represent and , respectively, and belong to only one chart each. The reciprocal coordinate change and its inverse function are smooth functions away from zero, so this topological atlas also supplies a smooth atlas.
Why can neither chart be enlarged to a single coordinate chart on the whole circle? The circle is a closed set and a bounded set in the Euclidean plane, hence compact by the Heine-Borel theorem. A global coordinate chart would give a homeomorphism to a nonempty open set . Its image would be compact and therefore closed in the real line. By connectedness of the real line, this forces , which is not compact. This is the one-dimensional instance of no compact manifold has a single Euclidean chart. Locally the circle is indistinguishable from the real line; globally compactness obstructs a single chart.
For , a topological -manifold with boundary is a Hausdorff second-countable space locally homeomorphic to relatively open sets in the half-space . The openness here is in the subspace topology of , not necessarily in . Its intrinsic boundary consists of points sent to ; the remaining points have ordinary coordinate charts with images open in Euclidean space. The intrinsic boundary is independent of the chosen chart.[ref]
Week 2 course notes. Topology I: smooth manifolds, Week 2, Section 1.3, equation (21), Definition 1.21 and Remark 1.24, page 7
The closed interval illustrates the distinction: its interior points have open interval charts, while and have charts modeled on , using and . Its intrinsic boundary is . The circle has empty intrinsic boundary even though its boundary of a set as a subset of the Euclidean plane is the whole circle. A topological manifold without boundary is therefore a special case with , and a smooth atlas on the half-space charts gives a manifold with boundary in the smooth sense.
The category of topological manifolds has topological manifolds without boundary as its objects of a category and all continuous maps between them as its categorical morphisms. Allowing every dimension of a manifold lets maps connect spaces of different dimensions. Identity functions are continuous, and function composition preserves continuity, so the category laws are inherited from functions. Its isomorphisms are exactly homeomorphisms.
In coordinate charts on and on , a continuous map is represented locally by on . Changing coordinate charts changes this expression through topological transition maps, while itself stays fixed. This viewpoint separates the underlying continuous map from the coordinates used to describe it; restricting to smooth manifolds and smooth maps gives the corresponding smooth category.
A piecewise linear ball is a simplicial complex admitting a homeomorphism to an -simplex that is linear on the simplexes of suitable finite simplicial subdivisions. Its boundary is a piecewise linear sphere.
Two piecewise linear balls of dimension three glued along a common boundary disk form another piecewise linear ball. The Schoenflies theorem identifies each boundary pair with a sphere and a hemisphere. Coning the resulting boundary homeomorphisms extends them over the balls, which then become the two halves of a standard ball. The same argument shows that removing a ball attached along one boundary disk leaves a ball.
A smooth four-manifold is a four-dimensional smooth manifold. Its intersection form and gauge-theoretic invariants impose strong constraints on its possible smooth and symplectic structures.
Remove tubular neighborhoods of diffeomorphic embedded oriented surfaces with opposite normal Euler numbers, and glue their boundary circle bundles by a fiber-reversing identification. The resulting smooth manifold is a fiber sum. The square-zero case uses trivial normal bundles. Additional symplectic hypotheses give a symplectic fiber sum along a square-zero surface.
For standard unknotted spheres contained in four-balls in and , the standard fiber-reversing gluing gives the displayed connected sum. The complement of an unknotted in is , and its double is . The portions of and outside the four-balls remain as connected summands. Taking both ambient manifolds to be the Complex projective plane gives a smooth fiber sum with no symplectic form, by the symplectic connected-sum obstruction.
If a closed oriented smooth four-manifold splits as a connected sum with both , its ordinary Seiberg–Witten invariants of a four-manifold vanish. Combined with Taubes nonvanishing theorem, this obstructs a symplectic structure in that orientation.
A closed symplectic manifold of real dimension four with has a nonzero Seiberg–Witten invariant of a four-manifold in its canonical structure, with value . The positive index of the intersection form hypothesis avoids chamber dependence. This provides the symplectic connected-sum obstruction.
A closed symplectic manifold of real dimension four cannot be a connected sum of two oriented smooth four-manifolds each with positive positive index of the intersection form. The total exceeds one; Taubes nonvanishing theorem and connected-sum vanishing of the Seiberg–Witten invariant would force the same invariant to be both nonzero and zero.
Glue two copies of a compact manifold along their boundaries to form its double. A collar gives the double a smooth structure when is smooth. Folding the copies onto gives a retraction; in particular, inclusion of either copy is injective on homology. For an oriented manifold, use the opposite orientation on the second copy.
A topological tripod is three copies of the closed interval with their zero endpoints identified to a single junction . Equivalently, embed three line segments with distinct directions in the Euclidean plane and use the subspace topology. It is a compact, connected metric space, and is Hausdorff, second countable, and paracompact. Every interior arm point has a coordinate chart to an open interval, and each outer endpoint has a half-interval chart as in a topological manifold with boundary. The junction has neither kind of chart.
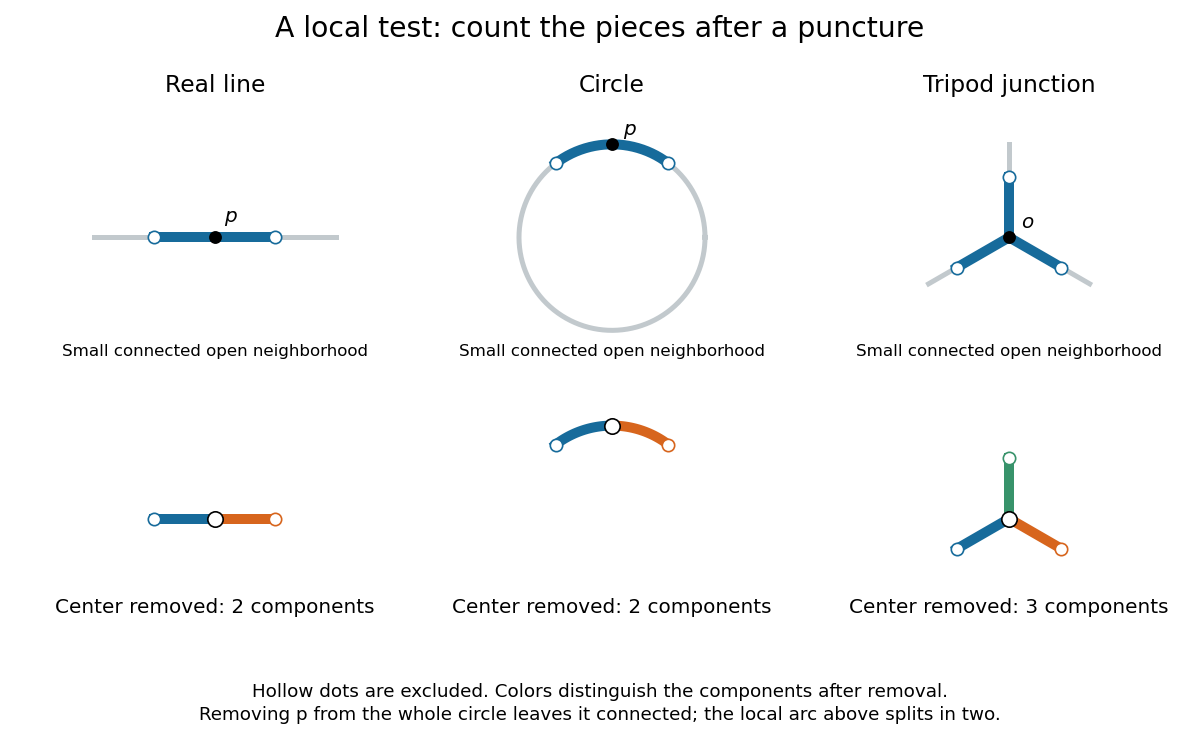
Removing the center of a small neighborhood leaves two pieces on a line or circle, but three at a tripod junction
. Details. Here is a precise local obstruction. Let be a small open neighbourhood of consisting of initial segments of the three arms, excluding their outer endpoints. Every connected open neighbourhood of contained in contains an initial segment on every arm, because is open at . Its intersection with each arm has no gaps: if a point between and a point of were missing, cutting there would separate the part beyond it from the rest of , contradicting connectedness. Thus has exactly three connected components, one interval per arm.
Suppose a coordinate chart to the real line existed at . Choose a small open interval about lying inside , and restrict the chart to . This is a connected open neighbourhood of contained in . Removing leaves three connected components in , while removing leaves two in . A homeomorphism preserves connected components, so this is impossible. This restriction step is essential: the count is proved for any sufficiently small connected chart neighborhood, not merely one chosen drawing.
A higher dimension of a manifold cannot repair the junction. For , repeat the argument with an open ball about : a punctured open ball in is path-connected, whereas still has three connected components. A zero-dimensional chart would make an isolated point, which it is not. A chart at a boundary point of a topological manifold with boundary similarly gives a punctured relative half-ball: one connected component when , and a path-connected space when . Consequently the topological tripod fails the local definition even when intrinsic boundary is allowed.
The circle provides a useful warning about scale: deleting a point from the whole circle leaves a connected space, but deleting it from a sufficiently small connected arc leaves two connected components. Local chart tests use the latter. The circle and interval are not homeomorphic article uses deletion from the whole spaces for a different, global obstruction.
Invariance of domain says that a continuous map that is an injective function between topological manifolds without boundary of the same dimension is an open map. It is useful in the Penrose singularity theorem: projecting a compact achronal boundary along timelike curves onto a Cauchy hypersurface gives a nonempty subset that is both open and closed, forcing that connected Cauchy hypersurface to be compact.
A smooth manifold carrying a nondegenerate bilinear form on each tangent space, with one negative and all remaining positive eigenvalues, or the overall reversed-sign convention. Its nonzero null vectors have vanishing metric quadratic form.
The metric signature records the signs of the diagonalized nondegenerate metric tensor, equivalently its numbers of negative and positive directions. For a four-dimensional Lorentzian manifold, both and its overall negative convention are common. The numerical signs of contractions and component Hodge star operator identities must be consistent with that choice and the orientation.
In metric signature , a spacelike submanifold of a Lorentzian manifold has an induced metric tensor defining a positive-definite quadratic form. With the overall reversed metric signature, its induced metric tensor instead has only negative eigenvalues. The definition applies to any dimension: enclosing charge-integration surfaces in four dimensions are two-dimensional examples, whereas a spacelike Cauchy hypersurface in four dimensions is three-dimensional.
A topological manifold has dimension when its manifold charts have coordinate domains open in . For a smooth manifold, each tangent space has dimension , and a tangent bundle has vector bundle rank .
The codimension is the difference between the dimension of a manifold and that of its submanifold. For complex submanifolds, complex codimension one means real codimension two.
Attaching an index- handle to an -dimensional manifold with boundary glues along . The complementary replaces the attaching region in the boundary.
A four-handle is an index-four handle. In a four-dimensional handle decomposition it is a four-ball attached along its whole boundary, a three-sphere. It caps a spherical boundary component left by earlier handle attachments.
An index- handle in dimension is this product of disks, attached along . Its core disk is , and its belt sphere is . The complementary boundary piece is . Crossing a critical point in the Morse handle-attachment theorem produces precisely this local change.
A framed embedding of the left-hand region in an -dimensional manifold specifies an index- surgery. Remove its interior and glue the right-hand region along their common boundary . The cobordism realizing this change attaches an index- handle of dimension . On an oriented surface, index-two surgery cuts out an annular neighbourhood of a simple closed curve and caps its two boundary circles.
A zero-handle in an -dimensional handle decomposition is . Its attaching region is empty, so it starts a connected component of the manifold. In dimension four it is a four-ball; adding one-handles and two-handles gives a four-dimensional handlebody with a two-dimensional CW spine.
The core disk of a -handle attachment is . Together with its cap in the preceding stage, it often represents a homology class; for a surgery trace, capped two-handle cores give the basis of its surgery linking matrix.
A handle decomposition builds an -dimensional manifold by successively adjoining along . The attaching data comprise an attaching sphere and its framing of an embedded sphere. Reading a decomposition backwards replaces index by index and interchanges its attaching spheres and belt spheres.
In a critical level handle embedding, the handles occur at distinct heights in an ambient product with the real line. Between consecutive heights, the boundary of the already attached handles travels through a product collar neighbourhood. At a handle height the horizontal slice contains the handle, attached to the incoming boundary along its attaching region. This separates the local topology changes from the intervening product regions.
Write each sphere as two disks, . In their product, is a zero-handle; and are two-handles. Their attaching circles are the core circles of the complementary solid tori in , hence a Hopf link. Constant normal directions from the disk factors give both components the zero Seifert framing. The remaining is a four-handle. This product construction establishes the actual diffeomorphism type, rather than relying on its intersection form alone. The resulting intersection matrix is .
Attach two one-handles to a four-dimensional zero-handle, then a two-handle along the commutator of their generators with the product zero framing. The result is . Its spine is the usual cell structure of the torus: one vertex, two one-cells, and a two-cell attached by . An embedded representative of its generator is obtained by taking a once-punctured torus carried by the two one-handles and capping its boundary by the core disk of the two-handle. It meets the relative co-core once and has self-intersection zero. The boundary is , whose integral homology has ranks .
A handle slide replaces the framed attaching sphere of one handle by a band sum with a parallel copy of another handle of the same index. It changes the attaching data while preserving the diffeomorphism type of the resulting manifold. On the handle incidence matrix it performs an elementary row operation, or a column operation when applied to the dual decomposition.
In the intermediate-index range, if an attaching sphere meets a belt sphere at exactly one transverse point, handle slides can remove the intersections of every other attaching sphere with . The dual slides then remove the intersections of with the other belt spheres. Each move uses a band to the unique pivot sheet and a local isotopy removing the old and new intersections. If and , the remaining incidence block is , the Schur complement of the pivot. Extreme-index cases need separate hypotheses.
The belt sphere of an index- handle is in the boundary after attachment. It is the attaching sphere of the dual index- handle. Its intersections with the attaching spheres of later handles detect passages through this handle.
The attaching sphere of an index- handle is in the previous boundary. Its framing of an embedded sphere identifies a neighbourhood with and specifies the handle attachment.
Relative to a triangulation, a normal surface meets every tetrahedron in disjoint normal disks: four types of triangles cutting off vertices and three types of quadrilaterals separating opposite pairs of edges. A normal disk meets any edge at most once; its face arcs join distinct edges. Two different quadrilateral types cannot coexist in a tetrahedron.
For tetrahedra, count the seven disk types in each tetrahedron. Across each glued face the counts of each of its three normal arc types must agree. These are homogeneous linear equations with integer coefficients. An admissible solution also has at most one nonzero quadrilateral type in each tetrahedron. Matching the arcs in their boundary order reconstructs the normal surface up to an isotopy preserving the tetrahedra.
The weight of a normal surface counts its intersections with the edges of the triangulation. It is a positive linear function of its coordinates: each corner of a normal disk contributes the reciprocal of the number of tetrahedral sectors around its edge. Thus a nontrivial decomposition into compatible coordinate vectors gives both summands strictly smaller weight.
The Haken sum of compatible normal surfaces is obtained by resolving their intersection curves in the way that preserves the normal disk types. It adds normal surface coordinates, Euler characteristic and mod-two homology classes. The alternative local resolution can create returning face arcs and need not be normal.
A fundamental normal surface has a nonzero admissible coordinate vector which is not the sum of two nonzero admissible vectors. Fixing the allowed quadrilateral type in every tetrahedron reduces the problem to the Hilbert basis of a rational cone. There are finitely many choices of quadrilateral types and finitely many indecomposable vectors for each choice.
A punctured three-sphere is with the interiors of finitely many disjoint piecewise linear balls removed. Capping its spherical boundary components with balls restores . Removing another ball or gluing two such manifolds along one spherical boundary component preserves this class.
Suppose disjoint separating spheres cut a 3-manifold into pieces none of which is a punctured three-sphere. Compress one sphere along a disk disjoint from the others. The old sphere and the two new spheres enclose a three-times punctured sphere. At least one of the two pieces on the compressed side is not a punctured sphere; retain that new sphere and discard the other. The piece on its opposite side cannot become a punctured sphere, since capping its boundaries and applying the Three-dimensional Schoenflies theorem would make the original opposite piece a punctured sphere as well. Hence the number of spheres and the nontriviality condition can be preserved.
A three-ball is a three-manifold homeomorphic to the closed unit ball in . Its boundary is a two-sphere. Attaching a three-ball to a spherical boundary component is called capping that boundary; marked endpoints may be joined by a straight arc inside the cap.
A closed simply connected three-manifold is homeomorphic to the three-sphere. Now a theorem, this identifies every homotopy three-sphere with the standard sphere and removes homotopy-sphere ambiguities in three-dimensional connected-sum classification. Smooth structures are also unique in dimension three.
If a boundary surface inclusion has noninjective fundamental group map, there is a compression disk whose boundary represents a nontrivial element of that kernel. More generally the boundary can be required to avoid a prescribed normal subgroup if a singular disk with that property exists.
Start with a singular disk whose boundary represents a prescribed nontrivial class in a boundary subsurface. Repeatedly lift it through double covering spaces of regular neighbourhoods of its image. The number of distinct image simplexes strictly increases and is bounded by the number of domain simplexes, so the tower ends. At the top, vanishing first mod-two homology forces every boundary component to be a sphere. An embedded disk can then be constructed and projected down the tower. Resolving double curves preserves a boundary class outside a chosen normal subgroup, giving an embedded compression disk at the bottom.
A simple closed curve on the boundary of a three-manifold which is nullhomotopic in the manifold bounds a properly embedded disk. The boundary curve is retained; the Loop theorem can instead find a different simple essential curve in a nontrivial kernel.
If an orientable three-manifold has nonzero , it contains an embedded essential two-sphere. Consequently a closed orientable irreducible three-manifold with infinite fundamental group is aspherical: its simply connected noncompact universal cover has zero second homotopy and top ordinary homology, hence is acyclic and contractible by the Hurewicz theorem and Whitehead theorem.
A complete hyperbolic three-manifold is a complete Riemannian manifold of dimension three with constant sectional curvature . Its universal cover is hyperbolic space and its deck group acts freely and discretely by Riemannian isometries. In the orientable case it is a torsion-free Kleinian group.
For complete finite-volume hyperbolic space manifolds of dimension at least three, an isomorphism of fundamental groups is induced, up to the usual basepoint-path choice, by a unique hyperbolic isometry. The finite-volume noncompact case includes the Prasad extension. Thus complete hyperbolic metrics on a fixed finite-volume three-manifold have no deformation moduli, unlike metrics on closed hyperbolic surfaces.
A smooth, piecewise-linear or locally flat embedded two-sphere in the three-sphere has two complementary components, each with closure homeomorphic to a three-ball. Equivalently a tame embedded two-sphere in bounds a ball on its compact side. Local flatness is essential; arbitrary wild sphere embeddings are excluded.
A closed orientable three-manifold is geometrizable if its prime summands can be split along finitely many disjoint essential tori into pieces whose interiors carry complete geometric structures modeled on the eight Thurston geometries. Prime decomposition and capping sphere boundaries precede the torus cuts; a single homogeneous geometry on the original connected sum is not required.
Every closed orientable three-manifold admits a prime and torus decomposition into pieces modeled on the eight Thurston geometries. In particular, a closed irreducible orientable three-manifold with fundamental group carries a flat metric. The Bieberbach theorem then identifies it with the three-torus because an abelian crystallographic group has trivial linear holonomy. Simply connected closed three-manifolds are three-spheres by the Poincaré conjecture.
The eight simply connected three-dimensional homogeneous model geometries are , , , , , , and . A geometric structure is a locally homogeneous structure obtained as a quotient of a model by a discrete freely acting isometry group, equivalently with compatible model charts.
A closed connected orientable smooth manifold of dimension three is prime when a decomposition as a connected sum forces at least one summand to be the three-sphere. Unlike an irreducible three-manifold, it may contain a nonseparating embedded two-sphere.
Every closed connected orientable three-manifold is a finite connected sum of prime three-manifolds, unique up to order and the insertion of three-sphere factors. The corresponding fundamental group is the free product of the summand groups. A prime orientable three-manifold is either irreducible or ; this separates aspherical infinite-group cases from the infinite cyclic case.
In an orientable three-manifold, an embedded nonseparating two-sphere has a product neighborhood. Join its two boundary spheres by an arc outside that neighborhood and take a regular neighborhood of the union. This region is with an open ball removed. Its boundary sphere exhibits the displayed connected sum. Consequently a prime but nonirreducible orientable three-manifold is .
A compact three-manifold is boundary-irreducible when there is no embedded disk with interior in the manifold and boundary an essential curve in its boundary. Thus its boundary has no compressing disk.
An orientable three-manifold is irreducible if every embedded two-sphere bounds a three-ball. This makes innermost-disk simplifications of embedded topological surfaces possible without changing the ambient three-manifold.
In the orientable case an excellent compact three-manifold is an irreducible three-manifold and a boundary-irreducible three-manifold, is not a ball, contains a two-sided properly embedded incompressible surface, and has every properly embedded incompressible zero-Euler characteristic surface a boundary-parallel surface. In particular it has no essential annulus or torus. These properties give lower bounds on the Thurston norm of classes with essential boundary.
In a compact connected orientable three-manifold with no spherical boundary components, every embedded knot is homotopic to a knot with an excellent three-manifold as exterior. In particular this can preserve the generator class in , or the winding number of a satellite pattern one class in a solid torus. Homotopy here is weaker than isotopy.
For a compact oriented three-manifold, the integral relative class has norm the minimum of over properly embedded oriented topological surfaces representing . Homogeneity and continuity extend it to real relative homology. It is a seminorm, since spheres, disks, annuli and tori have zero cost.
For with a pair of pants and its circle fiber, a horizontal surface in a Seifert fibered space of degree has ; vertical surfaces in a Seifert fibered space have zero cost. Cutting and pasting these representatives, and classifying essential surfaces, proves . The dual Thurston polytope is therefore the segment between the two functionals under the natural pairing.
In an irreducible three-manifold with incompressible boundary, a minimizing surface can be cut along a separating incompressible torus after removing inessential intersection circles. The essential pieces have no disk or sphere components, so their costs add. Minimizing independently in the pieces and gluing their matching boundary curves gives the corresponding upper bound. This allows Thurston norm calculations for satellite knots.
The dual polytope consists of the real linear functionals on such that for every . Thus it is the polar of the unit ball of the Thurston norm and annihilates that seminorm's kernel.
An incompressible surface is a properly embedded two-sided topological surface with no compressing disk, subject to the usual exclusion of inessential spherical components. A compressing disk has boundary an essential closed curve on the topological surface and interior disjoint from it.
A hierarchy is a finite sequence of cuts along properly embedded two-sided incompressible surfaces, without spherical components, ending in disjoint three-balls. Disks are allowed. For an ambient manifold which is not orientable the two-sided cutting surfaces need not themselves be orientable. The existence of a hierarchy does not imply that every choice of incompressible cuts terminates.
A map between compact connected orientable irreducible 3-manifolds with nonempty boundaries, injective on the boundary and on the fundamental group, is homotopic to a homeomorphism relative to the boundary. The boundary determines degree , and the cover corresponding to the image of the fundamental group consequently has one sheet. Straighten the preimage of an incompressible hierarchy surface, cut both manifolds, and repeat. At the terminal balls, extend the prescribed boundary homeomorphisms by coning. The homotopies and homeomorphisms glue across the straightened surface collars.
In an orientable irreducible three-manifold, an incompressible cut is fundamental group-injective by the Loop theorem. Lift a three-manifold hierarchy to the universal cover. The terminal ball pieces are contractible and their gluing surfaces have contractible universal covers. The incidence graph is a tree, by the van Kampen theorem normal form for successive cuts. Finite subtrees are contractible by successively attaching a terminal piece along a contractible intersection. Every sphere map has compact image contained in a finite subtree, so all higher homotopy groups of the universal cover vanish.
Let be a once-punctured torus and let be a nonseparating essential curve. The annulus is an incompressible surface in . Cutting gives a pair of pants times an interval. Both products are genus-two handlebodies, since a compact connected surface with boundary times an interval is a handlebody of genus .
A compression disk for a two-sided embedded surface in a three-manifold is an embedded disk meeting exactly in its boundary, with boundary essential in . Replacing an annular neighborhood of this boundary by two parallel copies of the disk reduces the surface's genus or separates it into simpler pieces.
A properly embedded topological surface is boundary-parallel if it cobounds a product region with a topological surface in the ambient boundary, with the remaining boundary of that product contained in the ambient boundary. An annulus parallel into one boundary component has zero net oriented boundary class on that component.
In an orientable irreducible Seifert fibered space, an essential two-sided incompressible surface that is also a boundary-incompressible surface can be isotoped to a horizontal surface in a Seifert fibered space or a vertical surface in a Seifert fibered space.
A properly embedded topological surface is boundary-incompressible when no disk in the ambient three-manifold joins an essential arc on the topological surface to an arc on the ambient boundary, with the disk's interior disjoint from both.
A Heegaard splitting divides a closed three-manifold into two handlebodies with common boundary. For a three-manifold with boundary, one uses compression bodies, which can retain negative boundary components.
Two nonseparating compressing disks on opposite sides with the same boundary form an embedded sphere. Cutting each handlebody along its disk leaves it connected, so the sphere is nonseparating in the glued three-manifold. Capping the two resulting sphere boundaries gives a splitting of one lower genus of the remaining summand; the removed summand is .
The least genus of a Heegaard surface among all Heegaard splittings of a closed orientable three-manifold. Having a splitting of genus only proves ; stabilization supplies larger-genus splittings of the same manifold.
Heegaard Floer homology assigns groups to a closed oriented three-manifold with a Spin-c structure. A pointed Heegaard diagram of genus gives product Lagrangian tori ; the chain complex is generated by their intersection points and its differential counts Whitney disk classes represented by holomorphic disks. The minus, infinity, plus and hat versions use different powers or quotients of the variable . The Heegaard Floer cobordism maps and the Mixed Heegaard Floer invariant relate these groups to smooth four-dimensional topology.
For a closed smooth oriented four-manifold with , remove two balls to obtain , and choose an Admissible cut for a Heegaard Floer mixed map. Positivity and naturality show that the minus map of lands in , while the plus map of descends from . ThusThe coefficient of the bottom plus generator in this map, applied to , defines , up to the orientation sign, with . It vanishes unless . The construction is independent of the admissible cut by the cobordism composition and associativity laws. Two positive pieces explain the condition .
If and a connected closed oriented embedded surface has positive genus and , thenBlow up points on and choose the exceptional determinant classes which increase the Chern pairing on its proper transform by . The Blowup formula for the mixed Heegaard Floer invariant preserves nonvanishing, while the proper transform has square zero. A cut disjoint from it allows the relevant cobordism map to pass through . These groups vanish when the Chern pairing exceeds , so the mixed map would then vanish, a contradiction. Reverse the surface orientation for the absolute value. The positive-genus condition is essential: a small nullhomologous sphere has square zero and zero pairing and would violate the displayed inequality.
Let , and let be the exceptional sphere. Extend a Spin-c structure by . Then . More generally, an evaluation introduces the factor . This follows by putting the blowup on one side of an admissible cut: the punctured exceptional piece is negative definite, its minus and plus tower maps are multiplication by this power of , and the cobordism composition law gives the formula. In the case the exponent is zero, so nonvanishing is preserved.
For a knot in an integral homology three-sphere and , fix a Spin-c structure on the -surgery. Write for structures on zero-surgery with , using a capped Seifert surface. In compatible labels the completed-minus triangle isOne can equally use the plus theory without completing. The first map is the congruence-restricted zero-surgery trace map; the last is the sum of reverse, orientation-reversed -surgery trace maps. The middle map uses a Heegaard triple with an auxiliary lens-space generator. For that lens space is , giving the usual three two-ended cobordism maps. For it is important to retain the auxiliary boundary and its fixed Spin-c structure. The U-adic completion of Heegaard Floer homology makes the sums of maps well-defined.
A smooth oriented cobordism with a Spin-c structure induces -equivariant maps on the corresponding Heegaard Floer homology groups. A handle decomposition defines the maps using generator selection for one- and three-handles and holomorphic triangle counts for two-handles. Composition sums over extensions of the prescribed Spin-c structures. When the boundary determinant classes are torsion, the absolute grading shift isThe square is defined using the rational relative lift. If , the infinity map vanishes. Between rational homology spheres, when , the infinity map is an isomorphism of Laurent towers.
An admissible cut splits a four-dimensional cobordism as , with , and with the Mayer-Vietoris connecting map equal to zero. The last condition removes the ambiguity in gluing Spin-c structures on the two pieces. Positivity makes both infinity cobordism maps vanish, allowing passage through the Reduced Heegaard Floer homology of . A useful cut is the boundary of a neighborhood of a positive-square embedded surface, chosen so that its complement still has a positive direction. The nonzero normal Euler number makes of the neighborhood surject onto of its boundary, proving the connecting-map condition.
Use the convention that is generated by with , and . The chain complexes areThe last complex is generated by . Equivalently it is with its absolute grading shifted up by two. The short exact sequence gives the fundamental long exact sequence. For a rational homology sphere in each Spin-c structure, . The plus tower is , with bottom degree ; its corresponding minus tower is a free module with top degree .
Let on have . The ordinary groups areA sufficiently wound genus-one diagram gives a two-generator summand whose chain differential is multiplication by : the two relevant disks have opposite coherent signs and basepoint multiplicities differing by . The map is injective over , so its homology is the displayed quotient. Multiplication by is invertible in the quotient, showing that minus-to-infinity is an isomorphism and that the plus and hat groups vanish. In the U-adic completion of Heegaard Floer homology, is a unit, so both completed minus and infinity groups vanish. This example shows why genus bounds for the completed-minus or plus groups must not be transferred unchanged to the ordinary minus theory.
The reduced minus and plus groups areThe connecting homomorphism of the fundamental long exact sequence induces an isomorphism of degree . This follows immediately from exactness: its image is the indicated kernel, and its kernel is precisely the image quotiented out on the plus side. These groups isolate the information lost by inverting .
Completing the minus chain complex in powers of replaces by the formal power series ring ; its homology is written . This permits infinite sums of Heegaard Floer cobordism maps whose exponents tend to infinity, as occur in surgery formulas. A series with constant coefficient is a unit: its inverse is found recursively, or by the geometric series for its positive-order part. Such a series need not have a polynomial inverse, which is why exact triangles involving sums over all Spin-c extensions require a completion in the minus theory. Individual homogeneous cobordism maps are still defined on the ordinary minus groups.
For an admissible pointed Heegaard diagram, is a free chain complex with one generator for each point of . Each generator is an unordered selection containing exactly one intersection on each alpha circle and exactly one on each beta circle. After choosing coherent orientations,Here is the moduli space modulo strip translation, is the Maslov index, and is multiplicity at the basepoint. Holomorphic representatives have nonnegative domain multiplicities. The differential lowers grading by one and lowers it by two. Boundary strata of one-dimensional moduli spaces give the cancellation proving . Its homology is .
Over , holomorphic disk moduli spaces in a Heegaard Floer chain complex must be oriented compatibly with gluing: the orientation of a concatenated disk class is the product determinant-line orientation of its two factors. Boundary orientations of compactified one-dimensional moduli spaces then make broken disks cancel, yielding . Isolated regular disks contribute or . Changing the chosen orientation at an intersection generator changes the corresponding row and column signs of the differential and yields an isomorphic integral chain complex. Cobordism triangle counts require compatible orientation choices as well; an overall orientation ambiguity accounts for the usual sign ambiguity of the closed invariant.
An embedded positive domain which is a bigon or rectangle, has convex alternating alpha and beta corners, and contains no other selected coordinate in its interior, has Maslov index one. A bigon has Euler measure and two corner averages ; a rectangle has Euler measure zero and four corner averages . For the usual regular complex structure, its holomorphic disk count modulo translation is . For a bigon the Riemann map to the strip is unique up to translation. For a rectangle, the tautological correspondence represents the disk in the symmetric product by a branched double cover of the strip onto the rectangular domain: its conformal modulus fixes the branch parameter, and the only remaining freedom is translation. The resulting isolated regular disk gives one point in the oriented moduli space. The differential coefficient is , so a basepoint-free domain contributes a unit.
For generators in the same Spin-c structure and a Whitney disk class joining them,The ambiguity is the divisibility of on ; a torsion determinant class gives an integer relative grading. Adding a sphere class changes by two and by one, so it leaves the difference unchanged. For a domain , the index can be calculated as , where is Euler measure and each is the sum of averages of the four adjacent region multiplicities at the selected intersections.
For a torsion Spin-c structure, the relative grading of Heegaard Floer homology lifts canonically to a rational absolute grading, normalized by the bottom plus generator of having degree zero. Multiplication by has degree , and a Heegaard Floer cobordism map has degree . The correction term is the lowest grading of the image of in for a rational homology sphere. A pure tower then has bottom plus degree and top minus degree in the minus convention. Keeping that shift explicit prevents errors of two in surgery and mixed-invariant calculations.
For intersection generators , a Whitney disk is a map of a disk into the symmetric product, with its two boundary semicircles mapped to the two product tori and its endpoints mapped to . Its homotopy class belongs to . Projecting it to the Heegaard surface gives an integral domain. With the surface oriented, the convention is . The obstruction to a disk is the class obtained by joining the points along alpha arcs and returning along beta arcs. In the Heegaard Floer setup, its vanishing is equivalent to equality of the generators' Spin-c structures; for the rational homology sphere diagrams this is equivalent to .
Articles were limited to the first 100 out of 108 total.
Articles by others on the same topic



A **topological manifold** is a fundamental concept in topology and differential geometry. It is a topological space that, in informal terms, resembles Euclidean space locally around each point.