The center of pressure summarizes where a distributed normal pressure acts. On a planar contact region in , take a nonnegative pressure field and positive total normal force . Its center of pressure is the pressure-weighted positionIt is a continuous weighted mean, rather than necessarily the point of largest pressure. For discrete normal forces at , replace the integrals by sums. The resulting convex combination places the center of pressure inside the contacts' convex hull, or support polygon.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure (CoP) and Zero-moment point (ZMP), The special case of flat terrain
This definition preserves the torque as well as the resultant normal force. About the origin in the contact plane,A single vertical force applied at gives the same torque. Thus its line of action passes through the center of pressure. Conversely, force-and-torque measurements reconstruct the point throughThe origin and sign convention are part of these equations; moving the moment reference above the contact plane requires the corresponding torque translation.
For an original discrete example, four vertical reactions of , , and act at the successive corners , , and in metres. Their total normal force is , with and . Hence the center of pressure is . A rigid plate on four load cells provides a simple force platform implementation: calibrate the force channels and positions, then test known vertical loads at known locations. Subtracting the unloaded plate's own force and moment removes its contribution when reconstructing the added load. This is a proposed measurement test, not experimental data.
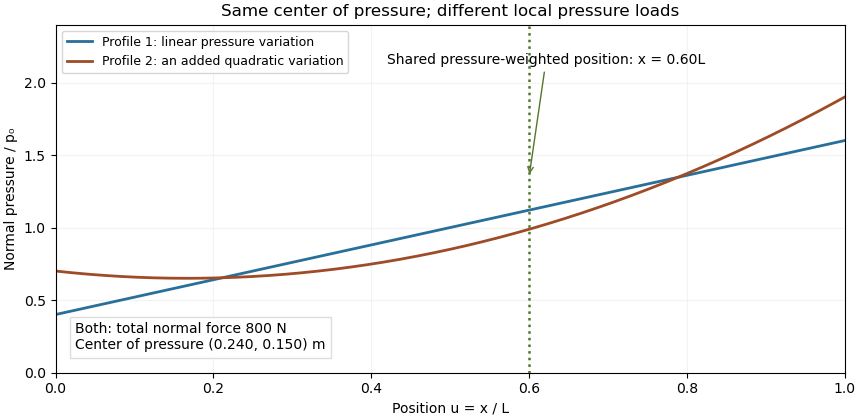
A continuous example shows the inverse problem hidden by this useful compression. On a rectangle of length and width , put and choose profiles independent of :Both profiles are positive on . The added polynomial has zero integral and zero first weighted integral:Thus both profiles give and the same center of pressure , while their peak pressures are and . These are pressure distributions with identical resultant force and center of pressure. For , and , both give despite different local loads. A force platform alone therefore does not identify every local pressure.

Two limits matter. If , the normal-pressure center of pressure is undefined. At fixed , an absolute moment error changes the reconstructed by , so fixed absolute measurement uncertainty is amplified as a contact unloads. Also, tangential contact forces can leave a residual contact torque at the center of pressure: with full resultant ,Selecting the normal-pressure centroid does not force this yaw torque to vanish.
Under the gravity-only, resting assumptions of support polygon, the center of pressure coincides with the horizontal center of mass projection. During motion it need not. For a planar model driven only by gravity and ground contact forces, at fixed center of mass height and with constant angular momentum about that centre, force and torque balance give . The acceleration term explains why the center of pressure is a contact-force measurement rather than a general substitute for center of mass position.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, equations cop and zmp and their stated constant-height/angular-momentum assumptions
In terrestrial robot locomotion, the center of pressure is the ground point summarizing the normal load shared by the active contacts. With contact positions and nonnegative normal reactions , its coordinates are the weighted averages and , provided the total normal force is positive. It lies in the current support polygon, but is a contact-force quantity rather than the robot's center of mass position.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure (CoP) and Zero-moment point (ZMP), flat-terrain definition
Force-sensor coordinates matter when reconstructing this point. Suppose a sensor origin lies height above a horizontal contact plane, with parallel coordinate axes. If it reports force and moment , the plane point is located at relative to that origin. Moment translation givesThe ground-plane transformation of a measured contact wrench must therefore precede interpreting moment/force ratios as a contact location.
For an original sensor example, take , force , and measured roll/pitch moments . The reconstructed point is . Ignoring the origin height would instead give . Those millimetre differences are coordinate effects, not a change in the physical pressure distribution.
During motion, the contact point need not equal the horizontal projection of the center of mass. The source's constant-height, negligible-angular-momentum-rate model relates their difference to horizontal acceleration; those assumptions must be established before using that simplified relation.[ref] A robot-foot experiment can compare known applied loads with the sensor's translated force/moment measurements. When approaches zero, reconstruction becomes sensitive to moment error; at zero normal load the normal-pressure point is undefined. A residual yaw couple may remain, as explained in residual contact torque at the center of pressure.
A ground-plane transformation of a measured contact wrench combines a change of coordinate axes with a change of the point about which moments are reported. A six-component wrench is incomplete without both pieces of metadata. Drake's primary SpatialForce reference explicitly tracks the application point and expressed-in frame separately from the stored force and torque values.[ref]
SpatialForce class in Drake documentation. Detailed Description; Shift and ShiftInPlace
Let rotate sensor-frame components into ground-frame components, and let be the ground-frame vector from ground origin to sensor origin . For measured force and moment about , the equivalent result about isThe plus sign uses the stated vector from the new origin to the old one. A shift expressed with the opposite vector uses the opposite sign. The offset and force must be expressed in the same axes before taking the cross product.
For a planar normal-pressure reconstruction with , computeThe special parallel-axis height correction in center of pressure is recovered with and .
For an original rotated-sensor example, use a 90-degree rotation about , sensor readings and , and . Rotation gives and . The translated moment is , yielding . The yaw moment remaining at that point is , so translating to the centroid does not erase the entire wrench.
A bench check applies known loads at known ground locations and repeats after changing sensor orientation. Geometry, tare loads, units and axis signs must all be included. A correct rotation with the wrong moment origin can still give an incorrect pressure location; a small normal load also amplifies reconstruction uncertainty.
The center of pressure locates the resultant of a distributed fluid pressure load relative to its moment. On a planar surface carrying parallel pressure forces, the first-moment ratio in center of pressure applies. On an airfoil, pressure variation and its resultant can change with the flow state, so the point is not a permanently fixed geometric centre. NASA's primary account explicitly distinguishes a moving center of pressure from retaining a force and pitching moment about an aerodynamic center.[ref]
Center of Pressure by NASA Glenn Research Center. Center of Pressure, Angle of Attack, and Aerodynamic Force sections
For an original hydrostatic plate example, take a vertical rectangle of width , extending from the free surface to depth in a constant-density fluid. If the same atmospheric pressure acts on its other face, the net gauge pressure at depth is . This hydrostatic relation follows from vertical force balance.[ref]
The Feynman Lectures on Physics, Volume II by Richard Feynman and others. Chapter 40, §40–1, Hydrostatics
The resultant and its depth areFor , , and , the net force is at depth . The area centroid is only one metre below the surface; the increasing pressure shifts the load's centroid downward.A tank demonstration can infer the resultant line from the force and hinge moment on a small plate while changing the water depth. The plate's own gravitational moment and the pressure on both faces must be included. This tests a specified pressure-load model, not a general claim that the point always lies below every geometric centre.
For aerodynamic net loads, differences of pressures on opposite faces can have both signs. The convex-hull property proved for nonnegative contact pressure then need not apply, and a small resultant with a finite moment makes its location ill-conditioned. A curved surface or a general wrench may also require a residual couple rather than a single force that removes every component of torque. The resultant convention and moment reference are therefore part of the definition.
A residual contact torque at the center of pressure is the moment left after translating a planar contact's resultant force to its normal-pressure centroid. Let the resultant wrench at an origin in be force and moment , with . Put , where and . Translation givesThe two horizontal moment components vanish, but the yaw component need not. The zero-moment-point construction for flat robot contact removes moments perpendicular to the surface normal; it does not assert that every component is zero.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, An aside: Zero-moment point derivation
A useful invariant makes the limitation exact. Since ,If this scalar is nonzero, no change of the moment origin can eliminate the entire moment vector. Replacing the whole contact by only one force at the center of pressure would discard that information.
For an original two-contact example, put equal normal loads of at and metres. Add tangential forces at the positive position and at the negative position. The total force is , the pressure centroid is the origin, and the opposing tangential forces give a pure yaw couple of . A friction coefficient of at least permits the stipulated tangential magnitudes at these loads.
A normal-load-only reconstruction would identify the correct centroid while missing the couple. A sensor measuring all force and moment components can distinguish the two situations. The origin, surface orientation and axis signs must be retained when comparing measurements. Near zero normal load, the centroid reconstruction itself becomes singular, independently of whether a tangential moment remains.
Pressure distributions with identical resultant force and center of pressure demonstrate that a pressure centroid is not a reconstruction of a pressure field. A normal-load measurement and its two first spatial moments constrain onlyA perturbation preserving all three integrals leaves the resultant and center of pressure unchanged. It is physically admissible only when the perturbed field remains nonnegative under the nonadhesive pressure model. The polynomial profiles in the parent article give one smooth example; the following construction shows that even a peak-pressure bound is missing.
Take a rectangular region of length and width , centered about its midpoint, and fix a normal load . A uniform field has pressure and centroid . Instead place the entire load uniformly on a smaller centered square of side , with zero pressure outside that square. Its pressure isSymmetry fixes the same centroid, and integration still gives total force . Yet its peak is , which has no upper bound as shrinks. Smooth symmetric concentrated profiles can provide the same conclusion if a continuous pressure field is required.
For an original numerical example, let , , and . Uniform pressure is . Concentrating the same load on a centered square gives while preserving the measured point . Both satisfy the stated nonnegative-field moment constraints.
Consequently a force/moment sensor cannot infer local peaks from the centroid alone. Local contact pressure from additional spatial measurements needs more data or justified material/contact assumptions, such as a constitutive model and known geometry. The source's normal-force centroid definition explains exactly which resultant information was retained.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure definition
The examples are inverse-problem constructions; they are not claims that arbitrary pressure maps can be realized by the same elastic surfaces.Local contact pressure from additional spatial measurements requires more information than total normal force and two first moments. One explicit reconstruction model partitions the contact into cells of known areas and centroids , assuming uniform pressure within each cell. Writing givesThese are three linear measurements of the cell loads. They need not determine every , as the nonuniqueness argument in pressure distributions with identical resultant force and center of pressure shows. The primary centroid definition specifies precisely which force/moment information is retained.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure definition
For an original four-cell example, use equal cells centered at successive positions with . Loads give and centroid . Adding to these loads changes neither the sum nor either first moment. Nonnegative loads permit . The alternative therefore gives the same global measurements.
An independently calibrated measurement of the first cell load resolves this one missing degree of freedom under the four-cell model. If it reads , the global moment equations recover the original other three loads. Their cell pressures are . Measuring all four cells instead provides redundant data for checking total load and the assumed geometry.
The local sensor output must actually represent a known cell-integrated force, or have a validated response model; a point sample cannot automatically be treated as an area average. Calibration errors, cell cross-coupling and imperfect coverage become additional measurement inputs. Spatial pressure-map resolution below a sensor cell remains limited even when every cell average is known: unmeasured within-cell peaks are not recovered by simply drawing a finer image. Constitutive or smoothness assumptions can add information, but must be identified as assumptions rather than extra measurements.
Spatial pressure-map resolution below a sensor cell concerns which variations of a contact pressure field can actually be distinguished by spatial measurements. A smaller display pixel does not imply a smaller independently measured contact region. The response of a pressure sensor, its sampling positions and any imposed reconstruction assumptions must be specified.
For an original ideal array model, cell of known area reports an area-average pressure,It determines that cell’s load , but not every value inside it. For a more general linear response, with known sensitivity . The null space of a spatial pressure measurement consists of perturbations whose weighted integrals vanish for all measured channels. Nonnegative fields that differ by such a perturbation remain indistinguishable in that model.
Consider square cells of side aligned with , and compare fields independent of :Every cell contains one full cosine period, so both fields give every channel the identical value . Yet varies between and . With and , a perfectly uniform field and a field spanning – produce the same ideal map. On an aligned finite rectangular array, the added cosine also has zero first moment within each cell, so even the global resultant and center of pressure agree. This is an inverse-problem construction, not a claim that both profiles arise from the same elastic contact geometry.
Cell averaging has a calculable spatial response. For a one-dimensional centered interval of width , averaging a complex wave multiplies its value at the interval center byThe first zero at explains the erased cosine above. Sampling introduces further ambiguity; even translating this ideal array cannot recover a component erased by its aperture at every position.
A regularity assumption can supply a conditional bound. If has a validated spatial Lipschitz constant over a square cell, its center value differs from its area average by at mostEvery point in the cell is at most half the diagonal from its center, so integrating the Lipschitz inequality proves this bound. For and , it gives about . The array readings alone do not establish that slope bound.
Interpolation chooses a finer representation from the measured values. SciPy explicitly describes its array zoom operation as spline interpolation; it does not describe collecting new pressure data.[ref] A proposed apparatus test scans a known small indenter across a sensor array at controlled total load, comparing independent load measurements with channel responses. The indenter’s actual contact area, load spreading, sensor cross-coupling and repeatability must be measured before inferring a spatial response. Additional smaller-aperture measurements or justified mechanical constraints can improve identifiability; a smoother image alone supplies neither.
The null space of a spatial pressure measurement consists of changes to a contact pressure field that leave every measured channel unchanged. For a linear response model on a contact region , writeThen . Two fields have identical outputs precisely when their difference lies in this kernel of a linear map. The sensitivity kernels , their support and the admissible class of pressure fields are part of the model.
For an ideal area-average sensor, inside cell and zero elsewhere. A positive and negative perturbation within one cell can cancel in its integral while remaining invisible to the other cells. This is the mechanism behind spatial pressure-map resolution below a sensor cell. It is a nonuniqueness of the observations, even if their numerical values are exact.
An original finite model divides each of two equal-area sensor cells into two equal halves with constant pressures . The observed averages areThis matrix has rank two and a two-dimensional null space spanned by and . Thus the fieldsboth produce . Their peak pressures differ by . Adding an independent measurement of determines the first pair, but still leaves the second pair’s difference undetermined. An extra channel helps only if it adds an independent constraint on the missing directions.
The linear null space is not itself a set of physical pressure fields: its perturbations can have either sign. For a nonadhesive contact, require as well. With the uniform field above, perturbations are admissible for . Positivity restricts the ambiguity without removing it. In contrast, a zero area-average reading together with a nonnegative pressure assumption forces pressure to vanish almost everywhere in that cell under the ideal model.
For a chosen finite basis of pressure fields, a singular value decomposition identifies the matrix null space. SciPy’s pinned implementation constructs its basis from right singular vectors and uses a relative singular-value cutoff to determine effective numerical rank.[ref]
SciPy 1.16.2 documentation. scipy.linalg.null_space, pinned v1.16.2 scipy/linalg/_decomp_svd.py, docstring and implementation lines 333–403
A numerical cutoff and an exact zero singular value are different notions. Near-null directions of a pressure sensor array have small nonzero responses and can amplify measurement error: a dimensionless singular value of turns a channel-error component into a coefficient error when inverted without regularization.A proposed apparatus check applies controlled local loads to estimate the sensitivity kernels, then compares fields with similar predicted channel outputs using independent spatial measurements. Contact area, load spreading and cross-coupling must enter that comparison. A reconstruction algorithm may select one smooth or nonnegative solution, but the selected structure is additional modeling information; it is not automatically an independently observed subcell pressure map.
Near-null directions of a pressure sensor array are changes of a modeled pressure field that produce small, rather than exactly zero, changes in the sensor outputs. They distinguish an ill-conditioned reconstruction from the exact ambiguity in the null space of a spatial pressure measurement. A formally invertible response can still contain very little usable information about some pressure patterns.
Choose a finite basis for the pressure field and a linear response , where contains pressure coefficients, the readings, and measurement error. With common pressure units for the coefficients and readings, letbe a singular value decomposition. A change changes the noiseless readings by . Inverting that component divides the measurement error by . If the errors have covariance , the standard deviation of the reconstructed coefficient along is . An exact zero gives no inverse; a small nonzero value gives noise amplification.
An original two-region example has uniform pressures and sensor matrixBoth sensors mostly measure the same average. Write and . Then and . Uniform pressures give readings ; the markedly different pair gives only . The matrix is invertible, but these outputs differ by just in one channel.
If each channel has independent standard uncertainty, the direct contrast estimate is , with standard deviation about . The matrix’s smallest singular value is approximately , consistent with roughly uncertainty in the unit-length contrast direction. Nonnegative pressure constraints can restrict the admissible answers, but do not turn these noisy readings into precise contrast information.
Numerical rank depends on a chosen tolerance. SciPy’s pinned null-space implementation compares singular values with a relative cutoff and returns right singular vectors beyond the retained rank.[ref]
SciPy 1.16.2 documentation. v1.16.2 scipy/linalg/_decomp_svd.py, null_space, docstring and lines 395–403
A floating-point cutoff detects numerical scale; a physical decision about usable information must also consider sensor noise, response uncertainty and the chosen pressure basis. Rescaling a coefficient can change a raw singular value without changing the apparatus.A noise-whitened pressure sensing matrix accounts for unequal or correlated measurement errors before comparing response strength. For positive-definite error covariance , analyze together with the same coefficient units and normalization. A duplicate noisy channel does not provide the same information as an independent measurement of the weak contrast.
Tikhonov regularization can limit amplification by using factors instead of . Relative to the true noiseless coefficient, this introduces attenuation . For and , that factor is about : the weak component is nearly suppressed. A smoother map can therefore have less noise while omitting real contrast. A proposed validation applies independently known pressure patterns that excite both average and contrast directions, repeats the measurements, and reports the error covariance and response-model uncertainty alongside reconstruction results.
A noise-whitened pressure sensing matrix measures how a contact pressure pattern changes sensor outputs relative to their joint noise, rather than their raw numerical size. For a linear measurement modelassume the error covariance is positive definite. Choose an invertible matrix satisfying . ThenThe transformed errors have identity covariance. This is the whitening transformation documented in the primary SciPy covariance interface; its example obtains approximately identity sample covariance from simulated observations.[ref]
A Cholesky decomposition supplies . Compute and by solving triangular systems rather than forming an inverse unnecessarily. The least-squares residual becomesThus an output change is significant according to its noise covariance, not merely the Euclidean length of the raw readings. The original pressure basis and its units must still be stated; whitening rows does not remove arbitrary column rescalings.
For an original two-channel example, use numerical pressure values in kilopascals andThe separate standard deviations are and with correlation . A residual whitens to , giving squared length about . The residual instead whitens to , giving squared length . Treating the channels as independent would assign both residuals squared standardized length two. The positively correlated noise makes opposite-sign discrepancies much less plausible than a shared shift.
A simple repeated-measurement model illustrates the information consequence. If two sensors measure the same scalar pressure with equal standard deviation and correlation , their mean has variance . At the standard deviation is about , rather than the independent-channel value . Adding an almost duplicate channel therefore supplies little improvement for that common pressure.
The pressure-map information matrix is . In a full-column-rank linear Gaussian model with known , the unconstrained weighted least-squares estimate has covariance . Small singular values of identify near-null directions of a pressure sensor array after accounting for noise. Alternative whiteners differ by an orthogonal row transformation and give the same information matrix; an individual whitened row need not represent one physical sensing cell.
A proposed array characterization applies repeatable known pressure patterns, estimates the channel covariance from repeated residuals, and checks the covariance on independent repeats after whitening. Drift and response-model uncertainty must be included if they belong to the intended error model. If is singular, a simple inverse whitening is unavailable: exact zero-noise constraints and redundant stochastic directions need separate treatment. A visually smooth pressure reconstruction does not establish that its weak directions were measured precisely.
A pressure-map information matrix quantifies which coefficients of a modeled contact pressure field are constrained by a sensor array, relative to its measurement noise. For with fixed positive-definite error covariance , defineHere is the noise-whitened pressure sensing matrix. Whitening removes the output-noise covariance from the residual metric; the primary SciPy covariance interface documents this transformation and demonstrates near-identity covariance on simulated observations.[ref]
The matrix is positive semidefinite because . Its null space is exactly the null space of : an unobserved pressure change remains unobserved after invertible row whitening. With independent Gaussian errors of known covariance, the log likelihood is a constant minus . Differentiating twice with respect to gives negative Hessian , identifying it as the Fisher information for this stated model.
If has full column rank, weighted least squares givesThis covariance follows by substituting and multiplying the error matrices. It concerns the unconstrained linear estimator with known response and covariance, not every reconstruction algorithm. Nonnegativity constraints, regularization and uncertain sensitivity kernels require additional treatment.
An original two-cell example begins with one average-pressure measurement, , with standard error. In numerical kilopascal coordinates,Its eigenvalues are and zero: the mean is observed, but the pressure difference is not. A second independent copy doubles the information matrix while leaving the difference unobserved. More repeats of the same mixture improve precision only in the already measured direction.
Instead add a direct measurement of the first cell with the same independent error. NowThe inferred first-cell pressure has standard deviation and the second . Their errors are negatively correlated because the second pressure is reconstructed by subtracting the first from twice the measured mean.
A rank-one update of pressure-map information follows when an independent new channel has sensitivity row and error variance : its added information is . A channel aligned with a weak pressure direction can therefore be more useful than another precise copy of a strong direction. Correlated new errors cannot be added by that independent-channel formula.
A proposed characterization uses repeatable known loading patterns to estimate , independent repeats to estimate , and withheld patterns to test predicted reconstruction covariance. State the pressure basis and units: rescaling a coefficient changes the numerical information entries. A sharp reconstructed image or a large matrix determinant alone does not establish that the underlying response model or noise assumptions are correct.
A rank-one update of pressure-map information describes the extra constraint supplied by one independent scalar pressure measurement. Suppose the existing pressure-map information matrix is , and a new sensor reports with known variance , independent of the existing errors. Adding its squared residual to the weighted least squares objective givesThe added matrix has rank one when . It is positive semidefinite because its quadratic form is . Thus the new observation cannot reduce information in any direction under this fixed linear map and noise model. The noise normalization is the same whitening transformation used to express a correlated residual metric as an ordinary squared norm.[ref]
The update can remove a missing direction only if the new channel actually sees it. More precisely,This follows because a sum of two nonnegative quadratic forms is zero exactly when both are zero. Repeating an existing mixture improves its precision but cannot identify a pressure contrast that all mixtures annihilate.
When is positive definite, write . The Sherman–Morrison formula yields the updated estimator covariance matrixMultiplication by verifies the identity directly. For a particular quantity , its variance falls by . A small noise level is valuable only together with a useful sensitivity direction.
For an original calculation in kilopascal coordinates, let , and . ThenThe variance of the sum drops from to . The negative off-diagonal entry means the two inferred coefficients now have negatively correlated errors; it does not mean either individual variance is negative.
A correlated-channel update of pressure-map information needs the new channel's residual after predicting it from old channel noise. Simply adding double-counts information when a common amplifier or reference contributes correlated errors. A proposed array experiment uses repeated known loads to estimate sensitivity and noise separately, adds one channel, and compares withheld-load errors with . Agreement tests the full assumed model, including independence and unchanged sensor response, rather than the matrix identity alone.
Articles by others on the same topic
There are currently no matching articles.