A topological space is connected when it has no separation of a topological space: no partition of a set into two nonempty open subsets satisfyingHere the union covers all of , and the intersection is the empty set, so no point belongs to both pieces. For a subset of a larger topological space, "open" means open in the subspace topology: each piece is the intersection of with an ambient open set. Both pieces must be open; merely dividing a drawing into two colours does not establish a separation of a topological space. [ref]
https://math.mit.edu/~hrm/palestine/munkres-topology.pdf. Munkres, Topology: A First Course, section 3-1, definition on p. 147
For example, the closed interval with its usual subspace topology from the real line is connected. The proposed split fails: the second subset is not open in , since every neighbourhood of in contains points less than . More generally, a connected subset of the real line is precisely a real interval. In contrast, for the unionthe open intervals and exhibit as nonempty open subsets in the subspace topology of . Their intersection is empty and their union is , so is not connected. Although are closed intervals in the real line, they are also open within .
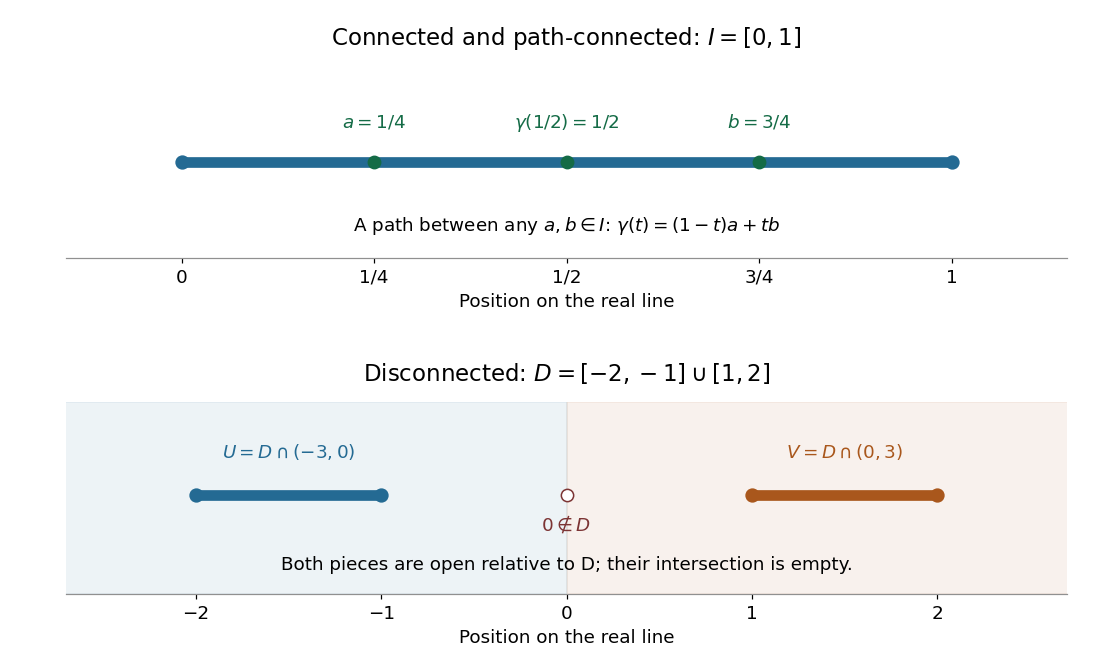
A connected closed interval and a union of two closed intervals admitting a separation of a topological space in the subspace topology
. Details. Why is connectedness useful? A continuous image of a connected space is connected: a proposed separation of a topological space in the image would pull back through the continuous map to a forbidden separation of a topological space in its source. Thus a continuous map from a real interval to the real line cannot skip values between two attained values. This is the intermediate value theorem. For a computed example, the continuous function on has image ; the value occurs at . Connectedness guarantees an input attaining that value even when we have no formula for it.
Path connectedness is a stronger condition: it supplies a continuous path between every pair of points. The topologist's sine curve below shows that a connected space need not be a path-connected space.
A topological space is disconnected space if it can be written as the union of two disjoint nonempty open subsets. Such a pair is a separation of a topological space. Each of the subsets is also closed, and conversely a nontrivial subset that is both open and closed gives a separation of a topological space with its complement.
A subset of a topological space is a connected set when its subspace topology is connected. Thus connectedness is tested using relatively open sets, not only subsets open in the ambient space.
Two disjoint connected sets can have a connected union when one contains a contact point of the other's closure. To prove the displayed criterion, suppose the union had a separation into disjoint nonempty relatively open sets . Each connected set lies wholly on one side; if both lie on the same side, the other side is empty. Otherwise assume and . Choose . Since is relatively open in the union and contains , some ambient open set containing meets the union only in . It must nevertheless meet by the definition of closure, a contradiction.
For example, the open unit disc centred at zero and the closed unit disc centred at two are disjoint, but their union contains the common contact point one through the second disc and is connected. In this example it is even path-connected: the real segment from zero to one lies in the first disc except for its endpoint, and that endpoint belongs to the second disc. Omitting the contact point from both discs instead gives a disconnected union.
Let be a compact Hausdorff space and let be compact subsets such that all finite intersections are nonempty and connected. Their total intersection is nonempty by the finite intersection characterization of compactness, and compact because it is closed in .
If were not connected, its separation of a topological space would divide it into two nonempty compact subsets. Separation of disjoint compact subsets gives disjoint ambient open sets containing the two pieces. The family consisting of and all has empty total intersection, so some finite subfamily has empty intersection. Hence a finite intersection of the lies in . Since meets both open sets, they disconnect , a contradiction. The hypothesis on all finite intersections is stronger than requiring each individual to be connected.
Use the arcs and points of the noncompact counterexample to the Šura-Bura lemma, and add the central ray to form . Define . Each graph tail is connected because its arcs meet the ray. Its relative closure in adds just , so each is closed and connected. These sets decrease and have intersection , which is compact and disconnected. The ambient is connected and Hausdorff but noncompact.
Suppose are nonempty connected spaces, and , are proper subsets. Then , with its subspace topology from the product topology, is a connected space. No closed set or open set hypothesis on is needed.
Choose , . The two topological subspaces and are homeomorphic to the factors, intersect at , and lie in . Their union is a connected subset . Every has or . In the first case its entire vertical copy lies in and meets ; in the second case the horizontal copy does so. Thus is a connected union with a connected hub.
Both properness assumptions are needed for this general result. Taking , and gives the two disjoint open half-planes and , a separation of a topological space of the complement.
Every real interval is connected. Otherwise a separation into two nonempty relatively open sets defines a continuous real function equal to zero on one side and one on the other. Choose one point of each set. The intermediate value theorem on the closed segment between them requires the value , a contradiction. The converse also holds: a connected subset of the real line contains every point between two of its points, since omitting an intermediate point separates it into its intersections with the two open half-lines.
Consider the graph of a function , using the sine of the multiplicative inverse of , together with a vertical closed interval:Give the subspace topology from the Euclidean plane. The symbol denotes a Cartesian product. The right endpoint belongs to . The continuous map sends the connected real interval onto . Hence is connected, and its closure is connected by closure of a connected set. Every height in is approached as tends to zero; for example,For , these inputs are and . For any other height , choose with ; then the sequence lies in and has limit of a sequence .
Nevertheless, has exactly two path components, and . Within , join inputs by the continuous path . Within , use for heights .
The obstruction to a continuous path between and is persistent oscillation, not a visible gap. Proof outline: suppose such a path exists, directed from to , and take its last time in . Immediately afterwards its first coordinate approaches zero and its second coordinate is . The intermediate value theorem forces the first coordinate to pass through inputs of both displayed types arbitrarily close to that departure time. The second coordinate therefore takes both values and arbitrarily close to that time, contradicting continuity. [ref]
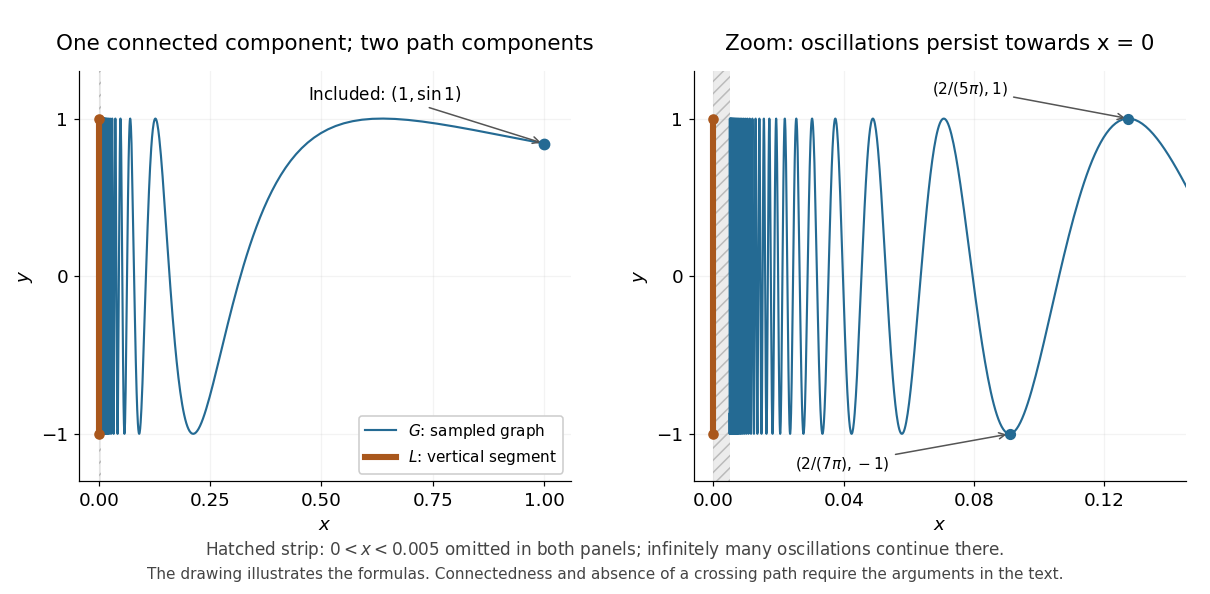
The topologist's sine curve has one connected component and two path components; the graph of a function is drawn only for , with further oscillations omitted near the vertical closed interval
. Details. The sampled graph of a function illustrates the formulas; it does not prove connectedness or the failure of path connectedness. Taking a closure preserves connectedness, but this example shows that it can destroy path connectedness.
A sequence of connected subsets with each consecutive pair intersecting has connected union. If the union admitted a separation, each connected subset would lie entirely on one side. Consecutive intersections force consecutive subsets onto the same side, hence all subsets onto one side, contradicting that both sides of the separation are nonempty.
The closure of the displayed connected spiral adds the unit circle. Its union with the closed unit disk is therefore connected but not path-connected. A path from the spiral to the disk would have a first contact time. Before contact its reciprocal radial offset defines a continuous parameter tending to infinity. The intermediate value theorem then forces sequences of path points with parameters integer and half-integer, approaching opposite circle points. This contradicts continuity at the first contact. Thus the spiral and disk form separate path-connected components.
If a nonempty scheme has no nontrivial idempotent in , then its underlying topological space is connected. Indeed, a decomposition into two nonempty clopen subsets would produce the global regular function equal to zero on one component and one on the other. In particular, being a field implies connectedness.
A subset of a topological space is a connected subset when , with the subspace topology inherited from , is a connected space. Thus connectedness is tested inside : a forbidden separation of a topological space consists of nonempty subsetswhere are open sets in . The ambient open sets need not be disjoint outside .
For example, in the real line with its usual topology, is a connected subset, whereas is not: its two singleton sets are open in its subspace topology. A subset of a connected space need not be connected. Conversely, is a connected subset of the disconnected topological space . The ambient topological space need not itself be connected.
A finite set of distinct points in the real line inherits the discrete topology: a sufficiently small open interval around each point isolates that point. Its only nonempty connected subsets are singleton sets. This depends on the topology: a nonempty finite set with the indiscrete topology is a connected space, since its only open sets are itself and the empty set. Here, as in the definition of connected space, the empty set is also connected because it admits no separation of a topological space.[ref]
Chapter 3: Connected and compact spaces. Definition 3.1.1 and Example 3.1.3: connectedness and discrete spaces
The distinction matters when finding connected components: we search among connected subsets of the specified topological space, rather than judging whether the surrounding drawing looks like one piece.
Suppose connected subsets all meet one connected member . A separation of their union would place entirely on one side. Each is also entirely on one side and intersects , so every lies on the same side, contradicting nonempty separation. Thus the union is connected. If the subsets are path-connected, join two points by a path to , a path inside , and a path back out. This needs pairwise contact with the hub, not one point shared by every subset.
In a plane set with and rational ratio , any irrational number lying between two attained ratios separates the set into the nonempty relatively open sets and . This exhibits a failure of connectedness using the continuous slope map, even though each individual ray is path-connected.
A separation of a topological space is a pair of disjoint nonempty open subsets whose union is . A space is connected exactly when it has no separation.
A connected component of a topological space is a nonempty connected subset that is maximal under subset inclusion. If is a connected component and with a connected subset, then . Maximality means that no larger connected subset contains ; it does not mean largest cardinality among all connected subsets.
For example, the connected components of in the usual subspace topology of the real line are and . Each is a real interval, and no connected subset of the real line can meet both without containing the missing point . For the finite set in the same subspace topology, the three connected components are its singleton sets.
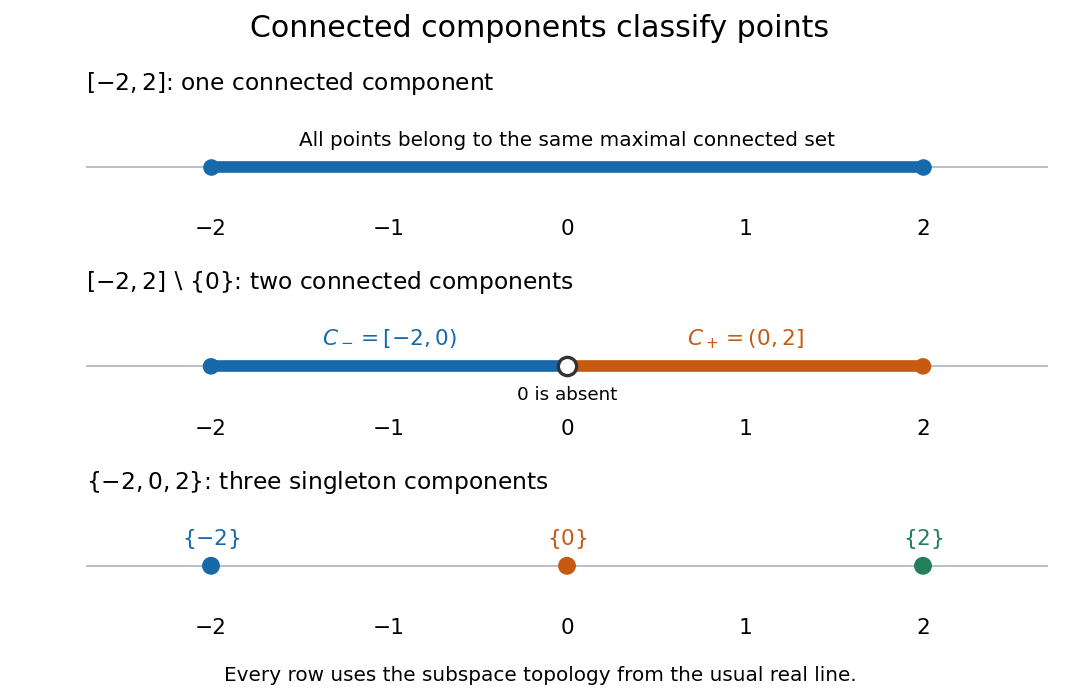
An intact real interval, an interval with an interior point removed, and a finite set have one, two, and three connected components in the usual subspace topology of the real line
. Details. Every point lies in exactly one connected component, constructed by taking the unionAll members contain , so their union is connected by connected union with a connected hub. The union includes every connected subset through , so it is maximal. Equivalently, defineThis is an equivalence relation: singleton sets give reflexivity, symmetry is immediate, and two connected subsets sharing the middle point have a connected union, giving transitivity. The equivalence classes are precisely the connected components. They form a partition of a set: they cover and any two are either equal or disjoint.[ref]
Chapter 3: Connected and compact spaces. Proposition 3.1.11, Definition 3.1.12 and Remark 3.1.16: maximal connected subsets and equivalence classes
Every nonempty connected subset lies within one connected component. Moreover, every connected component is closed in : closure of a connected set makes its closure connected, and maximality forces that closure to equal the original connected component. A connected component need not be open. For example, in with its usual subspace topology from the real line, all connected components are singleton sets, but is not open: every neighbourhood of in contains some .[ref]
Every connected component of a nonempty compact proper subset of a connected Hausdorff space meets its boundary. If not, the Šura-Bura lemma identifies as a quasi-component in the compact Hausdorff subspace . Finitely many clopen neighborhoods separate it from the compact boundary, giving a nonempty relatively clopen . Such is open in the ambient space, and is also closed there because is closed. It is proper because is proper. This contradicts connectedness.
The quasi-component of a point is the intersection of its clopen neighborhoods. Its connected component is always contained in it: a connected set meeting a clopen set cannot also meet its complement. Equality need not hold in noncompact Hausdorff spaces. The Šura-Bura lemma proves equality in compact Hausdorff spaces.
In a compact Hausdorff space, each connected component is its quasi-component and has a neighborhood basis of clopen sets. Let be the intersection of clopen neighborhoods of . It is compact. If it splits into two nonempty compact sets, normality separates them by disjoint open neighborhoods. The finite intersection characterization of compactness gives a finite intersection of clopen neighborhoods lying in their union. Its intersection with the neighborhood containing is then clopen and excludes part of , a contradiction. Thus is connected and equals the component. Applying the same finite-intersection argument to any neighborhood of proves the neighborhood-basis assertion. [ref]
https://www.cl.cam.ac.uk/research/hvg/Isabelle/dist/Isabelle/browser_info/HOL/HOL-Analysis/Homotopy.html. Formalized Šura-Bura results, including the compact Euclidean case
.Set , , , and let be the polygonal arc joining , , , and . In the planar subspace , each arc is clopen. The component of is therefore just . Any clopen neighborhood of contains the left endpoints of all sufficiently high arcs, hence those entire connected arcs, and by closedness also the limit of their right endpoints. Thus its quasi-component is . Higher arcs escape to infinity while their endpoints approach the two distinguished points.
The quasicomponent of a point is the intersection of all its clopen neighborhoods. Every connected set containing the point lies in its quasicomponent, since a clopen set cannot split a connected set. In a compact Hausdorff space, quasicomponents equal connected components by the Šura-Bura component lemma.
In a compact Hausdorff space, the quasicomponent is connected and equals the connected component of . If were a nontrivial separation, disjoint open neighborhoods of its compact pieces leave a compact complement missing . Finitely many clopen neighborhoods of intersect to a clopen containing inside . The piece is then clopen in the whole space, contains , and misses the nonempty other piece, contradicting the definition of . This also proves that any neighborhood of a component contains a clopen neighborhood of that component, by compactness of its complement.
The identity component is the connected component containing the identity element. It is a closed normal subgroup: products and inverses of connected sets through the identity remain in that component, and conjugation preserves it. It need not be open; in the additive group with its usual topology it is the nonopen singleton .
The product of connected spaces is connected, so the product of the two connected components lies in the component of . Conversely, continuous projections carry that component to connected sets in the factors, which must lie in and . These two inclusions prove equality in arbitrary topological spaces.
An embedded copy of in separates space into an inside and an outside. In particular, a connected closed surface embedded in is two-sided and orientable.
If is a continuous map and is a connected space, then its image , with the subspace topology from , is a connected subset of . The whole codomain need not be connected; the assertion concerns the values actually attained. No injectivity is required.[ref]
For example, the continuous function maps the connected closed interval onto the connected closed interval , even though opposite inputs have the same output. The same continuous function maps the disconnected union onto . Thus a connected image does not imply a connected source: a continuous map can merge different connected components.
For a continuous function representing a continuous reading, and force some input with . Its image is a connected subset of the real line, hence a real interval containing both endpoint readings. For the synthetic model , the missing-value test is explicit: . A step reading equal to for and for skips , but fails continuity at .
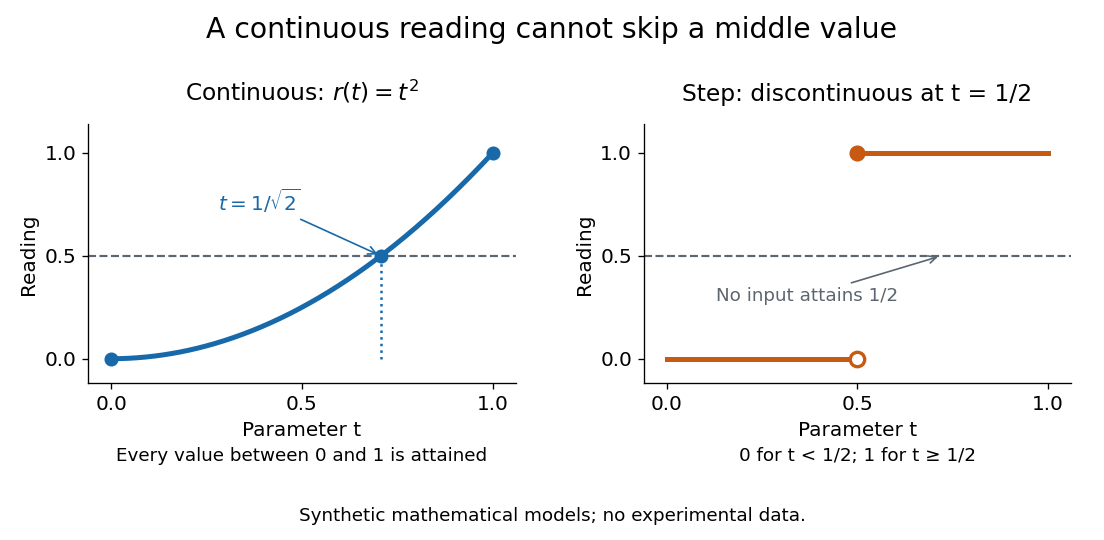
Proof outline: a separation of a topological space of into nonempty open subsets pulls back under to nonempty open subsets of . Their intersection is empty and their union is , contradicting connectedness. This also shows why a continuous map sends each connected component of its source into a single connected component of its target.
In the usual subspace topology from the real line, a subset is connected exactly when it has the defining property of a real interval:Every real number between two members must be present. Thus open intervals, closed intervals, intervals with only one endpoint included, and unbounded real intervals are connected. Singleton sets are connected too. With the no-separation of a topological space convention used here, the empty set satisfies the same property; some texts reserve the word connected for nonempty topological spaces.[ref]
General Topology by Tom Leinster. p. 68, and Proposition C2.6, p. 73: the nonempty convention and the interval characterization
Removing an interior point changes the answer:These two real intervals are exactly its connected components and its path components. Removing an endpoint instead leaves a real interval, for example , which stays connected. This is why an interior point of a closed interval is a cut point, whereas an endpoint is not. A nonempty finite set of points in the real line is connected exactly when it is a singleton set.
Proof outline: if but is missing, the subsetsgive a separation of a topological space, since the two open intervals make both pieces open in . Conversely, a nonempty real interval contains the continuous path between any two of its points, so it is path-connected and hence connected. Together with continuous image of a connected space, this characterization gives the intermediate value theorem: a continuous function on a real interval cannot jump over a value lying between two attained values.
A topological space is connected exactly when every continuous map from it to the discrete space is constant. A disconnection produces a nonconstant indicator map, while the continuous image of a connected space in must be a singleton.
If connected subsets cover a space and every two of them intersect, then their union is connected. Equivalently, any continuous integer-valued function is constant on each member, and the intersections force all those constants to agree.
The product of any family of connected spaces is connected. For two factors, fix and use the connected setsThey cover and all contain the connected horizontal slice .
Articles by others on the same topic

In topology, a connected space is a fundamental concept that refers to a topological space that cannot be divided into two disjoint, non-empty open sets. More formally, a topological space \( X \) is called connected if there do not exist two open sets \( U \) and \( V \) such that: 1. \( U \cap V = \emptyset \) 2. \( U \cup V = X \) 3.



