Original solutions to all three questions of the Geometry of surfaces course of the University of Oxford Part B examination, held on 7 June 2023. Source: released examination PDF, bundle pages 214–217; paper pages 1–4. The numbering follows the original paper. In 3(e), the displayed identity requires integration with multiplicity when the parameter interval wraps around the surface; the solution explains this omission in the native PDF.
The classification of compact surfaces says that every compact, connected topological surface without boundary is homeomorphic to exactly one of the following: the sphere ; a connected sum of surfaces consisting of tori; or a connected sum of surfaces consisting of real projective planes. The first two cases are orientable; the last case is a nonorientable surface. Their Euler characteristics areHere has genus , and has crosscaps; is the real projective plane and the Klein bottle. Thus orientability together with the Euler characteristic determines the closed surface up to homeomorphism.
If the convention permits a surface with boundary, also remove the interiors of disjoint closed discs from one of these closed surfaces. The Euler characteristic decreases by , giving in the orientable case and in the nonorientable surface case. The number of boundary components is then an additional invariant.
Number the polygon vertices in the order of the given polygonal schema, with its th polygon edge going from to , and subscripts interpreted modulo ten. Equal labels identify equal arrow endpoints. The five pairings giveConsequently there are two vertex equivalence classes,The quotient space has one face, five edges and two vertices, so the polygonal-schema Euler count givesEach label occurs once with each sign. Hence every pairing reverses the direction induced by traversing the boundary of the polygon, so an orientation of a surface on its interior extends consistently across every glued edge. Thus is orientable. The classification of compact surfaces now gives , or a closed orientable surface of genus two, equivalently the connected sum of surfaces of two tori.
Write for the internal angle at , using the numbering in part (b), and use the hyperbolic plane with Gaussian curvature . The necessary and sufficient conditions are equal lengths for each pair of equally labelled polygon sides, and total angle at each vertex equivalence class. Explicitly, the two angle conditions areNecessity follows because the identification must preserve arc length along each seam, and a smooth interior point of a Riemannian surface has total angle . For sufficiency, equally long hyperbolic geodesic segments can be identified by isometries. Across their interiors, two half-disc neighbourhoods join to a hyperbolic disc. At an identified vertex, the incident sectors form a cyclic disc with total angle , so no cone singularity of a surface metric remains. These local isometries therefore extend the Riemannian metric smoothly everywhere. This is the smooth hyperbolic polygon gluing criterion.
The ten internal angles sum to . The area of a hyperbolic geodesic polygon consequently givesEquivalently, the Gauss-Bonnet theorem gives .
The uniformization theorem says that every simply connected Riemann surface is biholomorphic to the Riemann sphere, the complex plane, or the unit disc. Its consequence for a compact Riemann surface of genus at least two is that the universal cover is the unit disc, equivalently the hyperbolic plane.
To explain the restriction, a spherical universal cover would make the fundamental group finite. Since a finite covering map multiplies Euler characteristic, is impossible for . If the universal cover were the complex plane, its deck transformations would be biholomorphisms . A nonidentity such map with has a fixed point, impossible for a deck transformation. Thus the deck transformation group would consist of translations. A discrete subgroup of translations with compact quotient space is a rank-two Euclidean lattice, whose quotient space is a torus, again incompatible with .
On the unit disc, the Poincare metric on a Riemann surfacehas Gaussian curvature and is invariant under every biholomorphism of the unit disc. It therefore descends through the deck transformation group to a hyperbolic metric on . Its local expression is a positive multiple of in every holomorphic coordinate chart, so it is compatible with the given complex structure. In fact, this hyperbolic metric is unique within that conformal class.
Take a hexagonal polygonal schema with boundary wordIdentify equally labelled polygon edges in the indicated directions. The two consecutive occurrences of identify the first three vertices; the two edges extend this class to the next two vertices, and the edges include the remaining vertex. Thus all six polygon vertices become one, while the six edges become three and the interior is one face. Its Euler characteristic isThis is the usual polygonal schema for the connected sum of surfaces of three real projective planes. The same-sign edge pairs force a nonorientable surface, consistently with . A closed orientable surface cannot have odd Euler characteristic.
Let and choose holomorphic coordinate charts centred at and . A nonconstant holomorphic map has a local expansion , where and . Taking a local holomorphic th root of the nonvanishing factor and changing the source coordinate gives the exact local form . The integeris the ramification index of a holomorphic map. A ramification point of a holomorphic map is a source point with , equivalently where its derivative vanishes; a branch value of a holomorphic map, also called a branch point here, is the image of such a point in . These are different sets, one in the source and one in the target.
Every fiber of a function is finite: locally it is the zero set of a nonzero holomorphic function, so its points are isolated, and compactness prevents infinitely many such zeros without an accumulation point. The same argument applied to the local derivatives makes the set of ramification points of a holomorphic map finite. The open mapping theorem and compactness show that is both open and closed in the connected target , hence is surjective.
For any , the degree of a holomorphic map isTo see independence of , choose disjoint small coordinate charts about its finitely many preimages. The local form shows that nearby values have preimages counted with multiplicity in the corresponding chart. Compactness excludes additional preimages outside these charts for sufficiently nearby values: a sequence of such preimages would have a limit in . The displayed sum is therefore locally constant, hence constant on connected . Away from branch values of a holomorphic map it is the ordinary number of preimages, and is a -sheeted covering map there.
The Riemann-Hurwitz formula isor, in terms of the two genera,For its proof, choose a triangulation of a surface on containing every branch value of a holomorphic map among its vertices. Every open edge and open face has lifts, since its interior avoids branch values of a holomorphic map. The lifted cells give a finite CW complex structure on . If are the target counts and , the source counts areIndeed, at a target vertex the deficit from distinct preimages is precisely , and all nonzero contributions occur over vertices. Taking the alternating sum gives , as required. This is the Triangulation proof of the Riemann-Hurwitz formula.
Every nonidentity biholomorphism in the finite group has only finitely many fixed points, by the identity theorem on a Riemann surface and compactness. Because the group action is a faithful group action, the union of these finite sets does not exhaust . A point outside this union has trivial stabilizer subgroup, so its group orbit has points by the orbit-stabilizer theorem. The generic fiber of a function of the projection is such an group orbit, givingMore precisely, put and . Differentiation at gives a group homomorphism . It is injective: if a nonidentity finite-order germ had the form with and , then its th iterate would begin , so no positive iterate could be the identity. A germ equal to the identity gives the identity on by the identity theorem on a Riemann surface. Thus is a cyclic group, with derivative image the th roots of unity.
For completeness, an explicit local coordinate linearizing isIt has , and reindexing the sum gives . Therefore a coordinate on the local quotient space is . Other translates of a sufficiently small neighbourhood of are disjoint unless their translating element lies in , so this local quotient space is also a chart for . The local cyclic quotient of a Riemann surface consequently gives
In a cyclic group of prime order , a stabilizer subgroup has order either one or . The latter case consists exactly of points fixed by all of . Thus the fixed points each have ramification index of a holomorphic map , and every other point has index one. Applying the Riemann-Hurwitz formula with degree of a holomorphic map givesEquivalently,The count concerns fixed points upstairs. Each is its own group orbit, so their images are also distinct branch values of a holomorphic map.
For a free action of a group, every stabilizer subgroup is trivial. Hence every ramification index of a holomorphic map is one, and the projection is an unramified covering map of degree of a holomorphic map . The Riemann-Hurwitz formula reduces toThis is also the multiplicativity of Euler characteristic under a finite covering.
The dihedral group here has order . Substituting into part (d) givesIn particular, requires genus seven. A geometric construction is to start with a round solid torus about the vertical axis, then drill thin radial tunnels through its tube in the horizontal midplane, equally spaced at azimuths , . The tunnels run from the central opening to the exterior; their directions are horizontal and radial. Round all their rims in the same way, preserving the dihedral symmetry, and let be the boundary of the resulting solid.
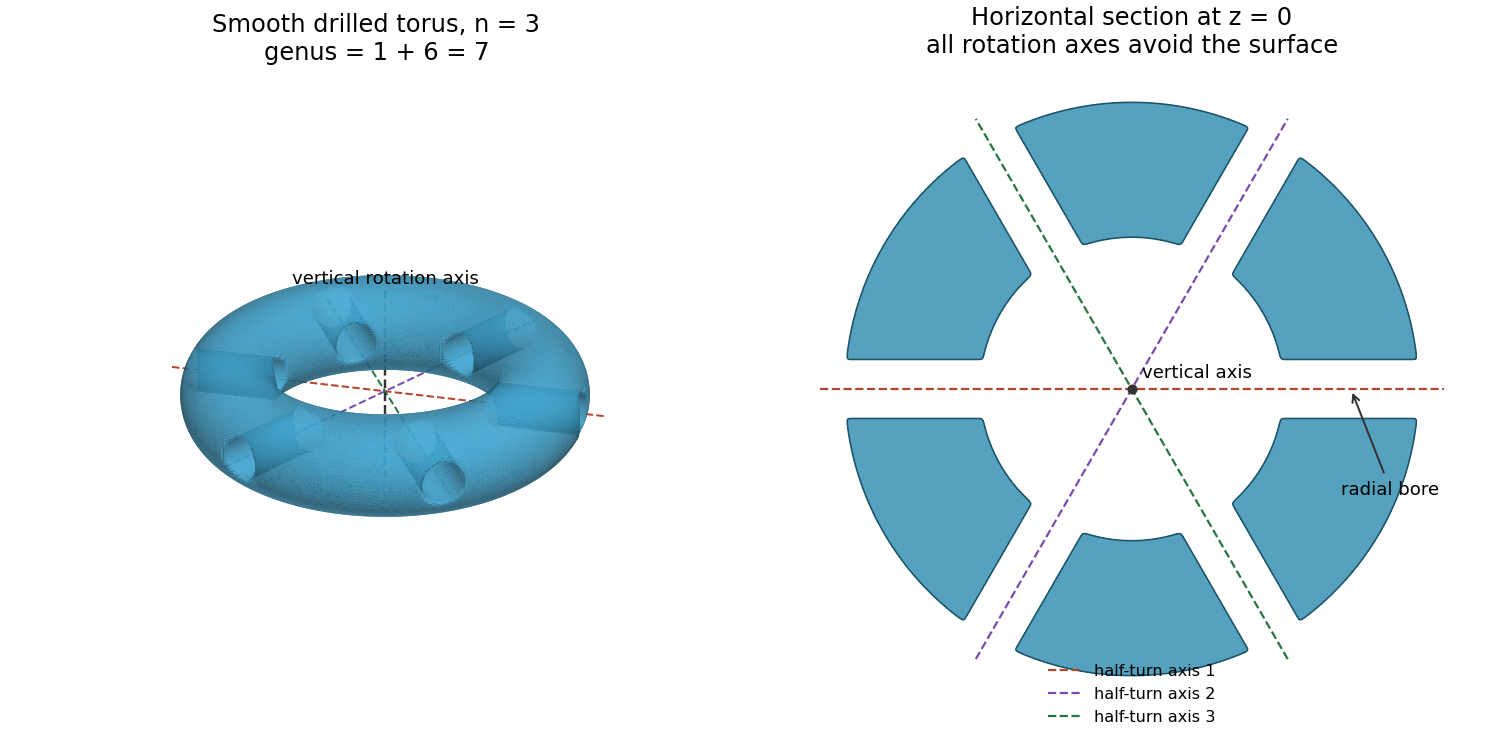
A genus-seven surface with a free dihedral action: six radial bores contain the horizontal rotation axes
. Details. 
Here is why the construction has exactly the required properties. Every nonidentity power of is a rotation in three dimensions fixing the vertical axis, which lies in the central opening and is disjoint from . Each element is a half-turn about a horizontal line at azimuth , modulo . The such lines meet the original solid torus in short radial segments. Each segment lies strictly inside one drilled tunnel, so these axes are also disjoint from . A nonidentity rotation in three dimensions fixes only its axis. Thus no nonidentity element fixes a point of , proving a free action of a group.
Rotation by permutes the tunnels, while preserves their arrangement and the original solid torus. Hence is preserved by the two generators and therefore by . The tunnels can be chosen sufficiently thin to be pairwise disjoint, and the rounding can be made group-invariant in small disjoint neighbourhoods of their rims. It neither changes the genus nor introduces an intersection with any axis.
Each tunnel removes two discs from the existing boundary and inserts the cylindrical wall of the bore. Its contribution to Euler characteristic is : the two removed discs contribute , and the inserted annulus and its boundary circles have zero Euler characteristic. The boundary remains connected and orientable, so each tunnel increases genus by one. Starting from a torus and drilling tunnels therefore gives . The construction also supplies a Riemann surface: use the complex structure associated with the induced oriented Riemannian metric. The ambient generators are isometries preserving the solid and ambient orientation of a vector space, so they preserve the induced boundary orientation and act by biholomorphisms. Part (d) then confirms that the quotient space has genus two. This is a free dihedral action on a drilled torus.
For a regular parametric surface , its tangent vectors are linearly independent. The first fundamental form is the induced inner product on the tangent plane, writtenIt measures squared lengths and angles; its determinant satisfies . Choose the unit normalThe second fundamental form, with shape operator , isThe subscript distinguishes the coefficient from a genus or a Riemannian metric. In these coordinates the shape operator has matrix , so the Gaussian curvature, the product of its two principal curvatures, isReversing reverses and both principal curvatures, leaving the Gaussian curvature unchanged.
Let be the horizontal rotation matrix through angle . Define the screw motionIts linear part is an orthogonal matrix with determinant one, and its remaining part is a translation. Thus it is a proper Euclidean motion of Euclidean three-space, with .
In horizontal-vector notation the given parametric surface satisfies . ThereforeThe defining circle in each horizontal plane is entirely parametrized by , so covers . The displayed equality and prove . This one-parameter subgroup preserves the dot products and cross products defining , and the chosen unit normal. Consequently their coordinate coefficients, and the Gaussian curvature, depend only on .
Set , , and . At , the first partial derivatives areTheir dot products give , , . HenceSince , the parametric surface is regular everywhere. Its cross product and unit normal at areThe second partial derivatives at areTheir dot products with give and . ThusPart (b) transports these first fundamental form and second fundamental form coefficients to every . Finally,The last expression is the surface area element from . In particular the Gaussian curvature changes sign where does; it vanishes at modulo .
Use the unit normal from part (c), and orient by increasing . Write for its unit tangent vector. The signed geodesic curvature convention used below iswhere is arc length. The second equality follows by differentiating : the term parallel to disappears in the scalar triple product. It makes the correction for a parameter which is not arc-length parametrization explicit.
Put , , , and . The speed is the constant . At ,soTaking its dot product with yields . ThereforeThe screw motion of part (b) makes this independent of . Thus is a geodesic precisely when is an integer multiple of . Reversing the direction of traversal or the unit normal changes the sign of signed geodesic curvature; its magnitude is the absolute value of the displayed expression. The signed convention is needed in part (e).
First interpret the surface integral through the given parametric surface, counting multiplicity. SetIts derivative isUsing part (c), the fundamental theorem of calculus givesOn the other hand part (d), including its arc length factor, givesand the corresponding expression for is . Subtraction provesIf , the parametric surface is injective on the rectangle, so this is exactly the stated surface integral over its image. It also remains the ordinary image integral at , since the repeated seam has zero surface area.
The assertion for arbitrary needs a multiplicity convention or the restriction . This omission is present in the native PDF. For example, take , , , . The image is the entire cylindrical band , since already covers a full turn. Its ordinary surface integral of Gaussian curvature isBut the difference of the two signed geodesic curvature integrals is . Thus ordinary integration over the image set makes the unrestricted assertion false. The boxed parameter integral is valid for all and and is the appropriate corrected statement. This distinction is the multiplicity of a parametrized surface integral.
For , let and use the orientation of a surface determined by . Its positive boundary orientation follows the bottom side in increasing , the right side in increasing , the top side in decreasing , and the left side in decreasing . The Gauss-Bonnet theorem for this disc with four corners readswhere the are the signed exterior angles.
The bottom and top sides have cancelling geodesic curvature integrals: a screw motion takes one to the other with opposite boundary orientation. Explicitly, along increasing at fixed , the speed is one and the signed geodesic curvature is on both sides. The right and left sides contribute, respectively, the integral along and minus the integral along .
Although the coordinate sides are generally not perpendicular, the corner contributions still sum to . Indeed, let be the angle between and , soStarting at the bottom-left corner, the exterior angles are , , and . Their sum is . Cancelling this from the Gauss-Bonnet theorem leaveswhich is the identity in part (e). For a rectangle covering more than one turn, apply the same argument on the parameter rectangle with its induced Riemannian metric, or partition it into narrower rectangles and cancel the artificial internal boundary contributions. This gives the version counting multiplicity, as required by the correction in part (e).
Articles by others on the same topic
There are currently no matching articles.