Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
A tree considered up to graph isomorphism, with vertex names ignored. For example, all four labelled trees that are star graphs on represent one unlabelled tree. Dividing the total in Cayley's formula by does not count unlabelled trees: different shapes can have different numbers of distinct labellings.
A tree whose vertices carry distinct labels from a fixed finite set, as a labelled combinatorial structure. Two labelled trees on the same vertex set are equal when their sets of edges are equal: any comparison must keep every label fixed. Cayley's formula counts these trees.
For with , a decreasing travelling wave connecting to satisfies , . If , choose with . The triangle , is forward invariant: on its sloping side, . The descending unstable manifold of the saddle equilibrium stays in this triangle and tends to , producing a positive heteroclinic orbit. Below the threshold the origin is a stable spiral for positive , forcing sign changes; at conserved energy also excludes the connection.
Fisher's equation is a reaction-diffusion equation combining diffusion with logistic growth. For positive , one-dimensional fronts joining to zero have minimum speed . The phase-plane construction of a Fisher travelling front and the linearized leading edge explain this threshold.
A front is a spatial profile connecting different asymptotic states on its two sides. A travelling wave front moves with a constant speed; a stationary front has zero speed. In a one-dimensional stationary reduction it is a heteroclinic orbit between the corresponding homogeneous equilibria. Equal first-integral values are necessary for a stationary front in a scalar conservative spatial equation.
Find a maximum-weight Hamiltonian cycle in a complete weighted graph or complete directed graph. Nonnegative weights admit a cycle-cover patching half-approximation for Max-TSP without a triangle inequality. For integer weights, changing to , with , changes an -vertex tour's weight from to . Consequently the strict-threshold decision version is NP-complete: minimum-tour threshold becomes maximum-tour threshold .
Use binary directed-edge variables , one incoming and one outgoing edge at each city, and integer order variables for cities other than a distinguished city. The constraints for distinct nondistinguished cities force order increase along every selected edge away from the distinguished city. Summing around any cycle avoiding that city gives a contradiction, so the degree equations describe a single tour. There are nonzero constraint entries apart from the degree equations, also totaling entries. With costs at most , the objective requires bits and the remaining sparse constraint encoding bits. Omitting zero matrix entries is essential for this particular size bound.
Binary arc variables with one outgoing and one incoming arc at each vertex describe a cycle cover of a directed graph. For every nonempty proper vertex subset , the displayed inequality forbids a directed cycle confined to . Together these inequalities make the cycle cover one Hamiltonian cycle. They can be generated as violated cuts or used in branch and bound, rather than all being stored initially.
Add a dummy job . Give the arc cost equal to job 's initial setup, the arc its changeover cost, and every arc zero cost. A Hamiltonian cycle through the dummy represents a schedule, starting just after and ending just before it. The total processing time is constant on a single machine, so minimizing cycle cost minimizes completion time. Dropping subtour elimination constraints gives an assignment problem lower bound.
A 2-opt tour move removes two boundary arcs and reverses the intervening block to reconnect one tour. Such moves define a local-search neighbourhood; block reversals of length two include adjacent swaps and hence connect permutation schedules. For directed costs the asymmetric 2-opt reversal cost must include every reversed internal arc, not just the boundary changes.
Assignment relaxation of the travelling salesman problem by  Codex 0 Created 2026-10-14 Updated 2026-10-31
Minimizing over binary variables with one outgoing and one incoming edge at every graph vertex, and , is an assignment problem. Its feasible solutions are cycle covers of a directed graph, whereas a travelling salesman problem requires one Hamiltonian cycle. The relaxed minimum is therefore a lower bound on the tour cost. If its optimum contains a proper subtour , every tour omits at least one edge of . Branching into subproblems that respectively forbid each edge of preserves every possible tour. Solving each child assignment problem and pruning those whose bounds exceed the best tour yields a finite branch and bound algorithm. Equality also permits pruning when only one optimum is wanted.
Combine the untransmitted maternal and paternal alleles into a hypothetical control genotype, paired with the child's transmitted genotype. Even when two heterozygous parents have a heterozygous child and parent-specific phase is ambiguous, the combined untransmitted genotype is unambiguously heterozygous. Such pseudo-controls are matched family controls, not independent random individuals; Hardy-Weinberg principle is therefore not guaranteed merely by this construction.
If one parent is heterozygous and the other parent's genotype is missing, a homozygous child reveals the observed parent's transmitted allele, whereas a heterozygous child need not. Selecting only revealed transmissions can therefore bias the transmission disequilibrium test. For allele-1 frequency under random mating and fair transmission, the probabilities of an allele-1 or allele-2 homozygous child from an observed heterozygous parent are and . Among selected homozygous children, the observed allele-1 transmission probability is , not generally . A complete-trio analysis avoids this reconstruction rule; methods retaining missing-parent families need an explicit likelihood function or a valid conditional adjustment. Family-based association tests using genotype data with uncertainty discusses this bias.
Bounded-input bounded-output stability means that every bounded plant input produces a bounded plant output from zero initial state. For a causal continuous-time linear time-invariant system with a proper rational transfer function, BIBO stability is equivalent to every pole of the reduced transfer function having strictly negative real part. Cancel common factors first: an apparent denominator root may be absent from the reduced transfer function. For with , the only pole is , so the first-order low-pass filter is BIBO stable. [ref]
https://ocw.mit.edu/courses/6-241j-dynamic-systems-and-control-spring-2011/996025f6db0d90b00f11c44fc49b85f9_MIT6_241JS11_textbook.pdf. Dahleh, Dahleh and Verghese, section 15.3.1 and example 15.5: input/output versus internal stability
Internal asymptotic stability also requires every unforced internal state to decay. A canceled factor can hide a growing internal state. For example, consider the linear system of ordinary differential equationsIts zero-state transfer function can be written and has BIBO stability. Yet from zero initial conditions and a unit-step plant input, grows without bound while the plant output remains bounded. The reduced transfer function conceals that second state. Even a transfer function with no visible cancellations can be implemented with additional hidden states; its poles alone do not establish internal asymptotic stability of an arbitrary implementation.
A proper rational transfer function is a rational function whose numerator polynomial has polynomial degree no greater than its denominator polynomial, after common factors are canceled. Every finite-dimensional continuous-time linear time-invariant system of the form , has such a transfer function . [ref]
https://ocw.mit.edu/courses/6-241j-dynamic-systems-and-control-spring-2011/996025f6db0d90b00f11c44fc49b85f9_MIT6_241JS11_textbook.pdf. Dahleh, Dahleh and Verghese, Lectures on Dynamic Systems and Control, section 15.3.1
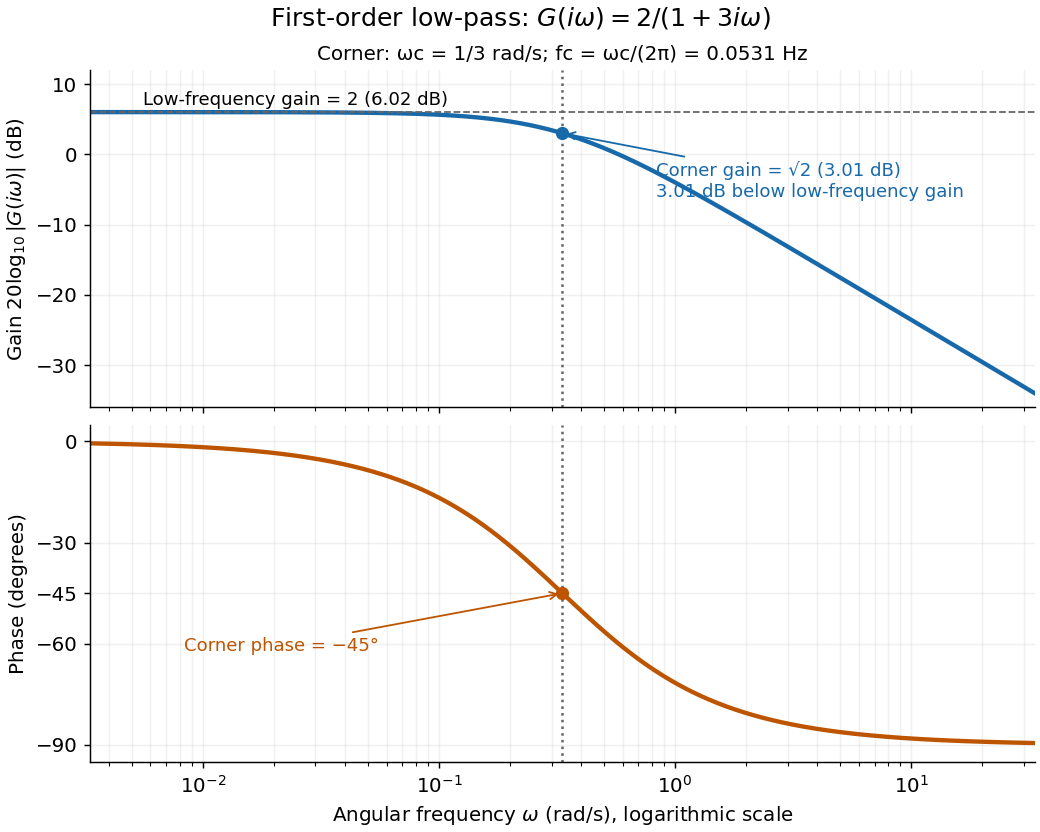
The continuous-time frequency response is the frequency response of a continuous-time linear time-invariant system. From zero initial state, a BIBO stable system driven by a sustained sinusoid approaches the steady responseAny decaying initial or switching transient is separate. The modulus is the amplitude gain; the complex argument is the shift in oscillation phase. Thus evaluating a transfer function at measures both how much of an oscillation passes through and how far it lags.
For the first-order low-pass filter, with , direct complex number arithmetic givesThe phase uses the inverse tangent branch between and . Low angular frequencies have gain close to and little lag. High angular frequencies have gain approximately and lag approaching . This is why the model is a first-order low-pass filter: it suppresses fast variation compared with slow variation. Rowell relates frequency response gain and phase to poles and then introduces Bode plots in MIT 2.004, lecture 32, sections 1 and 2.
At the corner angular frequency,For and , , the gain is , and the lag is degrees. The angular frequency is measured in radians per second; ordinary frequency is measured in hertz (cycles per second), with . Consequently the same corner is , not .
A first-order low-pass filter with positive constant gain and time constant obeys the ordinary differential equationThe derivative term limits how quickly the plant output follows a changing plant input. A larger time constant means slower adjustment. This standard form, with , is developed in Derek Rowell, MIT 2.004, lecture 20, section 1.1: first-order systems; the following calculation keeps the gain explicit.
Write . The Laplace transform of the derivative is , soSetting the initial condition gives the transfer function . Its single simple pole is , which has negative real part. The unforced response decays, and the input/output map has BIBO stability. The eventual gain for a constant plant input is .
For a unit step, represented by the Heaviside step function , the Laplace transform is . From zero initial condition,Take and , with dimensionless plant input and plant output. Then rises toward . After one time constant, at , it reaches , or of its final value. At , it reaches , or . These percentages describe the rise from zero, rather than an instantaneous jump to the target.
With a nonzero initial condition, the same step instead givesFor and , compare with . Their plant outputs differ by despite having the same transfer function and the same plant input. The extra exponential decay term must be supplied from the initial condition; and alone cannot determine it.
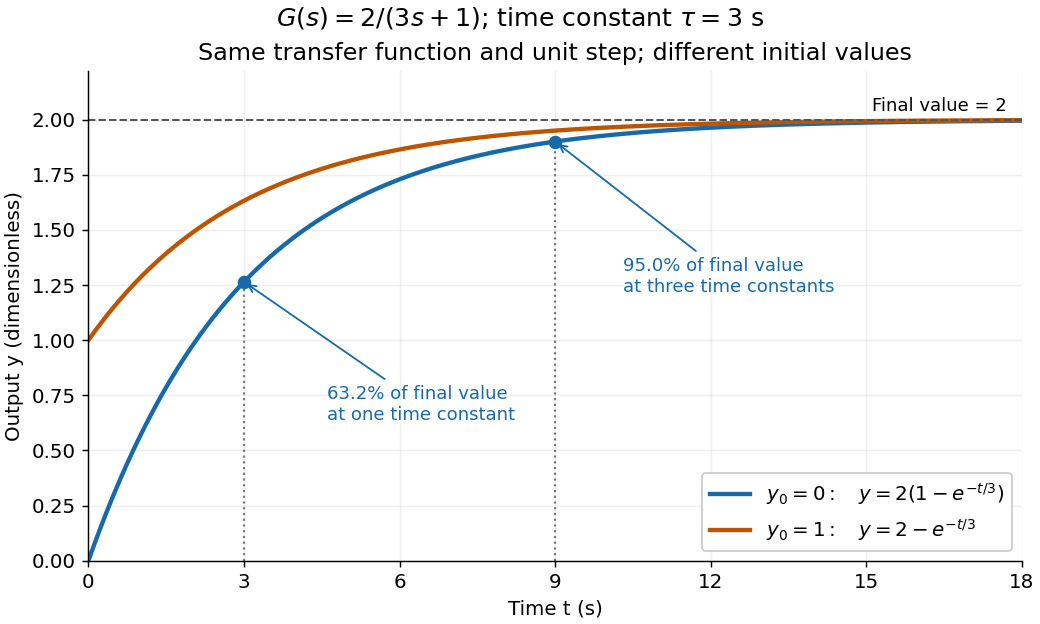
One transfer function, one unit step, two initial conditions
. The first-order low-pass filter has and time constant . The blue curve starts at and the orange curve at . The marked and levels refer to the blue curve's final value ; the two curves' difference is the decaying initial-state contribution. Details.A transcritical bifurcation need not already have its persistent branch at coordinate zero. The smooth parameter-dependent shift turns the displayed crossing of into the standard form with parameter . The crossing branches exchange dynamical stability. A mere nonsmooth relabeling of stable and unstable branches as would conceal this smooth exchange.
Applying the same measurable function to observations from two probability distributions cannot increase their total variation distance. Every output event is tested through its preimage , which was already one of the input events. ThereforeFor the four-outcome example, recording only whether the result is makes the output probability distributions identical: each is a Bernoulli distribution with parameter . The original total variation distance was , but this coarse measurement leaves zero discrepancy. Discarding information can make two sources less distinguishable.
The same contraction holds for a common Markov kernel : . On a finite set, expand , apply the triangle inequality to each output component, and use that each row of sums to one. A common randomized postprocessing step cannot increase distinguishability either.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:




All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact