Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 5 ii Solution by  Codex 0 Created 2026-10-03 Updated 2026-10-14
Evaluate all quantities at and assume a regular surface point, . The tangent plane passes through and is spanned by . ThusChoose the unit normal . The first fundamental form has coefficientswhile the second fundamental form has coefficientsTo derive the curvature formula, differentiate . This gives , , and . Therefore the shape operator , expressed in the tangent basis, isIts eigenvalues are the principal curvatures. Their product, the Gaussian curvature, is its determinant:Regularity ensures . Reversing changes the signs of and both principal curvatures but leaves unchanged. At a singular parameter point this quotient and the cross-product normal vector are undefined; an alternative regular chart or separate geometric analysis is required.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 5 i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14The core parametric surface interrogation is evaluation of the position and its derivatives through second order:Position answers point queries; first derivatives give the differential, tangent directions and normal vector; second derivatives supply curvature. An evaluator should also report the parameter domain, patch adjacency, boundary curves and knot or crease locations, and whether these derivatives exist at the queried point. At a discontinuity boundary it should provide the relevant one-sided limits rather than silently average them.
For spatial searches, provide restriction or subdivision into equivalent smaller patches and certified bounding volumes, with error estimates when an approximate mesh is used. These allow intersection and closest-point algorithms to reject remote patches and refine the remaining candidates. A useful interface therefore combines differential evaluation with domain/topology and enclosure information. Inverse parameter lookup, ray intersection and nearest-point search can be built from these primitives using subdivision and local root or minimization solves; they need not be presumed exact basic evaluations of every representation.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 4 iv Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Let the univariate linear precision sites be , meaningThen their Cartesian-product grid is a linear precision set for the tensor-product surface basis:Indeed, the first coordinate is , and the second is . More generally, take controls . The resulting parametric surface is exactlyThis proves linear precision of a geometric basis and affine map reproduction, including arbitrary changes of the embedding plane. In fact the products also reproduce the bilinear coordinate , since ; affine precision is the requested consequence.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 4 iii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Suppose in and in , including their respective knot joins. The mixed derivatives of the tensor-product surface basis areThese are continuous because each factor is continuous. A finite or locally finite control sum has the same property. In the usual total-order notation the parametric surface is therefore at least , and also has the stronger stated rectangular set of continuous mixed derivatives. Across a -knot its guaranteed order is , and across a -knot its guaranteed order is . No general improvement over a factor's smoothness is possible: setting and using recovers the univariate curve as a parametric surface constant in .
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 4 ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14If each univariate basis sums to one, distribute the finite sums, or use local finiteness when the basis is infinite:Thus the tensor-product surface basis is a partition of unity. In particular, translating every control point by a fixed vector translates the parametric surface by precisely that vector, and constant control data produce a constant parametric surface.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 4 i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14The tensor-product surface basis is . If both univariate bases consist of nonnegative functions, thenIf both factors are strictly positive at the chosen parameters, their product is strictly positive there as well. Its support is the Cartesian product of the two factor supports. With partition of unity, this nonnegativity additionally places the parametric surface point in the convex hull of the active control points.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 3 iii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14A norm estimate controls the worst possible refined differences for every choice of the initial controls. Submultiplicativity turns a length- contraction into a bound for arbitrary long products, so it proves a certain number of continuous derivatives. Its absolute values can lose cancellations; failure of the estimate is inconclusive. It therefore gives a lower bound on smoothness.
Conversely, an observable eigenmode of a repeated local product exhibits a particular sequence of shrinking neighborhoods with inadequate decay. General-position controls have a nonzero coefficient in that mode, so greater derivative continuity is impossible. Special symmetric or polynomial data may suppress the bad mode; this is why the general-position qualification matters. The obstruction gives an upper bound on smoothness, while failure to find an obstruction proves nothing. A lower bound on spectral growth becomes an upper bound on smoothness because large surviving differences correspond to rough behavior.
For example, the binary Cardinal cubic B-spline subdivision mask has symbol , up to an irrelevant index shift. At derivative order , the first-difference subdivision mask is , whose maximum parity sum is : the limit is at least . At , , and the surviving difference mode does not decay. For generic controls the third derivative is piecewise constant with nonzero jumps, so the subdivision curve is not . Here the lower and upper tests determine the exact integer continuity, but they need not coincide for an arbitrary subdivision mask. Stability, sum rules and borderline modes must be handled explicitly before interpreting any numerical estimate as a continuity level.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 3 ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14There are no numerical continuity bounds determined by and alone: the subdivision mask coefficients matter. First check constant reproduction, for every residue , and convergence. For the usual stationary scalar scheme, two useful calculations are a uniform contraction test and a spectral obstruction test. Higher smoothness is tested with derived difference subdivision masks.
Write and . Using backward differences , the generating-function identityproves the subdivision difference scheme relation . Iterating gives . To test a candidate limit, suppose the requisite sum rules hold, so is a finite Laurent polynomial. The scaled derivative controls are refined by the subdivision maskwhose residue sums are one. Their first differences are refined byThe powers of are essential because each refinement shrinks parameter intervals by .
A lower continuity bound comes from proving uniform contraction. The infinity norm of one difference-refinement step is bounded byIf , adjacent derivative controls contract geometrically at every location. More generally, form the -step subdivision maskand test . This proves convergence of the constant-preserving derivative scheme to a continuous limit. One justification is to compare consecutive piecewise-linear interpolants: their difference is bounded by a constant times the maximum adjacent-control difference, and the geometrically decreasing bound is summable. To identify the limit as , use fixed-degree Cardinal B-spline interpolants of the original refined controls. Their th derivatives are sums of the scaled finite differences; convergence of both functions and derivatives gives . Testing successive supplies a guaranteed lower bound.
An upper continuity bound comes from an observable noncontracting shape mode. Build finite local subdivision matrices for on a refinement-invariant control neighborhood. For a digit their entries are , since the new index is . Restrict to the realizable difference space and discard modes that do not affect the limit. A word corresponds to a nested parameter location. If its product has an observable eigenvalue with , repetition of this word makes some scaled derivative differences grow rather than tend to zero. For a stable limit representation, regularity would force these differences to vanish; hence general-position data cannot have continuity. A modulus-one mode requires examination of whether it actually persists, rather than an automatic rounding rule.
The two calculations can be organized through the joint spectral radius of these restricted matrices:These norm and spectral bounds for subdivision regularity make the test computable from the subdivision mask. The right bound certifies all-word contraction when it is less than one; the left bound detects a repeated-word obstruction when it exceeds one. Longer products improve the tests. A single matrix's spectrum is not a substitute for controlling arbitrary products. The product estimates also appear in Charina's analysis of subdivision regularity; the strict contraction and observable-mode arguments above explain their respective roles.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 3 i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Fix the indexing conventionwhere the subdivision arity is an integer. A change of the initial control can influence only indices after one step, where . After steps the possible descendant indices areLet be the smallest and largest active subdivision mask indices. Dividing by gives the enclosureTherefore the support of a stationary subdivision scheme, in initial control-grid units, is enclosed byFor the stated symmetric subdivision mask with active extremes , the width is . For a nonzero compactly supported basic limit function , this is an exact endpoint calculation: its refinement equation is . If is its right support endpoint, only the largest active subdivision mask index can contribute sufficiently close to the rightmost point of this sum; all smaller indices have argument beyond . Hence , giving . The left endpoint follows in the same way. This argument also excludes cancellation at an extreme for signed subdivision masks. The support for initial control is translated by . If the nominal subdivision mask was padded by zero coefficients, use its actual extremes; and a limiting subdivision curve has to exist before its support is meaningful. This calculation describes the entire possible influence region, rather than the width of a single refinement stencil on its finer grid.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 2 ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14The same relative coordinates give the proximity time of translating line segments asThis is a convex norm-constrained problem, rather than the linear feasibility problem for contact. One can solve it as a small second-order cone problem. If the distance between the initial line segments is at most , the answer is zero; if no feasible point exists, the threshold is never reached.
For an elementary analytic algorithm, consider the nine combinations in which each of is either free, fixed at zero or fixed at one. In each case, minimize the squared distance over the free parameters. Writing for plus the fixed endpoint contributions, and for the columns belonging to free parameters, stationarity isIf the Gram matrix is nonsingular, is affine in time. Retain only the time interval on which its entries lie in . The residual is then , and feasibility reduces toIntersect its solution interval with and the free-parameter validity interval, and record the first point. Include the four endpoint–endpoint cases, where there are no unfixed segment parameters. Take the earliest valid candidate among all cases. The actual closest pair belongs to one of these faces of the parameter square, so this enumeration cannot miss the first approach.
The complications are the quadratic threshold equation, changes of the active closest-point feature and singular Gram matrices for parallel or degenerate segments. In a singular case, keep the affine family of minimizers and its feasibility bounds, or use the original convex problem; a pseudoinverse answer alone can fall outside the segment even when another minimizer is feasible. Constant-distance cases and tangential threshold contact must also be retained. Merely checking moving endpoints misses approaches between interior points.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 2 i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Put , , and . A point on each moving segment has the form and , with . Contact is therefore equivalent toThe contact time of translating line segments is the minimum feasible . This reduces the entire continuous-motion problem to three linear equations and linear inequalities.
In three-dimensional space form the matrix . If it is nonsingular, solveusing a stable linear solver. A candidate with in the unit interval and is the only contact event and hence the earliest one; otherwise no contact occurs. Check initial intersection explicitly, so an already touching pair returns time zero.
If is singular, use a rank-revealing factorization to test consistency. Write every solution as , with columns of spanning the null space, and minimize its time coordinate subject to the box and nonnegative-time constraints. This is a small linear programming problem. It handles parallel segments, collinear overlap, a continuum of contact times and segments degenerated to points. Infeasibility means no future contact. When , the relative geometry is stationary: initially disjoint segments never meet. The first contact is the least feasible nonnegative time, not just an intersection of the two supporting lines.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 1 iv Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
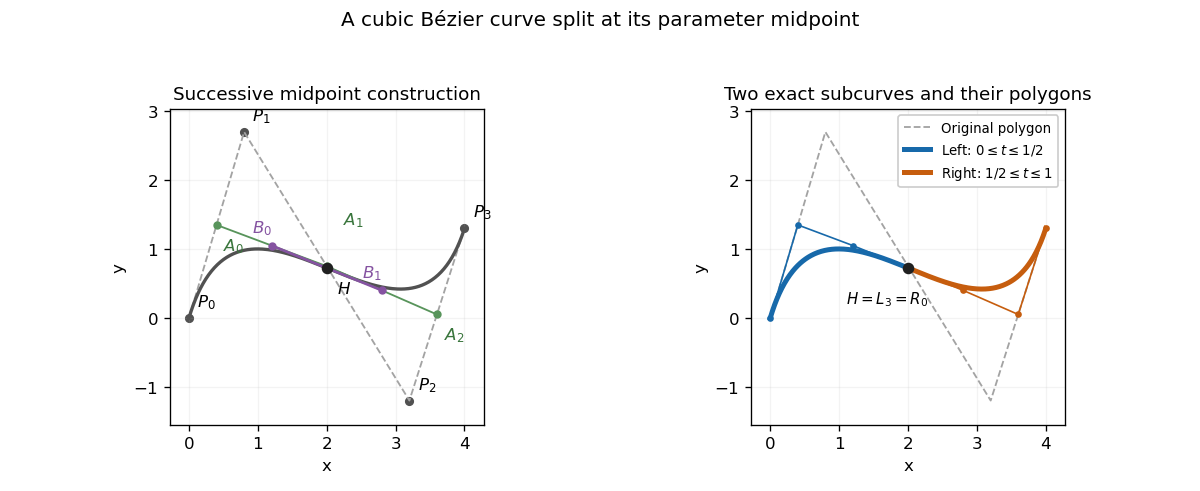
Codex 0 Created 2026-10-03 Updated 2026-10-14A cubic polynomial on either half is determined by its endpoint positions and endpoint derivatives. Use normalized parameters on the first half and on the second, so that derivatives with respect to are half the derivatives with respect to . Evaluation of the Bernstein basis at the split givesIf the left control points are , endpoint positions give . The cubic endpoint-derivative formulas give and . On the right, , and . Substitution yieldsThese are exact restricted Bézier curves, since they match all four endpoint Hermite data of the respective cubics.
The construction is also the midpoint case of De Casteljau's algorithm. Form for , then , , and . The two polygons are and . Their common tangent edges satisfy , as required for equal half-intervals. Thus the triangular midpoint construction simultaneously evaluates the split point and supplies the two exact representations.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 1 iii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Let the first Bézier curve have degree and control points , and the next have degree and control points . Use one increasing parameter on the two adjacent intervals. For a continuous join, their endpoints must agree: . If each interval has length , the endpoint derivatives are and . Therefore the parametric first-derivative join of Bézier curves is exactlyFor equal degrees, the two polygon edges incident on the common endpoint are equal vectors. Equivalently, are collinear with the join as their midpoint. Agreement of edge directions without these lengths gives only geometric tangent continuity at a nonzero tangent, not equality of derivatives in the chosen parameter. The displayed condition also covers zero endpoint derivatives. With unequal interval lengths , the condition is instead .
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 1 ii Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Applying the preceding derivative identity repeatedly yields the Bézier derivative control polygon for every order:where the forward finite difference is andThe induction step multiplies by the remaining degree and takes one more finite difference. Derivatives above order vanish. In particular,If the actual parameter interval has length and is its normalized coordinate, derivatives in the original parameter acquire the additional factor . These formulas allow derivative evaluation and join tests using only the control polygon.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 66 1 i Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Write for the Bernstein basis, and set when is outside its index range. Differentiating and using and givesHence, after shifting the first sum by one index,Thus the derivative is a degree-at-most- Bézier curve whose control points are . They are vectors rather than necessarily positions on the original Bézier curve. This is the Bézier derivative control polygon.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 65 4 d Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14A persistent saddle loop must return with the same energy. The Melnikov energy-balance method therefore requires, at first order,For the normalized orbit of part (c), put . Since , and ,For the general orbit has and . The energy mismatch is therefore proportional to , whose derivative with respect to is nonzero. This simple zero selects the saddle-loop curve:The remainder can be sharpened. Reversal of and interchanges and without changing the saddle-loop condition. Smoothness of the homoclinic splitting thus makes the selected an even function of , givingThe leading coefficient alone is enough to separate it from the Hopf curve . The integral hint in the PDF equals for nonnegative even integers ; for odd its integrand is odd and the integral is zero. Only even powers enter the calculation above.
Near the double-zero point, and with the stipulated absence of further bifurcations, the distinct open regions are:
- : no equilibrium points or local periodic orbits; wherever , and the flow passes through the bottleneck region.
- , : a saddle and a stable node or focus, with no local periodic orbit.
- , : a saddle, a stable focus and an unstable periodic orbit surrounding the focus. This cycle is its local basin boundary.
- , : a saddle and an unstable node or focus, with no small periodic orbit.
On the homoclinic curve the cycle becomes a saddle loop; its positive saddle trace makes the loop repelling on the cycle side. At the Hopf curve the unstable cycle shrinks into the negative equilibrium point. The node–focus discriminant curves merely change the spiral appearance and are not additional bifurcations. The impossibility of a periodic orbit for can also be seen without a picture: at a local minimum of periodic one would have and , but at its maximum the same strictly positive expression would be required to be nonpositive.
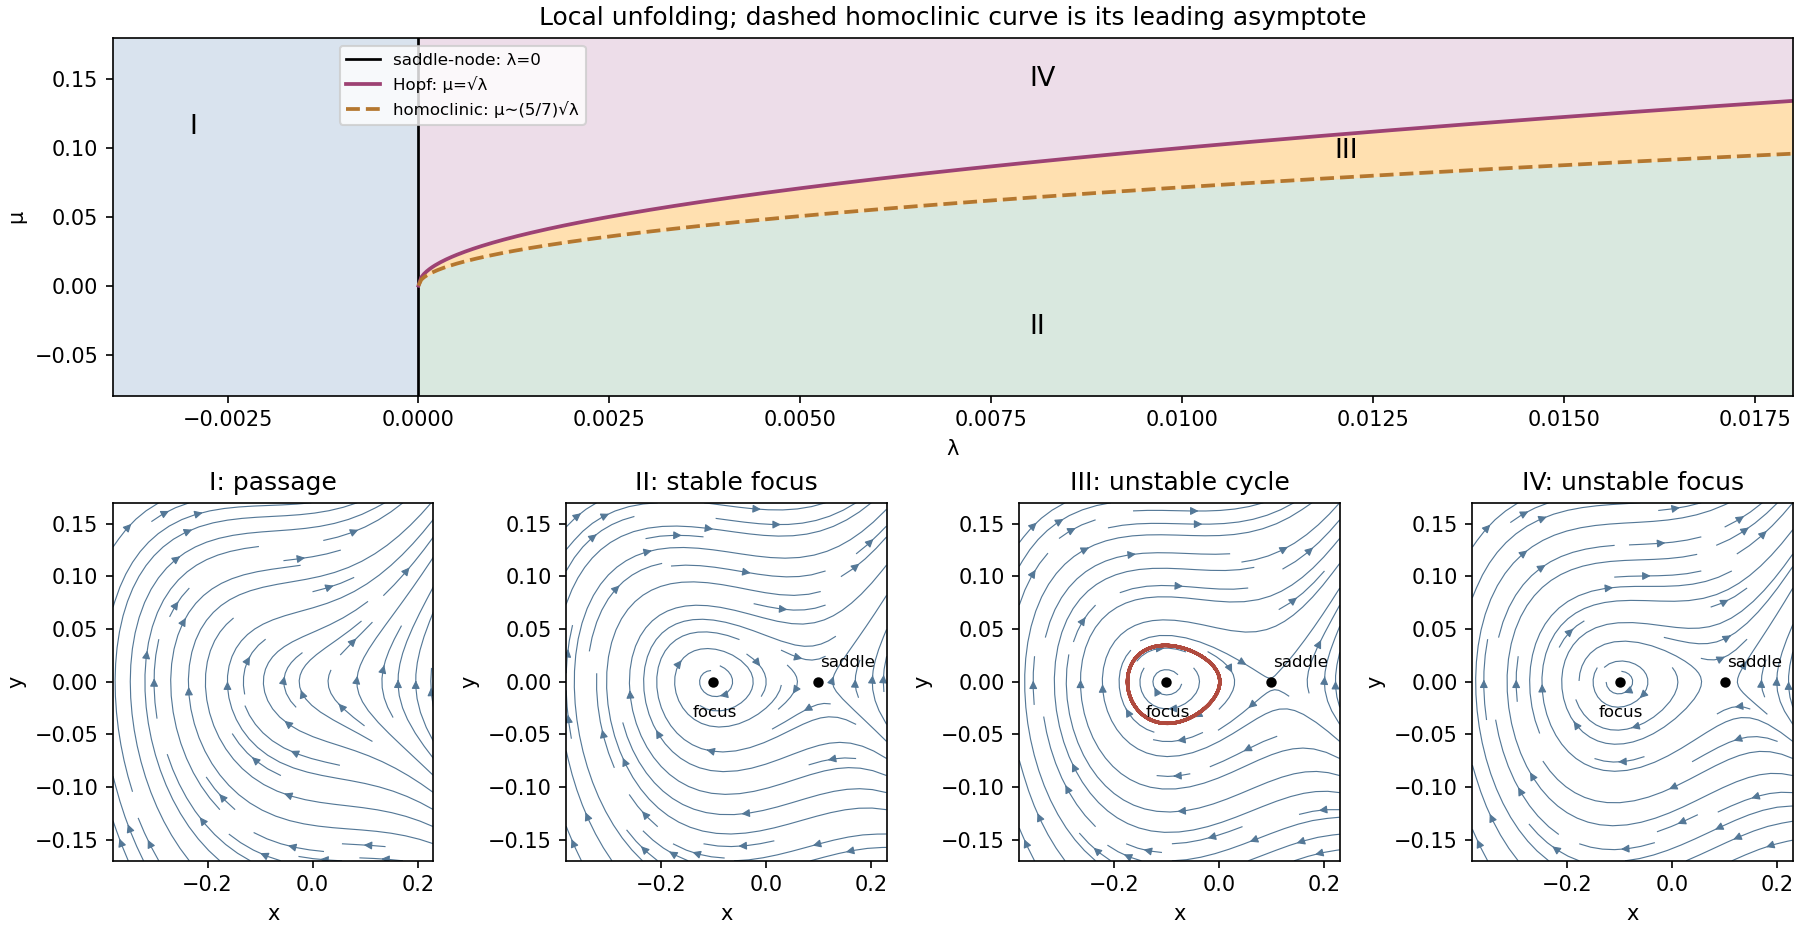
Local saddle-node, subcritical Hopf and homoclinic curves with the four nearby phase portraits
. Details. Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 65 4 c Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14 Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 65 4 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Set and use the stated weighted spatial and parameter scales. Dividing the two equations by and respectively giveswhere prime now means differentiation with respect to . The Hamiltonian function satisfiesThus is conserved for .
For , let . The conservative system has a center at with and a saddle at withClosed contours in the left potential well have . At the left-hand separatrix is a homoclinic orbit, sinceIt leaves and returns to , with its left turning point at . The right separatrix branches are unbounded. The energy levels above the saddle value are open, as are the separate right-hand components of lower energy levels. For there is no nondegenerate potential well and no such saddle loop.
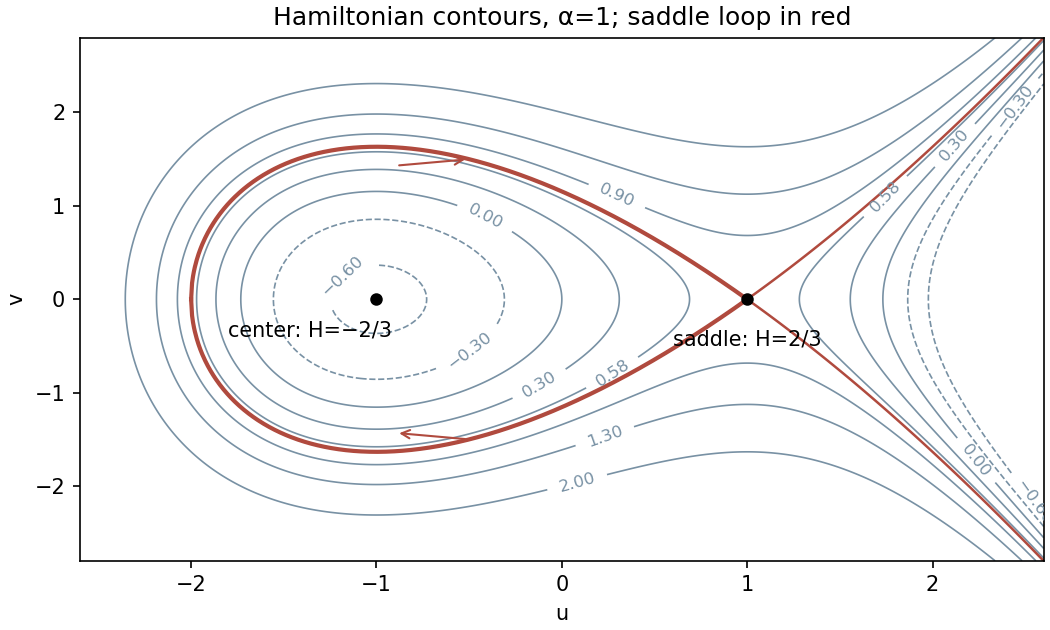
Conserved-energy contours, center and saddle loop of the leading Hamiltonian system
. Details. Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 65 4 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14For put . The equilibrium points are and , withThe positive branch is always a saddle. The negative branch is a sink for and a source for ; it is a node or focus according as is positive or negative. At the two branches meet in a saddle-node bifurcation when ; at the double zero eigenvalue with a nontrivial Jordan block gives a Bogdanov–Takens bifurcation. There are no real equilibrium points for .
The Hopf bifurcation curve is , equivalently on its positive- branch. Its frequency is . To determine the direction, shift , at this threshold; thenSet , to obtain , . A quadratic near-identity transformation, or harmonic averaging with its quadratic correction retained, gives the radial cubic coefficientwhere . The radial equation is . Hence the Hopf bifurcation is subcritical, with an unstable small periodic orbit on the stable-focus side .
The saddle's outgoing separatrix can return to its incoming separatrix, creating a homoclinic orbit. This global bifurcation cannot be detected from the equilibrium point's Jacobian matrix alone. The weakly Hamiltonian scaling below locates its curve and shows how the unstable Hopf cycle grows into the saddle loop. The final diagram includes the local saddle-node and Hopf curves and this global curve; it describes the neighborhood of the double-zero point.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 65 3 c Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Write , and . The polar amplitude equations arewith their reflected counterparts. On the equal-amplitude standing wave branch , equilibrium point requiresSquaring and adding eliminates the phase:For the candidate squared amplitudes areFor each positive root, set and . The quadratic identity ensures these define a phase. Conversely these phase equations imply the quadratic, so a nonzero phase-locked branch exists exactly when the discriminant is nonnegative and at least one root is positive.
Since , the discriminant condition is the printed for . It is sufficient under the usual above-onset supercritical assumptions , because then the plus root is positive. Without these assumptions the condition is not sufficient: satisfies it but gives . This is the positivity condition for a phase-locked standing wave, not a removable algebraic detail. The zero solution always exists and is distinct from the nonzero branch. For , the undivided equations must be used; a nonzero equilibrium point in this fixed rotating frame requires and . If , nonzero equilibrium points require and a compatible phase, with no cubic amplitude selection.
Strong enough forcing can overcome the nonlinear frequency shift, lock the sum phase to the external signal and produce a standing wave at half the forcing frequency. The difference phase remains free through spatial translation. The amplitude inequality is an existence condition, not a stability theorem: attraction requires the linearized forced amplitude equations, and nonlinear coefficients have not been restricted enough here to promise stability of every root.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:




All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact