
Parabolic comparison principle 2026-10-06
A first-contact argument compares a smooth solution with a subsolution or supersolution. At a first spatial minimum of their difference, the Hessian is nonnegative; a strictly favorable time derivative then contradicts contact. For , a positive decreasing constant-in-space barrier proves that positive periodic initial data stay positive for the lifetime of the smooth solution.
Obstacle problem Created 2026-10-06 Updated 2026-10-14
An obstacle constraint requires a solution to lie above a given function. In an optimal stopping problem, the value dominates the payoff, satisfies a generator equation where continuation is optimal, and a generator inequality where stopping is optimal. The complementary conditions can be expressed as a maximum equal to zero.
Parity conservation Created 2026-10-06 Updated 2026-10-18
An interaction commuting with the parity operator preserves total parity. A two-body final state has the product of its particles' intrinsic parities times the orbital factor , giving the parity selection rule for a two-body decay.
The solution map sends a data parameter to the set of minimizers of the associated objective, . Existence, uniqueness and local stability are distinct questions. Strong convexity gives uniqueness when a minimizer exists; the Aubin property gives a perturbation bound.
Truncated first moment bound 2026-10-06
For a nonnegative random variable with finite mean and , the part of the expectation on is at most . Subtracting gives . If the second moment is positive and finite, applying the Cauchy-Schwarz inequality to and the indicator variable gives the Paley-Zygmund inequality .
Molecular oxygen Created 2026-10-06 Updated 2026-10-14
The diatomic form of oxygen. Modern terrestrial abundance is maintained largely by oxygenic photosynthesis, balanced by chemical and biological sinks.
c-cyclical monotonicity Created 2026-10-06 Updated 2026-10-24
Direct-adjoint looping Created 2026-10-06 Updated 2026-10-07
Direct-adjoint looping repeatedly integrates a constrained state equation forward, integrates its costate or formal adjoint backward using terminal data, extracts the control gradient, and updates the control input within its constraints. It gives a practical route to local optimization but does not by itself prove a global minimum.
Passage through a translating optical trap Created 2026-10-06 Updated 2026-10-14
Optical slit 2026-10-06
An optical slit selects a narrow region of a focal plane. In a slit-limited spectrograph, the width of its image divided by the linear spectral dispersion sets the spectral width.
Optical camera 2026-10-06
An optical camera images incident beams on a photodetector; a spectrograph optical camera maps a diffracted direction into a position in its focal plane.
Focal ratio Created 2026-10-06 Updated 2026-10-18
The focal ratio, or f-number, of a converging optical instrument focused at infinity is the dimensionless quantitywhere is effective focal length and is the on-axis entrance pupil diameter. The notation f/4 means , not in a particular unit. A focal length with gives f/4. Closing the aperture stop until gives f/8 while retaining the same focal length. The mechanical opening need not equal . [ref]
https://www.edmundoptics.com/knowledge-center/application-notes/imaging/lens-iris-aperture-setting/. Gregory Hollows and Nicholas James, Edmund Optics, System Throughput, f-number, and Numerical Aperture
.For a thin lens in air with a circular aperture stop at the thin lens, the converging bundle from a distant on-axis point has half-angle satisfyingThe last step uses the small-angle approximation. For a compound optical lens, the cone is set by the image-side optical pupil and its distance from the receiving plane; the simple triangle is not an exact high-angle rule. At finite object distance a thin lens instead gives , by its imaging equation and transverse magnification, so its working cone corresponds to . Nominal focal ratio therefore does not alone specify close-range image irradiance. [ref]
https://www.edmundoptics.com/knowledge-center/application-notes/imaging/lens-iris-aperture-setting/. Hollows and James, working f-number and image-space cone
.Two useful scalings follow under stated conditions. For a fixed uniform incident beam and unchanged transmission, collected radiant flux scales as . For an extended source with fixed radiance, the central image irradiance scales approximately as in the paraxial approximation: the solid angle of the cone scales as . For an ideal uniformly illuminated unobscured circular entrance pupil, the first dark ring of the point spread function has angular radius and focal plane radiusHere is wavelength. These are first-zero radii, not diameters or a universal rule for resolving arbitrary objects. A proof outline evaluates the circular aperture's Fraunhofer diffraction using its Fourier transform, then uses the first zero of the resulting Bessel function. [ref]
Two-Dimensional Fourier Optics. Richard Fitzpatrick, University of Texas at Austin, Two-Dimensional Fourier Optics, circular-aperture first minimum
.At , the example's f/4 and f/8 first-ring radii are and . Closing the aperture stop halves , quarters collected radiant flux and doubles this diffraction radius. It can also reduce optical aberrations by excluding outer light rays; actual sharpness reflects both effects. This explains why a smaller aperture need not produce a sharper image. [ref]
https://www.edmundoptics.com/knowledge-center/application-notes/imaging/limitations-on-resolution-and-contrast-the-airy-disk/. Gregory Hollows and Nicholas James, Edmund Optics, The Airy Disk and Diffraction Limit
.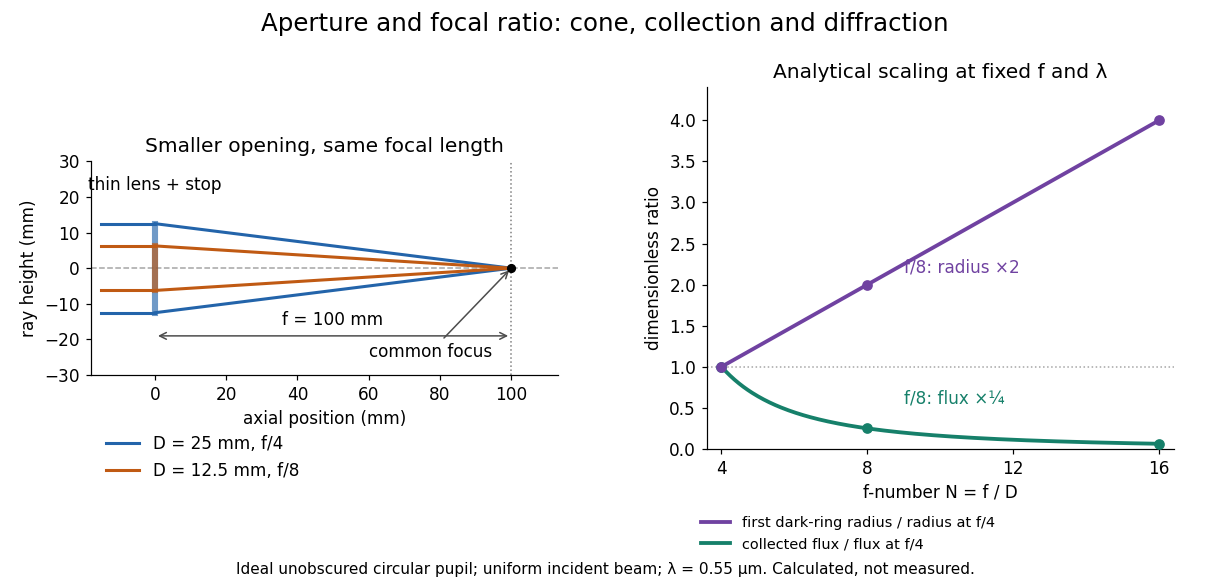
Aperture and focal ratio: a common optical focus, reduced collection and increased diffraction radius
. Original analytical illustration. Left: equal-scale thin lens geometry with and or . Right: collected radiant flux relative to f/4 is , and first-ring radius relative to f/4 is . The wavelength is ; the entrance pupil is circular, uniformly illuminated and unobscured. These are calculated quantities, not measurements. Details.
A proposed optical bench check puts a fixed collimator before a converging thin lens and a photodetector large enough to collect the entire image behind it. Compare two centred aperture stops of known diameters while fixing source output, detector gain and integration time. The integrated signal tests the collection law; a spatially resolved optical camera at the focal plane can separately measure the point spread function. Repeat a dark reading and the first aperture stop, and check that neither the incoming beam nor detector clips either bundle. A resolved pinhole source, imperfect collimation, optical aberrations and detector pixel size can dominate the apparent spot width; a single peak reading does not measure total collected radiant flux.
Convergence of a numerical method Created 2026-10-06 Updated 2026-10-14
For an initial value problem, convergence means that the largest global error on each fixed finite time interval tends to zero as the step size tends to zero and the starting errors vanish. For linear multistep methods, the Dahlquist equivalence theorem separates this requirement into consistency of a numerical method and zero-stability.
Multigrid method Created 2026-10-06 Updated 2026-10-31
A multigrid method solves a linear system by combining local relaxation with coarse-grid correction on a hierarchy of meshes. The key is to divide the work by scale: a suitable relaxation removes rapidly oscillating approximation error, while coarse-grid correction addresses slowly varying approximation error that relaxation barely changes. A broad error hump occupies many fine-grid points but fewer coarse-grid points; it becomes easier to resolve by relaxation after enough coarsening. This complementary action is why multigrid methods are useful for large finite difference method and finite element method systems.
For a concrete model, take the one-dimensional Poisson equation with homogeneous Dirichlet boundary conditions:Use interior points , , and the centered finite difference systemThus is a symmetric matrix and a positive-definite matrix. The minus sign in fixes this positive convention; changing both and to their negatives leaves the relaxation update unchanged. For , the linear system has the exact discrete solution , since the centered finite difference is exact on this quadratic polynomial. In general, the exact discrete solution need not equal the sampled continuous solution: solving the linear system removes algebraic approximation error, not the global discretization error.
Let solve , let be the current approximation, and define the signed approximation error . The linear-system residual is , so . In particular, a linear-system residual is available without knowing ; it supplies the right-hand side for a correction equation. With , a weighted Jacobi method sweep isThe sine eigenvectors shared by and the iteration matrix are , . Their eigenvalues areFor , one weighted Jacobi method sweep with multiplies the lowest Fourier frequency mode by about , but the highest Fourier frequency mode by about . Four sweeps retain about of the first amplitude and of the second. The sign reversal of the second amplitude is harmless when its magnitude shrinks. However, the plain Jacobi method, , has factor : at it is about . A nearly alternating mode near the grid's Nyquist limit therefore persists almost as strongly as the smoothest mode. Plain Jacobi method convergence on a fixed Dirichlet boundary condition grid does not imply effective smoothing.[ref] The high-frequency smoothing factor of weighted Jacobi is uniformly at most for and ; the exact finite-grid high-frequency Jacobi smoothing optimum distinguishes this convenient uniform choice from the finite-grid optimum.[ref]
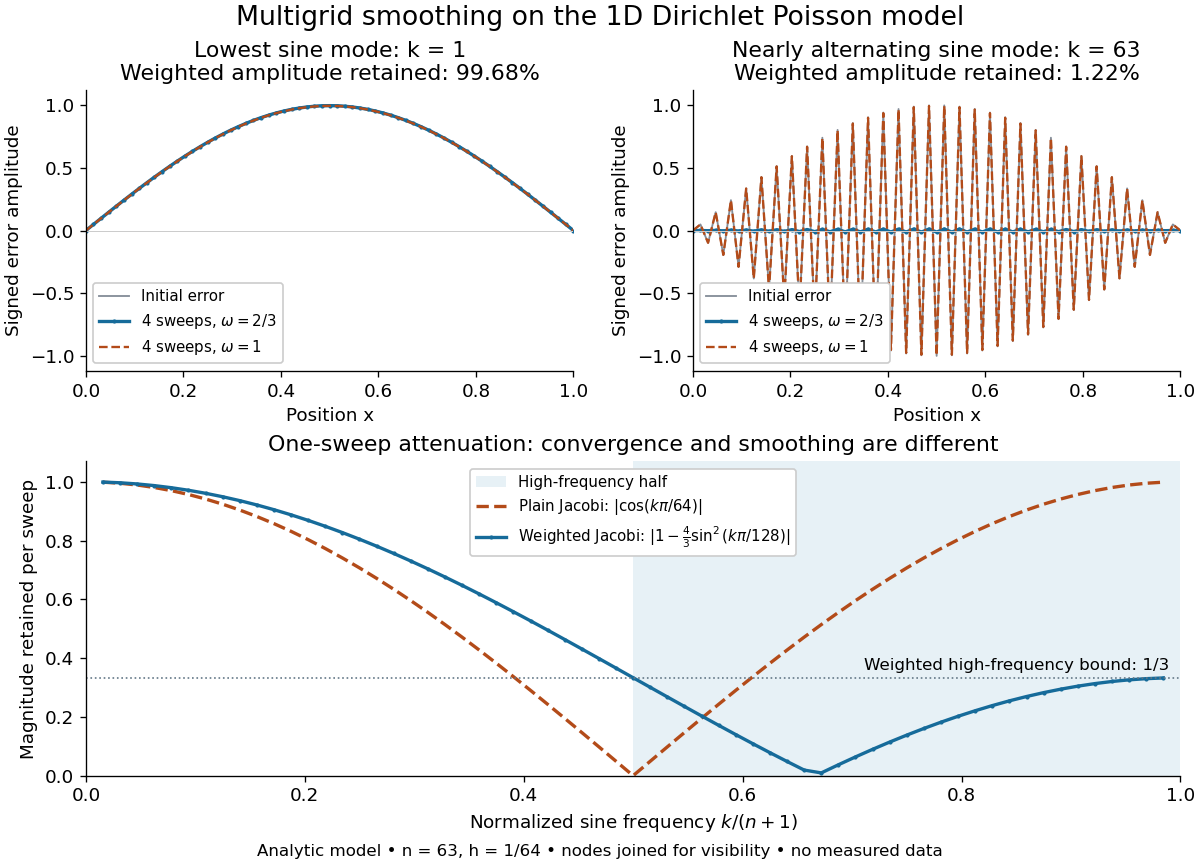
Analytic Poisson error modes: weighted Jacobi damps short wavelengths while plain Jacobi struggles near the Nyquist limit
. Details. 
One two-grid cycle applies a few weighted Jacobi method sweeps, computes the linear-system residual, performs coarse-grid correction, and applies a few more sweeps. The first relaxation makes the remaining approximation error easier to represent on a coarse mesh; the last relaxation damps oscillatory components left after the transferred correction. In a geometric multigrid V-cycle, replace the expensive exact coarse solve by one recursive cycle on the coarse correction equation, starting its correction from zero. Repeat until a tiny coarsest linear system can be solved directly, then return through the levels by adding each interpolated correction and post-smoothing. The descent and return give the cycle its V shape.[ref]
For this one-dimensional model, fixed sweep counts and bounded local finite difference and transfer work give a geometric multigrid V-cycle cost proportional to , hence in Big O notation. A fixed error reduction also needs a contraction factor bounded below one independently of ; per-cycle work alone does not establish that. Starting from arbitrary approximation error and demanding a relative reduction generally adds a factor proportional to in the cycle count. Full multigrid uses coarse solutions as initial guesses on successively finer meshes to target the global discretization error efficiently. The two-grid Poisson factor with weighted Jacobi illustrates favorable convergence for this model. Other partial differential equations, strong anisotropy, or poorly chosen coarse spaces and relaxation can defeat these choices; a linear-work guarantee for arbitrary linear systems does not follow.
A historical example of the multilevel viewpoint is Achi Brandt's April 1977 paper, which analyzes adaptive meshes and reports numerical experiments on linear and nonlinear boundary value problems. This is a documented development of the approach, not a claim that the paper was its first invention.[ref] The figure above is generated from the displayed eigenvalues, with lines joining discrete nodes; it contains no experimental measurements.
Implicit time-stepping method Created 2026-10-06 Updated 2026-10-31
An implicit time-stepping method determines a new solution value through an equation involving that same value. A small-step contraction mapping argument often establishes local solvability when the vector field is Lipschitz continuous. Examples include the Backward Euler method, implicit Runge-Kutta methods and implicit linear multistep methods. Solvability of the update is a separate issue from stability of a numerical method.
Null condition 2026-10-06
The null condition for a nonzero vector in a Lorentzian metric is . Applied to the tangent of a curve it makes the curve a null curve. Nullity alone does not imply the geodesic equation; an additional zero or tangent-parallel covariant acceleration is required.
Sum of future-pointing null vectors 2026-10-06
In Minkowski spacetime with metric signature , write two nonzero future-pointing null vectors as and , where and are unit vectors. Their Lorentzian inner product givesThus their sum is a future-pointing causal vector. It is a null vector exactly when the spatial directions coincide, and a timelike vector otherwise. The positivity of the time components is essential: adding past- and future-pointing null vectors can instead produce a spacelike vector.
Null geodesic incompleteness 2026-10-06
Null geodesic incompleteness means that some maximal geodesic with a null tangent has a finite endpoint of its affine parameter. This can indicate a removable missing region or a genuine obstruction; it does not alone assert curvature divergence.
Normed division algebra Created 2026-10-06 Updated 2026-10-07
A normed division algebra is a nonzero unital normed algebra in which every nonzero element has a two-sided multiplicative inverse. The complex Gelfand-Mazur theorem forces such an algebra to be , even when completeness is not initially assumed: embed it in its Banach algebra completion and use nonemptiness of the Banach-algebra spectrum.
Lorentz frame Created 2026-10-06 Updated 2026-10-14
A Lorentz frame at a spacetime event is an orthonormal tangent basis with metric . Future-oriented frames are related by proper orthochronous Lorentz transformations. Any such basis can be realized at the event by normal coordinates.
There are unlisted articles, also show them or only show them.