
Euclidean geometry Created 2026-09-24 Updated 2026-10-13
Euclidean geometry describes flat Euclidean space using lengths, angles, and rigid motions. A coordinate realization uses points , Euclidean distanceand angles determined by the dot product. The coordinate axes are a convenience: translations and rotations change coordinates while preserving these measurements. This makes Euclidean geometry useful for comparing figures and converting measurements along different directions into a single distance.
In the Euclidean plane, through a point outside a line there is exactly one parallel line. This is a standard equivalent formulation of the parallel postulate. Euclid's fifth postulate in the Elements instead describes when two lines meet using the interior angles made by a crossing line.[ref] The assumption has consequences we often take for granted: a triangle's interior angles sum to , and similar triangles can differ in size while keeping their angles. Comparing with spherical geometry reveals that these are properties of a particular geometry.
As a computed example, the diagonal from to in a rectangle has length . The Pythagorean theorem explains why perpendicular contributions add as squares. If the directions cease to meet at a right angle, the law of cosines supplies the missing angle-dependent term. The beauty is that a single distance formula unites geometric constructions, coordinate calculations, and orthogonality in linear algebra.
Make the assumptions visible: in a Cartesian coordinate system with orthogonal axes and the same length unit on each axis, take , and . The vectors and have dot product zero, establishing a right angle at before using the Pythagorean theorem. A sketch that merely looks like a right triangle supplies no such guarantee. Likewise, an image stretched horizontally and vertically by different amounts can distort both lengths and angles; a displayed shape and the assumptions defining it must be kept separate.
For a less origin-dependent measurement, take and . Their displacement vector is , so their Euclidean distance is again . Its Euclidean norm records the direct separation, whereas travelling first horizontally and then vertically covers length . This connects measuring a diagonal to locating two positions from a Cartesian coordinate system. A translation changes where the positions are recorded without changing their separation; a rotation changes the component values without changing the Euclidean norm.
Fractal geometry Created 2026-09-24 Updated 2026-10-13
Fractal geometry studies fractals. Fractal geometry studies recursively structured sets and spaces, often with noninteger scaling dimension.
Trigonometric function Created 2026-09-24 Updated 2026-10-13
Trigonometric functions turn an angle into a coordinate or a ratio of lengths. Start at on the unit circle and rotate counterclockwise through radians: the resulting point isThe cosine records horizontal position and the sine records vertical position. This definition continues around the whole circle, including negative angles, so the signs encode direction rather than requiring a separate rule for each right triangle.
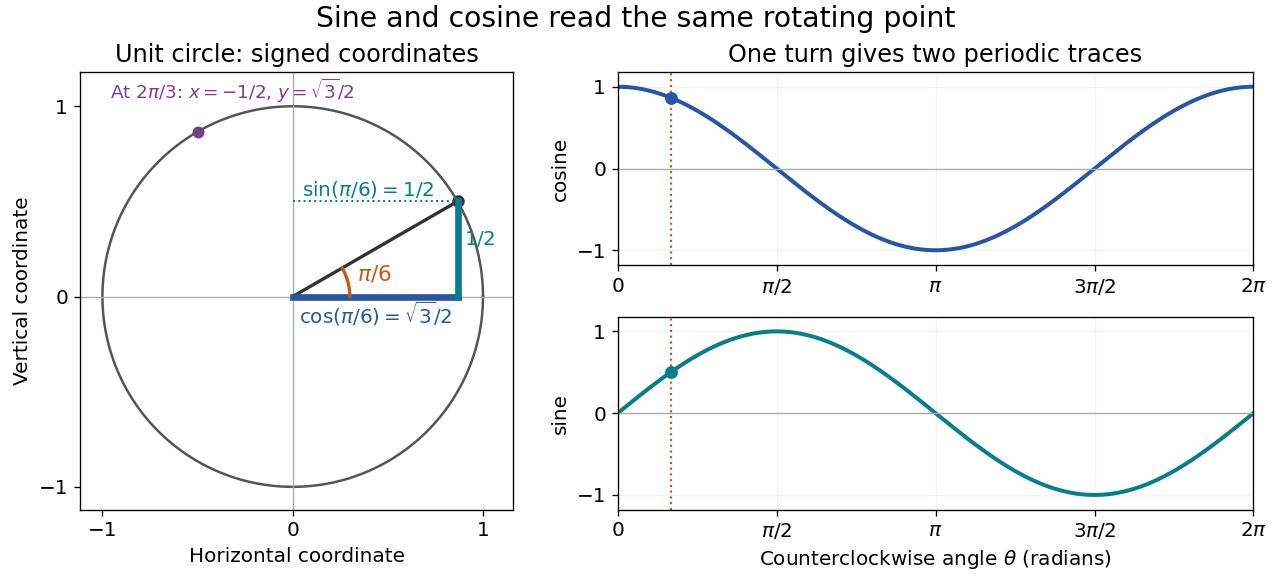

The unit circle picture explains why these functions are useful beyond measuring triangles. The two coordinates of a point rotating at constant angular speed are periodic functions. Scaling the radius to and using gives and . A circular motion becomes two simple repeating traces, connecting Euclidean geometry, simple harmonic motion, and Fourier series.
For an acute angle in a right triangle, rescaling its hypotenuse to one recovers the familiar ratios: sine is opposite side divided by hypotenuse, and cosine is adjacent side divided by hypotenuse. The tangent function is their ratio, , wherever the denominator is nonzero; the secant function, cosecant, and cotangent give the other reciprocal ratios.
The same names extend to complex numbers through the complex exponential:These definitions agree with the circle interpretation for real angles. For complex arguments, the values need not lie between and ; the literal circle-coordinate picture is restricted to real arguments. [ref]
https://dlmf.nist.gov/4.14. NIST Digital Library of Mathematical Functions, §4.14: exponential definitions and periodicity
Topological degree Created 2026-09-24 Updated 2026-09-24
Topological degree is an integer-valued signed count of preimages that is stable under suitable perturbations.
Spherically symmetric solution of Poisson equation Created 2026-09-24 Updated 2026-09-24
Sphere-plane intersection Created 2026-09-24 Updated 2026-09-24
Sequentially compact space Created 2026-09-24 Updated 2026-10-24
A space is sequentially compact when every sequence has a convergent subsequence. A metric space is compact exactly when it is sequentially compact.
Product topology Created 2026-09-24 Updated 2026-10-13
The product topology turns separate observations into a notion of closeness: a basic test checks finitely many coordinates, with a separate tolerance in each. For an index set and topological spaces , the underlying Cartesian product and its coordinate projection maps areThe product topology is the coarsest topology making every a continuous map.[ref]
Point-Set Topology, Chapter 2: Continuous functions. Definition 2.2.4 and Proposition 2.2.5: coordinate projections and the coarsest topology making them continuous
The Cartesian product specifies which points exist; the product topology specifies their neighborhoods. Finite observations motivate its finite-coordinate basis for the product topology, while convergence in a product space and continuity into a product space explain why it is useful. The compactness result for this construction is Tychonoff's theorem.
Plane Poiseuille flow Created 2026-09-24 Updated 2026-10-14
Plane Created 2026-09-24 Updated 2026-10-18
A plane is a two-dimensional affine subspace: a point together with every linear combination of two linearly independent direction vectors ,In three-dimensional Euclidean space, a Cartesian equation of a plane fixes one linear equation , with a nonzero normal vector . The two free directions are orthogonal to . A plane extends indefinitely; a rectangular patch in a drawing marks only part of it, and does not define an edge of the plane.
For example, the plane contains . The vectors and are linearly independent and satisfy . Hence its points are exactly : substitution gives for every real , and every solution has , .
The description separates position from direction. A translation of the plane changes and possibly , while retaining its parallel directions. A plane through the origin is a linear subspace; the displayed example is not, since the zero vector fails its linear equation. This distinction matters when applying orthogonal projection: subtract an anchor point before projecting onto the direction linear subspace.
Historically, Euclid's Euclid's Elements by Euclid, Book I Definition 7, describes a plane surface through the straight lines lying on it. David E. Joyce's accompanying guide notes that this older use can include a bounded square or circular figure. That usage differs from the whole unbounded affine subspace used here.[ref]
Book I, Definition 7. Euclid's Elements, Book I Definition 7 and David Joyce's Guide: plane surfaces and bounded figures
Path-connected space Created 2026-09-24 Updated 2026-10-13
A topological space is path-connected if, for every , there is a continuous mapThis continuous path must stay within for its entire duration. Its parameter need not represent physical time, and continuity does not require a derivative or finite arc length. [ref]
https://math.mit.edu/~hrm/palestine/munkres-topology.pdf. Munkres, Topology: A First Course, section 3-2, definition on p. 155
In the closed interval , any are joined by . For and , this becomes , so , , and . All its values stay in . In the union , however, a continuous path from to would attain by the intermediate value theorem, although . Thus is not path-connected.
Every path-connected space is a connected space. Proof outline: if admitted a separation of a topological space, choose and . A continuous path between them would have nonempty open inverse images with empty intersection and union . This contradicts the connectedness of that closed interval.
The converse fails: the topologist's sine curve is connected but has two path components. Path connectedness is useful when we need an actual continuous path of allowed positions, rather than only the absence of a separation of a topological space. For instance, when modelling allowed positions as a topological space, membership in the same path component answers whether one can move continuously between two positions while remaining in that topological space.
Joukowski map Created 2026-09-24 Updated 2026-09-24
Elliptic coordinates Created 2026-09-24 Updated 2026-09-24
Distance from a point to a plane Created 2026-09-24 Updated 2026-10-18
The distance from a point to a plane is the shortest Euclidean distance from the given point to any point on the plane. For with nonzero normal vector , a point hasThe numerator is the residual of the plane equation, not yet a length: its size depends on the chosen normal vector. Dividing by that vector's Euclidean norm removes this arbitrary scale.
For the original example and , the normal vector is and . The residual is , so the distance is . Using the equivalent plane equation instead gives numerator and Euclidean norm , hence the same . A point already on the plane has zero residual and zero distance.
Why is the perpendicular route shortest? Let be the closest point on a plane and any other point on it. The displacement is orthogonal to , so the Pythagorean theorem givesEquality holds only for . This is the closest-point principle of orthogonal decomposition, applied after a translation of an affine plane to its direction linear subspace.[ref]
Orthogonal Projection. Interactive Linear Algebra, §6.3.1: Orthogonal decomposition theorem, Closest vector and distance
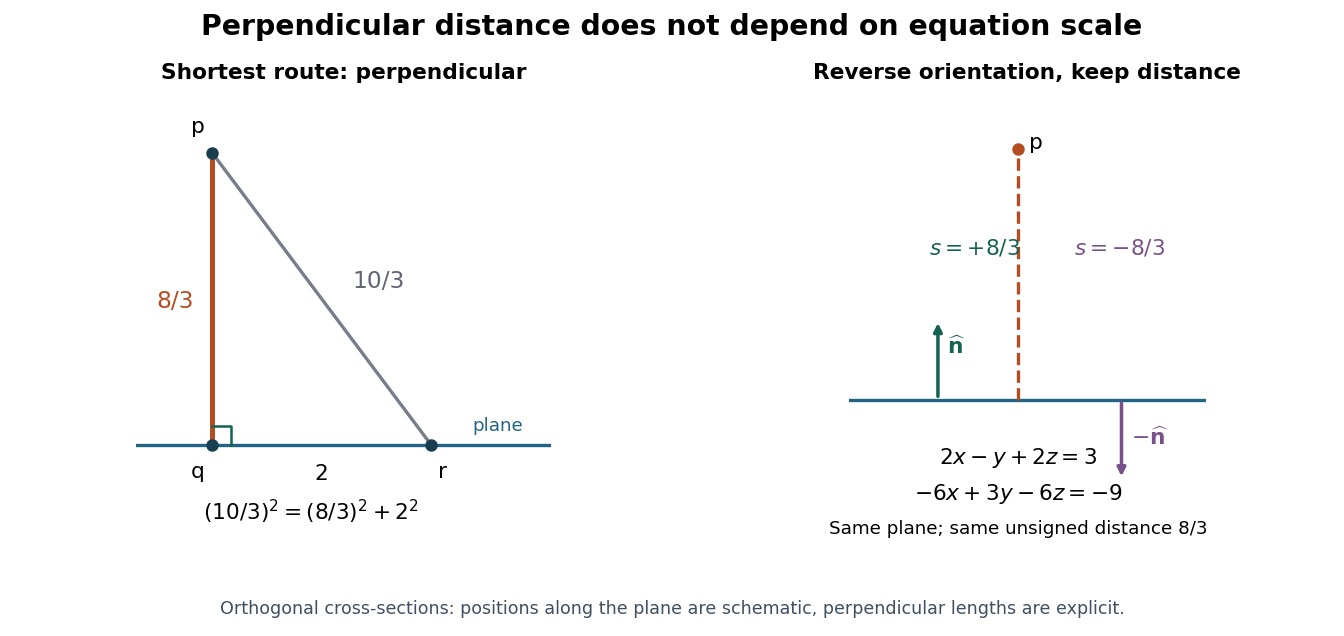
The perpendicular route to a plane is shortest, and rescaling its plane equation preserves the distance
. Original cross-section using the worked distance . The comparison point lies two length units along the plane from the closest point on a plane, giving a longer route of . The second panel reverses the unit normal without moving the plane. Details.
The formula is useful whenever the deviation from a flat reference should be measured geometrically. A raw linear equation residual cannot be compared across arbitrary equation scalings; a perpendicular distance can. The same reasoning works for a hyperplane in any finite-dimensional Euclidean space, with the appropriate number of coordinates.
Connected space Created 2026-09-24 Updated 2026-10-13
A topological space is connected when it has no separation of a topological space: no partition of a set into two nonempty open subsets satisfyingHere the union covers all of , and the intersection is the empty set, so no point belongs to both pieces. For a subset of a larger topological space, "open" means open in the subspace topology: each piece is the intersection of with an ambient open set. Both pieces must be open; merely dividing a drawing into two colours does not establish a separation of a topological space. [ref]
https://math.mit.edu/~hrm/palestine/munkres-topology.pdf. Munkres, Topology: A First Course, section 3-1, definition on p. 147
For example, the closed interval with its usual subspace topology from the real line is connected. The proposed split fails: the second subset is not open in , since every neighbourhood of in contains points less than . More generally, a connected subset of the real line is precisely a real interval. In contrast, for the unionthe open intervals and exhibit as nonempty open subsets in the subspace topology of . Their intersection is empty and their union is , so is not connected. Although are closed intervals in the real line, they are also open within .
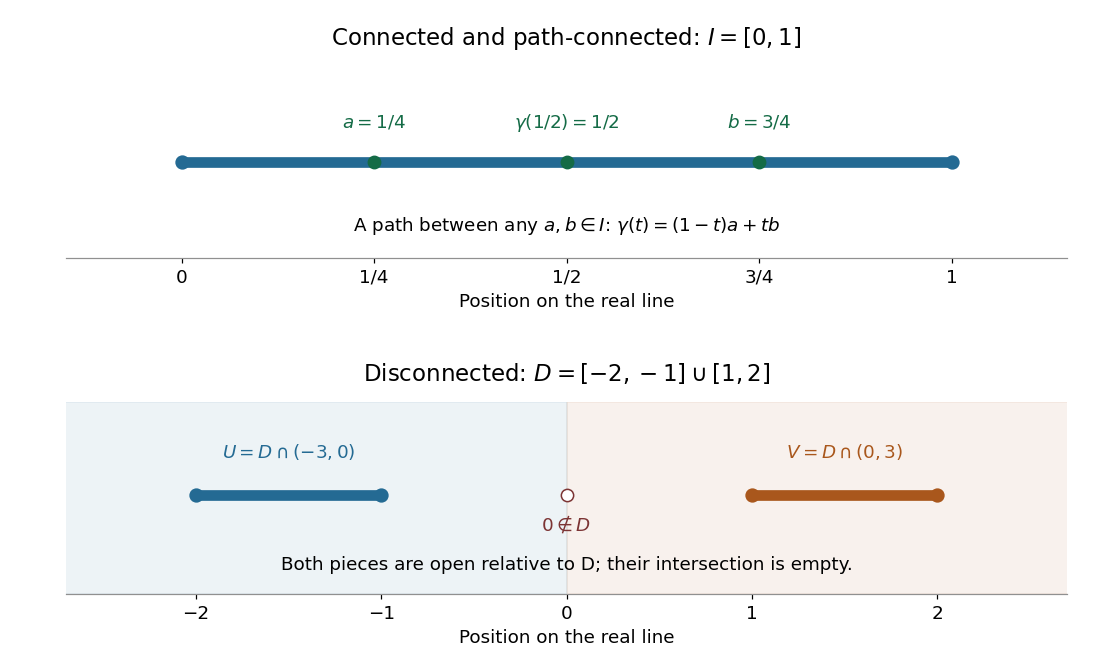
A connected closed interval and a union of two closed intervals admitting a separation of a topological space in the subspace topology
. Details. 
Why is connectedness useful? A continuous image of a connected space is connected: a proposed separation of a topological space in the image would pull back through the continuous map to a forbidden separation of a topological space in its source. Thus a continuous map from a real interval to the real line cannot skip values between two attained values. This is the intermediate value theorem. For a computed example, the continuous function on has image ; the value occurs at . Connectedness guarantees an input attaining that value even when we have no formula for it.
Path connectedness is a stronger condition: it supplies a continuous path between every pair of points. The topologist's sine curve below shows that a connected space need not be a path-connected space.
Conformal map Created 2026-09-24 Updated 2026-10-13
Classification theorem for surfaces Created 2026-09-24 Updated 2026-09-24
Differential geometry Created 2026-09-24 Updated 2026-10-13
Differential geometry uses calculus to study smooth curves, smooth surfaces, and smooth manifolds. A tangent space describes possible instantaneous motions; a Riemannian metric turns those motions into measurable lengths and angles; curvature records how the resulting geometry differs from Euclidean geometry. Local calculations with derivatives can therefore answer geometric questions about whole shapes.
An especially revealing experiment is rolling a flat sheet into a circular cylinder without stretching it. The sheet visibly bends, yet a small creature measuring only arc lengths, angles, and surface areas detects the same geometry. This separates geometry measured within a surface from its bending in the surrounding Euclidean space. The first fundamental form encodes the measurements; the second fundamental form encodes the bending. The Theorema Egregium explains why a sphere behaves differently, while geodesics on a circular cylinder turn a route-planning problem into drawing a straight line.
Complex geometry Created 2026-09-24 Updated 2026-10-18
Algebraic geometry Created 2026-09-24 Updated 2026-10-18
There are unlisted articles, also show them or only show them.