A surface of revolution is invariant under rotations around a fixed axis and is locally generated by rotating a profile curve.
The tractoid is the surface of revolution of a unit tractrix. For with , its coordinate tangent vectors are orthogonal and have squared lengths . The coordinates , transform this first fundamental form into , giving a local isometry to the hyperbolic plane. Thus its Gaussian curvature is minus one. The angular coordinate is periodic globally, while its unwrapped coordinate is a real variable; this distinguishes the local metric identification from a global embedding of the whole hyperbolic plane.
In unwrapped upper-half-plane coordinates, the annulus on a tractoid identifies modulo . Connect and by the upper circular hyperbolic geodesic with center . Its largest height is . The displayed condition puts the whole arc in the annulus. Under the angular identification its endpoints coincide, and the resulting geodesic segment winds once before returning. Its terminal tangent generally differs from the initial tangent, so this construction does not give a smooth periodic closed geodesic. It explains how local hyperbolic geometry creates a returning segment on a surface of revolution.
For the radial profile , with , use the parametrized surface , . The two tangent vectors are orthogonal and have Euclidean norms and . Their cross product gives the displayed surface area. Geometric surface area assumes a single covering of the radial profile. A general three-dimensional generating curve must first be replaced by its actual radius ; its spatial arc length cannot simply replace the radial profile's arc length.
The lateral surface obtained by rotating a straight segment in a plane containing the rotation axis has endpoint radii and slant length . Its surface area is : the radius is linear in the segment's arc length, so the surface area of a surface of revolution is . This formula excludes the end disks and assumes that the segment's radial direction is fixed. A straight segment whose endpoint horizontal directions differ generally sweeps a different surface of revolution.
Let a simple closed regular planar curve be invariant under point reflection through a center and remain strictly on one side of a coplanar axis of rotation, at distance from its center. If is its arc length, its surface of revolution has surface area . To prove this, choose coordinates with the center at the origin and the axis of rotation at . The surface area formula is . Pair each point with its reflected point: the arc length element is unchanged and changes sign. Thus , proving the result. The one-side condition prevents the surface from passing through the axis of rotation or requiring an absolute value with changing sign.
A toroid is a ring-shaped surface of revolution obtained by rotating a closed planar profile about an axis in its plane that stays outside the profile. A circular profile gives a torus; a rectangular profile gives a ring with rectangular cross-section. The enclosed solid supplies the core geometry in a toroidal winding, while the mathematical surface is its boundary. The distinction matters when computing a surface area versus a volume.
A solid of revolution is the three-dimensional region swept out by rotating a planar region about an axis in its plane. Perpendicular slices are disks or annuli, making volume, center-of-mass, and moment-of-inertia integrals one-dimensional.
A meridian has cylindrical radius and height . On a branch with monotone height and filled horizontal disk sections, the volume between nearby horizontal planes is , giving the formula. The conditions matter: a meridian that folds in height or bounds annular sections requires separate branches and inner-radius subtraction. A spherical angular wedge instead has volume when the solid fills each radial segment. Both describe volumes, but they partition the solid differently.
For a solid of revolution formed by rotating about the horizontal axis, with nonnegative continuous radius on , each perpendicular slice is a disk of area . Adding the slice volumes by a definite integral gives . If the rotated region instead has inner and outer radii , subtract the missing inner disks: . This is often called the washer method. A complete revolution is already included in the circular cross-sectional area, so no further factor of belongs in the volume integral.
Put for the profile parametrizationWith unit normal , the principal curvatures areConsequently and .
A parallel of a surface of revolution is the circle obtained by fixing the profile parameter and varying the rotation angle. Its radius is the distance from the rotation axis.
For the arc-length meridian metric , a unit-speed parallel has and . Its radial geodesic equation is satisfied exactly when . Thus extrema of the radius, and any other stationary radii, give geodesic circles. If every parallel is geodesic, the surface is a circular cylinder.
A meridian is the intersection of a surface of revolution with a plane containing the rotation axis. It is formed from a profile curve and its half-turn about the axis.
Suppose a smooth profile has , just to the right of , and . Use as a local parameter and write . The rotated surface is smooth at the pole if and only ifnear zero for a smooth function . It is then locally the smooth graph . Equivalently, the even reflection is smooth; in particular all odd derivatives of at zero vanish and the profile meets the rotation axis orthogonally. The analogous condition holds at the other endpoint.
A catenoid is the surface of revolution obtained by rotating a catenary about its directrix. One conformal parametrization is
An axisymmetric smooth connected soap film spanning equal radius- rings at heights has stationary profile , . The boundary equation is , . Its unique minimum occurs at , because the derivative numerator is . If is this root, the minimum is . There are no catenoids below that ratio, one at equality, and two above it. Existence of stationary connected films does not assert global minimality against pinching or disconnected competitors.
For the standard catenoid, the two principal curvatures are opposite, so its mean curvature vanishes. Its Gaussian curvature is , which also shows that no neighbourhood is locally isometric to a plane, cylinder, or regular part of a cone, all of which have zero Gaussian curvature.
For the catenoid profile spanning fixed-endpoint rings, the second variation of isThis refers to axisymmetric graph variations, not all possible changes in surface topology. Strict positivity for every nonzero admissible variation gives a strict local minimum in the topology: the positive lowest Dirichlet eigenvalue of the regular Sturm-Liouville problem gives coercivity, and sufficiently small coefficient perturbations preserve it. The zero variation must be excluded from a strict-positivity hypothesis.
A catenoid has zero mean curvature, but need not minimize area for its fixed boundary rings. For the profile on , take an endpoint-zero variation . The second variation of the rotational area isTo derive the integral, differentiate twice, then integrate its mixed term by parts; the endpoint term vanishes. To evaluate it, substitute , using the antiderivatives of and . The result is negative because and .
Small positive and negative perturbations remain positive and preserve the boundary values. The first variation vanishes, while the negative second variation gives nearby smaller areas. Thus being a minimal surface in the zero-mean-curvature sense is a stationarity condition, not a guarantee of area minimization for arbitrary boundary separations.
Forthe area density after integrating over is . If every height interval has area times its length, continuity forcesWhere , the sign of is constant and has derivative . Hence the profile lies on a circle of radius .
For the surfaces generated by and ,The diffeomorphism matches these curvatures, although comparison of the first fundamental forms shows that no local isometry exists.
For an arc-length profile with radius , the equation isThus gives locally, while gives wherever . At their mean curvatures are respectivelyso different choices of give locally noncongruent surfaces with the same constant Gaussian curvature.
For , rotate the unit-speed profilenear . Since , the resulting regular surface of revolution has . At its principal curvatures are and , so the point is not umbilical when and no neighbourhood of it lies on a sphere.
This is the circular generating-curve case of a Cylinder; the curvature formulas here refer to its lateral surface.
For , this parametric curve closes with a corner on a unit circular cylinder. Its speed is , so its arc length is . The cylindrical surface between the curve and has the same surface area, because unrolling gives the integral .
The curved surface of a circular cylinder, excluding any flat end caps. A parametrization of a radius- cylindrical surface is , with surface area element .
A circular cylinder of radius has induced metric locally equal to with . Its Riemann curvature tensor therefore vanishes, despite its nonzero extrinsic curvature. With outward unit normal and convention , its trace is and its principal curvatures are and zero. Its averaged mean curvature is . The angular identification changes global topology, not local flatness.
In coordinates on a circular cylinder of radius , the induced metric is . Its coefficients are constant, so the Christoffel symbols vanish and the affinely parametrized geodesic equation is . The nonconstant solutions are generators when , circular parallels when , and helices when both are nonzero. Unrolling the cylinder with coordinate makes all these curves straight lines in the Euclidean metric. Unit-speed parametrization additionally requires .
For a worked helix on a circular cylinder of radius , choose for . Unrolling gives the straight segment , so its arc length is . Its acceleration in space points normally to the surface, consistent with the geodesic equation.
This geodesic is not globally shortest between its endpoints: they share the same angular position, and the vertical generator has length . The helix minimizes length among paths with the same endpoints and one full winding, because their unrolled lifts join to . In general, geodesics minimize sufficiently short subarcs; changing winding can produce a shorter route. Keeping this local/global distinction makes unrolling useful without mistaking every straight lift for an unrestricted shortest path.
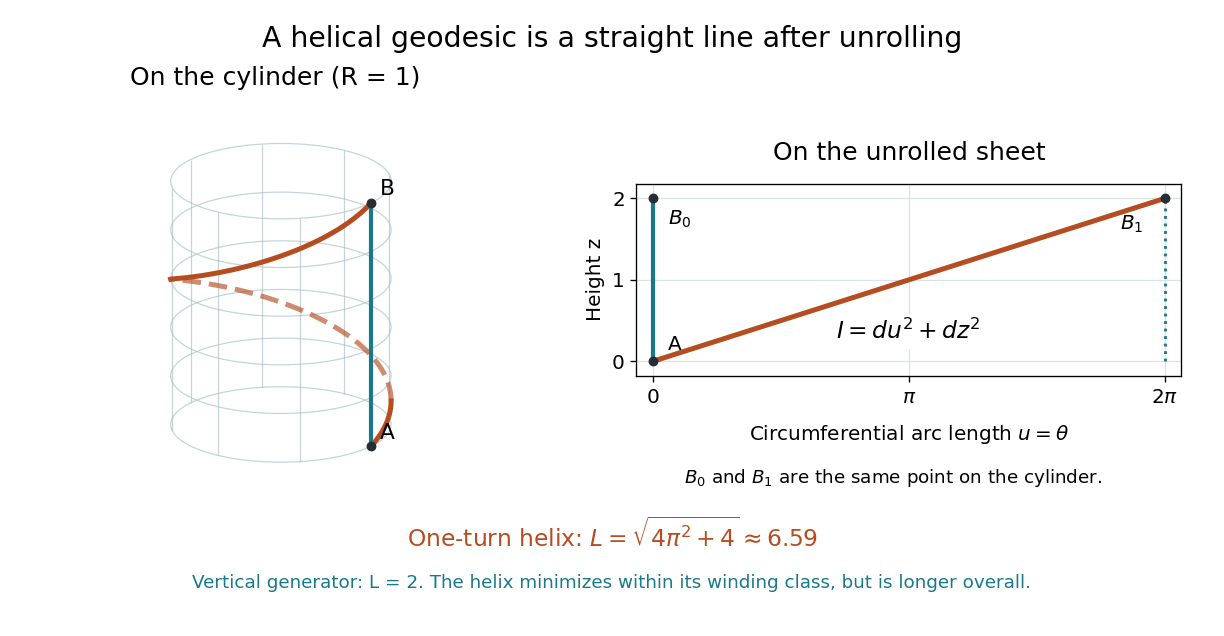

Unroll a circular cylinder of radius using the coordinate . Its line element becomes , so a geodesic lifts to a straight line in the plane. An endpoint has infinitely many lifts differing by . Minimize the ordinary Euclidean distance over those lifts to obtain the unrestricted shortest path. A fixed lift instead specifies a winding class and need not give the global shortest path.
For angular difference , put . Then . At , two different geodesics have the same shortest length. This is the source of the corner in the distance-versus-angle graph at the opposite generator of the circular cylinder.
For a geodesic in the metric , the cyclic coordinate givesEquivalently, the geodesic meets parallels according to Clairaut's relation.
For a sphere with metric , physical arc length gives . The cyclic coordinate proves conservation of , while unit-speed normalization givesThis azimuthal form requires . The solutions are great circles; meridians have and require another parameter.
Differentiating the spherical-geodesic first integral givesThe same equation follows from the affine geodesic equation after eliminating the arc-length derivatives. The squared first-derivative equation also fixes the normalization constant; a second-order solution must retain that first integral.
With polar angle and , the spherical-geodesic first integral gives and . The maximum absolute latitude is the different angle . At the great circle is the equator; at it is a meridian reaching both poles.
Let a compact smooth surface of revolution have exactly two poles, and let be the Clairaut first integral for a surface of revolution of a complete unit-speed geodesic. If , then , so the geodesic avoids open neighbourhoods of both poles. If , then is constant away from the poles and the geodesic lies in a meridian of a surface of revolution, whose complement contains a nonempty open set. Thus no complete geodesic has dense image.
Articles by others on the same topic
There are currently no matching articles.