Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article

A particle of type has independently a Poisson distribution of type- offspring with mean . Different particles reproduce independently. If is the probability generation is nonempty from one type- ancestor, then and , where . This iteration decreases to the survival probability of a branching process, the greatest nonnegative fixed point of . The expected type-count row vector in generation is .
For a finite group generated by , take the regular covering of a thrice-punctured sphere with monodromy and fill each lifted puncture by a disk. Locally the projection is , where is the order of its monodromy. The result is a closed oriented topological surface with an orientation-preserving group action. The nontrivial stabiliser subgroups are the conjugates of , and at the three types of ramification points. Counting lifted cells gives the displayed Euler characteristic. A subgroup acts freely exactly when it meets every conjugate of these three cyclic groups trivially. Its quotient is then a regular covering of degree equal to the subgroup order, and quotient Euler characteristic is divided by that order.
A positive elementary braid acts on the free group of punctured-disk meridians by the displayed substitution, fixing other generators. The inverse sends to and to . Applying Seifert-van Kampen theorem at the crossings and closing the braid gives the knot-complement presentation .
An axis-aligned bounding box is a Cartesian product of closed intervals aligned with a chosen Cartesian coordinate system:Only the two opposite corners and need to be stored. In two dimensions it is a rectangle. Changing the Cartesian coordinate system can change how tightly the axis-aligned bounding box fits the same object.[ref]
For a nonempty finite set of points , the smallest such axis-aligned bounding box hasThese minimum and maximum values also enclose the convex hull of : each coordinate of a convex combination lies between the smallest and largest input coordinates. In particular, three vertices of a polygon determine the axis-aligned bounding box of a filled triangle. For a general nonempty compact set, the same formulas use all its points; inspecting only an arbitrary finite sample is insufficient.
Given nonempty boxes and , the closed interval convention givesEquivalently, reject as soon as or in any coordinate. The surviving set intersection has endpoints and . This is an exact box test, while its conclusion about enclosed objects remains a conservative enclosure test.[ref]
3.7 Bounding Boxes. §3.7, Intersect() and Overlaps(): coordinate-wise intersection and inclusive comparisons
Equality counts as touching: and share an edge, so their set intersection is nonempty. Replacing every in the overlap formula by tests intersection of the interiors of full-dimensional boxes and excludes this contact. A zero-width closed interval can represent a point or a lower-dimensional enclosure, and must not automatically be discarded when touching counts. A box with some is empty; test emptiness before applying rules intended for nonempty boxes. The broad phase must retain touching candidates whenever the narrow phase counts touching as a hit.
For nonempty boxes, the smallest enclosing axis-aligned bounding box of their set union isThis operation supplies the parent boxes in a bounding volume hierarchy. It is an enclosure of the set union, rather than generally the set union itself. In floating-point arithmetic, comparisons are conclusive only for endpoints that still enclose the intended exact objects; use certified bounds such as interval arithmetic with outward rounding when that guarantee is required.
// Target: analysis.bigb
A bounding volume hierarchy is a data structure arranged as a rooted tree: leaves store objects, and each internal node stores a bounding volume enclosing its children in a rooted tree. Consequently, every node encloses all objects in its subtree. A common choice is a binary tree of axis-aligned bounding boxes. The objects assigned to sibling subtrees can be different even when their bounding volumes overlap.[ref]
Here is an exact two-dimensional example. Use the triangles from bounding volume, together with having vertices of a polygon and having vertices of a polygon . Group under , and under . Their parent axis-aligned bounding boxes and the box at the root of a tree areThe diagram shows all seven nodes. Taking the coordinate-wise minimum and maximum of the two child boxes constructs each parent box; the resulting box contains the set union of the children, and can also contain empty space between them.
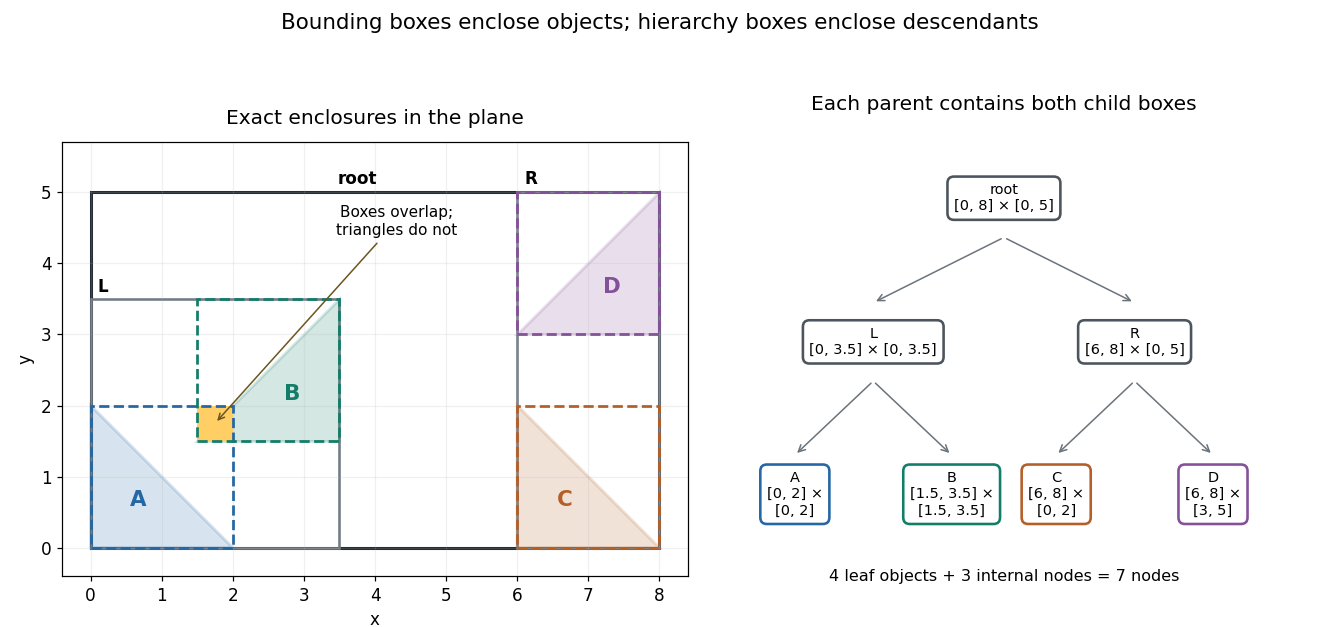
Four exact triangles, their enclosing boxes, and a seven-node bounding volume hierarchy arranged as a binary tree
. Details. A bounding volume hierarchy traversal starts at the root of a tree and discards a subtree when its bounding volume misses the query. Accepted internal nodes expose their children; accepted leaves supply candidates for actual shape tests. Box2D's official Collision: Dynamic Tree describes axis-aligned bounding box region queries that return overlapping leaf boxes. A query box that bounds a different query shape can produce additional false candidates.
For the closed query rectangleleft-first depth-first search tests the node boxes in order: root, , , , . The first four overlap ; does not, because its smallest -coordinate is . Pruning skips both and . Five box tests leave two broad phase candidates. The narrow phase rejects , since throughout , and accepts : the point belongs to both and . There are two detailed shape tests and one true hit.
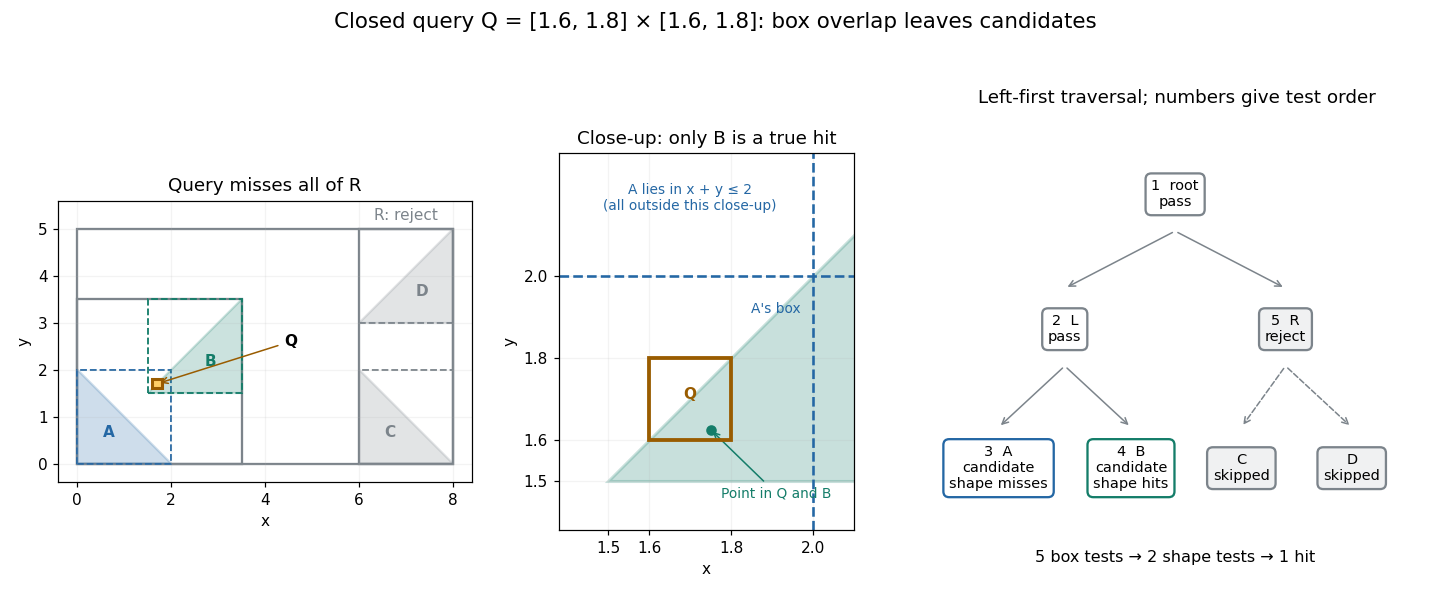
An exact rectangle query prunes the right subtree and leaves two box candidates but only one triangle hit
. Details. For a query asking for all intersections, time complexity depends on the number of visited nodes and the cost of each candidate shape test. With fixed dimension and constant bookkeeping cost per node, the work iswhere counts candidate objects and is Big O notation. A balanced binary tree has small height of a binary tree, but a query can enter both children at every level. In this example a query containing visits all seven nodes and tests all four triangles. More generally, a full binary tree with single-object leaves has nodes, so such a query takes work for constant-cost shape tests even when its height of a binary tree is . Listing hits itself requires outputs. Small height alone gives no unconditional logarithmic query bound.
For collision detection between two bounding volume hierarchies, traverse pairs of nodes: reject disjoint pairs of bounding volumes, expand a nonleaf member of an accepted pair, and apply the narrow phase at accepted leaf pairs. A single collection's self-query must exclude pairing an object with itself and avoid duplicate unordered pairs. If every object overlaps every other object, reporting all pairs already requires results. Construction quality, empty space in boxes and the queries determine how much pruning is useful.[ref]
For a short correctness outline, an object is enclosed by its leaf box, and each child box is enclosed by its parent box. Repeated subset relations carry this property to every ancestor. A true query intersection therefore prevents rejection at every ancestor of the object's leaf. Updating leaf boxes after motion also requires restoring all affected ancestor bounds before querying.
Collision detection determines whether geometric objects meet, under a specified convention for touching. A bounding volume test can reject a pair before a more detailed shape test.
A conservative enclosure test may retain disjoint objects as candidates, but must never reject a true set intersection. Increasing an enclosure can add candidates while preserving this implication.
For every fixed and , the sum is at most one. Pointwise convergence preserves this inequality. Taking the independent suprema over the pair and the point proves the assertion. Taking each bound separately would only give the weaker estimate two.
On a separable metric space, a sequence uniformly bounded in bounded Lipschitz norm has a pointwise convergent subsequence. Enumerate a countable dense subset and use the Bolzano-Weierstrass theorem and diagonal subsequence argument to obtain convergence there. Uniform control of the Lipschitz constant then makes the subsequence Cauchy at every point. The pointwise closure of the bounded Lipschitz unit ball preserves the original norm bound after rescaling.
For a finite real scalar matrix and unit vectors in a real Hilbert space, , with a universal constant. One valid bound is . Expand using odd tensor powers with coefficient magnitudes summing to , then apply the Gaussian sign identity . Taking converts the expectation back to the original inner product. Complex scalars admit a universal bound twice this real bound by separating real and imaginary parts.
An exact, or distinguished, triangle is one isomorphic to . For a degreewise short exact sequence , the map taking to the image of is a quasi-isomorphism: its kernel is the contractible cone of the identity on . Consequently the short exact sequence defines such a triangle.
The displayed oblique derivative boundary condition prescribes the derivative in a direction combining the outward normal and a tangent. It is oblique at a boundary point when the normal coefficient is nonzero. Uniform obliqueness additionally requires on the relevant boundary; pointwise nonvanishing alone does not supply that bound on an unbounded boundary.
If , the equation is tangential instead. Both derivative traces must be tracked when constructing a global relation. At corners, compatibility of the prescribed directions and data is a separate condition; at infinity, a growth or decay requirement completes the boundary value problem.
For a sufficiently regular function on a domain , its boundary trace is the restriction to , using the limit from within the domain when necessary. In a half-line evolution problem, the traces are boundary values of the spatial derivatives. An initial value does not generally determine every such trace without the partial differential equation and suitable boundary conditions. The Sobolev trace operator extends classical restriction continuously to appropriate Sobolev spaces, where pointwise values need not be defined.
A boundary value problem with prescribed outward normal derivative, or the associated weighted flux, on the boundary. Its boundary data are Neumann boundary data. For an elliptic divergence-form operator without a zeroth-order term, integration over the domain imposes a compatibility condition between total source and boundary flux. A connected domain generally leaves a constant undetermined, fixed by a mean or reference value.
A force-driven rigid particle with surface has a leading translating sphere in Stokes flow with . Expanding the no-slip boundary condition gives the first-order surface velocity , where . The first-order resultant force and torque vanish when the applied load is fixed. The Lorentz reciprocal theorem for Stokes flow, using the uniform surface traction in translating-sphere Stokes flow, therefore gives . For with symmetric traceless , the isotropic fourth moment gives . A rotating-sphere test similarly gives , which vanishes for an inversion-symmetric deformation.
For a nonrotating uniform-stratification fluid under the Boussinesq approximation driven at by a localized vertical-wall velocity, positive vertical wavenumbers radiate down and right and negative ones up and right. The real velocity separates into functions of and . Its in-phase component is half the imposed boundary profile on each beam; the quadrature component is its Hilbert transform partner. Thus compact localization at maximum boundary speed does not imply compact localization of all components at every phase. A finite-duration source contains several frequencies and spreads energy over their different ray angles and group speeds.
For a plane internal gravity wave in uniform buoyancy frequency, substitute into the displacement equation. The leading order gives ; the next order gives the displayed transport equation with . A boundary amplitude radiates as , choosing the sign of so the group velocity points into the fluid. The wavelength-averaged energy is and its vertical flux is times that energy. A causal ramp therefore creates a translating front, not an instantaneous monochromatic field throughout the half-space.
A periodic boundary condition identifies opposite ends of a domain by requiring the solution and the derivatives needed by the equation to agree there.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:




All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact