Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Continuous path
Connected space Created 2026-09-24 Updated 2026-10-13
A topological space is connected when it has no separation of a topological space: no partition of a set into two nonempty open subsets satisfyingHere the union covers all of , and the intersection is the empty set, so no point belongs to both pieces. For a subset of a larger topological space, "open" means open in the subspace topology: each piece is the intersection of with an ambient open set. Both pieces must be open; merely dividing a drawing into two colours does not establish a separation of a topological space. [ref]
https://math.mit.edu/~hrm/palestine/munkres-topology.pdf. Munkres, Topology: A First Course, section 3-1, definition on p. 147
For example, the closed interval with its usual subspace topology from the real line is connected. The proposed split fails: the second subset is not open in , since every neighbourhood of in contains points less than . More generally, a connected subset of the real line is precisely a real interval. In contrast, for the unionthe open intervals and exhibit as nonempty open subsets in the subspace topology of . Their intersection is empty and their union is , so is not connected. Although are closed intervals in the real line, they are also open within .
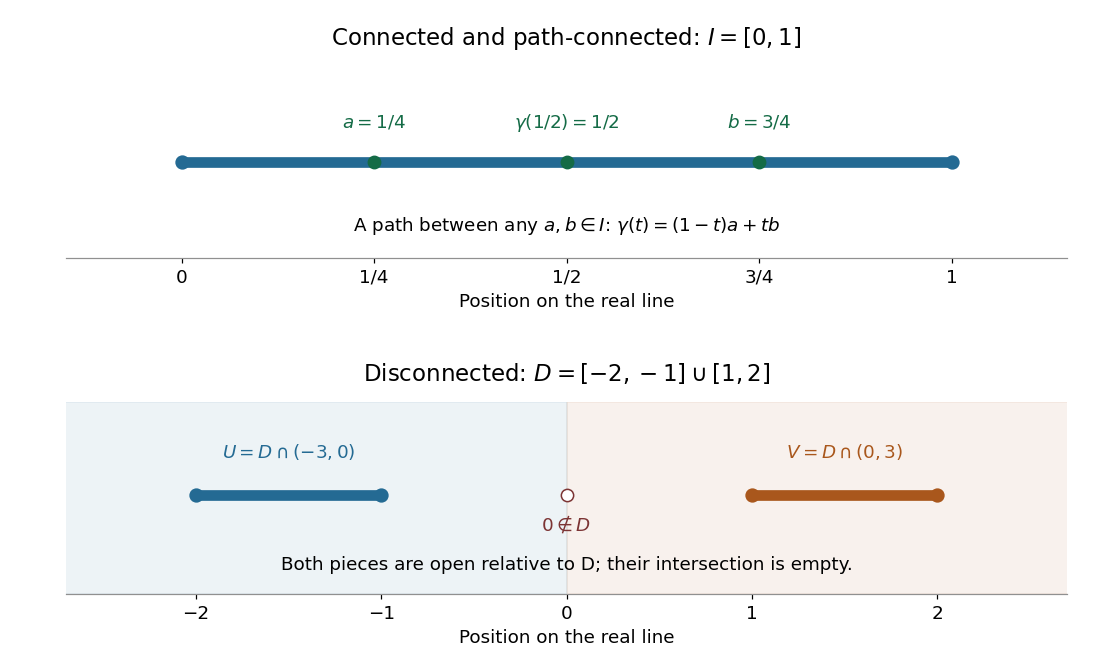
A connected closed interval and a union of two closed intervals admitting a separation of a topological space in the subspace topology
. Details. 
Why is connectedness useful? A continuous image of a connected space is connected: a proposed separation of a topological space in the image would pull back through the continuous map to a forbidden separation of a topological space in its source. Thus a continuous map from a real interval to the real line cannot skip values between two attained values. This is the intermediate value theorem. For a computed example, the continuous function on has image ; the value occurs at . Connectedness guarantees an input attaining that value even when we have no formula for it.
Path connectedness is a stronger condition: it supplies a continuous path between every pair of points. The topologist's sine curve below shows that a connected space need not be a path-connected space.
Connected subset of the real line Created 2026-09-29 Updated 2026-10-14
In the usual subspace topology from the real line, a subset is connected exactly when it has the defining property of a real interval:Every real number between two members must be present. Thus open intervals, closed intervals, intervals with only one endpoint included, and unbounded real intervals are connected. Singleton sets are connected too. With the no-separation of a topological space convention used here, the empty set satisfies the same property; some texts reserve the word connected for nonempty topological spaces.[ref]
General Topology by Tom Leinster. p. 68, and Proposition C2.6, p. 73: the nonempty convention and the interval characterization
Removing an interior point changes the answer:These two real intervals are exactly its connected components and its path components. Removing an endpoint instead leaves a real interval, for example , which stays connected. This is why an interior point of a closed interval is a cut point, whereas an endpoint is not. A nonempty finite set of points in the real line is connected exactly when it is a singleton set.
Proof outline: if but is missing, the subsetsgive a separation of a topological space, since the two open intervals make both pieces open in . Conversely, a nonempty real interval contains the continuous path between any two of its points, so it is path-connected and hence connected. Together with continuous image of a connected space, this characterization gives the intermediate value theorem: a continuous function on a real interval cannot jump over a value lying between two attained values.
Continuous image of a path-connected space 2026-10-31
If is continuous and is path-connected, then is path-connected. Choose preimages of any two image points and a continuous path between them in . Its composition with supplies the required path inside . The conclusion uses the subspace topology on the image, not an assumption that maps onto the whole codomain.
Edge path 2026-10-25
An edge path in a simplicial complex is a finite sequence of vertices of a simplicial complex such that is a simplex for each consecutive pair. Repeated consecutive vertices are allowed. Its geometric realization is a continuous path formed by traversing the corresponding line segments, with constant pieces for repetitions.
A connected geometric realization has an edge path between any two vertices. For a fixed vertex, the reachable vertices form a union of whole simplexes: all vertices of a simplex are pairwise joined by edges. The reachable and unreachable geometric parts therefore intersect each simplex in either the whole simplex or the empty set. Both parts are closed in the realization topology and are complements, so both are open. Connectedness forces the unreachable part to be empty. Conversely, edge paths between vertices and straight segments inside simplexes join arbitrary points, so the realization is path-connected.
Geodesic metric space Created 2026-09-28 Updated 2026-10-05
A metric space in which every two points are joined by a metric geodesic segment. Equivalently, they admit a continuous path whose metric path length equals their distance. In this general setting no Riemannian metric or covariant derivative is required.
Locally rectifiable path Created 2026-10-05 Updated 2026-10-06
A continuous path with finite arc length on every compact parameter interval. Families of such paths are used in the measurable-density definition of extremal length.
Metric path length Created 2026-10-05 Updated 2026-10-06
For a continuous path in a metric space, take the supremum over finite partitions of . This definition allows and needs no derivative. A metric geodesic parametrized on has length . In a Riemannian manifold, it agrees with the usual arc length integral for a smooth curve.
Monodromy theorem Created 2026-09-24 Updated 2026-10-14
The monodromy theorem says that, when analytic continuation exists throughout a domain, its ambiguity depends on homotopy. Let be a domain, , and a germ of a holomorphic function at . Assume admits analytic continuation along every continuous path in starting at . Two such paths ending at give the same terminal germ of a holomorphic function if they are homotopic with endpoints fixed in . [ref]
Here a homotopy with endpoints fixed is a continuous map satisfyingEvery intermediate path must stay in . Equality means agreement on a neighbourhood of , rather than merely equal values at . [ref]
The identity theorem provides local rigidity; the monodromy theorem shows precisely how topology controls the remaining global freedom. Deforming a route without crossing a forbidden point cannot change the resulting germ of a holomorphic function. Thus a complicated analytic continuation calculation can be replaced by one on a simpler homotopic route. Distinct homotopy classes can still give the same continuation: a rational function on its domain already gives a single-valued answer along every route, even around a pole.
Past exam of the mathematics course of the University of Cambridge 2015 ii Paper 3 2I Solution Created 2026-09-24 Updated 2026-10-06
Let be the closure of the polynomials in for the uniform norm. It is a closed algebra, since products of uniformly convergent sequences converge uniformly on the compact set .
Choose a point with . The uniformly convergent geometric seriesshows that this reciprocal belongs to . Join to by a continuous path in . Its image is compact and disjoint from , so their distance is positive. Partition the path into finitely many steps shorter than .
Suppose and , with on the path. Thenconverges uniformly on , since . Every partial sum belongs to , by its algebra property, and so does the limit. Working backwards along the partition transfers the pole from to . Thus : a polynomial exists withThis pole-moving polynomial approximation is the elementary mechanism behind the polynomial Runge theorem.
Past exam of the mathematics course of the University of Cambridge 2018 iii Paper 201 4 a Solution Created 2026-10-03 Updated 2026-10-05
A standard one-dimensional Brownian motion is a real-valued stochastic process satisfying almost surely, having continuous paths almost surely, and having independent increments withHere is the normal distribution with zero expected value and variance . Thus the increments are also stationary increments.
If Brownian motion is defined relative to a specified filtration , additionally require that it is an adapted process and that is independent of . For its natural filtration, this follows from independent increments. These are the defining properties of standard Brownian motion.
Past exam of the mathematics course of the University of Cambridge 2018 iii Paper 201 4 d Solution Created 2026-10-03 Updated 2026-10-05
Fix an integer and consider the independent incrementsFor fixed these are independent and identically distributed random variables with the normal distribution , so . The second Borel-Cantelli lemma gives for infinitely many , almost surely. Intersecting these probability-one events over the countably many preserves probability one.
On any path in this intersection, uniform continuity on would give some such that whenever . Choosing with contradicts the existence of an increment . Therefore Brownian paths are not uniformly continuous on the half-line:The event is measurable: for continuous paths, uniform continuity can be tested by countably many pairs of nonnegative rational numbers and tolerances . Brownian motion has uniform continuity on every compact time interval, but almost surely fails it on the whole half-line.
Past exam of the mathematics course of the University of Cambridge 2019 ib Paper 1 12G c Solution Created 2026-09-24 Updated 2026-09-29
If were a continuous path, then would be a continuous map from the connected interval to a discrete space, so it would be constant. This holds for every , and therefore itself must be constant. Since contains distinct points, no path joins every pair. Henceindeed, every path component is a singleton.
Past exam of the mathematics course of the University of Cambridge 2022 ib Paper 2 10G Solution Created 2026-09-23 Updated 2026-09-25
The implicit function theorem states that if and the partial derivative is an invertible linear map, then near the zero set of is uniquely the graph of a continuously differentiable function.
If is a differentiable bijection with differentiable inverse , the chain rule applied to and givesThus is an isomorphism with inverse .
If a continuously differentiable map has invertible derivative everywhere, the inverse function theorem makes it a local diffeomorphism. In particular it is an open map, so its image is open. Its image need not be closed: has nonzero derivative everywhere and image .
For the given map of elementary symmetric polynomials,and direct evaluation of the determinant givesHence the critical set isIts complement is the Zariski-open set on which the three coordinates are pairwise distinct. Each point has one of the six possible strict coordinate orderings, and each ordering defines a nonempty convex open region. A continuous path cannot change an ordering without crossing . Therefore has exactlyconnected components.
A space is path-connected if for every pair it contains a continuous path with and . For any choose preimages . A path between those preimages maps to , a continuous path from to staying in . Thus a continuous image of a path-connected space is path-connected. Surjectivity onto the ambient codomain is not needed; the conclusion concerns .
The answers, in the order completeness, sequential compactness, connectedness, and path connectedness, areDefine and for . The estimate proves continuity at zero by the squeeze theorem; elsewhere it follows from the usual continuous functions. Thus is the graph of a function on the closed set .
To check closedness directly, if in the Euclidean plane, then and continuity gives . Therefore is a closed subset of the complete metric space , hence is a complete metric space. The sequence has no convergent subsequence, since its first Cartesian coordinates tends to infinity, so sequential compactness fails.
For any two points , the mapis a continuous path in joining them. Thus is path-connected, and consequently connected. The factor is crucial: the oscillations shrink to the single point .
The answers areWrite . The given metric describes locally uniform convergence: if and only if for every fixed . Indeed,so convergence in forces . Conversely, split the defining series at : its tail is at most , and its finitely many initial terms tend to zero.
If is a Cauchy sequence in , the same single-term estimate makes it a Cauchy sequence in the supremum norm on every . The completeness of the continuous-map space in the uniform metric gives a continuous function on with uniformly there. Uniqueness of the limit of a sequence gives , so these functions define a single continuous function on . The preceding finite-head and tail argument proves . Thus the space is complete.
The constant functions have whenever . They have no convergent subsequence, so the space is not sequentially compact.
For fixed , set . On ,as . The equivalence with locally uniform convergence proves that is a continuous path for . Hence the space is path-connected and connected.
The product topology on has the open rectangles , with open in and open in , as a topological basis. The projection preimages are and , so both projections are continuous.
If is continuous, both coordinate compositions are continuous. Conversely, if both are continuous, thenis open for every basic rectangle, proving continuity of . Given paths between two chosen endpoints in each factor, their coordinatewise pair is therefore a continuous path in the product, proving that a product of path-connected spaces is path-connected.
For the compact-neighborhood assertion, fix . For each , choose an open rectangle containing inside . Compactness of chooses finitely many covering . PutThen , , and : any point of belongs to one of those rectangles' second factors, while lies in every first factor.
Compactness of now selects finitely many covering . SetThese are open, contain and , and if , choose an with and use . HenceIf or is empty, take the corresponding open factor empty and the other factor the whole space; the assertions then hold directly. No Hausdorff assumption on the factors is needed.
The sphere is path-connected. For which are not an antipodal pair, a continuous path isThe denominator never vanishes: a zero would make and antipodal. If , choose a unit vector perpendicular to and concatenate the paths from to and from to of the same form. Thus is connected. The quotient map is continuous and surjective, so the continuous image of a connected space theorem proves that is connected. In fact composing the paths above with also proves path connectedness.
Removing from the closed interval leaves the separation of a topological spaceThus is a cut point of .
In contrast, removing any point from the square leaves a path-connected space. To prove this, take distinct . Choose an interior point outside the two lines through and . Such a choice exists: a small circle in the interior meets each of those lines in at most two points. Since is a convex set, the line segments and stay in ; our choice of ensures that both avoid . Their concatenation is a continuous path from to in .
The product topology on agrees with its usual subspace topology in the Euclidean plane. If were a homeomorphism, its restriction would give a homeomorphismThe domain is connected, since path connectedness implies connectedness, while the target is not connected. This contradicts the preservation of connectedness by a homeomorphism.
Path component Created 2026-09-24 Updated 2026-10-14
A path component of a topological space is a nonempty subset maximal among its path-connected subsets. The path component through can be described asEvery point along such a continuous path also belongs to : the initial part of the path reaches that point. Thus the paths witnessing membership stay inside . This makes path components useful for deciding which allowed positions can be reached from one another by continuous motion.
Every path component lies inside one connected component, because every path-connected space is connected. Thus each connected component is a union of path components. In a locally path-connected space the two classifications agree, by connected locally path-connected spaces are path-connected. For a subset of the real line with its usual subspace topology, the classifications also agree: every connected component is a real interval, and interpolation supplies a continuous path within it.
The topologist's sine curve shows why the distinction matters in general. Use specifically the closed versionwith the subspace topology from the usual Euclidean plane. It has one connected component, , but two path components, and . The graph of a function is a continuous image of a connected space, and its closure is , so closure of a connected set gives connectedness. Each of is path-connected, but a continuous path crossing from into would force its second coordinate to oscillate between and arbitrarily near its departure time, contradicting continuity; the topologist's sine curve article gives the short argument. Also is not closed in , so path components need not be closed, unlike connected components.[ref]
General Topology by Tom Leinster. p. 78, and the discussion after Lemma C4.12, p. 84: the sine-curve obstruction and nonclosed path components; here the positive graph is restricted to
Being joined by a continuous path is an equivalence relation. Proof outline: the constant path joins a point to itself; reverses a path; and a path from to followed by one from to gives a path from to . For the last construction, run each path on half of ; their values agree at , so the pasting lemma for closed subspaces gives continuity. The equivalence classes are path-connected, are maximal, and form a partition of a set of into path components.[ref]