Source release: Oxford examination archive release thread, Part C bundle pages 430–433. The cover cross-lists Mathematics and Mathematics and Statistics, both at Part C, Wednesday 8 June 2011, 2.30pm–4.00pm.
Answer availability checked on 28 October 2026: bounded official Oxford searches by exact year, course, module and formal code found no exact-paper answers advertised. The official contemporary Part C course document confirms the course identity; it does not advertise answers to this paper. No later-year answer-release policy was assumed to cover 2011.
The deformation gradient is the derivative of the deformation map with respect to the reference configuration coordinates, at fixed time:Its determinant is the local ratio of current to reference volume: for an orientation-preserving deformation in continuum mechanics. Thus elastic incompressibility is the pointwise constraint , rather than a requirement that each individual principal stretch be one.
Choose the outward unit normal to the boundary of the chosen current material subbody. The traction is the contact force exerted on that subbody per unit current area at the boundary point. Reversing the subbody side reverses and .
By Cauchy's stress theorem, the dependence on is linear. With the usual column-vector convention the Cauchy stress tensor satisfiesThe same point has different traction vectors on differently oriented planes, but a single Cauchy stress tensor encodes all of them. In the absence of body couples, conservation of angular momentum makes symmetric.
In the current configuration, balance of linear momentum is the Cauchy momentum equationHere is the Cauchy stress tensor, is current mass density, is body force per unit mass, and is the velocity of the material particle currently at . The expression in parentheses is the material acceleration. The divergence is taken in current spatial coordinates, with .
Equivalently the right side is evaluated at the particle, because this is the same material acceleration in Lagrangian coordinates. For the subsequent static inflation with negligible body force, the equation reduces to .
Write for the reference outer radius and for the current outer radius. The inner material normal is . A fluid pressure applies traction there, so the radial Cauchy stress tensor component must be negative:The second condition uses zero external gauge pressure. Both faces also have zero shear traction; the axisymmetric diagonal stress field satisfies those conditions automatically. The axial constraint is plane strain, so supports may supply an axial reaction; it does not imply zero axial stress.
For the axisymmetric deformation map, take , , and . A reference cylindrical shell of unit axial length has volume , and the corresponding current shell has volume . Elastic incompressibility therefore gives .
Integrating from the inner surface, where , gives . The positive radius is consequentlyThe outer surface is not an additional independent unknown: , and hence .
Use orthonormal cylindrical bases in the reference configuration and current configuration. The deformation gradient maps a radial increment to , an azimuthal arc to , and an axial increment to itself. ThereforeDifferentiating the radius relation gives . Its three principal stretches areTheir product is one, as required by elastic incompressibility. The symbols called “strains” in the source are these stretch ratios; engineering strain would instead subtract one. The axial stretch is one because this is plane strain.
The multiplier enforcing elastic incompressibility contributes an arbitrary hydrostatic stress. Denote it by to distinguish it from the applied pressure . For the neo-Hookean solid, the Cauchy stress tensor is . Thus its principal components areThe axial component is , despite the unit axial stretch. The quantity is a Lagrange multiplier determined together with equilibrium and the traction conditions; it is not obtained by differentiating the reduced stretch energy while ignoring its constraint.
The radial equilibrium equation gives . Set , so that . Substitution of the neo-Hookean solid stress difference eliminates both and :This is a first-order ordinary differential equation for the radial stress, parametrized by the unknown inner radius. For inflation , its right side is positive, so increases from the negative inner pressure to zero at the outer surface. The denominator stays positive because .
Integrate the radial equilibrium equation across the thickness, retaining the integral rather than evaluating its antiderivative. The traction conditions give . Hence must satisfyAll endpoints and coefficients here depend only on and the specified material and reference geometry. This is the required implicit pressure–radius relation for inflation and extension of an incompressible tube with unit axial stretch. In particular gives zero integrand and . Once an admissible root is selected, the radial stress follows by integrating from the outer face, , and the remaining stress components follow from the constitutive equation.
Substituting the sinusoidal plane wave into the Navier-Cauchy equation gives , , and because . Equality of the amplitudes is thereforeThis is an eigenvalue problem for the acoustic tensor . Choosing a nonzero amplitude parallel to gives ; choosing any nonzero amplitude perpendicular to gives . For positive mass density and stable Lamé parameters, both squared speeds are positive. These choices construct nonzero solutions explicitly, proving existence.
Resolve each amplitude by the orthogonal projectionsThe acoustic tensor acts by on the longitudinal line and by on its perpendicular plane. ThusThe longitudinal component is a longitudinal wave, while the two independent transverse polarizations are transverse waves. Each projection obeys its own wave equation, and superposition adds the corresponding solutions.
A general planar disturbance is therefore a sum of the two types. For a single sinusoid with a common speed, both projections cannot be nonzero unless the two speeds coincide: projecting the eigenvalue equation gives and . This distinguishes superposition of waves with different speeds from a mixed polarization traveling rigidly at one speed.
Divide the Navier-Cauchy equation by mass density. Since and , it becomesEquivalently, using the vector calculus identity ,The divergence and curl consequently propagate at and , respectively.
Use the complex amplitude and take its real part at the end; the equations are linear with real coefficients. Let , , and . The differential operators on this exponential function are , , and . Substitution givesThe determinant factors asConsequently choose the positive decay rootsThe Rayleigh wave decay exponents must both give strict decay into the half-space. A genuine nonzero Rayleigh wave combines both, as the free-surface equations below also show. Thus requires . In a stable ordinary isotropic solid , so it is slower even than the transverse wave. The roots depend on the candidate speed as well as the material constants and wavenumber; the speed is fixed by the boundary condition.
For the root the elastic wave polarization is parallel to the complex derivative vector , givingFor the root the field has zero divergence, , givingThese relations also follow by inserting each decay root into either row of the matrix. The complete decaying displacement field has complex componentsmultiplied by , followed by the real part. The first constituent is irrotational and the second is divergence-free; both are needed to cancel the two surface tractions.
The material occupies , so its outward unit normal at the surface is . A free surface has zero traction, . ThereforeThe third condition is automatic for the two-dimensional displacement field with zero third component and no dependence on the third coordinate. The first two impose zero shear and normal stress at the free surface.
Write the in-plane displacement field as . The infinitesimal strain tensor gives , , and . The two nontrivial zero-traction conditions becomeEquivalently for the complex amplitudes they are and . Because the constitutive equation is real and linear, vanishing of these complex amplitudes enforces the conditions at every position and time.
Substituting both profiles into the shear traction condition givesFor the normal traction, use and . Removing the common nonzero factors yields the second equation. ThusA nonzero displacement field requires the determinant to vanish:Let and . Cancelling gives the Rayleigh secular equationSquaring and excluding the zero root gives ; any candidate must still satisfy the unsquared equation and the decay inequalities. For stable isotropic elasticity , this cubic has one root in : its values at zero and one have opposite signs, and its strictly negative second derivative on this interval prevents a second crossing back to a positive final value. Both sides of the unsquared equation are positive there, so this root is valid.
The root of the squared equation is not a propagating surface wave: at , the two roots coincide, and the null combination in this representation produces zero displacement field. As a numerical example, gives and . The surface-wave speed is independent of in this homogeneous half-space model.
Let be arc length, so inextensibility makes a unit tangent vector. The curvature is , hence for uniform bending stiffness. Balance of linear momentum in static equilibrium gives a constant resultant .
Taking the cross product directly,The scalar component of conservation of angular momentum therefore becomesTogether with and , this Euler elastica equation determines the centerline once the appropriate boundary conditions are supplied.
Put . With , the Euler elastica equation is . Linearization about the straight configuration gives . Under the boundary conditions explicitly stated, , a nonzero solution requiresThus with only the stated boundary conditions, the first critical compressive force is . The corresponding linear transverse displacement field, with , isand to first order. These are the successive small-amplitude buckling modes. The nonlinear branches retain the simple pendulum equation; if the angular amplitude is and , fitting half-periods into the rod gives , which tends to as . Here is the complete elliptic integral of the first kind, with its modulus, not its squared parameter.
Endpoint position compatibility for the Euler elastica adds a condition when fully fixed clamps have equal transverse height. If the word “clamped” also imposes , then . With , this retains only even , yieldingThe same exclusion is exact on the nonlinear branches: integrating the elastica equation gives , and an odd number of half-periods reverses the nonzero endpoint slope. Hence odd changes the endpoint height. The conventional fixed-clamp first Euler buckling load is the second boxed value, whereas the source's explicitly listed boundary conditions alone give the first. Additional clamped modes with a nonzero transverse reaction require releasing the imposed . Load-controlled buckling also permits axial shortening; an exactly inextensible rod whose endpoint separation is fixed equal to its full length has no room to buckle.
Set . The Euler elastica equation becomes . Multiplying by gives the first integralStraight asymptotic ends require and a horizontal tangent, so . This is the separatrix of a simple pendulum with its angle shifted by . A nonconstant solution moves from to , with the same physical tangent at both ends, taking infinite arc length to approach either limit. One explicit representative isUsing and and integrating gives the tensile elastica loopThis solution is nontrivial, tends to horizontal straight tails, and has finite excess bending energy. It is also necessarily self-intersecting. Indeed is even and is odd. For , let . Near zero , while , so there is a root . At the two distinct parameters , both points have and the same . Numerically .
Any nonconstant smooth solution with the same straight asymptotic conditions has this first integral. Between consecutive horizontal orientations, separating variables gives the displayed solution up to translation, reflection, and reversal. It cannot pass through a straight equilibrium at a finite parameter, by uniqueness of the ordinary differential equation. Thus all such nontrivial branches have the same loop crossing. This is an ideal zero-thickness rod solution; a physical rod with self-contact excluded cannot realize the crossing without adding contact forces.
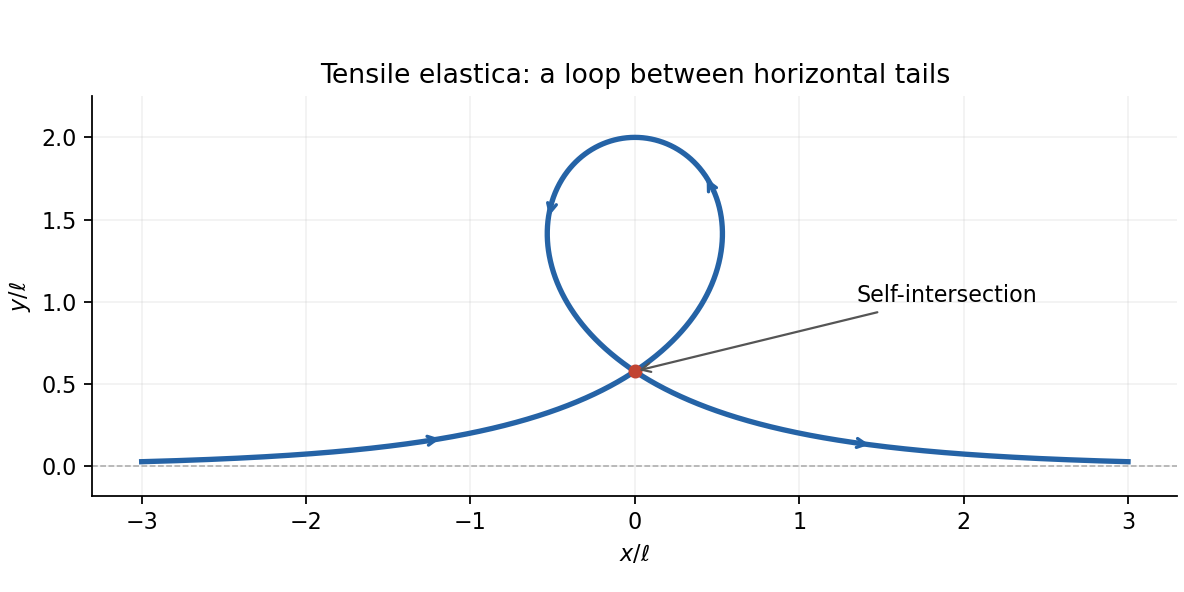
The tensile elastica loop and its self-intersection
. Details. 
Take the clamp at with . An end force without an applied end moment gives the free-end condition . With , the Euler elastica equation is . For , is small, so the leading equation isIntegrating with the two boundary conditions givesTo first order, and . HenceEquivalently at leading order, the familiar cantilever response. Because , the deflection is downward. The free-end displacement field and slope are and . The remainder notation holds with fixed positive and nondimensional unit rod length.
Articles by others on the same topic
There are currently no matching articles.