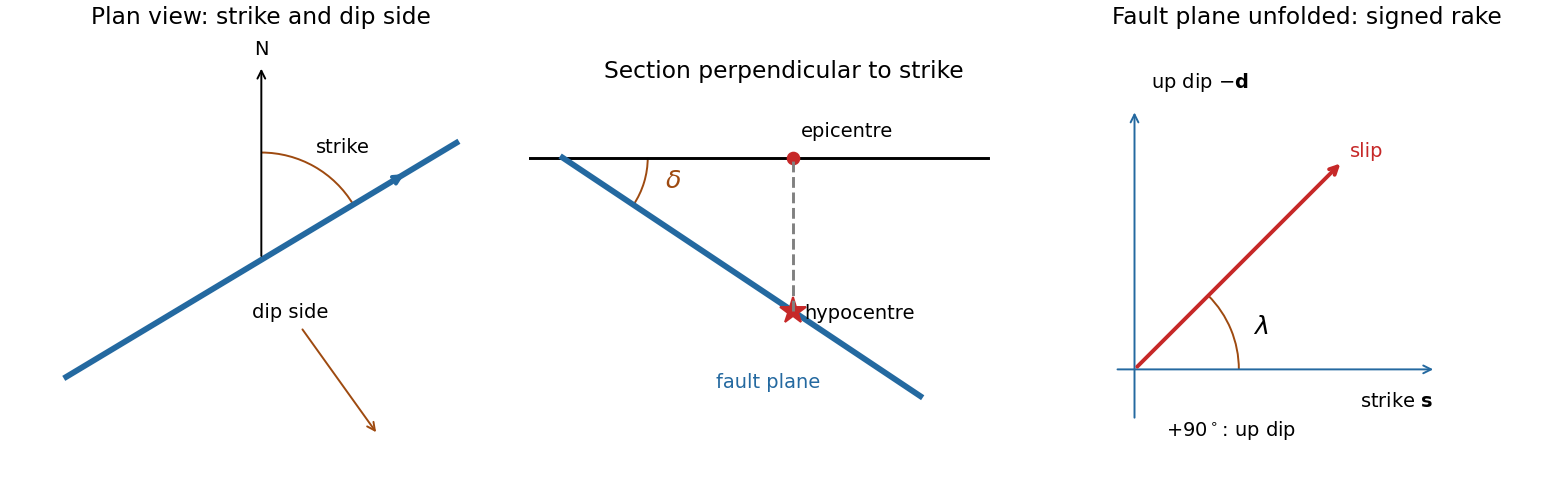
A fault plane represents the surface across which the two sides of a fault slip. A real fault need not be perfectly planar; these angles can describe a local planar segment. Its fault strike is the azimuth, measured clockwise from north, of its horizontal intersection. The line itself has a ambiguity; choose the direction for which the fault dips to the right. Its fault dip, , is the angle below horizontal measured perpendicular to that fault strike, from for horizontal to for vertical.
The fault rake, , is the angle of the relative slip vector within the fault plane. State the sign convention: if is the chosen strike direction and points down dip, useThus is slip along , is up-dip slip and is down-dip slip. This distinguishes the direction in which the fault is tilted from the direction in which it actually moves.
The hypocentre is the point where rupture begins within the Earth. The epicentre is the point on the surface directly above it. The hypocentre need not coincide with the centroid of the final rupture. Orientation uses strike and dip; motion additionally needs rake; epicentre and hypocentre locate the rupture's start.[ref]
Earthquake Hazards Program Glossary by United States Geological Survey. Entries “fault plane”, “strike”, “dip”, “hypocenter” and “epicenter”
Assume a stable, lossless elastic body with the usual symmetry of the elasticity tensor and boundary conditions that eliminate the surface terms in integration by parts, such as a traction-free outer surface. Its elastic stiffness operator is then self-adjoint. When density varies spatially, the precise eigenproblem is generalized:Here abbreviates the pair of mode labels. Equivalently, is a self-adjoint operator in the mass inner product. Stability makes real and nonnegative. Modes at different eigenvalues are orthogonal, and an orthonormal basis can be selected within each degenerate eigenspace. Completeness permits expansion of a suitable displacement field in these mass-weighted elastic normal modes.
Insert the expansion and project onto . Mass normalization diagonalizes both the acceleration term and the restoring term. For a symmetric stress glut tensor supported away from the boundary,The symmetry of the stress glut tensor removes the antisymmetric part of the displacement gradient, leaving the strain. The result is one independent forced oscillator per mode, with the stated excitation integral. If the modes instead have mass norm , that integral is divided by . A source touching the boundary requires the corresponding surface forcing to be retained rather than silently dropping it.
Rigid translations and rotations can be zero-frequency modes of a free body. Their strain vanishes, so an internal symmetric seismic moment tensor does not excite them through this coupling. Attenuation, radiative boundaries or other non-self-adjoint effects require modifications of the simple conservative expansion.
For a mode of positive frequency, differentiation of the causal convolution givesThe first boundary term vanishes because ; the second supplies because . Both initial values vanish. This verifies the forced-oscillator equation and its initial conditions, including a step source in the piecewise or distributional sense.
The spatial Dirac delta function reduces the excitation toFor an event at , put . Integrating the oscillator kernel from to gives the normal-mode response to a step seismic moment:Non-unit mass normalization introduces the same factor as above. Complex modes must be combined with their conjugate partners to produce a real displacement. The formal limit is ; for rigid-body modes here, because their strain is zero.
The step produces a static component plus continuing oscillations in this lossless model. It does not predict physical damping. A point source is appropriate when rupture dimensions are small compared with the wavelengths being analysed and rupture duration is short compared with their periods. Long-period observations of a relatively small earthquake can meet these conditions; high-frequency finite-fault directivity generally cannot. A finite source-time function replaces the ideal instantaneous step when its duration matters.
For seismic source inversion, collect calibrated, consistently filtered samples from all available stations and components into a data vector . For each trial source position and origin time, compute the corresponding elastodynamic Green tensor in an Earth model, including the instrument response used for the data. Write the symmetric seismic moment tensor in six independent symmetric basis tensors:Each column of is the synthetic seismogram for one basis tensor. An off-diagonal basis tensor contains both symmetric entries, so the double contraction and its factors of two remain consistent.
A suitable objective iswith noise covariance ; a justified penalty can be added for regularization. At fixed , solve for the six entries of by weighted least squares, preferably using a QR decomposition or singular value decomposition rather than explicitly inverting the matrix of the normal equations. Then search over the four nonlinear parameters using a coarse location/time grid followed by local refinement. This variable projection reduces a ten-parameter search to a four-parameter nonlinear search with an inner six-parameter linear fit. Merely having more than ten data samples does not ensure identifiability: the design matrix must have adequate rank and the network must resolve the source's radiation patterns.
Potential errors include inaccurate velocity, density, anisotropy and attenuation in the assumed Earth model; neglected finite rupture and source-time effects; timing, instrument calibration or component-orientation errors; correlated noise; uneven station coverage; and tradeoffs between depth, origin time and the moment tensor. Imposing a double-couple seismic source mechanism without evidence can hide genuine non-double-couple components. Regularization also changes the recovered source and should be reported.
Inspect residuals, singular values, recovery of synthetic sources and uncertainty under resampling or noise perturbations. Linearized covariance or a posterior distribution can quantify uncertainty within the assumed forward model, but does not automatically account for errors in that model. A good waveform fit alone is insufficient evidence that all ten parameters are uniquely recovered.
Take upward deflection as positive, use , and write . A positive added load depresses the plate, so is negative beneath it. Because bending moves the original surface while the load adds thickness, the final topography is . For the cosine mode the horizontal biharmonic operator multiplies by , givingEliminate to obtainThe original loading equation contains , whereas the relation after eliminating the added thickness contains . These must not be interchanged prematurely.
At first order in the relief, represent a displaced density interface by a sinusoidal mass sheet. A sheet of surface-density amplitude at depth produces a downward gravity amplitude at the datum. This follows by solving the Fourier-transformed gravitational Poisson equation above and below the sheet: the decaying potential has amplitude , with the normal derivative jump fixed by the sheet mass.
The top interface contributes ; the displaced crust–mantle interface contributes at depth . ThusThe second term is negative beneath a positive load: depression replaces denser mantle material by lighter crust. Substituting the deflection-to-topography ratio yieldsThis flexural gravity admittance combines mechanical compensation and attenuation of the buried interface's gravitational signal. It assumes small relief, a flat uniform thin plate, uniform density layers and the stated surface loading, without additional internal density anomalies. Here is the depth of the crust–mantle interface. It is not automatically the effective elastic thickness ; the latter enters through .
Define and . ThenAt long wavelength, the mass deficit at the lower interface nearly cancels the surface excess, and the gravity field does not resolve their vertical separation. For ,The first mechanical contribution is fourth order in , although the exponential also contributes terms at second and third order. If the ideal interface depth were zero, the leading term would instead be .
At short wavelength, bending resists the interface's deflection, and any remaining buried signal is attenuated. ConsequentlyThis is the uncompensated surface-sheet value. For nonnegative the approach is from below. With ,The scales and respectively mark gravitational depth filtering and flexural resistance; which appears first depends on . Admittance has dimensions of inverse time squared. The formal limit describes this model, not an assertion that thin-plate theory remains accurate at arbitrarily short wavelength.
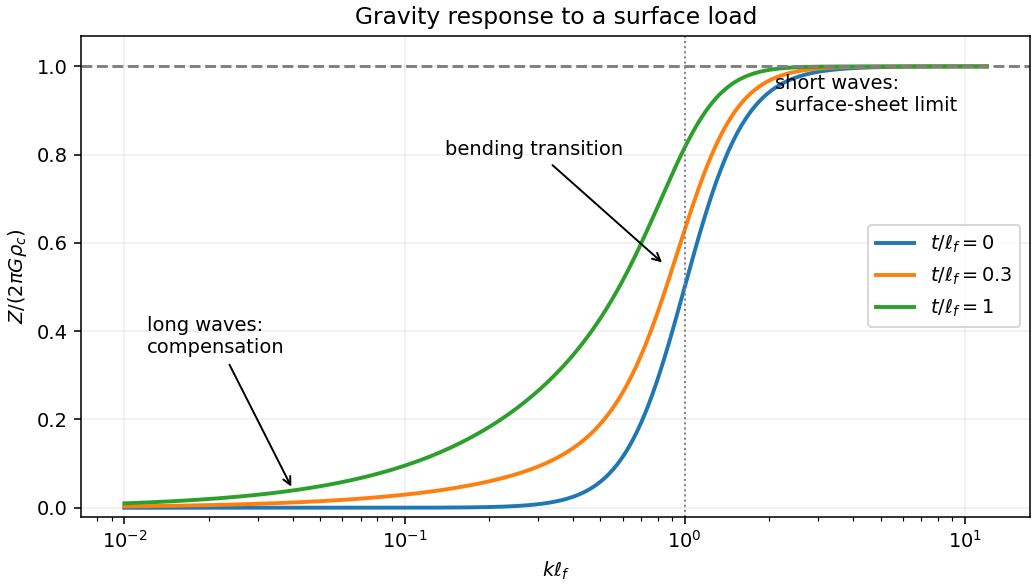
Compensated long wavelengths, flexural transition and the uncompensated gravity limit
. Details. New oceanic lithosphere is hot and mechanically weak. As it cools, the depth over which rock can sustain elastic stress on the loading timescale generally increases, so effective elastic thickness tends to increase with plate age at the time of loading. It is this mechanical state when the load is emplaced, together with subsequent relaxation, that matters; the present age alone is insufficient for an ancient load.
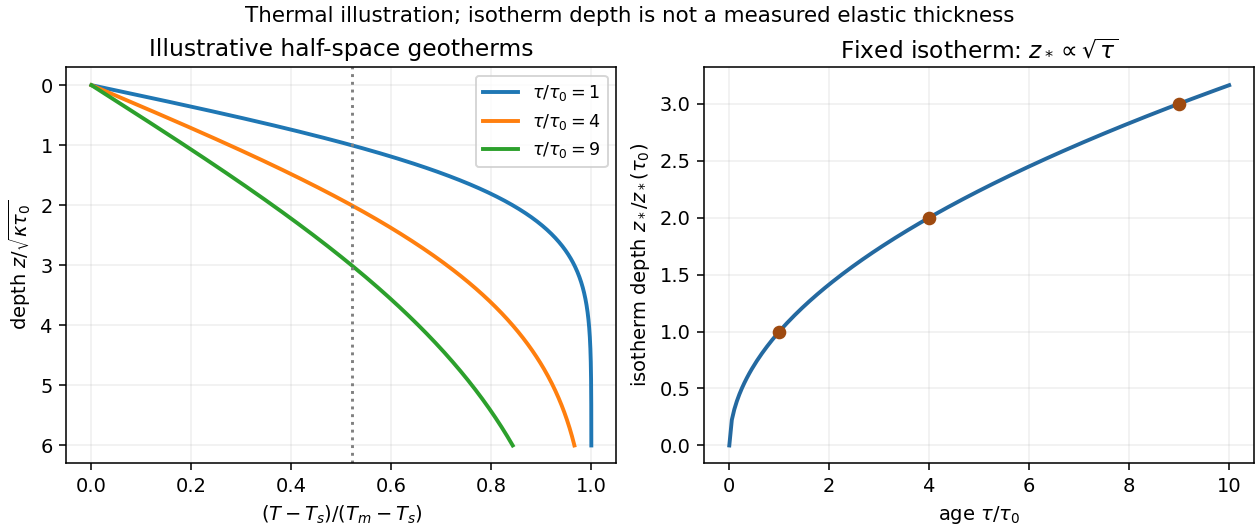
The half-space cooling model illustrates the thermal dependence. With age , surface temperature , initial interior temperature and constant thermal diffusivity ,A chosen temperature lies atIf the base of the mechanically strong layer approximately follows such an isotherm, initially follows a similar age trend. Cooling models constrained by ocean-floor depth and heat flow provide the thermal motivation; their fitted thermal thickness must not be mistaken for measured elastic thickness.[ref]
An analysis of the variation of ocean floor bathymetry and heat flow with age by Barry Parsons and John G. Sclater. 1977, pages 803–806 and discussion of half-space versus finite-plate cooling
In practice is an effective bending thickness rather than the depth of one universal temperature. Stress-dependent yielding, grain size, water content, composition, loading duration and reheating can alter it. Finite-plate cooling and basal heat input also limit indefinite square-root growth at old ages. Nor should be identified with either the thickness of the crust or the full seismically defined lithosphere.
Use the supplied surface temperature, , as the premise. With otherwise comparable material and geothermal gradient, this hotter boundary increases thermally activated material creep at shallow depth and places a chosen mechanical cutoff temperature closer to the surface. That effect alone would favour a thinner elastic layer than in a cool terrestrial oceanic plate.
Water weakening of rocks makes dryness act in the opposite direction. Water can enhance material creep; sufficiently dry material can remain strong at temperatures at which its wet equivalent relaxes. Experiments on dry diabase provide a concrete basis for a strong dry crust and possible mechanical coupling between crust and mantle, rather than requiring a weak crustal layer solely because the surface is hot.[ref]
High-temperature deformation of dry diabase, with application to crustal deformation on Venus by S. J. Mackwell and others. 1996, printed pages 793–794, dry strength and implications for crustal coupling
For an illustrative steady conductive geotherm with thermal conductivity and heat flux , a fixed strength cutoff givesTherefore the comparison would scale aswhere all temperatures are compared consistently and a dry rheology may have a higher effective cutoff . This is a conditional strength-layer estimate, not a universal definition of .
Venus can retain appreciable elastic thickness despite its hot surface; temperature favours thinning, while dryness favours strengthening. The supplied facts alone determine neither a numerical nor a definite ordering relative to Earth's oceanic plates. The comparison requires heat flow, subsurface thermal history, material rheology, interior water content and loading timescale. Little atmospheric water is evidence relevant to the hypothesis of dry rocks, not a direct measurement of deep water activity.
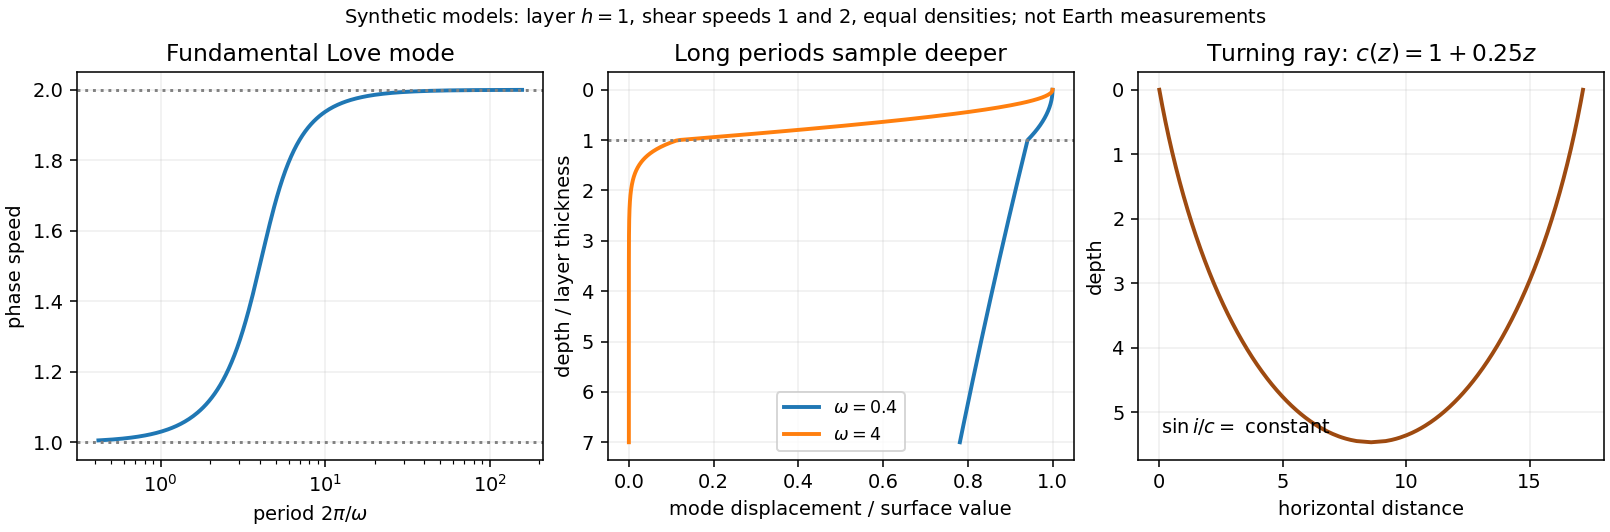
Seismic surface-wave dispersion. Rayleigh waves combine vertical and longitudinal motion in the vertical plane of propagation; Love waves have horizontal transverse motion and can be guided by a low-shear-speed surface layer. A homogeneous elastic half-space supports a Rayleigh wave with a frequency-independent speed in the ideal elastic limit, but depth-dependent Earth structure makes the surface-wave eigenfunctions and their propagation speeds depend on frequency. This structural dispersion can occur even when each constituent material is itself nondispersive.
Distinguish phase velocity from group velocity , which controls a narrow-band envelope in the appropriate weakly attenuating limit. Longer periods generally have deeper sensitivity, while shorter periods emphasize shallower structure. In a profile whose shear speed increases with depth this often makes long-period waves faster, but low-velocity zones, anisotropy and higher modes can change that trend. Frequency dependence need not be monotonic in every Earth model.
Measure phase delays or wave-packet arrival times across known source–receiver paths for many periods, accounting for source phase, cycle ambiguity, multipathing and mode identification. Compute predicted dispersion from trial elastic profiles and compare with observations. Linearization expresses the sensitivity schematically aswhere are compressional and shear speeds. A regularized inverse problem then estimates depth structure; many crossing paths additionally provide surface-wave tomography. Joint Love wave and Rayleigh wave measurements help distinguish shear-wave polarizations and constrain radial seismic anisotropy. Finite bandwidth, depth averaging and correlated sensitivities mean that one dispersion curve does not uniquely determine a detailed Earth profile.
Seismic ray theory, the eikonal equation and Fermat's principle. In a smoothly varying isotropic medium, insert a high-frequency ansatz into the scalar wave equation. The leading powers of frequency giveThe travel-time surfaces are wavefronts and rays are their normal trajectories, with slowness vector . The next-order equation transports amplitude, including geometrical spreading; attenuation is an additional material effect.
Fermat's principle says that the ray makes stationary under path variations with fixed endpoints. Stationarity, rather than always the global minimum, permits multiple arrivals. Its Euler–Lagrange equation, with arclength and unit tangent , isFor horizontal layering, the horizontal slowness is conserved, giving Snell's law at interfaces and smooth refraction between them. Here is measured from vertical. A turning point satisfies ; increasing speed with depth bends a downgoing ray back upwards. Travel-time tomography uses these ray integrals to infer spatial slowness variations.
The approximation requires wavelength to be small compared with structural variation scales. Caustics, turning-point amplitudes, diffraction, scattering and finite-frequency sensitivity require wave-based corrections. Thus seismic ray theory gives an economical geometric description and useful travel times, while surface-wave dispersion retains essential interference and boundary-mode physics.


Homologous temperature and deformation. Homologous temperature is , with both temperatures in kelvin and the appropriate pressure- and composition-dependent melting temperature. It measures proximity to melting more meaningfully than an absolute temperature alone. Pressure, composition and water can alter both and the flow law, so equal does not imply identical rheology.
A useful thermally activated material creep law iswith stress , grain size , activation energy and activation volume . Water activity can add another factor. Increasing temperature raises the rate at fixed stress when the activation enthalpy is positive, greatly lowering effective viscosity. Solid material can therefore flow on geological timescales well below melting.
Diffusion creep is approximately linear in stress: bulk-diffusion Nabarro-Herring creep has grain-size scaling , while grain-boundary Coble creep has in their ideal regimes. Dislocation creep usually has a stress exponent greater than one and weaker grain-size dependence. Its effective viscosity scales as at fixed temperature, so stronger forcing changes the apparent viscosity. At lower homologous temperature, brittle/frictional deformation or high-stress dislocation mechanisms can become important. The dominant process also depends on pressure and confinement; low temperature is not by itself a guarantee of brittle failure deep in a planet.
A deformation mechanism map compares the competing rates or strengths as functions of stress and homologous temperature at specified grain size, pressure and composition. Fine grains favour diffusion creep; larger stress favours nonlinear dislocation creep. There is no universal temperature dividing all these regimes. This sensitivity helps explain a strong outer lithosphere above a slowly flowing solid mantle and why modest thermal or water variations can reorganize deformation.
Determining the actual planform of mantle convection. The task is to infer the geometry of upwellings, downwellings and connecting flow in the present Earth, rather than to draw a preferred laboratory convection cell. Plate velocities and the distribution of subduction zones directly constrain surface motion and likely cold downwellings. Ridges, volcanism and hotspots provide further clues, but a ridge need not mark the centre of a deep plume, nor is every hotspot uniquely explained by one plume geometry.
Seismic tomography supplies three-dimensional velocity structure from body-wave travel times, waveforms and surface-wave dispersion. Fast slab-like structures can often be traced beneath subduction zones into the lower mantle. The 1997 global P-wave study reported long narrow lower-mantle structures connected with convergence and interpreted some slab segments as reaching the deepest mantle; that is evidence for deep circulation, not proof that every slab follows one route.[ref]
Evidence for deep mantle circulation from global tomography by R. D. van der Hilst and others. Nature 386, pages 578–584; abstract on lower-mantle structures and mantle-wide flow
Temperature affects seismic speed, but composition, phase changes, water and anisotropy also matter, so velocity is not itself a flow map.Gravity and the geoid constrain the spatially integrated density field and its induced boundary deformation. Dynamic topography supplies information about vertical stresses, after separating crustal structure, isostatic loads and thermal subsidence. Seismic anisotropy can constrain deformation and fabric orientations, subject to a mineral-physics relation between fabric and flow. Discontinuity topography and the mantle's heat budget provide further tests. Each observation has a different sensitivity to density, temperature and viscosity, making their combination more useful than any one image.
Compare these observations with three-dimensional geodynamic models that solve creeping-flow force balance, mass conservation and thermal transport, including buoyancy from temperature and composition, realistic plate motions, viscosity structure and phase boundaries. Predict seismic observables, gravity, geoid and dynamic topography from the same model, and assess data coverage and resolution before interpreting a feature. Whole-mantle exchange, impeded or deflected slabs near transition zones, and broad deep anomalies can coexist; the evidence does not require identical stacked or single-layer cells everywhere. The actual planform is constrained by joint seismic, gravitational, surface-kinematic and thermal evidence, with substantial nonuniqueness in its detailed flow and history.
Articles by others on the same topic
There are currently no matching articles.