Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 72 4 a Solution by  Codex 0 Created 2026-10-03 Updated 2026-10-07
Use historical changes up to 2012 rather than the present-day Arctic state, and separate extent, actual ice-covered area, thickness and age composition. They do not have interchangeable rates.
For summer horizontal coverage, September minimum extent fell from roughly million square kilometres around 1980 to million in 2012: about half the earlier extent. The fitted September monthly-mean trend through 2012 was about , or per decade relative to the 1979–2000 mean. Extent includes the whole area of grid cells above the specified ice-concentration threshold; actual covered area additionally weights fractional cover. A separate concentration-weighted September ice-area analysis for 1979–2012 gives a decline of roughly per decade, or ; this retrospective historical-period estimate is reported in an observational-area comparison. It should not be confused with the extent trend, even though these two absolute slopes are similar. These figures and definitions are documented in the 2012 Arctic sea-ice observations.
For thickness, the submarine and satellite record in the declassified submarine-data region, covering about of the Arctic Ocean, gives a winter mean of in 1980 versus in 2008: a reduction, averaging about . It is a regional winter comparison, not a basin-wide summer measurement. The same combined analysis reported recent 2003–2008 declines around in winter and in summer. The summer record is shorter and cannot justify extrapolating one constant summer-thickness slope back to 1980. See the original thickness analysis.
For composition, repeated summer loss and export depleted the thick multi-year sea ice reservoir and increased the relative importance of young and first-year sea ice. A directly comparable age indicator is the March fraction aged at least four years: about in 1988, in 2005 and only in 2012. This winter age measure records the loss of ice that had survived earlier summers; it is not the fraction of surviving September ice that is first-year ice. The youngest ice disproportionately melts in summer, so the age mix of survivors differs from that of the preceding winter cover. Overall, summer cover became smaller, thinner and supported by a much depleted reservoir of older ice.
Several mechanisms can accelerate Arctic sea ice decline. The ice-albedo feedback increases solar absorption as dark water replaces bright ice. Additional ocean heat content delays autumn freeze-up, leaving less time for winter growth. Thinner ice needs less latent heat to disappear, and fractured mobile ice is more easily exported or redistributed by wind stress and currents. Melt ponds lower surface albedo; increased open-water fetch permits waves that break the ice further. Persistent atmospheric warming and warmer incoming water act on this weakened cover.
However, strict irreversibility is not implied by these positive feedbacks. Winter open water loses heat, and thin ice grows rapidly because its conductive resistance is low. As a concrete counterexample to an unavoidable one-way transition, a 2011 coupled-model experiment imposed an ice-free summer and found recovery of ice extent typically within two years. This establishes a physically consistent recovery mechanism, not a guarantee that every real loss reverses on that timescale.
Under continued warming, rebuilding the former multi-year sea ice cover is unlikely; loss of one summer's cover is nevertheless not intrinsically irreversible. Sustained greenhouse gas forcing changes the climatic state towards which ice recovers, and rebuilding several age classes takes multiple summers of survival. The qualified conclusion is persistence or worsening under the continuing forcing, not a proved thermodynamic prohibition of recovery at fixed or reduced forcing.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 72 3 d Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07The independent, spatially homogeneous random-placement idealization gives a Poisson process of intersections along the sampling line. With line intensity , an interval of length contains no ridge with probability . The spacing thus has exponential distributionRandom orientation changes the intersection intensity, which has already been represented by the measured . Merely saying that positions are random does not prove a Poisson process: independence and homogeneity are additional assumptions. Finite segments, clustering or excluded widths can invalidate them.
For a shifted lognormal distribution, write with . Applying the change of variables formula, , givesThe threshold is a minimum observable separation. Finite keel widths impose geometric exclusion, and the sonar's footprint and ridge-identification criterion can suppress a shallow peak near a deeper peak. This sonar ridge shadowing or resolution effect means that need not be a universal physical distance between every pair of ridges; it can partly reflect how the profiles were processed.
A lognormal distribution is compatible with products of many positive factors: taking logarithms turns multiplicative changes into sums, which can approach a normal distribution. Repeated deformation, breakup, convergence and merging across scales are plausible contributors. The observed form therefore suggests correlated or multistage ridging rather than the simplest independent-intersection model. It does not identify a unique ridging mechanism. For example, directly generating with a normal distribution for produces the same spacing law without specifying any particular mechanics. Distributional agreement must be supplemented by dynamical and spatial evidence.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 72 3 c Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07Use the exponential ridge-draft model along the direction of motion relative to the seabed. During time , the stationary point samples track length . Peaks deeper than the seabed have line densityThe candidate seabed gouging by ice encounter rate is thereforeFor the usual case , replace by . For , every counted ridge is deep enough and .
The units are inverse time. This is the number of potentially scouring keel passages per unit time, not sediment volume removed per unit time. The latter also requires keel width, sediment properties and an erosion law. The expression assumes the ridge statistics remain applicable during drift and grounding does not arrest or reshape the deep keels before they reach the point. If speed fluctuates, use mean relative speed under independence from ridge occurrence, not the magnitude of a vector-mean drift that might cancel reversing motion.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 72 3 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07Let denote a ridge's peak sea-ice draft, reserving for the draft at a randomly sampled position. In the exponential ridge-draft model, normalization by the line density givesThe mean peak sea-ice draft isConsequentlywith , having dimensions inverse length and inverse length squared. The normalized peak probability density function is a shifted exponential distribution.
For the triangular argument, interpret the common ridge shape as geometrically similar triangles with common along-track slope and variable peak height. Literal congruence would require identical sizes and could not coexist with an exponential peak-draft distribution. Each side of a triangle has . A ridge reaching draft therefore contributes of horizontal track in the interval . Summing this occupation length over all qualifying peaks proves the triangular ridge occupation identity:ThusThis is a tail relation for sampled draft occupation, not an instruction to normalize and identically. Below , the ideal triangles contribute rather than the same exponential; level ice and gaps contribute their own draft distributions. If triangular keels are referenced to a level-ice base, the vertical coordinate must be shifted consistently. We also require nonoverlapping occupation: arbitrary choices of , mean draft and slope can otherwise demand more than the available track length.
Observed mean keel slopes are typically of order –, with broad individual variation rather than a single universal angle. Orientation matters: if a track crosses a straight ridge at angle to the crest, . The track slope can therefore approach zero at a grazing crossing. A sonar morphology study found location-dependent mean slopes about – after correcting for ridge orientation.
Young sea-ice pressure ridges often have recognizably triangular sections with angular, porous rubble and comparatively continuous crests. Melting, refreezing and repeated cracking modify older ridges: their blocks can become rounded and consolidated, and their keel or crest can fragment into separated hummocks rather than retain one triangular shape. A pre-exam multibeam study found first-year sea ice ridge slopes averaging roughly , while multi-year sea ice ridges often consisted of irregular separated smooth blocks. Multi-year sections can be broader or locally shallower, but age alone does not determine one slope angle. The constant-slope triangle is a useful statistical idealization, not a faithful shape for every old ridge.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 72 3 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07A sea-ice pressure ridge forms where horizontal convergence compresses sea ice. The initially thinner sheet or colliding ice floes fracture and ride over or under one another. Continued convergence piles broken blocks into an emergent sail and a submerged keel. The submerged volume is normally larger because buoyancy supports the pile. Pores and brine-filled gaps initially make the rubble unlike a solid intact sheet; refreezing can consolidate it.
A sea-ice shear ridge develops along a fracture where neighbouring ice moves tangentially in opposite directions or at different speeds. Rough edges interlock, crush and locally converge, producing chains of piled blocks along the shear boundary. Thus the large-scale strain is mainly shear, but the actual production of ridge rubble involves local compression. Pure sliding of perfectly smooth parallel surfaces need not create a ridge. Pressure ridging is driven by convergence; shear ridging is driven by relative tangential motion with local crushing and convergence.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 72 2 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Take positive in the off-ice wind direction, from the compact pack towards the open sea. The wind initially separates the outer ice floes, creating irregular polynyas. A larger opening gives more open-water fetch, so stronger short wind waves develop before reaching its downwind edge. Their reflection supplies a positive force on the downwind ice floes; these catch their neighbours and compact into an ice-edge band. Incoming longer swell exerts force in the opposite direction. The short waves can exert substantial force despite their smaller amplitude because a small ice floe reflects them much more effectively than it reflects the long swell.
The surface-gravity-wave energy of the short waves grows with fetch in the windward polynya, then decays rapidly across the band. Swell enters from the seaward side and usually attenuates more slowly. This gives inward forcing from the two sides: short-wave forcing is largest at the windward face and swell forcing is largest at the seaward face. In the next open polynya, short wind waves regrow from the weak transmitted component. Reflected waves also enhance energy locally on the incident side, with interference that is omitted from a smooth, phase-averaged sketch.
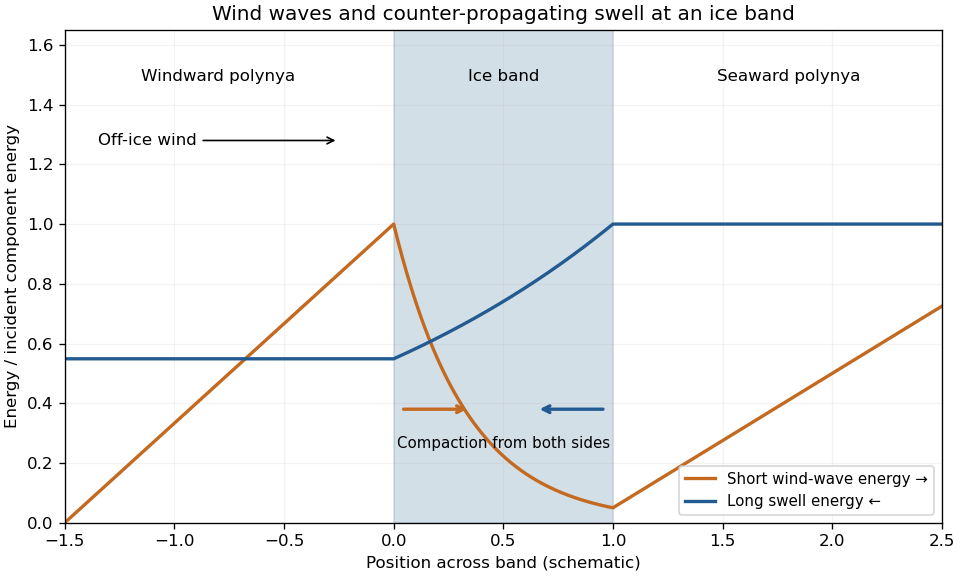
Each plotted component is normalized by its own incident energy; the curves do not assert equal absolute wind-wave and swell energies. The band is partially transmitting. For a perfectly opaque reflector, the transmitted component would instead vanish.
The initial bands have unequal floe inventories, widths and forcing. Differential drift and collisions merge some into composite bands. Larger bands tend to shield smaller downstream accumulations from the short-wave forcing needed to keep them separate, while sufficiently wide intervening polynyas can generate fresh wind waves and maintain separation. Finite available ice, available wave fetch, the opposing swell, wind strength and duration, floe size and thickness, and subsequent mergers limit the number of persistent bands. The wave-force formula alone does not select a universal count. This mechanism and its merger interpretation are supported by the original ice-band study.
There is a normalization issue in the requested stress calculation. Let be standard linear surface-gravity-wave energy for crest amplitude . The deep-water wave radiation stress is . Hence standard momentum balance givesFor lossless reflection with amplitude reflection coefficient , and , so .
In the usual independent-floe, weak-reflection approximation, there are about effective layers per unit distance. Each removes a fraction of the forward energy, givingThis yields the intended wave-driven ice-band compaction:The attenuation approximation retains the leading term in ; an independent discrete-layer model instead gives an energy coefficient . Neither coefficient follows from the single-object force formula without this additional scattering closure.
For ordinary crest amplitudes, the force printed in the paper is . With that printed normalization and the same attenuation law, its derivative is four times the requested stress. More generally, if , the printed lossless force gives . Recovering the stated stress from it requires instead, a different unspecified attenuation convention. The supplied force and stress cannot both be derived from standard amplitudes and the usual floe-layer attenuation law. Restoring the factor in the force gives a consistent intended model.
Using the printed force for the numerical question, perfect reflection gives , , and thereforeUsing the requested stress formula for partial reflection givesFor comparison, the consistently normalized perfect-reflection force is , and the printed force with standard attenuation would give for the partial-reflection derivative. The approximate stress is a force per horizontal area, not a direct measure of the three-dimensional ice-skeleton stress.
The inward force gradient helps maintain a coherent, close-packed band, especially near the incident-wave faces. It is modest enough that wind, current, swell changes or mergers can disrupt the arrangement; it does not guarantee permanent mechanical stability. Perfect reflection estimates a bounding force, whereas the much smaller partial-reflection stress varies as . No mechanical-strength law is supplied, so stability can be assessed only qualitatively.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 72 2 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07It is important to distinguish loss of forward-going surface-gravity-wave energy from conversion of mechanical energy into heat. Scattering attenuation by ice floes redirects energy; it can attenuate a coherent transmitted wave without dissipating the total energy.
For fixed floe geometry, increasing frequency usually increases attenuation over the relevant swell range: shorter wavelengths respond more strongly to the contrast between water and the elastic plate, and to repeated floe edges. Long surface gravity waves have weak curvature and often penetrate much farther. This is a trend over a specified frequency range, not a theorem excluding resonances.
The diameter dependence is governed by . An ice floe much smaller than the wavelength moves nearly with the water and scatters weakly. Scattering becomes appreciable when floe size is comparable with the wavelength, and interference between its two edges can give maxima and minima. At fixed ice concentration, larger ice floes also mean fewer edges per unit propagation distance, roughly proportional to . Consequently the attenuation coefficient need not increase monotonically with diameter: the single-floe reflection and the number of encounters must both be considered. Thickness increases areal inertia as and bending stiffness as , generally increasing wave mismatch and reflection, although detailed frequency-dependent resonances again prevent a universal monotonic law.
When , particularly for frazil ice and pancake ice, weak individual scattering leaves other processes dominant. Relative crystal and water motion causes viscous dissipation; an aggregate layer can behave as a viscous or viscoelastic material, and pancake ice collisions, rubbing and overwash remove energy. Their importance depends on concentration and wave amplitude.
For a uniform continuous sheet with horizontal dimensions much greater than the wavelength, there are no repeated floe edges in its interior. A perfectly elastic sheet over inviscid water supports undamped flexural-gravity waves, so internal scattering is not an explanation of decay there. Real attenuation can instead arise from internal ice anelasticity or viscoelasticity, a dissipative sub-ice viscous boundary layer, turbulence, cracks and brine-related processes. Small-floe mixtures and continuous sheets require dissipation models beyond the isolated-floe scattering picture.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 72 1 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Write for the vertical displacement of the sea ice, and take the undisturbed water surface as , with water occupying . The elastic plate has areal mass and bending stiffnessHere is Young's modulus and is Poisson's ratio. We neglect in-plane prestress, viscosity and plate shear deformation, and linearize about hydrostatic equilibrium. These are important assumptions: perfect elasticity alone does not specify every term in a floating-plate model.
For a plane wave , , potential flow in deep water has velocity potential . This solves Laplace's equation and decays downwards. The kinematic boundary condition gives . Linearizing the water pressure at the displaced interface gives an upward excess loadThe elastic plate equation is . Substitution and multiplication by therefore give the flexural-gravity wave dispersion relationEquivalently, with and ,This determines the positive wavenumber implicitly for prescribed positive angular frequency. It is unambiguous: the derivative of is , while runs from zero to infinity.
The phase velocity and group velocity areFor open-water deep-water gravity waves, , and hence and . At large period the ice-covered curves approach these straight lines. At shorter period, plate bending raises the speeds, so both ice-covered curves turn upward as period decreases. In the bending regime with negligible plate inertia, and ; in the formal plate-inertia-dominated limit, and . The latter extrapolation eventually leaves thin-plate validity and should not be read as a prediction at arbitrarily small wavelength.
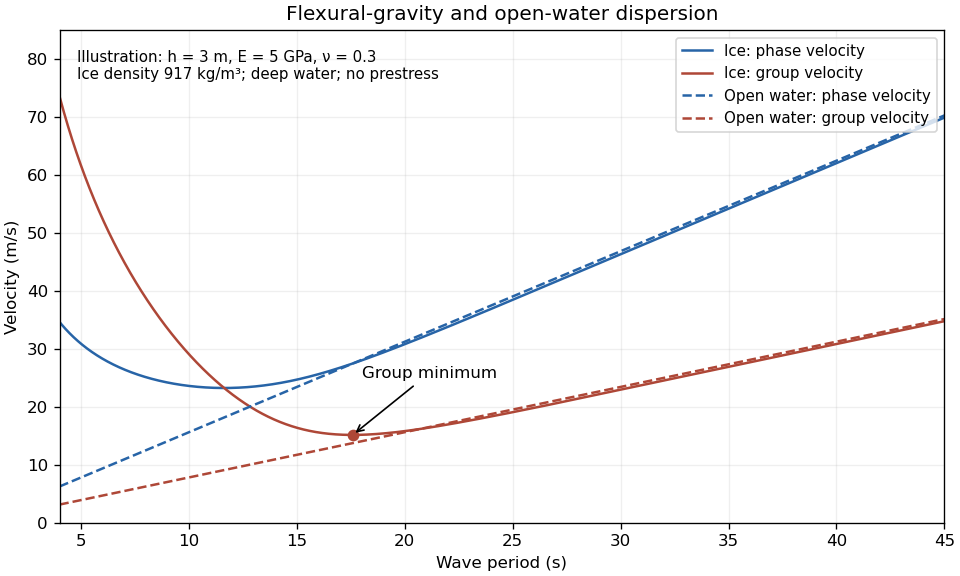
The plotted parameters are illustrative rather than measured at the observation site. They give a group-velocity minimum of a flexural-gravity wave near at period . There is no arbitrarily slow wave-energy branch under a continuous elastic sheet. Energy put into a localized disturbance travels away at at least this minimum group velocity; a slowly moving wind system cannot retain a wave packet indefinitely beneath itself. This reduces the opportunity for sustained local growth compared with slow, short open-water waves, and the continuous cover also prevents direct wind forcing of an exposed water surface. Incoming long swell can still propagate.
A group-velocity minimum of a flexural-gravity wave is not by itself a universal minimum wind speed for wave generation. A steadily translating forcing pattern requires a phase velocity matching its translation speed, so the minimum of , not , supplies the corresponding resonance threshold. Random wind forcing, dissipation and aerodynamic coupling must be specified before making an absolute generation claim.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 3 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07Set and use the sign-appropriate Cole-Hopf transformation . Direct differentiation givesThus the heat equation implies the viscous Burgers equation with the required negative nonlinear sign. Conversely, vanishing of the Burgers residual makes the final quotient depend only on , and a multiplicative time-dependent factor in removes it. The algebraic substitution works for any nonzero where .
For a forward dissipative initial-value solution, take and . This is essential for the supplied heat kernel: at , , its real Gaussian integral diverges even for . More generally that kernel requires . The physical viscosity convention selects the positive case; the mere condition does not justify a forward Gaussian function formula.
Integrating gives a positive continuous initial factor, normalized asIts heat kernel convolution converges for both signs of , since a Gaussian function dominates the one-sided exponential. DefineThe left half-line contributes ; completing the square on the right half-line gives . ThusWhen differentiating, the two moving-endpoint Gaussian function terms cancel, becauseOnly remains in the logarithmic derivative. The viscous Burgers step solution with negative flux is thereforeThe denominator is strictly positive, so lies between and , irrespective of the sign of . Its initial limits away from are the required step.
For the spatial limits, the Gaussian function tails must be compared with ; inspecting that exponential alone gives the wrong inference when . As , the complementary error function asymptotic givesAt , tends to zero even for , because its quadratic decay dominates any exponential linear in . Hence . At , use the identity above to obtainwhile approaches its full Gaussian integral. Thusfor both signs of .
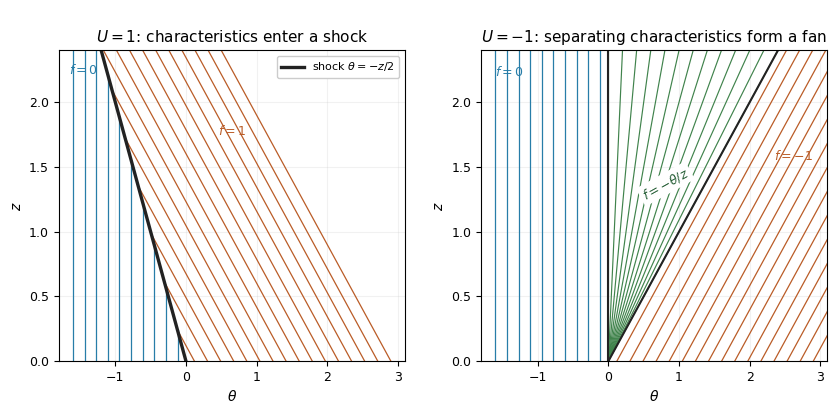
Since is strictly decreasing, holds exactly when . At this point , so the midpoint symmetry of a viscous Burgers step givesMore generally the exact symmetry is . For , the midpoint follows the inviscid shock trajectory. For , it is instead the center of an expanding fan, not a shock.
The vanishing viscosity approximation makes the comparison precise. For fixed and , near both tail integrals tend to the full Gaussian integral, so andThe layer has width and tends to the entropy shock, with value at its center. Outside it the limits are and .
For , inside both Gaussian function tails have large positive lower limits. Their asymptotics giveOutside this interval the limits are on the left and on the right. Thus positive viscosity selects the rarefaction wave, including the same midpoint value as the inviscid fan. The two sign cases agree with the preceding entropy solution construction, while a negative diffusivity would not furnish this dissipative selection.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 3 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14For the negative-flux Inviscid Burgers equation, the method of characteristics givesThe characteristic curve starting at therefore has , and henceFor smooth data this describes a single-valued classical solution as long as the characteristic flow map is invertible. Its Jacobian is ; after characteristic crossing, one must instead select a weak solution with the appropriate entropy solution condition.
The conservation form is , with conservation law flux . Integrating this scalar conservation law across a moving discontinuity, or differentiating its Heaviside representation as a distribution, yields the Rankine-Hugoniot conditionFor distinct one-sided limits it simplifies toThis jump-speed relation is exact for the Burgers conservation law; an additional entropy condition is needed to distinguish a physical compressive shock wave from an expansion discontinuity.
The step gives the Burgers Riemann problem with negative flux. If , characteristic curves from the left have speed zero, while those from the right have speed : they converge. The entropy shock wave has speed and thusCharacteristics enter this shock from both sides, since .
If , the right-hand speed is positive and the two families separate. A smooth steep approximation to the initial step spreads into a rarefaction wave. In the fan, the self-similar characteristic curve relation is , givingThe endpoint values match continuously. The discontinuity moving at would satisfy the jump condition even for , but its characteristic curves leave the discontinuity and it fails entropy admissibility. For the solution is identically zero.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 2 d Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07Use the Fourier transform pair , . The point force transforms to . With the dispersion relation defined above, the sheet equation becomesThe point-force radiation from a fluid-loaded sheet is therefore represented exactly byThe causal contour and outgoing acoustic square-root branch are fixed first with , then continued to the desired real frequency. This prescription fixes how poles and the branch points are passed.
For the acoustic far field , , take bounded away from grazing and . The method of steepest descent saddle point is , with . The supplied saddle point rule, including its factor, gives, provided the contour deformation crosses no poles,A convenient simplification, free of division by , isEquivalently, when ,The expression printed in the PDF is missing sound-speed factors for general dimensional . It agrees with this result if in fully normalized units; when is retained as an arbitrary sound speed, the numerator needs and the structural term needs in the last form. These factors arise respectively from cylindrical spreading, the pressure-density relation, and .
A direct countercheck is the transparent-sheet limit . The sheet jump condition then gives , so the saddle point rule requiresThe printed expression, interpreted continuously after multiplying out its structural factor, instead gives times the same phase. It differs by a factor ; for example it is eight times too large when . This limit also verifies the normalization of the corrected density field independently of the sheet's elastic-sheet tension.
To decide about poles, track the roots of on the chosen square-root sheet and deform the original causal contour to the steepest descent contour. A root contributes a residue exactly when it lies in the region swept out by that deformation; its sign is fixed by the contour orientation. Branch cuts must be retained throughout this comparison. Which roots are crossed can depend on observation angle, producing a change of the modal contribution when a pole meets the deformation boundary. A saddle point approaching a pole or a grazing endpoint requires an approximation uniform in that limit, rather than the isolated saddle point formula above.
The crossed poles are the free fluid-sheet modes of the preceding solution. Real subsonic roots represent evanescent acoustic surface waves carrying energy along the sheet, with normal decay; complex continuations represent leaky or radiating modes. Their residues must be added to the saddle point sound when the causal contour selects them. The specification “no poles contribute” is therefore a substantive condition on the contour, not permission to ignore zeros of the dispersion relation.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 2 c Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07With no incoming wave, both fluids obey the outgoing acoustic square-root branch. Their surface pressure amplitudes areSubstitution in the sheet's force balance yields the dispersion relation for an acoustic membrane wave:The equivalent denominator is useful away from the branch points . For real guided modes with , this is the familiar added mass of an evanescent fluid layer formThe normal fields decay away from the sheet; continued by analytic continuation roots may describe radiating or leaky modes.
On , , so the impedance from the preceding solution isThus the divergence of the reflection coefficient corresponds to a reflection pole of a fluid-loaded membrane. The prescribed incoming amplitude is zero, but a homogeneous fluid-sheet mode can have nonzero amplitude. This is a resonance or guided-mode pole of the analytic scattering problem, not arbitrarily large passive reflection at a real propagating angle. In particular, an undamped guided mode has an evanescent normal field and therefore a complex incidence angle in the plane-wave continuation. For real propagating incidence, and the finite-mass, finite-tension sheet has a purely imaginary structural impedance, so its passive reflection remains bounded.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 2 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07Define and use the outgoing acoustic square-root branchFor positive real frequency reached from below, on the propagating interval and is positive real for . The outgoing field in the lower fluid has pressure amplitude , since . If , the shared normal velocity is . The linear homentropic acoustic equations therefore giveThis lower-fluid wave is outgoing; no additional incoming sound is included in defining the impedance seen by the upper fluid.
Put . The sheet's force balance gives , hence . Its prescribed downward velocity amplitude is . Thus the tensioned-sheet acoustic impedance isThe first term is the lower fluid's normal acoustic impedance, and the second is the sheet's inertial and elastic-sheet tension response. For a real propagating angle, .
At fixed nonzero frequency and fixed wavenumber, gives , a zero-velocity, in-phase reflecting boundary. At fixed , gives the same reflection limit, but there is an important exception: elastic-sheet tension does not resist the spatially uniform mode . At normal incidence, the impedance remains however large the elastic-sheet tension is. With this mode is transparent. By contrast, arbitrarily large mass resists even a spatially uniform oscillation. These fixed-frequency limits exclude a simultaneously tuned structural resonance.
If , and . The identical fluids are effectively joined across a massless, untensioned interface: pressure and normal velocity continue without reflection. This is the matched case, rather than the pressure-release case.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 2 a Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07Use the prescribed harmonic convention . For a propagating acoustic plane wave, let and . The incident and reflected pressure amplitudes in the upper half-space have vertical factors and respectively:The linear homentropic acoustic equations imply . At the surface, the normal velocity is therefore , while the pressure amplitude is . The surface acoustic impedance condition givesHere is the normal acoustic impedance; the angle in this question is measured from the horizontal, not the normal. For a passive acoustic impedance, the mean power absorbed per unit area is . The four limiting cases have distinct meanings:
- If , . This is a pressure-release boundary: the pressure perturbation vanishes, while the normal velocity is generally nonzero. The reflected pressure has equal amplitude and a phase reversal.
- If , . The boundary is acoustically rigid, with zero normal velocity and doubled total surface pressure. There is no pressure phase reversal.
- If , . This is a matched boundary, taking up the incoming wave without reflection. Its pressure and normal velocity are those of the incident wave.
- Formally, means . A nonzero outgoing field can then exist with vanishing incoming amplitude. For a passive boundary at a real propagating incidence angle, a negative-real-part surface acoustic impedance cannot describe ordinary absorption: such a scattering pole must be interpreted through an active source or an continued by analytic continuation free-mode resonance. The sheet calculation below identifies the relevant free modes.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 1 d Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07Write and , where . Label the two arms by . Their positions are . To radiating far-field accuracy,The retarded time equation therefore gives, with ,For the first arm, , this is the requested phase expansion. The more explicit geometric error also makes the dimensional meaning of the printed term clear.
Apply the Taylor theorem to the rotating line force. Since , its first two orders, expressed in a common reference frame, areAlso , so the radial Mach number isThe absolute value causes no change of sign in this subsonic limit. Multiplying these two expansions before summing is essential: both the shifted force and the moving-surface retarded Jacobian contribute at the same order.
Denote the integrated numerator, including that Jacobian, by . Pairing the two blades cancels all terms odd in , including the first Doppler correction to the axial load. HenceThe factor comes from . Only the time-dependent term radiates at order . Applying to the integral now gives , and thusThere are also nonradiating terms of order . Multiply by for the acoustic pressure. The stated coefficient uses the rotation convention fixed above; reversing the rotation reverses the corresponding signed load and phase convention.
This is a compact rotating two-blade loading source acting as an acoustic quadrupole. The compact total rotating force cancels, leaving the first spatial moment of the loading. Its two factors of the observer's projection into the rotor plane produce : there is no leading sound on the rotation axis and the density amplitude is maximal in the rotor plane. The configuration repeats after half a rotation, explaining frequency . These statements concern amplitude; the corresponding acoustic intensity has a factor.
If , the displayed first-order contribution vanishes as well. For completeness, expanding the axial Jacobian to its next even order givesThe first remaining axial-load radiation is thenThus the constant axial total force does not produce the lower-order term, even though its moving spatial distribution can radiate at a higher order.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 1 c Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07The rotation introduces angular frequency and, after combining the two blades, harmonics such as . The acoustic compact-source approximation requires the propagation time to be small compared with . ThusIt also bounds every blade element's Mach number by . Consequently , and its leading value is one. The separate acoustic far field condition is .
Choose the positive rotation sense so that a first blade at phase has radial and tangential unit vectorsIntegrating the given line force from to yields . Its axial component is constant, while . Since , the compact acoustic dipole sound from this blade isThe other blade has phase and contributes the opposite rotating force. At a common compact retarded time, their total force is , soThis cancellation calls for the next source-delay correction; it does not mean that the complete moving-source field vanishes.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 70 1 b Solution by Codex 0 Created 2026-10-03 Updated 2026-10-07
Codex 0 Created 2026-10-03 Updated 2026-10-07In the Ffowcs Williams-Hawkings equation, the other source types are a surface acoustic monopole associated with acoustic thickness noise, and a volume acoustic quadrupole involving the Lighthill stress tensor. On an impermeable material surface, fluid and surface normal velocities agree. There is no through-surface mass-flux source; the remaining thickness source is . For a rigid body, the leading acoustic compact-source approximation to that source hasThus there is no leading net-volume acoustic monopole. To neglect thickness radiation beyond that leading cancellation, assume negligible volume displacement, as for ideal thin blades, or that its higher multipoles are small compared with the retained acoustic loading noise. Rigidity alone does not make a moving finite-volume body's local thickness source identically zero.
The volume acoustic quadrupole may be neglected for low Mach number motion when exterior turbulent or nonlinear stresses do not provide a competing strong source. We also assume small linear acoustics perturbations, a uniform reference sound speed, and negligible relevant viscous and entropy sources. These are source-strength approximations, particularly important if a loading contribution itself cancels by symmetry. Under them, the retained acoustic dipole is the force exerted by the object on the fluid, with the sign used in the previous solution.
Let , , and . In the acoustic far field, is large compared with the object and . For a source of size with and small surface Mach number, source-dependent delays and the Doppler factor can be neglected to leading order. The surface integral then contains just the total force . Differentiating its retarded time, rather than its spreading factor, gives the radiating termThe sign follows from . Differentiating or the direction instead produces the lower-order near field. A constant total force does not radiate at this leading compact order.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:




All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact