
Sine Created 2026-09-24 Updated 2026-10-14
For a real angle , is the vertical coordinate on the unit circle reached by a counterclockwise rotation through radians. For an acute angle in a right triangle, it is the opposite side divided by the hypotenuse. In particular,The first-quarter rise and second-quarter fall are visible in the circle projection; the lower semicircle gives negative values.
Reflecting the unit circle across the horizontal axis gives , so sine is an odd function. A full turn gives , making it a periodic function. For real arguments, its range is and its zeros of a function occur at for integers . The cosine describes the perpendicular coordinate of the same point, and the Pythagorean trigonometric identity keeps their two values tied together.
Breadth-first search Created 2026-09-24 Updated 2026-10-14
Breadth-first search is a graph search that explores successive layers of graph distance from a starting vertex . Here the graph is an undirected graph on a finite set of vertices, and distance counts edges, with no differing edge weights. Mark as discovered, assign , and place it in a FIFO queue. Repeatedly remove the front vertex and scan its adjacency list. Whenever a graph neighbour is still undiscovered, mark it immediately, record as its parent in a rooted tree in the discovery tree, assign , and enqueue at the rear. Marking on insertion ensures that another edge cannot enqueue the same vertex again. [ref]
https://raw.githubusercontent.com/kevin-wayne/algs4/master/src/main/java/edu/princeton/cs/algs4/BreadthFirstPaths.java. Sedgewick and Wayne, Algorithms: BreadthFirstPaths queue and discovery rule
Use the same undirected graph as depth-first search, with vertex set and edgeswhere denotes the unordered pair . Start at and scan graph neighbours in lexicographic order of their one-letter labels. The diagram's generator computes the following layers and the parent in a rooted tree assigned to each discovered vertex; the source is the root of a tree and has no parent in a rooted tree.
| Graph distance from | Vertices in discovery order | Parent in a rooted tree in the same order |
|---|---|---|
| none | ||
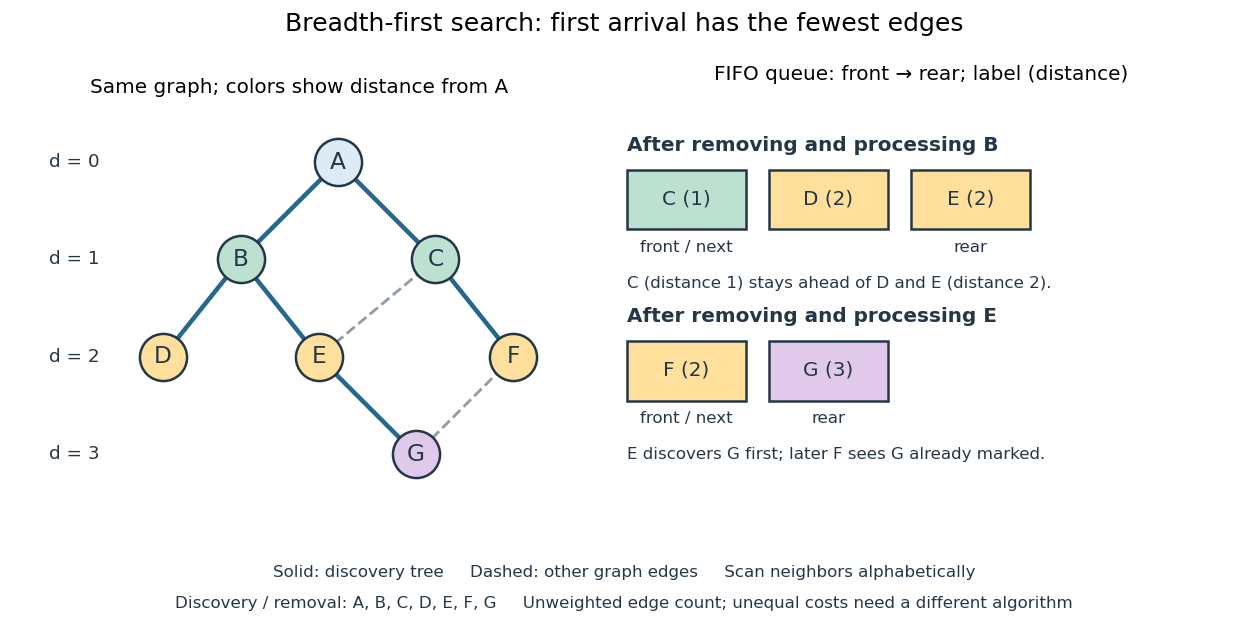
The discovery and removal orders both happen to be . After processing , the FIFO queue is : must be processed before the newer . Processing then skips the already discovered and enqueues , giving . Processing adds nothing. Processing discovers , giving ; later sees already marked and leaves its parent in a rooted tree unchanged. The discovery edges are , forming a rooted tree on all seven vertices even though the original graph contains graph cycles. The discovery tree contains six edges; it need not contain every examined edge.
First arrival is shortest because the FIFO queue keeps assigned distances in nondecreasing order, with entries from at most two consecutive layers. While processing distance , newly discovered vertices receive distance and join the rear. If an undiscovered vertex had a shorter graph path, its preceding vertex on that graph path would lie in an earlier layer and would already have discovered it. Thus is the minimum number of edges from to . This is a mathematical induction over the layers, not an assumption about the drawing. Following the parent in a rooted tree backwards at each step gives ; reverse that sequence to obtain the three-edge graph path . is another shortest graph path, but the specified graph neighbour order makes discover first. Changing that order can change the parent in a rooted tree without changing graph distances. [ref]
https://ocw.mit.edu/courses/6-006-introduction-to-algorithms-fall-2011/1208e162775f6f5cedfbb9f2b694ede0_MIT6_006F11_lec13.pdf. MIT 6.006, lecture 13: distance layers and shortest paths, pp. 4–6
The shortest-route guarantee concerns the shortest path problem measured by edge count. It also minimizes total cost when every edge has the same positive cost. With unequal edge weights, first discovery need not minimize total cost; nonnegative costs can instead be handled by the Dijkstra algorithm. Breadth-first search is useful for minimum-hop routes and for finding all vertices within a specified graph distance. Its FIFO queue finishes an older layer before the next one, whereas depth-first search uses a call stack or explicit LIFO stack to pursue one branch immediately.
With adjacency lists and constant-cost discovery checks, together with constant worst-case or amortized analysis cost for FIFO queue insertion and removal, the time complexity is in Big O notation. Every reached vertex is enqueued and removed once, each incident edge is scanned at most twice in an undirected graph, and initializing all marks and distances takes . The FIFO queue contains at most vertices; the example's maximum is three. Discovery marks, distances and the recorded parent in a rooted tree for each nonroot vertex also give auxiliary space complexity, excluding the graph. An array that shifts every entry on front removal can lose the linear time complexity; the FIFO queue abstraction alone does not make removal constant-cost. Ordering the adjacency lists is a separate preprocessing cost.
A single start reaches only its connected component of a graph. Unreached vertices retain distance and have no recorded parent in a rooted tree. Restarting at each still-undiscovered vertex, while preserving all discovery marks, produces a forest covering the graph; each new root of a tree gets distance zero, so these distances refer to that root of a tree, not to the original .
Spanning tree Created 2026-09-24 Updated 2026-10-14
A spanning tree of a connected graph is a subgraph that is a tree and contains every vertex of . Its edges must come from . For finite on vertices, every spanning tree has edges, the minimum possible number preserving reachability between all locations. This makes a spanning tree a compact certificate that the original graph is connected. A minimum spanning tree additionally minimizes a specified total edge weight; merely selecting a spanning tree supplies no such optimization. [ref]
Let be our seven-vertex tree with edge added. It has seven edges and a graph cycle. Removing gives the original spanning tree ; removing instead gives another spanning tree . Both retain all seven vertices and six edges, but their graph distances differ: , whereas . In , but , along , compared with . Preserving reachability permits longer journeys; breadth-first search can preserve graph distances from one chosen starting vertex.
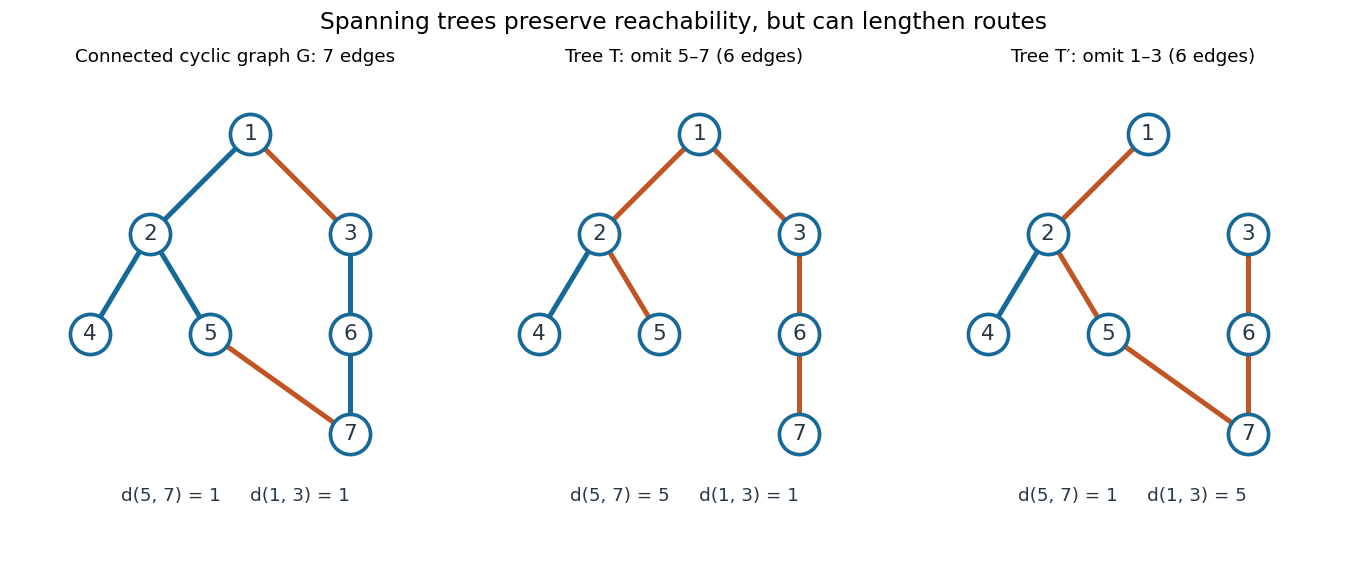
To construct a spanning tree, repeatedly delete any edge on a graph cycle. Its endpoints remain joined through the rest of that graph cycle, so the deletion preserves connectedness. Finiteness ensures that this stops at a connected acyclic graph. Conversely, adding an omitted edge to a spanning tree creates its unique fundamental cycle; deleting any other edge on that graph cycle produces another spanning tree. The displayed exchange replaces by . [ref]
https://www.maths.tcd.ie/~dwilkins/Courses/MA2C03/MA2C03Courseware_2014to15/MA2C03_S4_Yr1415.pdf. Trinity College Dublin, section 4.16: deleting cycle edges preserves connectivity
Forest Created 2026-09-24 Updated 2026-10-31
A forest is an undirected graph with no graph cycle; each of its connected components of a graph is a tree, including any isolated vertex. A finite forest with vertices and connected components of a graph hasIndeed, a connected component of a graph with vertices contributes edges; adding these counts gives . Equivalently, start with isolated vertices: every added edge must join different connected components of a graph, reducing their number by one. Joining vertices already connected would create a graph cycle. [ref]
https://ocw.mit.edu/courses/18-200-principles-of-discrete-applied-mathematics-spring-2024/mit18_200_s24_lec05-06.pdf. MIT, counting notes, p. 4: building forests by merging components
Deleting in our example gives , , and five edges: the two trees contribute . Deleting as well leaves isolated, so and four edges. A forest therefore describes separate hierarchies or the intermediate stages of building a spanning tree. The acyclic graph condition accounts for missing connections without assuming that all locations are mutually reachable.
Linear spreading speed Created 2026-09-24 Updated 2026-11-05
The linear spreading speed is the propagation speed predicted by the linearized dynamics near an unstable state. Forinsert an exponentially decreasing leading-edge mode , . This givesThe minimum occurs at and equals . Equivalently, the spatial equation has a repeated positive root at that speed.
For Fisher's equation, this is the Fisher-KPP minimum wave speed. It is a leading-edge calculation, not a universal speed theorem for every reaction-diffusion equation. A pulled travelling front is selected by that linear leading edge, while a sufficiently strong nonlinear interior can select a larger speed. Initial-data decay and nonlinear assumptions determine whether an observed invasion actually travels at the linear prediction.
Travelling-wave reduction of a reaction-diffusion system Created 2026-09-24 Updated 2026-10-14
The substitution turns time derivatives into and spatial diffusion into , reducing a reaction-diffusion PDE to an ODE system.
Nyquist stability criterion Created 2026-09-24 Updated 2026-11-05
The Nyquist stability criterion applies the argument principle to a specified negative-feedback return ratio . Assume a proper rational loop with a well-posed interconnection, no poles or closed-loop characteristic zeros on the imaginary axis, and no singularity at the closing part of the contour. Let count poles of in the open right half-plane and let count zeros of there, both with multiplicity. For a positively oriented contour enclosing that half-plane, let be the signed counterclockwise winding of its image under around . ThenA clockwise contour convention reverses the sign of , so the orientation must accompany the formula. Closed-loop input-output stability requires and exclusion of imaginary-axis zeros; simply passing through or encircling is not a conclusion without the pole count and convention.
Poles on the imaginary axis require an indented contour and a corresponding boundary analysis. Also, cancellations in a reduced transfer function can conceal unstable internal states, so a Nyquist conclusion about alone does not prove internal stability of an arbitrary nonminimal realization. The bounded-input bounded-output stability example exhibits that distinction.
Liouville number Created 2026-09-24 Updated 2026-11-05
A Liouville number is a real irrational number such that, for every positive integer , there are integers with and . It admits rational approximations of arbitrarily high polynomial accuracy.
For example, is a Liouville number: truncating after leaves a tail smaller than a constant times , while the denominator is . The Liouville approximation theorem bounds how well a fixed algebraic number that is an irrational number can be approximated, proving that every Liouville number is transcendental. The converse fails: transcendence alone does not require such exceptional approximations.
Coupling inequality for total variation Created 2026-09-24 Updated 2026-11-05
For any coupling of random variables, the coupling characterization of total variation distance gives , where denotes the law of a random variable. If two coupled Markov chains stay identical after their coalescence time , then andThe persistent agreement is essential: a first meeting time does not give this bound if the chains can separate again. A coalescing coupling turns a difficult comparison of probability distributions into a concrete question about how long a joint simulation takes to merge.
Coupling characterization of total variation distance Created 2026-09-24 Updated 2026-10-14
A coupling of probability distributions is a pair of random variables with those marginal distributions. On a finite set, and more generally on a standard Borel space, the least achievable mismatch isA maximal coupling attains the minimum; maximal here refers to agreement. An arbitrary coupling can have a much larger mismatch.[ref]
Markov Chains and Mixing Times, second edition by David A. Levin and others. §4.2, Example 4.6 and Proposition 4.7, printed pp. 49–52: finite-state coupling and common-mass construction
For the four-outcome example, assign the following joint probability mass: gets , gets , gets , and gets . The remaining must have ; place on and on . Row sums give , column sums give , and the diagonal contains . Agreement can reach 70%; mismatch cannot fall below 30%.
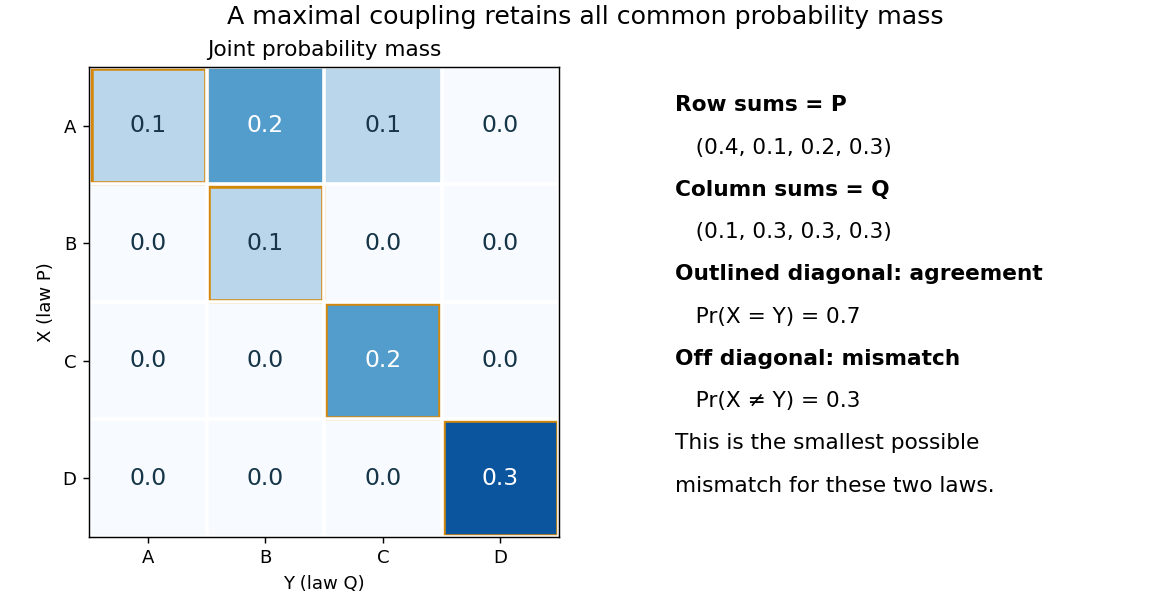
To see the lower bound, for any event ,The two indicator functions agree whenever . To attain the bound on a finite set, keep mass at and couple the remaining excesses. The two residual probability distributions live on disjoint subsets, so their part necessarily mismatches. When the probability distributions are identical, the residual part disappears entirely.
This is a choice of joint construction, not a claim that independently drawn observations are usually equal. Two independent random variables with the same continuous probability distribution can disagree with probability one even though their total variation distance is zero. The construction of a maximal coupling deliberately introduces statistical dependence to reveal how similar the marginal laws are.
Triangle KKM lemma Created 2026-09-24 Updated 2026-10-14
If three closed sets cover a triangle and respectively contain its three opposite sides, then their triple intersection is nonempty.
Topological surface Created 2026-09-24 Updated 2026-10-14
A topological surface is a Hausdorff space with a countable basis in which every point has a neighborhood homeomorphic to an open subset of .
Closed graph theorem for compact spaces Created 2026-09-24 Updated 2026-09-24
Unit sphere Created 2026-09-24 Updated 2026-10-14
Homeomorphism Created 2026-09-24 Updated 2026-10-14
A homeomorphism is a bijection between topological spaces such that both and are continuous maps. Equivalently, for every subset , is an open set if and only if is an open set in . A homeomorphism therefore transports the entire topology, including connectedness and compactness. It need not preserve numerical metric values, and a bounded set need not map to a bounded set.
For example, an explicit homeomorphism between an open interval and the real line isThe tangent function on is strictly increasing and takes every real value; the displayed arctangent inverse verifies the bijection. Both formulas define continuous maps on their stated domains. Computed values are , , and . Points approach infinity as approaches an excluded endpoint. Thus a bounded set can have the same topology as an unbounded one; neither of these topological spaces is compact.
A useful shortcut is the compact-to-Hausdorff continuous bijection theorem: a continuous bijection from a compact space to a Hausdorff space is a homeomorphism. Its images of closed sets are compact sets, hence closed sets in the target, which proves continuity of the inverse. The indiscrete topology example shows why the Hausdorff assumption matters. [ref]
Hausdorff space Created 2026-09-24 Updated 2026-10-31
A Hausdorff space separates any two distinct points by disjoint open neighborhoods.
Compact space Created 2026-09-24 Updated 2026-10-14
A topological space is compact when every open cover has a finite subcover: whenever open sets satisfy , some finite selection satisfies . A subset of an ambient topological space is compact when its subspace topology is compact; equivalently, every open cover of by ambient open sets has a finite subcover. The word every matters: finding one finite subcover of one open cover is not enough to establish compactness. [ref]
The closed interval is compact by the Heine-Borel theorem. For a concrete open cover, take the three open intervals , , and . Their union is , so they cover every point of , including both endpoints. The overlaps have lengths and , leaving no gaps. Each member is necessary for this particular open cover: removing them respectively leaves , , or uncovered.
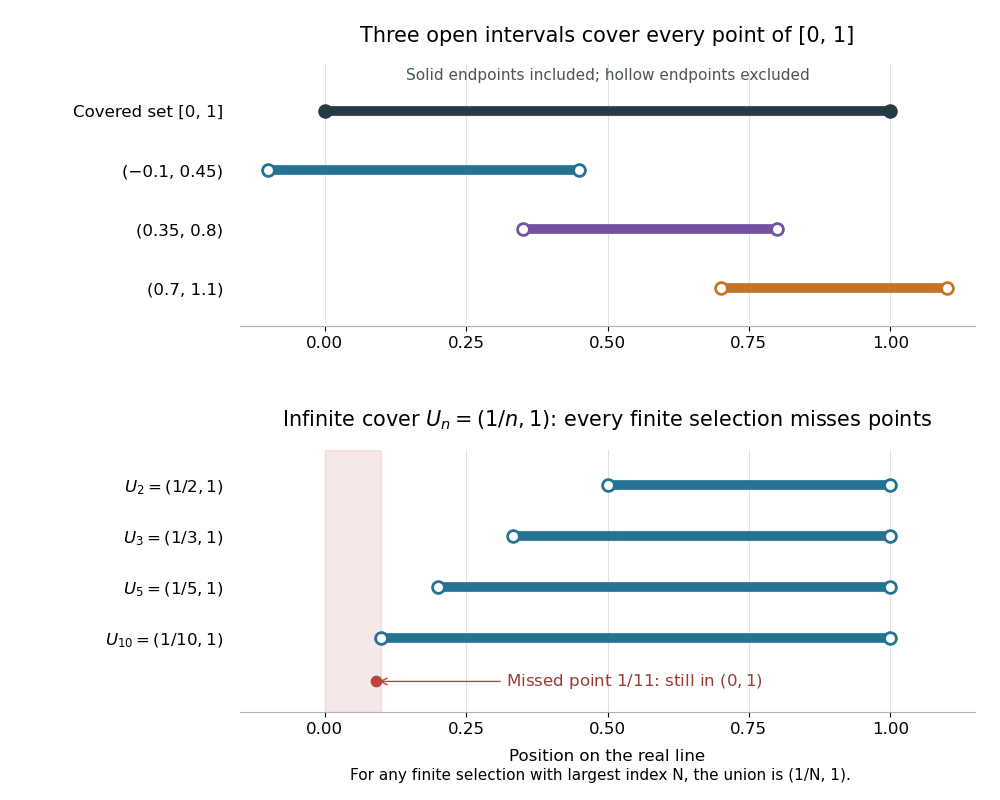


Above, hollow markers denote the excluded endpoints of the covering open intervals, while the solid endpoints belong to the covered closed interval. Below, each displayed open interval is one member of an infinite open cover of ; finitely many rows always leave points near zero uncovered. The rows are vertically separated for readability and all refer to the same real line.
The open interval is a bounded set but is not compact: the open setsgive an open cover of , since every has for sufficiently large . These are also open sets for the subspace topology on . Any nonempty finite selection has a largest index , so its union is just and misses the point , which still belongs to . Thus no finite subcover exists, however many members we select. The same family is not an open cover of , since it misses both endpoints.
In a metric space, compactness is equivalent to sequential compactness: every sequence in the subset has a convergent subsequence whose limit of a sequence belongs to that subset. This equivalence does not extend to all topological spaces. For example, for has limit of a sequence zero in . The same sequence lies in , but every subsequence still has limit of a sequence zero on the real line, so no subsequence converges to a point of . Merely approaching a boundary is harmless when the required point remains available. [ref]
https://ocw.mit.edu/courses/18-100b-analysis-i-fall-2010/b7780b2a0629359b11c5de998c72a147_MIT18_100BF10_compactness.pdf. MIT Analysis I, Compactness vs. Sequential Compactness, Theorem 1 and its metric-space proof
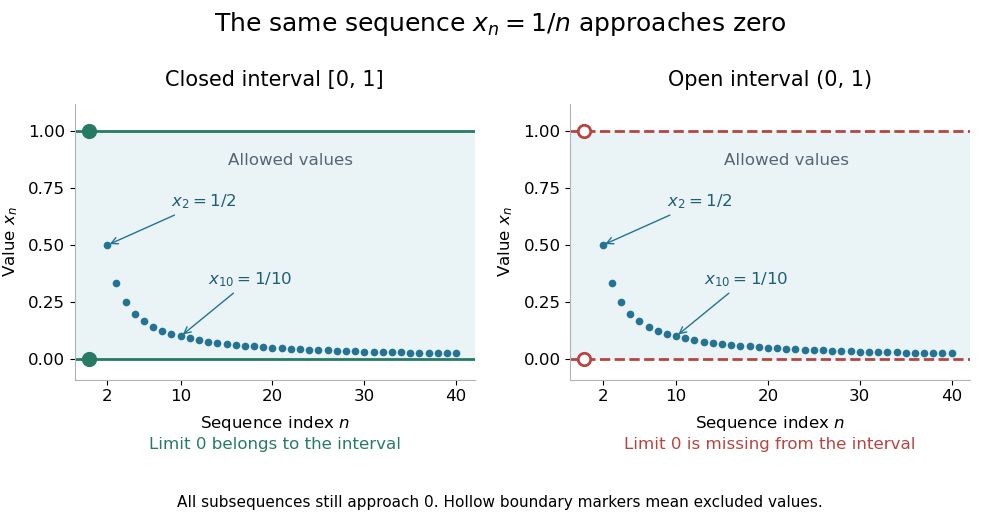
The same sequence approaches an included endpoint in a closed interval and a missing endpoint in an open interval
. Details. 
Both panels show the sequence for approaching zero. In the closed interval, zero is an allowed limit of a sequence; in the open interval, the hollow marker identifies the missing point. This single sequence disproves sequential compactness of ; compactness of still requires control of every open cover or every sequence, supplied by the Heine-Borel theorem.
An infinite set with the discrete topology similarly fails compactness, using the open cover by all its singletons. Every finite set is compact in any topology: select one covering open set for each point. The empty set is compact because the empty selection is a finite subcover. This open cover definition does not require the topological space to be Hausdorff; in algebraic geometry it is often called quasi-compactness.
The beauty of compactness is that information valid around each point can often be controlled using finitely many regions. A finite subcover lets us combine finitely many local bounds, or choose the smallest of finitely many positive tolerances, to obtain control across the whole compact space. This is why compactness repeatedly turns approximation into existence and why it is so useful in optimization through the extreme value theorem.
Every closed set in a compact space is compact, and a continuous image of a compact space is compact. The latter proof pulls an open cover back by inverse images, selects a finite subcover, and maps forward. This makes compactness useful for proving existence: the extreme value theorem guarantees that a continuous function from a nonempty compact space to the real line attains both a minimum and a maximum. For example, on has maximum at and minimum zero at its endpoints. On its infimum is still zero but is never attained. [ref]
Connected-space zero-product dichotomy Created 2026-09-24 Updated 2026-09-24
If continuous functions on a connected space satisfy and never vanish simultaneously, then the disjoint open sets and cover the space. One is empty, so one function vanishes identically.
Discrete space Created 2026-09-24 Updated 2026-10-14
Level set Created 2026-09-24 Updated 2026-10-14
There are unlisted articles, also show them or only show them.