
Open set Created 2026-09-24 Updated 2026-10-14
An open set is a member of the topology on a topological space. In a metric space, a subset is an open set precisely when every has an open ball contained in for some . For , one can take . At , this gives and . The radius depends on the point; no uniform radius is required. [ref]
Openness depends on the ambient topological space. In with its subspace topology, is an open set in , although it is not an open set in the real line. Similarly, the whole closed interval is both an open set and a closed set in itself. These relative open sets are what the continuity test uses for maps involving a subset with its subspace topology.
Arbitrary intersections of open sets need not be open sets: , a singleton that is not an open set in the usual real line. Any point is excluded once . This is why the topology axiom specifies finite intersections.
Quotient topology Created 2026-09-24 Updated 2026-10-14
The quotient topology turns an instruction to glue points together into a precise topological space. Start with a topological space and an equivalence relation . The quotient set consists of equivalence classes, and its canonical projection of a quotient set isThe quotient topology is defined by the rule using preimages of open sets:Thus a subset of the quotient space is open if and only if its entire preimage is open in . Each fiber is the whole equivalence class , so the preimage includes every point glued to any of its members.[ref]
This is the finest topology making a continuous map: every topology with that property can contain only subsets whose preimages are open. It really is a topology, because preimages preserve the empty set, the whole set, arbitrary unions, and finite intersections. The gluing example below shows why checking a complete preimage matters, especially at the seam.
The quotient topology also makes continuous maps out of a glued space easy to construct. A continuous map descends to a unique continuous map exactly when it is constant on every fiber of , meaning . Define ; the equivalence class representative cannot affect the answer. For every open set ,The right side is open, so the quotient topology makes open. Conversely, if for a continuous map , then composition of continuous functions makes continuous, and equal equivalence classes force equal values. This is the universal property of the quotient topology. [ref]
A surjective continuous map is not automatically a quotient map. On the same two-point set , take the identity map from the discrete topology to the indiscrete topology. It is continuous and surjective, but is not open in the target even though its preimage is open in the domain. The quotient topology for this identity map would be the discrete topology. Thus continuity supplies only one direction of the rule using preimages of open sets; a quotient map requires both.
Topological space Created 2026-09-24 Updated 2026-10-14
A topological space is a set together with a topology , a family of subsets satisfyingHere is the power set; the union may have arbitrarily many members, while the intersection must be finite. The members of are the open sets. These are axioms about subsets, with no assumed metric or surrounding Euclidean space. [ref]
https://www.maths.ox.ac.uk/system/files/attachments/Preliminary%20Reading%20%281%29.pdf. Richard Haydon, Oxford topology preliminaries, Definition 0.1
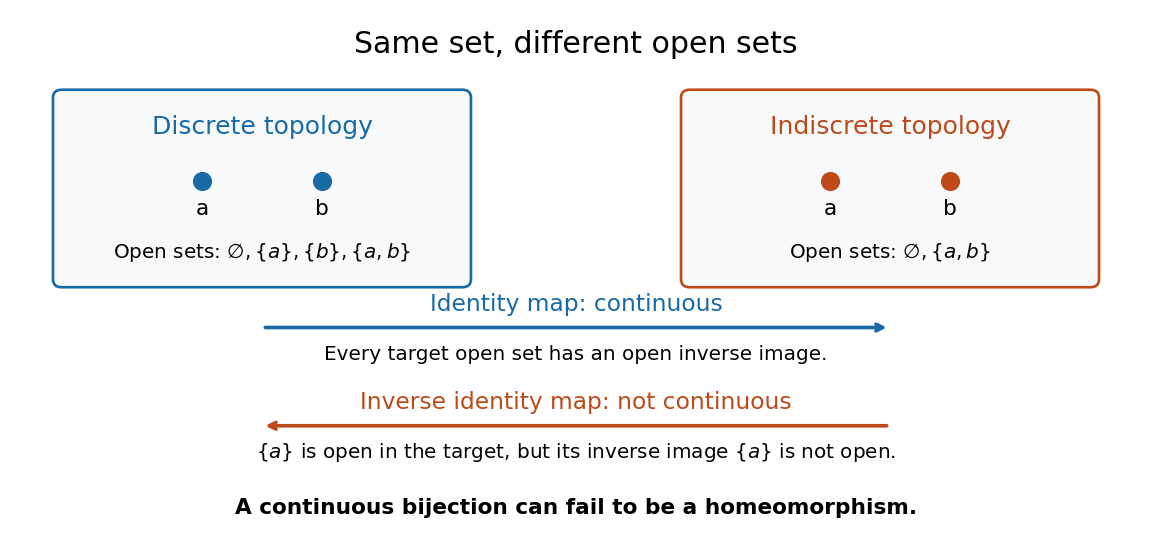
For , the discrete topology is , while the indiscrete topology is . Both satisfy the axioms. They describe different topological spaces on the same set: the first is Hausdorff and disconnected, while the second is connected and not Hausdorff. Each is compact because is a finite set.
The identity function is a continuous map: the only target open sets have inverse images and . Its inverse is not a continuous map, since the target open set has inverse image , which is not an open set in . Thus even a continuous bijection need not be a homeomorphism.
Closed set Created 2026-09-24 Updated 2026-10-14
A subset of a topological space is closed when its complement in that same ambient space is open: . For example, the closed interval is closed in the usual real line because its complement is the open set . Always specify the ambient topological space: a subset can be closed in a subspace topology without being closed in the surrounding space. [ref]
https://www.maths.ox.ac.uk/system/files/attachments/Preliminary%20Reading%20%281%29.pdf. Richard Haydon, Oxford topology preliminaries, Section 0.1
Being closed is not the logical negation of being open. In the usual real line, all four combinations occur: is open but not closed; is closed but not open; the half-open interval is neither open nor closed; and both the empty set and the whole real line are open and closed, hence clopen. Nor does being closed imply being a bounded set: is closed because its complement is open, but it is not a bounded set. The symbol is not an extra point that this interval must contain.
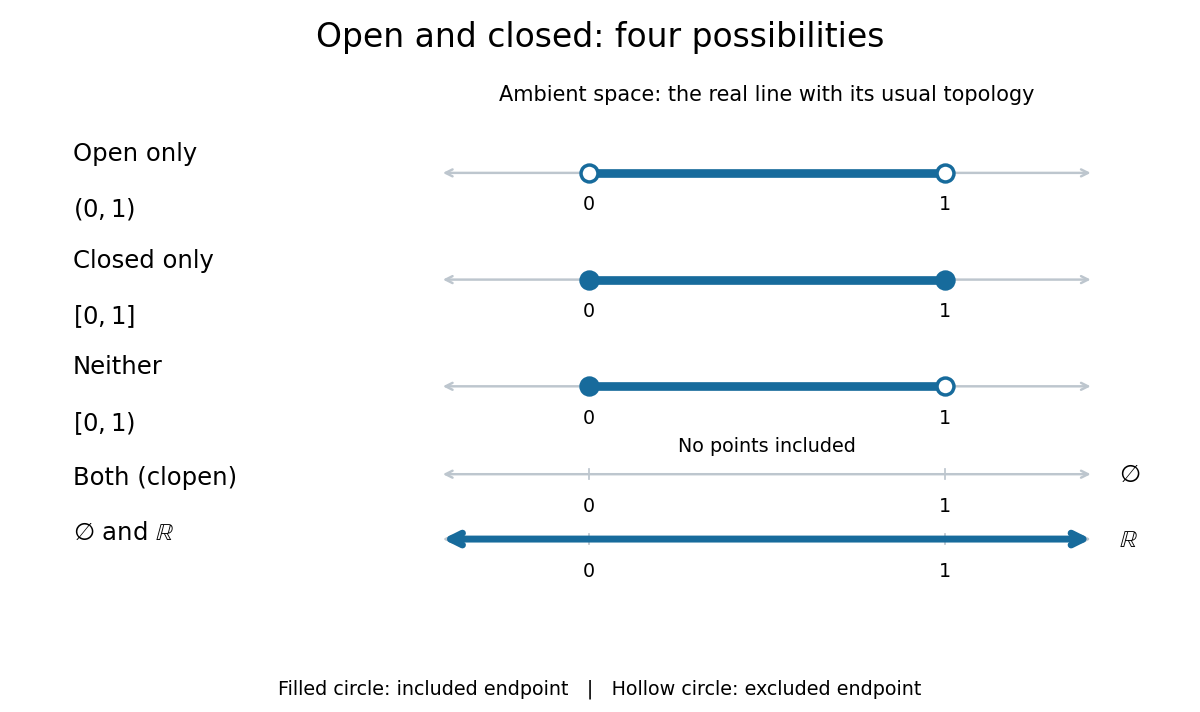
The four combinations of openness and closedness in the real line
. Details. The coloured strokes mark membership; filled endpoint circles mean included points, and hollow endpoint circles mean excluded points. The empty set has no coloured points, while arrows at both ends of the coloured real line indicate that membership continues indefinitely. These examples use the usual topology of the real line.
In a metric space , a subset is closed exactly when every convergent sequence in whose limit of a sequence lies in has . For example, lies in for and has limit of a sequence , which is missing; thus this half-open interval is not closed in the real line. This criterion is useful for keeping limiting constructions inside a prescribed set. [ref]
In every topological space, the general criterion is , using closure; equivalently, contains all its limit points. A closed set is always a sequentially closed set, but the converse can fail outside metric spaces. Arbitrary intersections and finite unions of closed sets are closed, by taking complements in the topology axioms.
One-form symmetry Created 2026-09-24 Updated 2026-11-05
A one-form symmetry is a global symmetry in field theory whose charged observables are line operators. In spacetime dimensions, its symmetry operators lie on closed manifolds of dimension , so their codimension is two. This differs from the codimension-one symmetry operators of an ordinary zero-form global symmetry.
A symmetry surface acts on a charged line through their linking. It can be deformed without changing a correlation function as long as it does not cross charged insertions; crossing changes the function by the relevant symmetry action. In four spacetime dimensions these generators are surfaces, while the charged observables remain lines. This language organizes constraints on gauge theories and distinguishes global symmetry data from a redundant local gauge description. [ref]
Generalized Global Symmetries by Davide Gaiotto and others. Introduction, printed pp. 2–3, equations (1.1)–(1.2): codimension q+1 generators and q-dimensional charged operators
Kramers--Wannier duality Created 2026-09-24 Updated 2026-11-05
Kramers--Wannier duality exchanges order variables with domain-wall or disorder variables. In multiple dimensions it naturally appears as a tensor-network map with a nontrivial symmetry-sector kernel.
Symmetry-protected topological phase Created 2026-09-24 Updated 2026-11-05
A symmetry-protected topological phase is short-range entangled but cannot be deformed to a product state without breaking a protecting symmetry or closing the gap.
Topological equivalence of gapped Hamiltonians Created 2026-09-24 Updated 2026-11-05
Two local Hamiltonian operators describe the same gapped phase when an allowed continuous path , , connects them while retaining a nonzero bulk spectral gap. The path must keep locality bounds under control. For a family of finite systems with an isolated low-energy sector, a standard sufficient condition is a lower boundindependent of system size and path parameter . A positive gap in each small finite system alone does not establish a gapped thermodynamic limit.
For sufficiently regular paths of local interactions, quasi-adiabatic continuation transports the low-energy subspace by a quasi-local evolution. Lieb-Robinson bounds control its spatial tails. The resulting equivalence concerns locality-preserving transport, not arbitrary unitary operators on a finite Hilbert space. [ref]
The permitted paths define what is being classified. In a symmetry-protected topological phase, they must preserve the specified symmetry. Allowing symmetry-breaking terms can join phases that were distinct under that restriction; the Haldane phase is an important example of why the symmetry condition matters.
Topological superconductor Created 2026-09-24 Updated 2026-11-05
A topological superconductor is a gapped paired-fermion phase supporting protected boundary Majorana modes.
Anyon Created 2026-09-24 Updated 2026-11-05
An anyon is an excitation in two spatial dimensions whose exchange statistics can differ from those of bosons and fermions. Two-dimensional paths can wind around each other in inequivalent ways, so exchanges are described by braids rather than only by permutations.
For Abelian anyons, a braid contributes a phase to the joint quantum state. For non-Abelian anyons, it can act as a noncommuting transformation on an anyon fusion space. Exchange and full encircling must be distinguished: a full braid involves two exchanges in a consistent orientation. In the surface-code anyon model, electric and magnetic excitations are individually bosonic but have mutual encircling phase , illustrating how mutual statistics can contain information absent from self-statistics. These are collective excitations, not a claim that an ordinary free electron changes its fundamental exchange statistics.
Abelian Chern--Simons theory Created 2026-09-24 Updated 2026-11-05
An Abelian Chern--Simons theory describes topological gauge fields in two spatial dimensions and time. In units , its bulk action can be writtenwhere are compact Abelian gauge field one-forms, is the wedge product of differential forms, and the K-matrix is symmetric, integral and invertible. This supplies a long-distance description of gapped Abelian quantum Hall states. [ref]
A quasiparticle labeled by an integer vector couples to the corresponding combination of gauge fields. The full encircling phase of charges isThus global particle paths can carry measurable braiding information even though the pure bulk action has no metric-dependent local wave term. Boundaries require their own treatment; the bulk formula alone does not specify every allowed boundary condition.
Metric space Created 2026-09-24 Updated 2026-10-14
A metric space is a set together with a metric measuring how far apart its elements are. The elements can be positions, functions, or other objects: what matters is that the metric obeys the same basic rules. This lets one discuss convergence in a metric space, continuous maps, and Cauchy sequences without first assigning Cartesian coordinates. The useful abstraction is that many arguments require only comparisons of distances, rather than the particular objects being compared.
Even the same set can support several informative metrics. On the plane with Cartesian coordinates, write and . Three standard choices are Manhattan distance, Euclidean distance, and Chebyshev distance:They come from the L1 norm, Euclidean norm, and maximum norm, respectively, through . For and , Manhattan distance is , Euclidean distance is , and Chebyshev distance is . All three answers are correct for their respective metrics.
The choice encodes the question being asked. Manhattan distance models travel along a rectangular street grid. Euclidean distance measures unrestricted travel along a line segment. Chebyshev distance measures the time needed when two Cartesian coordinates can change simultaneously, each at speed at most one. Thus choosing a metric is part of modelling, rather than a consequence of knowing the endpoints. These examples have the same metric topology, but different metric path lengths and different collections of metric geodesics.
A historical reference for the general study of metric spaces is Maurice Fréchet's 1906 paper Sur quelques points du calcul fonctionnel, published in volume 22 of the Rendiconti del Circolo Matematico di Palermo. [ref]
https://link.springer.com/article/10.1007/BF03018603. Fréchet, Sur quelques points du calcul fonctionnel, 1906
No-retraction theorem Created 2026-09-24 Updated 2026-09-24
No closed disc retracts continuously onto its boundary. This is equivalent to Brouwer fixed-point theorem by the standard ray construction and the antipodal map.
Brouwer fixed-point theorem Created 2026-09-24 Updated 2026-10-14
The Brouwer fixed-point theorem says that every continuous map has a fixed point when is a nonempty compact set and a convex set in a finite-dimensional vector space over the real numbers. Equivalently, take for a finite , with the usual Euclidean space structure: there is some such that . The conclusion guarantees at least one fixed point, without asserting uniqueness or telling us how quickly to find one. [ref]
https://courses.csail.mit.edu/6.5440/fall23/lectures/L23_images.pdf. MIT lecture slides on Brouwer's theorem
The standard pictures are a closed ball, including a closed unit ball, and a simplex. A filled disk qualifies; its bounding circle alone does not. A probability simplex also qualifies even though its dimension is smaller than that of its ambient Euclidean space. The hypotheses have concrete meanings: being a convex set keeps every line segment between allowed points inside , and compactness prevents escape or loss of a limiting point. In Euclidean space, the Heine-Borel theorem identifies compact sets with closed sets that are bounded sets. Crucially, every output must belong to the same as the input.
For a fully computable example, let be the filled unit disk. Apply a counterclockwise quarter-turn rotation, shrink by , and add a translation:This affine map is a continuous map. Because the rotation preserves the Euclidean norm, the triangle inequality gives, for every ,Thus the whole image lies strictly inside . More precisely, it is a disk of radius centred at . This containment check is what makes the Brouwer fixed-point theorem applicable; a formula being a continuous map by itself would not suffice.
The fixed point can now be found by a system of linear equations:Indeed, substitution gives . Its Euclidean norm is , safely inside . The figure shows arrows from sample inputs to their outputs; an arrow disappears at the fixed point because the displacement vanishes there.
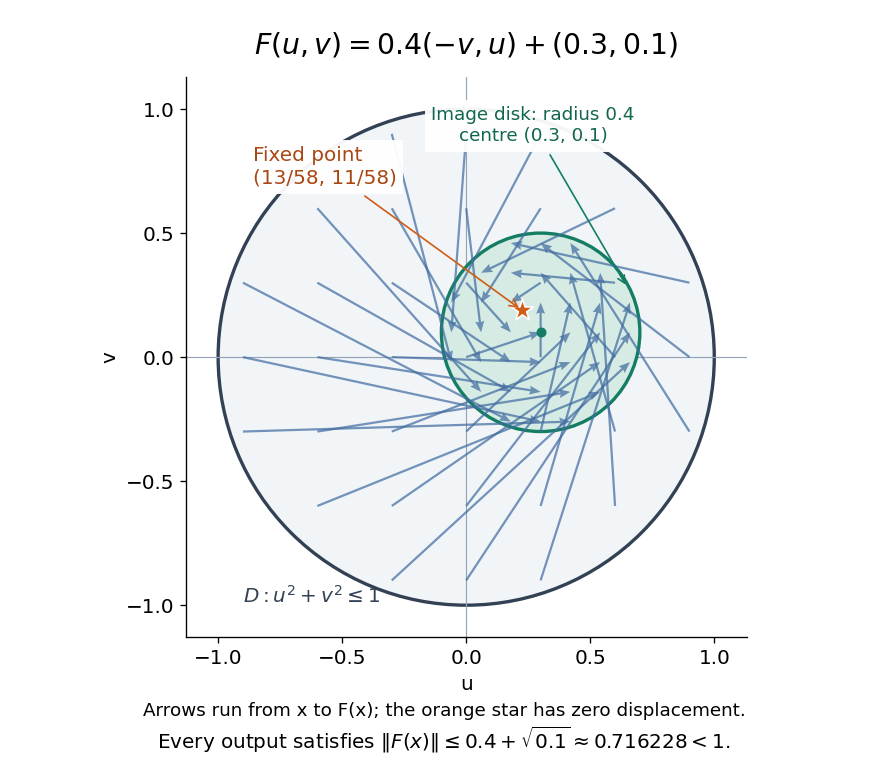
Repeated iterations of a map happen to succeed for this example. Starting at and setting gives , , and . Subtracting the fixed point equation yields , so the Euclidean distance to shrinks by exactly each step. This extra fact follows from the contraction mapping property and the Banach fixed-point theorem. It is additional information beyond the Brouwer fixed-point theorem.
The distinction becomes visible with two simpler continuous maps of the same disk. The pure rotation has exactly one fixed point, , since and force both to vanish. Yet iterations of a map starting at here cycle through , , and forever. Their Euclidean distance from stays one, so there is no convergence in a metric space. The reflection has an entire line segment of fixed points, namely . Starting off that line segment produces an alternating pair. Existence, uniqueness, and convergence of iterations of a map are separate questions.
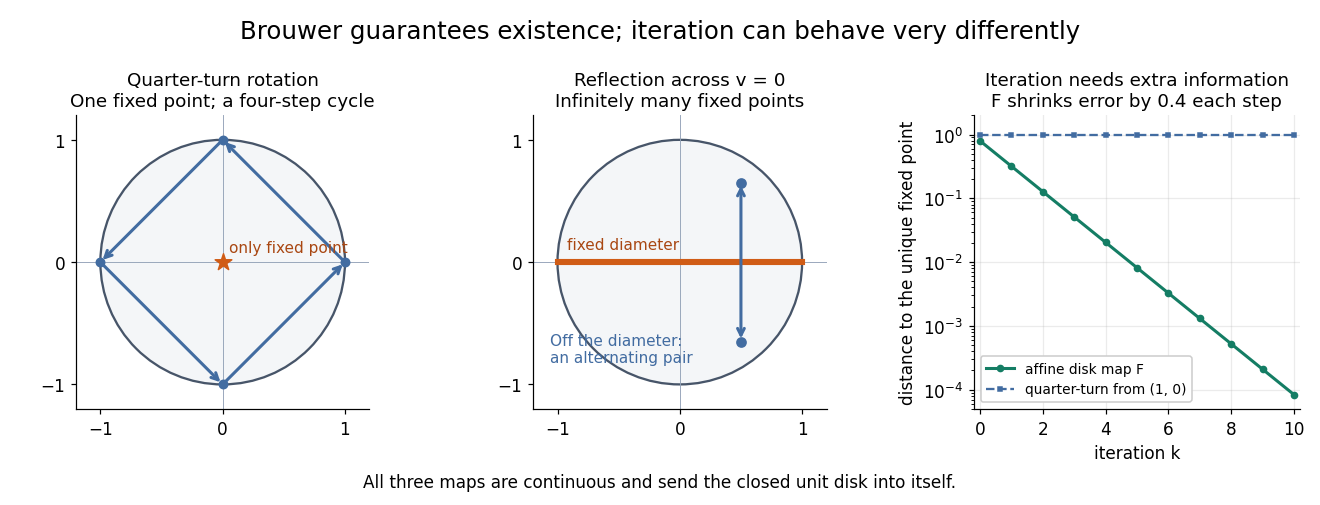


Removing hypotheses changes the answer. Restrict the same quarter-turn rotation to the circle . It remains a continuous map into that compact set, but its only possible fixed point, , has been removed. The circle is not a convex set. Conversely, on the unbounded convex set , the translation has no fixed point; on the open interval , also has none. Neither domain is a compact set. The finite-dimensional closed ball statement should likewise not be extended to arbitrary infinite-dimensional vector spaces, where a closed ball need not be a compact set.
The one-dimensional version explains the connection to the intermediate value theorem. For a continuous map , put . Then and , so the intermediate value theorem gives for some . In higher dimensions, the Brouwer fixed-point theorem supplies a corresponding existence principle when this scalar sign argument is unavailable. Its practical value is ensuring that a proposed equation has a solution once a suitable domain is found; it supplies no general promise of a fast algorithm.
A useful application is positive matrix eigenvector from simplex normalization: rescale the output of a strictly positive matrix to make its entries sum to one. For example, takeOn this probability simplex, has entry sum , so the normalized continuous map is . Both entries are positive and sum to one, keeping the image inside the probability simplex. Its fixed point equation is , hence . Consequently satisfies : a strictly positive eigenvector with eigenvalue . In larger dimensions, the Brouwer fixed-point theorem guarantees the corresponding positive eigenvector without requiring us to solve a system of linear equations in advance. The fixed point expresses preservation of relative weights, rather than preservation of their unnormalized size.
Proofs can be approached through the no-retraction theorem or Sperner's lemma. In the latter approach, increasingly fine triangulations locate approximate fixed points; compactness supplies a convergent subsequence, and continuous maps turn its limit into an exact fixed point. [ref]
https://www.mit.edu/~6.7980/brouwer.html. Daskalakis and Farina, Brouwer and Sperner
A primary historical reference is L. E. J. Brouwer's 1911 paper Über Abbildung von Mannigfaltigkeiten, whose digitized original is hosted by Zenodo under DOI 10.1007/BF01456812. This gives a direct route to the early literature behind the Brouwer fixed-point theorem. [ref]
https://zenodo.org/records/1428286. Brouwer, Über Abbildung von Mannigfaltigkeiten, 1911
Effective potential for timelike Schwarzschild geodesics Created 2026-09-24 Updated 2026-09-24
For equatorial timelike motion with specific angular momentum ,A circular orbit has and therefore requires .
Effective-potential stability of a circular orbit Created 2026-09-24 Updated 2026-09-24
A circular orbit at a strict local minimum of the radial effective potential is stable under small radial perturbations.
Bound-state quantization condition Created 2026-09-24 Updated 2026-10-03
Matching a wavefunction and its derivative across finite potential discontinuities, together with decay or wall conditions, permits only discrete bound-state energies.
Imaginary-coupled two-level Hamiltonian Created 2026-09-24 Updated 2026-11-05
Second-order nondegenerate perturbation theory Created 2026-09-24 Updated 2026-11-05
For a normalized nondegenerate eigenstate ,For a ground state, every denominator is negative, so the correction is nonpositive.
First-order nondegenerate perturbation theory Created 2026-09-24 Updated 2026-11-05
There are unlisted articles, also show them or only show them.