A volume integral integrates a scalar or componentwise vector field over a three-dimensional region with its volume form. In spherical polar coordinates the Euclidean volume form is . The divergence theorem relates a volume integral of a divergence to a boundary flux integral.
Let a bounded planar region have positive area and centroid . If a solid has nonnegative thickness above , its volume integral givesThus the average of an affine function over a region is its value at the centroid. The proof is the linearity of integration. For a disk the centroid is its centre, making the formula particularly useful for a cylindrical bore cut through a solid whose width varies linearly with height.
A partial derivative measures the local response of a function to one input while its other inputs stay fixed. For a function on an open subset of , its partial derivatives at are the limitswhen the respective limits exist. Each is an ordinary derivative of a one-variable slice: or . This is why the other variable is treated as a constant during partial differentiation.[ref]
4.3 Partial Derivatives. Calculus Volume 3, §4.3, definitions (4.12)–(4.13) and the one-variable slice interpretation
For an original example, take the polynomial functionHolding fixed gives , while holding fixed gives . At , the height is and the two partial derivatives are and . The values answer different experiments on the same mathematical model: change alone, or change alone.
The two exact slices through that point areDividing either height change by gives or ; taking the limit recovers the two slopes. At , the finite height changes are and , although their linear approximations are and . A derivative measures the limiting response, rather than an exact finite change.
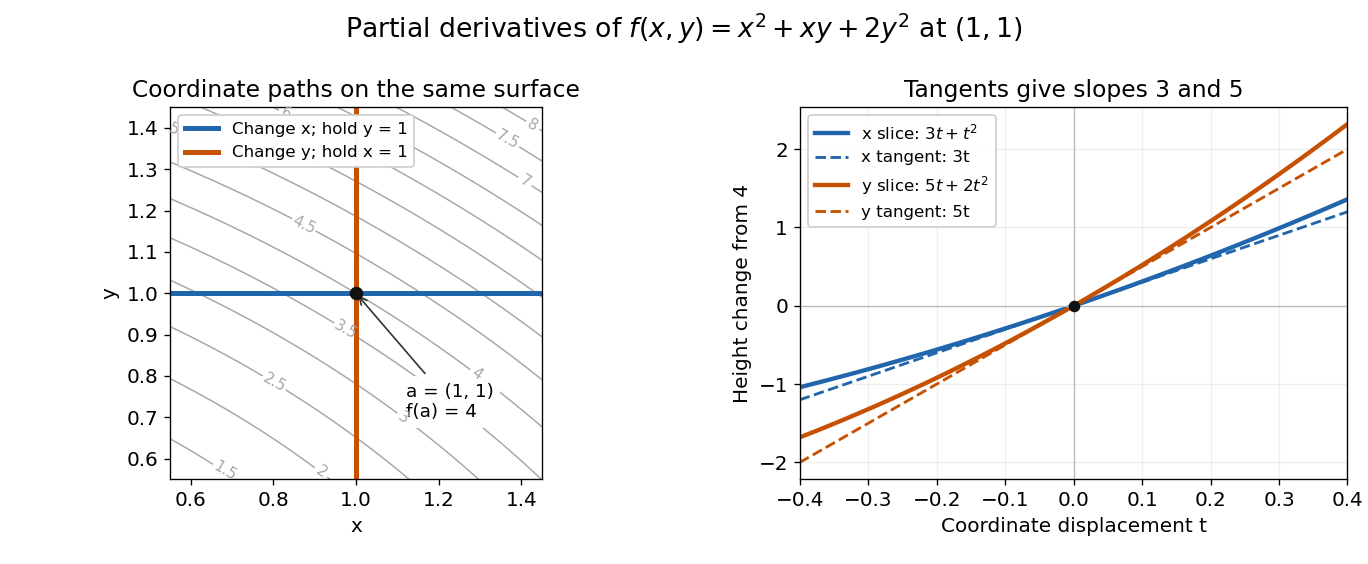
Two coordinate slices through one point give different partial derivatives
. Original contour plot of , with the point and coordinate paths. The right panel compares the exact slice height changes and with their tangent line predictions and . Both slices pass through height . Details.For a function of variables, varies only its th coordinate: it is the same difference quotient along , the th standard basis vector. This gives a practical sensitivity analysis: one can compare how a mathematical model responds to changes in its individual inputs, provided the chosen system of units and the quantities held fixed are stated. Comparing the numerical sizes of two partial derivatives in different units does not by itself identify a physically preferable input.
Existence of the partial derivatives at one point is weaker than differentiability. The example under partial derivatives do not imply continuity shows how both coordinate tests can miss a bad diagonal approach. When the first partial derivatives are continuous in a neighborhood, they do give differentiability there, allowing the total differential to combine all small input changes.
Define away from the origin and zero at the origin. Both partial derivatives exist everywhere and are zero at the origin, yet along the function is , so it is not continuous there. Coordinate-axis derivative tests do not control all neighboring directions.
A mixed partial derivative takes partial derivatives in different variables, for example . If both second partial derivatives are continuous in a neighbourhood, their order can be interchanged: . The chain rule transforms mixed partial derivatives under a linear change of variables by composing the corresponding first-order differential operators.
For away from the origin and zero at the origin, proves Fréchet differentiability with zero derivative. Yet and , giving the displayed unequal mixed partial derivatives. They exist but are not continuous at the origin, so Clairaut's theorem does not apply.
When the second partial derivatives are continuous in a neighborhood, the order of the mixed partial derivatives can be interchanged. Expressing a rectangular finite difference as either iterated integral by the fundamental theorem of calculus and shrinking the rectangle proves the equality. Mere existence of both derivatives does not imply this symmetry.
A time derivative is the partial derivative of an evolving field with respect to time while holding its spatial coordinates fixed. For a quantity depending only on time, it is an ordinary derivative.
The directional derivative tests a function along a chosen straight line, including lines that follow neither coordinate axis. For a fixed vector and a point in an open subset of , defineif the limit exists. With a unit vector , the parameter measures signed distance in the input Euclidean space, so the directional derivative is change per unit distance. For a general , it is change per unit parameter; the norm of also sets the rate of travel.[ref]
4.6 Directional Derivatives and the Gradient. Calculus Volume 3, §4.6, definition (4.36), unit-direction convention
For a differentiable real-valued function, the multivariable chain rule givesThus one gradient predicts the local response in every direction. This formula requires differentiability, rather than merely separate partial derivatives.[ref]
Return to at . Its gradient is . In the unit direction ,One can check this without invoking the gradient formula: substitution givesThe difference quotient is , whose limit is . This calculation separates the exact change along a finite path from its first-order rate at the starting point.
Changing the travel speed changes the parameter rate. Taking gives , because the input travels five distance units per parameter unit. For a differentiable function, for any real : negative reverses the orientation as well as scaling the rate. Normalizing before comparing different slopes avoids confusing direction with speed.
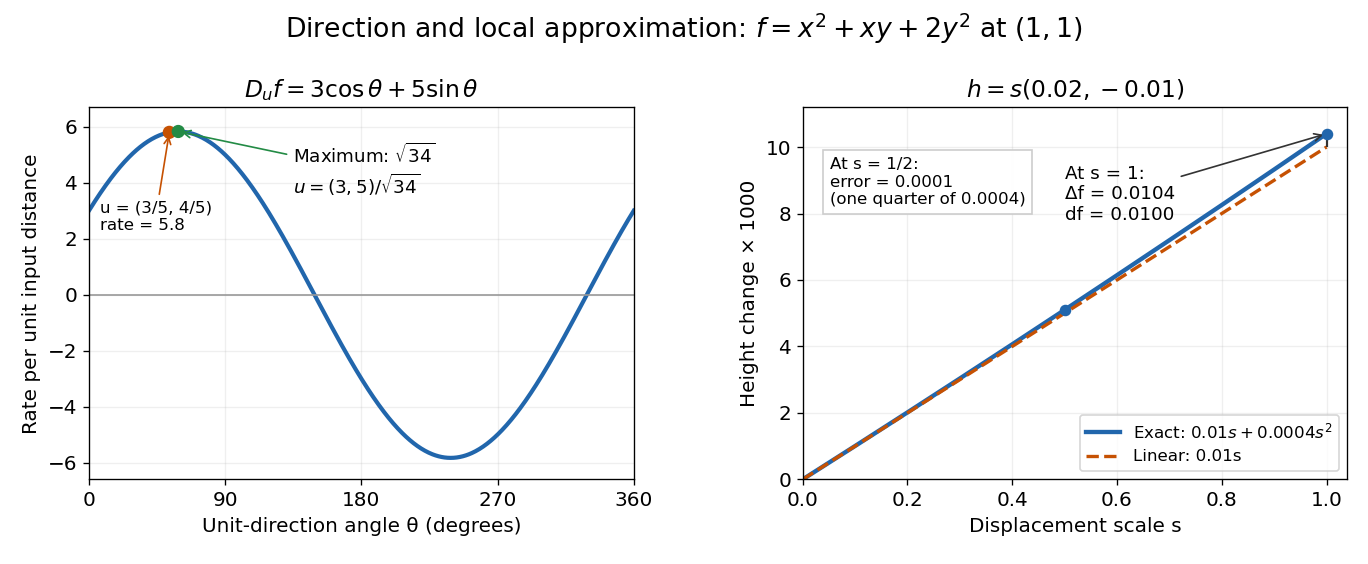
The Cauchy-Schwarz inequality bounds the rate in any unit direction by . Here the largest rate is , attained in the direction ; the chosen gives the slightly smaller rate . The perpendicular unit direction gives zero. That means no first-order height change, rather than no change at all: along this direction the example has .
This is useful for following a height or temperature scalar field, choosing a local search direction in mathematical optimization, and distinguishing a coordinate sensitivity from a response along an actual path. For a curved path, derivative along a curve uses its instantaneous tangent vector. Even existence of all directional derivatives does not guarantee one common linear approximation; directional derivatives do not imply differentiability gives a concrete counterexample.
A functional on a Banach space is Gâteaux differentiable at when the directional limits exist and form a bounded linear functional of . Fréchet differentiability is stronger, requiring a remainder uniformly small compared with the norm of the increment. A quadratic norm bound on the Taylor remainder gives the stronger property directly. Mere existence of unrelated directional limits would not establish linear differentiability.
For , starting at radius and moving radially outward through distance changes the function by . Solving yields the displayed exact distance. Its small-increment limit is , which is the initial directional derivative estimate. That linear estimate is not an exact equality for a specified finite change.
Away from the origin, the radial derivative is the directional derivative along the outward radial unit vector. For a Sobolev space function it is the same scalar product with the weak gradient, defined almost everywhere. On an annulus, it has no singular direction at the origin.
Define away from the origin and zero at the origin. Every directional derivative exists. Along a unit vector , the derivative at the origin is , which is not linear in . Thus these directional derivatives cannot be the restrictions of one Fréchet derivative, and the function is not Fréchet differentiable at that point.
For a locally Lipschitz function that is convex near , increasing secant slopes have a finite right limit. Positive rescaling of gives positive homogeneity in . The convexity bound gives subadditivity after subtracting , dividing by and taking the limit. Thus is a finite sublinear functional, although it need not be a linear functional.
In Cartesian coordinates on Euclidean space, the gradient of a scalar-valued differentiable function is the vector of its first partial derivatives. It converts a scalar field, such as temperature or a height, into a vector field describing its local change.
For a unit vector , the directional derivative is . The Cauchy-Schwarz inequality gives . At a point where , the greatest increase per unit distance occurs along , while the opposite direction gives the greatest decrease. These are first-order statements at the current point; they do not predict how the function behaves far along a straight path.
For at , . Moving in the direction gives rate and moving in the direction gives rate , but the steepest direction is , withThe direction has rate zero and is tangent to the level curve through that point. More generally, differentiating along a regular level curve gives , so the gradient is its normal vector.
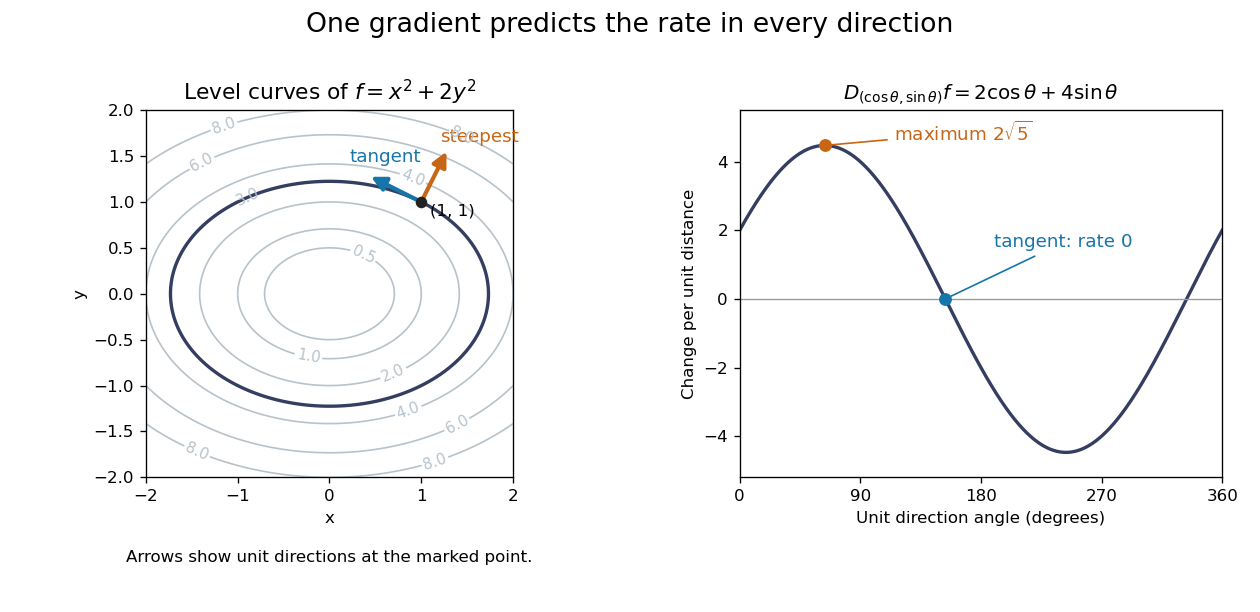
A gradient is normal to level curves and determines the directional derivative for every unit direction
. Details. This is useful when navigating a measured scalar field or applying gradient descent: one collection of partial derivatives predicts every infinitesimal directional change. The derivative assumes a differentiable function, not merely the existence of all directional derivatives. [ref]
4.6 Directional Derivatives and the Gradient. Calculus Volume 3 by Gilbert Strang and others; OpenStax: Directional derivatives and the gradient
.For a differentiable real-valued functional on a real Hilbert space , its functional gradient satisfies for every . A bounded linear derivative has a unique such representative by the Riesz representation theorem. The inner product matters: a formal variational derivative need not equal the functional gradient in another Hilbert space. For in a Reproducing kernel Hilbert space, the reproducing property gives . Substitution in the defining inner product proves this formula directly.
For , the multivariable chain rule givesIndeed, . Thus the gradient points radially outward when , inward when it is negative, and vanishes when it is zero.
At the origin the displayed quotient does not apply. If has a finite right derivative at zero, the radial function is differentiable there exactly when , in which case its gradient is zero. Necessity follows by comparing opposite directional difference quotients: their linear parts cannot both equal a common nonzero radial slope. Sufficiency follows from , the definition of differentiability with zero linear part.
For differentiable vector fields, expand the cross products using the contraction of two Levi-Civita symbols. The directional-derivative terms cancel the corresponding terms in the two cross products, leaving . This proves the displayed gradient identity by the product rule.
A gradient field is a vector field of the form for a scalar potential . Its curl vanishes wherever the required second derivatives commute.
The total differential is the linear map that combines the first-order responses to simultaneous changes in all coordinates. For a differentiable real-valued function at , it can be writtenHere is an input vector; denotes the coordinate linear functional . The coordinate formula and the Fréchet derivative describe the same linear map. The defining approximation isThe little o notation says the remaining approximation error becomes small relative to the input norm, across every direction of approach.[ref]
4.4 Tangent Planes and Linear Approximations. Calculus Volume 3, §4.4, differentiability definition (4.26) and total differential (4.27)
For at , . A simultaneous change gives the linear approximationThe exact algebra isConsequently the exact change is , and the approximation error is . If both input changes are halved, the linear prediction becomes and the error becomes : the first-order response halves, while the quadratic error falls by a factor of four. The right panel under directional derivative displays this comparison as the displacement is scaled.
For a quick check of differentiability, givesDividing by makes this bound tend to zero. The same calculation proves that the tangent plane to the graph of a function at is . It approximates the entire local surface, rather than only two coordinate slices.
The total differential is useful for estimating the combined effect of small input changes without reevaluating a complicated function. For example, if and , then . The exact remainder bound from the displayed polynomial is at most , so this example has throughout that input rectangle. These are deterministic bounds; a variance calculation additionally needs a joint probability distribution and its covariances. A first-order estimate is also local: large changes require control of the remainder, not merely knowledge of the partial derivatives at one point.
The Hessian matrix describes how the slope of a function changes in different directions. For a real-valued function with continuous second partial derivatives on an open subset of , it isThe symmetry of second derivatives makes a symmetric matrix under these hypotheses. It is also the Jacobian matrix of the gradient: near , a small displacement changes by . Thus the gradient measures the current slope, while the Hessian measures its local variation. [ref]
For example, take the quadratic formIts gradient and Hessian matrix areThe only critical point is the origin. Completing the square gives , so the origin is a strict global minimum. The eigenvalues and are both positive, recovering the same conclusion from the positive definiteness of the Hessian. Its eigenvectors identify the rotated directions in which the quadratic form has its smallest and largest bending.
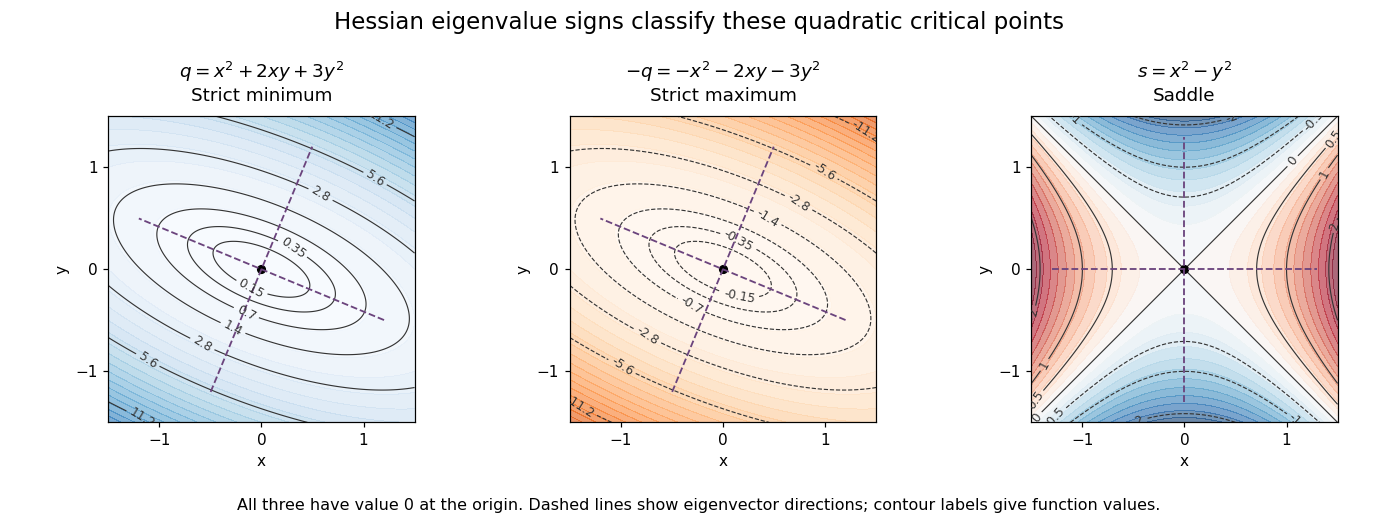
For a fixed vector , restriction to a straight line gives the directional interpretationThis is the quadratic form associated with the Hessian matrix. For a unit eigenvector , it equals the corresponding eigenvalue. Opposite signs therefore mean that some directions bend upwards and others downwards. The second-derivative test turns this information into a classification when the gradient vanishes.
The same object is useful for computation. Newton's method in optimization chooses a displacement by solving when the Hessian matrix is an invertible matrix; this makes the gradient of the local quadratic model vanish. For the displayed , the equation gives , so one exact step reaches the minimum from any starting point. For a general function, a Hessian with opposite-sign eigenvalues or a large condition number need not give a useful minimizing step, and the local minimum need not be a global minimum.
The name honors Otto Hesse. [ref]
https://web.mit.edu/course/other/wwmath/vectorc/minmax/hessian.html. MIT World Web Math: the Hessian and its namesake
An older geometric use is the Hessian criterion for flexes of a plane cubic, connecting a determinant of second partial derivatives with inflection points of an algebraic curve. Hesse's 1844 paper Über die Wendepuncte der Curven dritter Ordnung is an early source on that geometric problem. [ref]https://www.degruyterbrill.com/document/doi/10.1515/crll.1844.28.97/html. Hesse (1844), Journal für die reine und angewandte Mathematik 28, pp. 97–107: publisher's bibliographic record
Let be a twice continuously differentiable local diffeomorphism, and suppose . The chain rule gives the displayed transformation of the Hessian matrix: terms containing second partial derivatives of are multiplied by first partial derivatives of and vanish at the critical point. By Sylvester's law of inertia, the numbers of positive, negative and zero eigenvalues are unchanged. Independently of nondegeneracy, the local diffeomorphism preserves the critical point's status as a local minimum, local maximum or saddle point of a scalar function, because it maps neighbourhoods to neighbourhoods.
Applying a Hessian matrix to a vector without explicitly storing all its entries. For with diagonal , evaluate . This uses two matrix-vector multiplications and a diagonal scaling: arithmetic for dense , rather than forming the Hessian matrix. Iterative second-order methods can use this operation, with safeguards for indefinite curvature when the objective is nonconvex.
For twice differentiable , constant vectors and constant scalars , let , and let row of be . The chain rule givesThe second formula is the displayed matrix product because entry is the same weighted sum . Signed diagonal factors do not ensure a positive-definite Hessian matrix. The factorization also gives an efficient matrix-free Hessian-vector product.
The determinant of the Hessian matrix. For a twice continuously differentiable function of two variables, it is . A negative value at a critical point implies a saddle point; a positive value combines with the sign of in the second-derivative test. A zero value is inconclusive.
For with bounded Hessian matrix, Taylor's formula along the line from zero to gives . Its gradient obeys . Consequently is finite for when has finite measure, and .
For , a degenerate Hessian matrix can be supplemented by the first nonzero term of each one-variable displacement. Two negative leading even powers give a strict local maximum, two positive ones a strict local minimum, and opposite signs give a saddle. Looking along the coordinate directions and bounding the separated terms avoids an inconclusive quadratic test.
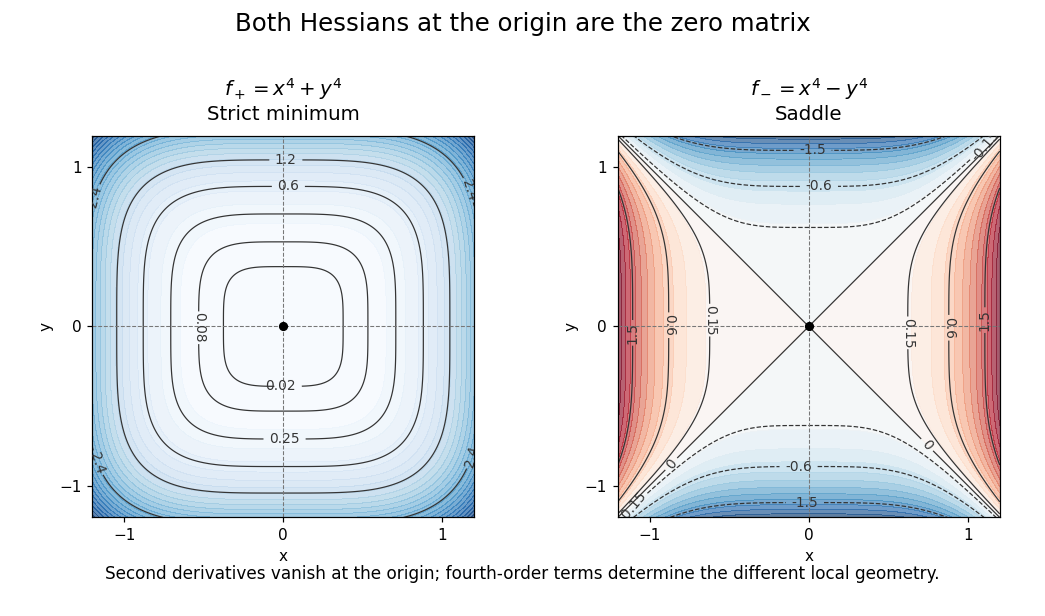
For an explicit contrast, considerBoth have zero gradient and the same zero Hessian matrix at the origin:Nevertheless, is positive at every nonzero point, so the origin is a strict global minimum. For , the restrictions and for show that the origin is a saddle point of a scalar function. Identical quadratic information can conceal different geometry when higher-order terms are decisive.
A symmetric matrix is negative semidefinite when for every vector . Equivalently, all its eigenvalues are nonpositive.
Let have continuous second partial derivatives near an interior critical point of an open subset of , with . The Hessian matrix gives the following sufficient conditions:
- All eigenvalues positive: a strict local minimum.
- All eigenvalues negative: a strict local maximum.
- Both positive and negative eigenvalues: a saddle point of a scalar function.
A positive semidefinite or negative semidefinite Hessian matrix with a zero eigenvalue does not settle the classification. The higher-order test for separated extrema gives two quartic examples with exactly the same zero Hessian. These conditions apply to an interior critical point; a boundary optimum or a constrained optimization problem requires attention to the allowed directions. [ref]
https://ocw.mit.edu/ans7870/18/18.013a/textbook/chapter11/section03.html. MIT 18.013A Calculus with Applications, §11.3: Hessian eigenvalues and the critical-point criterion
The proof outline is the Taylor expansionFor a positive-definite matrix, the smallest eigenvalue supplies a positive bound proportional to , which dominates the remainder for small enough . Negate the function for the local maximum case. For opposite-sign eigenvalues, choose the two corresponding eigenvectors: the leading terms have opposite signs along their lines.
There are also necessary conditions. At an interior local minimum, the Hessian matrix is positive semidefinite; at an interior local maximum, it is negative semidefinite. Restriction to each straight line reduces this to the one-variable second derivative condition. Since the Laplacian is the trace of the Hessian, it is nonnegative at such a local minimum and nonpositive at such a local maximum. The sign of the Laplacian alone is insufficient: has negative Laplacian but a saddle point of a scalar function at the origin.
Define and, elsewhere,All first and second partial derivatives exist at the origin: and . Thus its Hessian matrix there is the positive-definite matrix . Nevertheless and for , so the origin is a saddle point of a scalar function. A valid second-derivative test needs a second-order Taylor expansion with a remainder ; continuous second partial derivatives in a neighborhood are a sufficient hypothesis. Existence of those derivatives at the point alone does not supply this hypothesis.
The origin is a saddle point of a scalar function for every real parameter. For four further critical points have . Equal-sign coordinates give global maxima and opposite-sign coordinates give global minima, with values . The Hessian matrix there is . Their distance from the origin is , so as they escape every compact region. At nonpositive the origin is the only critical point. This illustrates why the number of critical points on an unbounded domain can change without a finite degenerate critical point appearing.
A critical point of a real function with continuous second partial derivatives is nondegenerate when its Hessian matrix is an invertible matrix there, equivalently when none of its eigenvalues is zero. A positive-definite matrix gives a strict local minimum, a negative definite Hessian gives a strict local maximum, and opposite-sign eigenvalues give a saddle point of a scalar function. A nondegenerate critical point need not be an extremum: has Hessian matrix , which is an invertible matrix.
Such critical points are the local building blocks of Morse theory.
Vector calculus studies differentiation and integration of scalar fields and vector fields. Three operators answer different local questions: the gradient describes change of a scalar value, the divergence describes net outward flow, and the curl describes local circulation. Their associated integral theorems turn local derivatives into measurements along paths and across boundaries.
The difference between divergence and curl is especially visible in two smooth vector fields on three-dimensional Euclidean space:At each point they have the same Euclidean norm , but their directions differ. For , and . For , and . One expands radially in each horizontal plane; the other describes rigid rotation.
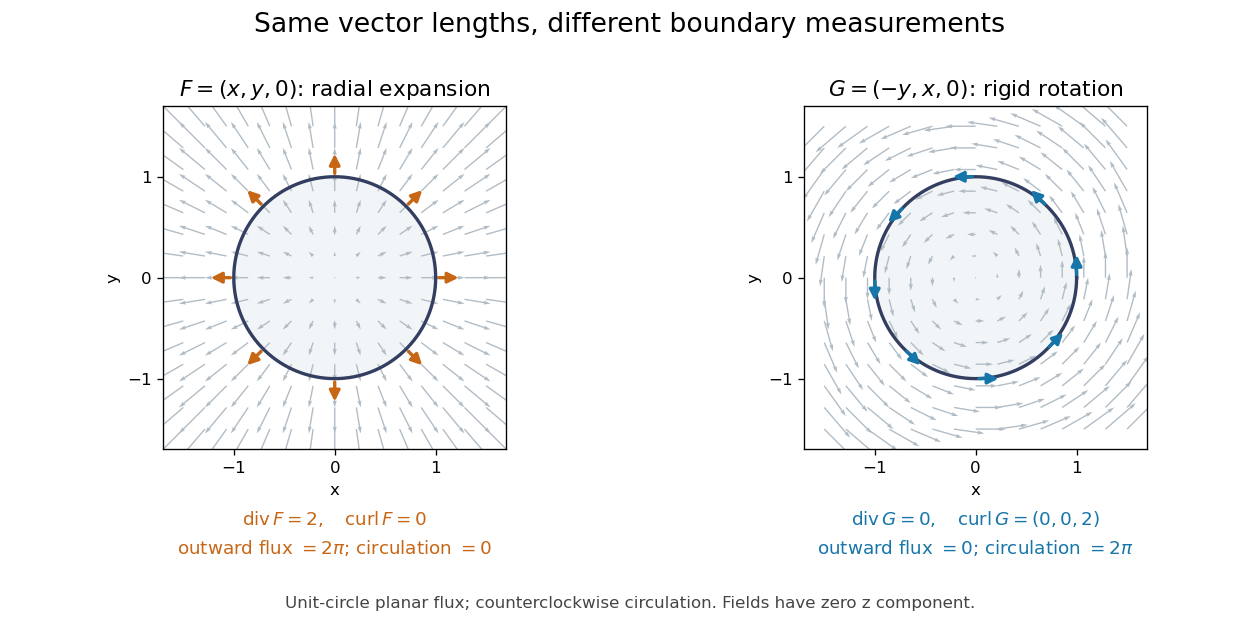
Equal-magnitude fields can have different divergence and curl: radial expansion gives outward flux, while rotation gives circulation
. Details. Around the counterclockwise unit circle in the plane , is normal to the boundary and has zero tangential component. Its outward planar flux integral is , while its line integral around the circle is zero. For the values are reversed: outward planar flux is zero, and circulation is . The divergence and curl predict exactly which boundary measurement survives.
Why is this useful? A velocity field can move material through a boundary or circulate it within a region. Conservation of mass connects its divergence with density changes through the continuity equation; its curl is vorticity. In electromagnetism, the Maxwell equations use the same operators to connect electric fields, magnetic fields, and their sources. The common mathematical language lets the same integral calculations work across different physical models. [ref]
https://openstax.org/books/calculus-volume-3/pages/6-5-divergence-and-curl. OpenStax: Divergence, curl, and their interpretations
.The geometric framework behind these operators is developed in differential forms. The Generalized Stokes theorem unifies the fundamental theorem for line integrals, Green theorem, Stokes theorem, and divergence theorem. In coordinates their formulas look different, but each relates accumulation over a region to a measurement on its boundary.
Wilson's Vector Analysis, published in 1901, was based on J. Willard Gibbs's lectures at Yale. Wilson's preface explains that examples from geometry, mechanics, and physics are interspersed with the mathematical development, so readers encounter applications as soon as they have the tools to understand them. That is a useful way to approach vector calculus: learn each operation through a measurement it makes possible. [ref]
https://archive.org/details/vectoranalysiste00gibbiala. Wilson: Vector Analysis, 1901, title page and general preface
.For a twice continuously differentiable vector field in Cartesian coordinates, expand the curl and then its divergence. Every mixed partial derivative occurs twice with opposite signs, proving the identity. In electromagnetism this forces the right side of the Ampère-Maxwell equation to be divergence-free, yielding local charge conservation.
For a sufficiently smooth real scalar field on Euclidean space, set . The product rule and equality of mixed partial derivatives giveThe divergence theorem, applied twice, consequently gives the useful pure-boundary identityHere uses the outward unit normal. This is the Euclidean zero-potential counterpart of the scalar stress-energy divergence identity.
For continuously differentiable vector fields, the gradient of their dot product expands as displayed. The contraction of two Levi-Civita symbols gives ; adding the directional derivative cancels the second term. Interchanging the fields and using the product rule proves the identity. It does not require either field to be irrotational.
The Helmholtz decomposition separates a vector field into a gradient field and a field with zero divergence. The precise function spaces, boundary conditions and decay hypotheses determine existence and uniqueness. In the square-integrable bounded-domain formulation, the solenoidal component is selected by the Leray-Helmholtz projection.
A vector field directed along the radius from a fixed origin, with magnitude depending only on radius. In three-dimensional Euclidean space and away from the origin, . The product rule gives , and the curl vanishes because the derivative matrix is symmetric. These identities alone do not establish regularity at the origin.
A vector field on an open subset of Euclidean space whose component functions have continuous first partial derivatives. Its Jacobian matrix is continuous; this is a standard regularity assumption for the divergence theorem and Stokes theorem.
The local flow of a smooth vector field is the family of solutions of its ordinary differential equation, with . Uniqueness gives wherever defined. A compactly supported smooth vector field on a manifold without boundary is complete, so its flow exists for all real times.
A smooth family assigns a tangent vector at each space-time point. Its flow maps solve , with the identity. For a varying differential form, differentiation gives .
A smooth time-dependent vector field on a compact manifold without boundary has flow maps throughout each compact time interval on which the field is defined. Finite-time escape is impossible on the compact state space. Uniqueness and the backward-time equation supply smooth inverses, so the flow is a smooth isotopy.
Differentiate the displayed homogeneity relation in at . On every regular point of , the radial vector field is therefore perpendicular to the normal gradient and tangent to the level surface. Its flow preserves that zero set. At a singular vertex this flow formulation remains meaningful even if there is no tangent plane.
For , the gradient satisfies . The product rule and Einstein notation then give the displayed divergence formula in dimension . In dimension three, its derivative matrix is symmetric, so the curl vanishes. Zero divergence forces on each positive radial interval. This formula does not assert regularity at the origin.
Let with and . Direct differentiation gives . For , integration against gives the displayed expression. Independently, the two boundary spheres contribute and , since the outward normal of the shell at its inner boundary points toward the origin. For , the divergence is zero in the shell and the surface contributions cancel exactly. The excluded origin must not be silently added to this regular-domain calculation.
The vector field has zero curl away from its excluded axis, but has circulation around a positively oriented circle enclosing that axis. Stokes theorem gives zero total circulation for a smooth annular surface avoiding the axis, whose inner and outer boundary circles have opposite orientations. It cannot be applied directly to a disk meeting the axis, because the field is undefined there.
An integral curve follows a vector field by solving the displayed ordinary differential equation. For a smooth vector field, integral curves through initial points assemble into its local flow.
For a continuously differentiable nonzero vector field , the curvature of a space curve following its direction isTake the unit tangent vector and differentiate with respect to arc length. The derivative of is parallel to and disappears from . Since , we have , proving the formula. It remains valid with zero curvature, even where the usual Frenet frame is undefined.
An axisymmetric vector field is invariant under rotations about a chosen axis. In cylindrical coordinates, its components are independent of the azimuthal angle.
For a solenoidal vector field with compact support and suitable integrability, apply the divergence theorem to . It gives zero boundary term and hence the displayed antisymmetry. Equivalently, for any constant vector , the vector triple product identity yields . A piecewise smooth field must have no normal jump at its support boundary; otherwise its weak divergence contains a surface contribution and the argument fails.
Suppose two oriented surfaces have the same oriented boundary and bounds a volume inside a domain where the vector field is smooth and solenoidal. The divergence theorem gives zero flux through their closed union, proving the displayed equality. If a global vector potential exists on the relevant surfaces, the Stokes theorem proves the equality directly from their common boundary. The domain condition matters: a singularity inside the joining volume can obstruct the divergence argument.
A spherical poloidal-toroidal decomposition represents a solenoidal vector field with zero flux through each sphere by scalar potentials . The second term is tangent to concentric spheres; the first carries the radial component. Requiring zero angular means for the potentials fixes their otherwise irrelevant radial additions. In a plane layer, the analogous fluctuating components are and , with any horizontally uniform components handled separately. These constructions enforce the divergence-free condition because the divergence of a curl vanishes.
// Target: fluid-mechanics.bigb
For an isolated solenoidal magnetic field, zero flux through every sphere removes the degree-zero spherical harmonic of . In a poloidal-toroidal decomposition, let . The spherical poloidal component obeysIf , put . The two sides of the bound are respectively and . Since , the bound follows, with equality for degree-one radial scalars. Together with the radial-flow dynamo energy bound it gives for a marginal or growing dynamo field.
// Target: fluid-mechanics.bigb
A scalar function on Euclidean space is spherically symmetric when it depends only on the distance from a fixed center.
If a helicity density evolves as a sum of directional derivatives along divergence-free fields tangent to the boundary, its volume integral is conserved because both terms become vanishing boundary fluxes.
For in Cartesian coordinates,
For a continuously differentiable vector field, the divergence is the limiting outward flux per unit volume through a small closed surface. Opposite faces of a small rectangular box almost cancel; the remaining differences in the three components give the sum of partial derivatives above. The divergence theorem extends this local balance to a whole region.
For , the divergence is . In a planar unit square, the right edge contributes outward flux and the top contributes , while the left and bottom contribute zero. The total equals the integral of the planar divergence over area .
If is a velocity field, positive divergence means local volume expansion, not automatically creation of mass. The continuity equation gives , where is the material derivative. For this field, a uniform initial density evolves as while material volumes grow as . Their product stays constant.
Horizontal flow convergence is the negative horizontal divergence of a velocity field. Positive convergence reduces the horizontal area of a material patch; for constant-depth linear shallow water equations, the surface equation is , so convergence raises the free surface and divergence lowers it. This is a fluid-flow notion, distinct from convergence of a numerical sequence.
The divergence defined through weak derivatives: pair a locally integrable vector field with a smooth compactly supported test function using the displayed integration-by-parts identity. A piecewise smooth field can have a surface contribution where its normal component jumps. Thus zero classical divergence on each side does not imply zero weak divergence across the interface.
The divergence with respect to velocity coordinates, with position held fixed. In dimensions, has . A kinetic conservation law must retain this term for velocity-dependent forces.
For the Levi-Civita connection of a Riemannian metric, the divergence of is . In coordinates it equals . On an oriented manifold it satisfies . The codifferential on a one-form satisfies , where is the musical isomorphism; this follows by integration by parts or the Hodge star formula.
For a vector field directed radially from a fixed axis and depending only on distance from that axis, cylindrical coordinates give . Zero divergence gives on any positive radial interval. Unless , this field is singular on the axis, so applications of the divergence theorem must use a domain avoiding it or account separately for that singularity.
For a locally integrable vector field, this formula defines its divergence as a distribution. For a piecewise smooth field, a jump of its normal component across an interface adds a surface measure to the smooth divergences. A continuous normal component eliminates that measure, as follows by integration by parts on the two sides.
The inverse-square radial vector field has zero ordinary divergence at every nonzero radius but flux through every centred sphere. It is locally integrable in three dimensions. For a smooth compactly supported test function , integrate by parts outside a ball of radius . The inward-oriented inner boundary gives , which tends to . This proves the displayed distributional divergence, with the three-dimensional Dirac delta function representing the point source.
For ,
A total divergence has the form . The divergence theorem converts its volume integral into a boundary flux, which vanishes when the field has suitable decay or boundary conditions.
Adding to a mechanical Lagrangian changes its action by . Fixed endpoint variations therefore leave its bulk Euler-Lagrange equations unchanged. For fields, adding changes the action by a boundary flux. The same conclusion holds for compactly supported variations or appropriate fixed boundary data. If depends on field derivatives, those boundary data must also control their variations. Such terms can still change canonical momenta, boundary observables, and representatives of Noether currents; equivalence of bulk equations does not mean that every boundary-value problem is identical.
For a twice continuously differentiable vector field, commuting partial derivatives and antisymmetry of the Levi-Civita symbol give
For a continuously differentiable vector field in three-dimensional Euclidean space, the component of its curl along a unit normal vector is the limiting circulation per unit area around a small loop in the perpendicular plane. The loop direction and the normal obey the right-hand rule. Stokes theorem gives the corresponding relation for a finite surface.
For the rigidly rotating velocity field , direct differentiation gives . A circle of radius has tangential speed and circumference , so its circulation is , twice the angular velocity times the enclosed area. The factor of two distinguishes vorticity from rigid-body angular velocity.
Curved integral curves alone do not demonstrate nonzero curl. The field has zero curl, yet its trajectories satisfy , and hence : away from the axes they are hyperbolas. The curl measures local circulation of the field, not the curvature of an individual trajectory.
The divergence theorem applied to for every constant vector gives , with outward unit normal . Indeed , while . Equality of the scalar projections for every proves the vector identity. Reversing the surface cross product reverses the sign.
For a continuously differentiable scalar field and vector field , the curl satisfiesIndeed, with fixed Cartesian basis vectors , the Cartesian expression for the curl and the product rule giveThe first sum is the cross product of the gradient of with ; the second is times the curl of . The formula is useful when applying the Stokes theorem to a weighted vector field.
For a twice continuously differentiable function, the curl of its gradient vanishes. In components, because the second derivatives are symmetric in while the Levi-Civita symbol is antisymmetric. Thus adding a gradient to a vector potential preserves the represented curl. No topological assumption is needed for this identity, unlike the converse assertion that every curl-free vector field has a global potential.
A continuously differentiable vector field on an open subset of three-dimensional Euclidean space is irrotational when its curl is zero. Under the Euclidean identification , this says that the differential one-form is a closed differential form. The Poincaré lemma gives a potential of a conservative vector field locally. A global potential additionally requires zero line integrals around every closed curve; simply connected domains ensures this. On the punctured plane extended in the third direction, has zero curl but integral around a circle, so it is locally conservative and has no single-valued global potential.
A vector potential for a divergence-free vector field is a vector field satisfying . It is not unique because adding a gradient leaves its curl unchanged.
Let be bounded, connected and simply connected, and let be a smooth divergence-free field. Suppose a sufficiently smooth vector field satisfies the displayed Poisson and boundary conditions. Divergence gives with zero boundary value, so harmonic uniqueness gives . The vector Laplacian identity then implies .
On a simply connected domain, define a scalar potential by integrating this curl-free difference along a path from a fixed point. Vanishing circulation around contractible loops proves path independence. Thus the difference is ; its divergence and boundary normal component give and . Green's identity yields , proving the reconstruction. Additional conditions on can specify its own boundary problem; the argument assumes its existence and proves that its curl is exactly . Simple connectivity is essential for eliminating possible non-gradient harmonic circulation fields.
Let be a continuously differentiable solenoidal vector field on an open star-shaped set containing the origin. Thenis a vector potential for . For , differentiation gives and . Boundedness near the origin removes the lower endpoint. A field defined only on a punctured domain need not satisfy these hypotheses.
The Laplacian takes the divergence of a scalar field's gradient. For a real-valued function on an open region of Euclidean space, with continuous partial derivatives through order two, its expression in a Cartesian coordinate system isThus the Laplacian, also called the Laplace operator, adds the coordinate second derivatives; equivalently it is the matrix trace of the Hessian matrix. Its output is another scalar field.[ref]
The Feynman Lectures on Physics, Volume II by Richard Feynman and others. Volume II, §2–7, equations 2.52–2.54: divergence of a gradient and the Cartesian Laplacian
Three original examples distinguish shape from this sum. The bowl has . The saddle instead has : opposite second derivatives cancel. It is a harmonic function, although its graph of a function is not a plane. For the Gaussian function , with , differentiation givesIts Laplacian is negative inside the circle of radius one, zero on that circle, and positive outside it. The Gaussian function itself is positive throughout: its value and its Laplacian describe different properties.
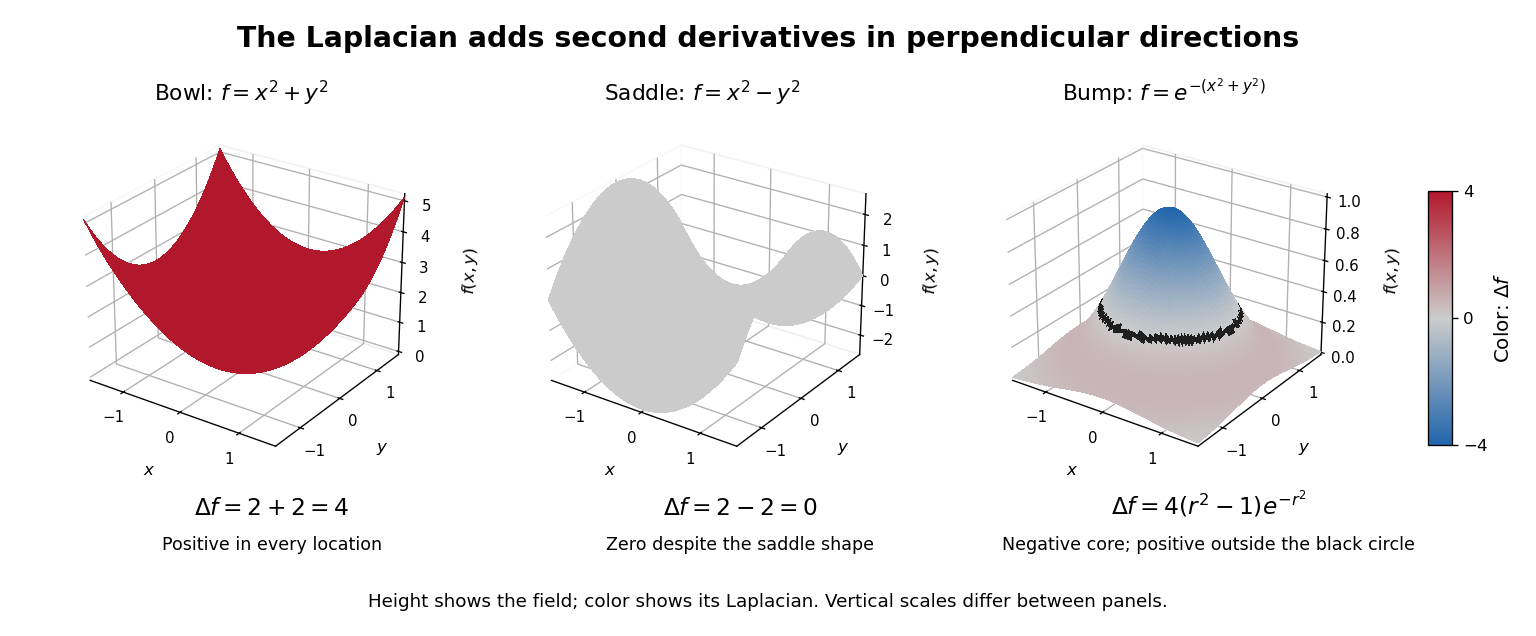
The sum does not favor a particular orientation. Under a change of Cartesian coordinate system represented by an orthogonal matrix , the Hessian matrix becomes . The cyclic property of the trace and preserve its matrix trace. This makes the Laplacian useful when the behavior depends on spatial differences equally in every direction, rather than on the arbitrary choice of axes.
For a vector field, the Euclidean Laplacian acts separately on components expressed in a fixed Cartesian coordinate system. Components in a position-dependent basis require differentiating that basis too; applying a scalar formula separately to polar components omits those terms.[ref]
The Feynman Lectures on Physics, Volume II by Richard Feynman and others. Volume II, component formula following equation 2.54 and final paragraph of §2–8: fixed rectangular components
The scalar formula in Laplacian in polar coordinates is valid away from ; smoothness at the origin must be handled in coordinates that remain regular there.For a constant orthogonal matrix , the Laplacian is unchanged by the coordinate transformation . If is twice continuously differentiable, the chain rule givesbecause by orthogonality of the rows. Here is the Kronecker delta. In two dimensions, the rotation matrix with makes the mixed partial derivatives cancel explicitly. The same argument works for reflections and translations, so the Laplacian depends on the Euclidean geometry rather than the orientation or origin of the coordinates.
The Laplacian detects whether a value lies below or above nearby values, to second order. For a scalar field whose partial derivatives through order four are continuous functions, take the arithmetic mean of four equally spaced neighbors:Applying Taylor's theorem in each coordinate cancels the first- and third-order terms between opposite neighbors. The two pairs leaveThis is an asymptotic expansion, rather than an equality for arbitrary . Rearranging gives the familiar central finite difference approximationThis finite difference replaces partial derivatives by five sampled values. The arithmetic mean lies above the center for a sufficiently small if the Laplacian is strictly positive there, and below if it is strictly negative. A zero Laplacian cancels this second-order discrepancy without requiring equality of individual values.
At , the bowl has center value zero and four neighbor values , so the discrepancy is exactly . The saddle has neighbor values , whose arithmetic mean is exactly zero. For the Gaussian function the discrepancy is , agreeing with .
A harmonic function need not equal this four-neighbor arithmetic mean for a finite . The polynomial has everywhere, but . Higher-order terms remain even when the second-order terms cancel.
At a local minimum, each coordinate second derivative is at least zero, hence the Laplacian is at least zero. At a local maximum the inequality reverses. The sum alone does not characterize an extremum: cancellation at a saddle point of a scalar function can also produce zero. The local-average interpretation explains why the heat equation smooths differences, and helps motivate the heat equation maximum principle.
For diffusion with a constant diffusion coefficient and no sources, the model flux is . A continuity equation gives . This proportionality is a constitutive assumption about transport; the continuity equation expresses conservation. If varies with position, it must remain inside the divergence, giving instead.[ref]
An exact constructed heat equation example on the whole plane uses dimensionless coordinates with and the smooth initial Gaussian function . Set . For ,Direct differentiation verifies both the initial condition andThe center decreases, while the region increases at that instant. The sign-change circle expands with radius . A fixed outer location can initially increase and later decrease as this circle passes it.
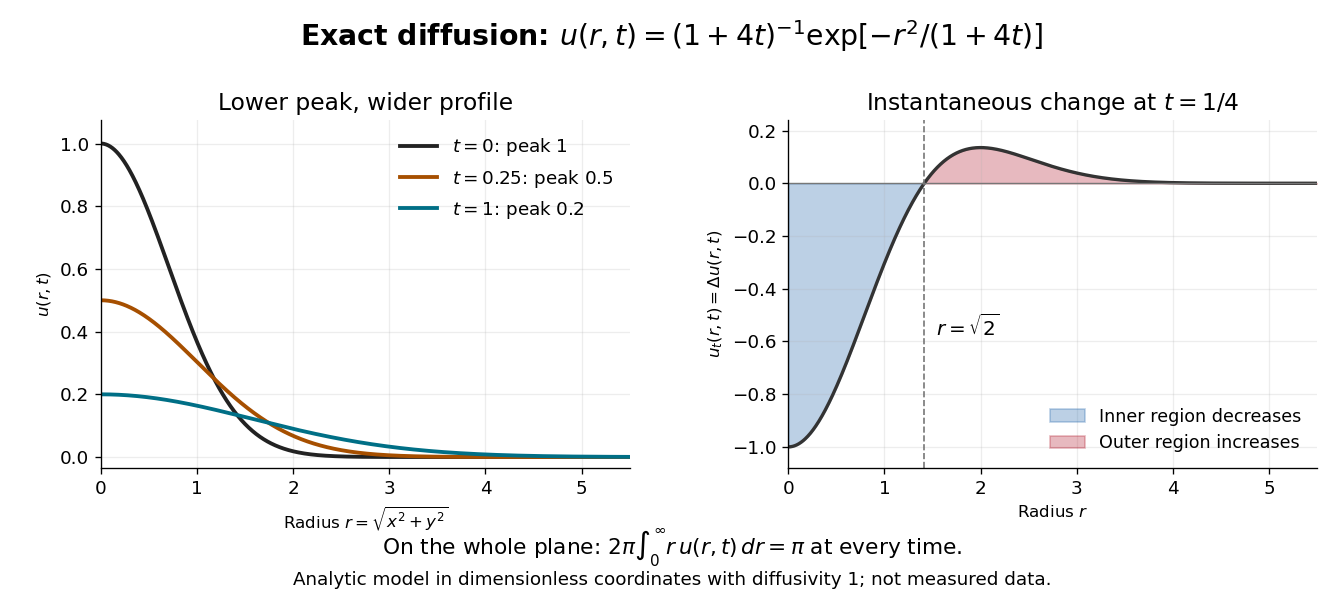
At time , the peak is , and the radius where the profile is times its peak is . The width grows as the height falls. Integration in polar coordinates givesThus a decreasing peak is compatible with a conserved spatial integral. Dividing by makes a probability density function with coordinate variances , connecting the same spreading to Brownian motion with diffusion coefficient one. Equivalently the profile is evolved by the Gaussian heat kernel with time parameter , since that article uses generator .
For , and , set , . The differential operators are and . Applying them twice givesTheir sum is the Laplacian in polar coordinates. The first-derivative terms come from differentiating the coordinate coefficients, as required for second derivatives under a two-variable coordinate change. The origin is excluded from the coordinate formulas, even when the underlying Cartesian function is smooth there.
For twice differentiable scalar fields,
The biharmonic operator applies the Laplacian twice. Under clamped boundary conditions, two integrations by parts give the positive quadratic form
The clamped problem uses the weak solution identity for every in the clamped second-order Sobolev space. For , the clamped Hessian identity and the Poincaré inequality make this a bounded coercive bilinear form. The Lax-Milgram theorem gives a unique weak solution without a mean-zero condition on .
The biharmonic equation is , where the biharmonic operator is the square of the Laplacian. In planar Stokes flow, taking the curl of the momentum equation and using a Cartesian streamfunction produces this equation. Its decaying spatial Fourier series modes have form .
For angular Fourier modes of integer order , the biharmonic equation in polar coordinates has radial basis . Apply the Laplacian twice to obtain the displayed indicial equation. For , repeated roots give the radial basis ; for , the basis is . These are Cauchy-Euler equations. Regularity at the origin and boundary conditions select the admissible powers. For , a constant radial factor still multiplies or , so it is bounded but fails continuity at the origin.
If are holomorphic functions, both real and imaginary parts of solve the biharmonic equation. In Wirtinger derivatives, , so is harmonic and its next Laplacian is zero. This construction gives local representations of planar solutions of the biharmonic equation; it is useful for the biharmonic stream function for planar Stokes flow.
For a smooth three-dimensional biharmonic function regular throughout a ball, its surface average has exactly this form. Taylor expansion and rotationally invariant spherical moments turn each even term into a multiple of an iterated Laplacian; terms from the fourth derivative onward vanish when . This is the mean-value identity that converts the reciprocal surface average into Faxén's first law.
For smooth vector fields ,andBoth follow by contracting two Levi-Civita symbols and applying the product rule.
The displayed vector calculus identity follows by contracting the two alternating tensors in the component formula for curl. If both fields have zero divergence, only the two directional derivatives remain. It rewrites the transport terms in the adjoint linearized Navier-Stokes evolution.
Articles were limited to the first 100 out of 263 total.
Articles by others on the same topic



Multivariable calculus, also known as multivariable analysis, is a branch of calculus that extends the concepts of single-variable calculus to functions of multiple variables. While single-variable calculus focuses on functions of one variable, such as \(f(x)\), multivariable calculus deals with functions of two or more variables, such as \(f(x, y)\) or \(g(x, y, z)\).