Lagrangian mechanics derives motion from the stationary action of through the Euler--Lagrange equations.
A massless fixed-axis pulley carries a rim point mass at radius . A mechanical string gripping its rim without slipping passes over a fixed guide pulley to a hanging mass . Choose the angle from downward vertical so the hanging mass descends by . The Lagrangian is . The stable equilibrium satisfies with , and exists for . Its small-amplitude angular frequency is .
An inextensible uniform chain of length L and linear mass density links a mass m sliding on a frictionless table to a hanging mass M. If the initial hanging chain length is zero and x is its subsequent hanging length, all moving material has speed . The kinetic energy is , while the gravitational potential energy is . The Euler-Lagrange equation gives the displayed equation until a mass hits the floor or reaches the edge. Increasing hanging chain weight produces a hyperbolic cosine displacement from rest, rather than uniform acceleration.
Attach the table-end mass to a linear spring of spring constant k. Adding spring potential energy gives restoring curvature about equilibrium. The positive gravitational feedback from increasing hanging chain length subtracts from the spring stiffness. Stable oscillations require ; equality is neutral in this ideal linear model, while gives exponential departure. The frequency is independent of the preload, although the equilibrium position is not.
A reduction of Lagrangian mechanics that fixes conserved momenta of cyclic coordinates while keeping an Euler-Lagrange description for the remaining coordinates. It is named for Edward Routh. The Routhian applies a partial Legendre transform to the eliminated velocities.
Use the convention for the eliminated cyclic coordinates, expressing their velocities in terms of their fixed conjugate momenta. Terms involving derivatives of those eliminated velocities cancel because . Thus the remaining coordinates obey the usual Euler-Lagrange equations for R. For a particle of fixed angular momentum in a central potential, this gives , rather than the expression obtained by direct substitution into L alone. An opposite overall sign convention is also used, with correspondingly signed mixed Hamiltonian equations.
For a Lagrangian , its energy function satisfies along the Euler-Lagrange equations. This follows by differentiating and cancelling the terms. It is conserved when has no explicit time dependence. For imposed moving constraints it need not coincide with inertial mechanical energy; a Jacobi integral is an important example.
For a uniform slender ladder of length sliding while touching a smooth wall and floor, use its angle from the vertical. Its centre of mass is and its central moment of inertia is . Hence the Lagrangian is , and its Euler-Lagrange equation is . The contacts are physically possible only while their normal forces are nonnegative. If released from rest at , energy conservation gives , and the wall force becomes . Contact is lost at , after which the constrained equation no longer describes the motion.
A point mass attached to a massless straight spring can change its radial distance from a fixed support while swinging in a vertical plane. Its lower equilibrium length is . Linearizing the Euler-Lagrange equations there gives independent radial and angular normal modes with squared angular frequencies and . The formal upper stationary state has and exists in positive-length coordinates only when ; its angular mode is unstable.
A tabletop mass joined through a hole by a massless inextensible string of length to a hanging mass has radial inertia and conserved angular momentum . The radial energy is , with . Its effective potential diverges at the hole for and has a unique minimum at . Since , small radial oscillations at fixed have squared angular frequency .
An Atwood machine couples two hanging masses by an inextensible mechanical string over a pulley. With ideal massless hardware, Newton's second law gives the downward acceleration of the heavier mass as . To prove it, write and , then add. The apparatus associated with George Atwood turns a small difference of weights into slow, measurable acceleration.
Two initially equal buckets of total mass share an ideal Atwood machine. If one loses sand at constant rate and the sand leaves with zero initial velocity relative to that bucket, the leakage supplies no rocket thrust. The remaining masses satisfy for upward velocity of the leaking side. Using and integrating from rest gives .
If the initial sand fraction is , emptying occurs at . This gives the displayed speed, which tends to zero for and to for . The latter is a finite limiting result, not a physical claim about an exactly massless empty bucket. The derivation is an application of a variable-mass system, rather than of for a closed body.
A compound Atwood machine replaces one hanging mass by another pulley carrying two masses. Let the upper mechanical string carry mass opposite the moving pulley, and let the lower mechanical string carry masses at upward heights . The length constraints on the mechanical strings give the height of as up to a constant. Thus its Lagrangian isThis follows by adding the three kinetic energies and subtracting their gravitational potential energies. Constant coordinate shifts annihilating the linear potential energy give conserved generalized momentum components by Noether's theorem.
For a mechanical system whose imposed motion is uniform rotation with angular velocity about a fixed axis, a conserved rotating-frame energy can exist even when the inertial mechanical energy changes. With angular momentum about that axis, it is . For a bead constrained to rotate with , this becomesFor in uniform gravity, division by mass yieldsThis is the first integral that controls the bead's radial motion. Different normalizations and signs are used for the related Jacobi constant in celestial mechanics.
For a pendulum whose support slides without horizontal force, the support coordinate is cyclic and total horizontal momentum is conserved. At zero horizontal momentum, eliminating support velocity leaves the displayed angle-dependent effective inertia. The energy is . Fixing the momentum before evaluating motion is distinct from fixing the support position.
Zero horizontal momentum fixes the horizontal centre of mass. The bob coordinates become and . Eliminating the angle gives an ellipse; an ordinary oscillation traverses only its permitted arc. The support counter-moves, so the bob's path differs from the circle about a fixed pivot.
A Lagrangian is degenerate when its Hessian with respect to velocities is singular. The momentum–velocity relation then cannot be inverted for every velocity. Some Euler–Lagrange equations can become algebraic constraints rather than independent second-order equations. A massless limit can produce this behaviour; disappearance of an equation at quadratic order does not establish an unconstrained mode of the exact nonlinear model.
A uniformly charged circular ring hasHere is the spring constant for extension of its full circumference and the symmetric gauge is used. The canonical angular momentum is conserved. Eliminating the angle gives . This model neglects electric self-interaction and noncircular deformation.
For negligible natural radius and release from rest at , . The effective radial potential is a sum of and terms, whose two turning radii have squared product . HenceThese formulas assume . At exactly zero field the ideal ring collapses to zero radius instead of making a regular positive-radius turning point.
With , define and . Then , the radial frequency is , and release at gives with . The physical solution requires . If , the formal oscillation reaches zero and cannot be continued as a negative ring radius without a new collapse model.
Although the energy in velocities is , the Hamiltonian in canonical variables isThe field therefore enters Hamilton's equations through the relation between canonical and mechanical momentum, even though a magnetic field does no work.
A constraint that depends explicitly on time can exert a normal force that does actual work, even when its force does no work on an allowed instantaneous virtual displacement. The surface motion gives the constrained particle a normal component of actual velocity.
A point mass attached to a massless rotating hoop of radius is connected by a taut string wrapping around the hoop to a vertically suspended mass . Measure from the downward radius toward the string's tangency side. The wrapped length decreases by , so the suspended mass descends by the same amount. Therefore and up to a constant. The Euler-Lagrange equation gives the displayed equation. For , the stable equilibrium has , and the small-oscillation angular frequency is . When , the system approaches a simple pendulum of length .
A generalized coordinate is one of a set of independent parameters specifying the configuration of a mechanical system subject to its constraints. An angle locates a bead constrained to a fixed circular hoop. Expressing kinetic energy and potential energy in these coordinates gives the Lagrangian and its Euler-Lagrange equations.
The time derivative of a generalized coordinate. It is an independent velocity argument of a mechanical Lagrangian, but need not have the units or direction of a Cartesian velocity: for an angular coordinate it is an angular velocity. A regular Legendre transform replaces these variables with the corresponding canonical momenta.
A regular Lagrangian defines a fibre derivative and the Cartan one-form . Its two-form is nondegenerate when the velocity Hessian is invertible. The energy is . The equation determines the Euler–Lagrange vector field. A hyperregular Lagrangian makes the fibre derivative a global diffeomorphism and transports this dynamics to Hamiltonian phase space.
A potential is invariant under the screw transformation . The Noether conserved quantity for a mechanical point symmetry isa linear combination of axial linear momentum and axial angular momentum.
A generalized coordinate absent from the Lagrangian is cyclic. Its conjugate generalized momentum is conserved by the Euler-Lagrange equations.
The action of a path is the time integral of its Lagrangian. The principle of stationary action requires its first variation to vanish for every admissible fixed-endpoint variation.
The principle of stationary action says that the physical path between fixed endpoints is a stationary point of the action.
Replacing a Lagrangian byadds only the endpoint term to the action. Fixed-endpoint variations therefore give the same Euler--Lagrange equations.
For electromagnetic scalar and vector potentials and ,Withthe Euler--Lagrange equations give the Lorentz force , while the canonical momentum is .
Under and , the charged-particle Lagrangian changes byIt therefore has unchanged equations of motion by total-time-derivative invariance.
For a constant uniform magnetic field , choose the symmetric gauge . The coordinate parallel to is cyclic, so its canonical momentum is conserved. Since , this component is also the mechanical momentum .
In Lagrangian mechanics, the coordinate variable describes the configuration; its conjugate momentum need not equal the Cartesian mechanical momentum.
A coordinate is ignorable, or cyclic, when . The Euler--Lagrange equation then gives , so its generalized momentum is conserved.
If a Lagrangian is independent of a coordinate, the conjugate momentum to that coordinate is conserved by the Euler--Lagrange equations.
If and depends only on and , then rotations about the axis leave invariant. The quantity supplied by Noether theorem is the axial angular momentumIf also has no explicit time dependence, the energy is conserved independently.
A double pendulum consists of two pendula coupled because the second pivot moves with the first mass. It has two degrees of freedom: even when the upper pivot is fixed, moving the upper arm carries the lower pivot along. This makes the double pendulum a compact example of how mechanical constraints couple motion, and how Lagrangian mechanics converts geometry into dynamics.
Use two equal point masses and two massless rigid rods of equal length , with joints that allow free rotation in one vertical plane. The upper pivot is fixed; gravity is uniform, with gravitational acceleration . Neglect joint friction and drag force. Both angles are measured from the downward vertical, positive toward the right, in radians. In particular, is an absolute angle, not the bend between the rods: that bend is .
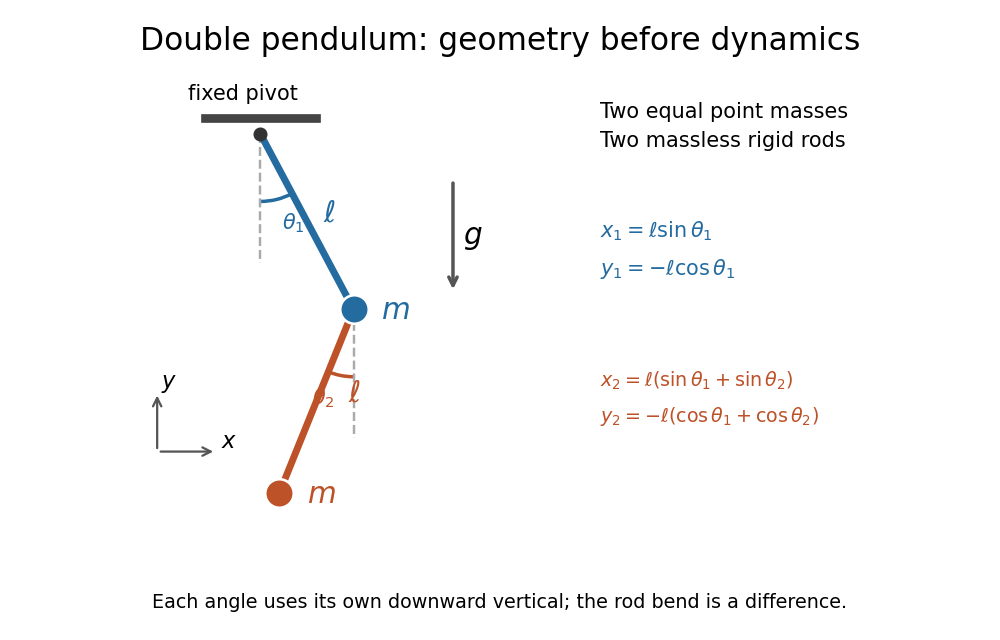
Equal point masses and massless rods: both angles are measured from the downward vertical
. Original diagram of the ideal double pendulum. Dashed vertical lines are the separate references for and ; the lower position vector is the sum of the two rod vectors. The drawn angles illustrate geometry, rather than the small-angle approximation. Details.The double pendulum Lagrangian below gives the exact dynamics of this ideal model. Near the downward stable equilibrium, normal modes of a double pendulum replace the coupled motion with two independent harmonic oscillators. Their fixed amplitude ratios explain which releases make the rods swing together and which make them swing in opposite directions.
With equal rod lengths and absolute downward-vertical angles , the endpoint separation is . A zero-rest-length spring between the fixed support and the final mass contributes to the Lagrangian. It favours bending away from maximum extension and can reduce the gravitational bending stiffness.
Choose Cartesian coordinates with origin at the upper pivot, to the right and upward. The two position vectors areThese expressions satisfy the rod holonomic constraints and automatically. This is the practical advantage of using the two angles as coordinates: the rod tensions need not be unknowns in the motion calculation.[ref]
Classical Dynamics by David Tong. Classical Dynamics, chapter 2, §2.3, printed pp. 17–19: elimination of ideal constraint forces using coordinates adapted to holonomic constraints
Differentiate these position vectors to obtain the velocities. The dot product between their two rod contributions uses , givingAdding the two kinetic energies and measuring gravitational potential energy from the downward equilibrium givesThe coefficient has a geometric meaning: the upper rod raises both masses, and its motion contributes to both kinetic energies. The coupling in is present because the lower mass has a moving pivot. The zero chosen for changes by a constant and leaves the Euler-Lagrange equations unchanged.[ref]
Classical Dynamics by David Tong. Classical Dynamics, chapter 2, §2.5.2, printed p. 28, equations (2.68)–(2.72): general point-mass double pendulum; the derivation here specializes to equal masses and lengths and uses upward
The principle of stationary action applies to . Its fixed-endpoint first variation, after integration by parts, isIndependent allowed variations therefore give one Euler-Lagrange equation for each angle. Stationary action alone does not assert a minimum.[ref]
Write . Applying the Euler-Lagrange equations to the double pendulum Lagrangian, then dividing by , givesFor example, the upper generalized momentum is . Its time derivative contains . Subtracting cancels the mixed product and leaves the positive term in the first equation. This cancellation is a useful check on the sign convention.
The matrix multiplying the two angular accelerations isIt is invertible for every configuration, so specified angles and angular velocities determine both angular accelerations. For the same reason whenever the angular velocities are not both zero. The mass cancels from the motion equations, while the timescale is set by .
As an exact constructed release, put , , and both angular velocities zero. Solving the two equations at release yieldsFor , the upper rod initially moves back toward vertical, while the lower rod initially moves away from it. The lower pivot's acceleration makes this possible even though the lower rod starts vertical. The small-angle approximation gives and .
The conserved mechanical energy is , because the Lagrangian has no explicit time dependence. Directly, is times the first equation multiplied by plus the second multiplied by , so the equations imply . This also supplies a check when computing a trajectory.
The University of Toronto's institutional demonstration “Chaotic Behaviour (Double Pendulum)”, activity Me-020, uses a metal stand with four leveling feet and a pendulum arm carrying a white dot. Preparation includes leveling the stand and correcting any wobble. The instructions call for holding the arm vertically upward and releasing it; the readout is the visible motion of the dot. A further comparison inserts a metal dowel in a groove on the release arm and repeats the release at the same location. Keeping the stand steady and repeating the release position provide practical controls. The page supplies no numerical angle trace or calibrated timing, and does not explain the dowel's mechanical effect. It therefore documents a qualitative release demonstration, without quantitatively testing the equal-point mass model. Its extended arms also have moments of inertia absent from massless rods. Irregular visible motion alone does not establish sensitive dependence on initial conditions.[ref]
Chaotic Behaviour (Double Pendulum) (University of Toronto Department of Physics). Chaotic Behaviour (Double Pendulum), activity Me-020, Description: leveling, vertical release, white-dot readout, dowel insertion and repeated release; Apparatus
A separate comparison with normal modes of a double pendulum would require small downward releases and measurement of both angles over time. The actual arm masses, centres of mass and moments of inertia would first have to enter the Lagrangian. The upward release in this demonstration explores a different regime from small oscillations about the downward stable equilibrium.
For point masses with generalized coordinates, kinetic energy follows by differentiating their Cartesian position vectors and summing .
Two frictionless beads of positive masses on a circular hoop are joined by two identical springs of spring constant , constrained to follow the two arcs. At their diametrically opposite equilibrium, each spring has natural length equal to half the circumference. For signed arc length displacements in the same rotational sense, the potential energy is . The normal mode of common rotation has mode shape and zero angular frequency, while the other normal mode has mode shape and the positive angular frequency in the title.
Adding the equations of motion shows that satisfies . Subtracting them gives for . Thus the complete zero mode is , including uniform rotation, and the relative motion is a harmonic oscillator. In the limit at fixed , the oscillatory motion of the heavier bead vanishes for fixed lighter-bead amplitude, and . A common drift still survives if its initial velocity is held fixed.
Four equal beads of mass are connected cyclically by identical springs of stiffness following arcs of a frictionless circular guide. In signed arc displacements , the quadratic Lagrangian is . The stiffness is times the four-cycle graph Laplacian. Its eigenvectors can be chosen as , , , and , with squared frequencies in the title. Their dot products with are decoupled normal mode coordinates. The zero mode is a rigid rotation; the two middle modes span a degenerate eigenspace; the highest mode alternates adjacent arc displacements. Changing the guide radius multiplies angular inertia and angular spring energy by the same factor, leaving these frequencies unchanged.
Near a stable equilibrium with and , the harmonic approximation truncates the Taylor series of the potential energy at quadratic order. With constant mass , Newton's second law then gives a harmonic oscillator with angular frequency . The approximation requires displacements small enough that the omitted terms are negligible; it does not describe a flat minimum where .
If the quadratic kinetic energy has a singular coefficient matrix, some generalized coordinates have no independent linearized inertia. The small oscillation equations can then contain algebraic constraints, and the number of finite normal mode frequencies can be smaller than the number of coordinates. One should use the polynomial without dividing by . Giving a nominally massless component a small mass can restore a high-frequency mode whose frequency diverges as that mass tends to zero.
A cart of mass moves horizontally on a spring of stiffness , carrying a simple pendulum of bob mass and length . Let be cart displacement and the small angle from downward vertical. The quadratic Lagrangian isThe kinetic cross term comes from the bob's horizontal velocity to first order. The generalized eigenvalue problem has mass matrix and restoring matrix . Their characteristic determinant gives the displayed polynomial in . For , the squared angular frequencies are , with mode shapes . The bob and cart move in phase in the lower normal mode and in opposite phases in the higher normal mode.
For a bob of mass on a massless rod of length , let a massless support slide horizontally against a spring of stiffness . With support displacement and angle from downward vertical, the quadratic Lagrangian, divided by , is . Subtracting its two Euler-Lagrange equations gives . There is one finite normal mode, with the displayed frequency. A stiff spring fixes the support and recovers the simple pendulum frequency. The missing second finite frequency reflects a singular kinetic matrix in small oscillations, not an omitted oscillation branch.
Consider three beads of masses on a horizontal hoop, connected in cyclic order by identical springs constrained to follow the arcs. Their common natural length affects only a constant in the potential energy, since the sum of the three arc lengths is fixed. About the equally spaced configuration, angular displacements haveThe generalized eigenvalue problem has the rigid rotation as a zero mode. Exchanging the equal masses separates an antisymmetric normal mode , with squared angular frequency , from a symmetric normal mode , with squared angular frequency . The last mode shape has zero total angular momentum. The hoop radius cancels from both the kinetic energy and the restoring quadratic form. These formulas use arc-constrained springs; straight chord springs have a different potential energy.
For point masses on concentric horizontal rings in parallel planes, set , , and . A spring of zero natural length gives . The inertia-weighted angle separates the Lagrangian into a free common rotor with inertia and a relative rotor with inertia . Static equilibria have or . Their normal modes are the common displacement with zero frequency and the relative displacement with the displayed squared frequency. The aligned family has a restoring relative mode; the antipodal family has an exponentially growing one. The zero mode is required by rotational symmetry. Small nonzero total angular momentum produces common drift, so stability of the aligned family modulo rotations should be distinguished from Lyapunov stability of one fixed equilibrium point.
A uniform rigid body disk of mass and radius moves in a frictionless plane. Let identical springs attach equally spaced rim points to fixed anchors in their radial directions. The equilibrium spring length is , natural length , and spring constant . Write the small centre displacement as and the rotation as . For a spring with radial and tangential unit vectors , its length isThis follows by a second-order Taylor series for the distance between and . In the elastic potential energy , the equilibrium tension multiplies the second-order change of length. Thus it contributes to the linearized stiffness even though the displacement is small.
The equally spaced directions satisfy and . Summing the spring energies givesThe kinetic energy is , using the moment of inertia of a uniform disc. The Euler-Lagrange equations give the displayed squared angular frequencies. The translational normal modes are degenerate; rotation is independent. At zero prestretch the rotational frequency vanishes at quadratic order, and finite-angle spring stretching first contributes at higher order.
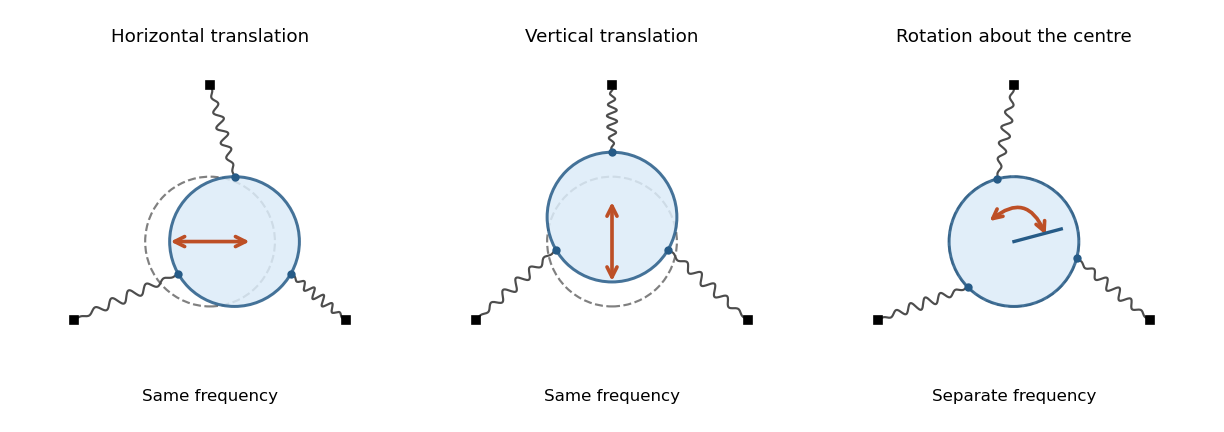
At an equilibrium, a positive-definite Hessian matrix of the potential gives stable small oscillations. If a continuous symmetry supplies zero modes, positive definiteness on the directions transverse to the symmetry gives stability of the relative configuration.
For two masses hung in series from springs of natural length , the lower equilibrium spring tension is and the upper tension is . Hence their equilibrium lengths are
For equal masses and spring constants , vertical displacements from equilibrium have stiffness and mass matricesThe two squared frequencies and displacement ratios areGravity shifts the equilibrium but does not enter these vertical frequencies.
The Hessians of kinetic and potential energy at equilibrium give the symmetric mass matrix and stiffness matrix .
The Hessian of potential energy at an equilibrium. With a positive mechanical mass matrix, its generalized eigenvalues give squared small-oscillation frequencies. Distinct normal modes are orthogonal in the mass-weighted inner product.
The symmetric coefficient matrix of kinetic energy to second order in generalized velocities. For independent horizontal point-mass coordinates it is diagonal, with the particle masses on the diagonal. Together with the mechanical stiffness matrix it gives the generalized eigenvalue problem for small oscillations.
Three equal point masses move in a plane and are connected pairwise by ideal springs of equal positive stiffness . At an unstretched equilateral triangle equilibrium, let be the vertex positions relative to the centre, and let be small displacements. If , the quadratic potential energy is , and the kinetic energy is .
There are three independent zero-frequency motions: two common translations and the infinitesimal rigid rotation , where . The uniform radial motion is the breathing normal mode, with . The two shear modes are and , each with .
For a compact proof of the spectrum, form the matrix taking the six displacement components to the three first-order spring extensions, orienting the three edges cyclically. Its row norms squared are two, and every pair of rows has inner product . Thus , with eigenvalues . The nonzero eigenvalues of are the same, so the stiffness matrix has the three positive values in the title and a three-dimensional kernel of a linear map. The three rigid motions span that kernel. A zero mode has time factor rather than a nonconstant periodic oscillation.
A horizontal bar of mass hangs from a spring of incremental stiffness , and two equal masses hang separately from the bar through springs of stiffness . The bar remains horizontal and all motion is vertical. For physical displacements from the loaded equilibrium, the kinetic energy and quadratic potential energy areGravity determines the static extensions; its linear terms cancel at equilibrium. Exchange of the lower masses splits the normal modes into the antisymmetric mode with , and two symmetric modes . The latter obey and . Their determinant gives the title quadratic in , and . For , their squared angular frequencies are , with displacement ratios respectively. The lower symmetric mode moves all masses in phase; the higher one moves the lower pair against the bar.
Let three equal masses move vertically, with one spring of stiffness attaching mass 1 to a fixed support and two further springs of the same stiffness attaching masses 2 and 3 separately to mass 1. For absolute downward displacements from equilibrium, the small-oscillation mass and stiffness matrices areThe normal modes haveExchange symmetry of the two lower masses gives the antisymmetric mode with mass 1 stationary. In the symmetric sector, put ; the reduced equations give , producing the remaining two frequencies. The lower mode moves all masses in phase; in the higher mode the lower pair moves against the upper mass.
Using individual rope-length changes instead gives . In those generalized coordinates and . Mode amplitudes must therefore be identified as physical displacements or rope-length changes before interpreting them. The model assumes taut elastic elements and small vertical motion; gravity shifts the equilibrium extensions.
For three collinear masses , with , , connected consecutively by two springs of stiffness and with free ends, let denote displacements from an equilibrium. The kinetic energy and potential energy are , , whereThe generalized eigenvalue problem for small oscillations hasDirect substitution verifies each pair; the three distinct eigenvalues exhaust the three-dimensional problem. The zero normal mode translates the complete system without extending either spring. The second holds the middle mass fixed while the end masses move oppositely. The third moves the end masses together and the middle mass oppositely, leaving the centre of mass fixed.
For mass-matrix orthogonality of normal modes, the squared norms are respectively , and . Dividing each shape by its corresponding square root gives . The general motion is a linear combination of the two oscillatory modes and ; the latter describes free translation with constant velocity.
For end masses , central mass and two equal springs of stiffness , use the normal modes , and . Their squared frequencies are , and . The prescribed velocity decomposes asThusThe zero mode is a uniform center-of-mass motion, with conserved total momentum and velocity . The other two modes have fixed centre of mass. Dividing their velocity coefficients by their nonzero frequencies gives the sinusoidal displacement amplitudes; for the zero mode the correct time dependence is linear rather than a bounded sine. This distinguishes translation of the complete system from its internal vibration.
For symmetric stiffness matrix and positive-definite mass matrix , eigenvectors ofwith distinct squared frequencies satisfyThus normal modes are orthogonal in the kinetic-energy inner product.
For equal lengths and mass ratio , the squared angular frequencies are , where is the upper mass, the lower mass, and . The equal-mass case admits particularly simple mode shapes.
Use the ideal model of the double pendulum, with both angles measured from the downward vertical. Around , the Taylor expansions and give the quadratic LagrangianHere both angles and their angular velocities are counted as small. Consequently the correction to is fourth order and does not enter . The Euler-Lagrange equations give . The mass matrix is not diagonal: an angular motion of the upper rod carries the lower mass too.[ref]
Classical Dynamics by David Tong. Classical Dynamics, chapter 2, §2.6.1, printed pp. 41–42, equations (2.130)–(2.132): equal-mass, equal-length linearized double pendulum
For a normal mode, put with fixed amplitude vector . The resulting generalized eigenvalue problem for small oscillations is . With , its characteristic equation isSolving this quadratic and using the second row, , givesThe lower-frequency normal mode has the rods in phase, with the lower angle times the upper one. The higher-frequency normal mode has opposite signs, corresponding to an oscillation phase difference of . These are ratios of absolute angles. The horizontal displacements are instead and ; their ratios are and respectively. Thus the lower mass moves horizontally opposite to the upper mass in the faster normal mode.
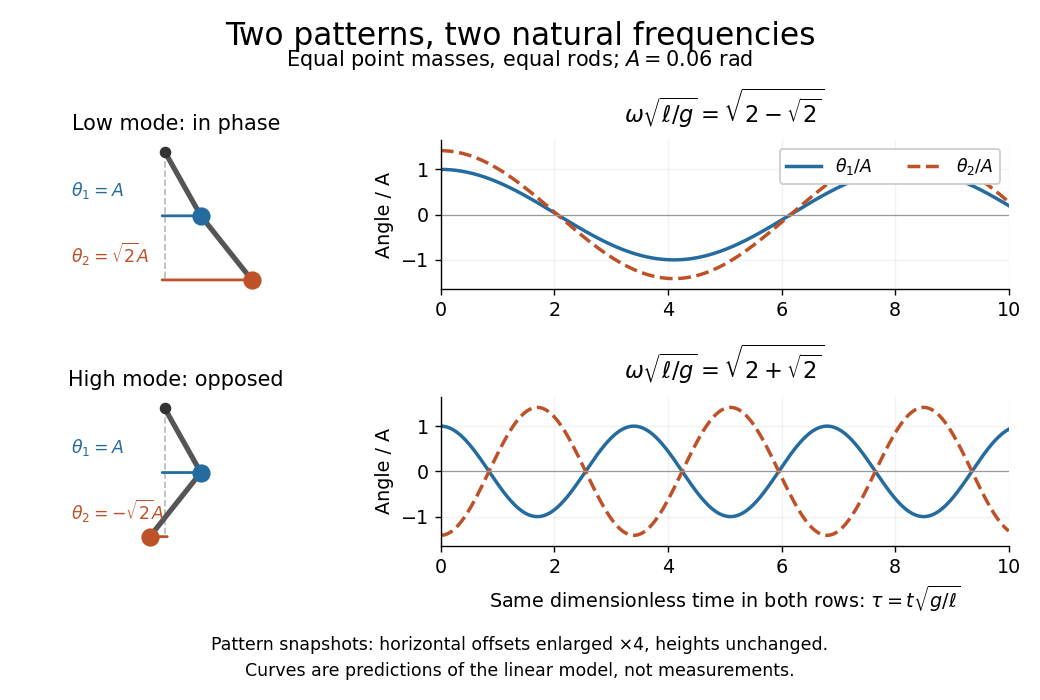
Both squared angular frequencies are positive. Their ratio satisfies , independently of , and . For a constructed model with and , the angular frequencies are approximately and , and the oscillation periods are and . Doubling both masses leaves these unchanged; multiplying both rod lengths by four doubles both oscillation periods.
The eigenvectors are not orthogonal in the ordinary dot product: . They satisfy mass-matrix orthogonality of normal modes, sinceWriting therefore removes the cross terms from both quadratic energies. The two normal coordinates satisfy . This is why the normal modes are useful: one coupled system becomes two independently evolving harmonic oscillators, and any small release can be decomposed into them. At larger angles, the discarded terms in the double pendulum equations of motion matter and this exact linear superposition no longer applies.
For equal point masses and upper/lower massless rods of length , angular coordinates from the downward vertical give mass matrix and stiffness matrix . The generalized eigenvalue problem reduces to , where . The slow mode has angular-amplitude ratio , and the fast mode has ratio .
For equal rod lengths , upper mass and lower mass , use horizontal displacements , at first order. The quadratic kinetic energy is , while the stiffness matrix isThe generalized eigenvalue problem for small oscillations is , not . In particular the lower Euler-Lagrange equation is , independent of the lower mass factor after division by that mass. This reproduces the normal modes of a double pendulum and distinguishes the mechanical mass matrix from its stiffness matrix.
An upper mass and lower mass joined by equal light strings of length have small-angle mass and stiffness matrices and . The squared frequencies are and , with angular eigenvectors and respectively. Equal-angle release decomposes with coefficients and . The angles are measured from vertical, not between strings.
Release the upper rod at radians while keeping the lower rod vertical, , with both angular velocities zero. The initial condition is the sum . The solution from linearization is thereforeAt release the lower angle vanishes by cancellation between the two normal modes. Their different angular frequencies then destroy that cancellation. Differentiating twice gives and , agreeing with the small-angle limit of the exact double pendulum equations of motion.
The quadratic mechanical energy at release is . Each normal mode contributes half, because . Equal coordinate amplitudes need not mean equal energies in general; here the modal inertias and squared angular frequencies happen to compensate. Releasing instead along or , with zero angular velocities, excites just one normal mode.
A weakly coupled degenerate pair can split by order when the small parameter enters a singular mass or stiffness matrix.
If the mass and stiffness matrices commute with a permutation representation, each symmetry subspace is invariant under the generalized eigenvalue problem for small oscillations. On an irreducible subspace, Schur lemma forces a commuting operator to be scalar, producing a degenerate normal mode multiplet.
Connect every pair among moving scalar coordinates and one fixed coordinate by identical springs of stiffness . The coupling pattern is the complete graph with one vertex fixed. Its potential energy is . The moving-coordinate stiffness matrix is the principal submatrix displayed in the header. For equal masses , the uniform normal mode has squared angular frequency , while every sum-zero vector has squared angular frequency . There are such degenerate modes. This follows directly from the Laplacian spectrum of a complete graph and its rank-one matrix form. Constant gravitational forces shift the equilibrium without changing the stiffness.
For two masses, connect each to a fixed anchor and to the other mass with equal stiffness . Set to choose units. The squared angular frequencies have characteristic equation . Requiring a frequency ratio of two means that these roots are and . Their sum and product give , yielding the two reciprocal ratios in the header. Restoring units multiplies all squared frequencies by , leaving the permitted mass ratios unchanged. The term octave refers here only to this two-to-one ratio.
Let three equal masses move on a circle of radius , and let the potential be with . At equal spacing , angular displacements have a zero-frequency rigid-rotation mode and a two-dimensional sum-zero eigenspace withThe two vibrational modes are degenerate by the permutation symmetry.
For three unit masses with unit springs between every pair and one unit spring anchoring each mass to the origin,where is the all-ones matrix. The collective mode has angular frequency , while the two-dimensional sum-zero subspace has angular frequency .
For equal masses , wall-spring constants , and coupling-spring constant , the small-oscillation mass and stiffness matrices areIf , , and , the squared normal frequencies are
For two equal masses with equal wall springs released with displacements , their second displacement is , where is the mean of the two positive normal mode frequencies and their difference. The first nonzero time with is a fast turning point, not the slow maximum of its beat envelope. With , writing gives . Thus , using the first root of in . The envelope instead first reaches its maximum at .
Articles by others on the same topic

Lagrangian mechanics is a formulation of classical mechanics that uses the principle of least action to describe the motion of objects. Developed by the mathematician Joseph-Louis Lagrange in the 18th century, this approach reformulates Newtonian mechanics, providing a powerful and elegant framework for analyzing mechanical systems.



Originally it was likely created to study constrained mechanical systems where you want to use some "custom convenient" variables to parametrize things instead of global x, y, z. Classical examples that you must have in mind include:lagrangian mechanics lectures by Michel van Biezen (2017) is a good starting point.
- compound Atwood machine. Here, we can use the coordinates as the heights of masses relative to the axles rather than absolute heights relative to the ground
- double pendulum, using two angles. The Lagrangian approach is simpler than using Newton's laws
- two-body problem, use the distance between the bodies
When doing lagrangian mechanics, we just lump together all generalized coordinates into a single vector that maps time to the full state:where each component can be anything, either the x/y/z coordinates relative to the ground of different particles, or angles, or nay other crazy thing we want.
Then, the stationary action principle says that the actual path taken obeys the Euler-Lagrange equation:This produces a system of partial differential equations with:
- equations
- unknown functions
- at most second order derivatives of . Those appear because of the chain rule on the second term.
The mixture of so many derivatives is a bit mind mending, so we can clarify them a bit further. At:the is just identifying which argument of the Lagrangian we are differentiating by: the i-th according to the order of our definition of the Lagrangian. It is not the actual function, just a mnemonic.
Then at:
- the part is just like the previous term, just identifies the argument with index ( because we have the non derivative arguments)
- after the partial derivative is taken and returns a new function , then the multivariable chain rule comes in and expands everything into terms
However, people later noticed that the Lagrangian had some nice properties related to Lie group continuous symmetries.
Basically it seems that the easiest way to come up with new quantum field theory models is to first find the Lagrangian, and then derive the equations of motion from them.
For every continuous symmetry in the system (modelled by a Lie group), there is a corresponding conservation law: local symmetries of the Lagrangian imply conserved currents.
Genius: Richard Feynman and Modern Physics by James Gleick (1994) chapter "The Best Path" mentions that Richard Feynman didn't like the Lagrangian mechanics approach when he started university at MIT, because he felt it was too magical. The reason is that the Lagrangian approach basically starts from the principle that "nature minimizes the action across time globally". This implies that things that will happen in the future are also taken into consideration when deciding what has to happen before them! Much like the lifeguard in the lifegard problem making global decisions about the future. However, chapter "Least Action in Quantum Mechanics" comments that Feynman later notice that this was indeed necessary while developping Wheeler-Feynman absorber theory into quantum electrodynamics, because they felt that it would make more sense to consider things that way while playing with ideas such as positrons are electrons travelling back in time. This is in contrast with Hamiltonian mechanics, where the idea of time moving foward is more directly present, e.g. as in the Schrödinger equation.
Genius: Richard Feynman and Modern Physics by James Gleick (1994) chapter "The Best Path" mentions that Richard Feynman didn't like the Lagrangian mechanics approach when he started university at MIT, because he felt it was too magical. The reason is that the Lagrangian approach basically starts from the principle that "nature minimizes the action across time globally". This implies that things that will happen in the future are also taken into consideration when deciding what has to happen before them! Much like the lifeguard in the lifegard problem making global decisions about the future. However, chapter "Least Action in Quantum Mechanics" comments that Feynman later notice that this was indeed necessary while developping Wheeler-Feynman absorber theory into quantum electrodynamics, because they felt that it would make more sense to consider things that way while playing with ideas such as positrons are electrons travelling back in time. This is in contrast with Hamiltonian mechanics, where the idea of time moving foward is more directly present, e.g. as in the Schrödinger equation.
And partly due to the above observations, it was noticed that the easiest way to describe the fundamental laws of particle physics and make calculations with them is to first formulate their Lagrangian somehow: S.
TODO advantages:
- physics.stackexchange.com/questions/254266/advantages-of-lagrangian-mechanics-over-newtonian-mechanics on Physics Stack Exchange, fucking closed question...
- www.quora.com/Why-was-Lagrangian-formalism-needed-in-the-presence-of-Newtonian-formalism
- www.researchgate.net/post/What_is_the_advantage_of_Lagrangian_formalism_over_Hamiltonian_formalism_in_QFT
Bibliography:
- www.physics.usu.edu/torre/6010_Fall_2010/Lectures.html Physics 6010 Classical Mechanics lecture notes by Charles Torre from Utah State University published on 2010,
- Classical physics only. The last lecture: www.physics.usu.edu/torre/6010_Fall_2010/Lectures/12.pdf mentions Lie algebra more or less briefly.
- www.damtp.cam.ac.uk/user/tong/dynamics/two.pdf by David Tong
Euler-Lagrange equation explained intuitively - Lagrangian Mechanics by Physics Videos by Eugene Khutoryansky (2018)
Source. Well, unsurprisingly, it is exactly what you can expect from an Eugene Khutoryansky video.