Choose two independent labels for the magnetic field lines, constant along each line. These are Euler potentials: . Where the two gradients are independent, the vector perpendicular to both is , so initially writeThe solenoidal condition gives . Thus is constant along a field line and is locally a function of its labels. Redefining one label, for example , absorbs this factor. Dropping the tilde givesThis representation automatically has zero divergence, since it is also .
For an magnetic arcade, assign the labels on one polarity of the footpoint surface and transport them along each line to its other footpoint. They specify both line identity and magnetic flux: on a transverse surface, flux coordinates can be chosen so that the directed flux element is . In particular,The boundary labels at paired footpoints must agree, so prescribed boundary functions encode a compatible footpoint mapping, not independently arbitrary values at the two ends.
The construction assumes a smooth family of nonintersecting lines that can be labelled from a transverse boundary patch, with suitable patches at nulls or coordinate singularities. A local Euler-potential representation does not establish the existence of two globally single-valued regular labels for every possible solenoidal field; closed, recurrent or more complicated field topology can obstruct such a global choice. The line-tied magnetic arcade geometry supplies the relevant simplifying assumption here.
Use the magnetic energy . Vary the Euler potentials while keeping their boundary values fixed. The field variation isLet . Integration by parts givesbecause on the boundary. ThereforeThe two interior variations are independent. At a smooth minimum their coefficients must vanish, so the curl is perpendicular to both potential gradients and hence parallel to wherever :This is a force-free magnetic field: the Lorentz force density vanishes. Taking the divergence also gives , so the proportionality factor is constant along a field line but need not be the same on different lines.
The fixed-label variation preserves the encoded field-line connection rather than allowing arbitrary reconnection during minimization. The argument proves a necessary condition for a smooth minimum, not that every force-free stationary field is a stable energy minimum. It also does not include gas pressure or gravity in the minimized functional.
A linear force-free magnetic field has a spatially constant proportionality factor, . Taking its curl and using givesHenceThe constant has dimensions of inverse length in this convention. If it varied in space, the extra term would remain, so the same Helmholtz equation would not follow merely from a nonlinear force-free condition.
Use the original scanned boundary condition. The scan fixes the normal-field amplitude at the corner . The supplied TeX drops the condition and would instead prescribe a constant normal field on the entire bottom. Those are different boundary-value problems; the solution below uses the legible original scan.
Choose a positive integer , put , and seek a separated decaying mode. A suitable flux function isThis is a decaying linear force-free magnetic arcade. The first and third curl components then satisfy the force-free equation automatically; its second component requires . ThusDirect differentiation gives and . Both horizontal components vanish at , and . The magnetic field on the bottom is , not a uniform .
A strictly decaying real normal mode requires , soFor the fundamental, single-arcade choice , this becomes . Equality gives no vertical exponential decay, while a larger magnitude gives an oscillatory rather than decaying vertical dependence for that mode. The data do not explicitly fix the horizontal mode number. If arbitrarily fine higher-mode arcades are permitted, every finite real admits some integer with . The fundamental restriction must therefore not be advertised as a necessary bound for every possible field satisfying only the stated pointwise and wall data.
For a fundamental field line, is constant along its projection in the plane. If denotes its normalized flux-function value, its arch isThe maximum height is at . In the horizontal projection,Thus the vertical projections are arches and the horizontal projections are straight sheared segments joining their paired footpoints. Positive gives positive horizontal slope, negative reverses the shear, and gives an unsheared potential arcade. Higher repeats such cells across the width.
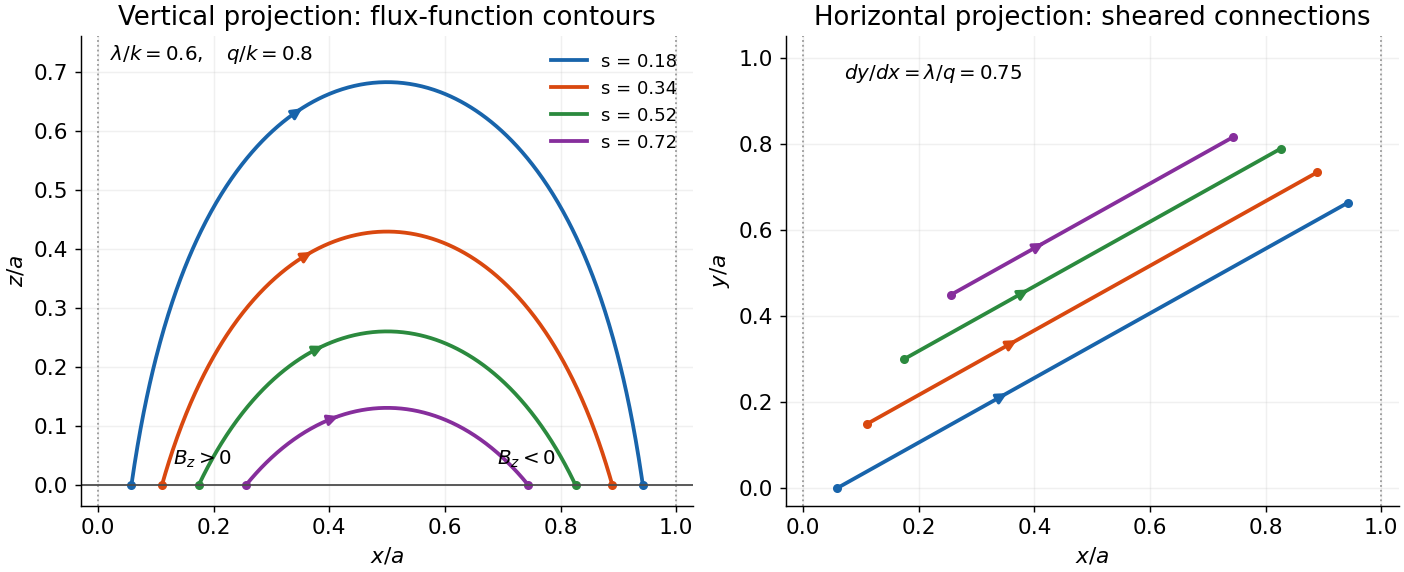

The transcription's alternative uniform-bottom condition would be inconsistent with exponential decay and zero side flux for : solenoidality gives , whereas a uniform nonzero bottom would give a conserved flux that cannot decay to zero. This integral check is an independent reason not to silently solve that mistranscribed problem.
Take and label each dumbbell once. Locally assume its probability density and number density vary negligibly over a connector length. The oriented connector crossing count follows geometrically: a connector crosses a small plane element precisely when its midpoint lies within a slab of normal thickness . For configurations in , the unsigned crossing number per unit area is thereforeThe expression without the absolute value is an oriented crossing count, or an unsigned count restricted to . It cannot be an unrestricted nonnegative number: a connector gives a negative printed expression despite physically intersecting the plane.
To obtain traction, keep the force orientation as well. For , the spring force on the bead below the plane exerted by the bead above it is . For the opposite orientation it is . Multiplying that force by the unsigned crossing count in either case givesIntegrating over all labelled configurations yieldsThere is no extra factor of two: each dumbbell was labelled and counted once, and the orientation-dependent force has already supplied the sign. This is the local continuum stress approximation; resolving appreciable spatial variation across a finite connector would require a nonlocal stress construction.
Let , , and , so the single-bead mobility is . Assume an incompressible solvent, constant , negligible bead inertia, and a symmetric positive-definite . The last requirement makes the resistance invertible and Brownian diffusion physically admissible. At a given position and time, depends on the moment but not on the individual configuration .
Use the source's gradient convention , and write for the component-first gradient. Then . The spring forces on the two beads are and . Their overdamped probability currents areHere the Brownian term written as is a force weighted by probability density. Its corresponding conditional osmotic force is ; treating the given term as an unweighted deterministic force per bead would not produce the stated Fokker–Planck equation.
With midpoint , the derivatives are and . Subtracting the bead currents gives the configuration currentThe midpoint current is after neglecting the specified spatial Brownian diffusion. Configuration probability conservation therefore givesSince has components , this agrees with the source's . The factor two in both spring relaxation and configuration diffusivity comes from relative motion of both beads.
The second moment is the unnormalized conformation tensor. Now multiply by and integrate over configuration space. Assume sufficiently decaying tails so every boundary term at infinite separation vanishes. The affine current gives ; spring drift gives ; two integrations by parts of diffusion give . HenceBecause , is a polynomial in and commutes with it. ThusThis is the Hookean dumbbell conformation equation with anisotropic mobility, an exact second-moment closure within the stated model; no Gaussian approximation to was needed.
The upper-convected derivative of the identity is . Applying it to the polymer stress therefore givesConsequently the coefficients and the closed stress equation arewhere in the printed convention. Here is a polymer relaxation time, unrelated to the inverse-length parameter of question c; is the polymer viscosity scale. The coefficient has inverse-stress units. In the dimensional mobility parameter in the Giesekus model, the dimensionless factor is , not the dimensional printed in this problem.
The upper-convected rate removes the affine stretching and rotation of material connectors. If , then a tensor transported purely as has . Under a time-dependent rigid rotation , the rate transforms as : this is material frame indifference, not an ordinary componentwise time derivative. The resulting equation is the Giesekus model in these dimensional conventions.
The isotropic subtraction is fixed by zero polymer extra stress at thermal equilibrium. With no flow and positive mobility, the stationary distribution isso . The constitutive equation correspondingly has a zero-stress quiescent state and a Newtonian low-rate limit . Without subtracting exactly , the spring contribution would retain an equilibrium isotropic stress and the equation would acquire corresponding reference terms. Because mobility itself depends on , that reference cannot simply be shifted while retaining the same model. The separate fluid pressure enforcing incompressibility is not included in this polymer extra stress.
For steady uniaxial extension of the Giesekus model, the component-first velocity gradient is diagonal, . For a steady spatially uniform diagonal stress, the material derivative vanishes and the convected terms are and . The off-diagonal equations vanish identically, and symmetry permits equal transverse components. The remaining equations areSet , and , with . For , the branches continuously connected to zero stress at zero rate areA sufficient nondegenerate range for physical solutions at every nonnegative rate is . Indeed with , so positive conformation implies positive mobility. The longitudinal quadratic equation is nonpositive at and has a nonnegative root of a polynomial. The transverse quadratic equation has values at and at , so its larger root of a polynomial lies in . Thus the displayed branches satisfy , giving . The other algebraic roots do not provide a physical branch connected to the equilibrium distribution. For constant positive diagonal , the associated stationary configuration distribution is a Gaussian with covariance .
For positive on the physical branch, the stretching stress remains finite through . At that rate,At large extension rate,Thus the stress continues to grow, but the uniaxial extensional viscosity approaches the finite plateau rather than developing a finite-rate pole. The transverse stress approaches as its conformation tensor variance becomes small. At small rate the two stresses are and , so .
When , the physical steady branch instead isThe stretching stress diverges as from below. Above that threshold its algebraic continuation has and cannot be a conformation covariance. There is no physical finite steady stretching state. The transient equationgives linear growth at and exponential growth at larger rates, the Hookean coil-stretch failure of the upper-convected Maxwell limit.
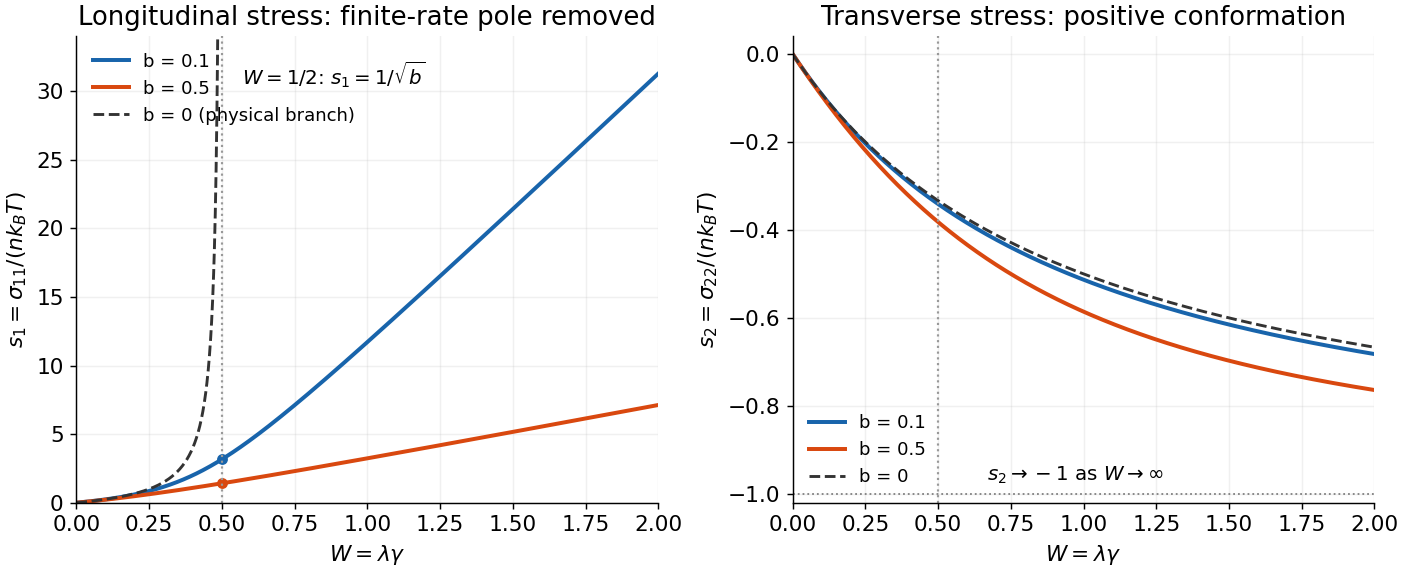
Anisotropic mobility rounds the Hookean extensional-stress singularity
. Dimensionless longitudinal and transverse stresses are plotted against the extension-rate parameter W. Positive dimensionless mobility factors 0.1 and 0.5 give regular equilibrium-connected branches. The isotropic-mobility longitudinal branch is shown only below its physical steady-state threshold W equal to one half. Details.
Parameter qualification. Positivity of alone, without a restriction on , does not ensure real physical steady solutions for the entire tensor. For example , makes the transverse equation , which has no real root. Its diffusion/resistance interpretation is already inadmissible for some conformations. The physically positive-mobility regime stated above avoids that counterexample; the source's positive- case must not be taken as a guarantee for arbitrary parameters.
Articles by others on the same topic
There are currently no matching articles.