Source paper: released examination archive, member
2014/T/a13757w1.pdf. The original cover dates the examination to 24 June 2015, 9.30am to 11.00am. The folder name is not the examination year.The complete three-page replacement is in the Mathematics Part A FOI release, member
FOI-20210708-1 - Data/a13757w1 (5).pdf. Its intact pages 2–3 establish the complete three-question tree. The answers below replace the provisional fragments with full solutions to all 23 verified leaves, including the previously unavailable simplicial-complex and surface-classification material. The original archive link above is retained for provenance.A topological space is connected if it has no separation: two disjoint nonempty open sets whose union is the whole space. Equivalently, its only subsets that are both open and closed are the empty set and the whole space.
A subset is connected when its subspace topology has this property. Thus the sets in a proposed separation of a subset need only be relatively open, rather than open in the ambient space.
Suppose were a separation. By connectedness, all of lies on one side, say : otherwise would separate . A point of then lies in , so connectedness of forces all of into as well. This makes empty, a contradiction.
Therefore the union of two intersecting connected subsets is connected. The argument also proves the connected union with a connected hub rule for arbitrarily many connected pieces meeting one connected subset.
If were a separation, thenwould be disjoint nonempty relatively open sets covering . They are relatively open by continuity of the restriction . This contradicts connectedness of .This is the continuous image of a connected space theorem; no separation property of the target is required.
Use the basis of a topology consisting of open rectangles:It covers , since . Whenever a point lies in two basis rectangles, their intersection is another basis rectangle containing it:These are precisely the two basis of a topology axioms. Arbitrary unions of the rectangles therefore form a topology, the product topology. To check the finite-intersection axiom directly, distribute the intersection of two unions over all pairs of rectangles and use the displayed formula. The empty union gives the empty set.
If both factors are Hausdorff, two distinct product points differ in at least one coordinate. Disjoint open neighbourhoods in that coordinate, multiplied by the other whole factor, give disjoint open neighbourhoods of the product points. Thus the product is Hausdorff.
Conversely, assume the product is Hausdorff. Fix , using nonemptiness. For , choose disjoint open neighbourhoods of and and refine them to basis rectangles and . Since , their disjointness forces . These separate , proving that is Hausdorff. Fixing a point of proves the same for .The nonempty hypothesis is essential: a product with the empty set is empty regardless of the other factor. This is the Hausdorff property of a nonempty product.
Choose and , possible because the two subsets are proper. The crosslies in the indicated complement. Its two arms are homeomorphic to the connected factors and meet at , so is connected by part (a)(ii).
For any remaining point , either or . In the first case the whole connected subset lies in the complement and meets at . In the second case use , which meets at . These connected fibres together with cover the complement. The connected union with a connected hub argument therefore givesNeither proper subset needs to be open, closed, or connected.
Every topological subspace again has the cofinite topology: its nonempty open subsets have finite complements in , and every finite exclusion is obtained by intersecting with a cofinite open subset of . As usual, the empty set is also open; this exception is implicit in the paper's shorthand definition.
If is infinite, any two nonempty relatively open sets intersect, since their complements are finite. Hence is hyperconnected space and therefore connected. If is finite, its cofinite topology is discrete topology. It is then connected exactly when it has at most one point. ThusThere are also infinite disconnected subsets of the product. Choose distinct and put . This is infinite. The traces on of the ambient open setsare respectively and . They are disjoint, nonempty and cover , giving a separation. This answers the infinite-subset question, rather than only producing two isolated product points.
A topological space is compact if every open cover has a finite subcover:There is no Hausdorff requirement in this definition.
Let be an open cover of . By continuity, the inverse images are open in ; by surjectivity, they cover . Compactness supplies finitely many covering . Applying and using shows that the corresponding finitely many cover .
Thus a continuous surjective function from a compact space has compact target. This is the continuous image of a compact space theorem.
For the canonical projection of a quotient set , defineThe inverse images of the empty set and whole target are and . Inverse images commute with arbitrary unions and finite intersections, so the topology axioms follow from those of . This is the quotient topology, and it makes continuous by definition.
The crucial criterion is an equivalence: is open precisely when is open. This is stronger than continuity alone and is what makes the next part work.
If is continuous, then so is , as a composition of continuous functions. Conversely, suppose is continuous. For an open subset ,is open in . The quotient topology criterion therefore says is open in . This proves continuity of .This is the universal property of the quotient topology.
Since misses , the open set contains the whole collapsed equivalence class . Every other equivalence class is a singleton, so is saturated under the saturation of a subset operation:Its preimage is open, so the quotient topology givesThe hypothesis is exactly what prevents the saturation of a subset from adding missing points of the collapsed class.
Use , . This is continuous, identifies the two endpoints, and is otherwise injective. Its fibres are exactly the equivalence classes for collapsing a subset to a point with . Hence it factors uniquely through a bijectionBy the universal property of the quotient topology, is continuous. The interval is compact, so its quotient is compact. The unit circle is Hausdorff. The compact-to-Hausdorff continuous bijection theorem now shows that is a homeomorphism:Indeed the theorem makes the inverse continuous because images of closed subsets of a compact space are compact and hence closed in a Hausdorff target.
Every quotient class has a representative in : the collapsed class has representatives , and the others are the points of . Thus is a continuous surjection from a compact interval onto . It follows that is compact, despite the noncompact original space.
Define the continuous mapThe formulas agree at both junctions, and its fibres are exactly the required equivalence classes. It induces a continuous bijection , which is a homeomorphism by compactness and the Hausdorff condition on the circle.The quotient notation means that the displayed entire subset becomes one point.
Collapsing the integers gives a Hausdorff space. For two distinct noninteger points, choose disjoint small open intervals around them that avoid . Each interval is saturated under the saturation of a subset operation, so its image is an open neighbourhood of its class. For a noninteger and the collapsed class, choose . The disjoint open setsare saturated; contains and contains all integers. Their images separate the two quotient points. These exhaust all pairs of distinct classes.
Collapsing the rationals does not give a Hausdorff space. The preimage of the singleton collapsed point is , which is not closed in . Therefore that quotient singleton is not closed, whereas every singleton of a Hausdorff space is closed.Equivalently, every nonempty saturated open subset of meets the dense set and therefore contains it all. Every nonempty quotient open set contains the collapsed point, making separation from any other quotient point impossible.
No countable subset works. For any countable set , choose : each nonempty interval is uncountable. The sequence tends to infinity, so every tailis closed in and disjoint from . By part (i), is open in . These sets increase and cover , since no point belongs to every tail. But any finite selection is contained in its largest member, which still misses every quotient point in that member's remaining tail. The represent distinct singleton classes.
This is an open cover without a finite subcover, provingThe argument does not assume that is closed, bounded, or discrete. It is the noncompactness after collapsing a countable real subset obstruction.
The standard simplex of dimension isIt is the convex hull of the coordinate vectors, and its faces of a simplex arise by setting selected coordinates to zero.
An abstract simplicial complex is a pair where is the vertex set and consists of finite nonempty subsets of , contains every singleton, and contains every nonempty subset of each member. A member with vertices is an -simplex.
Its geometric realization is obtained by gluing one standard simplex for each member along the faces specified by common vertex subsets. Equivalently, its points have barycentric coordinates with finite support, nonnegative entries summing to one, and support a simplex of . Use the topology induced by this gluing, equivalently the weak topology of a simplicial realization.
List the finite vertex set as . Map a point to its barycentric coordinates:On each simplex this is an affine map and therefore continuous. The definitions agree on every common face, so the quotient topology defining the realization makes continuous on all of . Barycentric coordinates are unique after zero coordinates are added, so is injective.
Since Euclidean space is Hausdorff, distinct images have disjoint open neighbourhoods. Their inverse images separate the original points. Hence is Hausdorff. A continuous injection into a Hausdorff space is enough for this conclusion; no prior Hausdorff assumption on the domain is being used.
An -dimensional topological manifold is a Hausdorff, second countable topological space in which every point has an open neighbourhood homeomorphic to an open subset of . Equivalently, charts can be chosen onto open balls. This is the without-boundary convention.
A topological surface is a two-dimensional topological manifold. When connectedness is included in the convention for a surface, impose it as well; in the classification statement below the surface is explicitly connected. A closed surface means a compact surface without boundary, rather than merely a closed subset of another space.
Here is an explicit simplicial complex on six vertices. Take every subset of one of the following ten triangular facets:For example, denotes , with all its edges and vertices included. Its one-skeleton has all fifteen edges of the complete graph. Every edge belongs to exactly two triangles. The links of a simplex at the six vertices are the following cycles, with the first vertex understood to repeat at the end:Thus every vertex has a disk neighbourhood, as do edge and face interior points. The realization is a compact connected surface without boundary. Its Euler characteristic isThe classification theorem for surfaces identifies the unique closed connected surface with this Euler characteristic as the real projective plane. Consequently this complex triangulates . The explicit facet and link checks make this a genuine simplicial complex, not a polygon whose boundary identifications have been mistaken for simplicial faces.
A polygon with a complete set of side-identifications consists of a closed polygonal disk, a pairing of all its boundary sides, and a specified endpoint-matching homeomorphism for each paired pair. Form the quotient by these side maps, leaving interior points distinct. A convenient encoding labels paired sides by the same letter and gives them arrows; traversal in the arrow direction contributes , and traversal against it contributes to the boundary word. Every letter occurs exactly twice.
The orientations determine whether matched endpoints are identified in the same or reverse boundary-traversal order. This endpoint data is essential: pairing the same geometric sides with different directions can produce nonhomeomorphic surfaces. Subdividing the disk and the paired sides gives a triangulation of the resulting surface.
The classification theorem for surfaces states that every connected closed combinatorial surface is homeomorphic to exactly one of:
- the two-sphere;
- an orientable surface of orientable genus , the connected sum of tori;
- a nonorientable surface of crosscap number , the connected sum of real projective planes.
The orientable family has Euler characteristic ; the nonorientable family has Euler characteristic . Orientability together with Euler characteristic distinguishes the entries.
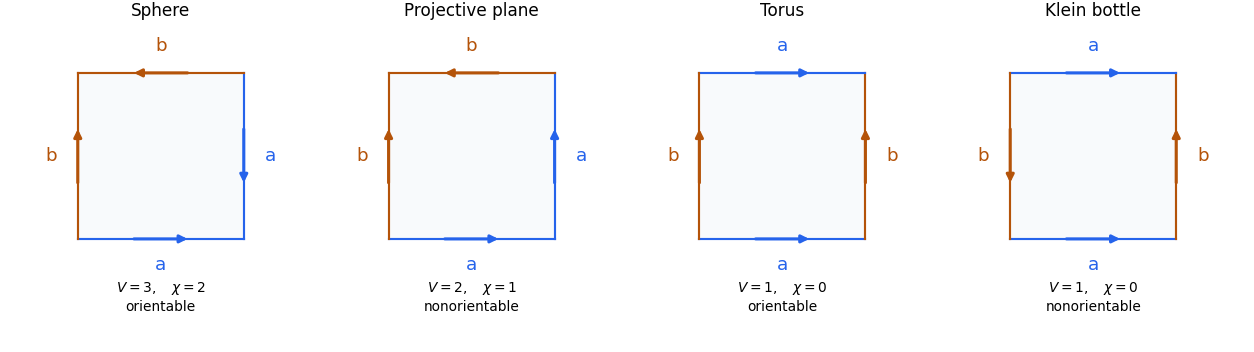
Boundary words giving the required polygonal schemas areA two-sided polygon here means a disk with its boundary split into two arcs; subdivision produces an ordinary polygon with more sides without changing the quotient. Alternatively the square word represents the sphere. Each four-letter block in the orientable word adds a torus handle; each repeated-letter block in the nonorientable word adds a projective-plane summand.
There are exactly four homeomorphism types: the two-sphere, real projective plane, torus, and Klein bottle.
For completeness, enumerate all pairings. Four sides have three pairings; each pair can be matched in either direction, giving twelve signed pairings before symmetries. Up to cyclic relabelling, the repeated labels are either adjacent, of form , or alternating, of form , where . The second adjacent pattern rotates to the first. Endpoint identification gives the following table:Here the quotient always has two edge classes and one face, so its Euler characteristic is . To reproduce the vertex count, label consecutive square vertices . For paired sides , a same-direction pairing identifies with and with ; a reversed-direction pairing identifies with and with , with indices modulo four. Taking the generated equivalence classes gives exactly the displayed values of .
The quotient is orientable precisely when each label is traversed once positively and once negatively around the boundary: then the face orientation extends across every paired edge. A same-direction pair obstructs such an orientation. Thus the two possibilities are distinguished as the orientable torus and nonorientable Klein bottle; the other rows are fixed by Euler characteristic and the classification theorem for surfaces.
Explicit square representatives areAll edge interior points have disk neighbourhoods by joining two half-disks, and each identified vertex has a cyclic sequence of corner sectors, again a disk neighbourhood. There are no leftover boundary edges. The enumeration therefore describes closed surfaces, and the twelve signed pairings leave no additional cases.

Articles by others on the same topic
There are currently no matching articles.