Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Under the corresponding holomorphic and uniform remainder hypotheses, the expansion in Watson lemma remains valid for a complex large parameter , uniformly in every closed subsectorwith . A rotation of an endpoint contour reduces oscillatory factors to this decaying Laplace form.
For a flow invariant in one horizontal direction, the volume flux per unit width is the velocity integrated across the flow depth. It has dimensions of area per unit time.
A nonunit is an element of a ring with no two-sided multiplicative inverse in that ring. For example, is a nonunit in the integers, even though multiplication by obeys the cancellation law. Thus being a nonunit does not imply being a zero divisor.
The set of nonunits need not be an ideal. In , both and are nonunits, but their sum is a unit. In a commutative local ring, by contrast, the nonunits form its unique maximal ideal.
Let be an integral domain that is a Noetherian ring, and let generate a prime ideal. If the localization of a ring is a unique factorization domain, then is a unique factorization domain. Indeed, integrality of over , with minimal, forces and hence proves that is an integrally closed domain. The Nagata theorem for divisor class groups then says that is generated by the height-one primes containing ; the only one is the principal prime , so .
If a topological space is the union of finitely many closed subspaces and continuous maps on those subspaces agree on every overlap, they combine into a continuous map on the whole space. For a closed set in the target, its preimage is a finite union of closed sets, proving continuity.
A Schrödinger operator is a differential operator of the formwhere is the Laplace operator and is a potential function. Its eigenvalue problem is the time-independent Schrödinger equation.
A self-adjoint operator of this form with supplies the Quantum Hamiltonian of a particle in the potential .
Bright and dark state reduction of a star-coupled Hamiltonian by  Codex 0 Created 2026-10-03 Updated 2026-11-05
Suppose one state couples to degenerate states with amplitudes , while the degenerate states do not couple to each other. The normalized bright state proportional to is the only combination coupled to . Every orthogonal combination is a dark state and remains an exact eigenstate at the degenerate energy. The remaining spectrum comes from a two-dimensional Hamiltonian whose off-diagonal entry is .
In the long-wavelength approximation, a particle of charge in a spatially uniform electric field has perturbationIts transition amplitudes are controlled by matrix elements of the position operator.
A fermionic path integral integrates histories valued in Grassmann variables. Products and integration order carry signs, so the measure convention forms part of the definition. Its finite-dimensional building block is the Berezin integral.
For independent complex Grassmann pairs , choose the measure convention for which the one-pair integral of is . ThenExpanding the exponential function terminates because each Grassmann variable squares to zero. Extracting the term containing every variable antisymmetrizes the products of matrix entries, producing the determinant.
This determinant formula concerns paired complex variables. For an even number of real Grassmann variables with an antisymmetric matrix, the corresponding Gaussian gives a Pfaffian. For comparison, the ordinary complex Gaussian integral with positive Hermitian matrix is . Thus the precise determinant power depends on whether variables are real, complex or paired; it should be specified before passing to infinitely many field modes.
The fermionic Fock space of modes is the exterior algebra . Creation acts by exterior multiplication and annihilation by contraction.
A statistical model is identifiable when distinct parameter values determine distinct probability distributions. In a nonidentifiable parameterization, data can at most estimate combinations of parameters that remain unchanged along each equivalent parameter set.
Forfixed and , the stationary point near givesWhen , the stationary point coalesces cubically with the endpoint at zero and the leading order changes to .
If a phase at an endpoint satisfies with , the leading region has width . Rescaling reduces the leading term to a cubic oscillatory integral and produces decay .
The Kalman filter alternates a Kalman prediction step with a Kalman measurement update. It carries a state estimate forward using a state-space model, then adjusts it by the part of the new observation that was not predicted: the innovation. The Kalman gain determines the adjustment from the uncertainty of the prediction and the measurement noise. A noisy measurement should have less influence than an equally surprising precise one.
For a precise discrete-time statement, let the state and observation be vectors in real vector spaces obeying the linear state-space modelThe matrices and control inputs are known. Assume a Gaussian random vector with mean and covariance matrix , and mutually independent centered Gaussian noises , independent of , with covariance matrices . Suppose is positive-definite, so the observation innovation covariance is invertible. Then the recursions below give the exact posterior mean and posterior covariance matrix , hence the full conditional multivariate normal distribution. They also minimize mean squared error. Without the Gaussian assumptions, suitable second-order assumptions still give best affine state estimates, but do not generally give an exact posterior distribution. [ref]
https://www.cs.utexas.edu/~pstone/Courses/393Rfall15/readings/Welch%2BBishop-TR-95.pdf. Welch and Bishop, An Introduction to the Kalman Filter, section 1, UNC technical report TR 95-041, 2004 revision
.For an exact scalar example, suppose the predicted state has normal distribution and a measurement reports in the same units. With measurement noise variance , the Kalman gain is and the posterior distribution isWith the same prediction and observed value but measurement noise variance , the Kalman gain becomes and the posterior distribution is instead . Both updates move toward the observation; the more precise measurement moves the estimate further and reduces uncertainty more.
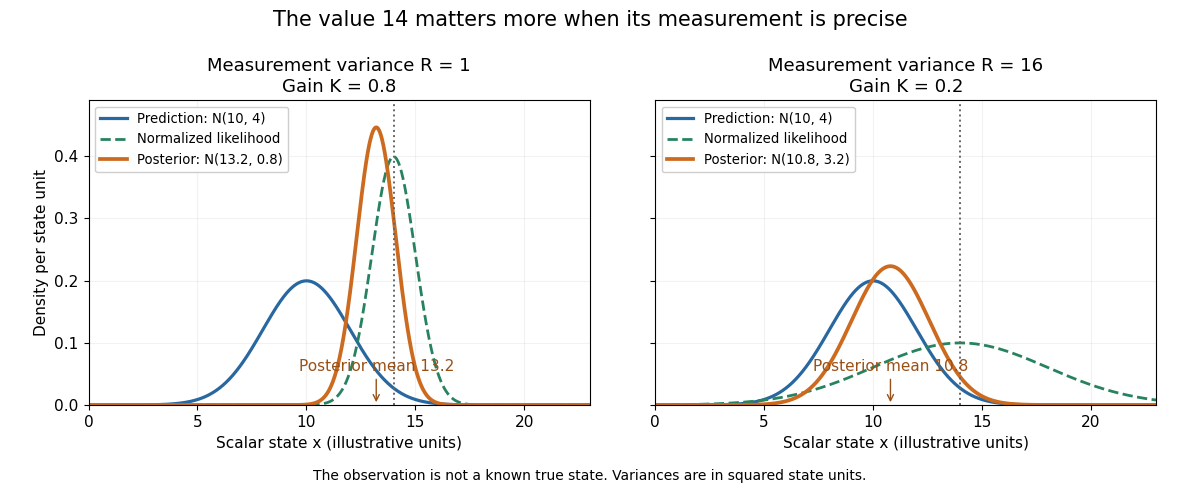
The same observed value produces different Kalman measurement updates when its uncertainty changes
. Both panels start from and observe . The green curve is the likelihood function normalized over the scalar state for this unit-coefficient observation model. The orange curve is the posterior density; its narrower width reflects reduced variance. The vertical dotted line marks the observed value, rather than a known true state. Details.The useful compression is exact under the stated model: the two objects contain everything from the past observations needed for the next update. Their size depends on the state dimension, not on the length of the observation history. This makes causal state filtering practical when observations arrive continually. It also gives Linear-quadratic-Gaussian control an estimate of the state on which to act.
Rudolf E. Kalman's 1960 paper organized linear filtering around state transitions, error covariance and recursive computation, connecting estimation with optimal regulation. Its introduction acknowledges earlier work by Wiener, Bode, Shannon and others; the useful historical claim is this particular formulation, rather than that estimation began in 1960. [ref]
https://www.cs.cmu.edu/~motionplanning/papers/sbp_papers/k/Kalman1960.pdf. Kalman, A New Approach to Linear Filtering and Prediction Problems, Journal of Basic Engineering 82 (1960), pp. 35–45
.For real scalar fields with canonically normalized quadratic kinetic terms, the tree-level scalar mass matrix is the Hessian matrix of the scalar potential at a stationary vacuum:Its eigenvalues are squared masses in units . A negative eigenvalue is a local instability of that candidate vacuum.
The kinetic normalization is essential. More generally, expand about withwhere is the potential Hessian matrix and is a real symmetric positive-definite matrix. A mode obeys the generalized eigenvalue problemEquivalently, canonical field normalization gives the symmetric squared-mass matrix . For one field with kinetic coefficient and quadratic potential , the physical squared mass is .
Broken continuous global-symmetry directions are zero vectors of the potential Hessian matrix, producing Goldstone bosons when the kinetic form is nonsingular. A Higgs mechanism changes which scalar modes remain independent physical particles; explicit symmetry breaking can lift a zero mass. Thus both the potential and kinetic structure are needed to read a physical spectrum.
A vacuum expectation value is the expectation of a field or operator in the vacuum state. A nonzero value that is not invariant under the full symmetry group can select a point of the vacuum manifold and spontaneously break the symmetry.
The Schwarzschild-de Sitter spacetime is the spherically symmetric vacuum solution with positive cosmological constant. In static coordinates its metric function is , with a black-hole horizon and a cosmological horizon when .
Ultrarelativistic limit of the boosted Schwarzschild metric away from the null plane by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06An RSA fixed point satisfies . Since every valid public exponent is odd, ; therefore is a fixed point whenever is.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:



All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact