Source paper: www.whatdotheyknow.com/request/physics_preliminary_examinations/response/1162943/attach/3/Twain.7z?cookie_passthrough=1
This is the ordinary sitting of 9 June 2014, whose source is retained in the archive's legacy unspecified-stage directory. All eleven questions are solved, including all four alternatives in Section B. The tutorial clarification printed with Question 9 is accounted for in c.
Use nonrelativistic mechanics and let be the constant centre-of-mass velocity. In the centre-of-mass frame, conservation of momentum gives before and after the elastic collision. Thus , and the kinetic energy isThe decomposition and constant centre-of-mass velocity show that the elastic collision preserves , so the positive constant multiplying forces that speed to remain unchanged. The same momentum relation fixes the second speed:Only their directions can change; the two velocities remain antiparallel in this frame. This derivation does not require a head-on collision.
For equal masses, let the incoming laboratory frame velocity be and the outgoing velocities be . Conservation of momentum and kinetic energy giveSquaring the first equation and subtracting the second yields . HenceThe stated oblique collision ensures both outgoing speeds are nonzero. In the degenerate head-on case one particle can stop, and a direction cannot be assigned to its zero velocity.
Let be the signed distance from the Earth's centre along the polar tunnel, with and . The shell theorem leaves only the enclosed mass contributing to the gravitational field. ConsequentlyThis is simple harmonic motion with and . Crossing the centre takes a quarter-period; reaching the opposite surface takes a half-period:The body's mass cancels. The polar diameter lies on the rotation axis, so the tunnel motion has no additional centrifugal force or Coriolis force from the Earth's rotation. A realistic radial density profile would change the harmonic equation.
A straight diameter at nonzero angle to the rotation axis moves the body toward that axis during the inward half of its trip. With no external axial torque, the total axial angular momentum of the Earth and body is conserved. The body's contribution to the moment of inertia decreases toward the centre, so the Earth spins slightly faster; the reverse happens on the outward half, restoring the original rotation rate at the far surface.
For a body of mass constrained to follow a tunnel fixed in the Earth, an illustrative angular-momentum balance isHere is the Earth's axial moment of inertia, treated as constant, and is the signed distance along the diameter. A frictionless guide can still exert normal forces: these supply the transverse acceleration and exchange axial angular momentum with the rotating Earth. Simply allowing an unconstrained body to fall would not keep it inside a narrow nonpolar straight tunnel. The effect vanishes for and is largest for an equatorial diameter.
Choose the smaller disc's initial sense as positive. For either uniform disk, the axial moment of inertia is , so . The signed initial angular velocities are and , giving total axial angular momentum zero. The frictionless axle supplies no axial torque, and the pins' negligible mass supplies no extra stored kinetic energy. ThusThese equations allow the original state or its simultaneous reversal. A nontrivial elastic pin impact selects reversal of the relative contact velocity, rather than continued interpenetration. ThereforeThe requested magnitudes are unchanged: and . The intersecting pin paths make the impact possible; no additional lever arm is needed once axial angular momentum and energy conservation have been imposed.
Generalized coordinates are variables that specify the allowed instantaneous configuration of a mechanical system. They need not be Cartesian positions: a rigid pendulum's angle is a suitable single coordinate. With constraints solved, the particle positions are functions .
The number of degrees of freedom is the number of independent coordinates needed to specify an allowed configuration locally. For unconstrained point particles in three dimensions it is ; independent regular holonomic constraints reduce it to . Redundant constraints must not be counted twice, and nonholonomic velocity restrictions require separate care.
A holonomic constraint can be written as an equation involving coordinates and possibly time, without an irreducible dependence on velocities. For example a particle confined to a fixed sphere obeys . A general rolling without slipping constraint in three dimensions need not be integrable into such a coordinate equation.
Use the inverse Lorentz transformation, with :Taking differentials along the object's trajectory givesThis is the collinear relativistic velocity addition law. It concerns the velocity of one object measured in two frames. By contrast the rate of change of the distance between two objects in one laboratory frame can be as large asattained by oppositely directed light signals; for massive objects it is approached but not attained. This is not an object's speed in the other's rest frame and cannot transmit a signal faster than .
Take the light to travel along positive x, while the water moves with signed velocity . In the water's rest frame its light phase velocity is . The relativistic velocity addition law from a gives the laboratory phase velocityExpanding to first order in , with , yieldsEquivalently : the counterflow reduces the forward light speed. This is the nondispersive Fresnel drag coefficient. The refractive index is taken as constant over the relevant frequencies; dispersion and its frequency-shift corrections are outside this approximation.
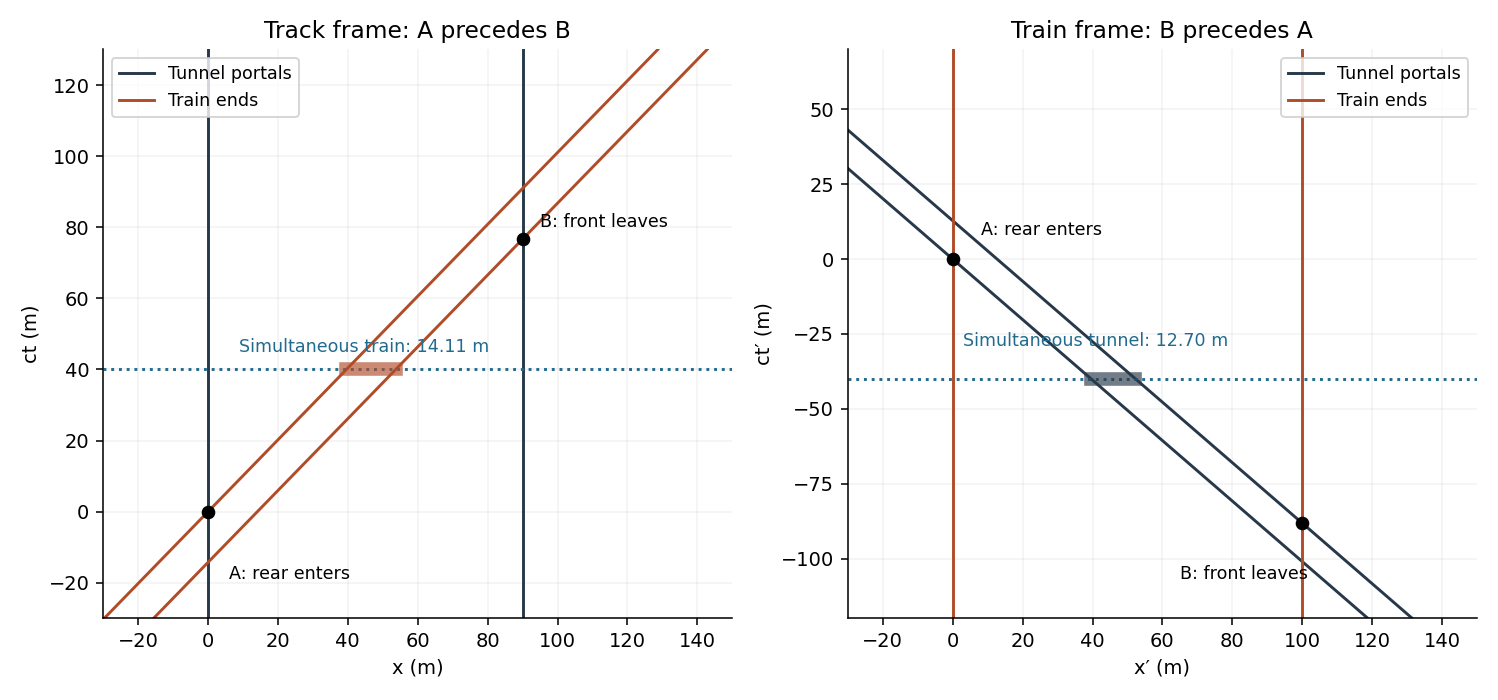
For , the Lorentz factor is . In the tracks' rest frame the train undergoes length contraction to , which fits in the tunnel. There is a time interval during which it is entirely inside. In the train's rest frame the tunnel instead has length , so it never simultaneously contains the whole train:These refer to different sets of simultaneous events, as required by relativity of simultaneity. Quantitatively let be the rear entering the near portal, with , and the front reaching the far portal. In the track frame,The train is wholly inside between these events. Transforming their time separation givesThus the front leaves before the rear enters in the train frame. The two events are spacelike separated, so their time order may reverse without a causal contradiction. No doors or forced acceleration need be added to the problem.

Let measure the spoke's displacement from downward equilibrium. The total moment of inertia about the axle is : the rim is a thin thin hoop, and the attached body is a point mass. The rim's weight has no axle torque, while the attached mass gives restoring torque . HenceEquivalently conservation of energy gives . For small angles, , so the motion is approximately with . The small-amplitude period isAt finite amplitude the nonlinear pendulum equation remains valid but this period approximation does not. The limit recovers a simple pendulum of length .
Choose positive x along the rocket's motion. If its instantaneous total mass is and it ejects a positive amount , the exhaust velocity in the original inertial frame is to first order. Conservation of momentum over that increment givesIntegrating the rocket equation from to givesThe constant exhaust speed is relative to the rocket, not the initial frame. Kinetic energy of rocket plus exhaust is not conserved because stored fuel energy is released. The calculation is Newtonian and requires resulting speeds small compared with the speed of light.
Let be the transferred fuel mass. Before any engine reversal, rocket A has mass and velocityFor exhaust collection by a second rocket, under the stipulated eventual capture of all exhaust, final conservation of momentum for the complete initially stationary system gives . ThusCapture is inelastic: no kinetic energy conservation for B is assumed. Finite exhaust flight time changes the intermediate sharing of momentum but not this endpoint balance if the stated complete capture actually occurs.
The ballistic exhaust interception condition is a physical restriction on that idealization. For purely ballistic exhaust to reach a receding collector to the rear, its laboratory velocity must be more negative than B's while interception occurs. In the negligible-flight-time approximation this requires . Very large fuel ratios need not meet that condition throughout a complete burn; the boxed endpoint formula is conditional on the prompt's complete-collection stipulation, not an unconditional prediction for every ballistic two-rocket geometry.
Neglecting exhaust flight time, no momentum is stored in transit andSince the velocities have opposite signs, equal nonzero speeds imply equality of the instantaneous masses. For and , this occurs at , or . ThereforeThe common-speed event occurs after of A's original fuel has been transferred, rather than when either rocket has its final mass. At this event the rearward exhaust still overtakes B: . Thus the interception restriction in b does not invalidate this event even though extending complete ballistic capture over the much later burn would need separate checking.
Put and . At reversal the transferred mass is , leaving A with and, after capture of that exhaust, B with . The first burn givesAfter reversal A emits its remaining exhaust away from B, so B receives no further fuel and eventually coasts at this velocity. Applying the rocket equation with reversed thrust to A givesBoth now move toward negative x, but A moves faster in that direction. The asymptotic closing speed isThis conclusion does not require a burn rate or an initial separation: after a finite burn, the positive eventual closing speed closes any finite remaining gap. Those additional inputs would be required to calculate the meeting time. Any pre-reversal exhaust still in transit affects the timing, not B's eventual momentum after collecting that fixed amount.
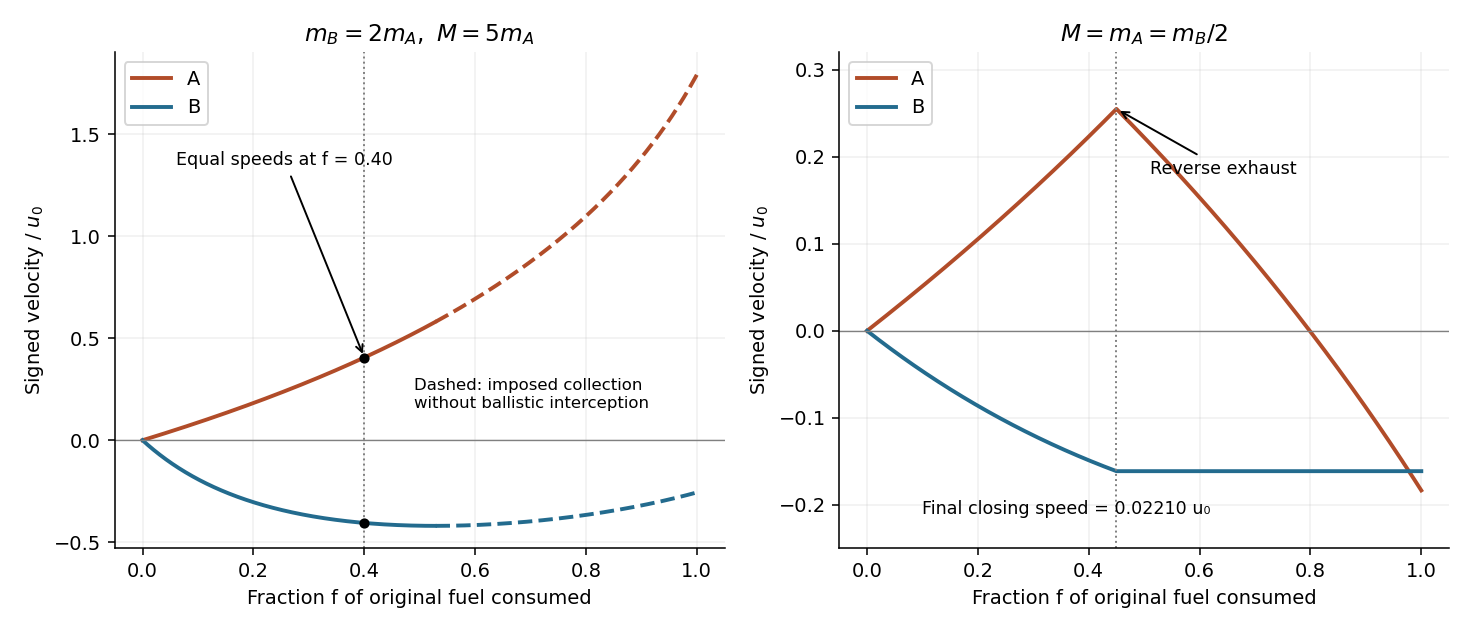
Signed velocities during exhaust collection and thrust reversal
. Original Newtonian calculations versus the fraction of original fuel consumed. Left: the equal-speed event in the ideal negligible-flight-time collection model; the later dashed extension is conditional on collection and can violate ballistic interception. Right: reversing thrust at 45 percent produces a small positive eventual closing speed. Details.
For the eccentric circular-hole disk inertia, let be the mass of the complete disc before removing material, the missing mass, and the wheel's remaining mass. Denote the complete disc's centre by C and the axle/hole centre by H; . Assume the hole fits inside the disc, . The parallel axis theorem gives the full disc's moment of inertia about H as . Subtract the absent little disc about its own centre H:The axle is a support, not part of the rotating wheel's stated mass. Its frictionless bearing does not alter this moment of inertia. For fixed-axis angular velocity ,The missing material must be subtracted with its actual displacement relative to the axis; treating the wheel as a concentric annulus would give the wrong result.
For a freely rolling rigid body, decompose the kinetic energy into translation of its centre of mass G and rotation about G. The centre of mass after removing material lies on the side opposite H:Another use of the parallel axis theorem givesThus at the same angular speed,This compares the rotational component, not the total rolling kinetic energy. The total also contains and need not be smaller than . Describing all rolling motion as instantaneous rotation about its contact point includes that translational contribution; it is not the rotational component intended by this comparison.
The supplied PDF labels this equation clarified from original for tutorial purposes. Use the model of an eccentric wheel with missing-mass kinetic energy neglected: neglect the missing disc's contribution to kinetic energy, while retaining its subtraction from gravitational potential energy. Do not silently replace the gravitational mass by the full-disc mass as well.
Choose as the clockwise angle of from the upward vertical, and set . The rolling without slipping constraint makes changes in equal changes in the distance C travels down the slope. Choose its additive origin so when the hole is vertically above C. Then, up to an irrelevant height constant,The approximate kinetic energy is that of the complete uniform disc rolling at :Subtracting the missing disc's gravitational potential energy givesApply the Euler-Lagrange equation to :ThereforeHere have dimensions of acceleration and has dimensions of inverse length. The initial conditions are under the vertical-above interpretation. If an initial orientation is instead specified relative to the slope normal, the same coordinate convention produces a different initial , not different constants. With the equation becomes , the familiar solid-disc result. Retaining the hole's exact kinetic energy would introduce coordinate-dependent inertia and extra terms; the printed neglect is what permits the requested constant-coefficient form.
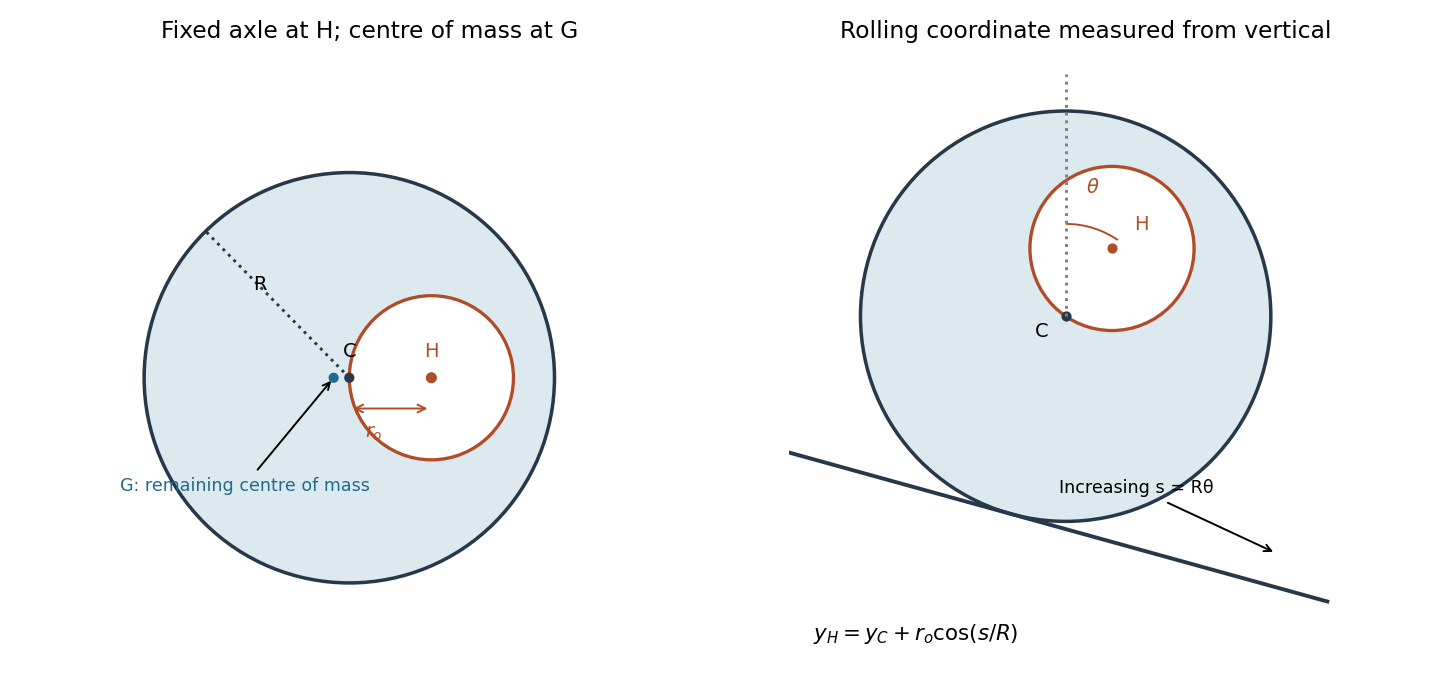
The axle, geometric centre and centre of mass of the perforated wheel
. Original geometric constructions. Left: fixed-axis inertia subtracts a missing disc about H. Right: the rolling coordinate is the hole angle from the upward vertical; the centre travels downhill by R times the angle, while the missing mass contributes a cosine to potential energy. Details.
The incident particle obeys the energy–momentum relation . The stationary target contributes energy and zero momentum. A single product inherits the total four-momentum, so its invariant mass satisfiesHenceHere is the incident total energy, including rest energy. In a one-particle final state, exact production of a specified mass fixes the incident energy; there is no adjustable final relative motion to absorb excess energy. A resonance with a finite decay width relaxes that ideal exact equality over its line shape.
For fixed-target electron-Positron formation, set in a and solve for the incident total energy:The incident kinetic energy is smaller by another , a negligible relative change here. Most of the fixed-target energy becomes motion of the final rho meson in the laboratory.
With equal and opposite incoming momenta, the centre-of-momentum frame is the laboratory. Each incoming particle has the same total energy, and there is no final translational kinetic energy at formation:This large contrast illustrates the invariant-energy advantage of colliding beams. The given resonance mass is used rather than replacing it with a modern tabulated value.
Treat the atmospheric proton as stationary in the Earth frame, the incident antiproton as vertically downward, and neglect atmospheric energy loss, scattering and the Earth's curvature initially. Take . Conservation of energy and equal outgoing energies giveEqual energies imply equal momentum magnitudes. Their transverse momenta cancel, so the two muons have equal downward components , whereEach muon therefore makes an angle with the downward vertical satisfyingThe paths are not both vertical: replacing their path lengths by would miss this two-body kinematic correction. Since , the proper flight time over vertical height isFor equal-energy atmospheric muon-pair survival, independent exponential particle decays with mean proper muon lifetime , both survive with probabilityEquivalently each travels about , with proper flight time about , and survives with probability about . The result is decay-only survival to an ideal surface, not a prediction including air interactions or detector efficiency. For a spherical Earth of radius , the exact path length is ; inserting gives a small curvature correction.
Here is the gravitational constant, is the separation of the orbiting object from the central body's centre, and is the magnitude of the object's conserved orbital angular momentum, not angular momentum per unit mass. Approximate the much heavier central body as fixed, neglect other forces, and use the Newtonian gravitational potential energy , with zero at infinity.
A central force confines the motion to a fixed orbital plane. In plane polar coordinates its kinetic energy is . Conservation of angular momentum gives ; eliminating yieldsThe centrifugal term belongs to the radial effective potential; it is the eliminated transverse kinetic energy, not an additional physical interaction. If recoil of the central body mattered, the relative-coordinate reduction would use the reduced mass.
Write and let be the original circular orbital speed. An impulse leaves the orbital angular momentum unchanged if it is radial: its angular impulse is zero. The tangential velocity remains , and an added radial component givesThus kinetic energy increases even though angular momentum does not. For a Radial kick from a circular Kepler orbit, the new specific orbital energy and squared specific angular momentum areThe orbital eccentricity is , while the semi-latus rectum is . HenceFor the trajectory is a parabolic Kepler orbit and has no finite furthest radius; its periapsis is . For it is a hyperbolic orbit, with the same formula for but unbounded radius:One must not use the negative denominator in the bound-orbit expression as a negative physical apocentre. On a departing unbound branch the conic's periapsis may already lie in the past; the future minimum from the kick event is then . These are ideal conic orbits; a periapsis inside a real planet would cause impact before the ideal continuation.
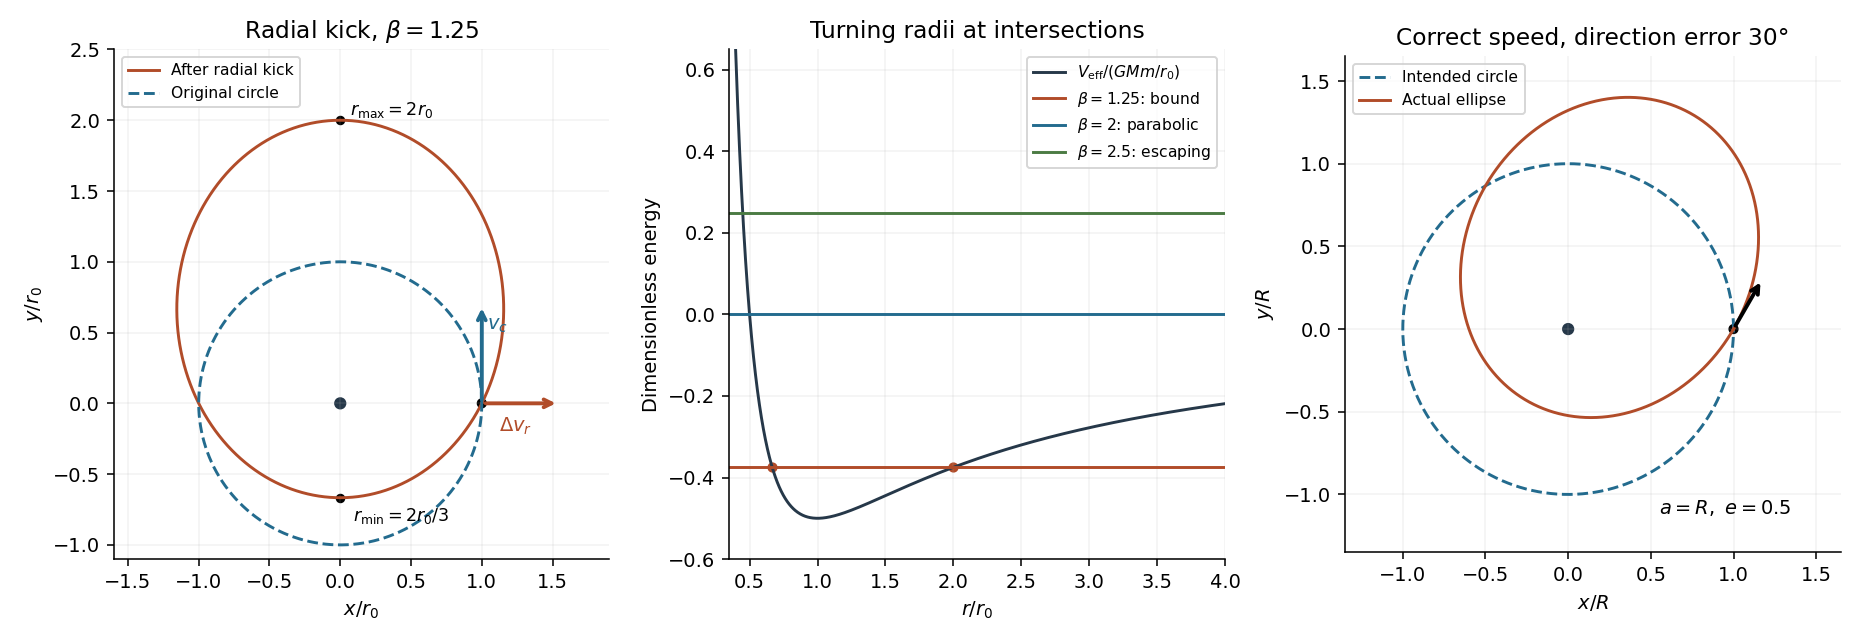

For a fixed-speed orbital launch-direction error, the initial radius and speed are correct, so the specific orbital energy is still and the new semi-major axis is still . Resolve the launch velocity into radial and tangential components, taking as the in-plane deviation from the intended tangent:For a nondegenerate orbit , the orbital eccentricity follows from :The intended circular orbit has radius everywhere, so the largest radial distance between the orbit curves occurs at either apsis:This is the geometric separation of the two orbit curves, not the distance between two satellites compared at equal elapsed times. The latter also depends on orbital phase. A purely radial launch is a degenerate zero-angular-momentum trajectory through the central body and requires separate treatment of the collision.
Articles by others on the same topic
There are currently no matching articles.