The cover dates this paper to 6 June 2022; the archive member is misleadingly filed under 2021/T. Source gap: printed page 2 is missing from the damaged public PDF. Questions 1–3 cannot be reconstructed; the remaining solutions cover every recoverable part of questions 4–10.
TODO: source missing. Printed page 2, containing question 1, is absent from the supplied damaged PDF. Its statement, subparts and numerical data are unavailable, so no solution can be inferred responsibly.
TODO: source missing. Printed page 2, containing question 2, is absent from the supplied damaged PDF. Its statement, subparts and numerical data are unavailable, so no solution can be inferred responsibly.
TODO: source missing. Printed page 2, containing question 3, is absent from the supplied damaged PDF. Its statement, subparts and numerical data are unavailable, so no solution can be inferred responsibly.
For motion in a central potential, conservation of angular momentum gives . In polar coordinates, the conserved mechanical energy isConsequently, for ,The sign in distinguishes inward and outward motion. Choosing the orientation so , it is also the sign of . The expression under the square root must be nonnegative. If , the motion is radial and is constant, so cannot be parametrized by this way.
Take . At a radial turning point, , and the effective potential givesFor , the smaller positive radial turning point is conveniently written without division by :This includes , where . For there is also an outer radial turning point; the two coincide for the circular orbit at . Smaller energies are inaccessible at that . For there is just one positive radial turning point. If , there is no centrifugal barrier and an inward trajectory can reach the singular centre; its limiting closest distance is zero.
The requested omission of is not possible. For example, at and fixed nonzero , doubling halves . Thus alone cannot determine closest approach.
Use upward generalized coordinates. Let be the displacement of the lower pulley and that of the mass. The two inextensible mechanical strings imposeFor ideal massless pulleys and mechanical strings, only the three masses contribute kinetic energy. HenceUp to a constant, their gravitational potential energy isThe Lagrangian of this compound Atwood machine is therefore
A constant displacement proportional to leaves the velocities unchanged and changes by zero. It is therefore a continuous symmetry of the Lagrangian. The generalized momentum components areNoether's theorem gives the conserved quantityA direct check using the Euler-Lagrange equations isThe normalization of a symmetry generator is arbitrary. One can take the transformation parameter to have length units and dimensionless, giving the units of momentum. Alternatively, for the paper's convention with dimensionless parameter and length-valued , use ; the conserved quantity is then . The conserved content is identical.
The special relativity expression for momentum is , with Lorentz factor . Equal speeds imply equal Lorentz factors, so the pion and proton momenta are in the ratio of their rest masses:The common dimensionless product is , giving and .
By time dilation, the laboratory mean lifetime is , where . The exponential decay law evaluated at travel time gives the surviving pion fractionUse the exact product from part (a), rather than approximating the speed separately. With ,Thus about emerge without decaying, and about decay inside the pipe. This assumes the given common longitudinal speed and neglects losses from other interactions.
Align the spatial axes and make the origins coincide at . For an inertial frame moving at velocity along , the Lorentz transformation isThe inverse Lorentz transformation follows by interchanging primed and unprimed coordinates and replacing by .
Let the object be at rest in , with proper length . Measuring its length in requires two endpoint events simultaneous in , so . The Lorentz transformation then givesThis is length contraction. The simultaneous endpoint events in are not simultaneous in ; that relativity of simultaneity is essential to the measurement.
For the two rockets, take the first rocket's Earth-frame velocity as and the second's as . The velocity-addition formula gives the second rocket's velocity in the first rocket's rest frame:Its Lorentz factor is , and therefore its measured length isHere “appear” is interpreted as a length measured using simultaneous endpoint positions in the observer's inertial frame. A photograph, involving unequal light travel times, is a different measurement.
Write the incident and scattered photon energies as and . Conservation of relativistic energy gives the recoiling electron energy . By momentum conservation, its momentum is the difference of the two photon momenta; henceInsert these into the relativistic energy-momentum relation for the electron:Expanding and cancelling terms givesSince , the Compton scattering formula follows:The scale is the electron Compton wavelength. At , : there is no energy or momentum transfer in this ideal forward limit, so the electron remains at rest. At , the wavelength shift is maximal:The electron gains its largest kinetic energy, , and recoils forward while the photon reverses direction.
Define as the magnitude of the inward central force, so and . The conserved angular momentum is . Eliminating from the mechanical energy yieldsThe added term in the effective potential is the centrifugal barrier. If instead denotes the signed radial force component, the convention becomes .
A circular orbit has constant . Both its initial radial velocity and radial acceleration must vanish, givingEquivalently, the initial tangential speed and angular velocity obeyThe initial polar angle is arbitrary, and the energy is fixed at . Either orientation is possible. These conditions give an exact circular orbit even if it is unstable; stability requires an additional positive second derivative of the effective potential.
For the power law central potential , differentiate the effective potential:The circular orbit condition is . Thus, when , and ,The sign condition expresses attraction. At the force vanishes and there is no nontrivial circular orbit. At , attraction requires and the condition reduces to . In that exceptional case the effective potential is identically zero and every is a possible circular radius for the tuned ; there is no isolated preferred radius. A small radial velocity then gives , rather than an oscillation.
Put , where . The Taylor expansion at a circular orbit isThe constant has no effect on the force. The paper's displayed harmonic potential should be read as this expansion after subtracting that constant and neglecting higher orders; it is not an equality for the absolute effective potential in general. For example, when and , and , whereas the printed quadratic expression is zero at .
Differentiating again and then using givesThe linearized radial equation of motion is , so the radial frequency in a power-law central potential isFor the circular orbit is unstable and radial disturbances grow exponentially, with growth rate . At the linear restoring force vanishes, as described in part (c). Thus an attractive central force alone does not guarantee small oscillations.
Choose the orientation . To leading order in the radial disturbance, the azimuthal angular frequency is , soFor either orientation the positive frequency ratio is . At , the ratio is : there is one radial oscillation per revolution. The bound Kepler orbit is an ellipse with the force centre at a focus, with one closest and one furthest approach per revolution. Its exact polar coordinates equation isAt , the ratio is : there are two radial oscillations per revolution. The isotropic harmonic oscillator trajectory is an ellipse centred on the force centre. An exact parametrization isHere repeats twice during one full circuit. The two different placements of the force centre distinguish these ellipses. These are the two all-bound-orbit cases of Bertrand's theorem.
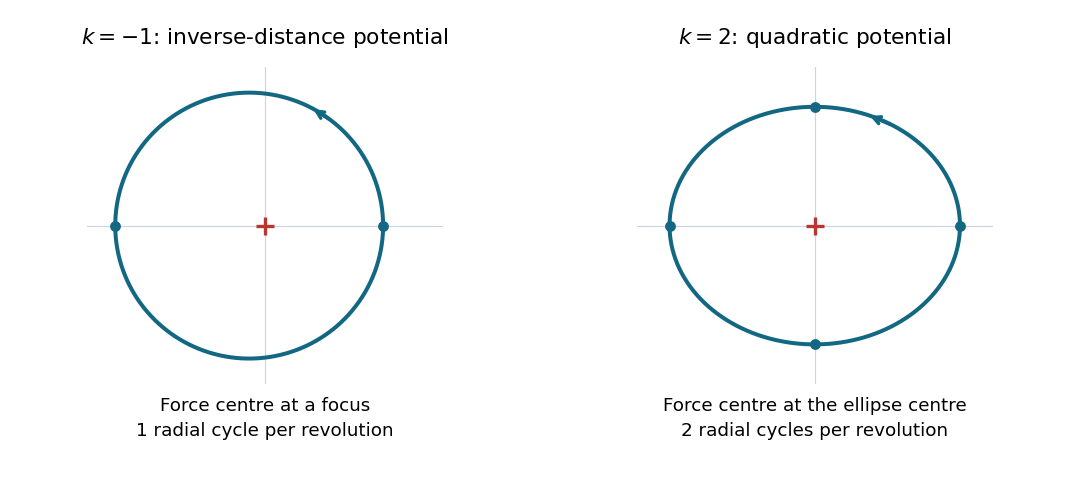
Nearly circular ellipses: one radial cycle about a focus for the inverse-distance potential, and two about the centre for the quadratic potential
. Details. 
The diagram makes the remaining distance to the wall: decreases from to . With the endpoint condition , integrating the supplied mass gradient givesAssume escaping sand has the same horizontal velocity as the bucket at release. There is then no horizontal recoil: the momentum flux of the outgoing sand cancels the contribution to the bucket's momentum derivative. The variable-mass system equation is thereforeSet , the speed towards the wall. Since , the initial condition givesConsequently the remaining sand has kinetic energyIn terms of , . Its derivative is and its second derivative is , givingThe magnitude of the remaining sand's momentum isIt is easier to maximize its square, . Its derivative is , giving the unique interior maximumBoth kinetic energy and momentum tend to zero at , even though the idealized speed diverges. There is no finite-mass bucket left at the endpoint, so that divergence signals the limit of the idealization.
The leaking bucket under constant tension has : the kinetic energy maximum is closer to the wall. As the bucket loses mass, its increasing speed continues to boost after has begun to fall. Equivalently, and , so kinetic energy has the stronger dependence on the growing speed. The work is shared between the remaining sand and the sand already lost; it is not all the bucket's instantaneous kinetic energy.
Take upward velocity as positive, and let be the rearward rocket exhaust speed. During , the ejected parcel has mass and laboratory velocity to first order. The momentum change of the rocket and this parcel equals the gravitational impulse:Discarding the second-order product gives the vertical rocket equationWith and , integration for free flight starting from rest at givesThe logarithmic term is the ideal Tsiolkovsky rocket equation contribution; is the gravity loss. Immediate upward departure requires positive initial acceleration, orAt exact equality the initial acceleration is zero, but further burning reduces the weight and permits departure immediately thereafter. If departure is allowed to be delayed while fuel burns on the pad, the condition is instead at some time before burnout. With final rocket dry mass , any powered departure before burnout requires ; the free-flight formula then starts at the actual departure time with , giving .
For the specified data, the initial mass includes the payload. The rocket fuel fraction givesThe payload is already part of the final mass; it is not the entire rocket dry mass and must not be added a second time. Here , well below the stated rocket exhaust speed, so departure is immediate. The burnout speed isThis is the speed at burnout. Subsequent motion under the assumed uniform gravity has .
For an equal-speed elastic impact on a free rod, let be the signed distance of the impact point from the rod's center of mass, , and the horizontal impulse delivered to the rod. For a smooth impact the impulse is perpendicular to the rod. If the ball's signed final velocity is , the rod's center of mass velocity is and its angular velocity is , momentum balance and angular impulse giveBoth objects have positive final translational velocities for a nonzero impact away from the centre. More explicitly, restitution in an elastic collision gives , and henceEqual final speeds thus require . One can also see that the alternative would violate .
By conservation of kinetic energy in the elastic collision,Thus . Since , elimination of givesEither side of the center of mass works; the nearer end is a distance away. The final angular speed is . These values also satisfy the restitution condition because the struck point's velocity is , reversing the initial relative contact velocity.
The free rod has the same mass and length as in part (a). There is no pivot. Put the rod's initial center of mass at and the impact end at . At impact the combined center of mass isConservation of momentum gives the combined center of mass velocity . Evaluate angular momentum about this combined center of mass; the incident ball's perpendicular lever arm is , so its initial magnitude is .
After the perfectly inelastic collision, the parallel axis theorem gives the combined moment of inertiaWith negligible external angular impulse, conservation of angular momentum therefore givesIts sense is that of the incident ball's angular momentum, clockwise in the source diagram. As a consistency check, the final kinetic energy isThus , or one fifth of the initial kinetic energy, is dissipated in sticking. Treating the rod's original centre as a fixed pivot would give an incorrect angular velocity.
Let be the center of mass acceleration downhill and the uphill static friction. Translation and rotation about the center of mass obeyThe rolling without slipping constraint is . For the coin's moment of inertia , this gives , soThe normal force is . Static friction can enforce rolling without slipping only if , givingThe static friction acts uphill to provide the torque; it is not automatically equal to , attaining that limiting value only at the threshold. For finite the result lies between and .
The cover dates this resit to 6 September 2021; its archive member is misleadingly labelled
2020/L/a10287w1.pdf.Interpret as the vertical drop of the cylinder's centre of mass, and initially take the suspended rod to be vertical. The moment of inertia of a uniform solid cylinder is . Before impact, rolling without slipping gives , so conservation of mechanical energy givesUse the usual instantaneous smooth elastic collision model: the horizontal impact impulse passes through the cylinder's centre of mass, and the floor supplies negligible tangential impulse during impact. The cylinder's angular velocity is then unchanged during impact; its rotational kinetic energy does not transfer to the bob. The rod supplies no horizontal impulse when vertical. If and are the signed cylinder and bob velocities immediately afterwards, conservation of momentum and the unit coefficient of restitution giveDuring the subsequent simple pendulum swing, conservation of mechanical energy givesThe cylinder generally slips immediately after this impact, which is consistent with imposing rolling without slipping only on the descent.
Impact convention matters. The floor-impulse dependence of a rolling-cylinder collision gives a different answer if a different constraint is imposed. If instead the floor enforces rolling without slipping throughout the impulsive collision, it supplies a nonzero horizontal impulse. The cylinder's effective translational mass is then . Writing for the impulse delivered to the bob gives , and . Hence and , giving . The original wording specifies the descent constraint but does not specify an impulsive floor-friction law; the first boxed value uses the smooth-impact convention.
Choose the heavier particle's outgoing velocity above the initial direction. Let its speed be , and let the lighter particle have components . Thus and are nonnegative deflections on opposite sides. Conservation of momentum givesThe elastic collision conserves kinetic energy:Taking the squared magnitude of the vector momentum equation yieldsEliminate with the kinetic energy equation. For a nontrivial collision, , soSubstituting back into the two momentum components givesThereforeThe ratio alone does not determine the quadrant: for , the lighter particle can move backwards. The two component equations select the correct . At , the outgoing direction is perpendicular to the initial direction; the displayed tangent has a pole there.
Let be the start of deposition and be the original moment of inertia of a uniform disc. Assume that all deposited sand sticks and remains at radius , with negligible thickness and no losses. The sand's incoming angular momentum about the vertical axis is zero. Neither the bearing nor gravity supplies an axial torque, so conservation of angular momentum givesConsequently the angular velocity and angular acceleration areThe rotational kinetic energy isThus, for ,This is mass-loaded rotation: the sticking process dissipates mechanical energy even though angular momentum is conserved. Indeed . If or , no additional axial moment of inertia is deposited and the nonzero initial rotational kinetic energy never halves.
In the inertial centre of mass frame, the Lagrangian mechanics description starts from kinetic energy minus potential energy:Define the two-particle relative coordinate . The centre of mass condition givesSubstitution therefore givesThe Euler-Lagrange equation is simply . Thus center-of-mass reduction turns a two-body problem into a one-particle central force problem with reduced mass , reducing six position components to three relative components. In an arbitrary inertial frame one adds the independent centre of mass term ; that free motion does not affect the relative solution. Since depends only on separation, conservation of angular momentum further confines a nonradial relative trajectory to a plane.
Interpret the percentage relative to the classical kinetic energy, so that . Set and use the Lorentz factor . The relativistic kinetic energy and classical kinetic energy giveFor the positive nonzero speed, insert and cancel :It follows thatHere is the proton's rest energy; the resulting relativistic kinetic energy is . The zero-speed equality before cancellation has no meaningful percentage excess because both kinetic energies then vanish.
Take positive velocity towards , and interpret as the emitted frequency in the probe's rest frame. The relativistic velocity-addition formula gives the probe's station-frame velocity:For reception at the station, photons propagate backwards while the probe recedes. The longitudinal relativistic Doppler effect givesBefore the probe overtakes , their separation decreases. The probe's velocity in 's inertial frame isThe approaching-source relativistic Doppler effect therefore givesAn independent frame calculation gives the same result: forward photons have station-frame frequency , and a receiver moving at measures . If reception occurs after the probe passes , backwards photons instead give . The direction of propagation and the reception geometry are essential to choosing the Doppler factor.
Powered ascent. Use upward signed velocity, constant gravitational acceleration , constant relative rocket exhaust speed , vertical flight from rest, no drag force, and no impulse at stage separation. The constant- approximation is an explicit modelling assumption; a varying Newtonian gravitational field would require integrating a different ascent equation. Put and . During ascent , and momentum balance gives the rocket equation with gravity:The launch rocket thrust exceeds , so immediate lift-off is consistent. At ascent burnout the entire attached vehicle still has mass , not ; the latter is the separated first stage. The burn duration and endpoint speed are
Coasting height. Integrating the ascent velocity from zero height givesFor example this follows by substituting in . At separation,The separated stage then undergoes free fall in a constant gravitational field with initial upward speed . Conservation of mechanical energy during this coast givesIts smaller mass after separation does not change that coasting height.
Reserve burn. On descending to , conservation of mechanical energy gives downward speedReset time to at reserve ignition. Now , and . Downward ejection supplies upward rocket thrust. The upward signed velocity isThus the formal free-flight burnout value iscorresponding to a formal downward speed of . Keeping throughout instead gives downward; premature rounding is especially damaging because three large velocity terms almost cancel.
The free-flight endpoint is below ground. Integrating the same reserve-burn velocity givesAt the stated endpoint this gives for . The surface is crossed at approximately , before reserve burnout. The stage has already hit the surface, so a physical post-impact burnout speed cannot be inferred without a ground-contact model. The boxed velocity is the intended ideal continuation, not an achievable free-flight landing result under these exact assumptions. In particular, the given numbers do not describe an exact soft landing. The constant-rate retro-rocket landing must satisfy both its velocity and height conditions.
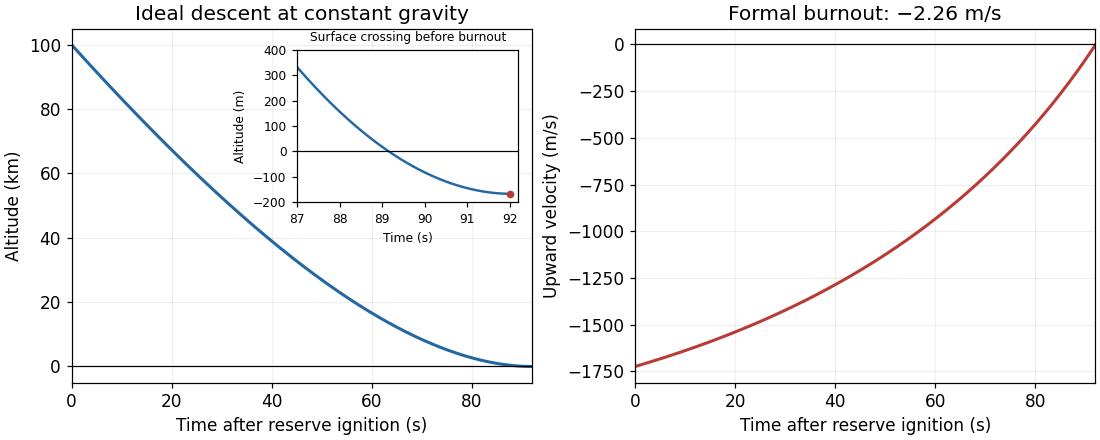
Constant-gravity reserve descent: the formal trajectory crosses ground before its nominal burnout
. Details. 
Axis theorems. The parallel axis theorem stateswhere is the moment of inertia about an axis through the centre of mass, is about a parallel axis, is the body's total mass, and is the perpendicular separation of the axes. Expanding proves the result because at the centre of mass. The perpendicular axis theorem applies to a planar lamina in the plane:All three axes meet at the same point, lie in the lamina and is normal to it; the identity follows from being the squared distance to the axis. It is not a theorem for an arbitrary three-dimensional body.
Cylinder integrals. Put the cylinder's midpoint at and its symmetry axis along . Its uniform mass density is . The transverse moment of inertia of a uniform solid cylinder about the axis isEquivalently each thin circular slice has diametral moment of inertia , by the perpendicular axis theorem and symmetry, and shifting it by adds . The parallel axis theorem then gives the transverse end-axis moment of inertia:The axial moment of inertia of a uniform solid cylinder is . Equating it to givesHere the source's principal axis means the cylinder's symmetry axis; its transverse centre axes are also principal axes. This equality describes a short cylinder rather than the thin-rod limit.
Hammer dynamics and forces. Treat the compact head as a point mass and neglect its intrinsic moment of inertia. Let be the displacement from downward vertical, and let point along the rod from pivot to head, with in the direction of increasing . DefineThe two external weights and act at distances and from the pivot. The frictionless pivot supplies a reaction but no torque about its axis. The total restoring torque and rotational equation of motion areFor completeness, Newton's second law for the centre of mass gives both components of the pivot force:The negative radial component points towards the pivot. These follow from the centre of mass acceleration and the total weight . They specify the external forces even when the oscillation is not small.
With the small-angle approximation, , this is simple harmonic motion. The physical pendulum has small-amplitude oscillation periodFor release from a finite amplitude , conservation of mechanical energy instead gives . Integrating a quarter-cycle gives the exact oscillation periodwhere is the complete elliptic integral of the first kind; recovers .
For and , compare with the simple pendulum value :For small oscillations, the hammer's oscillation period is about shorter. The extra rod weight adds restoring torque proportionately faster than it adds pivot moment of inertia.
Assume the station's mass remains fixed through an instantaneous kick, with subsequent motion governed only by the Earth's Newtonian gravitational field. Put , and work per unit station mass. The initial circular orbit has specific angular momentum and specific orbital energy given byLet denote the fractional increase of kinetic energy. The position and potential energy are unchanged during the kick, soUnchanged angular momentum at unchanged position fixes the tangential velocity; the added kinetic energy must be radial. Thus this is a radial kick, not a purely tangential speed increase. The new orbital eccentricity follows fromAt either radial turning point, the Kepler radial energy equation gives . Its two roots, equivalently the periapsis and apoapsis of the elliptic orbit, areFor , andAn inward or outward kick gives the same pair of radial turning points, although it places the station at a different phase of the orbit. These two finite positive radii require .
Retain the unchanged-angular momentum assumption of the preceding part. The initial orbit has radius , and the desired pericentre distance is . Using givesThe required fractional increase in initial kinetic energy is thereforeHere because the instantaneous kick does not change potential energy. Since the initial total orbital energy is , an alternative convention for the requested fractional energy change givesThe total orbital energy becomes less negative. Explicitly specifying its denominator avoids interpreting a positive energy input as a decrease of energy.
Let be the separation of the Earth and Moon, and let be the spacecraft's distance from the Earth's centre towards the Moon. On , the two gravitational forces oppose each other. Their equality, by Newton's law of universal gravitation, isTaking the positive square root givesThe centre of mass of the two bodies is at from the Earth's centre. Thus the gravitational field null between two point masses lies a distancefrom their centre of mass, on the Moon's side. With , and , soThe point is from the Moon. It is an instantaneous zero of the physical gravitational field, not a co-rotating Lagrange point: a spacecraft remaining fixed relative to the Earth-Moon line would need a nonzero centripetal acceleration. With zero net force it cannot follow that circular co-rotation.
Invariant and collision. For a particle of rest mass , special relativity gives relativistic energy and momentumTherefore the relativistic energy-momentum relation isIt is the squared Minkowski norm of the four-momentum, multiplied by , and hence is preserved by every Lorentz transformation. Explicitly a boost with speed along gives , , with , . Expanding gives because . Spatial rotations preserve , completing the invariance argument for all inertial frames.
For the incoming moving particle, and . The total laboratory energy and momentum before the perfectly inelastic collision areFour-momentum conservation identifies these with the final particle's energy and momentum. Its rest mass is thereforeThe result exceeds the sum of the incoming rest masses; some initial kinetic energy has become internal rest energy. Since for a massive particle,
Two-body decay. Work first in the parent's rest frame, denoted by a star. Four-momentum conservation requires equal and opposite daughter momenta. Their equal rest masses give equal energies:Thus their rest-frame velocities are . Applying the relativistic velocity-addition formula with boost gives the two laboratory velocities:Their laboratory energies follow directly from the Lorentz transformation of four-momentum:The corresponding signed laboratory momenta areTheir sums recover and , and each satisfies . One daughter moves forwards and the other backwards in the laboratory; both are collinear with the original flight axis. Numerically, , , and .
The cover identifies the ordinary sitting of 7 June 2021, despite the public bundle's filename. Solutions cover all ten questions, including every alternative in Section B.
Neglecting the planets' masses compared with the Sun's mass, Newton's law of universal gravitation supplies the centripetal acceleration of each circular orbit:Thus Kepler's third law, calibrated by the Earth's orbital period of one year and orbital radius of one astronomical unit, givesBoth orbits are taken to have the same direction. Their relative angular speed is , so the Sun-centred interval between successive conjunctions is the synodic periodUsing the supplied rounded orbital radii explains the small difference from the commonly quoted approximately twenty-year interval.
From the Earth, the two lines of sight are displaced differently because Jupiter and Saturn are at different distances. The Earth's annual motion along its orbit therefore shifts the dates of apparent conjunctions by amounts of order months. The broad recurrence remains about twenty years, but successive apparent conjunctions need not be equally spaced: apparent retrograde motion can produce a group of three conjunctions separated by months during one encounter. The Earth's daily rotation adds a much smaller change of viewpoint. This is a geometrical comparison in the stipulated coplanar model; daylight and the horizon can prevent a particular conjunction from being visible at a chosen surface location.
Take downward distance and downward speed , with constant gravitational acceleration and quadratic drag coefficient . The printed vector square has no standard vector meaning; the directionally consistent drag force is . For this downward fall, Newton's second law becomesThe terminal velocity is obtained by setting the net force to zero:From rest, the speed increases monotonically towards this limiting value. In fact ; thus it is a supremum approached at infinite time, and a tower of finite height need not permit it to be reached.
For the required distance, use the chain rule . Writing gives a linear ordinary differential equation:Consequently,Here has units of inverse length, so the result has the required units of distance and is independent of the falling mass.
First take , put , and suppose . The force is the negative derivative of the potential energy:The potential energy is an odd function, passes through , and approaches zero from above as and from below as . Its stationary points are :Thus the sole stable equilibrium is the local minimum at ; the local maximum at is an unstable equilibrium. The requested values at the stable equilibrium areThe force is an even function, positive for , negative for , and zero at . Its central maximum is . Sinceits two minima occur at , with , and at both ends. These values fix the shapes of both requested sketches.
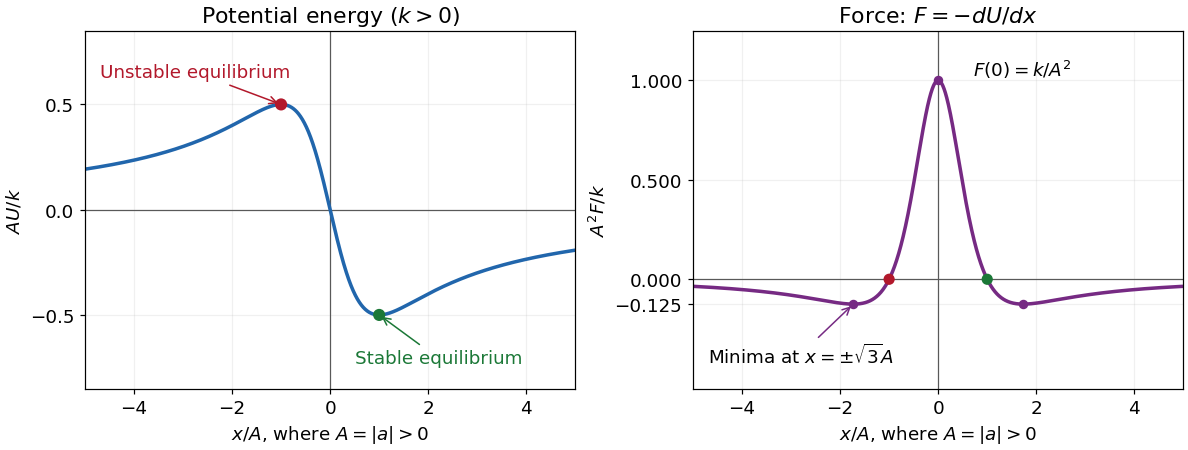
Dimensionless potential energy and force for positive k and nonzero a, with the stable and unstable equilibria marked
. Details. 
In one dimension, attraction towards the origin means , while repulsion from the origin means . With that explicitly stated convention,A positive force alone means rightward, not necessarily outward. At the origin , so it is not an equilibrium; the inward/outward distinction is undefined exactly there.
The sign assumptions matter because the paper calls merely constants. For both curves reverse sign, the stable equilibrium is , its potential energy is , and the attraction/repulsion intervals interchange. For the force vanishes everywhere on the nonsingular domain and there is no isolated potential energy minimum. If and , then for and , with no finite equilibrium.
Choose the vertical axis downward, and measure the polar angle from it. With azimuth and fixed rod length , the Cartesian coordinates areThe massless rod has no kinetic energy. Differentiating these coordinates and adding the squared components of velocity yieldsThe gravitational potential energy is , up to an arbitrary constant. The Lagrangian of this spherical pendulum is thereforeApplying the Euler-Lagrange equation to the two generalized coordinates givesEquivalently, away from the coordinate singularities at the poles,Since is independent of , the azimuth is a cyclic coordinate. Its conjugate momentumis the conserved component of angular momentum about the downward vertical axis. The polar angle is not a cyclic coordinate. Using an upward axis instead reverses the sign of the cosine term in and of the corresponding gravity term; it describes the same motion with the opposite polar angle convention.
Orient the axis along the displacement from the earlier event to the later one, so and . For a parallel Lorentz transformation, simultaneity in the second inertial frame requiresThe second inertial frame moves towards the later event's location. The positive value establishes spacelike separation, which permits this change of simultaneity. For a general velocity , the condition is : only its component along the separation is fixed at the displayed value, and transverse components are allowed provided . Thus the parallel velocity has the smallest possible speed.
A physical inertial frame must have , givingThere is no attained maximum: is the supremum. For the concrete boundary case , the events have null separation and the formula would require ; no inertial frame can make them simultaneous.
Use the Earth's inertial frame, with the Earth at and the star at light years, neglecting their relative motion. Take the stated relative velocity of to be forward along the same direction as . The relativistic velocity addition law givesIn units of light years and years, and the spacecraft worldlines are and . Their passages at the star occur atThe return radio wave from follows the leftward light worldlineIntersecting this with 's worldline gives , henceThis is the Earth-frame coordinate time of reception on , as requested; it is not the reading of 's own clock. If an observer on the Earth watched that reception through a returning light signal, they would see it later.
Each transmission from the star takes another years to reach the Earth. ThereforeAll times are measured from the common passage by the Earth; the spacecraft continue at their stated velocities during the calculation.
Inertia is resistance to a change of motion. Translational inertia is measured by mass in Newton's second law; rotational inertia about a specified fixed axis is measured by the moment of inertiawhere is perpendicular distance from that axis. For a thin uniform rod, take axes perpendicular to the rod. With linear mass density ,The second result uses the parallel axis theorem; direct integration over gives the same value. The axis specification is essential: an ideal thin rod has zero moment of inertia about its own longitudinal axis.
During the short elastic collision, neglect the impulse from gravity. The pivot can exert an external impulse, so total linear momentum of rod plus particle need not be conserved. Its torque about the pivot is zero, so conservation of angular momentum about that point applies. Let be the particle's signed outgoing horizontal velocity, and the rod's outgoing angular velocity, positive towards the incident motion. ThenSubstituting into the kinetic energy equation givesDiscarding the zero-impulse branch , the actual collision givesThe rod's lower end initially moves forward at , so the bodies separate. Afterwards the free particle undergoes projectile motion. With the pivot as origin and downward, its trajectory is , , where at the collision. The rod instead swings about the fixed pivot in a vertical plane as a physical pendulum.
The rod's initial rotational kinetic energy is . Reaching the horizontal raises its centre of mass by , increasing gravitational potential energy by . Consequently,For the threshold case, measure the rod's angle from the downward vertical and reset at its first horizontal turning point, so and . The restoring torque about the pivot gives the exact equation of motionAt the horizontal, , so the rod immediately swings back. Conservation of mechanical energy yieldsOn the initial descent its explicit time dependence is specified by the definite integralIt continues through the vertical to , reverses, and repeats without damping. An alternative expression valid throughout the oscillation uses the Jacobi elliptic sine. Put , , and let denote the complete elliptic integral of the first kind. ThenThis is not simple harmonic motion at an amplitude of . Its oscillation period exceeds its own small-amplitude value by the factor .
A simple pendulum of length obeys . At the same amplitude , its oscillation period is , soThe rod swings more slowly. Its equivalent simple pendulum length is , not the distance to its centre of mass. The same oscillation period ratio holds in the common small-amplitude limit, but replacing the actual 90-degree motion by that limit would underestimate both oscillation periods.
For a satellite of mass moving in the Newtonian gravitational field of a much larger, effectively fixed mass , put . Its conserved mechanical energy, with gravitational potential energy zero at infinity, isHere is the instantaneous centre-to-centre distance, the satellite's speed, the gravitational constant, and the semi-major axis of its bound elliptic orbit. The kinetic energy and potential energy vary around the orbit, while their sum remains constant. Dividing by and solving for gives the vis-viva equation, .
For this Hohmann transfer orbit, the periapsis and apoapsis distances are and , soThe vis-viva equation gives the endpoint speedsAs a check, conservation of angular momentum at the two endpoints gives because each velocity is perpendicular to its radius. Using and gives andThe departure impulse must increase the speed in the direction of the initial circular orbit:These are Sun-centred speeds; leaving the Earth's own gravitational field would require an additional calculation beyond this idealized solar orbit transfer.
At , the desired circular orbit speed is . The arrival impulse is thereforeThe required thrust on the spacecraft is forward, tangent to its orbit, to accelerate it. The rocket ejects exhaust backwards, opposite to the spacecraft's velocity; this distinguishes the direction of thrust from the direction in which the exhaust is fired.
The Hohmann transfer time is half the orbital period of the transfer ellipse. From Kepler's third law, relative to the Earth's one-year orbital period,Meanwhile Mars's orbital period is . The spacecraft arrives radians from its departure position. For a rendezvous, Mars must reach that same position after advancing through . Thus its initial lead angle over the departing spacecraft isMars must be ahead by this angle in the common direction of motion around their orbits. At departure the spacecraft and the Earth share the inner orbital position; arrival occurs on the opposite side of the Sun.
Take upwards in the source diagram. Write for 's incoming speed, so the initial velocities areA contact-direction assumption is needed for a unique answer. The diagram specifies the incoming velocities but does not specify the contact normal or an outgoing angle. First adopt the usual intended model: the impulse is horizontal, so neither particle changes its component of velocity. This is the smooth oblique collision model with a horizontal line of centres at impact. Bringing to rest in the direction then brings it entirely to rest.
Let be 's outgoing component of velocity. Conservation of momentum and conservation of kinetic energy givePut . The second equation becomes , so . ThereforeThe outgoing kinetic energies areThe outgoing speed of is , directed above the negative axis at angle . The initial kinetic energy is also , as required for an elastic collision.
For the perfectly inelastic collision with these same incoming velocities, both particles share a common outgoing velocity. Conservation of momentum givesIts direction is again above the negative axis. The separate translational kinetic energies of the constituents and their total areThe loss of translational kinetic energy isThis becomes internal energy, for example deformation and heating; total energy is conserved. In the elastic collision no kinetic energy is lost and the particles separate with different velocities. In the perfectly inelastic collision relative motion disappears and the common velocity is the original centre of mass velocity.
The limitation of the printed data can be made explicit. Without the horizontal-impulse assumption, write the final velocity of as . Then conservation of momentum determinesand conservation of kinetic energy gives onlyThere is a family of possibilities. For a concrete second solution, givesThese velocities conserve both components of momentum and conserve kinetic energy, and they satisfy the specified vanishing component for , while requiring a different incoming speed. They can arise from a smooth contact normal proportional to . Thus the horizontal-impulse result is conditional, rather than uniquely implied by the printed statement. For any member of this family the corresponding sticking result remains well determined once is chosen:The last expression is the lost relative kinetic energy in a perfectly inelastic collision of these two point masses.
The laboratory is the parent's rest frame. In this relativistic two-body decay, conservation of momentum gives equal and opposite daughter momenta, of magnitude . Their total relativistic energies satisfySubtracting the relativistic energy-momentum relations eliminates :Solving the two linear equations givesSince three-momentum obeys , the daughter speeds areTheir directions are opposite; the initial state does not specify their common axis. The kinetic energies are and . Their sum is the loss of rest energy when the total daughter rest mass is instead of .
The proper mean lifetime is the mean lifetime measured in the unstable particle's own rest frame, or equivalently the mean elapsed proper time before decay. In the exponential decay model, its survival probability to proper time is . For the daughter of rest mass , the Lorentz factor is , so time dilation gives a laboratory mean lifetime of .
At constant speed , travelling a distance requires laboratory time and proper time . Its mean decay length isfor . HenceThe mean lifetime sets the scale of an exponential distribution; it is not a fixed deadline, so travelling beyond one mean decay length has a nonzero probability.
Articles were limited to the first 100 out of 748 total.
Articles by others on the same topic
There are currently no matching articles.