Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 116 5 Solution by  Codex 0 Created 2026-10-03 Updated 2026-10-14
Fix a reference path from to . By path connectedness, a path can be joined to it by a smooth homotopy strip withSmooth homotopies may be used by the relative smoothing theorem; piecewise smooth homotopies give the same integrals. Orient the square by and define the Lagrangian path-area functional byHere denotes the functional called in the question. The minus sign is the convention for which downward gradient flow is -holomorphic on the standard oriented strip.
For relative symplectic-area independence, glue two choices, with one orientation reversed, along their common reference and final paths. The resulting oriented surface is a relative -cycle in . Since , it bounds a relative -chain: as an absolute chain, for a chain supported in . The symplectic form is closed, and it restricts to zero on each Lagrangian submanifold. Using piecewise smooth relative chains, Stokes theorem givesEquivalently, integration of the closed symplectic form defines the zero pairing on the zero relative homology group. The two strips therefore define the same value of .
Choosing a different reference path changes every value by the negative area of one fixed connecting strip, independent of . Changing the initially assigned reference value also adds a constant. Path connectedness ensures that this is one global constant, rather than an independent constant on each component.
For the first variation, let be a variation vector field along , with and . Differentiate the defining strip integral. Stokes theorem, or the variation formula for the integral of a closed differential form, reduces it to the final edge; the side edges give zero because their variations and tangent vectors lie in the Lagrangian submanifolds. With the chosen sign,If this vanishes for every admissible , it in particular vanishes for every field supported in . Nondegeneracy of the symplectic form, together with the fundamental lemma of the calculus of variations, forces in the interior and hence everywhere by smoothness. Conversely, a constant path makes the displayed integral zero. The constant must lie in both endpoint submanifolds. ThusNo transverse-intersection assumption is required; the critical set can be empty or have positive dimension.
A compatible almost complex structure is a smooth bundle map such thatThese conditions makea Riemannian metric. Its symmetry follows from the -invariance and skew symmetry of , and its positivity is the final compatibility condition. It also satisfies .
Use the formal metric on the path space,The variation formula becomesThus a formal downward flow satisfiesPut the standard complex structure on the strip, with . The J-holomorphic curve equation says , which is equivalent to the displayed flow equation because . The converse is identical: a smooth J-holomorphic curve on the strip with the specified Lagrangian boundary conditions gives a formal downward trajectory of .
As a sign check, along such a strip,The drop in therefore equals the positive symplectic area swept out by the strip. The word formal matters: the calculation gives the interior equation and its Lagrangian boundary conditions; it does not assert that arbitrary smooth initial paths produce a well-posed ordinary flow on the smooth path space. In particular, the expression need not satisfy the endpoint tangent restrictions for an arbitrary initial path. The claimed correspondence concerns smooth solutions of the strip equation.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 116 4 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Take the normalizationThe first variation of geodesic energy says that the critical points on the fixed-endpoint path space are exactly the affinely parametrized geodesics. The kernel of the second variation of geodesic energy, or Riemannian index form, is the space of Jacobi fields vanishing at both endpoints. Hence a geodesic is a nondegenerate critical point exactly when that space is zero, or equivalently when its terminal endpoint is not a conjugate point to its initial endpoint along the given geodesic.
The Morse index theorem states that the index is the sum of the multiplicities of all conjugate points strictly inside the parameter interval:The multiplicity at the terminal endpoint gives nullity rather than an additional contribution to the index. These statements use the usual Sobolev completion of the path space; smooth paths have the same homotopy type.
First suppose as well as , and put . There is a unique great circle through these two points. Every critical path runs along it with constant speed, possibly passing around it extra times. Ifthen a complete enumeration without repetitions isIts length is . Equivalently the two positive length lists areThere are no other critical paths, because a nonconstant geodesic of the round sphere is a constant-speed great circle and its plane must contain .
To compute conjugate points and indices of round-sphere geodesics, the round unit sphere has constant sectional curvature . Along a geodesic of speed , a normal Jacobi field in a parallel direction satisfies . A field with is therefore a constant multiple of in each of the normal directions. Its tangential component satisfies and contributes no endpoint-vanishing field. Consequently the conjugate points occur at , each with multiplicity . Since neither length list contains an integer multiple of , all the displayed critical paths are nondegenerate, and the Morse index theorem gives
The permitted case requires separate treatment. There is a constant geodesic, which has index and nullity zero. All other critical paths areFor each , this is a family parametrized by ; both directions of traversal are included through and . The interior conjugate points number , and the endpoint is also conjugate. ThusThese are Morse-Bott critical manifolds for , rather than nondegenerate critical points. For the same formulas give zero index and nullity, with the two isolated directions comprising .
For the requested homology calculation, choose distinct nonantipodal endpoints. Concatenation with a fixed path back to the basepoint gives a homotopy equivalence between this fixed-endpoint path space and the based loop space . We use the Morse cell-attachment theorem for geodesic energy: on a complete compact Riemannian manifold, the fixed-endpoint energy, when all its critical points are nondegenerate, gives a CW complex of the same homotopy type with one cell of dimension equal to the index of each critical point. One can obtain this theorem from finite-dimensional broken-geodesic approximations and ordinary Morse theory; critical energy values tend to infinity here.
The two index lists interleave to give exactly one cell in every dimension , . If , these dimensions are separated by at least two. The cellular homology groups therefore have zero boundary maps, since no occupied cell dimension has an occupied dimension one lower. With integer coefficients,This determines the graded abelian groups. The argument does not need an identification of the multiplication on loop-space homology.
Finally apply the Freudenthal suspension theorem: for an -connected based CW complex , , the suspension homomorphismis an isomorphism for and a surjection for . A sphere is -connected, and its reduced suspension of a topological space is homeomorphic to . HenceThe isomorphism is the suspension map. Its stable range is also reflected by the Morse theory cell structure of : after its bottom -cell, the next positive-dimensional cell has dimension . For the stated homology problem , all the connectivity hypotheses apply.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 116 3 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Use the Riemann curvature tensor convention . A Jacobi field is a smooth vector field along satisfyingwhere is the covariant derivative along a curve for the Levi-Civita connection. Differentiating a geodesic variation gives this equation, and conversely every Jacobi field arises from a geodesic variation by varying its initial point and velocity.
Choose a parallel frame along and write . The Jacobi equation becomes the linear systemThe existence and uniqueness theorem for linear ordinary differential equations says that each pair determines exactly one solution on . Addition and scalar multiplication preserve the equation. Thus evaluation of initial position and covariant velocity is a linear isomorphismand the dimension is
For the convexity assertion, use the convex-normal meaning of a geodesically convex open set: its points are joined by a unique geodesic within the set, and the joining geodesic depends smoothly on its endpoints. Equivalently, the appropriate star-shaped restriction of is a diffeomorphism onto the set. The convex-normal-neighbourhood theorem supplies such sets around every point. Mere existence of some minimizing geodesic, without this uniqueness and normality, would not imply the assertion.
Let and . For a Jacobi field with and , differentiating gives the standard differential-of-the-exponential map identityIn a convex normal neighbourhood, is invertible. Therefore a Jacobi field vanishing at both endpoints has and hence is identically zero. The difference of two fields with the same endpoint values consequently vanishes. More precisely, the mapis an isomorphism: it is injective and both spaces have dimension . The constant-geodesic case follows directly from . This uses the convex-normal-neighbourhood theorem, the differential-of-the-exponential map identity, and linear ordinary differential equation uniqueness.
For the special unitary group example, use Jacobi fields from conjugation at a central endpoint. WriteThe endpoints of are and . The latter is central. For every considerConjugation is an isometry for a bi-invariant Riemannian metric, and geodesics of a bi-invariant metric are one-parameter subgroups. Thus is a geodesic variation. Its Jacobi field iswhich vanishes at and because both endpoints are central. Its initial covariant derivative is .
The linear map has kernel equal to the centralizer of an element of a Lie algebra of . Indeed, implies on differentiating at , and that commutation conversely implies . The repeated first two eigenvalues giveAs , rank-nullity theorem givesExplicit independent generators are the fields belonging to , , and . Their initial derivatives are independent because the eigenvalue differences in the and entries are . This also demonstrates directly why the endpoint-value conclusion fails along this geodesic.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 116 2 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06An index- handle is , attached along . Its attaching sphere is with its attaching framing of an embedded sphere, and its belt sphere in the new boundary is . A handle decomposition is an ordered sequence of such handle attachments.
A handle slide of one -handle over another replaces its framed attaching sphere by a band sum with a parallel framed copy of the second attaching sphere, along a band in the boundary of the previously attached handles. The second handle stays fixed. The band transports the framing of an embedded sphere. The union of the two handles and their attaching collars can be reidentified by a diffeomorphism, so this changes the decomposition, rather than the underlying manifold. A sequence of these moves, allowing the usual isotopies of attaching data, gives handle decompositions related by slides. Reading the decomposition backwards interchanges attaching spheres and belt spheres; a slide of dual handles is a slide of the corresponding original handles.
For the standard handle-calculus assertion, take , so both the relevant attaching and belt spheres are connected. We need the local geometric move behind handle-slide isolation of a cancelling pair. Write . If is an intersection of some , , with , choose an arc on from to , and take a narrow parallel band to the unique sheet of at . Slide over an appropriate parallel copy of . Choose the copy's orientation so that the new sheet at has the opposite local smooth intersection number to the sheet at .
Within a thin neighbourhood of the arc, the old sheet at and the added sheet at are the two ends of one band. An isotopy pushes that band through the neighbourhood of and removes both ends. Outside this neighbourhood the original is unchanged, apart from the added copy of the parts of away from . Since meets only at , this copy contributes no further intersections with . Thus one slide followed by an isotopy removes one original geometric intersection with . This is a local band move, not an appeal to handle cancellation or to an algebraic cancellation of signs.
The arcs and bands may be chosen one at a time; in the one-dimensional sphere case, start with an intersection adjacent to , so that the arc interior contains no other intersection. Perturb to make all intersections transverse. The relevant spheres are compact, so there are only finitely many intersections. Repeating the move for every leaves and fixed and givesThe bands can avoid the remaining attaching data; any consequent change to intersections with other belt spheres is allowed at this stage.
For the second stage, view the same interface from the dual decomposition. Now are attaching spheres and are belt spheres. Apply the same local move to each intersection of , , with , sliding that dual handle over the one with attaching sphere . This changes the original -handles. It keeps and fixed, while removing the unwanted intersections with . The parallel copies and bands may be taken disjoint from all , , because those spheres are already disjoint from and from . Hence their intersections with remain empty. We obtainNo handle has been removed.
There is an implicit index-range qualification in this geometric assertion. If arbitrary zero-handles are included, the second conclusion need not hold: two zero-handles joined by one one-handle have an attaching zero-sphere with one endpoint on each zero-handle belt sphere. Slides preserving this handle inventory cannot make its second endpoint avoid both belts. The dual obstruction occurs for top-index handles. Thus the argument uses the customary intermediate-index setting of the handle-slide lemma; the unqualified assertion at the extreme indices would require additional hypotheses or additional moves.
For the numerical formula, fix coherent orientations for the integer smooth intersection numbers, and letKeep the orientation at the surviving point, so its number remains . A slide of a -handle adds or subtracts the first row of the intersection matrix. Removing all geometric intersections in the first column has net row operationEven if opposite-sign intersections require extra slides, their net signed coefficient is the displayed one. In particular,The dual slides then perform the column operationsSince , these operations leave the lower-right block unchanged. Thus the final answer, including both stages of slides, isThe remaining block is the Schur complement of the unit pivot . If the original orientation is chosen so that , it is simply . For unoriented handles use intersection numbers modulo , with the same formula interpreted in .
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 116 1 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14Along the downward gradient flow, the gradient-flow dissipation identity, the chain rule and the defining property of the Riemannian gradient giveA smooth vector field on a compact manifold is complete, so the trajectory exists for every . In particular, its function value never increases.
If the trajectory is still in at time , its monotone function value has stayed in throughout . ConsequentlyThus a uniform exit bound isThe trajectory is outside the closed band for every . Once it leaves below level , monotonicity prevents its return. The argument also covers the zero-width band .
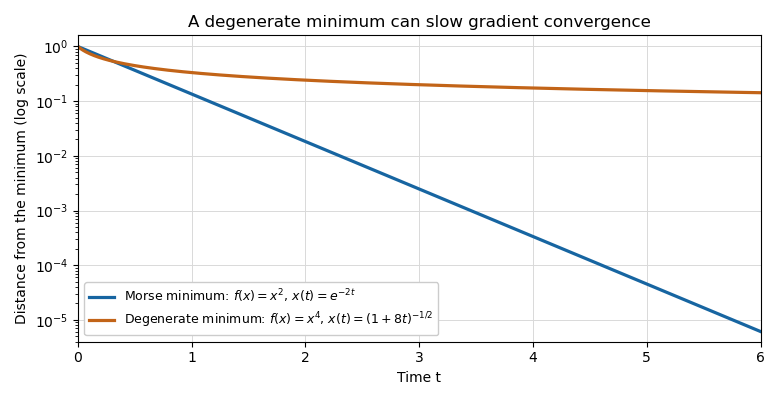
For the total occupation-time bound for a gradient flow, let and , which exist by compactness. For every , the same gradient flow identity givesTaking , by monotone convergence theorem, gives the total occupation-time boundThis allows arbitrarily many visits to ; it bounds their total duration. Neither of these two estimates needs the Morse function hypothesis.
For exponential convergence of a Morse gradient flow, first observe that a limiting point is a critical point. Indeed, writing for the flow and using continuous dependence on initial data,Differentiation at gives .
We use the Morse lemma: near a nondegenerate critical point of Morse index , there are coordinates in whichChoose a Riemannian metric equal to the Euclidean metric on a smaller ball in these coordinates. Such a global Riemannian metric exists by a partition of unity: patch this metric to any background metric outside a slightly larger ball. One can do this simultaneously at every critical point, since a Morse function on a compact manifold has only finitely many critical points. The metric is chosen before forming its gradient flow; changing the metric can change trajectories.
For this metric, any trajectory converging to eventually remains in the smaller coordinate ball. From some time onward its equations are exactlyConvergence forces , and thenThe straight radial segment stays in the coordinate ball, so its length bounds the Riemannian distance from above:Increase beyond both and . Then the requested strict estimate holds for all :This proof uses the Morse lemma, existence and uniqueness for smooth ordinary differential equations, continuous dependence on initial data, and the existence of a partition of unity. The expanding coordinates explain why convergence to a saddle occurs only along its stable manifold.
For a counterexample, use an arc coordinate around a point of the circle, its flat local metric, and a globally smooth function that equals on this arc. Such a function can be made by a smooth cutoff, agreeing with a positive constant outside a larger arc. For sufficiently small the downward gradient flow remains in the arc and isIt converges to the degenerate critical point , and its Riemannian distance from is for sufficiently large . For every , , so no exponential bound is possible. This counterexample is on a compact manifold as well.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 115 4 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Let be the inclusion. The restriction of a connection to an embedded submanifold is the pullback connection on . Concretely, for a tangent vector field on and a local section of , extend smoothly off and define by differentiating the extension in direction . Two extensions differ by a field whose coefficients vanish on . Their derivatives along every tangent curve in vanish too, and the connection's coefficient terms are multiplied by the zero field. The answer is therefore independent of the extension. Dependence only on the value of the first argument follows from the connection's linearity over smooth functions.
The induced Riemannian metric is positive definite, so the fibrewise orthogonal projection is smooth. For tangent fields define the projected ambient connection . It is real-linear and satisfiesbecause . Thus is a Koszul connection on .
The Levi-Civita connection is characterized by the torsion-free connection and metric connection conditionsThese determine it uniquely. For the ambient Levi-Civita connection, the Gauss formula is , withLinearity over smooth functions in is immediate. In , the additional term is tangent and is killed by . Thus tensoriality makes a bilinear map into the normal bundle. Its antisymmetric part isbecause the Lie bracket of vector fields tangent to is tangent. This proves the symmetry of the second fundamental form in an arbitrary Riemannian ambient manifold.
Write the curvature operators as and with in place of . To match the four-slot notation in the requested identity, useThis convention is stated because permuting the slots can change the displayed signs.
If is a normal field and is tangent, metric compatibility applied to gives the tangential derivative of a normal field identityUsing the Gauss formula and this identity,Here the normal part of pairs to zero with . Interchange and subtract; the bracket term obeys . It follows thatRearranging proves the Gauss equation in a curved ambient manifold:All expressions are tensorial, so choosing local extensions of the four tangent vectors proves the pointwise identity at . With flat Euclidean ambient space, and this reduces to the usual Gauss equation.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 115 3 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-14
Codex 0 Created 2026-10-03 Updated 2026-10-14A smooth vector field along a map is a smooth section of the pullback tangent bundle : it assigns , with smooth coefficients in each local frame. It need not be the restriction of one ambient vector field, since a curve may return to the same point with different values of .
An affine connection, also called a Koszul connection, induces a pullback connection on this bundle. In coordinates, write and . Its covariant derivative along a curve isThe connection transformation law, or the Leibniz rule applied to a change of frame, makes this expression independent of the frame. In particular it is defined even when ; it differentiates the section's coefficients as well as the frame.
The field is parallel precisely when . In a frame along a coordinate segment this is the linear ordinary differential equationThe Picard-Lindelöf theorem gives a unique solution with prescribed initial value. Smooth coefficients on compact subintervals are bounded, and the usual norm estimate for a linear ordinary differential equation prevents finite-time blowup there. A finite sequence of coordinate segments covers the image of the compact interval ; solve successively and use uniqueness on overlaps. This gives a unique parallel field on the whole interval for every .
Define parallel transport by . Linearity of the equation and uniqueness give . Solving along the reversed curve supplies its inverse. Therefore each is a linear isomorphism.
For two affine connections, put . Their rules givesince the two terms cancel. The tensoriality of this operation proves that the difference of affine connections is a tensor, of type , with smooth coordinate coefficients .
A parametrized geodesic satisfies , or the geodesic equationWith , this becomes the first-order system , . Its right side is smooth, so the Picard-Lindelöf theorem gives a unique local solution for each initial point and tangent vector. This establishes uniqueness with the parametrization fixed.
The two accelerations differ byIf for every tangent vector, either acceleration vanishes exactly when the other does. Conversely, start the -geodesic with arbitrary initial vector at an arbitrary point. If it is also a -geodesic with the same parameter, evaluating this identity initially gives . HencePolarization makes the latter condition equivalent to : parametrized geodesics determine the symmetric part of an affine connection. In particular torsion-free connections are determined by their parametrized geodesics, since their difference is also symmetric and must then vanish.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 115 2 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06In a manifold chart, write a smooth differential form as , with increasing. Define its exterior derivative byTo check that this definition is global, change coordinates to . The chain rule expresses as . Differentiating it gives zero because the second partial derivatives of are symmetric and is antisymmetric. The coordinate definition satisfies the graded Leibniz rule, so differentiating the transformed expression for leaves exactly . This agrees with the original formula and proves independence of the manifold chart. The same cancellation of mixed derivatives gives .
The de Rham cohomology is thereforethe vector space of closed differential forms modulo exact differential forms.
Here is a Green-theorem proof of exactness on a disc. Identify the disc with a round disc centred at zero, and let be a closed differential form. Set . For and in the disc, Green theorem on the oriented triangle with vertices gives zero boundary integral, since . HenceTaking and dividing by yields . The radial integral defining is smooth, so andDegenerate triangles follow by continuity. The same proof works on any star-shaped plane domain, including the whole plane.
Integration requires an orientation: take to be an oriented compact -dimensional smooth manifold without boundary. The Generalized Stokes theorem says for every smooth -form . Every -form is closed by dimension, and changing it by an exact differential form leaves its integral unchanged. Thusis a well-defined linear map . Compactness alone does not supply the orientation omitted from the printed integration statement.
For an -dimensional Lie group, choose a nonzero and define the invariant volume form on a Lie group byEach is an isomorphism, so is nowhere zero and defines an orientation. The composition identity gives . Moreover, every left-invariant differential form of degree is determined by its value at , so the space of such forms is one-dimensional.
Under the supplied invariant-representative assumption, all top-degree de Rham cohomology classes are multiples of . For compact , orient it so is positive; then , whereas the Generalized Stokes theorem makes every exact top form have integral zero. Therefore andunder that assumption. For actual compact Lie groups, this argument applies when is connected. The supplied assumption fails for disconnected groups: on , the two components have independent degree-one classes, while globally left-invariant top forms form only a one-dimensional space. In general the top-degree de Rham cohomology of a compact Lie group is , where is its number of connected components.
For , use and . Stereographic projection identifies each with the plane. The disc argument gives and for any closed differential one-form . The overlap is connected, so makes the difference a constant. Adjust one potential by that constant; they glue to a global smooth function with . ThusFinally, is a compact connected Lie group: the identificationidentifies it smoothly with the special unitary group . Matrix multiplication and inversion supply its smooth group operations. The preceding invariant-volume argument therefore gives
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 115 1 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06A smooth vector field is a smooth section of a vector bundle of the tangent bundle, so . In a manifold chart, with smooth coefficients. It acts on a smooth function by . For a diffeomorphism , the pushforward of a vector field isThe Lie bracket of vector fields is the commutator of their actions on smooth functions:The second derivatives of cancel, so this is again a vector field. The corresponding Jacobi identity is .
A local flow of is a smooth map on an open neighbourhood of satisfying and . On a sufficiently small neighbourhood and time interval, each is a diffeomorphism onto its image, with inverse . Uniqueness of integral curves of a vector field gives wherever both sides are defined. These are local statements; no assumption of a complete vector field is required.
A smooth tensor field of type is a smooth section of , where the factors are the tangent bundle and cotangent bundle. The flow definition of the Lie derivative of a tensor field isHere pullback applies to each vector factor and the dual of to each covector factor, evaluating at . Thus all tensors being differentiated lie in the same fibre over .
For a smooth function, , and the chain rule givesFor a vector field , in local coordinates the expansions and giveConsequentlyPullback preserves tensor products and tensor contractions, so differentiation makes this definition a tensor derivation. It therefore agrees on every tensor field with the Lie derivative of a tensor field determined by these two formulas.
Now put . The chain rule givesThus is the local flow of . In the case , if , uniqueness of integral curves of a vector field makes on their common domains, or . Conversely, differentiating this commuting identity at zero gives , hence . This proves that diffeomorphism invariance of a vector field is equivalent to commuting with its local flow, with every identity understood on the domain where its compositions exist.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 114 5 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Here is an intrinsic definition that also proves well-definedness. For a complex line bundle , define its First Chern class to be the Euler class of its canonically oriented underlying real rank-two bundle: pull its integral Thom class back along the zero section after forgetting relative support. The complex orientation fixes the sign, so this construction makes no arbitrary choice of generator.
For a rank- complex vector bundle , let be its projective bundle of lines, let be the tautological bundle, and put . On every fiber , is the positive degree-two generator. The Leray-Hirsch theorem says that if globally defined cohomology classes restrict to a free basis of the cohomology of every fiber, then multiplication by those classes identifies the cohomology of the total space with a free module over the base. Applied here, it givesThe finite trivializing cover in the question is sufficient for this application: the assertion holds on each trivializing open set by the Künneth theorem, since the fiber has finite free cohomology, and the Mayer–Vietoris sequence and the Five lemma glue it over the finite cover. The same local argument constructs the oriented Thom class used for line bundles. It does not require a choice of classifying map.
There are therefore unique classes such thatDefine and for . For rank zero the Total Chern class is . This is the projective bundle definition of Chern classes. Existence and uniqueness follow by expressing in the displayed free module basis, with degrees determining each coefficient. The projective bundle and tautological bundle are intrinsic to , and the line Thom class is uniquely fixed by orientation. Hence the resulting Chern classes do not depend on trivializations or other auxiliary choices. For a line bundle the relation is , agreeing with the original normalization. Pulling back this unique relation also proves naturality. This standard construction and the sum theorem are treated in Vector Bundles and K-Theory, Section 3.1.
The requested result is the Whitney sum formula for Chern classes:Here , and the formula holds for complex vector bundles over a common base. In particular, a trivial bundle has total Chern class .
Now take and let be its tautological bundle. The standard Hermitian inner product gives the rank- complex bundle , with . The orthogonal complex line flag manifold in the question is precisely : over a first line , the second line is any line in . Local orthonormal frames give this identification as a fiber bundle, with fiber .
Let on , also writing for its pullback to . By part 3(a), . The Whitney sum formula for Chern classes givesLet be the second tautological line on , and set . Thus are exactly the pullbacks of the positive hyperplane classes from the two projective factors. The projective bundle definition of Chern classes for givesTogether with , this gives a surjective graded ring mapThere are no additional relations. Indeed the second relation is monic of degree in , so polynomial division makes its source free over on . The projective bundle formula for complex vector bundles gives exactly the same free basis on the target. The map sends each basis element to its corresponding basis element, and is therefore an isomorphism. ConsequentlyThis is the cohomology ring of the orthogonal complex line flag manifold. Its additive basis is with , . As a symmetry check, multiplying the second relation by gives , so as expected from the second projection. For , every line has a unique orthogonal line, and the relations become , , giving the ring of . If , the space is empty and the second relation is , so the printed formula still gives the zero cohomology ring.
Past exam of the mathematics course of the University of Cambridge 2016 iii Paper 114 4 Solution by Codex 0 Created 2026-10-03 Updated 2026-10-06
Codex 0 Created 2026-10-03 Updated 2026-10-06Let and . Here a closed submanifold means compact and without boundary, which is the condition needed for a compactly supported dual class. The orientations of and orient the normal bundle . Its Thom class is the unique relative class of degree restricting to the chosen orientation generator on every normal fiber. A tubular neighborhood identifies this class with one near in . Choose a compact normal disc neighborhood and extend the relative class to compactly supported cohomology of . Equivalently, apply Poincare duality to the pushed-forward fundamental class of :This compactly supported dual of a compact submanifold is independent of the tubular neighborhood and represents intersection with . Fix the convention in complementary degree. Its image in ordinary cohomology restricts to zero on , because it comes from relative cohomology supported near . If a submanifold is only closed as a subset but is noncompact, its usual dual lies in ordinary cohomology instead; compact support is not asserted in that situation.
Now let be the diagonal, with the orientation inherited from , and let . For each , choose a basis of and its dual basis of satisfying . The Poincare duality pairing and the Künneth theorem give the cohomology class of the diagonalThe sign can be checked from the defining identityFor , moving the degree- class in the second factor past contributes , and interchanging and contributes ; the displayed coefficient cancels their product. Equivalently its exponent is modulo two.
The cohomological pushforward between closed oriented manifolds is characterized byfor complementary degrees. This follows immediately from its definition by Poincare duality and naturality of evaluation on pushed-forward homology. In degree , the matrix trace of on is consequentlyFor finite-dimensional maps between two possibly different vector spaces, . Thus this matrix trace equals that of on . Pulling back the diagonal formula by and applying graded commutativity of the cup product now yieldsThis establishes the Lefschetz coincidence number with the requested sign convention.
If for every , the map factors through . The diagonal class restricts to zero there, so its pullback is zero and . Taking the contrapositive proves the Lefschetz coincidence theorem:No transversality or isolated-coincidence assumption is needed. This cohomological argument also applies to continuous maps, which covers the last request.
For a map of degree , the adjoint identity above gives, for all complementary classes on ,Nondegeneracy therefore gives . Cyclic invariance of matrix trace proves the self-coincidence number of a map of nonzero degree formulaIn particular, has one even-dimensional cohomology generator in each degree , so . HenceIf is homotopic to , homotopy invariance of cohomology gives and thus . The Lefschetz coincidence theorem supplies a point at which and agree.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:



All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact