The Stokes theorem states that for an oriented smooth surface with compatible oriented boundary and a continuously differentiable vector field,Here , whereas a normal vector to the specified plane is . Their dot product is zero. Thus every closed curve in that plane has zero circulation by the Stokes theorem.
The source says “any curve” and displays an ordinary line integral, without specifying that it is closed or giving endpoints. An open curve need not give zero. On the plane, put and ; the pulled-back differential one-form becomesTherefore the complete endpoint-dependent answer iswhich specializes to zero for a closed curve. For example, the path from to lies in the plane and has integral . This illustrates a conservative restriction of a vector field to a plane despite nonzero ambient curl.
The velocity vector of the helix is , whose Euclidean norm is . Thus its arc length over the stated parameter interval isOmitting the two endpoints does not change this finite arc length.
Rationalize the difference of square roots before taking the limit. For positive , divide the resulting numerator and denominator by :Each factor now has a finite nonzero denominator limit, giving
For , increases from , while decreases from . They meet at , after which their order reverses. In particular, their positive separation on is .
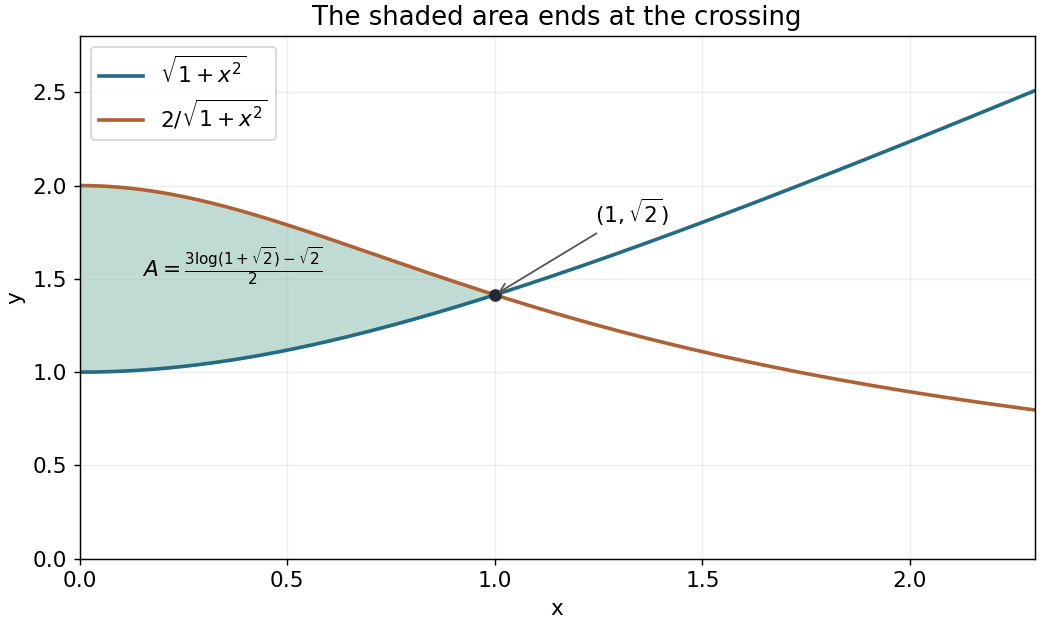

Use the hyperbolic substitution , . With , the definite integral for the area becomesSince , and , the answer is
Let . Implicit differentiation of the two constraints gives the linear systemAdding them, then substituting back, gives at regular pointsThe relevant Jacobian determinant is . Thus the special parameter value is , assuming the other factors are nonzero. At that parameter, adding the original constraints gives : the intersection curve lies wholly in the plane and cannot be parametrized by on an interval. Calling its derivatives “infinite” describes a vertical projection, not a finite-valued differentiable pair at ; the displayed ratios then have simultaneous zero numerators on the intersection and are undefined.
There are also point-dependent failures when , or . These can produce vertical tangents or require a different local parameter, and simultaneous numerator zeros need separate analysis. The implicit function theorem guarantees finite only where the stated Jacobian determinant is nonzero. This distinction is the geometry of a singular projection of an implicit curve.
Multiply the secant function integrand by :The numerator is the derivative of the denominator. The formula holds on any real interval avoiding zeros of ; on such an interval cannot vanish because .
Write the initial triangular pulse as the function , extended by zero to negative arguments:At , the initial displacement and zero velocity give and on the positive half-line. Fix the harmless opposite additive constants by taking both travelling waves to vanish at positive infinity. ThenThe second formula follows from the fixed-end boundary condition . Thus is one-half of the odd extension of the initial displacement, andThis is the odd-extension solution for a semi-infinite fixed string: the reflected displacement reverses sign. Evaluating the travelling profiles givesThe first profile is a positive triangle supported on , with peak at . The second has a negative triangle on with minimum at , and a positive triangle on with maximum at .
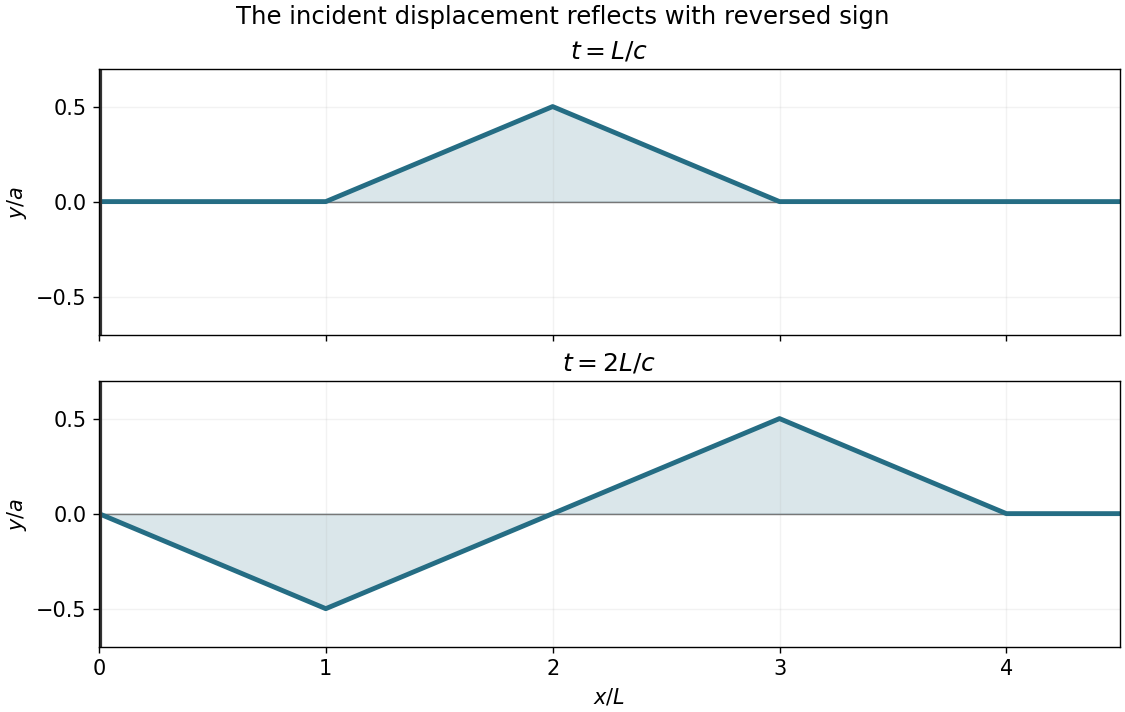
The two requested displacement profiles after fixed-end reflection of a triangular pulse, with lengths scaled by and heights by
. Details. 
The gradient is , so the real stationary points are and . The Hessian matrix is diagonal, with entries and . At the origin it has opposite-sign eigenvalues, giving a saddle point. At each of the other two stationary points it is negative definite, giving strict maxima of value . These are also the global maxima, sinceThere are no local minima, and the function is unbounded below. The zero contour has two lobes touching at the saddle; positive contours are closed curves around the maxima.
Under the stated change of variables,Inside the resulting circular cap the constraint is automatic. Comparing its circle and horizontal boundary givesHere is the positive half-width used in the source figure, independent of the pulse-height notation in the preceding question. The Jacobian determinant is in the chosen quadrant, so the integral is one-quarter of the circular segment area:
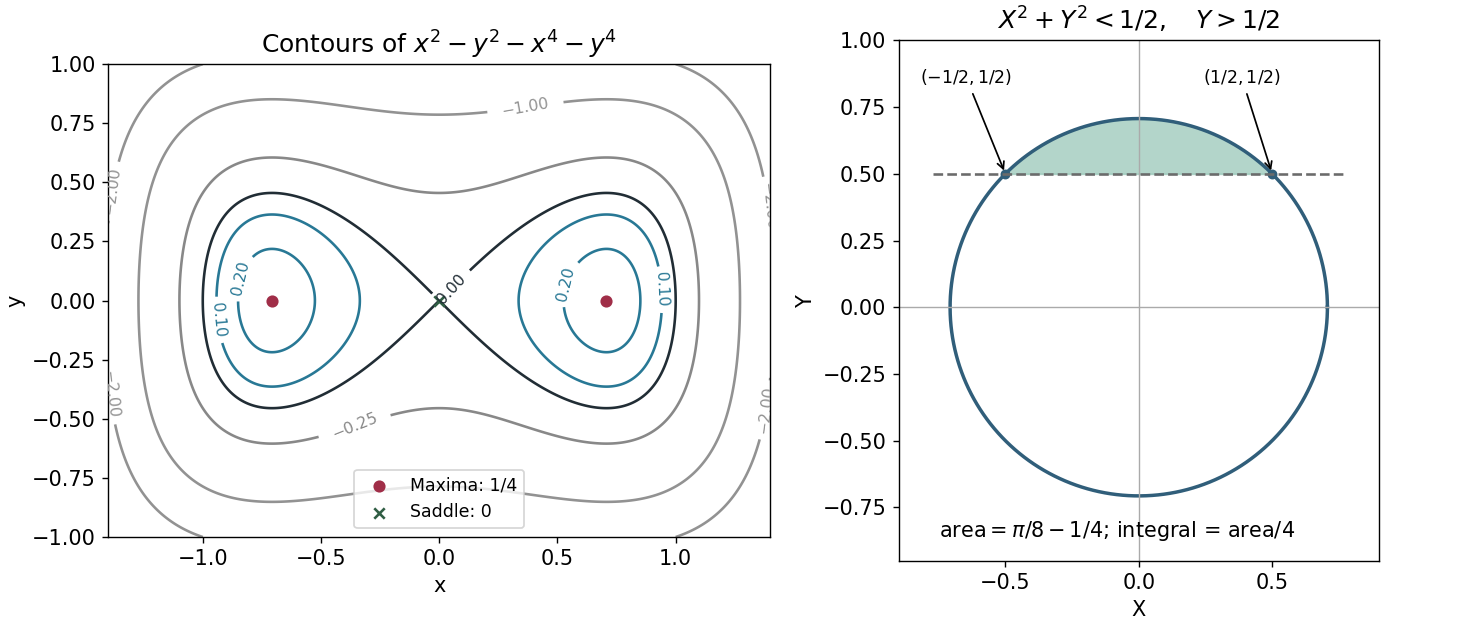
The contours, maxima and saddle, and the circular cap produced by the change of variables
. Details. 
Apply the divergence theorem to . Since are constant and is a solenoidal vector field, the product rule givesIts boundary flux vanishes when has compact support, or when its normal component vanishes on the boundary of the integration volume. Integrating therefore provesFor a discontinuous field, the divergence-free hypothesis must include its boundary jump, in the sense of a weak derivative. A field that merely has zero divergence at interior points can still have a nonzero surface source; that weaker hypothesis would not justify discarding the flux. The result is the antisymmetric first moment of a localized solenoidal field.
Use the vector triple product identity:For the th component of the second integral, the antisymmetric first moment of a localized solenoidal field with gives . Thus the two terms on the right have opposite integrals. Consequently
Inside the unit ball, . On its sphere, , so the jump to zero outside adds no surface divergence. The field therefore satisfies the required weak derivative condition.
By reflection symmetry, integrals of over the ball vanish. Rotational symmetry and spherical coordinates giveHence the left side is . Meanwhile , so its integral is . Thereforeexactly the same vector.
Let . The inextensible-string constraint gives the upward displacement . Thus the quadratic potential energy is . The vertical velocity of the second mass is of second order in the small motion, so the quadratic kinetic energy is .
The Euler-Lagrange equations for this quadratic Lagrangian giveSmall displacements are used both in the quadratic approximation to the gravitational potential energy and in neglecting the higher-order vertical kinetic energy. These are the spring-supported pendulum normal modes at linear order. The corresponding force picture sets the string tension to at leading order and its horizontal angle to .
Put , . The positive stiffness-per-mass matrix isSubstitution of a normal mode requires . Its characteristic equation is . ThereforeFor , their sum and product are positive, so both squared angular frequencies are positive and .
Define . Normalizing the first displacement amplitude to one, either row of the eigenvector equation givesThe two normal modes are , and arbitrary small motion is their superposition. The lower-frequency mode has , so the masses move in phase; the upper-frequency mode has , so they move in opposite phase. The identity verifies orthogonality of these eigenvectors for equal masses.
The product-to-sum identity gives . Thus the first mass must have equal and opposite cosine-mode amplitudes and no sine-mode amplitudes. Equivalently, release the second mass from a displacement while the first is at equilibrium, both initially at rest:The two normal mode coefficients in are and . Therefore, withthe two displacements areThese initial conditions are necessary for a nontrivial product with exactly the stated time origin, as well as sufficient: follows from the product, and its zero third derivative at zero, together with the first coupled equation, forces . Since both normal frequencies are positive, . This is the product form used to describe beating, although a well-separated slow envelope requires the two normal frequencies to be close. No such extra near-degeneracy is assumed in the exact formula.
For a plane wave, acts as and as . Substitution givesso, for , the dispersion relation isAssume and real angular frequency. The ratio is negative exactly on , giving imaginary wavenumbers and an evanescent wave. Thus the propagating frequency gap is . At there is no finite- solution, while has ; neither endpoint is an ordinary finite-wavelength propagating mode.
Choose the branch , so the phase velocity is positive in the allowed bands. Direct differentiation gives the phase velocity and group velocityThe opposite spatial branch reverses both signs. On the chosen branch, the requested limits areThe band-edge limits are taken from their propagating sides. More precisely, with and ,
For the final case, set . Substitution of at gives . Its characteristic polynomial factors as , henceThe initial data give , and . Thus , , , andThe time-independent contribution is essential: static modes lost by cancelling frequency would be missed if one divided the dispersion relation by and retained only its two nonzero-frequency roots.
Articles by others on the same topic
There are currently no matching articles.