Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Kinetic energy
Use the squared total energy-momentum four-vector, expressed in energy-squared units. With the proton initially at rest,At the reaction threshold, the outgoing proton and pion have no relative kinetic energy in their centre-of-momentum frame, so . Solving givesThe numerical value uses the supplied and rest energies. The threshold exceeds the pion's rest energy because the outgoing system must carry the incident photon's nonzero laboratory momentum.
Let be the relative velocity and the centre-of-mass velocity. Inverting givesSubstitute into the sum of the two kinetic energies. The cross terms cancel, while the coefficient of is the reduced mass . HenceThe first term is translation of the centre of mass; the second is the kinetic energy measured in the centre-of-momentum frame. For an isolated perfectly inelastic collision, the bodies finish with a common velocity, while their total momentum and thus are unchanged. The kinetic energy converted to internal forms is thereforewhere is their initial relative speed. Total energy remains conserved; it is the translational-plus-relative kinetic energy that decreases.
Write the incoming particle speed as , its final signed speed as , and the rod's final centre-of-mass velocity along the impact direction as . Let be the signed impact distance from the centre, and choose the sign of the angular velocity so that the contact point's velocity component is . The rod's central moment of inertia is .
The impulse delivered to the rod is . Conservation of linear and angular momentum givesUsing these in conservation of kinetic energy,This is the equal-mass instance of the effective contact mass calculation. For , both final speeds are nonnegative, so equal speeds require . Therefore andBoth symmetric impact points lie on the rod, since .
The effective potential includes the angular part of the kinetic energy. Taking gives , henceFor , this diverges at both zero and infinity and has a unique minimum. Finite-energy motion therefore remains between two radial turning points, or at the minimum itself. For , the centrifugal barrier is absent, but still bounds every finite-energy trajectory; radial motion can pass through the force centre.
Past exam of the physics 1 paper of the University of Oxford 2019 9 b Solution Created 2026-10-25 Updated 2026-11-05
Take positive uphill, positive to the right, and the cylinder's rotation positive anticlockwise. Contact with the fixed-angle surface determines its normal position; no slipping gives . These two constraints leave as the two independent coordinates of the cylinder rolling on a freely translating wedge.
The cylinder centre is at . Since the angle is constant, its squared speed is . Including the block's kinetic energy and , and dropping a constant from the potential, givesThe cyclic coordinate is . Its conserved conjugate momentum is , the total horizontal momentum. The two Euler-Lagrange equations areEliminating the accelerations, with , givesThus the cylinder rolls downhill and the wedge accelerates rightward. For , and , the ordinary fixed-incline result.
The massless inextensible string has hanging length , measured downward from the table. Thus . In polar coordinates, the tabletop mass has squared speed . Adding the two kinetic energies and setting the hanging gravitational potential energy to givesand the Lagrangian isThe canonical momenta are and . Performing the Legendre transform gives the HamiltonianIt equals the total mechanical energy and is conserved because has no explicit time dependence. Also is a cyclic coordinate, so is conserved angular momentum about the vertical through the hole. The table and the string guide supply external forces; conservation of the system's total linear momentum does not follow. These are the two independent generic integrals needed for the reduced tabletop mass coupled to a hanging mass.
The initial angular momentum is , and the initial total energy isWhen the hanging mass reaches the table, . Conservation of angular momentum fixes the tabletop tangential speed there to . At the limiting case of just reaching, radial velocity is zero. Equating the two energies,yieldsMore generally, the boundary radial kinetic energy isso reaching requires , with equality for just reaching and strict inequality for nonzero outward radial speed at contact. This condition is also sufficient: is strictly convex, and the allowed interval connecting the initial radius to has no intervening higher effective potential barrier. At the threshold the initial radial acceleration is outward and is the outer turning point.
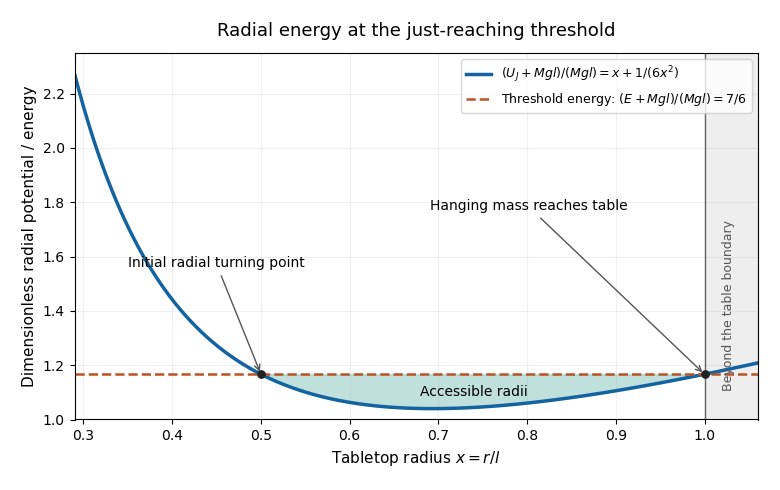
Effective radial potential at the threshold for the hanging mass to reach the table
. The horizontal energy level intersects the effective potential at r/l equal to one half and one. The interval between them is accessible. The curve is shifted by the irrelevant constant Mgl and normalized by Mgl; the physical region ends at r/l equal to one. Details.
The retained mass at time is . Incoming rain has zero horizontal momentum in the ground reference frame. During , horizontal momentum conservation for the carriage and the rain about to enter givessoThis is a variable-mass system: the entering mass must be accelerated horizontally, even though no external horizontal force acts on the carriage-plus-rain system. Integrating the velocity,For this is also the distance travelled. Its limit is . Vertical impact can dissipate kinetic energy; horizontal momentum conservation does not require kinetic energy conservation.
Put and , the common Lorentz factor. The initial total relativistic energy and momentum areAssume that coalescence emits no additional radiation. By four-momentum conservation, the final rest mass is the rest mass of a coalescing relativistic collision:The final velocity is , the centre-of-momentum frame velocity.
For ,The leading term is the classical sum of masses. The first correction is the internal energy retained after sticking, divided by : the initial classical kinetic energy is , while the common-motion kinetic energy is . Their difference is , consistent with mass-energy equivalence.
A totally inelastic collision in the sticking sense has zero final relative velocity, so . Both velocities are the conserved centre-of-momentum frame velocity:Thus the bodies move together along the original incident direction; the moving projectile has . The common outgoing state is stationary in the centre-of-momentum frame. The lost translational kinetic energy iswhich can become internal energy. As explained in part 8, setting only the normal coefficient of restitution to zero in a smooth oblique collision does not force sticking: tangential relative motion can remain.
For an elastic collision with , the positive root in the laboratory scattering circle formula is the only nonnegative one. With ,ConsequentlyThe heavy target can absorb a finite momentum with negligible velocity and negligible kinetic energy. Thus the projectile may change direction substantially while retaining its speed; a backward reflection also has .
For equal masses and an elastic collision, andThus the nonzero outgoing branch isand the other nonnegative algebraic root is . The latter is the head-on transfer of the incoming momentum and kinetic energy to particle 2: . A stationary particle has no defined outgoing direction, so this root is not a separate physical outcome for every chosen .
On the nonzero branch, momentum conservation givesThe two nonzero outgoing velocities are perpendicular: squaring momentum conservation and comparing with kinetic energy conservation gives . For , the nonzero root is negative and must be rejected; backward scattering of a moving incident particle is impossible in this equal-mass, initially stationary-target case.
In the laboratory frame, the initial target is at rest and the outgoing directions are directly related to detector positions. The centre-of-momentum frame has zero total momentum, so the two outgoing momenta are equal and opposite; it cleanly separates bulk motion from relative kinetic energy. Transforming back is needed to predict laboratory angles and speeds. Neither reference frame removes the need for an appropriate collision law.
Take the incident direction as and put . Momentum conservation fixes the centre-of-momentum frame velocity, and a Galilean transformation gives the initial velocities in that frame:After the collision, . Hence both particles have the same final-to-initial speed ratio,The relative kinetic energy is multiplied by . This common ratio exists independently of how the outgoing direction is selected.
The meaning of restitution matters here. The usual coefficient of restitution is a ratio of normal separation and approach speeds, not total speeds. In a smooth oblique collision, the tangential relative velocity is unchanged. If the incoming relative velocity makes angle to the contact normal, thenFor example, and give . Therefore the requested identification is not generally true with the standard normal definition. The printed equation is valid if its denotes the relative speed retention in an oblique collision, namely , or if an additional collision model supplies that equality. The elastic cases have and are unaffected by this qualification.
To derive the scattering formula under that convention, write . Its components give the laboratory scattering circleSolving the resulting quadratic for the nonnegative speed yieldsWith , this is the requested formula. A real square root and are both necessary: a negative algebraic root is not a second physical speed, and does not define a scattering angle. The subsequent limits are taken using this laboratory scattering circle.
The laboratory is the parent's rest frame. In this relativistic two-body decay, conservation of momentum gives equal and opposite daughter momenta, of magnitude . Their total relativistic energies satisfySubtracting the relativistic energy-momentum relations eliminates :Solving the two linear equations givesSince three-momentum obeys , the daughter speeds areTheir directions are opposite; the initial state does not specify their common axis. The kinetic energies are and . Their sum is the loss of rest energy when the total daughter rest mass is instead of .
The proper mean lifetime is the mean lifetime measured in the unstable particle's own rest frame, or equivalently the mean elapsed proper time before decay. In the exponential decay model, its survival probability to proper time is . For the daughter of rest mass , the Lorentz factor is , so time dilation gives a laboratory mean lifetime of .
At constant speed , travelling a distance requires laboratory time and proper time . Its mean decay length isfor . HenceThe mean lifetime sets the scale of an exponential distribution; it is not a fixed deadline, so travelling beyond one mean decay length has a nonzero probability.
Choose the vertical axis downward, and measure the polar angle from it. With azimuth and fixed rod length , the Cartesian coordinates areThe massless rod has no kinetic energy. Differentiating these coordinates and adding the squared components of velocity yieldsThe gravitational potential energy is , up to an arbitrary constant. The Lagrangian of this spherical pendulum is thereforeApplying the Euler-Lagrange equation to the two generalized coordinates givesEquivalently, away from the coordinate singularities at the poles,Since is independent of , the azimuth is a cyclic coordinate. Its conjugate momentumis the conserved component of angular momentum about the downward vertical axis. The polar angle is not a cyclic coordinate. Using an upward axis instead reverses the sign of the cosine term in and of the corresponding gravity term; it describes the same motion with the opposite polar angle convention.
Inertia is resistance to a change of motion. Translational inertia is measured by mass in Newton's second law; rotational inertia about a specified fixed axis is measured by the moment of inertiawhere is perpendicular distance from that axis. For a thin uniform rod, take axes perpendicular to the rod. With linear mass density ,The second result uses the parallel axis theorem; direct integration over gives the same value. The axis specification is essential: an ideal thin rod has zero moment of inertia about its own longitudinal axis.
During the short elastic collision, neglect the impulse from gravity. The pivot can exert an external impulse, so total linear momentum of rod plus particle need not be conserved. Its torque about the pivot is zero, so conservation of angular momentum about that point applies. Let be the particle's signed outgoing horizontal velocity, and the rod's outgoing angular velocity, positive towards the incident motion. ThenSubstituting into the kinetic energy equation givesDiscarding the zero-impulse branch , the actual collision givesThe rod's lower end initially moves forward at , so the bodies separate. Afterwards the free particle undergoes projectile motion. With the pivot as origin and downward, its trajectory is , , where at the collision. The rod instead swings about the fixed pivot in a vertical plane as a physical pendulum.
The rod's initial rotational kinetic energy is . Reaching the horizontal raises its centre of mass by , increasing gravitational potential energy by . Consequently,For the threshold case, measure the rod's angle from the downward vertical and reset at its first horizontal turning point, so and . The restoring torque about the pivot gives the exact equation of motionAt the horizontal, , so the rod immediately swings back. Conservation of mechanical energy yieldsOn the initial descent its explicit time dependence is specified by the definite integralIt continues through the vertical to , reverses, and repeats without damping. An alternative expression valid throughout the oscillation uses the Jacobi elliptic sine. Put , , and let denote the complete elliptic integral of the first kind. ThenThis is not simple harmonic motion at an amplitude of . Its oscillation period exceeds its own small-amplitude value by the factor .
A simple pendulum of length obeys . At the same amplitude , its oscillation period is , soThe rod swings more slowly. Its equivalent simple pendulum length is , not the distance to its centre of mass. The same oscillation period ratio holds in the common small-amplitude limit, but replacing the actual 90-degree motion by that limit would underestimate both oscillation periods.
For a satellite of mass moving in the Newtonian gravitational field of a much larger, effectively fixed mass , put . Its conserved mechanical energy, with gravitational potential energy zero at infinity, isHere is the instantaneous centre-to-centre distance, the satellite's speed, the gravitational constant, and the semi-major axis of its bound elliptic orbit. The kinetic energy and potential energy vary around the orbit, while their sum remains constant. Dividing by and solving for gives the vis-viva equation, .
For this Hohmann transfer orbit, the periapsis and apoapsis distances are and , soThe vis-viva equation gives the endpoint speedsAs a check, conservation of angular momentum at the two endpoints gives because each velocity is perpendicular to its radius. Using and gives andThe departure impulse must increase the speed in the direction of the initial circular orbit:These are Sun-centred speeds; leaving the Earth's own gravitational field would require an additional calculation beyond this idealized solar orbit transfer.
At , the desired circular orbit speed is . The arrival impulse is thereforeThe required thrust on the spacecraft is forward, tangent to its orbit, to accelerate it. The rocket ejects exhaust backwards, opposite to the spacecraft's velocity; this distinguishes the direction of thrust from the direction in which the exhaust is fired.
The Hohmann transfer time is half the orbital period of the transfer ellipse. From Kepler's third law, relative to the Earth's one-year orbital period,Meanwhile Mars's orbital period is . The spacecraft arrives radians from its departure position. For a rendezvous, Mars must reach that same position after advancing through . Thus its initial lead angle over the departing spacecraft isMars must be ahead by this angle in the common direction of motion around their orbits. At departure the spacecraft and the Earth share the inner orbital position; arrival occurs on the opposite side of the Sun.
Take upwards in the source diagram. Write for 's incoming speed, so the initial velocities areA contact-direction assumption is needed for a unique answer. The diagram specifies the incoming velocities but does not specify the contact normal or an outgoing angle. First adopt the usual intended model: the impulse is horizontal, so neither particle changes its component of velocity. This is the smooth oblique collision model with a horizontal line of centres at impact. Bringing to rest in the direction then brings it entirely to rest.
Let be 's outgoing component of velocity. Conservation of momentum and conservation of kinetic energy givePut . The second equation becomes , so . ThereforeThe outgoing kinetic energies areThe outgoing speed of is , directed above the negative axis at angle . The initial kinetic energy is also , as required for an elastic collision.
For the perfectly inelastic collision with these same incoming velocities, both particles share a common outgoing velocity. Conservation of momentum givesIts direction is again above the negative axis. The separate translational kinetic energies of the constituents and their total areThe loss of translational kinetic energy isThis becomes internal energy, for example deformation and heating; total energy is conserved. In the elastic collision no kinetic energy is lost and the particles separate with different velocities. In the perfectly inelastic collision relative motion disappears and the common velocity is the original centre of mass velocity.
The limitation of the printed data can be made explicit. Without the horizontal-impulse assumption, write the final velocity of as . Then conservation of momentum determinesand conservation of kinetic energy gives onlyThere is a family of possibilities. For a concrete second solution, givesThese velocities conserve both components of momentum and conserve kinetic energy, and they satisfy the specified vanishing component for , while requiring a different incoming speed. They can arise from a smooth contact normal proportional to . Thus the horizontal-impulse result is conditional, rather than uniquely implied by the printed statement. For any member of this family the corresponding sticking result remains well determined once is chosen:The last expression is the lost relative kinetic energy in a perfectly inelastic collision of these two point masses.
Invariant and collision. For a particle of rest mass , special relativity gives relativistic energy and momentumTherefore the relativistic energy-momentum relation isIt is the squared Minkowski norm of the four-momentum, multiplied by , and hence is preserved by every Lorentz transformation. Explicitly a boost with speed along gives , , with , . Expanding gives because . Spatial rotations preserve , completing the invariance argument for all inertial frames.
For the incoming moving particle, and . The total laboratory energy and momentum before the perfectly inelastic collision areFour-momentum conservation identifies these with the final particle's energy and momentum. Its rest mass is thereforeThe result exceeds the sum of the incoming rest masses; some initial kinetic energy has become internal rest energy. Since for a massive particle,
Two-body decay. Work first in the parent's rest frame, denoted by a star. Four-momentum conservation requires equal and opposite daughter momenta. Their equal rest masses give equal energies:Thus their rest-frame velocities are . Applying the relativistic velocity-addition formula with boost gives the two laboratory velocities:Their laboratory energies follow directly from the Lorentz transformation of four-momentum:The corresponding signed laboratory momenta areTheir sums recover and , and each satisfies . One daughter moves forwards and the other backwards in the laboratory; both are collinear with the original flight axis. Numerically, , , and .
Choose the heavier particle's outgoing velocity above the initial direction. Let its speed be , and let the lighter particle have components . Thus and are nonnegative deflections on opposite sides. Conservation of momentum givesThe elastic collision conserves kinetic energy:Taking the squared magnitude of the vector momentum equation yieldsEliminate with the kinetic energy equation. For a nontrivial collision, , soSubstituting back into the two momentum components givesThereforeThe ratio alone does not determine the quadrant: for , the lighter particle can move backwards. The two component equations select the correct . At , the outgoing direction is perpendicular to the initial direction; the displayed tangent has a pole there.