A magnetohydrodynamic wave is a linear disturbance of a conducting fluid and its magnetic field. A uniform ideal plasma supports an Alfvén mode and fast and slow magnetosonic modes.
In a uniform ideal-MHD plasma at rest, take the wavevector parallel to a nonzero background field. Projecting the linear velocity equation along and perpendicular to the field gives two transverse Alfvén polarizations at speed and one longitudinal acoustic polarization at speed . Compression does not bend field lines for the longitudinal branch. The general oblique fast/slow magnetosonic modes reduce to the corresponding faster/slower parallel branches, with degeneracies when their speeds agree.
Ambipolar damping is attenuation of magnetic disturbances by friction between the magnetically coupled charged fluid and a neutral fluid. In a strongly collisional mixture, the fluids nearly move together, but their small relative velocity dissipates energy. With drag coefficient , the frictional energy loss is . Neglecting other dissipative processes does not remove this collisional loss.
For equal ion and neutral mass densities, let , and use Fourier time dependence . Solenoidal displacements obey and . For nonzero frequency, the neutral equation gives . Substitution in the ion equation givesEquivalently, the growth rate obeys . A time-independent neutral displacement with zero velocity is a relabeling of a uniform fluid, not an additional wave root of the velocity/magnetic-field system.
For , the equal-density ion-neutral cubic has a rapidly damped mode and two propagating modes . The reduced phase speed uses the total density . The exact displacement ratio is . It is nearly for the rapidly damped counterflow and nearly for the propagating modes. Thus the latter have small ion-neutral slippage of relative size , responsible for ambipolar damping.
An entropy mode is a perturbation of entropy and density with no leading pressure or velocity perturbation in a uniform ideal fluid. For an adiabatic equation of state define . An entropy perturbation can have and , so it has zero frequency in the local fluid frame. In anisotropic reduced magnetohydrodynamics, with , and turbulence mixes its variance as a passive scalar.
A polarization specifies the direction or trajectory of the oscillating velocity and magnetic field in a magnetohydrodynamic wave. The linear Alfvén wave has velocity perpendicular to the plane of the background magnetic field and wavevector; the magnetosonic waves have velocity in that plane. A real fixed polarization vector gives a linear oscillation. Two orthogonal components of equal amplitude in quadrature give a circular trajectory. For propagation parallel to a uniform field, combining the two degenerate transverse linear polarizations produces circular polarization; at finite amplitude its constant transverse magnetic-field magnitude removes the longitudinal magnetic pressure gradient.
For an ideal incompressible flow rotating about the axis of the field , use cylindrical Fourier modes . The azimuthal derivative of a cylindrical vector Fourier mode reduces induction to . If the boundary eigenproblem gives , with real , eliminating the perturbation gives the displayed dispersion relation. Here for SI current density; the formula is conditional on that boundary eigenrelation.
In the uniform-current rotating magnetohydrodynamic wave dispersion, exponential growth requires . For integer and this is possible only for and . Positive and negative branches are related by complex conjugation. The equality case is a repeated frequency and requires separate analysis of possible algebraic growth.
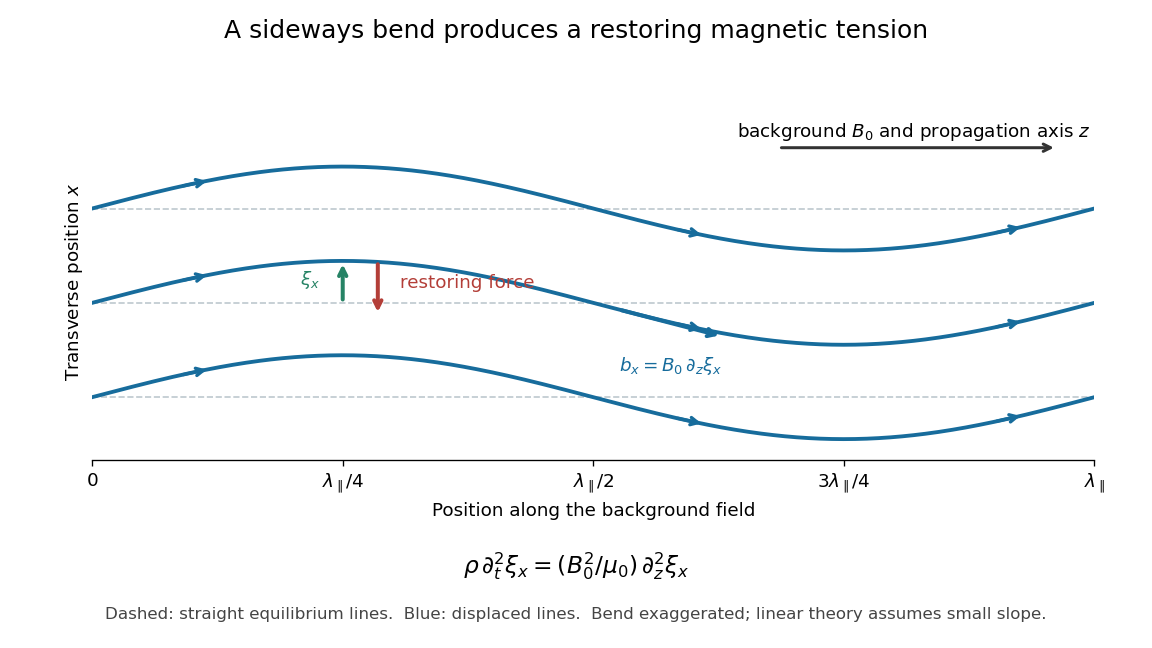
An Alfvén wave is a magnetohydrodynamic wave in which magnetic tension restores a sideways disturbance of a conducting fluid. In the small-amplitude, uniform-background ideal magnetohydrodynamics model, its shear polarization of waves has displacement perpendicular to both the background magnetic field and the wavevector. It is an incompressible flow disturbance: the mass density and gas pressure have no first-order fluctuation. Its dispersion relation is , where is the background Alfvén velocity.
The mechanism resembles a plucked taut string: magnetic flux freezing makes sideways fluid flow bend magnetic field lines, and their magnetic tension accelerates neighboring fluid. The fluid supplies inertia and the bent magnetic field supplies the restoring stress. This permits energy transport without a first-order compression, unlike an acoustic wave. Hannes Alfvén's 1942 paper, Existence of Electromagnetic-Hydrodynamic Waves, considered precisely a uniform axial magnetic field, infinite electrical conductivity and sideways velocity depending on axial position and time; it proposed a solar application. This was a theoretical prediction, followed by the distinct Lundquist liquid-metal Alfvén wave experiment.[ref]
Existence of Electromagnetic-Hydrodynamic Waves by Hannes Olof Gösta Alfvén. 1942, pp. 405–406; ideal-conductor plane-wave argument, reproduced on slide 4 of Kinetic Alfvén waves in space plasmas

For oblique propagation, the shear Alfvén wave has velocity normal to the plane containing the wavevector and background magnetic field. The fast magnetosonic wave and slow magnetosonic wave instead have velocity in that plane and generally involve compression, with gas pressure and magnetic pressure contributing to their restoring forces. For exactly parallel propagation the plane is not unique: either transverse polarization of waves is allowed, and some modal speeds coincide. For the shear branch has , while the fast magnetosonic wave can still propagate perpendicular to the magnetic field. One should identify the polarization of waves as well as the phase velocity. The statement that the shear mode is incompressible concerns this linear mode; a finite linearly polarized disturbance can drive a quadratic compressive response, as in the magnetic-pressure obstruction to a linearly polarized Alfvén wave.
Take a static uniform fluid of mass density , constant gas pressure, and background magnetic field with . Use SI units, vacuum permeability , zero electrical resistivity and zero viscosity. Write and , with both disturbances perpendicular to . Retain only linear order in their amplitudes. There is no background fluid flow, so the linear material derivative is .
The continuity equation has , hence ; choosing no initial mass density fluctuation gives . For this shear mode the gas pressure fluctuation is also zero. In the ideal magnetohydrodynamic momentum equation, the Lorentz force density can be writtenBecause , the perturbed magnetic pressure starts at quadratic order. The surviving transverse magnetic tension gives the first equation below. Expanding the ideal magnetohydrodynamic induction equation gives the second:Differentiate the first in time and substitute the second. Both velocity and magnetic field disturbances obey the one-dimensional wave equation:For a plane wave proportional to , this gives , or . The magnetic and velocity amplitudes satisfy : they have opposite signs for propagation along and equal signs for propagation along . The general uniform-background shear polarization of waves, perpendicular to both and , gives the same dispersion relation with . Its group velocity is , whereas its phase velocity normal to an oblique wavefront has magnitude .
Dot the two Linear Alfvén wave equations with and , respectively, and add. The result is conservation of energy withA single traveling Alfvén wave has equal kinetic energy and perturbation magnetic energy, and . This equality need not hold instantaneously at each point of a superposed standing wave.
As an original ideal-model example, stipulate , and a uniform path . Using , the Alfvén speed is and the transit time is . Doubling the magnetic field halves that time. A sinusoidal velocity with peak amplitude has magnetic peak amplitude and mean energy flux in the positive direction. These are stipulated ideal parameters, not historical measurements or a prediction including vessel walls.
Finite electrical conductivity allows magnetic diffusion, with magnetic diffusivity . In the same uniform, unbounded geometry as the Linear Alfvén wave equations, neglect viscosity but add to induction. For real and time dependence , elimination givesThus weak magnetic diffusion, , gives an amplitude decay rate . For , both temporal roots are purely decaying; they no longer describe an oscillating traveling mode. This temporal calculation at fixed real wavenumber is different from a driven vessel at fixed real frequency, where a complex spatial wavenumber describes penetration and attenuation. Viscosity also dissipates kinetic energy, and walls introduce transverse gradients and additional losses.
For an axial length , comparing the magnetic diffusion time with the transit time gives the ratio . A large value favors propagation before diffusion, but a narrow vessel can introduce a shorter transverse diffusion scale. In the actual 1949 analysis, finite electrical conductivity and vessel dimensions restrict the useful frequency interval; above its upper limit the response becomes a skin wave.[ref]
Experimental Investigations of Magneto-Hydrodynamic Waves by Stig Lundquist. Abstract: finite-conductivity frequency interval, upper limit and geometrical lower limit
For fixed real positive angular frequency , a transverse Alfvén wave proportional to in a uniform fluid has when magnetic diffusivity is retained and viscosity is neglected. Choose the branch with positive real and imaginary parts for propagation and attenuation along . For , . The amplitude attenuation length is , whereas the energy attenuation length is . With wavelength , and . Fixed-real-wavenumber temporal Resistive damping of an Alfvén wave is a different boundary-value prescription.
Stig Lundquist, the author printed as S. Lundquist, reported an early laboratory test in 1949. The apparatus used mercury in a stainless-steel cylinder, a vibrating disk, and a floating mirror to indicate the motion at the liquid surface. The reproduced apparatus drawing also shows a scale; the accompanying account gives an applied magnetic field of .[ref]
Numerical investigations of rotating MHD in a spherical shell by Andrey Sheyko. Andrey Sheyko, Numerical investigations of rotating MHD in a spherical shell (2014), p. 8, Figure 1.4 and following paragraph; reproduction of Lundquist's apparatus
The imposed magnetic field ran along the cylinder, while the bottom disk oscillated to excite azimuthal motion. Varying the drive frequency sought a standing wave resonance. A later authored experimental account describes this as an early hint: the resonance peak was not reached, and magnetic damping was substantial.[ref]
Torsional Alfvén waves in a dipolar magnetic field: experiments and simulations by Z. Tigrine and others. 2019, Section 1, paragraph beginning “Only a few laboratory experiments”: mercury vessel, bottom crenelated disk, resonance search and unreached peak
The experiment therefore tested a bounded azimuthal shear disturbance, related to a torsional Alfvén wave, rather than an infinite plane wave or a compression-driven magnetosonic wave.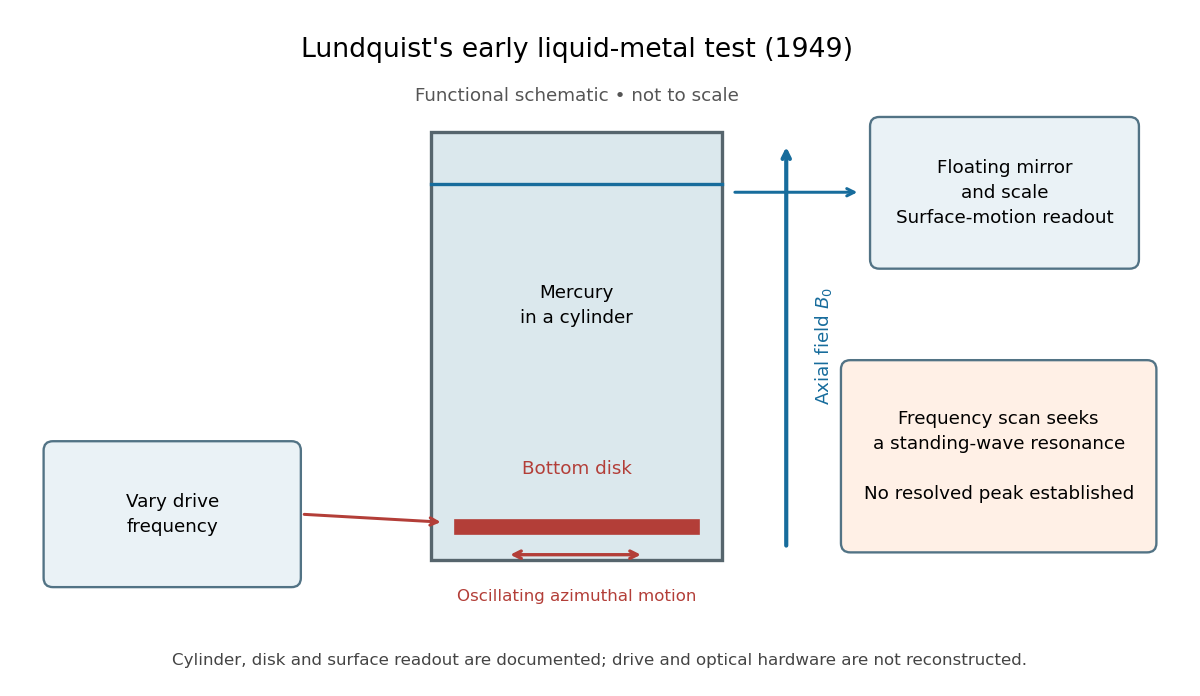

The magnetic field provides the controlled physical parameter: the ideal Alfvén wave prediction makes a propagation speed proportional to its strength, while a resonance also depends on the vessel's boundary conditions. A quantitative test must compare the driven response with finite-electrical conductivity theory and account for mechanical coupling and wall losses. An observed surface motion alone cannot distinguish all these mechanisms. The reproduced apparatus account gives neither a numerical drive frequency nor a field-off comparison. Lundquist's paper itself calls the experiment preliminary and proposes further investigations.[ref]
Experimental Investigations of Magneto-Hydrodynamic Waves by Stig Lundquist. Abstract, final sentence: preliminary experiment and proposed investigations
For an incompressible shear flow with uniform magnetic field , define for time dependence and . Eliminating the magnetic perturbations from the horizontal momentum equations gives the displayed product for . Away from the Alfvén wave resonance, it yields . At resonance one must retain the original system: for constant , , , any smooth transverse amplitude with and all other amplitudes zero is an Alfvén wave. Its nonzero vorticity disproves the unrestricted zero-vorticity reduction. Exponentially growing modes with real background coefficients cannot encounter these real-frequency resonances.
A kinetic Alfvén wave is a dispersive extension of the Alfvén wave in a plasma when perpendicular kinetic or two-fluid effects, including a pressure response, matter. Its particular dispersion relation depends on the ordering and plasma parameters. A similar product of parallel and perpendicular wavenumbers can occur in a whistler wave, but agreement of a scaling power does not identify the underlying physical equations.
Neighboring magnetic surfaces with different Alfvén speeds carry the same axial waveform at different rates. For a traveling profile , differentiation produces the displayed term, so transverse gradients grow even without axial wave steepening. Small magnetic diffusivity or viscosity can eventually act strongly on these gradients. The ideal process redistributes phase rather than directly dissipating wave energy.
A torsional Alfvén wave couples azimuthal velocity to a toroidal magnetic field around a fixed poloidal magnetic field. Axisymmetric induction gives and magnetic tension gives . Their combination is the displayed wave equation. Its local dispersion relation is .
For uniform-density incompressible flow with , and , the azimuthal magnetohydrodynamic momentum equation and ideal magnetohydrodynamic induction equation hold automatically. Let . The remaining equations require and , so is necessary and locally sufficient. A single traveling profile is unrestricted; two nonzero profiles on an unrestricted axial domain must be opposite exponentials or independent of their traveling arguments. Bounded profiles of both signs therefore reduce to steady solutions.
For a rotating conducting sphere, a geostrophic azimuthal velocity couples to the cylinder-integrated magnetic stress . Put and let be the cylinder height. With an insulating boundary and no flow through it, cylindrical averaging removes the Coriolis force and gives , . The local squared wave speed is , the cylinder average of .
For a cylinder-averaged torsional Alfvén wave with time-independent , differentiating this quadratic form gives . Regularity at the axis and vanishing magnetic torque at the outer endpoint therefore imply conservation. By Cauchy-Schwarz inequality, ; equality holds for the torsional-wave magnetic component proportional to along each cylinder. A stationary magnetic component orthogonal to is invisible to .
The magnetic tension stress transports axial angular momentum along a poloidal magnetic field. In purely azimuthal ideal flow the poloidal energy flux is . This proportionality is valid even at vanishing flux, where an ordinary ratio is undefined. The coupled fluxes explain how a torsional Alfvén wave redistributes rotation.
A finite-amplitude ideal-MHD Alfvén wave can rotate the transverse magnetic field at constant magnitude, with constant mass density, pressure and longitudinal components. Its transverse velocity obeys and its speed is constant along the wave. The constant magnetic pressure prevents compressive acceleration.
A finite sinusoidal transverse field , , has varying magnetic pressure. In a purely transverse traveling Alfvén wave, longitudinal momentum requires , but the adiabatic pressure equation with requires . A traveling compensating gas pressure cannot satisfy both conditions. The uncompensated force is quadratic in amplitude and drives a compressive response. A regular periodic one-dimensional traveling solution cannot evade this by varying mass density: its mass, transverse momentum and induction integrals force constant mass density at the zeros of the transverse field and hence throughout the nontrivial wave.
In homogeneous ideal magnetohydrodynamics, a constant longitudinal field and transverse field , , give an exact traveling wave with constant mass density and pressure, , and the displayed transverse velocity. Induction and transverse momentum reduce to the same wave relation. Since is constant, there is no longitudinal magnetic pressure gradient. All nonlinear terms are compatible with the constant-density solution, even in a compressible fluid.
For propagation along , the Alfvén right eigenvector has , and . Its speed is , . When the transverse background field vanishes, both transverse polarizations are allowed.
The Alfvén frequency is the frequency of an Alfvén wave with wavevector in a uniform magnetic field and mass density . For a vertical field and vertical wavenumber , its square is . Its competition with orbital shear determines the ideal magnetorotational dispersion relation.
An Alfvén wing is a stationary Alfvénic disturbance attached to a conducting obstacle moving through a magnetized plasma. In a super-Alfvénic flow its boundaries follow downstream characteristics.
For a stationary cold-plasma disturbance with obstacle speed , the characteristic slope is . It approaches in the strongly super-Alfvénic limit.
A magnetosonic wave is a compressive MHD mode polarized in the plane of the wavevector and background magnetic field.
For sound speed much larger than Alfvén speed , and angle between the wavevector and magnetic field, the fast magnetosonic wave has . The slow magnetosonic wave has . The fast mode is predominantly longitudinal sound. The slow mode becomes almost incompressible, polarized in the plane of the wavevector and magnetic field; the Alfvén wave is polarized perpendicular to that plane. The latter two are predominantly magnetic-tension waves with equal leading phase speeds.
The high-pressure limit of the slow magnetosonic wave approaches an incompressible polarization in the plane of the background magnetic field and wavevector, perpendicular to the latter. It has the displayed leading dispersion relation, the same as the out-of-plane Alfvén wave. Magnetic tension is the restoring force, and pressure balances the compressive component of the magnetic force. In exactly incompressible homogeneous ideal magnetohydrodynamics it is one of the two transverse magnetic polarizations.
For one-dimensional flow obeying an isothermal equation of state with , the primitive variables form a four-variable hyperbolic system and is constant. The speeds relative to satisfy . These are the fast and slow magnetosonic waves. The independent out-of-plane Alfvén wave polarization and a freely advected entropy mode are absent from this reduced isothermal system.
For propagation in a direction with field component of the Alfvén velocity, the squared fast magnetosonic wave and slow magnetosonic wave speeds are the roots of . They are real and nonnegative, and satisfy . A steady acceleration equation can become singular when the flow equals either of these speeds.
If a steady wind equation has the form , a smooth nondegenerate crossing requires at the corresponding magnetosonic critical speed. Subsequent differentiation or the full system determines the admissible slope. The numerator condition alone does not prove that a global smooth wind exists.
In a strictly cold flow governed by ideal magnetohydrodynamics the sound speed vanishes, so the slow magnetosonic wave speed is zero. A nonzero-speed outflow therefore has no ordinary finite interior slow crossing. For the cold radial magnetohydrodynamic wind integral, on the sub-Alfvénic branch , assuming . A small retained specific enthalpy is needed to locate a finite slow point; the zero-temperature limit can move it to the launch boundary. The usual simultaneous numerator and denominator regularity conditions still apply to nondegenerate critical points.
The fast magnetosonic mode uses gas and magnetic pressure as reinforcing restoring forces and is the faster root of the magnetosonic dispersion relation.
The slow magnetosonic mode is the lower-frequency compressive root and is guided more strongly along the magnetic field.
The tube speed combines sound and Alfvén speeds according toIt is smaller than both constituent speeds.
An MHD interface wave propagates along a discontinuity and decays away from it. Continuity of normal displacement and total pressure determines its dispersion relation.
For two incompressible streams of equal density with a common tangential magnetic field parallel to their velocities, decaying normal modes and interface displacement/total-pressure continuity give in units . The displayed dispersion relation follows, with . Thus excludes exponential Kelvin-Helmholtz instability; equality is marginal. Above threshold the growth rate is . The transverse horizontal wavenumber affects the decay length through but not this growth threshold. Magnetic tension supplies the stabilizing restoring force.
Articles by others on the same topic
There are currently no matching articles.