Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Manifold chart
Coordinate basis Created 2026-09-28 Updated 2026-10-14
A manifold chart with coordinates induces a smooth local frame of the tangent bundle, with tangent vectors forming a basis of each tangent space. Their Lie brackets of vector fields vanish because mixed partial derivatives of smooth functions commute. Under a change of coordinates they transform by the chain rule: , with coefficients given by the Jacobian matrix.
Coordinate-projection atlas of an ellipsoid Created 2026-10-06 Updated 2026-10-14
For nonzero real , scale the ambient coordinates by . On the half where , omitting is a manifold chart onto the open unit ball; its inverse restores . These charts form a smooth atlas of the ellipsoid, including for negative .
Cotangent space Created 2026-10-06 Updated 2026-10-07
The cotangent space at is the dual vector space . Its elements are covectors on the tangent space. In a manifold chart , the basis is dual to . Under a coordinate change to , the coefficients of obey . The disjoint union of these spaces is the cotangent bundle.
Critical point of a smooth map 2026-10-14
Imagine folding a sheet along its horizontal axis by the smooth map , . The inputs and have the same output. Along , horizontal motion still changes the output, but vertical motion produces no first-order change: . These inputs are critical points of a smooth map even though their differential is not the zero linear map. The missing direction in the target tangent space is what matters.
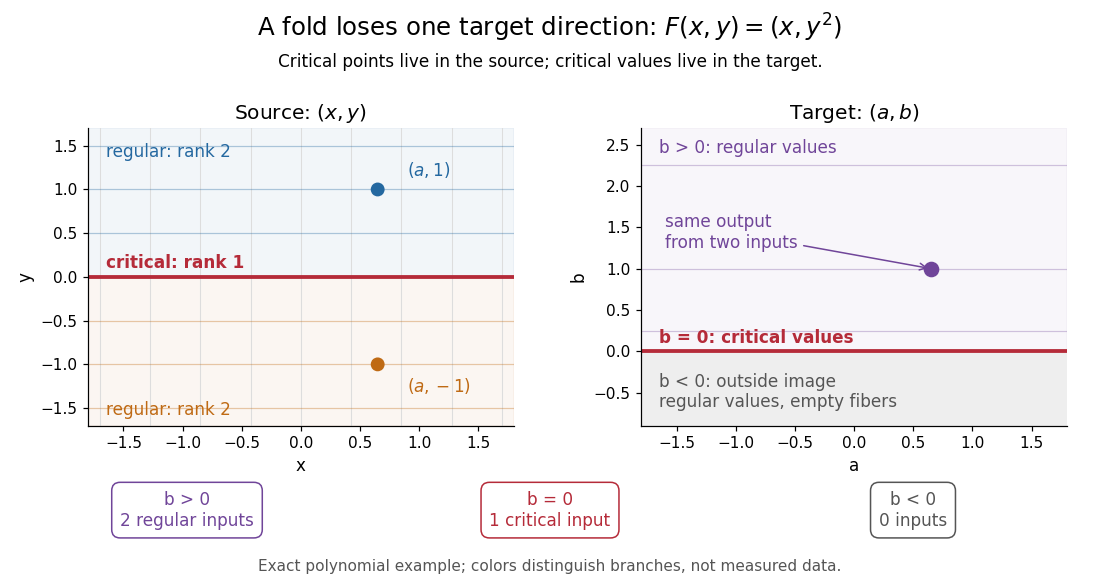

Precisely, let be a smooth map between smooth manifolds without boundary. An input is a critical point of a smooth map when its differentialis not surjective, equivalently when its rank of a linear map is less than . An input where it is surjective is a regular point; a map with no critical points of a smooth map is a submersion. The threshold is the target dimension, not . In manifold charts, compute the matrix rank of the Jacobian matrix; changes of charts preserve that matrix rank. [ref]
For the fold,Thus its set of critical points of a smooth map is the entire horizontal axis. Away from that axis, its differential can produce every infinitesimal target displacement. At the axis, it can produce only horizontal ones. This diagnoses where the two inverse branches in the picture merge.
For a scalar smooth function , the target dimension is one. A linear map to fails to be surjective exactly when it is zero, so here a critical point of a smooth map means . In Euclidean space this is precisely the familiar critical point condition : every first partial derivative vanishes. On a Riemannian manifold, it is equivalently for the chosen Riemannian metric; the Riemannian gradient depends on that metric, but whether it vanishes does not. See Loring W. Tu, An Introduction to Manifolds, Proposition 8.23 for the scalar coordinate criterion. The scalar smooth function has a critical point at zero without a local maximum or local minimum.
A source of lower dimension gives a different warning. For the smooth map , , the Jacobian matrix is the column , of matrix rank one at every input. Every input is a critical point of a smooth map, since the target dimension is two, even though this parametric curve has nonzero velocity everywhere and is an immersion. More generally, if , no differential can be surjective, so every input is critical. The terminology measures the ability to fill target directions, rather than whether the parametrized curve looks smooth.
Differential geometry of surfaces 2026-10-14
The differential geometry of smooth surfaces studies their induced Riemannian metrics and intrinsic or extrinsic curvature. The first fundamental form measures lengths, while the second fundamental form and shape operator describe bending in an ambient Euclidean space. A regular parametric surface must have linearly independent tangent vectors : otherwise its parameters cannot provide a manifold chart with two independent directions.
For a sphere of radius , use colatitude and longitude :Thus a change has arc length : equally spaced longitudes draw closer together toward a pole. The coordinate degeneracy at the poles belongs to this parametrization, not to the smooth surface.
Both principal curvatures of the sphere have magnitude and the same sign, giving Gaussian curvature . A plane has , and a circular cylinder also has because one principal curvature vanishes. These three familiar shapes show why visible bending alone cannot measure intrinsic Gaussian curvature.
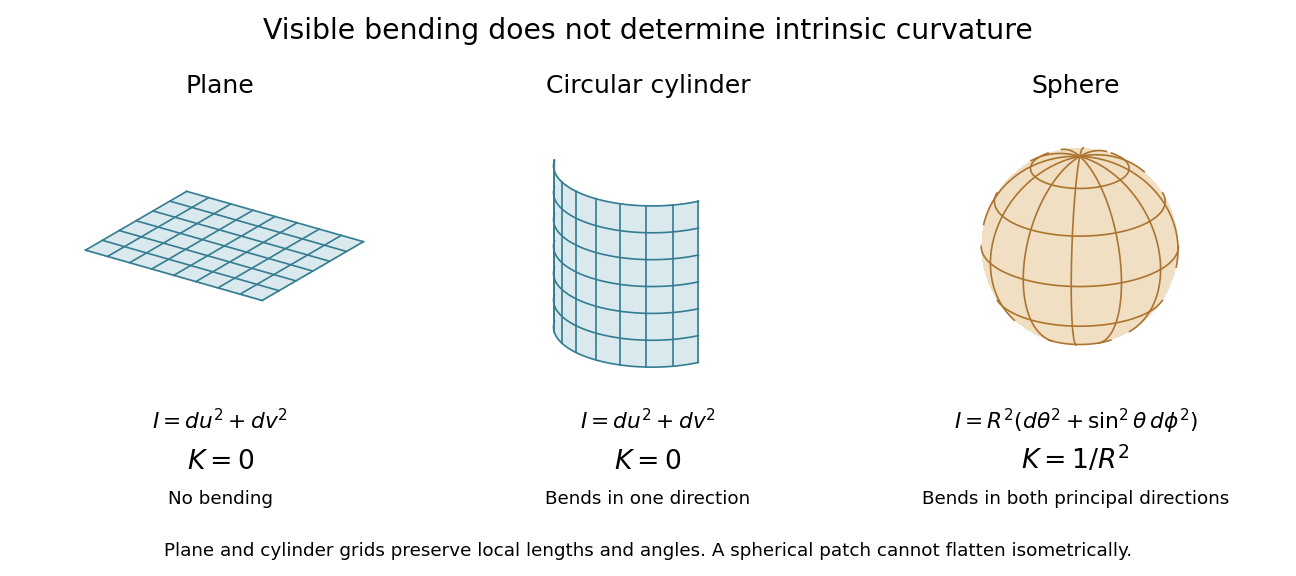
Visible bending and Gaussian curvature are different measurements
. Details. 
Dimension of a manifold 2026-10-05
A topological manifold has dimension when its manifold charts have coordinate domains open in . For a smooth manifold, each tangent space has dimension , and a tangent bundle has vector bundle rank .
First fundamental form Created 2026-09-24 Updated 2026-10-14
The first fundamental form of a smooth surface is the restriction of the ambient inner product to each tangent space . For a regular parametric surface , it is
Here means , not a componentwise square. The coefficients form the Gram matrix of the two coordinate tangent vectors. Regularity makes this a positive-definite matrix, so and .
To calculate the length of a curve , apply the chain rule and integrate its speed:The same inner product gives the angle between nonzero tangent vectors through , and gives the area element as a positive density. One compact expression therefore supplies rulers, protractors, and surface area measurements.
For the lateral surface of a circular cylinder, take the circumferential arc length rather than the angle:Direct inner products give , hence . This is exactly the Euclidean metric on the unrolled plane. For instance, a path with , , has length on either surface. Every corresponding path retains its length, not merely this example, so sufficiently small neighborhoods retain their intrinsic distances. The local isometry preserves angles and surface areas too. Globally is periodic with period : unrolling requires a seam, and the whole circular cylinder is not a single planar manifold chart.
Holomorphic stereographic atlas of the sphere Created 2026-10-07 Updated 2026-10-18
On the unit sphere, use away from the north pole and away from the south pole. Their overlap relation is a holomorphic map, giving a holomorphic atlas for the Riemann sphere. The opposite sign of in the second manifold chart ensures a holomorphic rather than antiholomorphic transition.
Writing the sphere coordinates as avoids confusing their height with the complex coordinate . The two manifold charts cover the whole unit sphere:On their overlap, givesThe coordinate transformation and its inverse are holomorphic, so these manifold charts make the sphere a Riemann surface. The sign in is essential. Geometric projection from the south pole with the same planar axis labels would give . The complex conjugation in that transition prevents it from being holomorphic. For , the correct second coordinate is : positive corresponds to negative imaginary part in this manifold chart.
Local potential of a closed differential one-form Created 2026-10-06 Updated 2026-10-14
For a smooth differential one-form with , take a manifold chart identifying a neighborhood with a ball centered at zero, and set . Closedness means . ConsequentlyThus in any dimension. This is the one-form case of the Poincaré lemma, and applies to spacetime as well as three-dimensional vector calculus. A global potential need not exist on a domain with nonzero periods.
The matrix logarithm near the identity maps onto an open set of its real compact symplectic Lie algebra . Its inverse is the matrix exponential. These statements follow by applying the logarithm to and , and differentiating . Left translations provide manifold charts at every group element. In block form with and , giving real dimension .
Metric volume form 2026-10-06
On an oriented Riemannian manifold, the metric volume form is the volume form taking value one on positively oriented orthonormal frames. In an oriented manifold chart it has the displayed expression. Under an orientation-preserving coordinate change with Jacobian , acquires the factor , precisely matching the transformation of the top exterior product. Thus the expressions agree on chart overlaps. Orientation is needed to make a globally positive form, though the volume density exists without it.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 15 2 Solution Created 2026-10-03 Updated 2026-10-14
A -dimensional embedded submanifold has the subspace topology and, near each of its points, a manifold chart identifying it with a coordinate slice . These slice charts for an embedded submanifold give its smooth structure, and its inclusion is a smooth embedding.
A regular value of a smooth map is one for which is surjective at every . If the preimage is nonempty this forces .
The inverse function theorem used here says that if is smooth and is an invertible matrix, then its restriction to a suitable neighbourhood of is a diffeomorphism onto an open neighbourhood of , with smooth inverse.
To prove the regular level set theorem, fix and choose coordinates centred at . The coordinate representative has a rank- Jacobian matrix. After permuting domain coordinates, its first columns form an invertible matrix. DefineIts Jacobian matrix is block triangular with invertible diagonal blocks, so the inverse function theorem makes a local coordinate change. In these coordinates, is precisely the slice with first coordinates zero. Thus it is an embedded submanifold of dimension , withAn empty preimage is harmless; the local assertion is then vacuous.
Three equivalent formulations of orientability of a smooth manifold are: an oriented atlas whose transition Jacobian determinants are positive; a smoothly varying orientation of a vector space on each tangent space; and a nowhere-vanishing smooth top-degree differential form. An oriented atlas gives compatible oriented coordinate frames. A partition of unity glues their positive local top forms, and a nonzero top form declares a frame positive precisely when it evaluates positively on that frame. These constructions prove the equivalence.
For the orientability of a regular fibre, write . The derivative gives a short exact sequence of vector bundlesThis is the reason the normal bundle of a regular fibre is trivial. Choose any fixed positive basis of and an ambient orientation on . Declare a frame of positive whenis positive in , where . Changing a lift adds a tangent vector and leaves the determinant sign unchanged. Local smooth lifts exist because is surjective, so this rule varies smoothly and agrees on overlaps. It gives a global orientation on . Only an orientation of the single vector space was chosen; itself need not be orientable.
Past exam of the mathematics course of the University of Cambridge 2008 iii Paper 19 1 Solution Created 2026-10-03 Updated 2026-10-14
A smooth vector field on a smooth manifold is a smooth section of its tangent bundle. It acts on smooth functions by . In a manifold chart, . The Lie bracket of vector fields is the commutator of their actions on functions:Expanding in coordinates makes all second derivatives cancel and givesThus the commutator is again a smooth vector field, not a second-order operator. The coordinate expression represents the intrinsic derivation on functions, so agrees on overlaps.
For a diffeomorphism , its pushforward of a vector field isFor every smooth function on , the chain rule gives . Applying this twice yieldsSmooth functions determine a tangent vector, and is surjective, so
On a Lie group, a left-invariant vector field satisfies for every left translation . Given , setThis field is smooth by smoothness of multiplication. The equality proves left invariance. Conversely, left invariance forces , so is the unique left-invariant field with value at . This is a linear isomorphism between and the space of left-invariant vector fields.
The pushforward identity applied to shows that is again left invariant. Consequentlydefines a Lie bracket on . Bilinearity and antisymmetry follow from the operator commutator. Its Jacobi identity follows by expanding the three nested commutators: the six triple compositions cancel in pairs. These properties transfer through the linear isomorphism, making the Lie algebra of .
For the general linear group , use matrix-entry coordinates . It is an open subset of , so every tangent space is naturally . Since , its differential sends to , and henceFor ,and reversing gives . Thus ; evaluating at the identity gives the matrix commutator
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 15 1 Solution Created 2026-10-03 Updated 2026-10-07
An -dimensional smooth manifold is a Hausdorff space with a countable topological base, equipped with a smooth atlas of homeomorphisms from open subsets onto open subsets of , whose overlap maps are smooth diffeomorphisms. The smooth structure is the maximal smooth atlas compatible with these manifold charts. Here manifolds have no boundary unless specified otherwise.
For a space with all the requested topological properties but no such atlas, take the topological tripod: three closed intervals joined at one endpoint. It is a compact connected subspace of the plane with its induced metric. A countable base of planar rational balls restricts to a countable base, the metric makes it Hausdorff, and compactness gives a finite subcover of every open cover, hence a locally finite refinement and paracompactness.
At an interior point of any arm, arbitrarily small neighborhoods are intervals. A coordinate ball in dimension at least two would remain connected after deleting its center; an interval does not. Dimension zero would make the space discrete. Thus any possible connected manifold structure would have dimension one. But a sufficiently small neighborhood of the junction, minus the junction, has three components, whereas an interval chart has two. This contradiction rules out even a topological manifold structure, and hence any smooth one.
The product smooth structure uses manifold charts . Transition maps act separately in the two coordinate blocks and are smooth with smooth inverses. Products of countable bases give a countable base, and the product remains Hausdorff. Therefore with this natural smooth structure.
Define the tangent space by point derivations: a tangent vector at is an -linear map on germs of smooth functions at , satisfying . Addition and scalar multiplication preserve this rule, so these derivations form a vector space. In coordinates , the local identityfollows by integrating the derivative of along the coordinate line segment. Derivations annihilate constants, so it gives . The coordinate derivations are independent since they evaluate the coordinate functions as . ThusFor a smooth map, define the differential of a smooth map intrinsically by . It is again linear and satisfies the derivation rule at , so it maps into . Its coordinate matrix is the Jacobian of the coordinate expression of , independently of the charts by the intrinsic definition and chain rule.
Finally, a zero differential forces each target coordinate function to have all derivatives zero on a small connected source coordinate ball mapping into one target chart. Integration on straight segments makes those functions constant there. Hence is locally constant. Each nonempty fiber is both open and closed, so connectedness gives the zero-differential constancy theorem, .
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 15 2 Solution Created 2026-10-03 Updated 2026-10-07
A Riemannian metric is a smooth field of positive-definite symmetric bilinear forms on the tangent spaces, equivalently a smooth section of with that positivity. Its musical isomorphism isNondegeneracy makes every fiber map an isomorphism. In coordinates the map has matrix , and its inverse has matrix . Smoothness of the inverse follows from the inverse-matrix formula and the nonvanishing determinant. Both maps cover the identity on , giving a smooth vector bundle isomorphism.
For local flattening of a Riemannian metric, choose a manifold chart neighborhood around with closure contained in , and let on . Choose a smooth bump function , with compact support in and equal to one on a smaller neighborhood of . SetThe formulas glue smoothly because the modification is supported strictly inside . A convex combination of positive-definite forms is positive definite. On the metric is exactly , so gives an isometry to a Euclidean open subset. Outside the original metric remains unchanged.
Geodesic completeness means that every geodesic with arbitrary initial point and tangent vector extends for every real affine parameter. On each connected component, the Hopf-Rinow theorem equates this with completeness of the Riemannian distance.
The Euclidean-end claim needs a compact-core interpretation that is absent from its literal hypotheses. Indeed, with , and satisfy those hypotheses. The geodesic reaches the missing unit sphere at and cannot continue within . Thus the printed assumptions alone do not prove completeness.
Here is the intended compact-core completeness for a Euclidean end. Write for the end coordinates and assume additionally thatis compact for every sufficiently large . Choose such an beyond the metric transition and large enough to include the initial point of a geodesic. Its speed is constant. On every segment outside , the Euclidean radius changes at a rate at most , so over a finite parameter interval it cannot exceed . The full segment therefore stays in the compact set . Its velocities also stay in a compact subset of , since their metric norm is fixed and the base set is compact. The smooth geodesic ordinary differential equation consequently extends past any supposed finite endpoint. The reversed-time argument is identical. This proves completeness under the compact-core condition, and explains exactly what the exterior-of-a-ball counterexample lacks.
For upward stability of Riemannian completeness, lengths of all curves satisfy , hence . A -Cauchy sequence is therefore -Cauchy and has a limit because is complete. Smooth positive-definite metrics induce the manifold topology. More explicitly, on a small coordinate ball around , has a bounded largest matrix eigenvalue, so the coordinate straight segment gives . Thus convergence to is also in . That distance is complete, and Hopf-Rinow yieldsFor disconnected , apply this argument on each component.
Past exam of the mathematics course of the University of Cambridge 2013 iii Paper 50 1 Solution Created 2026-10-03 Updated 2026-10-07
There is a small domain issue in the printed notation. If means a quotient vector space by the horizontal plane, the displayed formula does not descend to that quotient vector space: and represent the same class but give different values. The intended construction is stereographic projection, restricted to the unit sphere with the north pole removed. Interpreting the slash as removal of the plane also supplies a suitable ambient domain. The holomorphic stereographic atlas of the sphere is obtained as follows.
Write and . On use . Its inverse, with , isThese formulas give a smooth manifold chart from onto . On choose the second manifold chartIts inverse is , and , so this is also a smooth manifold chart onto . The conjugation in this second stereographic projection is essential. On the overlap, , soBoth directions of this transition are holomorphic maps on , with nonzero derivative. The two manifold charts cover the sphere, hence define a holomorphic atlas, giving precisely the Riemann sphere. If one instead used in both manifold charts, the transition would be and would not be holomorphic.
Orient the sphere by this holomorphic atlas. The given volume form is smooth at infinity: replacing by in its exterior product gives the same expressionMoreover, , so the normalization of this volume form isThus the printed volume form has half the area of the standard round unit sphere; replacing its integral by would introduce an erroneous factor of two.
For , the holomorphic map extends over infinity, since the target reciprocal coordinate is when the source reciprocal coordinate is . Its pullback of a differential form isUsing givesThe degree of a map between oriented manifolds is thereforeFor , the formula on the finite manifold chart is the constant . Its unique continuous extension is also at infinity, rather than an undefined expression . Its pullback of a differential form is zero and its degree of a map between oriented manifolds is zero.
For the preimage calculation when , choose a regular value . There are exactly distinct roots of . At each root the real Jacobian determinant is , so every local contribution to the degree of a map between oriented manifolds is . Their sum is , agreeing with the integral. The exceptional values and infinity are avoided because they are branch values when . For the constant map, any is a regular value with no preimages, giving the same answer zero. This establishes the degree of a power map of the Riemann sphere for every allowed .
Past exam of the mathematics course of the University of Cambridge 2014 iii Paper 15 1 Solution Created 2026-10-03 Updated 2026-10-14
The exterior derivative is an -linear map , agrees with the differential of a smooth function, satisfies the graded Leibniz rule for , and has . These properties determine it locally and hence globally. To see locality directly, if a differential form vanishes near , choose a smooth bump function equal to one near and supported where . The identity gives . Thus global forms can be computed using local extensions in a manifold chart.
In coordinates write . Since , the graded Leibniz rule forcesThis is the uniqueness of the exterior derivative from its axioms. The coordinate formula also establishes existence: it has the stated properties, and the chain rule shows that coordinate changes give the same operator.
The de Rham cohomology is the real quotient vector spaceThus a cohomology class records a closed differential form modulo an exact differential form. In degree zero there are no exact forms; closed functions are locally constant. The Poincaré lemma says that every closed form of positive degree on a star-shaped open subset of is exact, and hence that positive-degree closed forms are locally exact on a smooth manifold.
For the first de Rham cohomology of the two-sphere, let and . Stereographic projection identifies each with , so a closed one-form has primitives . On the connected overlap , the derivative of is zero, so this difference is a constant. Subtracting that constant from makes the primitives agree. They glue to a global smooth primitive. Therefore .
Let be the double covering map and the antipodal map. The pullback of a differential form identifies forms downstairs with -invariant forms upstairs. Averaging commutes with . If an invariant form is exact upstairs, averaging its primitive proves it exact downstairs. Conversely an invariant cohomology class has an invariant representative by the same averaging. This proves the de Rham cohomology of a finite quotient identification . In degree zero the sphere is connected and fixes constants; degree one is zero; in degree two the granted action is multiplication by , whose invariant real subspace is zero. Forms of degree greater than two vanish. HenceThis is real de Rham cohomology; it does not detect the integral two-torsion of the real projective plane.
Past exam of the mathematics course of the University of Cambridge 2014 iii Paper 15 2 Solution Created 2026-10-03 Updated 2026-10-06
A Lie group is a finite-dimensional smooth manifold with a group structure for which multiplication and inversion are smooth. The group defined here is the compact symplectic group , rather than the full complex symplectic group. Also, the displayed matrix expression requires to be ; the printed size is incompatible with .
Since , we have . The matrix exponential commutes with conjugation, as follows term by term from its absolutely convergent power series. ConsequentlyTo construct logarithm charts for the compact symplectic group, consider the real vector spaceDifferentiating the defining identities at gives precisely these conditions. Conversely if , is unitary andso . These are the infinitesimal conditions of the compact symplectic Lie algebra.
Near , the convergent matrix logarithm series is smooth and inverse to the matrix exponential near zero. These local inverses respect transpose, conjugate transpose, and conjugation; also when both matrices are sufficiently close to . Shrink their neighborhoods accordingly. If there, unitarity givesThe symplectic identity is equivalent to , so, putting , it gives , equivalently . Thus this local logarithm restricts to a bijection between a neighborhood of in and an open neighborhood of zero in . Its inverse is the restricted matrix exponential. These restrictions are manifold charts; left multiplication translates them to every via . The chart overlaps are smooth compositions of multiplication, exponential and logarithm. The subspace topology is Hausdorff and second countable, inherited from the finite-dimensional matrix space, so these charts give a smooth manifold.
Closure under products and inverses follows from and unitarity. Matrix multiplication is polynomial in real and imaginary entries, and inversion on the unitary group is , a real linear operation. Their restrictions are smooth in the charts just constructed. Hence is a Lie group without needing a closed-subgroup theorem.
Write in blocks. The two infinitesimal conditions giveThe skew-Hermitian matrix has real parameters; the complex symmetric matrix has complex parameters, hence real parameters. ThereforeFor , any two-by-two matrix satisfies , so the group is . Explicitly,The rows are orthonormal and the determinant is one; conversely unitarity and determinant one force this form. This is the SU(2) as the three-sphere parametrization. The map and its inverse, extraction of the first row, are smooth. Thus is diffeomorphic to .
Past exam of the mathematics course of the University of Cambridge 2014 iii Paper 15 4 Solution Created 2026-10-03 Updated 2026-10-06
A Levi-Civita connection on a Riemannian manifold is a covariant derivative that is a torsion-free connection, , and a metric connection, . A covariant derivative is -linear in , real linear in , and obeys .
Combining metric compatibility for the cyclic triples and eliminating reversed derivatives with the torsion identity gives the Koszul formulaSince is nondegenerate, this determines uniquely. For existence, use the right-hand side to define : expansion of the Lie bracket of vector fields shows it is -linear in , hence defines a smooth one-form, which the musical isomorphism converts to a smooth vector field. The same expansion shows and . Subtracting the formula with exchanged gives torsion zero; adding its versions for exchanged gives metric compatibility. Thus it is a Levi-Civita connection. Equivalently its coefficients in a manifold chart are the Christoffel symbolsThe intrinsically defined Koszul formula ensures these local expressions fit together. This proves the fundamental theorem of Riemannian geometry.
The product Riemannian metric on isThe two factor tangent spaces are orthogonal, and the sum is positive definite. Lift from and from . We check against lifted local frame fields from both factors, which together span each product tangent space.
If is lifted from , then , while depends only on , so . Also and is horizontal, hence orthogonal to . Every term in the Koszul formula is zero. If is lifted from , and depends only on , so . Now and is vertical, hence orthogonal to . Again every term is zero. Thus is orthogonal to both spanning frame families, and positive definiteness yieldsThis calculation uses the lifts' independence of the other factor coordinates; a vector field with varying coefficients in those coordinates can have a nonzero mixed derivative.
Past exam of the mathematics course of the University of Cambridge 2014 iii Paper 15 5 Solution Created 2026-10-03 Updated 2026-10-06
Use the given orientation throughout, and the usual convention that the manifold has no boundary. In an oriented manifold chart the metric volume form isIf is another oriented chart and , then , so because . This is exactly the transformation of the top exterior product. The formulas therefore agree on overlaps and define a smooth positive volume form. Equivalently it takes value one on any positively oriented orthonormal tangent frame.
The metric induces an inner product on -forms by making the increasing exterior products of an orthonormal coframe orthonormal. The Hodge star operator is the unique pointwise linear map satisfyingFor an increasing multi-index , is the complementary wedge with the sign making . Swapping the blocks of and factors introduces . ThereforeIn particular and .
For compactly supported smooth , the -form has compact support. Stokes theorem and the graded Leibniz rule giveA top form equals . Consequently this Hodge integration by parts for one-forms becomes exactlyCompact support of is enough; need not itself have compact support.
Define the codifferential on -forms by and the Hodge Laplacian by . A harmonic differential form is a smooth form in . On functions this is the positive Laplace-Beltrami operator, . This sign convention is required by the product identity; it is the negative of the convention also commonly used for the Laplace-Beltrami operator.
For a -form , the square of the Hodge star operator and the codifferential formula giveApplying the second formula to and the first to givesThus Hodge star commutes with the Hodge Laplacian. Since is invertible, is harmonic if and only if is harmonic. This holds without compactness; we have not used the generally false noncompact implication that a harmonic form must be closed and coclosed.
For a smooth function and one-form , the same graded Leibniz rule gives . Apply this to to obtain the product rule for the positive Laplace-Beltrami operator
The Hodge decomposition theorem states that on a compact oriented boundaryless Riemannian manifold, smooth forms have the -orthogonal decompositionand each de Rham cohomology class has a unique harmonic differential form representative. To spell out the last conclusion, a harmonic form is closed and coclosed because . If a closed form decomposes as , then ; integration by parts gives . Thus it represents . A harmonic exact form has zero norm by adjointness, proving uniqueness. The analytic existence of the decomposition is the stated Hodge decomposition theorem.
Now let be compact, connected and oriented. A harmonic function satisfies , so it is constant. The Hodge star operator identifies with , hence . A Riemannian metric exists by Question 3 even if none was initially chosen. Using the harmonic representative of each class, we obtain the top de Rham cohomology of a compact connected oriented manifoldThe class is nonzero also directly from Stokes theorem, since while every exact top form has zero integral. Boundarylessness matters: a compact interval has zero first de Rham cohomology.