Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Tangent vector
Shape operator Created 2026-09-24 Updated 2026-10-14
The shape operator measures how the unit normal turns as we move along a smooth surface. A plane has a constant unit normal, whereas the outward unit normal of a sphere turns in every direction in the tangent plane. Keeping the direction of this change, rather than just its magnitude, lets one recover the principal curvatures and their principal directions.
Choose an orientation of a surface , with Gauss map . The shape operator at is the linear mapHere is the differential of the Gauss map. Its output belongs to , identified with because both are the vector plane perpendicular to . The minus sign is our convention throughout this branch. [ref]
https://ghomi.math.gatech.edu/Classes/Math497C/LectureNotes9.pdf. Ghomi, Lecture Notes 9, §2.2: Gauss map and shape operator
The shape operator packages the second fundamental form as an operator using the inner product supplied by the first fundamental form:The symmetry of the second fundamental form makes the shape operator a self-adjoint operator for this inner product. Thus an orthonormal basis of principal directions diagonalizes it. In a coordinate basis of a parametric surface, writeThe matrix need not be a symmetric matrix in this coordinate basis: its self-adjointness means . Using the eigenvalues of alone gives the principal curvatures only when is the identity matrix. [ref]
For a worked example, parametrize the lateral surface of an outward-oriented circular cylinder of radius using circumferential arc length and axial coordinate :The coordinate tangent vectors are an orthonormal basis. Since and , the shape operator satisfiesChanging to angular coordinate gives and ; still has eigenvalues . This is why the first fundamental form must participate in the calculation.
For a sphere of radius centered at the origin, the outward unit normal is . Hence , so both principal curvatures are . For a plane, and the shape operator vanishes. Reversing the unit normal negates the shape operator and both principal curvatures; the Gaussian curvature remains unchanged while the mean curvature changes sign, as in orientation reversal of surface curvature.
Singular projection of an implicit curve 2026-10-25
For two constraints , the implicit function theorem gives differentiable functions when the Jacobian determinant is nonzero. At its zeros this particular projection can fail even when a geometric curve remains. A nonzero tangent vector with zero component gives a vertical tangent in that projection. Singular constraint representations require further care: a determinant of zero alone does not prove an infinite derivative or even a regular intersection.
Smooth mechanical constraint 2026-10-24
An ideal contact mechanical constraint supplying a normal reaction and no tangential friction. For a stationary constraining surface, the permitted velocity is a tangent vector, so the normal force has zero power and does no work. For a moving surface, normality alone does not imply zero power in the laboratory frame.
Spherical geometry 2026-10-13
Spherical geometry studies lengths and angles measured along the surface of a sphere, rather than through its interior. It is a useful model whenever travel is constrained to a round surface. Its straightest paths are great circle arcs: they are geodesics, even though they appear curved in the surrounding Euclidean space. Two distinct great circles meet at an antipodal pair, so the parallel-line picture of Euclidean geometry does not apply.
For a sphere of radius , write two positions as , with unit vectors. Their shorter surface route has great-circle distancewhere the dot product gives the central angle in radians. The straight chord through the surrounding Euclidean space instead has length . For a quarter-circle separation these are and : specifying which distance we mean has a measurable effect. On the unit sphere, and great-circle distance equals the central angle.
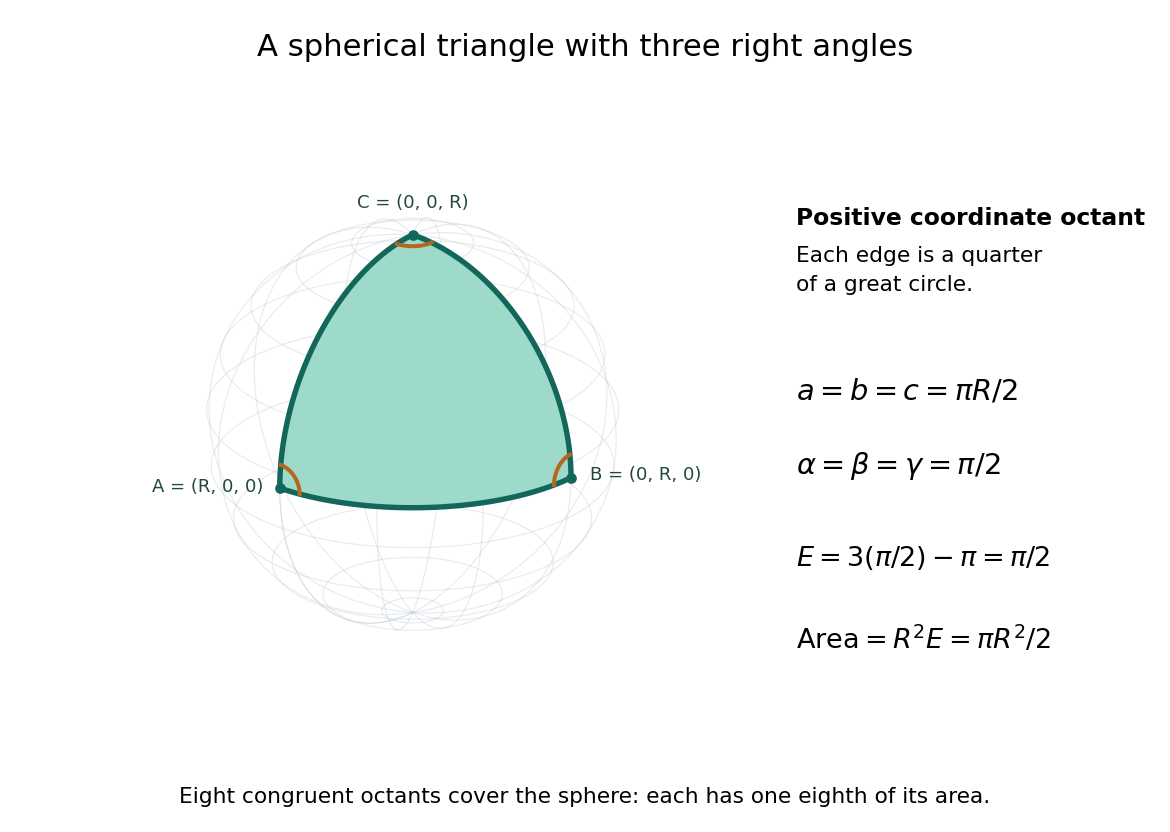
Consider the spherical triangle with vertices , and , joined by the shorter great circle arcs. Each side has length . At each vertex the two outgoing tangent vectors point along the other coordinate axes and are orthogonal, so all three interior angles are . This is the positive coordinate octant of the sphere, not a flat triangle drawn inside it.
For a convex minor spherical triangle with interior angles in radians, the spherical excess formula statesOur octant therefore has area . Independently, eight congruent octants partition the sphere, giving again. Thus angles alone determine area when is fixed, unlike Euclidean geometry, where similar triangles can have arbitrarily different areas. The Gauss-Bonnet theorem explains the connection: the sphere's constant Gaussian curvature times the area equals this excess. For spherical triangles whose area is small compared with , the excess is small, recovering the familiar flat picture.
Spherical law of cosines 2026-10-14
For a nondegenerate convex minor spherical triangle, the spherical law of cosines relates two angular sides , their included interior angle , and the opposite angular side :Relabelling the vertices gives the corresponding formulas for and . As with the spherical law of sines, physical side lengths must first be divided by the sphere's radius. The spherical law of cosines determines uniquely from when the data describe such a spherical triangle. It also recovers each interior angle from three sides, for exampleUsing the cosine and the range selects a unique angle, avoiding the supplementary-angle ambiguity of an inverse sine calculation.
To derive the spherical law of cosines, let be the vertex unit vectors at , so , and . The outgoing unit tangent vectors at are and . Their dot product is both and , proving the identity. This gives a geometric explanation: spherical trigonometry compares angles in the tangent plane using vectors in the surrounding Euclidean space.
For a worked example on the unit sphere, take the verticesAt , the outgoing unit tangent vectors are and , so the interior angle is a right angle. The vertex dot products give . The spherical law of cosines then reduces to the right-angle identity , givingTo find , use the relabelled spherical law of cosines:The physical side lengths on a sphere of radius are and . For example, on a toy sphere with metres they are approximately , and metres; the interior angles stay the same. Applying the planar Pythagorean theorem directly to the angular sides would instead give . That flat right triangle calculation does not give the great-circle distance between and .
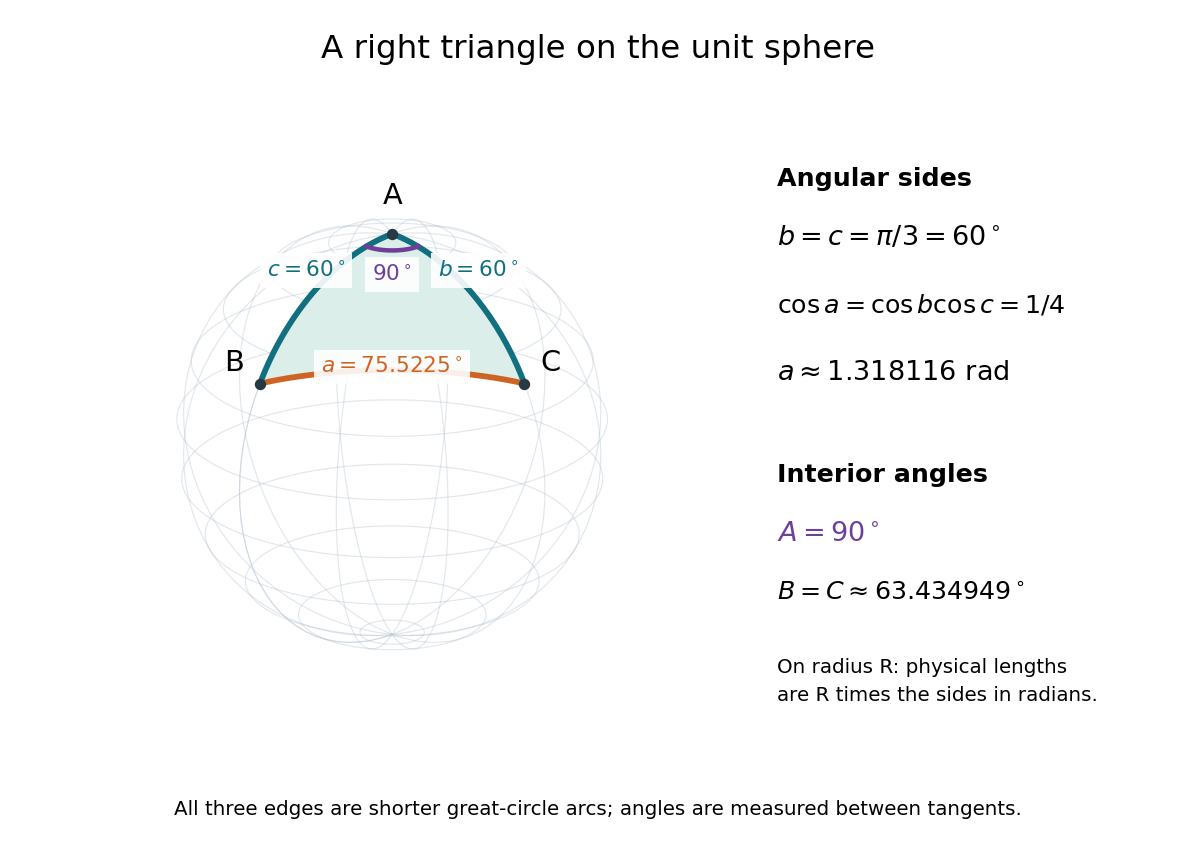
The familiar law of cosines reappears as a local approximation. With all small in radians, substitute the small-angle approximations and into the spherical law of cosines and keep terms through second order:Multiplication by gives the planar law of cosines for the physical side lengths. For a fixed small surface triangle on a progressively larger sphere, the angular sides shrink and this approximation improves. Thus the curved and flat formulas fit together: the Pythagorean theorem is recovered locally when is a right angle.
Spherical law of sines 2026-10-14
For a nondegenerate convex minor spherical triangle, with angular sides opposite interior angles , the spherical law of sines statesThe sines of sides refer to central angles, so a physical side length on a sphere of radius must enter as . All six angles lie in , and the denominators are positive. The reciprocal form, , is equivalent. This is Tatum's sine formula, equation 3.5.1, in Celestial Mechanics, section 3.5: spherical sine and cosine formulas.
A short proof explains the symmetry of the spherical law of sines. Let be the vertex unit vectors at . At , the outgoing unit tangent vectors towards are and . Their angle is , so the magnitude of their cross product is . Since both tangent vectors are orthogonal to , the scalar triple product obeysDividing by proves the spherical law of sines. Its beauty is that the same three-dimensional scalar triple product can be calculated at any vertex, producing all three ratios at once.
For the spherical triangle worked out under the spherical law of cosines, , and . Hence , and the spherical law of sines givesThe inverse sine gives , but the supplementary angle has the same sine. The spherical law of sines alone therefore leaves two candidates for this angle. The spherical law of cosines, using the known three sides, gives and selects ; likewise . When only two sides and an opposite angle are given, two distinct valid spherical triangles can remain. A cosine relation resolves an inverse sine branch only when enough additional data are known; it does not make every ambiguous data set unique.
Spherical triangle 2026-10-14
A spherical triangle is bounded by three great circle arcs. For the usual convex minor spherical triangle, the vertices are neither antipodal nor on one great circle, and its angular sides and interior angles lie in . An interior angle is measured between outgoing tangent vectors to the two sides at a vertex, rather than between straight chords inside the sphere. The spherical law of sines and spherical law of cosines determine its side-angle relations; the spherical excess formula determines its area.
Subdivision surface 2026-10-14
A subdivision surface is the limit of repeated mesh refinement and vertex averaging. Exact interrogation evaluates this limit and, where defined, its tangent vectors and normal vectors; a finite refined control mesh is generally only an approximation to the limit.
// Target: analysis.bigb
Surface area of a surface of revolution Created 2026-10-25 Updated 2026-10-31
For the radial profile , with , use the parametrized surface , . The two tangent vectors are orthogonal and have Euclidean norms and . Their cross product gives the displayed surface area. Geometric surface area assumes a single covering of the radial profile. A general three-dimensional generating curve must first be replaced by its actual radius ; its spatial arc length cannot simply replace the radial profile's arc length.
Tangential boundary derivative 2026-10-05
A tangential boundary derivative differentiates the boundary restriction of a function along a tangent vector. Prescribing it fixes the boundary value only up to a constant on each connected boundary component. This differs from a Neumann boundary condition, which specifies a normal derivative.
Tangent plane Created 2026-10-14 Updated 2026-10-31
For an embedded regular surface and , the affine tangent plane isIt is a set of points through , whereas the tangent space is a vector space of displacements with zero vector. Some texts also call that two-dimensional tangent space the tangent plane; here the translation by distinguishes the two uses. For a regular parametric surface with ,where the partial derivatives are evaluated at . Regularity means that these tangent vectors are linearly independent, equivalently . Their cross product is a normal vector. [ref]
https://www.math.uga.edu/sites/default/files/inline-files/ShifrinDiffGeo.pdf. Theodore Shifrin, Differential Geometry: A First Course in Curves and Surfaces, Chapter 2, §1: regular parametrizations and tangent planes
For an implicit regular surface , require a smooth function with . ThenDifferentiating proves that every surface velocity lies in the displayed kernel of a linear map; the implicit function theorem gives a local graph with two independent coordinates, proving equality. The gradient is the normal vector with respect to the ambient dot product. [ref]
For the sphere , , and the affine tangent plane has equation . At the unit sphere's north pole , compare the plane with the displacement tangent space . The regular parametric surface , for , gives and , confirming the same answer.
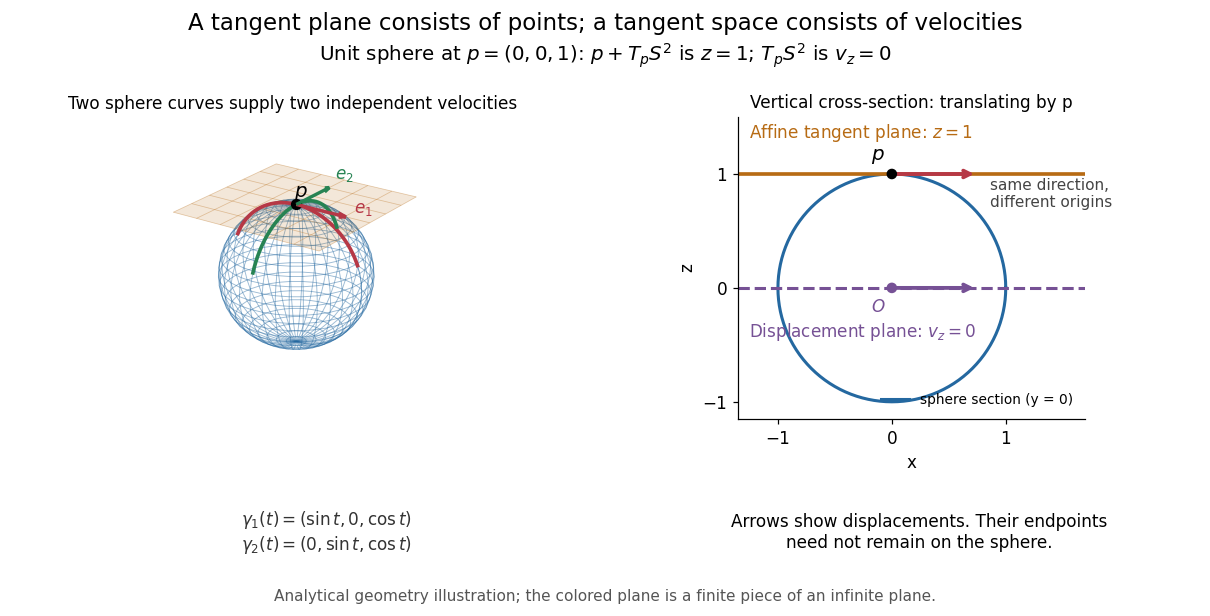
This analytical illustration shows a unit sphere and a vertical cross-section. The smooth curves and give the two displayed tangent vectors at . The straight point for any nonzero is outside the sphere when , since . A tangent plane therefore captures first-order motion, not an exact patch of the regular surface.
The same idea makes local approximation useful. For the graph of a function with a smooth function, the affine tangent plane is . [ref]
https://openstax.org/books/calculus-volume-3/pages/4-4-tangent-planes-and-linear-approximations. Gilbert Strang and Edwin Herman, OpenStax Calculus Volume 3, §4.4: tangent planes and linear approximations
With continuous second partial derivatives, the vertical error is in Big O notation. On the unit sphere near its north pole, : the tangent plane loses quadratic bending while preserving all first-order velocities.A failed regularity test needs interpretation. Replacing the sphere equation by makes everywhere on the same perfectly regular sphere, so this defining smooth function cannot recover its tangent plane. Similarly, the usual spherical parametric surface loses matrix rank at the poles, while the graph parametrization above remains regular there. A vanishing gradient or degenerate parametrization invalidates that calculation; it alone does not prove that the underlying geometry has no tangent plane.
Tangent space Created 2026-09-24 Updated 2026-10-14
At a fixed point of an -dimensional smooth manifold without boundary, the tangent space is the real vector space of all tangent vectors at . In manifold charts and , a tangent vector has componentsThe coordinate basis transforms inversely, so the tangent vector is unchanged. This invertible Jacobian matrix also preserves vector addition and scalar multiplication, giving a vector space of dimension independently of coordinates. [ref]
https://www.math.toronto.edu/mein/teaching/LectureNotes/Man.pdf. Eckhard Meinrenken, Differentiable Manifolds, §1.5: tangent spaces and coordinate bases
For example, at in , use the alternative manifold chart , . The Jacobian matrix sends to . Indeed, the smooth curve gives . Conversely, and , so . The numbers change; their action on every smooth function does not.
For an embedded submanifold , the tangent space can be identified with the vector subspaceA proof outline explains why every coordinate vector is possible: in a manifold chart , lift the short straight path using . Its tangent vector has components . For a regular local parametrization , the same chain rule gives , where . This is the tangent space from a local parametrization.
For the sphere , differentiating that equation gives . Conversely, for any nonzero with , the smooth curvelies on the sphere and has ; use a constant smooth curve for . Thus , not merely a subset of that plane. At this vector subspace is , while the affine tangent plane drawn through is .
This also explains a mechanical constraint without requiring a force calculation. In the ideal mathematical model of a particle confined to a stationary sphere, its allowed velocities at are exactly : the radial component must vanish, but either independent tangential direction is available. For a general stationary holonomic constraint with independent equations, the regular level set theorem gives . These are instantaneous kinematic possibilities; they do not determine the actual subsequent motion. On a general smooth manifold, tangent spaces at different base points cannot be identified canonically; an affine connection supplies parallel transport when such comparisons are needed.
Tangent vector Created 2026-09-24 Updated 2026-10-18
A tangent vector at a point of a smooth manifold without boundary records an instantaneous velocity through . Its base point is part of the data; measuring its length additionally requires a Riemannian metric. Intrinsically, a smooth curve with defines its tangent vector by how every local smooth function changes along it:This is a derivation at a point. Two smooth curves through represent the same tangent vector if these derivatives agree for every such smooth function; equivalently, their coordinate velocity vectors agree in one manifold chart. The chain rule makes that agreement independent of the chosen manifold chart. [ref]
For an embedded submanifold of Euclidean space, the intrinsic tangent vector is represented by the ordinary derivative , with its base point retained. A drawn arrow starting at represents that tangent vector; its endpoint need not lie on the embedded submanifold. Nor is a tangent vector required to be a unit tangent vector: a stationary smooth curve gives the zero vector, which belongs to the tangent space but has no direction to normalize.
Here are explicit calculations. In , and have different routes but the same tangent vector at . For , both give . For a circle of radius , has tangent vector at : changing changes the speed or reverses travel without changing the circle.
A reparametrization with gives, by the chain rule, . A regular change of curve parameter has . The singular choice instead givesBoth describe the same parabola, whose tangent line at the origin is still the horizontal axis. The zero velocity diagnoses this singular change of curve parameter, whose inverse is not differentiable at zero; it does not show that the geometric tangent line is absent. The regular curve supplies its nonzero direction.
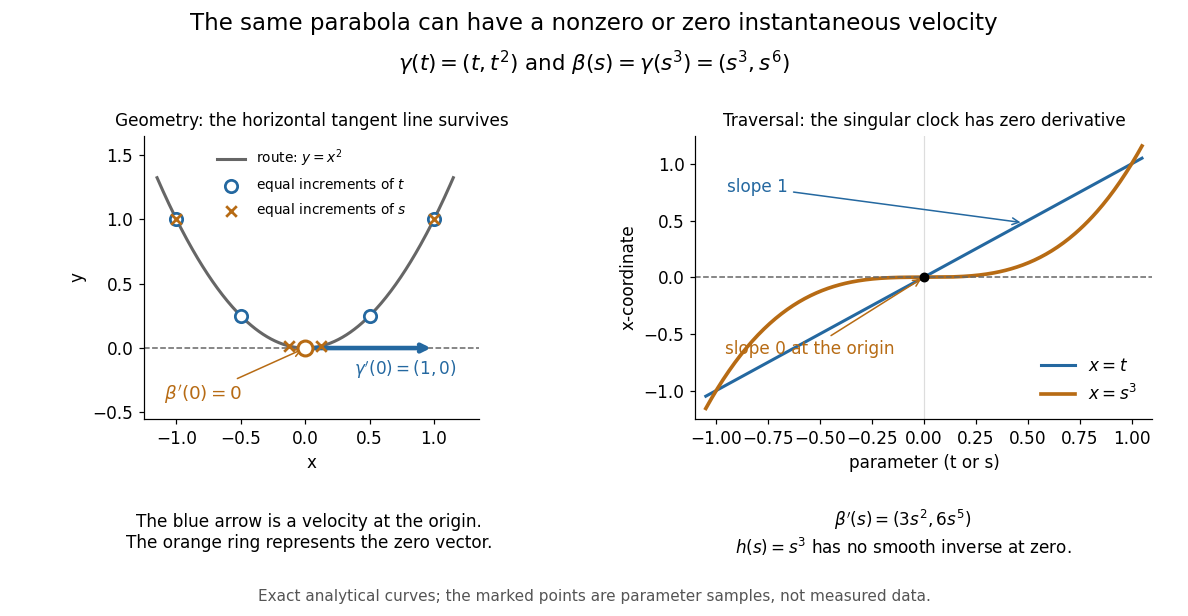


The diagram is an analytical illustration of these exact parametric curves, with equal parameter increments marked on each route. It separates geometry from traversal: the tangent line depends on the route, while a velocity vector also depends on how the curve parameter advances.
Theorema Egregium Created 2026-09-24 Updated 2026-10-14
For smooth surfaces, Gaussian curvature depends only on the first fundamental form and its first two coordinate derivatives. Consequently any smooth local isometry satisfies . The surprise is that is defined using the shape operator, which describes bending in space, yet its value can be recovered from measurements made entirely within the surface.
In his 1827 paper, Carl Friedrich Gauss expressed Gaussian curvature through the metric coefficients and their partial derivatives in Article 11, then stated its invariance under development in Article 12. Article 13 explicitly compares a plane with surfaces developable onto it, including cylindrical surfaces. The paper was presented on 8 October 1827 and printed in 1828; the Morehead–Hiltebeitel English translation appeared in 1902. [ref]
https://www.gutenberg.org/files/36856/36856-pdf.pdf. Gauss's original paper in English translation, Articles 11–13 and title pages
A plane and a circular cylinder can have different principal curvatures while both have . Their matching first fundamental forms exhibit the actual local isometry. In contrast, no nonempty open patch of a sphere of radius can be flattened smoothly into a plane while preserving its first fundamental form: cannot become zero. Making the patch small reduces practical distortion, but never produces an exact local isometry. This is a geometric obstruction to a perfectly distance-preserving flat map of a spherical world, independent of where one places a seam.
The following proof outline connects the two descriptions of Gaussian curvature. For a parametric surface with metric coefficients , decompose its second derivatives by the Gauss formulaTaking tangent vector inner products determines the lowered Christoffel symbols solely from the Riemannian metric:Comparing and gives the Gauss equationConsequentlywhere is the corresponding component of the intrinsic Riemann curvature tensor, with the sign convention in the displayed Gauss equation. The final expression uses only and its first two derivatives.
Timelike cone 2026-10-31
The timelike cone is the open set of nonzero tangent vectors with timelike squared norm. It has future and past components once a time orientation is chosen. Homogeneity extends an identity for unit timelike vectors to this whole open set. In particular, if a symmetric quadratic form vanishes on every timelike vector, its polynomial vanishes on an open set and therefore vanishes identically. This observation proves the converse from geodesic first integrals to the Killing equation.
Timelike curve Created 2026-09-24 Updated 2026-10-20
A timelike curve has a nonzero tangent vector with negative Minkowski norm in metric signature at every regular point. A physical massive observer's world line is also future-directed. Parametrizing it by coordinate time gives , or : the local tangent condition is exactly the subluminal speed condition. It is stronger than checking only that two endpoints have timelike separation.
Tractoid 2026-10-31
The tractoid is the surface of revolution of a unit tractrix. For with , its coordinate tangent vectors are orthogonal and have squared lengths . The coordinates , transform this first fundamental form into , giving a local isometry to the hyperbolic plane. Thus its Gaussian curvature is minus one. The angular coordinate is periodic globally, while its unwrapped coordinate is a real variable; this distinguishes the local metric identification from a global embedding of the whole hyperbolic plane.
Transversal surface intersection tracing Created 2026-10-14 Updated 2026-10-14
For a parametric surface and a scalar implicit equation , set . At a regular transversal intersection, , and is a parameter tangent vector. Normalize its image under to choose physical arc length steps. A predictor followed by Newton method correction of and a transverse plane equation gives a local continuation method. Certified patch bounds are useful for finding seeds; corner signs alone do not detect a closed intersection entirely inside a patch.
Unit tangent vector Created 2026-09-24 Updated 2026-10-14
For a regular curve with nonzero velocity vector, its unit tangent vector isThe Euclidean norm in the denominator removes the traversal speed, leaving a unit vector that records direction. A positive change of traversal speed leaves this direction unchanged; reversing the direction of travel reverses . In arc length coordinates, .
For the parabola , the velocity vector is and the speed is . At , . The tangent vector and the unit tangent vector point in the same direction, but only the latter has Euclidean norm one. The principal normal vector is a further choice based on how this direction changes, where the curvature is nonzero. [ref]
In elliptic cylindrical coordinates, write a vector field as using the local orthonormal unit vectors. The scale factors of orthogonal coordinates are , so the divergence and curl areApplying the divergence to the gradient of a scalar function gives . These formulas hold where . They use physical components along unit vectors, rather than components along the unnormalized coordinate tangent vectors.