Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Mass
The moment of inertia about a specified axis is , where is perpendicular distance from the axis. The parallel axis theorem states for two parallel axes separated by , one passing through the centre of mass of a body of mass .
It is easiest to calculate the eccentric disc by subtraction. Let be the mass of the unperforated disc and the removed mass. Uniform thickness and density give and , hence and . The hole is tangent to the rim, so its centre, and therefore the shaft axis, lies from the original disc centre. About the shaft axis,The shaft contributes . ThusThe motor's torque is at nonzero angular velocity, while the resisting torque is . The rotational equation of motion and its equivalent energy balance areAt the steady state, input power equals dissipated power, givingFor the acceleration, use . Then with , soThe approach to takes infinite time. This constant-power rotational acceleration idealizes the start: diverges at rest, although the energy balance has a well-defined limiting solution. A real motor has finite starting torque.
In a fixed point-mass Newtonian gravitational field, a test mass experiencesBecause this is a central force, its torque about the attracting centre vanishes and angular momentum is conserved. The orbit lies in a fixed plane and sweeps out equal areas in equal times. Since the force is also conservative, the specific orbital energy is constant:The last two terms form an effective potential. They show how the angular-momentum barrier competes with attraction and determines the turning radii. For nonradial motion the orbit is a conic section:Negative energy gives an ellipse, with ; zero energy gives a parabola; positive energy gives a hyperbola. The circular limit has , and . For a bound ellipse of semimajor axis , and the orbital period is . The local escape speed is . These are the point-mass, test-particle limits; extended mass distributions or noncentral perturbations change the orbit laws.
The Lorentz force determines the motion of a charged particle:At nonrelativistic speeds, . The electric field does work at rate , while the magnetic part of the Lorentz force is perpendicular to velocity and does no work. A uniform electric field gives constant acceleration ; with a transverse initial velocity, the trajectory is a parabola.
In a uniform magnetic field, the parallel velocity is constant, while the perpendicular component undergoes circular motion. The angular cyclotron frequency, orbit radius and helical pitch areThe sign of determines the sense of rotation. For perpendicular uniform electric fields and magnetic fields, the guiding centre has the electric drift velocityIndeed, , so the remaining motion is cyclotron rotation about that drifting centre, with possible motion along the magnetic field. The drift is independent of electric charge sign and mass. At relativistic energies, retain and the corresponding relativistic orbit radius rather than assuming constant nonrelativistic acceleration.
Take a representative tennis-ball mass of . The speed is nonrelativistic, so the de Broglie wavelength isThis is an estimate because the mass was not specified. The wavelength is vastly smaller than any practicable aperture or obstacle separation: a diffraction angle of order is unresolvably small for laboratory-scale . Moreover, interactions with air, thermal radiation and the apparatus destroy observable coherence between macroscopically distinct paths. Quantum mechanics still applies; the small wavelength and rapid decoherence explain why ordinary experiments reveal classical trajectories rather than a measurable interference pattern.
For uniform Earth density, the shell theorem says that only mass within radius contributes to the gravitational field there. Since enclosed mass is proportional to ,At depth , . A simple pendulum has small-amplitude period , so the pendulum clock below a uniform-density surface runs at the fraction of its surface-calibrated rate. After a surface-clock hour, its lag isThe mine clock is slower because gravity is weaker under the stated uniform-density assumption. The expansion gives the same result. This is a change in the mechanical pendulum period, not a relativistic clock effect; a realistic Earth density profile would require a different interior-gravity calculation.
Use distinct symbols for the dimensions of mass, length, time, temperature and amount of substance. The molar gas constant has dimensions , while the given is a molar mass with dimensions . Matching dimensions in the proposed power law giveswith the amount-of-substance equation repeating . ThereforeDimensional analysis fixes these exponents but not a dimensionless multiplier. For example, an open-tube mode number and the gas's heat-capacity ratio enter the actual resonance frequency without changing the dimensions.
The original diagram has a horizontal bottle neck, so weight does not enter the axial force balance. Gauge pressure acts on the cork's end area and supplies outward force . The radial contact force is the contact pressure times the cylindrical contact area, . The limiting friction is , so outward sliding occurs whenThe assumption of equal static and kinetic friction coefficients removes a separate force drop when slipping starts.
Initially the pressure is marginal at , so . During extraction the contact length decreases, while the pressure force stays constant. The net force is therefore . The cork's mass is , giving the pressure-driven cork ejection equationFor and , solving the constant-coefficient equation givesThe equilibrium is unstable: as the cork moves out, friction decreases and the unbalanced force grows.
Multiplying the equation of motion by and integrating gives . The contact ends at , soEquivalently, the net work is . Exactly zero initial velocity would leave the ideal marginal configuration stationary. The exit time diverges as , even though the limiting exit speed is finite.
The density is , so . For an ideal upward launch at this speed, conservation of mechanical energy gives height above the exitThis neglects air resistance and the small gravitational work during extraction compared with the launch energy. Actual gas pressure need not stay constant, so it is an idealized estimate.
For particles in an inertial frame, total momentum and angular momentum about a fixed origin areThe momentum derivative is the total external force when internal forces cancel pairwise. Angular momentum is conserved when the total external torque vanishes and the internal torques sum to zero, as for pairwise equal-and-opposite central forces. Equal-and-opposite internal forces alone need not cancel internal torque if their lines of action are different. An isolated system with these internal-force properties conserves both quantities; if fields carry momentum, the complete system must include them.
For a straight rocket, let its instantaneous remaining mass be and let be ejected during a velocity increase . The exhaust's inertial velocity is to first order. Conservation of momentum givesIntegrating from initial mass to dry mass yields the rocket equationIt is the rocket-plus-exhaust system that is isolated; the rocket alone is a variable-mass open system.
For the firework, the original diagram places one tangentially firing point rocket at the end of each radial rod. The parallel axis theorem changes each rod's central inertia to . Adding all rods and fueled rockets givesWhen fuel is exhausted, .
Let now denote the total remaining fuel in all three rockets, so . Fuel at the rim co-rotates before ejection. Its backward tangential exhaust velocity is , and its angular momentum per unit mass about the axle is . For an infinitesimal ejection,Since , the co-rotation terms cancel and leave . The tangential-exhaust rotor with a fixed dry inertia therefore obeysNeglecting the exhaust's initial tangential motion would give an incorrect angular-momentum balance. The rod mass remains in the denominator throughout the burn.
Expand the cloud's potential energy about a stable equilibrium: . Equilibrium gives , stability gives , and reflection symmetry also removes odd terms. For small displacements, and .
Including the electric and damping forces, Newton's second law is . Dividing by gives the Lorentz oscillator modelThe specified convention uses as the damping coefficient per unit mass.
For the steady response, represent the field by and the displacement by , taking real parts for physical quantities. Substitution givesDefine the nonnegative amplitude and . ThenFor positive , . For electrons , the phase of a negatively charged driven oscillator is : the low-frequency displacement is opposite to the field, rather than in phase with it. A signed amplitude could absorb this extra , but the phase convention must then be stated. The induced dipole has phase for either charge sign. Transient free oscillations have been omitted because the question asks for steady state.
For the electron cloud, andThe visible range corresponds to between and , below this resonance. The resonant wavelength is about , in the ultraviolet.
The acceleration amplitude is . At fixed incident field amplitude, the scattered intensity is therefore proportional toWell below resonance and outside strong damping corrections, is nearly frequency-independent and this becomes the Rayleigh scattering wavelength dependence . The shortest visible wavelengths are consequently scattered much more strongly into directions away from the direct solar beam than the longest ones, producing a blue sky. The simple fourth-power approximation gives a factor 16 between 400 and 800 nm at equal incident intensity. Retaining the undamped denominator with the given resonance raises that factor to about 22.7, since the upper end is not extremely far below resonance. The exact ratio needs the unspecified damping and incident solar spectrum; the stronger scattering of the blue end is the robust conclusion here.
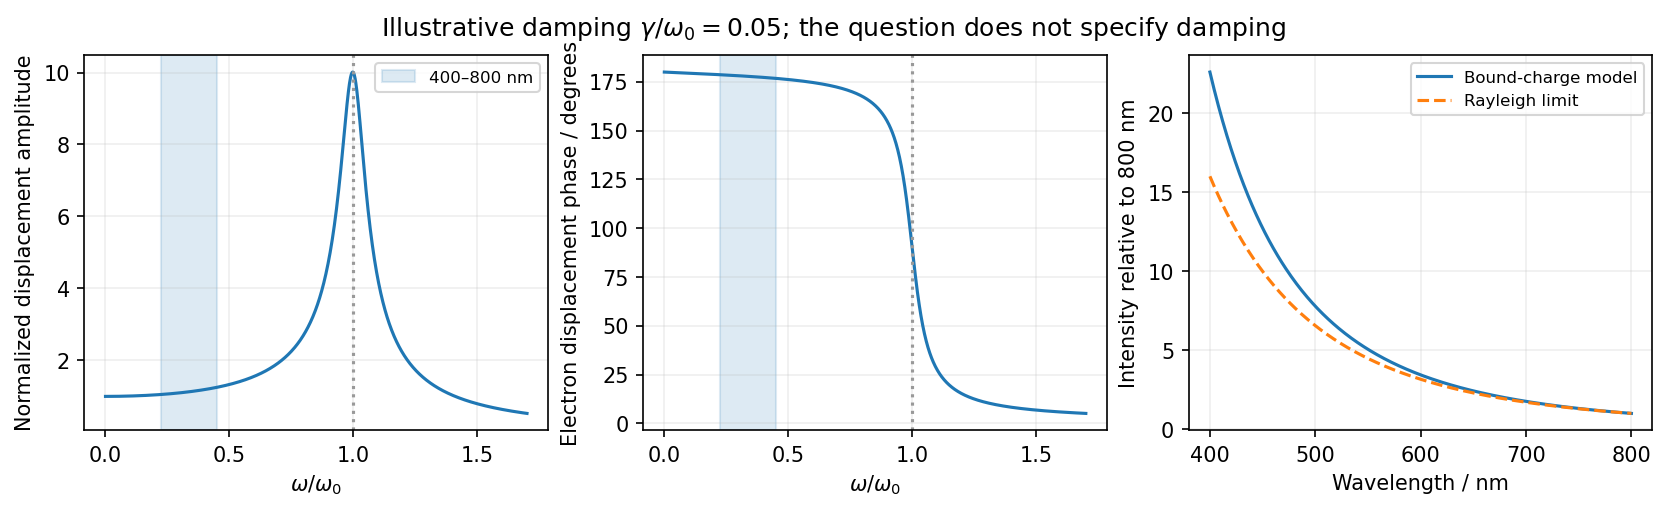
The model describes frequency-dependent scattering, not the detailed perceived color after solar-spectrum weighting and human visual response. It also explains why treating the electrons as free at visible frequencies would miss the bound-charge fourth-power limit.
At the first two specified times, the displacement profiles areThe second curve is the first shifted right by . More generally a point of fixed wave phase satisfies , so it moves along . Hence the wave travels in the positive direction withThis phase velocity is distinct from the local transverse velocity of a string element.
For the force derivation take a short segment between and . Let the tangent angles to the positive axis be and . The left tension pulls along the negative tangent and the right tension along the positive tangent. With small slopes and approximately constant tension magnitude , the horizontal components cancel to leading order andThe segment mass is , where is mass per unit length, not volume density. Newton's second law therefore givesThe approximation neglects bending stiffness, damping and changes in tension caused by finite-amplitude stretching.
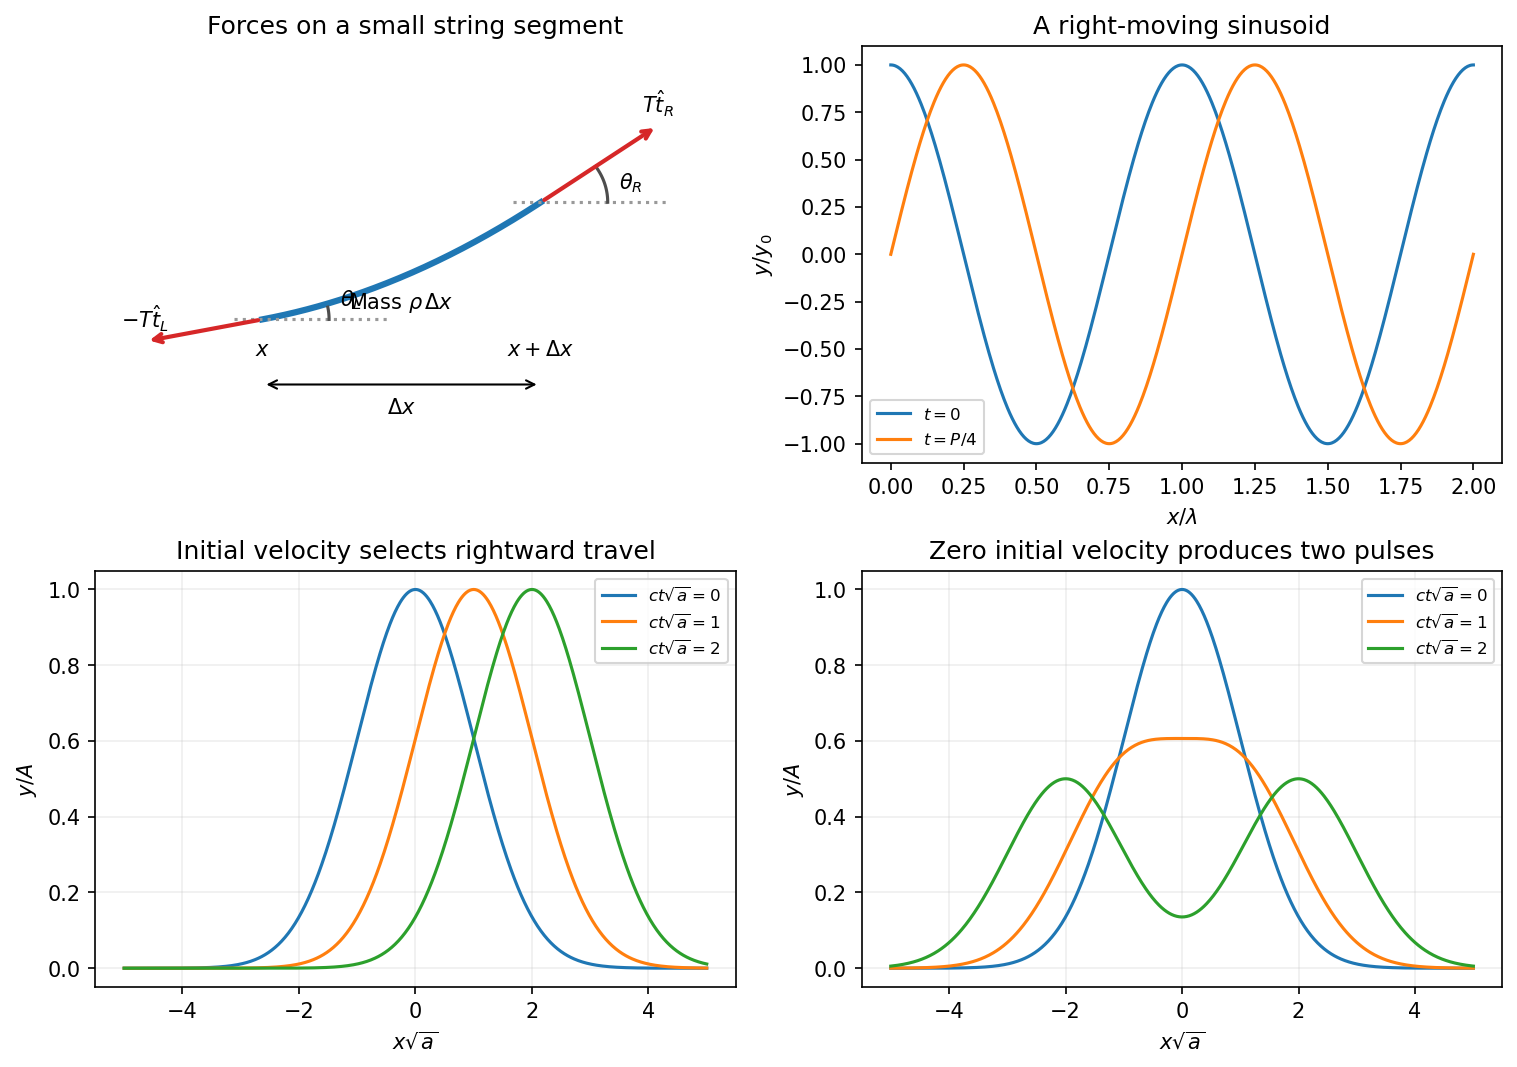
Converting the supplied density gives , soFor the pulse, define with . The given initial velocity is , exactly the velocity associated with a right-moving displacement . ThereforeIt moves right without changing shape in this nondispersive model. With the same initial displacement but zero initial transverse velocity, D'Alembert's formula instead gives the Gaussian pulse splitting from zero initial velocityThe two half-amplitude pulses travel in opposite directions. Their initial velocities cancel, while their initial displacements add to the prescribed Gaussian. The two initial-value problems have different kinetic energies; splitting into half-height pulses does not contradict energy conservation. These forms assume a string long enough that reflections from its ends have not returned.
A charge moving nonrelativistically in prescribed fields obeys the Lorentz force lawThe magnetic part is perpendicular to velocity, so : the electric field can change kinetic energy, while the magnetic field alone changes direction without doing work.
In a uniform electric field with no magnetic field, acceleration is constant: and . The trajectory is a parabola when there is initial motion perpendicular to the field, and a line when motion is purely along it. Reversing the charge reverses the electric acceleration.
In a uniform magnetic field with no electric field, resolve velocity into parallel and perpendicular components. The parallel component is constant; the perpendicular component rotates at the cyclotron frequencyThe resulting path is a helix, or a circle if , with pitch . Charge sign determines its sense of rotation. These relations underlie magnetic bending and mass/charge analysis. At relativistic energies, use momentum ; at fixed energy the cyclotron frequency becomes .
For uniform crossed fields , the velocity satisfies . The orbit is a gyromotion about a guiding center drifting withindependent of mass and charge sign. A velocity selector transmits particles with the appropriate direction and speed without deflection. If the electric field has a component along the magnetic field, that component accelerates the parallel motion instead. Nonuniform fields can add other drifts; the simple helix and uniform crossed-field expressions require the stated uniform-field assumptions.
A position-dependent force is a conservative force when its work depends only on endpoints. Equivalently, its work around any closed allowed path vanishes, and one can define a potential energy satisfyingThe potential is defined up to an additive constant. A vanishing curl, , is a local test; it guarantees a global single-valued potential on a simply connected region with suitable regularity. Holes or excluded singularities require checking the global path condition.
The work-energy theorem gives . For a static potential this implies . If depends explicitly on time, then instead under that force alone. Friction and other nonconservative forces add their own power and can convert mechanical energy into heat.
Examples include the gravitational potential energy outside a spherical mass and the electrostatic energy , where . For a point source charge , , giving attraction or repulsion through the sign of . A spring has and force . An equilibrium has ; a strict local minimum is stable against small displacements when the quadratic curvature is positive. Expanding about that minimum explains the harmonic restoring force used in many small-oscillation models.
Magnetic force on a moving point charge does no work, but it is velocity-dependent and is not generally a position-only force . Likewise a time-varying magnetic flux induces a circulating electric field with , so that electric field cannot globally be represented solely by an electrostatic scalar potential. These distinctions prevent treating every field force as conservative simply because an energy description exists for the complete system.
Use dimensions for mass, length and time. The reduced Planck constant, gravitational constant and speed of light have dimensionsFor to have the dimensions of a length, dimensional analysis requiresThe first equation gives ; the third gives . Substitution in the second gives . HenceWith , and , the Planck length isThe proposed monomial fixes the dimensionless prefactor to one; dimensional analysis on its own cannot select an arbitrary dimensionless multiplier.
Powered vertical flight. Take upward velocity as positive, and let be the downward exhaust speed relative to the rocket. During the rocket's mass changes by , and exhaust mass leaves with Earth-frame velocity . Compare the momentum of the rocket plus this newly expelled exhaust before and after the interval:Discard the second-order product . The result is , orThe positive rocket thrust is . Integrating with and gives the rocket equation with gravitational loss:Using for the rocket alone without the exhaust momentum flux would give the wrong equation for this open system.
Orbital speed under the stated gravity assumption. A circular orbit of radius requires centripetal acceleration . If the magnitude of gravitational acceleration is the stipulated constant even at the orbit,This treats gravity as centrally directed for the orbital calculation, while retaining its constant magnitude. The subsequent flat-surface approximation treats its direction as locally vertical.
Burnout height. During the unpowered projectile motion, horizontal velocity is constant. At the top of the trajectory the vertical component vanishes, so the horizontal component must equal the orbital speed . At burnout, therefore,These follow either by integrating or by the vertical work-energy theorem. Substituting the preceding constant- orbital result givesThe vertical component is initially positive, as required to reach the orbit after burnout.
Alternative inverse-square interpretation. A real Earth's exterior Newtonian gravitational field is not constant over a altitude change. If instead means the surface value , then Newton's law of universal gravitation gives andUsing this orbital speed but the paper's constant- flat projectile motion approximation for the coast would giveThis alternative changes the global constant-gravity assumption; it is not the same model as the result. An exact curved Kepler orbit coast would also abandon the prescribed flat trajectory. The printed assumptions support the constant-magnitude answers above, while the inverse-square values explain the different answer obtained from the usual physical Earth-orbit formula.
Directions. Choose along the horizontal spindle from the pivot to the disk, and vertically upward. With lever arm and weight , the torque about the pivot isClockwise precession viewed from above has . The relation therefore requires the spin angular momentum to point along , from the disk toward the pivot. The disk spins clockwise when viewed from its outer face looking along the spindle toward the pivot. Looking from the pivot reverses that apparent rotation. The right-hand rule fixes these signs unambiguously.
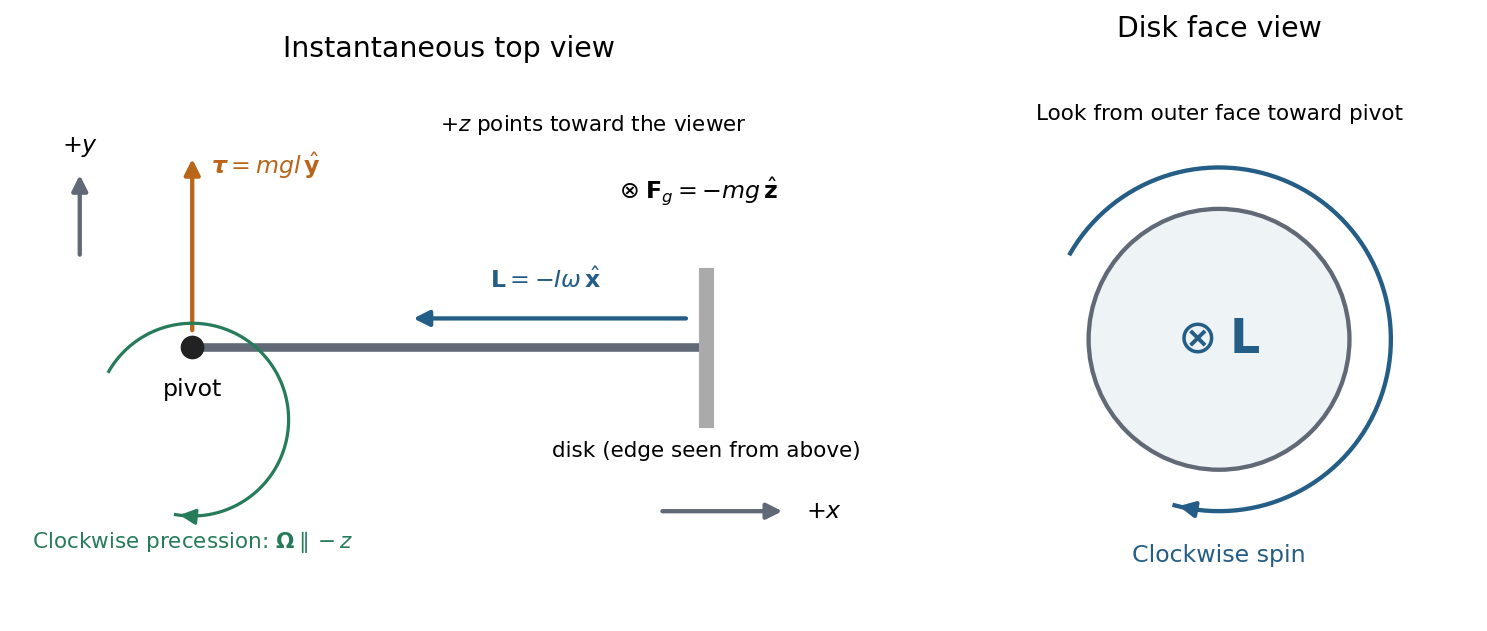


The drawing shows an instantaneous top view; the disk's angular momentum and the horizontal spindle turn clockwise together. The pivot force has zero torque about the pivot.
Rate of precession. For steady horizontal motion the spin contribution has magnitude and turns through in time . Its change is perpendicular to itself and has magnitude . HenceThis is the usual slow steady gyroscope precession relation. Any constant vertical angular momentum associated with steady precession has zero time derivative; the horizontal spin contribution supplies the changing component here. Transient nutation is excluded by the prescribed horizontal steady motion.
Clock design. Convert both rotation rates to angular frequencies:For the moment of inertia of a uniform disc, , so the mass cancels:
Spin friction. At fixed geometry, reducing increases . The precession period, , therefore decreases. This trend holds while slow steady precession remains a suitable description; it cannot be extrapolated to a stopped disk.
Counterweight. To oppose the disk's gravitational torque, place the counterweight on the other side of the pivot, at . The net torque isA horizontal axle can remain fixed when this vanishes, givingFor the fixed spin direction already found, counterbalanced gyroscope precession has signed rateMoving the counterweight outward from the pivot first slows the clockwise motion, eliminates its driving torque at balance, and then reverses the steady motion to counterclockwise. A counterweight on the disk's side would add to the gravitational torque. These statements neglect axial spin moment of inertia of the counterweight and assume the stated horizontal motion, without a separately imposed precession at balance.
Momentum identity. From the Lorentz factor, . The relativistic three-momentum therefore satisfiesTogether with relativistic energy , this gives the energy–momentum relation .
Parent in the laboratory. The rest energy is , while the total relativistic energy is . ConsequentlyIts momentum magnitude is .
Daughters in the zero-momentum frame. The centre-of-momentum frame is initially the parent's rest frame. Conservation of momentum gives . Equal daughter rest masses then imply equal relativistic energies. Conservation of relativistic energy givesTheir speeds are thereforeThe two velocities are opposite, and . Their total kinetic energy is .
Invariant of the complete system. Before the decay, in the centre-of-momentum frame,After the relativistic two-body decay,In the laboratory, four-momentum conservation fixes the summed daughter energy to and their summed momentum to the parent's . Thus the same calculation isThe invariant is formed after summing the daughter four-momenta; adding their separate squared rest energies would omit the relative-motion contribution to the invariant mass of the pair.
Axial moment of inertia. In the original diagram is the outer radius and the inner radius. For uniform mass density , a coaxial annulus of thickness has . Therefore the axial moment of inertia of a hollow cylinder isSince , factorizing the fourth-power difference givesFor a solid cylinder , giving . For a thin cylindrical shell with fixed mass and , . The latter limit agrees with every mass element being at radius .
Undamped rolling oscillations. Let be axle displacement from the spring equilibrium. Rolling without slipping imposes . The sum of translational and rotational kinetic energy isThe potential energy is . Differentiating in the absence of damping, or applying the force and torque equations below, givesFor the thin shell , the effective inertia is , and the angular frequency of the simple harmonic motion isStatic contact friction supplies the required torque but does no work when the contact point is instantaneously stationary.
Damped force balance. Take rightward force as positive and counterclockwise rotation as positive. Write for the signed static friction at the bottom contact. ThenEliminate and use :Here has units , so has units and units . The stated drag force is interpreted as acting through the axle, with no additional viscous torque. An oil bath could also exert such a torque physically, but its magnitude is not specified by this force-only model.
Light damping. Substitution of into the differential equation gives . In the underdamped regime ,Taking real linear combinations gives the general damped harmonic oscillator displacementThe constants are fixed by the initial displacement and velocity. For example, release from rest at gives and . Light damping means , in which case and the envelope decays slowly compared with an oscillation.
Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge 2018 Section D 13 Solution Created 2026-10-18 Updated 2026-10-20
Equation and interpretation. The supplied equation is the time-independent Schrödinger equation for a nonrelativistic particle with mass in a prescribed potential energy . Equivalently,It is an eigenvalue problem for the Hamiltonian operator. A stationary energy state has full wavefunction . By the Born rule, is the probability of finding the particle in a small interval , with wavefunction normalization .
Infinite barriers. Infinite exterior potential energy excludes any finite-energy probability outside the interval. The infinite square well consequently has outside and the hard-wall boundary conditionsThe interior wavefunction must meet the zero exterior amplitude continuously. Its derivative need not be continuous across an infinite wall; imposing both zero value and zero derivative would eliminate every nonzero interior solution.
Ground state. Inside the well , so , with . Its general solution is . The left wall gives , and the right wall gives for . Thus the discrete energy eigenvalues are . The smallest, , is the ground state. Sinceits normalized wavefunction, choosing an irrelevant overall phase to make it positive inside, is
Finite barriers. For a finite step and constant particle mass, both and are continuous at . Wavefunction matching at a finite potential step follows by integrating the Schrödinger equation across a vanishingly small neighborhood of the step: a bounded potential cannot generate a finite jump in . The bound-state exterior solutions decay rather than vanish identically:Normalizability excludes the growing exterior exponentials. The equivalent interior boundary conditions are and ; neither boundary value is zero for the nontrivial ground state.
The ground state of a finite square well remains symmetric about and has no nodes. It bends smoothly into exponential tails at both walls, extending over a larger region than the infinite-well state. Its maximum after normalization is lower for the deep well considered here. When , the penetration length is short, so the two shapes are close except near the walls and in the exterior tails.
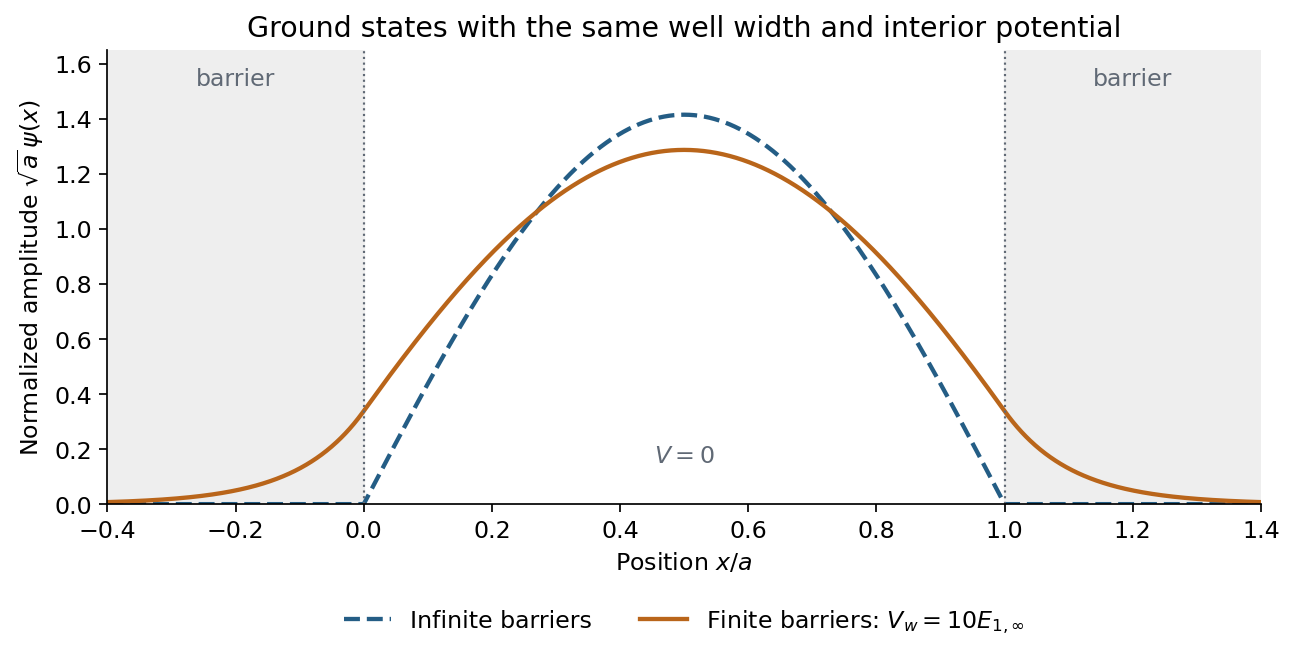
Normalized infinite- and finite-well ground states, with smooth exponentially decaying tails for the finite well
. Details. 
The finite curve is an illustrative exact matched solution with ; no numerical wall height is specified by the question.
Energy comparison. The finite barriers relax the confinement, allowing a less rapidly varying interior wavefunction and therefore smaller kinetic energy. More explicitly, the even interior solution is proportional to , and matching to the tails gives . The lowest root lies at , while the infinite well has . HenceAs , the tails disappear and the finite-well energy approaches the infinite-well value from below. This comparison uses the same zero of potential energy inside both wells.
Field of discrete masses. Newton's law of universal gravitation and superposition give the gravitational field away from the source points:It is the force per unit test mass, with units , and points toward each positive source mass.
Infinite circular cylindrical rod. Let be the radius of the circular cross-section, so , and write for the linear mass density. Choose a coaxial cylindrical Gaussian surface with radius and length . Translation and rotation symmetry make . The end caps have zero field flux because their normals are axial; on the curved surface the outward-normal component is the constant negative value . Gauss's law for gravity therefore givesThe gravitational field of an infinite uniform cylinder inside the material instead has enclosed mass , giving . The exterior result assumes a circular cylindrical rod; area by itself would not specify the exact near field of a noncircular cross-section.
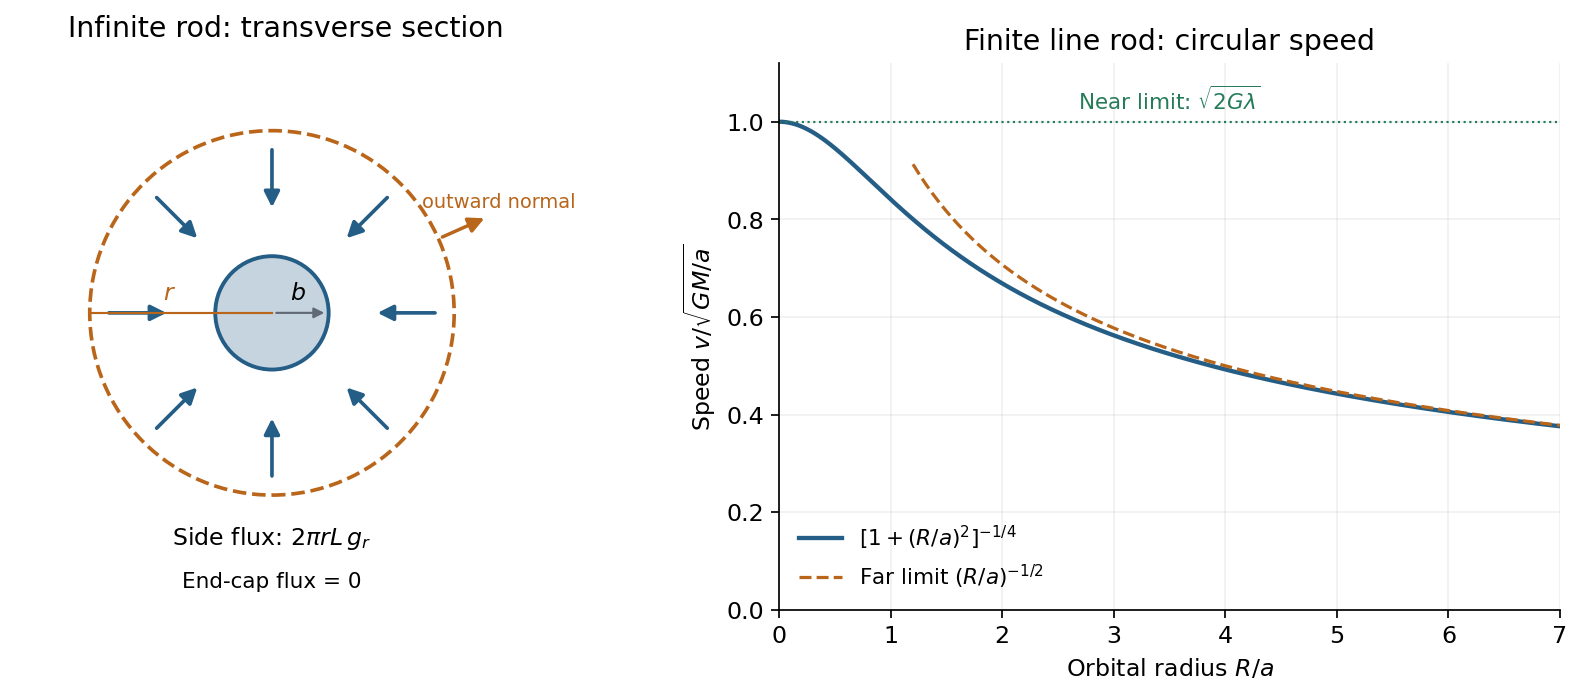
Gaussian-cylinder cross-section for an infinite rod and the circular-speed curve of a finite line rod
. Details. 
In the left panel the dashed circle is a transverse section of the coaxial Gaussian surface; the field points inward and the surface normals outward. Its side area is .
For an exterior circular orbit, Newton's second law equates the force required for centripetal acceleration to gravity:The orbital speed is independent of radius and of the orbiting object's mass, for orbits outside the infinite rod.
Finite rod. Taking the supplied field as the gravitational field of a finite uniform line segment, the corresponding balance at radius isSince , its two limits areThe first reproduces the infinite-rod result: a nearby observer sees a very long source. The second is the familiar circular orbit speed about a point mass, since a distant observer cannot resolve the rod's length. The dimensionless curve isIt starts at a constant plateau and decreases smoothly, approaching an dependence far away. For , , consistent with the sketch.
Derivation of the finite-rod field. Put the source along on the axis. In its central perpendicular plane, an element is at distance . Its field magnitude is , and its inward radial component has the extra factor . The axial components cancel between and . ThusReplacing by givesThe integral treats the source as a line mass. For a finite cylinder of nonzero cross-section, the displayed finite-rod formula is a thin-rod approximation, not an exact field for all . Its near-rod limit should therefore be read as , keeping the orbit outside the material; the apparent line-source singularity at does not describe the interior of a real cylinder.
For a light test particle of mass outside a spherical source of mass , Newton's law of universal gravitation gives . It is a central force, so its torque about the source vanishes and angular momentum is conserved. The motion therefore lies in a fixed plane when . Its gravitational potential energy is , and conservation of mechanical energy givesHere is specific orbital energy and is specific angular momentum. A Kepler orbit has polar equationThe angle is measured from periapsis. The conic section is an ellipse for and , a parabola for and , and a hyperbola for and . The circle is the elliptical case. The special case is radial motion and must be handled as a degenerate limit. Bound ellipses have the source at one focus, which is Kepler's first law.
For a bound orbit of semi-major axis , . Combining this with the energy equation gives the vis-viva equation:The particle therefore moves faster near periapsis and slower near apoapsis. Conservation of angular momentum also gives constant areal velocity, , expressing Kepler's second law. Using the ellipse's area and gives the orbital periodwhich is Kepler's third law.
A circular orbit follows from centripetal acceleration , giving and . The minimum escape velocity from radius follows from the marginally unbound condition :These ideal orbits neglect drag force, other gravitating bodies and changes in the central source. For two comparable masses, the relative two-body problem uses instead of . An orbiting object is continuously in free fall; the inward gravitational force changes its direction even when its speed is constant. These inverse-square results assume the physical variation of gravity with radius, rather than extending a near-surface constant- approximation to an entire orbit.