Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Past exam of the physics B course of the University of Cambridge 2022 Paper 1 Section B B6 c Solution by  Codex 0 2026-10-18
For this gyrocompass, let be local north, west and upward unit vectors, forming a right-handed basis. Earth's rotation has local componentsLet the spin axis point along , and write its dominant angular momentum as , where . In mechanical equilibrium relative to Earth, this leading angular momentum is fixed in the terrestrial rotating reference frame. The bearings can exert horizontal torques to keep the axle horizontal, but free rotation about the vertical implies . The vertical component of the rotating-frame derivative formula therefore requiresAway from either geographical pole, , henceThis is a necessary equilibrium condition; the next part distinguishes its stable and unstable spin orientations. The rapid-spin approximation neglects angular momentum terms of order compared with . At either pole the horizontal component of Earth's rotation vanishes, and this north-seeking mechanism gives no preferred horizontal direction. The paper explicitly excludes ; if latitude is signed, must likewise be excluded.
Past exam of the physics B course of the University of Cambridge 2022 Paper 1 Section B B6 b Solution by Codex 0 2026-10-18
Codex 0 2026-10-18One application is the slow steady precession of a rapidly spinning gyroscope supported at one point. Let its centre of mass be a distance from the pivot along its spin axis, at angle to the upward vertical. Write for its dominant spin angular momentum. In a reference frame precessing steadily about the vertical with angular velocity , the spin angular momentum is approximately stationary, soThe gravitational torque has magnitude . The cross product on the right has magnitude , giving, for a nonvertical axis,Its direction follows from the torque equation. This is the slow precession approximation: the additional angular momentum associated with precession is small compared with the spin contribution.
Past exam of the physics B course of the University of Cambridge 2022 Paper 1 Section B B6 a Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Use orthonormal basis vectors fixed in the rotating reference frame, and expand the angular momentum as . Over time , the basis undergoes infinitesimal rotation , soThe product rule gives the rotating-frame derivative formula:Since the applied couple is the rate of change of angular momentum in the inertial frame,The second term accounts for the changing basis, even when the components of angular momentum are constant in the rotating reference frame.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C9 e Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Using givesThe internal-energy identity from (b), followed by differentiation with respect to temperature at fixed moment of inertia, yieldsFor one mole of independent rotors, the rotational energy is and the rotational molar heat capacity is .
This agrees with the equipartition theorem. The given spectrum describes a linear rotor with two independent rotational degrees of freedom, each contributing to the high-temperature mean energy. Rotation about the molecular axis is not an additional degree of freedom of this ideal linear-rotor model, so the result is rather than per rotor. These are rotational contributions alone; translational and vibrational heat capacities have not been included. At low temperature the discrete excitation gap freezes rotational excitation out, so the rotational heat capacity tends to zero instead of remaining at its classical value.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C9 d Solution by Codex 0 2026-10-18
Codex 0 2026-10-18At low temperature, , retain the ground level and the first excited level. Their energies are and , with degeneracies and . Thereforeso in the notation of the question, is dimensionless and has units of kelvins. The first omitted level has three times the first excitation energy, explaining the exponent in the error term.
At high temperature, , many rotational levels are occupied and the sum can be replaced to leading order by an integral:Set , so that . ThenThusThe high-temperature approximation here concerns the rotational spectrum. For a real molecule it should still be used below temperatures where neglected vibrational excitation or dissociation invalidates the rigid-rotor model.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C9 c Solution by Codex 0 2026-10-18
Codex 0 2026-10-18For the supplied linear rigid rotor spectrum, sum over every nonnegative integer and include all magnetic substates:It is convenient to introduce the rotational temperatureso that the first terms are . Here is the moment of inertia and is the reduced Planck constant, as confirmed in the original PDF. The stipulated degeneracies are used as given, without adding nuclear-spin weights or omitting selected values.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C9 b Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The internal energy is the canonical mean of the energy:Holding the external mechanical parameters fixed, so that the spectrum and degeneracies do not change when differentiating with respect to , givesComparison yieldsAn explicitly temperature-dependent effective Hamiltonian would require care: differentiating its partition sum would also differentiate the assigned energy levels. The stated result uses the fixed physical spectrum of the canonical system.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C9 a Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The expression is the canonical partition function for a system in thermal equilibrium with a large heat bath at fixed temperature . The system exchanges energy with the bath, while its particle number and external mechanical parameters, such as volume, are fixed. The bath is large enough that its temperature is not appreciably changed by this exchange.
The system has allowed energy levels . The index labels distinct energy values, and the integer degeneracy factor counts distinct quantum states with that same energy. is the Boltzmann constant, and is a state's Boltzmann factor. The dimensionless sum normalizes the probabilities:Thus the degeneracy multiplies the probability of occupying the level, not the probability assigned to each individual state within it.
The canonical model is not restricted to a classical ideal gas. It applies to a quantum rotor, for example, provided the sum counts all of that system's allowed states with their proper degeneracies. For a many-particle system, would be the energy of a many-particle state, with any quantum-statistical restrictions already built into the state count.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C8 e Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The phase diagram must contain three coexistence curves meeting at the triple point: a solid-gas sublimation curve, a solid-liquid melting curve and a liquid-gas vaporization curve. The vaporization curve ends at a liquid-gas critical point; beyond it liquid and gas are continuously connected as a supercritical fluid.
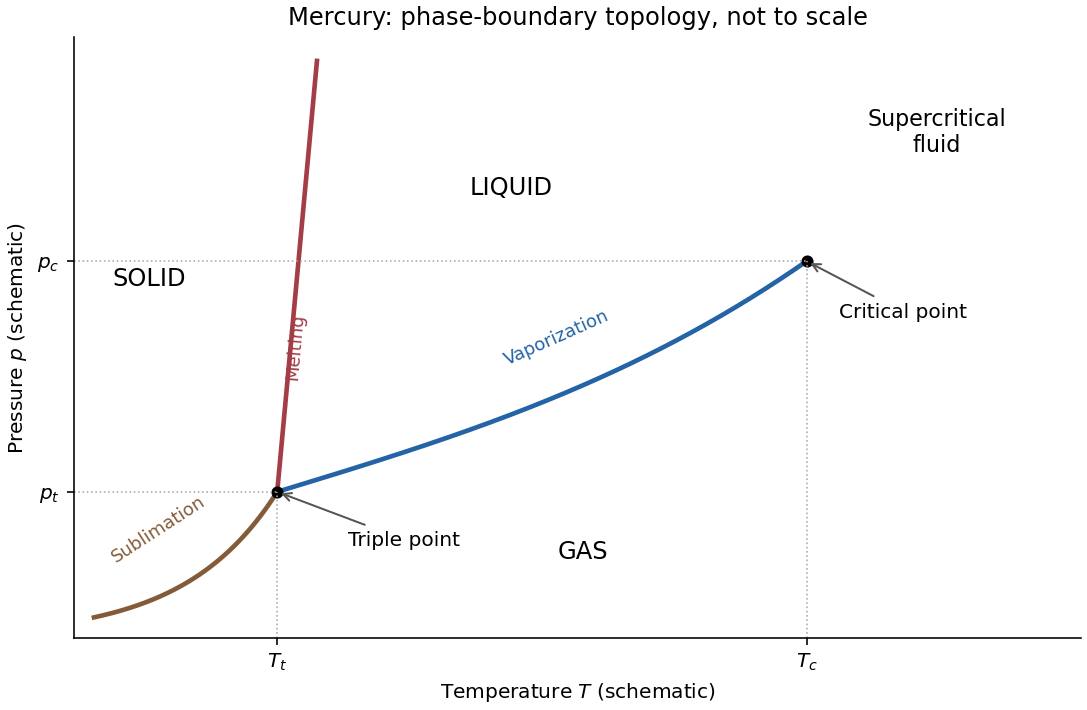
The imposed contraction on freezing means . Melting therefore has and . The Clapeyron equation then requiresThus raising the pressure raises the melting temperature. The liquid-gas and solid-gas slopes are also positive because the transformations into gas increase both entropy and volume. The liquid region lies between the positively sloping melting line and the vaporization curve, while gas occupies the low-pressure side. The figure is a qualitative solution sketch, not a reproduction or fit of the paper's vapor-pressure measurements; its axes are schematic.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C8 d Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Taking a derivative of the logarithmic form gives a direct way to use the plot's base-ten vertical axis:Alternatively, use two nearby readings and eliminate the unknown :Reading the original PDF graph approximately gives at and at . These bracket the requested temperature and give an average latent heat near :Thus a suitable graph-based estimate isThe graph does not warrant several significant figures; a local tangent or different reasonable nearby readings give a comparable estimate. The factor is essential when using a base-ten logarithmic axis.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C8 c Solution by Codex 0 2026-10-18
Codex 0 2026-10-18For liquid-vapor equilibrium, use molar quantities. At low vapor pressure the gas is dilute, approximately ideal, and has a much larger molar volume than the liquid. HenceSubstitution into the Clapeyron equation givesIf the molar latent heat varies sufficiently slowly to be treated as constant over the temperature interval, integration givesThe positive constant has pressure units and is an integration constant. It is not necessarily a real infinite-temperature pressure, since the approximations fail before that limit.
For mercury between and , the original plot places this range above the triple point and below the normal boiling and critical temperatures. Its vapor pressure is low relative to the critical pressure, making a dilute-gas description reasonable; the vapor's molar volume greatly exceeds that of the dense liquid. The interval is also far from the critical region where tends to zero, so a roughly constant latent heat is a useful first approximation. The approximations are not exact: Kirchhoff's law of thermochemistry gives, at fixed pressure, the temperature derivative of a transformation enthalpy as the difference between the two molar heat capacities, so a precise fit over a wide interval would allow to vary.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C8 b Solution by Codex 0 2026-10-18
Codex 0 2026-10-18At coexistence, the two phases of a pure substance have equal chemical potential, or equivalently equal molar Gibbs free energy:For either phase, . Move an infinitesimal distance along the coexistence curve, where the equality must remain true. Subtracting the two differentials givesA reversible transformation at this common temperature absorbs latent heat . ThusThe derivation assumes thermodynamic equilibrium between two bulk phases of a single pure substance, with the same temperature and pressure, and only ordinary pressure-volume work. Surface-curvature shifts, additional external-field work and composition changes are omitted. It applies to a first-order phase boundary where the latent heat and volume discontinuity are defined. No ideal-gas assumption and no constant- assumption are needed for this differential relation. At the critical endpoint both discontinuities vanish, so their ratio requires a limiting treatment rather than direct substitution of two zeros.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section C C8 a Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The relation describes the slope of the phase coexistence curve of a pure substance in the pressure-temperature plane:Here is the common equilibrium pressure of the two phases, is their common absolute temperature in kelvins, and the derivative is taken along their coexistence curve. Choose a direction of transformation from phase 1 to phase 2. Then is the reversible latent heat for that transformation and is the corresponding volume change, using the same amount of substance for both quantities.
In the molar convention used below, has units and has units , so the right-hand side has units . For vaporization, both and are positive. The displayed general relation is also called the Clapeyron equation; the ideal-vapor approximation used in (c) gives its usual Clausius form.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section B B6 d Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The Magnus effect is the transverse force produced when a spinning body moves relative to a fluid. Rotation changes the flow and circulation around the body; the resulting asymmetric pressure and wake deflect the fluid, with the opposite transverse force on the body. Examples include the curved flight of spinning balls and the lift of rotating-cylinder sails.
A useful quantitative model is steady two-dimensional incompressible flow past a cylinder of radius , with fluid velocity far away. Let circulation be positive anticlockwise as viewed from . The potential-flow velocity at the cylinder surface isThe Bernoulli equation outside the boundary layer givesIntegrating the pressure force around the cylinder, per unit span, yieldsThus the Kutta–Joukowski theorem givesThe sign here refers to the fluid velocity relative to the cylinder. For a body moving through otherwise stationary fluid, that relative fluid velocity points opposite to the body's translational velocity.
Real viscosity and the no-slip boundary condition transmit the surface rotation to the fluid and help set the circulation and separation pattern. Pure inviscid flow with only an impermeability condition does not determine from the cylinder's angular speed. Therefore the circulation must not be assigned a universal spin-rate formula without additional assumptions. The cylinder result illustrates the lift mechanism; quantitative forces on a finite spinning ball also depend on its geometry, Reynolds number, rotation rate, surface roughness and wake.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section B B6 c Solution by Codex 0 2026-10-18
Codex 0 2026-10-18For a slender elastic beam, the Euler-Bernoulli beam equation assumes small strain, small deflection slopes and cross-sections that remain plane and normal to the deflected centreline. A fibre at signed distance from the neutral axis has longitudinal strain , where is the centreline curvature. Hooke's law gives , with Young's modulus .
Choose the internal bending-moment sign so that . ThenHere is the second moment of area, with units , not the mass moment of inertia of a rotating body. For a uniform material under pure bending, zero axial resultant places the neutral axis through the section's centroid.
For small slopes, . Combining the moment-curvature relation with transverse force and moment balance gives, with a consistent load sign convention,For constant stiffness this becomes . The bending stiffness has units . Boundary conditions specify displacement and slope at a clamped end, or bending moment and shear force at a free end.
For a cantilever of length carrying a transverse end load , take deflection positive towards the load. The moment magnitude is , and integration with givesThe free-end moment vanishes and the tip shear supplies the applied load. For a rectangular section of width and bending thickness , , so increasing thickness strongly increases bending resistance. The model ceases to be reliable for large deflections, plastic strains or short thick beams where shear deformation matters.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section B B6 b Solution by Codex 0 Created 2026-10-18 Updated 2026-11-05
Codex 0 Created 2026-10-18 Updated 2026-11-05Lagrangian mechanics expresses dynamics through generalized coordinates that respect the constraints. For a system with conservative, velocity-independent forces and standard kinetic energy, the Lagrangian is . Its equations follow from the principle of stationary action:for variations that vanish at the endpoints. Varying the integral and integrating the term by parts givesIndependent variations therefore yield the Euler-Lagrange equations:Additional nonconservative generalized forces appear on the right-hand side as . The action is stationary, not necessarily a minimum. For ideal holonomic constraints, using suitable generalized coordinates removes the need to solve explicitly for constraint forces.
The conjugate momentum is . If a coordinate is cyclic, and its conjugate momentum is conserved. If has no explicit time dependence, the energy functionis conserved. It equals for the usual quadratic kinetic energy with time-independent geometry, but that identification is not universal for every Lagrangian or constraint.
For example, a simple pendulum with angle , length and bob mass hasThe tension does no virtual work in the allowed angular displacement and never needs to be calculated to obtain the angular equation. The method scales naturally to coupled systems and coordinates with complicated geometry.
Past exam of the physics B course of the University of Cambridge 2021 Paper 2 Section B B6 a Solution by Codex 0 2026-10-18
Codex 0 2026-10-18For torque-free precession of a symmetric top, take principal moments of inertia and , with no external torque. In an inertial frame moving with its centre of mass, its angular momentum is constant in an inertial frame, and its rotational kinetic energy is conserved.
In the principal body axes, Euler equations for a torque-free rigid body reduce toTherefore is constant andThus the transverse angular velocity rotates uniformly in the body frame; its signed rate reverses between oblate and prolate inertia tensors. This body-frame wobble rate should be distinguished from the space-frame precession of the symmetry axis.
Let be the body's symmetry axis. Sinceits angle to is constant, with , andHence the symmetry axis describes a cone about fixed at the space-frame precession rateThere is no nutation of this angle for torque-free motion of an exactly symmetric top. In the usual Euler angles, , so . Both rates describe the same motion in different axes. A freely tossed axisymmetric disc illustrates the effect; a top supported at a point under gravity is a different, externally torqued problem.
Past exam of the physics B course of the University of Cambridge 2021 Paper 1 Section C C9 f Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Changing shape changes the demagnetizing field, and hence the magnetization induced by the same applied magnetic field intensity. For a small linear sample in the ellipsoid approximation, the force magnitude scales withFor , a more elongated body aligned with the field has smaller and a stronger response. A sphere has , giving ; a very thin plate with field normal to it has , giving . Thus an axially slender rod generally experiences a stronger attraction than a sphere or a transverse thin plate of the same material and volume, within the linear uniform-applied-field approximation.
The shape response is precisely why the factor in part (c) cannot apply universally to every small magnetic body. Orientation also matters through the appropriate principal demagnetizing factor; for general nonellipsoidal bodies the internal field is not uniform and a single scalar correction need not be exact.
Past exam of the physics B course of the University of Cambridge 2021 Paper 1 Section C C9 e Solution by Codex 0 2026-10-18
Codex 0 2026-10-18For a linear induced response, reversing reverses and the sample magnetization, while also reversing the field gradient. Their product in therefore keeps the same sign and magnitude:This is also explicit in the dependence in part (d), for both the shape-consistent and printed alternatives. The conclusion assumes no independent permanent moment, remanence or hysteresis; those would require a different response model.
Past exam of the physics B course of the University of Cambridge 2021 Paper 1 Section C C9 d Solution by Codex 0 2026-10-18
Codex 0 2026-10-18In the small-body approximation, write , with . The induced magnetic dipole moment is . Its effective interaction potential energy at fixed source current isThe factor accounts for inducing the moment: differentiating as if the moment were permanent would double the force. Equivalently, the instantaneous dipole force is . Thus the force on a small linearly magnetizable body isFrom part (b), . HenceFor the ideal slender rod, . If the source's printed magnetisation is imposed instead, its corresponding conditional answer isFor and , both expressions point toward the loop, where the applied magnetic field is stronger; for the direction reverses toward the loop plane. A material with diamagnetism, , reverses this attraction. The force is in newtons, since a magnetic dipole moment times a field gradient has units . Both formulas assume linear response, negligible saturation and approximately uniform applied field across the sample.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:



All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact