
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 78 2 Solution Created 2026-10-03 Updated 2026-10-14
For body-force-free Stokes fields with the same viscosity,To prove this Lorentz reciprocal theorem, integrate the divergence of the difference of the two cross-work fluxes. Both stress divergences are zero; incompressibility and symmetry of the Newtonian stress reduce each cross-gradient contraction to . These are equal, so the divergence integrates to zero. The argument applies to an exterior domain by first cutting it off and taking the outer radius to infinity; the decaying velocity and stress make the outer boundary contribution vanish.
Define the generalized force as force and torque exerted by the rigid body on the fluid. With a resting far field and no-slip boundary conditions, on the body, and linearity givesFor two such motions the reciprocal theorem becomesSince the six-component velocities can be chosen independently, . The ordinary work identity givesfor every nonzero rigid-body motion. If the integral were zero, would make the connected exterior flow an infinitesimal rigid motion. Its decay at infinity requires that motion to be zero, which is incompatible with a nonzero no-slip body velocity. Thus is positive definite. Fluid-on-body forces have the opposite sign; their map is , not a positive-definite resistance matrix.
Write and . The helix has , soIts unit tangent is , where . The given slender-body force density is the force per arc length exerted on the fluid. For pure axial translation, , it givesFor pure rotation, , it givesThe axial torque per unit arc length is . Integrating along the wire gives the axial resistance matrix of a slender helixThus translation gives , and rotation gives . These are the requested axial components; the axial swimmer approximation does not require proving statements about the other components. The equality of the two off-diagonal coefficients checks reciprocity, andFor the organism, retain the specified entrainment approximation: the head moves with the local large-scale fluid translation, and its angular velocity differs from the local fluid rotation by . Put . Its torque on the fluid is therefore , and its force is neglected. Neutral buoyancy and absence of external torque giveSolving,This is the entrained-head approximation for a helical microswimmer, which differs from treating the head as an isolated sphere in otherwise stationary fluid. The flagellum's angular speed is also .
At fixed , the speed is maximal at and tends to zero at either limiting pitch. At fixed other parameters it decreases as : the longer flagellum has more resistance at the fixed torque supplied in this model. Holding the number of turns fixed instead would make change with pitch, so that is a different comparison.
The motor exerts equal and opposite torques of magnitude on flagellum and head, whose relative angular speed is . Therefore its rate of working isEquivalently, the work delivered to the fluid is . Translation contributes no net work because the total force vanishes. This explains the independence from and , without assigning an isolated-fluid drag law to the entrained head.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 78 1 a Created 2026-10-03 Updated 2026-10-14
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 77 3 Solution Created 2026-10-03 Updated 2026-10-14
Choose a fixed vertical datum so the physical free surface is at , with constant; its depth above the bottom is . The gradient of the constant datum does not enter the pressure force. With , the rotating shallow water equations areThe fluid is hydrostatic with depth-independent horizontal velocity at this order. The pressure-gradient force uses the free-surface slope, not the layer-depth slope: .
Let be relative vertical vorticity, the absolute vorticity, and . Taking the horizontal curl of the two momentum equations and expanding the advective derivatives givesMass conservation is . The two stretching factors cancel, proving the exact shallow-water potential vorticity conservation lawThe denominator is , the actual column thickness that changes under horizontal convergence; an arbitrary surface elevation does not obey that column mass equation. There is no term because the reduced layer quantities have no vertical dependence. The vertical motion has already supplied the layer-thickness equation, rather than remaining an independent coordinate of this model.
Now take and assume , . To first order,For a small Rossby number, leading geostrophic flow satisfies and . ThusFor , the barotropic deformation radius is . Multiplication of the first-order PV by givesThis is the required shallow-water quasi-geostrophic potential vorticity, including the bottom contribution.
Write and . The initial state has , so . The specified homogenization sets in and leaves it unchanged outside. Hence the requested change isFor this is a descending straight segment from to , with zero exterior values and jumps at the two edges. Endpoint values do not affect the inversion. It is the anomaly, not the full final PV profile, that appears as the source below.
For the zonal mean, , , and potential-vorticity inversion requireswith decaying disturbance at both infinities. The odd source makes the unique decaying solution odd. A particular interior solution is , so writeBoth and must be continuous at : a jump would introduce a delta function or its derivative into a source that has only finite jumps. Matching at givesand thereforeDifferentiate the interior streamfunction to obtainThe exterior profiles needed for the sketches are and .
For , put , , so . Uniform Taylor expansion givesConsequentlyFor the leading interior current is westward and approximately parabolic.
For and away from the edges, and : the surface follows the bottom slope centrally. Near , the exponentially thin corrections give positive edge jets of width and peak scale when . Those jets decay in the exterior. The elevation is odd, has opposite-sign extrema just inside the edges, and decays to zero outside; at the positive edge . The following sketch uses the full matched solution with . For negative , the current and PV-change signs reverse, while this elevation profile does not.
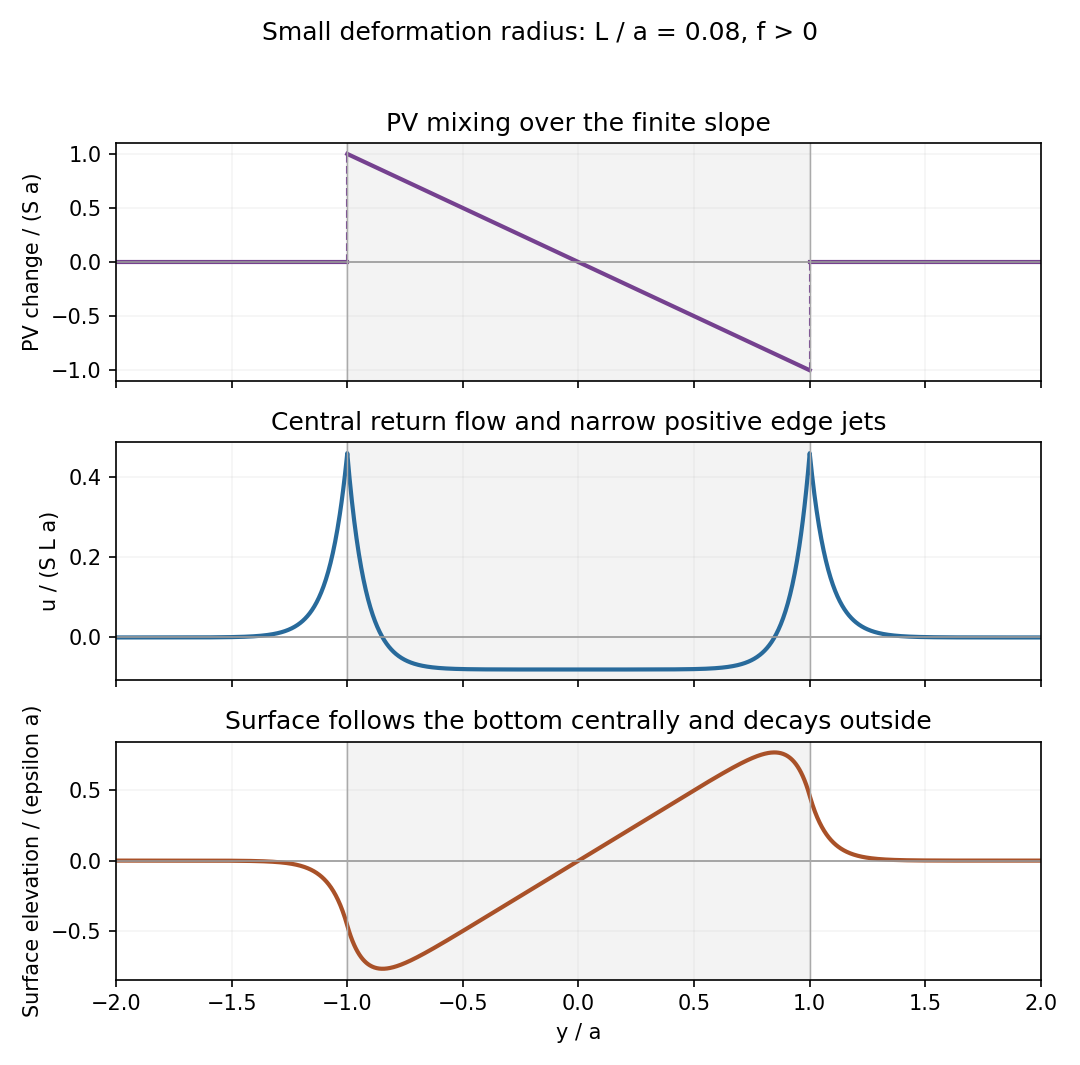
Potential-vorticity change, central current with edge jets, and free-surface elevation after mixing over a finite bottom slope
. Details. Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 77 2 Solution Created 2026-10-03 Updated 2026-10-14
Here write for the buoyancy perturbation about the resting constant- stratification; the total buoyancy also includes its background gradient . Use kinematic perturbation pressure . The weak-forcing Linearized Boussinesq equations areWeakness means that perturbation advection is small compared with the retained linear terms. With the specified streamfunction convention, the transverse vorticity isDifferentiate the horizontal momentum equation in and subtract the derivative of vertical momentum. The pressure derivatives cancel, givingThe second equation uses and is the forced internal-wave equation.
For free waves at frequency , the internal gravity wave dispersion relation gives . Thus the horizontal response scale is much larger than the vertical scale. Vertical acceleration is small in the vertical momentum equation, leaving the hydrostatic approximation . Correspondingly the transverse vorticity is predominantly : neglect relative to in the inertial vorticity term. The restoring term must still be retained, since it balances the small time derivatives.
For put , and interpret physical fields as real parts. The reduced equation isOne can solve it while obtaining the buoyancy simultaneously. Define and . The first-order hydrostatic equations becomeHence and obeyApply the method of characteristics with zero fields in the past. Withthe solution is . Consequently the hydrostatic response to a localized horizontal force isThese are exactly the required two characteristic integrals, derived with their relative sign fixed by the buoyancy equation. Quiet-past initial conditions exclude additional freely propagating solutions.
For the consistency check, set , so both integrals run over the fixed range . Differentiation at fixed now givesThis change of variable is important: it includes the time dependence of both the sampled forcing and the moving integration geometry without omitting a term. Each straight path intersects for a time interval of length at most . If , thenThe characteristic size of the hydrostatic buoyancy and pressure-gradient balance is , as follows from the analogous bound on in its integral formula. Thus the omitted acceleration has relative scale at most a constant timesTogether with the low-frequency assumption, this verifies the requested hydrostatic consistency. It is a comparison of characteristic magnitudes, rather than division by a buoyancy value at a node where both terms may vanish. The capital here is the buoyancy frequency, as printed in the PDF.
For , only contributes. If , every point lies outside the source interval, so both integrals vanish:This finite propagation cone belongs to the reduced hydrostatic wave equation.
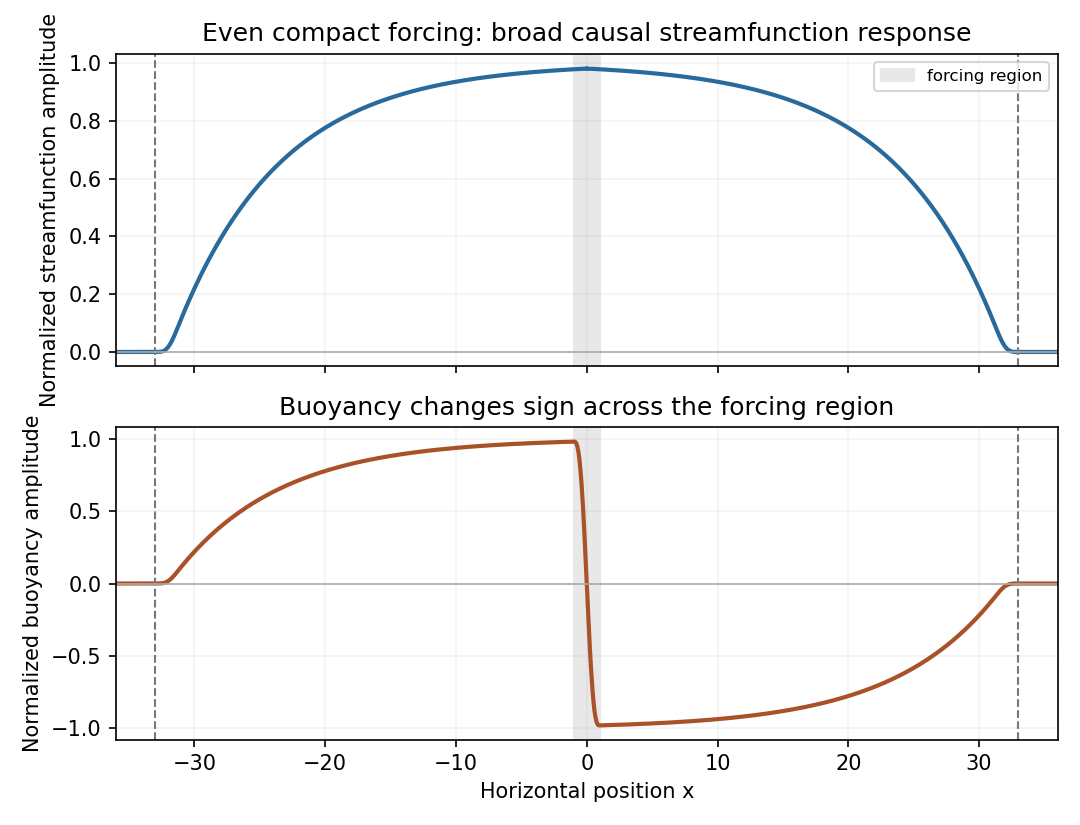
The hypotheses do not require an even forcing, so no single symmetric graph follows for every permitted . For an illustrative smooth even nonnegative profile, is even and is odd. At late time and fixed , if , thenThus the streamfunction develops a broad nearly level interior response with outgoing fronts, while the buoyancy changes sign across the source and approaches opposite interior plateaus to its left and right. Both vanish beyond the fronts. For , a vertical phase with gives real fields and . The figure plots those profiles up to positive normalization factors, for an even compact forcing increasing slowly from zero.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 77 1 Solution Created 2026-10-03 Updated 2026-10-14
Let be a constant reference density and define total buoyancy acceleration by . Absorb the reference hydrostatic pressure into a kinematic pressure . The ideal nonrotating Boussinesq equations areFor a resting density profile , the background satisfies and the squared buoyancy frequency isStable stratification has . The Boussinesq approximation requires fractional density variations to be small over the domain and parcel excursions, so density can be replaced by in inertia while its small variation is retained in the gravitational force. For an approximately uniform density gradient over height , this requires . The stipulated incompressibility alone does not justify neglecting density variation in inertia.
Put and . To linear order the two-dimensional internal gravity wave equations areThe exact impermeability condition on is the kinematic boundary conditionTaylor expansion about permits at leading order if the boundary slope and its displacement relative to the vertical wave scale are small: and . The second condition controls both the omitted evaluation correction and the product , since continuity gives . Hence for the harmonic forcing,The propagating calculation assumes and ; a time-independent boundary does no oscillatory work on fluid initially at rest. If but , incompressibility forces the vertical velocity to be independent of height, so the unbounded column has no finite-energy radiating internal-wave solution. The propagating wave-generation problem therefore needs the stated nonzero horizontal wavenumber.
For a plane mode with phase , let be its complex amplitudes. The linear equations giveSubstituting into gives the dispersion relationNo waves enter from above. The appropriate radiation condition therefore selects upward vertical group velocity, not upward phase propagation:The boundary-forced internal gravity wave satisfying the boundary condition isThe displacement is , consistent with times the displacement. For a right-moving boundary choose , without loss of generality. Then , and the constant-phase lines of an internal gravity wave have slope : the crests rise toward the right. Their acute angle with the horizontal isThe group velocity is along these crests in the upward-right direction, whereas the wavevector and phase propagation point downward-right.
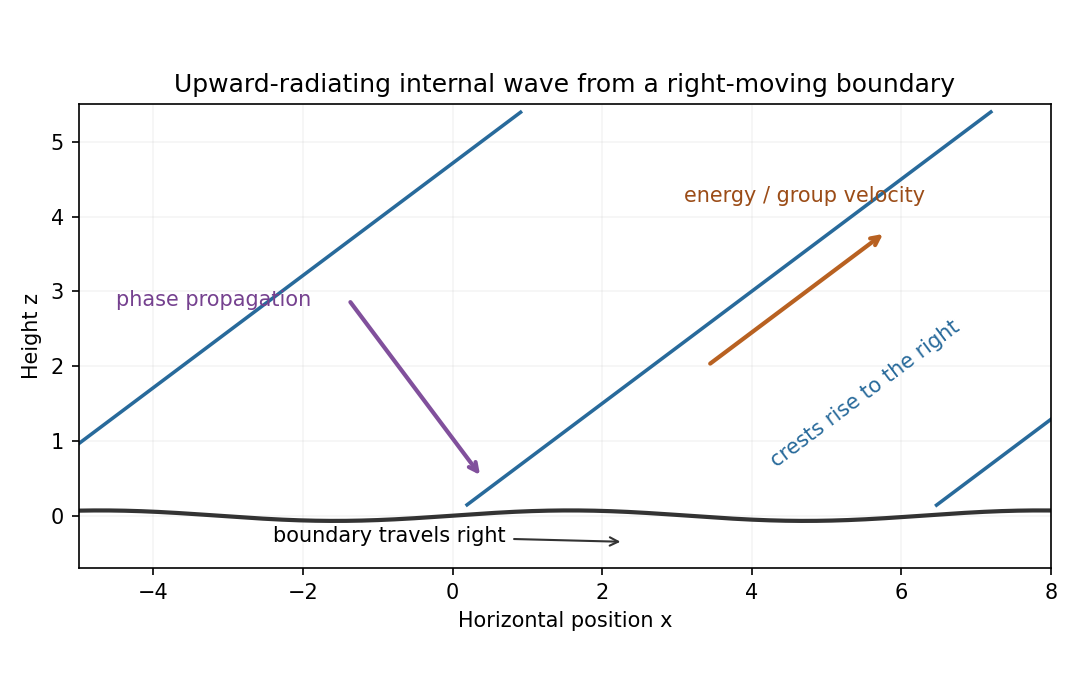
Rising wave crests with upward group velocity and downward phase propagation above a right-moving boundary
. Details. The physical pressure perturbation is . Pressure work at the lower boundary, to second order in amplitude, is its period-mean pressure times vertical boundary velocity. Static hydrostatic terms average to zero over a cycle. ThereforeAs an independent energy check, the wave's mean kinetic-plus-buoyancy energy density is , and multiplication by gives exactly this upward energy flux.
For the exact horizontal mean-momentum equation, incompressibility writes the horizontal momentum equation asAverage over a horizontal period. Require the pressure and velocity fluxes to be periodic, or more generally their horizontal derivative averages to vanish; in particular there must be no imposed mean pressure gradient. ThenHorizontal averaging also makes ; the zero mean boundary displacement rate gives . These conditions exclude an independent mean mass flux or horizontal force. The mean equation applies in the fluid, with flattening of the small moving boundary understood at the order used above.
For slow switch-on, define , using for . The outgoing internal-wave envelope radiation condition is . Replace in the oscillatory fields by . A modulation time must satisfy and , with a frequency bandwidth sufficiently narrow to linearize the dispersion relation. The exact boundary derivative also contains ; it is smaller by the slow-modulation parameter and is beyond this leading envelope approximation.
To leading slow-modulation order, the wave momentum flux isSince , integrating the mean-momentum equation from rest gives the internal-wave momentum depositionThis is second order in wave amplitude, with smaller relative slow-modulation corrections. Mean-flow feedback on the leading wave is higher order. The mean current is created as the wave envelope arrives; an already uniform wavetrain has no local flux divergence.
Finally move horizontally with speed . The initial uniform relative flow is , with infinite total energy in the unbounded column. Its finite mean-energy change is insteadAt finite time the envelope is absent sufficiently far above, so integrating the momentum equation givesThis is the boundary work and mean-flow energy of an internal wave relation. In the moving frame the boundary pattern is stationary to leading modulation order. It extracts energy from the incident mean flow and converts it to outgoing internal-wave energy; in the laboratory frame the same energy is supplied as boundary work.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 76 6 Solution Created 2026-10-03 Updated 2026-10-14
In infinitesimal elasticity and plasticity in continuum mechanics, decompose the symmetric strain as . For incompressible isotropic elasticity, , with the shear modulus and both strains traceless. The associated flow rule for the Von Mises yield criterion has after absorbing a positive factor into . Plane strain has , soIf initially, it remains zero by this homogeneous scalar differential equation. Then and , so is consistent with zero initial plastic component. This proves consistency, not a claim that arbitrary prestressed plane-strain histories must have zero separate components. The out-of-plane shear components can consistently be zero by the same argument.
Write , so . The proposed in-plane parameterization hasIts squared contraction is , proving the yield condition identically. Its principal deviatoric stresses are . Define the two slip line families by tangent unit vectorsThus lines have tangent angle and lines have tangent angle . Their normal extensions from the associated plastic strain rate vanish, while their shear stresses have maximum magnitude ; they are not the principal stress directions.
In the absence of body force, differentiate the stress parameterization in the two equilibrium equations. One obtainsThe symmetric matrix multiplying has eigenvectors with eigenvalues . Taking its contraction with these vectors provesHence the Hencky stress relations areConstants can differ between lines, and these signs depend on the specified negative shear-stress convention.
Place the notch tip at the origin, with the opening towards negative and tensile loading in the transverse direction. For a usual reentrant notch, . The upper face has tangent angle . Choose its tangent directed away from the tip and outward material normal pointing into the notch. Direct rotation of the stress gives the normal and tangential traction componentsTake the notch faces traction-free, as intended by the notch problem. Then the cosine vanishes. Select the tensile branch , for which the face-tangential normal stress is . Thus the upper face has . Choosing the opposite branch would describe compression rather than the tensile field.
Construct the centred slip-line fan at a traction-free V-notch to connect this surface state to the forward symmetry axis. Near the upper face there is a constant-stress region. It joins a fan bounded by raysInside the fan choose lines radial and lines circular about the tip, so their angle parameter is . Along a circular line the first invariant givesThe second invariant is automatically constant along each radial line because are independent of radius. Thus this is an actual equilibrium fan, not just an assumed transport of a surface value. At it matches the free-face constant state. At it matches a forward constant-stress region withReflect the upper field across the symmetry axis to obtain the lower field. The forward region has zero shear, respects this symmetry, and contains the positive axis. There , and henceThis value holds in the fully plastic notch-tip region described by the field. It is not a uniform stress assertion for the entire axis of an arbitrary finite specimen, including any elastic or far-field region.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 76 5 Solution Created 2026-10-03 Updated 2026-10-14
Differentiate the pulled-back Kirchhoff stress tensor , using the velocity gradient convention :Thus the lower-convected stress pull-back givesFor an explicit objective time derivative check, superpose , with and skew. Then and , whereasThe additional terms in are . They cancel the extra material-derivative terms, proving . The translation has no effect on a stress or velocity gradient.
For the incompressible Oldroyd-A model, avoid using the same symbol for a stress tensor and its relaxation time by referring to below only as the scalar relaxation time. Define . The constitutive equation becomesBy the pull-back identity, satisfiesAn integrating factor givesPush forward by and . For a convergent, fading remote-past history with the transported homogeneous term tending to zero as , this proves the fading-memory representation of the Oldroyd-A model:For arbitrary finite-time initial data retain . Thus the printed integral-only expression incorporates an initial-memory condition; it is not an unconditional replacement for all initial-value solutions.
For time-dependent simple shear,Put . The relative deformation is , so the entire transported integrand simplifies toConsequently the explicit nonpressure stresses areSymmetry gives , and the unshown third-direction nonpressure components vanish. The superscript here labels the paper's nonpressure constitutive stress; it need not have zero trace. Subtracting supplies the total Cauchy stress tensor.
For constant shear rate , use and the integrals and . This gives the steady simple shear of an Oldroyd-A fluid resultand thereforeThe incompressibility pressure cancels from this normal-stress difference. With the usual , it is nonnegative, while the second normal-stress difference equals its negative.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 76 4 Solution Created 2026-10-03 Updated 2026-10-14
For fixed nominal boundary tractions and dead body forces, use the total potentialThe dead-load terms are linear in the deformation map. Let be a constraint-preserving perturbation path through equilibrium, with and . Differentiating twice gives and . Equilibrium has nominal stress tensor . Its virtual-work relation, applied to , gives the otherwise remaining first-derivative contribution . Therefore the constrained second variation isFor a time-dependent linearized perturbation , the incremental reaction stress contains , but its power vanishes because . Multiply the incremental momentum equation by , integrate by parts, and use zero incremental dead-load traction or the prescribed displacement condition. One obtainsPositive is therefore the standard constrained second-variation stability in elasticity criterion: perturbations cannot grow in this quadratic energy norm. A statement in a specified displacement norm also uses the usual coercivity and boundary conditions removing uncontrolled rigid-motion modes; translations with are not tested by the displayed condition. This is a small-perturbation energy argument, not a claim of global nonlinear stability.
For the cube use incompressibility in the form . A neo-Hookean solid has , and hence the spatial-index-first transpose of nominal stress is . On the diagonal family, equality to givesThe first relation immediately gives . Eliminating and factoring yieldsThus .
Let and . Its derivative vanishes only at , where and . Also at both ends of . Therefore has two distinct positive roots for , one repeated root at , and none below. There is an exception to the printed assertion that both roots differ from one: at , one root is exactly . Indeed, with , the equation becomes , so the only other positive stretch is .
Evaluate the stability form directly on the prescribed uniform perturbationIt satisfies . The determinant Hessian identity isMeanwhile . For the unit reference cube,On the trivial branch, andThus the undeformed state is stable in this perturbation family for , unstable for , and quadratically neutral at .
On a nontrivial branch, substitute and put :The smaller root always has , hence , and is stable. For , the larger root lies between and one, so and it is unstable; the trivial branch is the second stable equilibrium. For , the larger root lies above one and has , so it is stable; the trivial branch is now unstable. Whenever there are three distinct equilibria in this family, precisely two are stable and one unstable against the specified uniform perturbations. This does not establish stability to every nonuniform or symmetry-breaking perturbation.
The homogeneous tensile bifurcation of a neo-Hookean cube has a nontrivial-branch fold at and a meeting with the undeformed branch at . The latter is the bifurcation from the undeformed state. Stating both values distinguishes this branch intersection from the earlier creation of the two nontrivial solutions.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 76 3 Solution Created 2026-10-03 Updated 2026-10-14
Use reference cylindrical coordinates and current coordinates . The prescribed map has , and . In the corresponding orthonormal cylindrical bases, differentiate physical line elements to obtain the deformation gradientThe radial direction is an eigenvector of the right Cauchy-Green deformation tensor with eigenvalue . Its other block isIts trace is and its determinant is . Thus its eigenvalues solve . The principal stretches are the positive square roots of these eigenvalues:Their product is one, independently checking incompressibility.
The strain energy density is per reference volume, so stored energy per initial cylinder height is . The end rotation is and the current height is , giving applied power per initial height . For quasistatic reversible loading, equate this with for independent changes of . This proves the torque and axial force of a twisted incompressible cylinder formulasIn the second derivative hold , the twist per initial length, fixed. Holding twist per current length instead would mix the generalized forces.
For the Mooney-Rivlin solid, compute invariants directly from rather than differentiating individual eigenvalue square roots:The second identity follows from when . Retain the paper's minus sign on its term. Integrating and givesConsequentlyAs checks, untwisted unit stretch gives , and setting recovers the neo-Hookean solid formulas. A convention with a positive second-invariant coefficient corresponds to replacing this by its negative.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 76 2 Solution Created 2026-10-03 Updated 2026-10-14
Take any fixed material subvolume of the reference configuration, with outward normal vector , current particle velocity , and positive temperature . The first law of thermodynamics, including kinetic energy, isThe heat-flux sign is negative because is outward. The Second law of thermodynamics supplies the corresponding integral Lagrangian entropy inequality:The temperature in each supply or flux term is the local temperature, not a common temperature pulled outside the integrals.
Apply the divergence theorem and use the reference momentum conservation equation . In the total-energy equation, the kinetic derivative cancels the body-force work and the term. Since , the remaining local Lagrangian internal energy balance and Lagrangian entropy inequality areThey hold pointwise because was arbitrary. In particular,
The specific Helmholtz free energy is . Substitution yields its balanceand elimination of the heat supply yields the Clausius-Duhem inequalityFor , expand the derivative to obtainThe usual Coleman-Noll procedure admits independent reversible choices of and at a fixed state. Their coefficients must vanish, since either sign and arbitrary magnitude would otherwise violate the inequality. ThusInternal-variable evolution and heat conduction must satisfy this remaining inequality. Substituting the constitutive relations back into the energy balance givesThe last printed equation is missing a factor on its internal-variable term. The PDF defines with per unit mass, so the expression above is the dimensionally consistent consequence. Equivalently define the volumetric thermodynamic force conjugate to an internal variable ; the term is then with no extra density. The two conventions must not be mixed.
For thermoelasticity with a temperature-dependent constraint, admissible rates obeyThe reversible coefficient functional need now vanish only on this tangent hyperplane. Hence it can be a scalar multiple of the constraint normal:ThereforeThe reaction terms cancel on admissible rates, leaving the same internal-variable/conduction inequality and entropy heating equation. The multiplier is determined by equilibrium and boundary conditions rather than by the free energy alone.
For linear thermoelasticity with prescribed thermal volume, write , , and . Hold the internal variables fixed in this reversible linearization, and evaluate all derivatives below at and zero reaction. The stress-free reference state has . Since there, first-order nominal and Cauchy stress tensors agree. Their constitutive laws becomewhere equality of mixed free-energy derivatives givesThe linearized constraint is . Thus volume is thermally prescribed; strict temperature-independent incompressibility corresponds to . The coefficient is an entropy slope; the corresponding volumetric heat capacity at fixed deformation is .
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 76 1 Solution Created 2026-10-03 Updated 2026-10-14
Let be an invertible, orientation-preserving deformation gradient, with . To prove Nanson's formula, take two reference surface tangent vectors . Their current images are , and their oriented area vectors are proportional to and . For every vector , the scalar triple product givesThus , andThis proof also identifies the area transformation as the cofactor of , rather than a transformation by itself.
Use the paper's material-index-first nominal stress tensor . Equality of force on the same material surface in its two configurations gives . Substitute the area transformation to obtainHere is the Kirchhoff stress tensor. With symmetric Cauchy stress tensor, the matrix forms are and . This is the transpose of the first Piola-Kirchhoff stress tensor; keeping the index convention prevents a spurious transpose later.
For the velocity gradient , let be the rate-of-strain tensor. Then the reference-volume mechanical power isThe last step uses stress symmetry, as supplied by angular-momentum balance in an ordinary continuum without couple stresses: a symmetric tensor has zero contraction with the skew part of .
By work-conjugate stress and strain, a pair must satisfy for every deformation rate, with both sides measured per reference volume. For the Green-Lagrange strain tensor, set and calculateCyclically rearranging the contraction shows . Hence the symmetric conjugate isthe second Piola-Kirchhoff stress tensor.
The inverse right Cauchy-Green strain is , because . Differentiating givesConsequently , andThe two stress measures have a geometric interpretation in the convected coordinate net. Its basis vectors are and its reciprocal basis is . The entries of are the contravariant components in , whereas are the covariant components, equivalently . They describe the same spatial Kirchhoff stress tensor in a deforming, generally nonorthonormal coordinate net.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 75 3 Solution Created 2026-10-03 Updated 2026-10-14
Use the quasisteady lubrication approximation for the premelting film between the disk and the underlying ice. The ice is anchored to the lower plane; new ice formed from water supplied through this upper film raises the disk. Let be its upward separation rate, the premelted thickness, the liquid dynamic viscosity, a common ice/water mass density, the specific latent heat of fusion, and the absolute bulk melting temperature. As usual in this leading model, neglect the ice–water density difference, pressure-dependent changes in due to a common phase pressure, inertia and edge corrections. The imposed thermal field is taken as maintained by an external heat supply/removal system, so no additional heat-conduction bottleneck is introduced.
Write , and . The Clapeyron pressure relation for equal-density phases makes the pressure difference across the solid–liquid interfaceThis thermomolecular pressure is the repulsive stress transmitted through the film. To calculate a definite rate one also needs a film-thickness constitutive law. In the standard nonretarded dispersion-force model, define as the magnitude of the repulsive effective Hamaker constant, with its sign convention specified byHere is disjoining pressure, not the permeability used in the preceding question. The sign of an effective Hamaker coefficient depends on the three materials; the positive parameter here denotes an interaction that stabilizes a premelted film. The problem does not specify numerically, so it must remain a defined material parameter.
Take the reservoir pressure at the rim to be . With no-slip boundary conditions on both sides of the thin film, the radial volume flux per unit width isA disk moving upward at rate needs water volume per unit time to freeze below radius . Regularity on the axis and mass conservation therefore give , or . ThusDefine , so . Integrating inward from givesWater is drawn inward by a pressure deficit; its viscous resistance reduces the load that the thermal force can support. The net normal stress on the disk is . Let be the downward apparent load after subtracting ordinary buoyancy. For an ideal thin disk with negligible buoyant volume, , where is gravitational acceleration. If a finite displaced volume is known, use its submerged weight instead; the stated mass and radius alone do not determine that volume.
The disk force balance isConsequently the premelted-film lifting of a disk rate isFor this gives the requested expression in terms of the mass. Every additional symbol in this formula has been defined above. The growing-ice lifting branch exists only when the bracket is positive.
At the threshold the required water flux and viscous pressure deficit vanish. The maximum load supportable at the specified radial thermal profile is thereforeThe factor is the area average of the parabolic undercooling, not an arbitrary geometrical correction. At equality the lift rate is zero; strictly positive lift requires . There is no radius-only, temperature-independent maximum load in this ideal model: one must specify the imposed undercooling or a physically admissible range of it.
For a fixed positive load define and . The lifting branch isIt begins at zero, increases with , and is concave downward because . Below threshold no positive steady heave is possible: the thermomolecular force is too weak to support the load. The mathematical continuation to negative is not a prediction of upward ice-driven separation there.
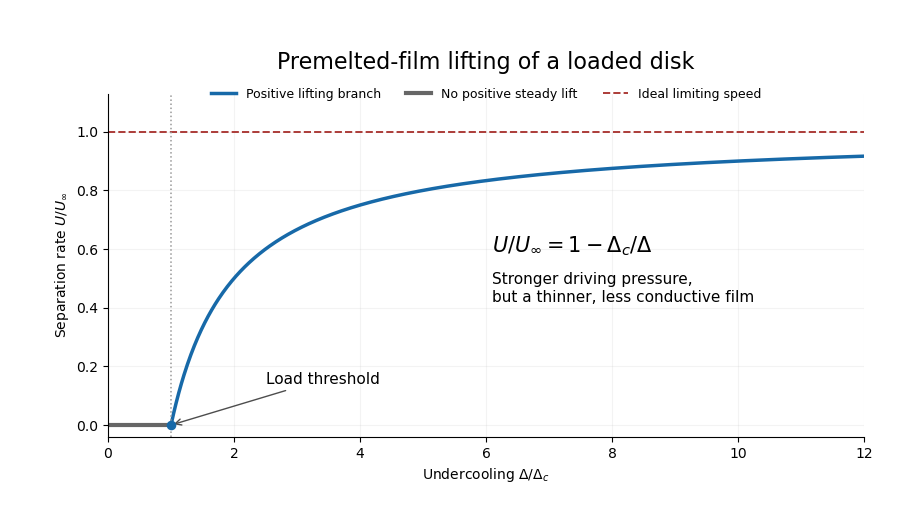


Increasing undercooling increases the available thermal pressure, but it also thins the premelting film. In the inverse-cube disjoining pressure model, , so the hydraulic conductance decreases in exact inverse proportion to the driving scale. The remaining load correction tends to zero and the rate approaches a plateau:For positive load this is approached from below, not attained at finite undercooling. With zero load the reduced model gives the same constant rate wherever its thin-film assumptions hold.
Two limits of the calculation are worth making explicit. First, the formal diverges at the warm rim, so a narrow outer connection to bulk water replaces the thin-film solution there; this leading model assumes that its contribution to the integrals is negligible. Second, very large undercooling produces a molecularly thin film and eventually invalidates continuum lubrication theory and the simple dispersion-force law. Thus the plateau is the maximum within the stated ideal constitutive model, not an unrestricted extrapolation for real water.
If a different molecular interaction is intended, the result is not universal. For any supplied equilibrium in the equal-density model the direct force calculation instead givesThis displays exactly where the film law enters. The closed formula and plateau above use the conventional repulsive inverse-cube law; premelting alone, without that material law, would not determine a unique rate curve.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 75 2 Solution Created 2026-10-03 Updated 2026-10-14
Work in the frame of the steadily advancing mush, so the rigid primary-crystal skeleton moves with . Let be solid fraction, the pore-liquid concentration, the Darcy flux relative to that skeleton, and the common thermal conductivity. Set , the thermal diffusivity. The actual pore velocity is . Primary crystals are taken to exclude solute; the residual pore liquid freezes into a two-solid eutectic product at the bottom. These are the standard binary mushy layer assumptions implicit in using a single liquidus and an eutectic floor.
It is convenient to use hydraulic pressure , absorbing the constant-density gravitational term. With equal phase properties, no solute diffusion, negligible fluid inertia and local liquidus equilibrium, a complete mush model isThe last equation follows from conservation of energy with mixture specific enthalpy . Sensible heat is transported by the total volume flux ; the primary solid carries the latent-enthalpy flux . In particular the sign of the latent-heat term is fixed by the downward-moving skeleton.
At the liquid roof, imposeHere . The gradient condition matches heat flux into the imposed liquid field, since there is no phase-fraction jump at this roof and the phase conductivities are equal. The pore velocity there equals the relative Darcy velocity. At the floor,There is no liquid penetration into fully solid material. The unspecified solid fraction at the floor is determined by the solute balance, not set to one: remaining eutectic liquid freezes as it crosses the floor. If denotes the bulk concentration of the final solid product, the floor solute balance and Stefan condition areMaintaining the floor at permits the solid-side bath to remove this final latent heat. Equivalently its required gradient is . No additional imposed solid-side gradient is specified. Laterally we take the quadratic-pressure strain solution, without sidewalls; finite sidewalls would require additional flow conditions and generally break this horizontal invariance.
For uniform permeability of a porous medium, incompressible flow gives . The roof pressure and zero normal flow at the floor are satisfied byHorizontal outflow is balanced by downward inflow. The parameter is an inverse time; in the printed pressure condition already has dimensions of pressure divided by length squared, so no extra density factor belongs in this definition.
With , and , the -dependence disappears from both scalar balances. Although is nonzero, its horizontal divergence cancels in . The exact strain-driven steady mush equations becomeTogether with , , and , they determine the scalar fields and the unknown thickness. This reduction proves that the equations admit horizontally invariant scalar solutions despite the imposed straining flow. An equivalent useful form, obtained by differentiating the solute equation, isThis exact form also shows why one must not silently discard latent heat in an arbitrary strong-flow calculation.
Define , and . For the stated regular ordering , strain transport dominates skeleton transport and the bounded phase-change enthalpy contribution. More precisely, at fixed finite thermal strain number , the dimensionless energy equation isso its skeleton and integrated latent-heat corrections are small in and respectively. The leading strain-dominated mush temperature profile obeys . Put and . Integrating first for and then for givesThe error function profile follows from integrating a Gaussian, with . Matching the roof gradient gives the requested transcendental thickness relationFor prescribed and the right side decreases continuously from infinity to zero as increases, so it fixes one positive leading-order thickness. The resulting must still satisfy the assumed ordering and the phase-fraction constraints.
To find the product composition, integrate the exact solute balance from the roof to an arbitrary depth. With ,At , the exact floor composition is thereforeThe minus sign has a direct physical meaning: the horizontal outflow removes more salt than arrives at the same depth from a uniform- liquid, leaving a depleted solid product. Using the leading error function profile andyieldsThe full solid fraction follows by substituting this same profile into the preceding integral formula for . It has and . A physical branch requires and . In this monotone profile, ensures a nonnegative liquid fraction everywhere; it is not permissible to interpret a negative formal result as a material composition.
The error-function reduction is a regular leading approximation, not a uniform statement for every possible scaling of the thermal strain number. If becomes singularly large along the ordering limit, a thin basal layer can amplify the discarded terms. The printed two inequalities alone do not specify that extra scaling. In such a regime the displayed exact scalar equations and boundary conditions, rather than an unqualified zero-latent-heat profile, provide the appropriate thickness and composition calculation.
There are unlisted articles, also show them or only show them.