
Solid Earth Created 2026-09-24 Updated 2026-11-05
The Solid Earth is the rocky interior-and-surface system of Earth, including its crust, mantle and metallic core. The term includes the liquid outer core of the Earth as well as the solid inner core. Mechanical classifications overlap these compositional layers: the lithosphere contains the crust and the relatively rigid uppermost mantle.
The response also depends on timescale. The mantle supports elastic waves on seismic timescales while undergoing slow mantle flow over geological times. The outer core's liquid response prevents propagation of bulk S waves, whereas compressional P waves can propagate through it. These contrasting responses help constrain the internal structure through seismic waves.
A quantitative reference describes radial profiles of mass density and elastic wave speeds. The Preliminary Reference Earth Model, developed by Adam M. Dziewonski and Don L. Anderson, combines wave observations with global constraints such as Earth's mass and moment of inertia. Its averaged layers are a reference for interpreting departures observed in the real, laterally varying Earth.[ref]
Preliminary reference Earth model by Adam M. Dziewonski and Don L. Anderson. Abstract and model construction: radial density and seismic properties
Geometric group theory Created 2026-09-24 Updated 2026-10-18
Geometric group theory studies finitely generated groups through their actions on metric spaces and through the large-scale geometry of spaces such as their Cayley graphs.
Knot theory Created 2026-09-24 Updated 2026-10-18
Knot theory studies closed curves in three-dimensional Euclidean space that cannot intersect themselves, and asks which can be deformed into one another without cutting or passing one strand through another. Its basic object is a knot: a smooth embedding of a circle, considered up to ambient isotopy. Several disjoint knots form a link. More generally, knot theory studies such embeddings in other manifolds and in higher dimensions.
The central surprise is that a flexible circle can carry permanent information about how it sits in space. A trefoil knot and an unknot each consist of just one circle, but no ambient isotopy turns one into the other. A knot diagram translates this spatial question into a finite drawing; Reidemeister moves describe the changes of drawing that preserve the knot. Knot invariants translate it into computations: unequal Alexander polynomials of a knot, Jones polynomials, or knot groups certify different knots. Equal values of a particular knot invariant generally leave the question open; even an isomorphism of knot groups alone is not a complete classification.
An early foundation for working with knot diagrams is Kurt Reidemeister's 1927 paper Elementare Begründung der Knotentheorie, published in volume 5 of Abhandlungen aus dem Mathematischen Seminar der Universität Hamburg, pages 24–32.[ref] Marc Lackenby's authored notes Elementary knot theory, Section 2.4, explain the Reidemeister move theorem and its role in searching for a certificate that two knot diagrams represent the same knot.[ref]
Hyperbolic geometry Created 2026-09-24 Updated 2026-11-05
Hyperbolic geometry is the geometry of constant negative curvature. Its standard model is hyperbolic space, the complete simply connected Riemannian manifold with sectional curvature . In two dimensions, the Poincaré half-plane model isIts geodesics are vertical lines and semicircles orthogonal to the real axis. The real axis is an ideal boundary, at infinite hyperbolic distance from every interior point.[ref]
A primer on mapping class groups (Version 5.0) by Benson Farb and Dan Margalit. Section 1.1.2, pages 19–20
The parallel postulate fails: through a point off a hyperbolic line, there are infinitely many hyperbolic lines disjoint from it. A hyperbolic triangle has angle sum less than , and its hyperbolic area is exactly the angle defect in curvature . A hyperbolic disc of radius has area , growing exponentially in . These give concrete ways that hyperbolic geometry differs from the locally Euclidean behavior seen at very small distances.
The normalization fixes a length scale: multiplying the Riemannian metric by changes its curvature to and multiplies all lengths by . Quotients by suitable discrete subgroups of isometries produce hyperbolic surfaces and hyperbolic three-manifolds, connecting the geometry to fundamental groups and topology.
Topology Created 2026-09-24 Updated 2026-10-18
Topology studies topological spaces through open sets and continuous maps. Its central equivalence is a homeomorphism: a bijection that preserves continuity in both directions. This lets us distinguish spaces by connectedness or compactness even when numerical metric values are irrelevant. The open interval and the real line have the same topology in this sense, although only the former is a bounded set with its usual metric.
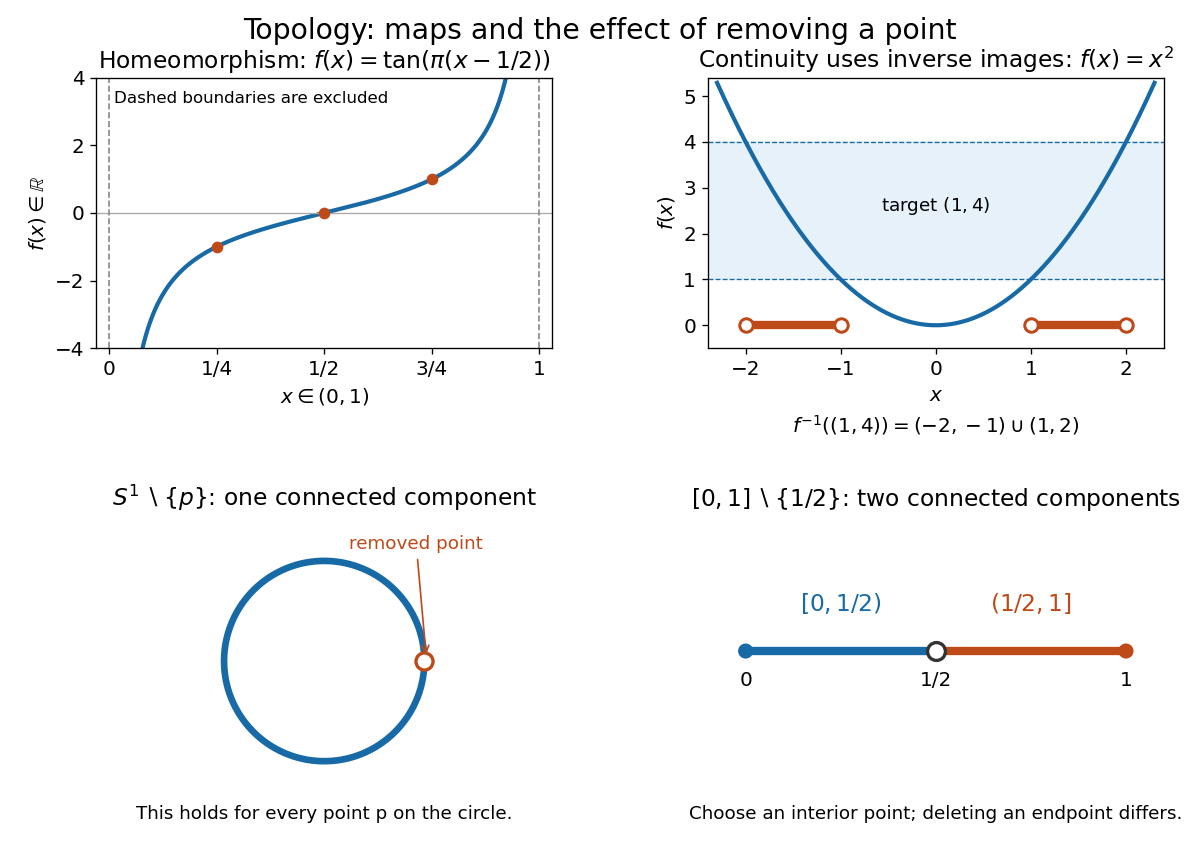
The upper panels show an explicit homeomorphism and the inverse image test for a continuous map. The lower panels exhibit an obstruction to a homeomorphism: removing any point from a circle leaves a connected space, whereas removing an interior point from a closed interval gives two connected components.
Homotopy is a different notion: it varies a continuous map continuously with a parameter and may collapse points. For example, contracts to zero. Thus this closed interval and a singleton have the same homotopy type, but there is no homeomorphism between them because there is no bijection. Homotopy equivalence need not preserve compactness. [ref]
The abstract viewpoint already appears explicitly in Tietze's 1923 paper: he describes topology as the study of properties invariant under invertible continuous maps with continuous inverses, and discusses axioms for neighbourhoods, citing Hausdorff's 1914 book, page 213. [ref]
https://gdz.sub.uni-goettingen.de/fulltext/PPN235181684_0088/00000294?_format=xml. Tietze, Beiträge zur allgemeinen Topologie I, page 290
Differential form Created 2026-09-24 Updated 2026-10-13
A differential form is a smooth field of alternating multilinear maps that can be integrated over an appropriately oriented manifold of matching dimension. A one-form measures a directed displacement; a two-form measures an oriented area element. The point is to express what is being accumulated along a curve or over a surface without tying the answer to one set of coordinates. This makes line integrals, surface integrals, and the integral theorems of vector calculus parts of one construction.
For a concrete one-form, take in the plane. Travel from to along the bottom and then the right edge of the unit square. The horizontal leg contributes zero because ; the vertical leg has and contributes . Taking the left and then the top edge instead gives zero: the vertical leg has , and the horizontal leg again has . The two paths have the same endpoints but different integrals.
Now replace with the exact differential . Both paths give , because integrating an exact differential along a curve gives the endpoint difference of its potential. Here that difference is . This is the fundamental theorem of calculus applied to a function along a parametric curve, and is the basic reason conservative vector fields have path-independent work.
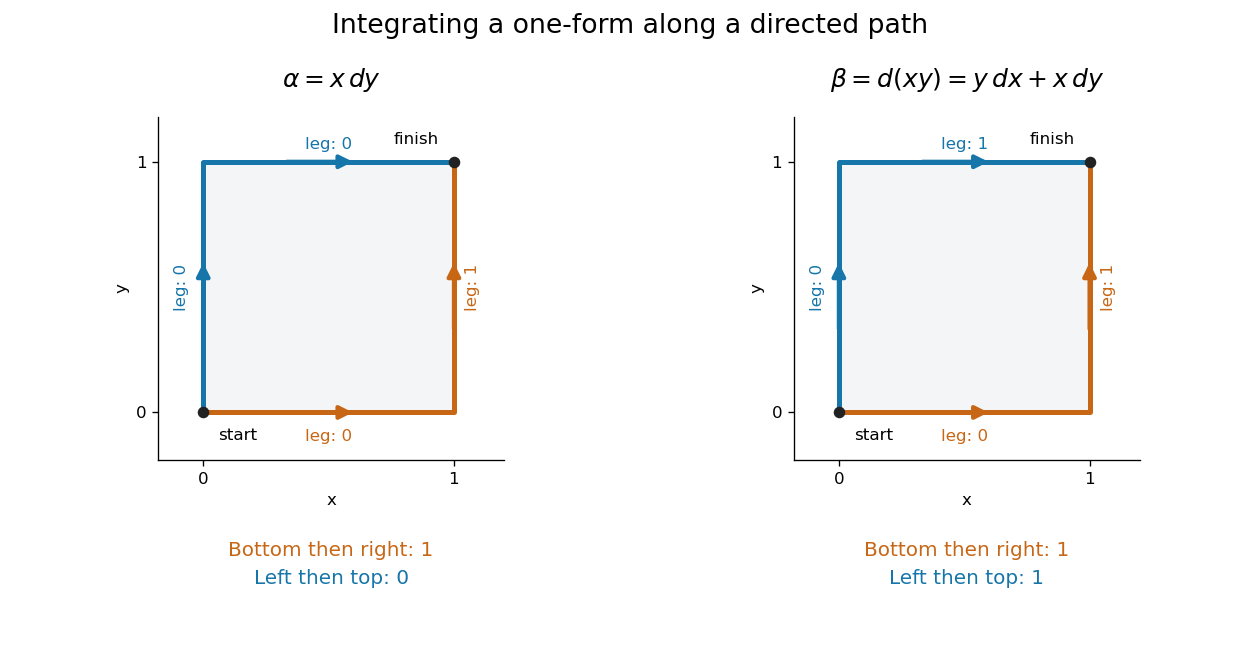
Two routes between the same endpoints distinguish a path-dependent one-form from an exact differential
. Details. The exterior derivative records the local obstruction in the first example: . The Generalized Stokes theorem turns the difference between the two path integrals into the integral of this two-form over the square, whose oriented area is . Interior edges cancel when adjoining pieces are added; only the outer boundary survives. That cancellation connects a local calculation with a global measurement.
More precisely, a degree- differential form assigns to each point a multilinear scalar-valued function of tangent vectors at . Interchanging two arguments changes its sign. A one-form is therefore a covector field, while a two-form vanishes on a pair of parallel vectors. Degree zero simply means a smooth function. The space is a vector space; the wedge product of differential forms combines degrees, and the exterior derivative raises degree by one.
The usefulness goes beyond bookkeeping. Pullbacks of a differential form supply the right transformation law automatically under a coordinate change. The Generalized Stokes theorem unifies the fundamental theorem of calculus, Green theorem, Stokes theorem, and divergence theorem. Meanwhile, the distinction between closed differential forms and exact differential forms detects holes through de Rham cohomology. Reyer Sjamaar develops these connections in sections 5.4 and 9.3 of his university notes. [ref].
Diffeomorphism Created 2026-09-24 Updated 2026-10-13
Spherical symmetry Created 2026-09-24 Updated 2026-10-06
Euclidean geometry Created 2026-09-24 Updated 2026-10-13
Euclidean geometry describes flat Euclidean space using lengths, angles, and rigid motions. A coordinate realization uses points , Euclidean distanceand angles determined by the dot product. The coordinate axes are a convenience: translations and rotations change coordinates while preserving these measurements. This makes Euclidean geometry useful for comparing figures and converting measurements along different directions into a single distance.
In the Euclidean plane, through a point outside a line there is exactly one parallel line. This is a standard equivalent formulation of the parallel postulate. Euclid's fifth postulate in the Elements instead describes when two lines meet using the interior angles made by a crossing line.[ref] The assumption has consequences we often take for granted: a triangle's interior angles sum to , and similar triangles can differ in size while keeping their angles. Comparing with spherical geometry reveals that these are properties of a particular geometry.
As a computed example, the diagonal from to in a rectangle has length . The Pythagorean theorem explains why perpendicular contributions add as squares. If the directions cease to meet at a right angle, the law of cosines supplies the missing angle-dependent term. The beauty is that a single distance formula unites geometric constructions, coordinate calculations, and orthogonality in linear algebra.
Make the assumptions visible: in a Cartesian coordinate system with orthogonal axes and the same length unit on each axis, take , and . The vectors and have dot product zero, establishing a right angle at before using the Pythagorean theorem. A sketch that merely looks like a right triangle supplies no such guarantee. Likewise, an image stretched horizontally and vertically by different amounts can distort both lengths and angles; a displayed shape and the assumptions defining it must be kept separate.
For a less origin-dependent measurement, take and . Their displacement vector is , so their Euclidean distance is again . Its Euclidean norm records the direct separation, whereas travelling first horizontally and then vertically covers length . This connects measuring a diagonal to locating two positions from a Cartesian coordinate system. A translation changes where the positions are recorded without changing their separation; a rotation changes the component values without changing the Euclidean norm.
Fractal geometry Created 2026-09-24 Updated 2026-10-13
Fractal geometry studies fractals. Fractal geometry studies recursively structured sets and spaces, often with noninteger scaling dimension.
Trigonometric function Created 2026-09-24 Updated 2026-10-13
Trigonometric functions turn an angle into a coordinate or a ratio of lengths. Start at on the unit circle and rotate counterclockwise through radians: the resulting point isThe cosine records horizontal position and the sine records vertical position. This definition continues around the whole circle, including negative angles, so the signs encode direction rather than requiring a separate rule for each right triangle.
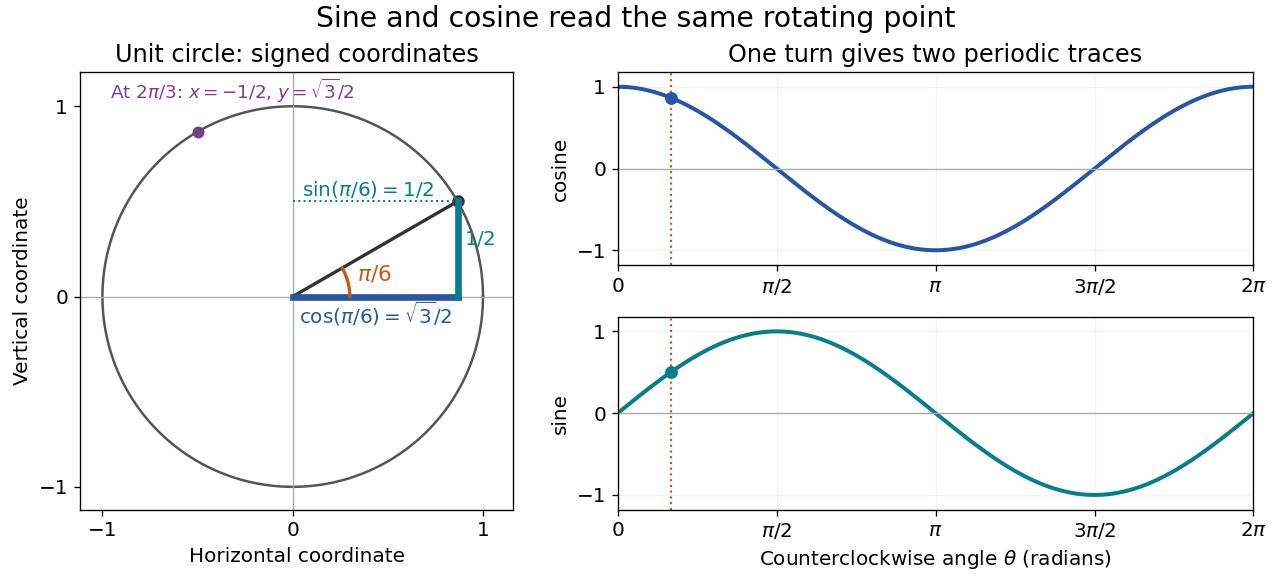


The unit circle picture explains why these functions are useful beyond measuring triangles. The two coordinates of a point rotating at constant angular speed are periodic functions. Scaling the radius to and using gives and . A circular motion becomes two simple repeating traces, connecting Euclidean geometry, simple harmonic motion, and Fourier series.
For an acute angle in a right triangle, rescaling its hypotenuse to one recovers the familiar ratios: sine is opposite side divided by hypotenuse, and cosine is adjacent side divided by hypotenuse. The tangent function is their ratio, , wherever the denominator is nonzero; the secant function, cosecant, and cotangent give the other reciprocal ratios.
The same names extend to complex numbers through the complex exponential:These definitions agree with the circle interpretation for real angles. For complex arguments, the values need not lie between and ; the literal circle-coordinate picture is restricted to real arguments. [ref]
https://dlmf.nist.gov/4.14. NIST Digital Library of Mathematical Functions, §4.14: exponential definitions and periodicity
Topological degree Created 2026-09-24 Updated 2026-11-05
For a continuous map between connected closed oriented manifolds of the same positive dimension , the topological degree is the integer determined byThe chosen fundamental classes fix the signs. This homology definition makes sense without differentiability and is invariant under homotopy. For spheres, it is the integer by which the induced map multiplies their top homology group.[ref]
If is smooth and is a regular value, the finite preimage giveswhere the sign compares the chosen orientations in source and target. Thus opposite local signs can cancel: topological degree is a signed count, rather than the number of preimages.
For the circle map , with and an integer, the topological degree is . An orientation-reversing reflection has topological degree , while a constant map has topological degree zero. A nonzero topological degree forces surjectivity; a homotopy between continuous maps preserves their topological degree.
Spherically symmetric solution of Poisson equation Created 2026-09-24 Updated 2026-11-05
For in three dimensions, , Poisson equation becomesFor a bounded continuous source, regularity at the origin forces ; otherwise a singular term remains. A constant source gives . An exterior source-free region has . Thus the radial field is determined by enclosed source, with physical constants and signs fixed by the convention for Poisson equation.
Sphere-plane intersection Created 2026-09-24 Updated 2026-11-05
A sphere-plane intersection is a circle, a point, or the empty set. For a sphere of radius whose centre has distance from the plane, the circular case has radius and centre at the orthogonal projection of the sphere centre onto the plane. The Pythagorean theorem proves the radius formula. The cases are respectively , and ; a plane through the centre cuts a great circle.
Sequentially compact space Created 2026-09-24 Updated 2026-10-24
A space is sequentially compact when every sequence has a convergent subsequence. A metric space is compact exactly when it is sequentially compact.
Product topology Created 2026-09-24 Updated 2026-10-13
The product topology turns separate observations into a notion of closeness: a basic test checks finitely many coordinates, with a separate tolerance in each. For an index set and topological spaces , the underlying Cartesian product and its coordinate projection maps areThe product topology is the coarsest topology making every a continuous map.[ref]
Point-Set Topology, Chapter 2: Continuous functions. Definition 2.2.4 and Proposition 2.2.5: coordinate projections and the coarsest topology making them continuous
The Cartesian product specifies which points exist; the product topology specifies their neighborhoods. Finite observations motivate its finite-coordinate basis for the product topology, while convergence in a product space and continuity into a product space explain why it is useful. The compactness result for this construction is Tychonoff's theorem.
Plane Poiseuille flow Created 2026-09-24 Updated 2026-11-05
Plane Poiseuille flow is steady pressure-driven viscous fluid flow between two stationary parallel plates. Let their separation be , take , and write the streamwise pressure gradient as with . For a fully developed incompressible Newtonian fluid of dynamic viscosity , momentum balance and the no-slip boundary condition give
The centre moves fastest because the stationary walls retard nearby fluid. Integrating the velocity profile gives the volume flux per unit width . Doubling the plate separation increases that flux by a factor of eight at fixed pressure gradient. A transparent narrow channel with suspended tracer particles can reveal the slower motion near the walls; the parabolic prediction assumes a laminar, fully developed region away from the entrance.
Plane Created 2026-09-24 Updated 2026-10-18
A plane is a two-dimensional affine subspace: a point together with every linear combination of two linearly independent direction vectors ,In three-dimensional Euclidean space, a Cartesian equation of a plane fixes one linear equation , with a nonzero normal vector . The two free directions are orthogonal to . A plane extends indefinitely; a rectangular patch in a drawing marks only part of it, and does not define an edge of the plane.
For example, the plane contains . The vectors and are linearly independent and satisfy . Hence its points are exactly : substitution gives for every real , and every solution has , .
The description separates position from direction. A translation of the plane changes and possibly , while retaining its parallel directions. A plane through the origin is a linear subspace; the displayed example is not, since the zero vector fails its linear equation. This distinction matters when applying orthogonal projection: subtract an anchor point before projecting onto the direction linear subspace.
Historically, Euclid's Euclid's Elements by Euclid, Book I Definition 7, describes a plane surface through the straight lines lying on it. David E. Joyce's accompanying guide notes that this older use can include a bounded square or circular figure. That usage differs from the whole unbounded affine subspace used here.[ref]
Book I, Definition 7. Euclid's Elements, Book I Definition 7 and David Joyce's Guide: plane surfaces and bounded figures
Path-connected space Created 2026-09-24 Updated 2026-10-13
A topological space is path-connected if, for every , there is a continuous mapThis continuous path must stay within for its entire duration. Its parameter need not represent physical time, and continuity does not require a derivative or finite arc length. [ref]
https://math.mit.edu/~hrm/palestine/munkres-topology.pdf. Munkres, Topology: A First Course, section 3-2, definition on p. 155
In the closed interval , any are joined by . For and , this becomes , so , , and . All its values stay in . In the union , however, a continuous path from to would attain by the intermediate value theorem, although . Thus is not path-connected.
Every path-connected space is a connected space. Proof outline: if admitted a separation of a topological space, choose and . A continuous path between them would have nonempty open inverse images with empty intersection and union . This contradicts the connectedness of that closed interval.
The converse fails: the topologist's sine curve is connected but has two path components. Path connectedness is useful when we need an actual continuous path of allowed positions, rather than only the absence of a separation of a topological space. For instance, when modelling allowed positions as a topological space, membership in the same path component answers whether one can move continuously between two positions while remaining in that topological space.
Joukowski map Created 2026-09-24 Updated 2026-11-05
The standard Joukowski map is , defined for . It sends the unit circle to since . For , the circle maps to an ellipse with semiaxes and . Its derivative vanishes only at , so it is conformal elsewhere. The exterior of the unit disk gives a bijection onto the complement of the segment: the inverse quadratic has reciprocal roots and exactly one lies outside. Translations and scalings give other common normalizations.
There are unlisted articles, also show them or only show them.